
Submitted:
25 October 2024
Posted:
29 October 2024
You are already at the latest version
Abstract
In this paper, we propose the definition of block tensors and the real representation of tensors. Equipped with the simplification method, i.e., the real representation along with the M-P inverse, we demonstrate the conditions that are necessary and sufficient for the system of dual split quaternion tensor equations (A*NX,X*SC)=(B,D) when its solution exists. Furthermore, the general expression of the solution is also provided when the solution of the system exists and we use a numerical example to validate it in the last section. To the best of our knowledge, it is the first time that the aforementioned tensor system has been examined on dual split quaternion algebra. Additionally, we provide its equivalent conditions when its Hermitian solution X=X* and η-Hermitian solutions X=Xη* exist. Subsequently, we discuss two special dual split quaternion tensor equations. Last but not least, we propose an application for encrypting and decrypting two color videos and we validate this algorithm through a specific example.
Keywords:
dual split quaternion tensor equation
; Einstein product
; real representation
; η-Hermitian solution
; Moore-Penrose inverse
MSC: 11R52; 15A09; 15A69
1. Introduction
Irish mathematician W.R. Hamilton pioneered the related research about the concept of quaternions in 1843 [1]. There has been a rapid development in quaternions during recent years. There exist various kinds of related work about quaternions that achieve valuable results [2,3]. Most recently, researchers focus on the theories of solving quaternion matrix equations, i.e., general and special solutions of quaternion matrix equations [4]. Quaternions and quaternion matrices have been comprehensively applied to multiple areas including algebra, analysis, topology, and physics. In particular, they are crucial in several fields, such as signal processing [5], image processing [6], and quantum physics [7].
In 1849, building upon Hamilton’s work, James Cockle further introduced "split quaternions" [8]. The set of split quaternions is denoted as:
where
As a derivative version of quaternions, its form is similar to the original definition of quaternions, but they are indeed two different algebras. The definition proposed by James Cockle has a more complex algebraic structure. Split quaternions play a significant role in various fields, e.g., physics, quantum mechanics, signal processing, and deep learning. Split quaternions have been applied to denote Lorentz rotations, and Lorentz transformations can be represented as unitary matrices of split quaternions, which reveals the geometric and physical importance of split quaternions [10,11,12,13,14,38,39].
Clifford [42] later proposed dual numbers and dual quaternions in 1873 and they have already become the basis of handling some typical engineering problems [15]. Dual split quaternions, like dual quaternions, expand the idea of dual numbers to include split quaternions. Building on the principles of split quaternions, dual split quaternions have been applied to diverse disciplines including algebra, geometry, and physics [9,16,17,18].
Below is a typical matrix equation system that this paper mainly focuses on. There exists some related work providing solutions to it, while this paper will explore this equation system defined in the domain of dual split quaternion tensor.
Due to its wide applications in fields such as biology, inverse problems in vibration theory and linear programming, system (1) has been extensively studied. Rao and Mitra [19] established the criteria for the solvability of the system (1). They also presented their general solutions. Khatri and Mitra [20] examined their Hermitian solutions within the complex field. Wang [21] derived conditions for solvability and provided solutions for bi-symmetric cases of system (1) in the quaternion skew field. Li and others [22] examined generalized reflexive solutions for complex system (1). Yuan [23] used spectral decomposition to investigate least squares solutions for system (1). Xie [24] applied the M-P inverse as well as the rank of quaternion matrices to determine the equivalent conditions when there exist solutions and then propose the general solution. Si and others [39] used real representations to establish various solutions of system (1) and their equivalent conditions over split quaternion field.
It is revealed that tensors are useful in engineering and science, and there are some papers focusing on the solutions of tensor equations [25,26,27,28,29,35]. Based on the extensive applications of tensors, this paper focuses on solving system (1) defined on the space of dual split quaternion tensors. To the best of our knowledge, it is the first exploration of the above system within the dual split quaternion tensor algebra. Specifically, it aims to solve the following system of dual split quaternion tensor equations:
This paper is designed with such structure: Section 2 describes essential definitions and corollaries that are essential to our subsequent analysis. Section 3 investigates the conditions that are equivalent for system (2) when there exist solutions. In this section, We further demonstrate its general solution in cases where solutions are attainable. Furthermore, we present the sufficient and necessary criteria when system (2) have -Hermitian solutions. Based on these results, we will introduce the equivalent condition for the Hermitian solution, along with the general expressions of solutions for two specific dual split quaternion tensor equations. Ultimately, we will present a specific numerical example and an encryption and decryption algorithm as an application.
In this paper, the dual number field, quaternion field, split quaternion field, dual quaternion field, and dual split quaternion field are represented by , , , , and respectively. All tensors over are represented using .
2. Preliminary
In this section, there are three parts to provide fundamental knowledge for the subsequent demonstration of this paper. In the first part, we will give the definition of dual split quaternion tensors. The second part will cover some definitions and propositions about tensors. Lastly, we will present various real representations of split quaternion tensors.
2.1. Dual Split Quaternion Tensors
is a multidimensional array tensor with entries. Let , , and respectively represent the sets of the order M tensors with dimensions over the real field , real quaternion algebra , and real split quaternion algebra .
For , . When , is referred to as the transpose of and is denoted by . When , is the conjugate transpose of , represented as . A diagonal tensor has all zero entries except for the elements . When all diagonal elements of are equal to 1, is referred to as a unit tensor, expressed as . Specifically, if , it is expressed as . denotes the zero tensor whose elements are all zero.
Definition 1
By extending quaternions and split quaternions to include dual numbers, we derive the definitions of dual quaternions and dual split quaternions:
The sets of dual quaternion tensors and dual split quaternion tensors [9,30] are represented as follows:
For , means that and , and vice versa. is called the conjugate transpose of . are called the -conjugate transposes of , where .
For , is uniquely identified as , where and . The conjugate transpose of satisfies . Additionally, for , the -conjugates and -conjugate transposes [36] of have following forms:
and
Definition 2.
Let . Provided that fulfills subsequent criteria:
we refer to as a η-Hermitian tensor.
For , then we can derive that and . And means that and , and vice versa.
2.2. Basic theory with Einstein product
Definition 3
([31]). Let and , then we can define the Einstein product of tensors and through the operation as follows:
Proposition 1.
Let and , then
- ;
- and .
Definition 4
([32,35]). Let and . is referred to as the Moore-Penrose inverse of , expressed as , if the subsequent conditions are all fulfilled:
- ;
- ;
- ;
- .
Furthermore, projectors and have following forms:
Similar to block matrices, reference [32] provides the definition of block tensors and reference [33] provides the definition of block tensors when their sizes are same. Next, we extend the definitions from references [32,33] to split quaternion tensors to give the definition of block tensors with the same size.
Definition 5.
Let and , then
-
The ’row block tensor’ formed by and is , andwhere .
-
The ’column block tensor’ formed by and is , andwhere .
In particular, let , , and , then
Remark 1.
is the tensor located at row i, column in the aforementioned block tensor and it will be used in the following statement.
Lemma 1
([32]). Let , , , and , , then
Next, we will introduce the definition of the transformation t between a tensor and a matrix within split quaternion algebra [34,35]. Under this definition, we can simplify the tensor into a matrix.
Definition 6.
The transformation with is defined as follows:
where and .
Lemma 2
([35]). Let and . Then t satisfies following properties:
- The map t is bijective and its inverse map exists as follows:
- t satisfies: and .
Example 1.
Let is defined by
Then
Consequently, there is a one-to-one correspondence between the elements of the split quaternion matrix and the split quaternion tensor. Thus, we can make use of the above definition to transform the tensor into a matrix for further calculations.
2.3. Real Representations of Split Quaternion Tensors
In this section, we will provide various real representations using the definition of block tensors in the above section.
Let , where , . We will define three kinds of real representations of based on the real representation in [12]:
As shown in the next proposition, we present the relevant characteristics of real representations discussed previously. These properties will play a crucial role in subsequent sections and can be easily obtained through simple calculations. Let
Proposition 2.
For , let , and . Then
- ;
- ;
- ;
- ;
- ;
- ;
- ;
- ;
- ;
- .
3. The General Solution to System (2)
Using the definitions and lemmas outlined above, this part will examine the solutions to system (2). At the beginning of this section, we present two lemmas. Utilizing Definition (6), we can transform tensors into matrices. Consequently, the subsequent lemmas can be readily proven using matrix proof techniques found in references [24,37], so this paper will not delve into the details. Building on these lemmas, split quaternion tensors’ real representations are used for obtaining the necessary and sufficient criteria when system (2) exists solutions as well as the general solution expression.
Lemma 3
Then
is consistent if and only if
Building on this, the general solution for system (3) is stated in the following form:
where are arbitrary tensors of appropriate size defined on .
Lemma 4
Then the subsequent descriptions are equivalent:
- The system (2) is solvable.
Based on these, the general solution for the system (2) is represented as , where
and are random tensors with suitable dimensions.
Remark 2.
Note that the set of real tensors is included within the set of quaternion tensors since real numbers are special cases of quaternions with all imaginary parts set to 0. Thus, the conclusions above also hold in the field of real tensors.
Theorem 1.
Suppose that , , , and . Set
Then the subsequent descriptions are equivalent:
- The system of dual split quaternion tensor equations (2) is solvable.
-
The system of real tensor equationsis consistent.
Based on these circumstances, the general solution of the system (2) can be represented as , where
and are random tensors with proper dimensions.
Proof. (1)⇔ (2)
If condition (1) holds, it indicates that the system (2) possesses a solution. Thus, we can express the solution for the system (2) as , where . By substituting into system (2), we obtain the following split quaternion tensor equations:
Let . Apply the real representation to the system, and by (b), (c) of Proposition (2), then we have
i.e.,
Thus, is a pair of solutions to the system (4).
On the other hand, let be the solutions to the system (4). By (da) of Proposition (2), we have
i.e.,
Thus, represent solutions to the system of real tensor equations. Likewise, and are also solutions to the system. Then, we define
Set
By direct computation, we have
and
where
and
Then, we let
and
where and .
Due to (fa) of Proposition (2), , . Thus, due to
we can obtain as the solution of system (5). And it is clear that system (2) and system (5) are equivalent. Therefore, when system (2) has solutions, system (4) also has solutions, and vice versa. In addition, we can deduce the general solution of system of dual split quaternion tensor equations by Lemma (4) as , where
and are random tensors with suitable size.
Besides, (2) and (3) are equivalent to each other that can be easily proven using Lemma (3) and Lemma (4). We will not elaborate further on these points here. □
In the following part, we will propose equivalent conditions required when system (2) have -Hermitian solutions.
Theorem 2.
Suppose that , , , and .
Set
Proof.
It is only necessary to demonstrate the situation for , the other situations are identical to it, so we omit them. Let’s assume that is a j-Hermitian solution of system (2), where . Then we have
Let . Apply the real representation to the system, and by (b), (c) of Proposition (2), then we have
i.e.,
According to (g) of Proposition (2) and the definition of real representation, we have
Thus, the above system can be expressed as
i.e.,
By (e) in Proposition (2), we have
Consequently,
i.e.,
On the other hand, if system (4) has a pair of solutions that satisfies , then the system (4) can be denoted as
and
As indicated by (db) in Proposition (2),
are also solutions to the system. Next, we define
Set
By direct computation, we have
and
where
and
Then, we let
and
where and .
Due to (fb) of Proposition (2), , . Thus,
That is, is a pair of solutions of system (4). Then,
The above system is equivalent to
i.e.,
and
Based on above theorems and lemmas, we will next present the equivalent condition when system (2) possesses a Hermitian solution. Additionally, we will put forward the equivalent criteria when two specific equations and have solutions, along with their general solution expressions.
Corollary 1.
Let and , and . Set
Then the system (2) has a Hermitian solution , and it means that the system of real tensor equations
has a pair of symmetric solutions , and vice versa.
Corollary 2.
Let and , where . Set
Then the subsequent descriptions correspond to each other:
- Dual split quaternion tensor equation is solvable.
- The following system of real tensor equations is consistent,
- .
Based on these circumstances, the general solution of tensor equation is represented as , where
where
and are arbitrary real tensors with appropriate dimensions.
Corollary 3.
Suppose that and . Let
Then the descriptions below correspond to each other:
- Dual split quaternion tensor equation is solvable.
- The following system of real tensor equations is consistent.
- .
Based on these situations, the general solution of tensor equation can be expressed as , where
where
and denote random tensors over with suitable dimensions.
4. Numerical Example
This segment will show an example to substantiate Theorem (1) and an example as an application of Theorem (1).
Example 2.
Let , , and , where
From MATLAB 7.0, it can be proven that part (3) of the Theorem (1) in this paper holds:
and
i.e.,
Then, it can be deduced that the system of dual split quaternion tensor equations (2) is solvable and a solution of this system can be expressed as , where
and
Example 3.
In this section, we propose a method for video encryption and decryption using Theorem (1) and provide a specific example to demonstrate this method.
Figure 1.
The model of encrypting two videos.
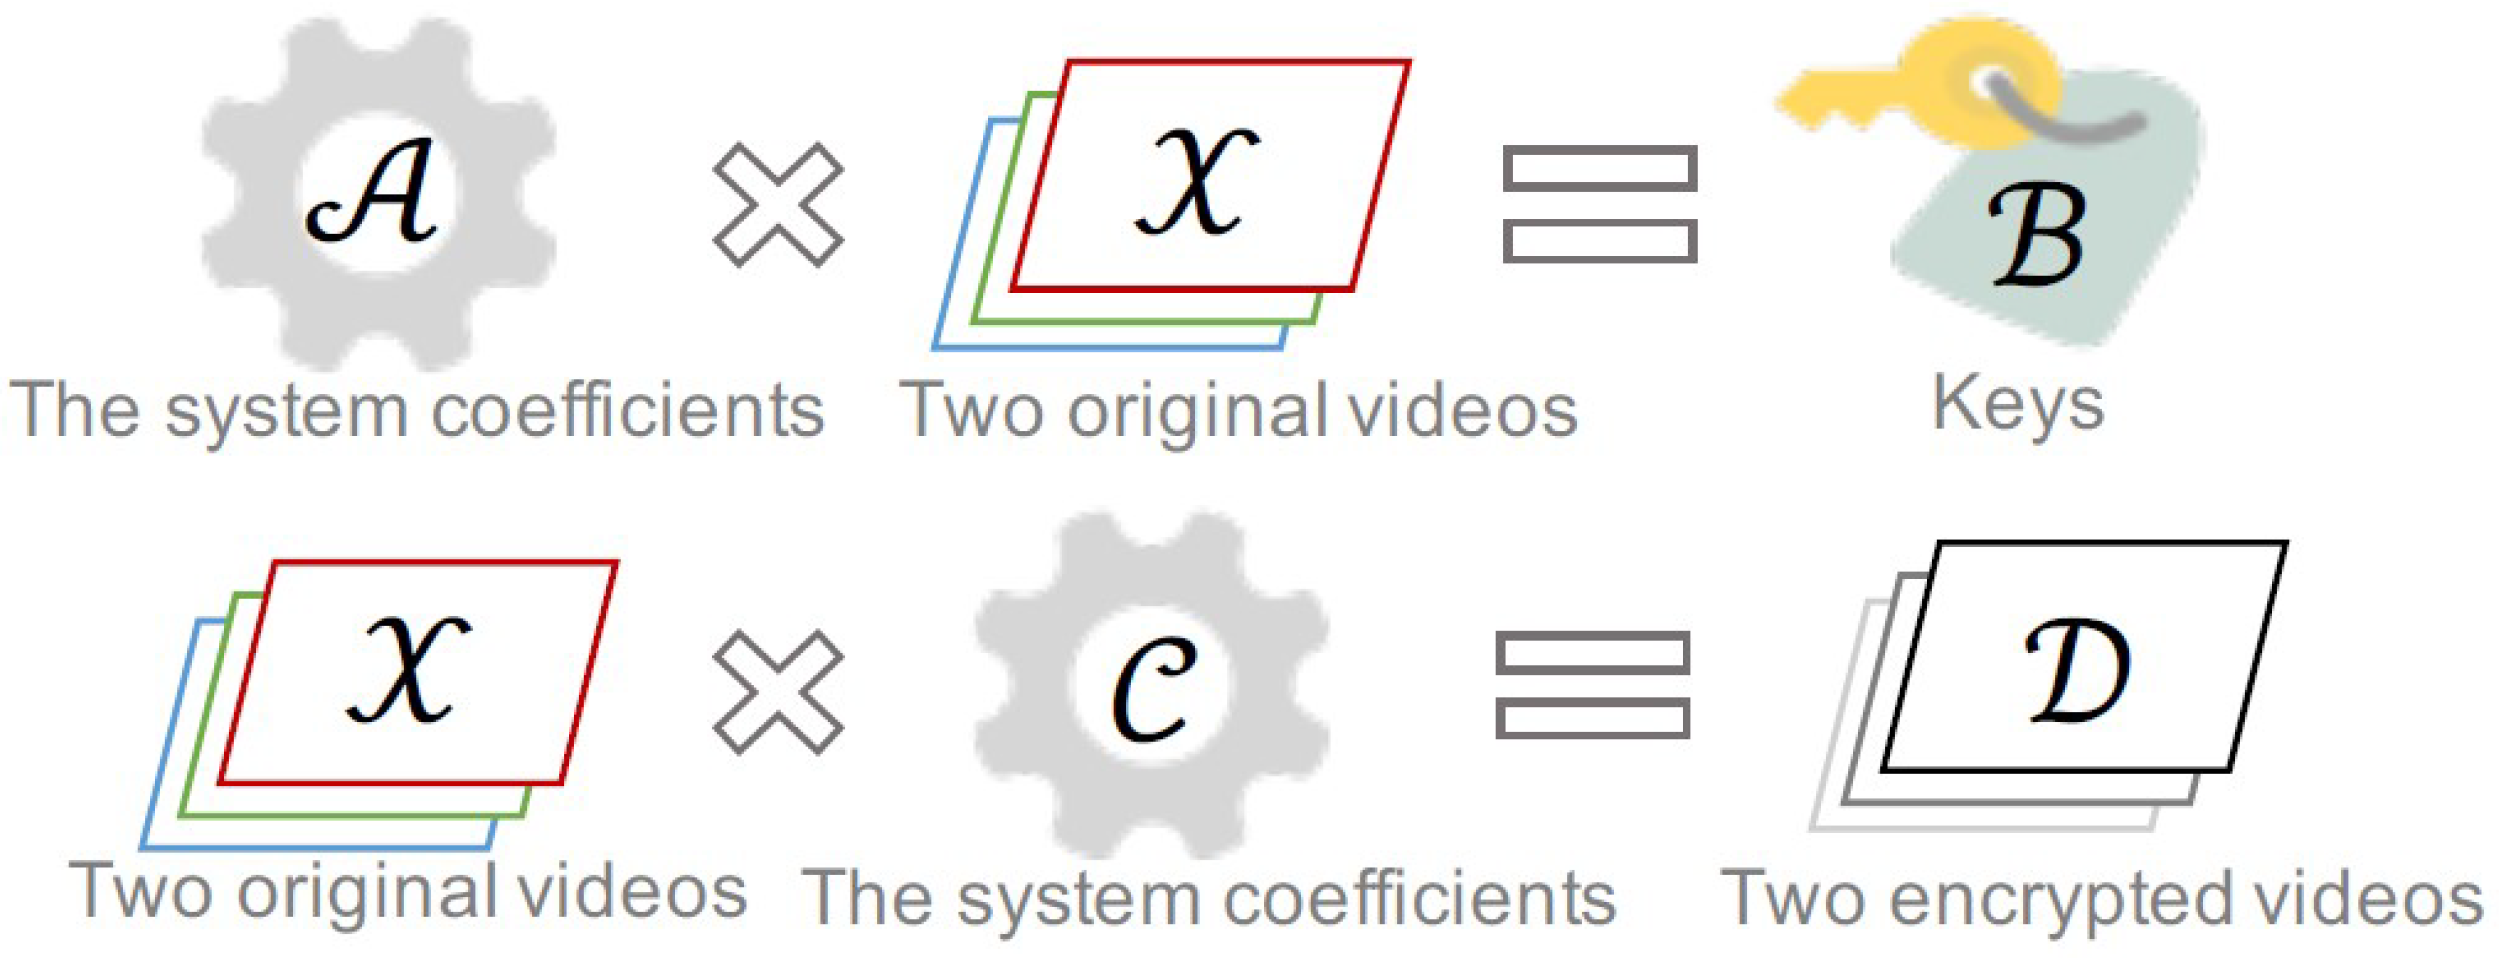
It is clear that system (2) and the following system are equivalent, so we can use system (22) to encrypt and decrypt videos.
We use two original videos and , each composed of 51 slices of color images of size pixels, represented as [41]. That is, . and are the system coefficients. For simplicity, we select all , , and as real matrices and they are invertible. And we represent and as keys. and represent two encrypted videos. The process of encryption is described below:
| Algorithm 1 Encryption process |
|
For the decryption process, we use two encrypted videos, and , obtained from the encryption process, along with keys and , as well as system coefficients , , , and , to recover the two original color videos. The decryption algorithm is represented as follows:
| Algorithm 2 Decryption process |
|
Figure 2.
The original, encrypted, and decrypted images of randomly selected slices from color videos and .
Figure 2.
The original, encrypted, and decrypted images of randomly selected slices from color videos and .
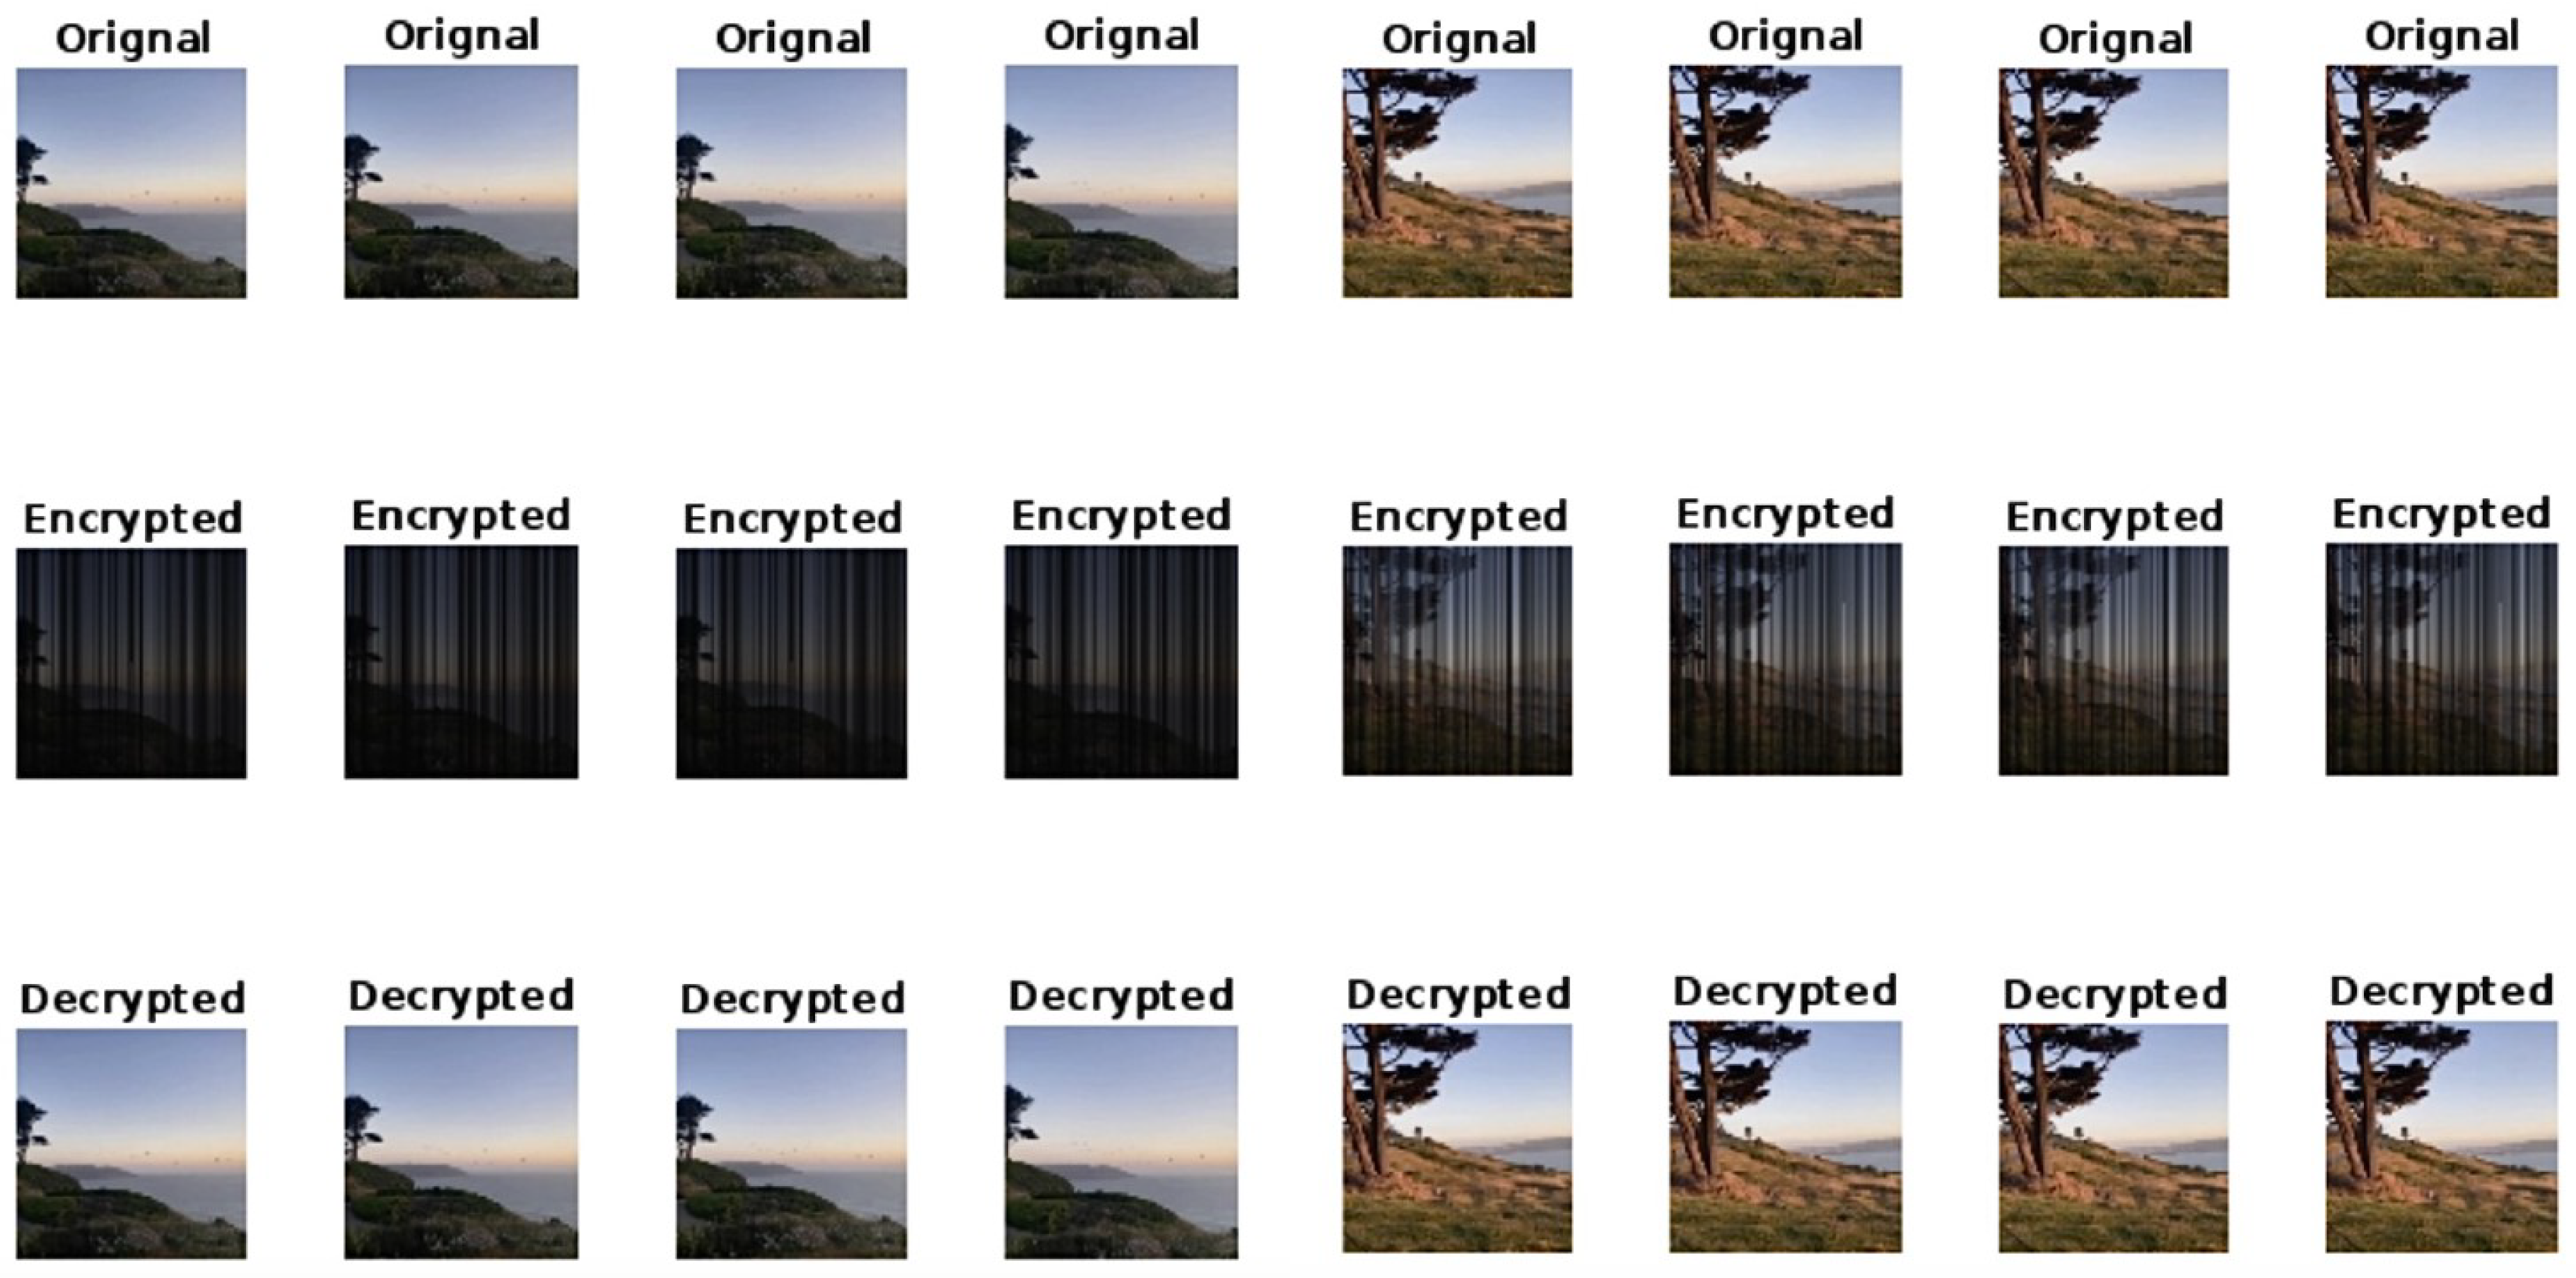
The encryption’s CPU time is 59.2300 seconds and the decryption’s CPU time is 145.9600 seconds. The figure below illustrates a portion of slices from the encrypted and decrypted videos results:
To assess the quality of the encryption and decryption algorithm for color videos, we utilize the Peak Signal-to-Noise Ratio (PSNR), Structural Similarity Index Measure (SSIM) and Feature Similarity Index Measure (FSIM), with the results presented in Table 1 and Table 2. A higher PSNR value usually indicates smaller errors, meaning that the quality of the processed image is higher. The results show that the PSNR values are all greater than 30 and all SSIM and FSIM values are equal to 1, indicating a high degree of similarity between the decrypted videos and the original videos. This further demonstrates the effectiveness of our encryption and decryption algorithm.
5. Conclusions
We use the real representations of split quaternions to simplify the system of dual split quaternion tensor equations into real tensor equations. Based on this, we put forward the equivalent conditions for this system’s solvability and the general expression of solutions. Subsequently, this proposed theorem is applied to two specific cases of dual split quaternion tensor equations. Furthermore, the paper presents the equivalent conditions when the Hermitian solution (denoted as ) and -Hermitian solutions (denoted as ) of the system (2) exist, using various real representations. Additionally, we provide a numerical example using MATLAB to validate the correctness of the key theorem presented in this paper. In the end, we use Theorem (1) to present a method for encrypting and decrypting two color videos, along with a specific example. The algorithm’s efficacy is demonstrated by PSNR, SSIM and FSIM.
Author Contributions
All authors have equal contributions in conceptualization, formal analysis, investigation, methodology, software, validation, writing an original draft, writing a review, and editing. All authors have read and agreed to the published version of the manuscript.
Funding
This research is supported by the National Natural Science Foundation of China (No. 12371023).
Data Availability Statement
Data are contained within the article.
Conflicts of Interest
The authors declare no conflicts of interest.
References
- Hamilton, W.R. Lectures on quaternions. Landmark Writings in Western Mathematics 1640–1940, 1853. [Google Scholar] [CrossRef]
- Zhang, F.Z. Quaternions and matrices of quaternions. Linear Algebra Its Appl. 1997, 251, 21–57. [Google Scholar] [CrossRef]
- Kösal, H.; Tosun, M. Commutative quaternion matrices. Adv. Appl. Clifford Algebr. 2014, 24, 769–779. [Google Scholar] [CrossRef]
- Zhang, Y.; Wang, Q.W.; Xie, L.M. The Hermitian solution to a new system of commutative quaternion matrix equations. Symmetry. 2024, 16, 361. [Google Scholar] [CrossRef]
- Cyrus, J.; Clive, C.T.; Danilo, P.M. A class of quaternion valued affine projection algorithms. Signal Process. 2013, 93, 1712–1723. [Google Scholar] [CrossRef]
- Miao, J.; Kou, K.I. Color image recovery using low-rank quaternion matrix completion algorithm. IEEE Trans. Signal Process. 2021, 31, 190–201. [Google Scholar] [CrossRef]
- Adler, S.L. Quaternionic quantum mechanics and quantum fields. International Series of Monographs on Physics. 1995, 88. [Google Scholar] [CrossRef]
- Cockle, J. On systems of algebra involving more than one imaginary and on equations of the fifth degree. Philos. Mag. 1849, 36, 434–437. [Google Scholar] [CrossRef]
- Kula, L.; Yaylı, Y. Dual split quaternions and screw motions in Minkowski 3-space. Iran. J. Sci. Technol. Trans. A Sci. 2006, 30, 245–258. [Google Scholar] [CrossRef]
- Alagöz, Y.; Oral, K.H.; Yüce, S. Split quaternion matrices. Miskolc Math. Notes. 2012, 13, 223–232. [Google Scholar] [CrossRef]
- Erdoğdu, M.; Özdemir, M. On eigenvalues of split quaternion matrices. Adv. Appl. Clifford Algebras. 2013, 23, 615–623. [Google Scholar] [CrossRef]
- Erdoğdu, M.; Özdemir, M. On complex split quaternion matrices. Adv. Appl. Clifford Algebras. 2013, 23, 625–638. [Google Scholar] [CrossRef]
- Kula, L.; Yaylı, Y. Split quaternions and rotations in semi Euclidean space E24. J. Korean Math. Soc. 2007, 44, 1313–1327. [Google Scholar] [CrossRef]
- Özdemir, M.; Ergin, A.A. Rotations with unit timelike quaternions in Minkowski 3-space. J. Geom. Phys. 2006, 56, 326–332. [Google Scholar] [CrossRef]
- Chen, Y.; Wang, Q.W.; Xie, L.M. Dual quaternion matrix equation AXB=C with applications. Symmetry. 2024, 16, 287. [Google Scholar] [CrossRef]
- Diatta, A.; Manga, B.; Sy, F. On dual quaternions, dual split quaternions and Cartan-Schouten metrics on perfect Lie groups. arXiv:2310.02114, arXiv:2310.02114. 2023. [CrossRef]
- Erdoğdu, M.; Özdemir, M. Split quaternion matrix representation of dual split quaternions and their matrices. Adv. Appl. Clifford Algebr. 2015, 13, 787–798. [Google Scholar] [CrossRef]
- Atasoy, A.; Ata, E.; Yayli, Y. et al. A new polar representation for split and dual split quaternions. Adv. Appl. Clifford Algebras. 2017, 27, 2307–2319. [Google Scholar] [CrossRef]
- Rao, C.R.; Mitra, S.K. Generalized inverse of matrices and its applications. Sankhyā: The Indian Journal of Statistics. 1971, 33, 289–300. [Google Scholar]
- Khatri, C.G.; Mitra, S.K. Hermitian and nonnegative definite solutions of linear matrix equations. SIAM J. Appl. Math. 1976, 31, 579–585. [Google Scholar] [CrossRef]
- Wang, Q.W. Bisymmetric and centrosymmetric solutions to systems of real quaternion matrix equations. Comput. Math. Appl. 2005, 49, 641–650. [Google Scholar] [CrossRef]
- Li, F.L.; Hu, X.Y.; Zhang, L. The generalized reflexive solution for a class of matrix equations (AX=B,XC=D). Acta Math. Sci. 2008, 28, 185–193. [Google Scholar] [CrossRef]
- Yuan, Y. Least-squares solutions to the matrix equations AX=B, XC=D. Appl. Math. Comput. 2010, 216, 3120–3125. [Google Scholar] [CrossRef]
- Xie, L.M.; Wang, Q.W. A system of dual quaternion matrix equations with its applications. arXiv:2312.10037, 2023; arXiv:2312.10037. 2023. [Google Scholar] [CrossRef]
- Wang, Q.W.; Lv, R.Y.; Zhang, Y. The least-squares solution with the least norm to a system of tensor equations over the quaternion algebra. Linear Multilinear Algebra. 2020, 70, 1942–1962. [Google Scholar] [CrossRef]
- Wang, Q.W.; Xu, X. Iterative algorithms for solving some tensor equations. Linear and Multilinear Algebra. 2018, 67, 1325–1349. [Google Scholar] [CrossRef]
- Liang, M.L.; Zheng, B.; Zhao, R.J. Tensor inversion and its application to tensor equation with Einstein product. Linear Multilinear Algebra. 2018, 67, 843–870. [Google Scholar] [CrossRef]
- Xie, M.; Wang, Q.W. ; Reducible solution to a quaternion tensor equation. Front. Math. China. 2020, 15, 1047–1070. [Google Scholar] [CrossRef]
- Xie, M.; Wang, Q.W.; Zhang, Y. The Minimum-Norm Least Squares Solutions to Quaternion Tensor Systems. Symmetry. 2022, 14, 1460. [Google Scholar] [CrossRef]
- Qi, L.Q.; Ling, C.; Yan, H. Dual quaternions and dual quaternion Vectors. Commun. Appl. Math. Comput.. 2022, 4, 1494–1508. [Google Scholar] [CrossRef]
- Einstein, A. The formal foundation of the general theory of relativity. Sitzungsber. Preuss. Akad. Wiss. Berlin (Math. Phys.), 1914; 1030–1085. [Google Scholar]
- Sun, L.; Zheng, B.; Bu, C.; Wei, Y. Moore-penrose inverse of tensors via einstein product. Linear and Multilinear Algebra. 2015, 64, 686–698. [Google Scholar] [CrossRef]
- Chen, C.; Surana, A.; Bloch, A.; et al. Multilinear time invariant system theory. 2019 Proceedings of the Conference on Control and its Applications. 2019, 118–125. [Google Scholar] [CrossRef]
- Brazell, M.; Li, N.; Navasca, C.; Tamon, C. Solving multilinear systems via tensor inversion. SIAM J. Matrix Anal. Appl. 2013, 34, 542–570. [Google Scholar] [CrossRef]
- He, Z.H.; Navasca, C.; Wang, Q.W. Tensor decompositions and tensor equations over quaternion algebra. arXiv preprint arXiv:1710.07552, arXiv:1710.07552. 2017. [CrossRef]
- Liu, X.; He, Z.H. On the split quaternion matrix equation. Banach J. Math. Anal. 2020, 14, 228–248. [Google Scholar] [CrossRef]
- He, Z.H.; Wang, Q.W. The general solutions to some systems of matrix equations. Linear Multilinear Algebra. 2015, 63, 2017–2032. [Google Scholar] [CrossRef]
- Si, K.W.; Wang, Q.W. The General Solution to a classical matrix equation AXB=C over the dual split 1uaternion algebra. Symmetry. 2024, 16, 491. [Google Scholar] [CrossRef]
- Si, K.W.; Wang, Q. W; Xie, L.M. A classical system of matrix equations over the split quaternion algebra. Adv. Appl. Clifford Algebras. 2024, 34, 51. [Google Scholar] [CrossRef]
- Eduardo, B.C.; Zuleima, V.F.; Ulises, U.L. The Lorentz Group Using Conformal Geometric Algebra and Split Quaternions for Color Image Processing : Theory and Practice. IEEE Access. 2023, 11, 56785–56800. [Google Scholar] [CrossRef]
- Zhang, X.F.; Li, T.; Ou, Y.G. Iterative solutions of generalized Sylvester quaternion tensor equations. Linear and Multilinear Algebra. 2023, 72, 1259–1278. [Google Scholar] [CrossRef]
- Clifford, W.K. Preliminary sketch of bi-quaternions. Proc. Lond. Math. Soc. 1873, 4, 381–395. [Google Scholar] [CrossRef]

Table 1.
PSNR, SSIM and FSIM of the video 1.
| Video 1 | PSNR | SSIM | FSIM |
|---|---|---|---|
| 1 | 279.8545 | 1 | 1 |
| 2 | 280.0351 | 1 | 1 |
| 3 | 279.8906 | 1 | 1 |
| 4 | 279.4681 | 1 | 1 |
Table 2.
PSNR, SSIM and FSIM of the video 2.
| Video 2 | PSNR | SSIM | FSIM |
|---|---|---|---|
| 1 | 248.0390 | 1 | 1 |
| 2 | 248.2462 | 1 | 1 |
| 3 | 247.9977 | 1 | 1 |
| 4 | 246.5033 | 1 | 1 |
Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2024 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license (http://creativecommons.org/licenses/by/4.0/).
Copyright: This open access article is published under a Creative Commons CC BY 4.0 license, which permit the free download, distribution, and reuse, provided that the author and preprint are cited in any reuse.