

Submitted:
03 December 2024
Posted:
04 December 2024
Read the latest preprint version here
Abstract
The study of the emission, propagation, and reflection of balls leads to the mechanical ballistic law that applies to balls with and without mass. A natural extension of the ballistic law is to encompass massless entities such as light. According to ballistic law, a ball or light emitted by a source inherits the velocity of the source in the absolute frame. The phenomenon described by the ballistic law works in the absolute frame which acts as the background of inertial frames and governs the kinematics of balls and light in each inertial frame. It explains why the speed of light is the universal constant c in any inertial frame in which a source and mirror are at rest, why the laws of physics have the same form in any inertial frame, and why no experiment in such a frame can prove its motion. By understanding the kinematics of light, we can understand the multiple issues rooted in Lorentz’s transformation and Einstein’s special relativity. For example, the theory of special relativity misapplies the symmetry observed in some phenomena to two inertial frames. Thus, it duplicates a physical phenomenon from one inertial frame considered stationary, to another. The Lorentz transformation confirms the speed of light c in the moving and opposite direction of the inertial frame. Simultaneously, it varies in any other direction converging to infinite. The time contraction in the moving direction of the inertial frame is different from the time dilation in the opposite direction, and both times are different from those in any other direction. Thus, each direction requires a ruler and time synchronization. Lorentz’s transformation has no length contractions to support this fundamental concept of special relativity. These unacceptable conclusions prove that the theory of special relativity is self-negating. Furthermore, Lorentz’s transformation is derived from a mechanical perspective. The incorrectness of this derivation rejects the identical hypothesized Lorentz’s derivation and special relativity; even more it proves the constancy of time passing in the universe.
Keywords:
kinematics of balls
; kinematics of light
; ballistic law
; emission of light
; propagation of light
; reflection of light
; speed of light
; observation of light
; Lorentz’s transformation
; special relativity
1. Introduction
From 2017 to 2019, we studied Michelson‒Morley's experiment, Fizeau's experiment, the observation of binary stars, and other topics related to light as well. These studies were essential in understanding light reflection, emission, and propagation as mechanical phenomena in the following years.
The first part of this article summarizes the kinematics of light, a concept emerging from a series of articles beginning in 2020 on the reflection of balls with and without mass. The study of ball reflection gives the velocity formula for a ball reflected by a wall for any incident angle the moving ball makes with the wall’s moving direction and for any inclination of the wall, not just the known formula for a two-ball frontal collision. A complete study of ball reflection for any incident angle and wall inclination was required when the reflection of hypothetical massless balls was applied to light as a massless entity. We continued with the emission and propagation of balls with and without mass, which, when applied to light, show that the emitted light inherits/possesses the velocity of the source at emission. Until the end of 2023, considering the ballistic law of light, we explained experiments and observations that have been misunderstood for over 100 years.
The kinematics of balls, with and without mass, and light are identical. As such, if we include the massless entities in mechanics, we can state that the ballistic law gives light the mechanical speed of its source besides the emitted speed of an electromagnetic nature.
The second part of this article examines the Lorentz transformation and special relativity revealing their hidden incorrectness.
2. Kinematics of Balls
2.1. Balls from Rest Brought to a Velocity
Figure 1 exemplifies in the absolute frame a carrier that brings a ball from rest at a point to a velocity at a point . At point the carrier stops and the ball travels free at the velocity .
The constant force created by carrier acts on the ball of mass in a straight line along the length at a constant acceleration . In time , while the speed of the ball increases from zero to , the inertial force of the ball acts with the same magnitude in the opposite direction of force that changes the ball’s state. Energy consumed to overcome is given by the mechanical work created by the force , . While the ball is moved from rest to speed , it gains energy stored in its momentum , which opposes any force that changes its new state. Indeed, the integral of momentum , as a linear function with a constant slope and the variable speed from zero to gives the energy gained by the ball, . When the force stops, the ball continues traveling at the velocity having momentum .
Differently from balls with mass, the massless balls travel from rest to speed without the force to act upon them, , without energy consumption, , and without momentum after that, . Massless balls need a carrier that only consumes energy for itself.
Suppose a carrier with balls of different masses travels at a velocity . In that case, all balls travel independently from the carrier and one another with velocity regardless of their mass. At the limit when a ball's mass converges to zero, the hypothetical massless ball travels at the same velocity .
2.2. Balls Emitted at Velocity by a Moving Source at Velocity
Figure 2 represents in the absolute frame a source of light at velocity that emits at a point a ball at a velocity in the instant direction . In the instance of emission, the kinematics of the emitted ball of mass depends on two vector momentums. One momentum is given by that the ball already has while moving with the source and another by in the instance of emission. The vector sum of the two momentums is where and is the propagation ball's velocity from the instant emission point of to point after a time . The action and reaction forces between the source and the emitted ball at the instant of emission are not considered.
The vector equation of momentums is independent of the bolls’ mass; therefore, the vector equation of velocities is . At the limit when the mass of a ball converges to zero, the equation of the momentums gives the same equation of the velocities . In this case, no action and reaction forces are present between the source and the massless ball at emission.
Suppose in the absolute frame a hypothetical source traveling at a velocity emits balls of different masses at the same speed in various directions. Thus, each emitted ball including massless ones respects the vector equation of momentums and has the velocity . For massless balls, in the vector equation of momentums, is zero as and are.
2.3. Ballistic Law Applied to Balls Emitted by a Source in Motion
Considering Subsections 2.1 and 2.2, we can understand the phenomenon that acts on emitted balls formulated in the ballistic law: balls with or without mass inherit the velocity of their source in the absolute frame in the instance of emission. The mathematical expression of this law gives the propagation velocity of a ball in the absolute frame as the vector sum of the source velocity and the emitted velocity of the ball in the emission instance, .
Suppose in the absolute frame, a source at rest emits spherical ball fronts at a speed and period in all directions uniformly distributed in space. Each spherical ball front has its center at the source at all times. The length between two consecutive balls traveling in the same direction is the same; this is true for all directions.
Figure 3 illustrates the circular ball fronts emitted in the paper plane by the same source traveling at a velocity in the absolute frame. The drawing presents the case when at a scale for m/s, m/s and s. At the initial instance at point , the source emits the first spherical ball front and at point the second one.
At point is shown the circle of the instant velocities with center at and at point the circle on which all velocities originating at land; both circles have a radius of m and are in the absolute frame. At time s, the ball front emitted at is on the circle with a radius of m at point where the second ball front is emitted. After time s, the wavefront emitted at is on the circle with a radius of m and the wavefront emitted at is on the circle with a radius of m, both circles at point . The length between two consecutive balls traveling in the same direction is m.
Each velocity applies on one ball in the absolute frame. For example, the ballistic law acts on the ball emitted in the direction and its velocity along is the vector sum of velocity along and common velocity along . The same reasoning applies to velocity of any other ball.
The ballistic law acts in the background of the absolute frame and makes the phenomenon in the inertial frame like that in the absolute frame. Each spherical ball front is emitted at the speed and period with balls uniformly distributed in the space of the source inertial frame having its center at the source at all times. In the absolute frame, each spherical ball front travels at the velocity with its center at the source location at all times and continuously expanding with a radius increasing in time with .
The ballistic law governs the kinematics of balls with mass or massless and it can be extended to massless entities such as light. Therefore, the constant light speed of an electromagnetic nature given by Maxwell’s equations emitted in any direction in the absolute frame by a source in motion replaces the emitted velocity from mechanics. The velocity of the source of a mechanical nature remains the same. Therefore, the propagation velocity of a wave’s wavefronts in the absolute frame is which applies to each wave emitted in any direction in the absolute frame. In the source inertial frame, the phenomenon is like in the absolute frame when the source is at rest and each spherical wavefront has its center at the source at all times; light travels in any direction with the speed , wavelength , period , and frequency .
2.4. Elastic Collision of Two Balls Moving in Opposite Directions
In the absolute frame, two balls, one with mass traveling at velocity and the other with mass traveling at velocity, are engaged in a frontal elastic collision, as shown in Figure 4. The velocities of the balls after collision are and, respectively. The equations for the law of conservation of momentum and energy of the balls before and after collision are as follows:
The two equations yield the solution for speed and
For , the simplified solution and are given with approximation. The solutions are offered without considering the direction of the velocities. Considering the direction of positive, the direction of is negative and the directions of and are positive, as shown in Figure 4. Therefore, the simplified solutions with approximation becomes and. At the limit when converges to zero, the simplified solutions are and
When the ball of mass travels in the opposite direction, the simplified solutions for the massless balls are and , considering the same positive direction.
The massless balls obey the law of conservation of momentum , and the law of energy conservation . According to the equations of these two laws, massless balls do not have momentum and no energy is required to change their state.
A wall can replace the ball of mass to study the reflection of massless balls in any direction as in Figure 5. The mass of the wall can be ignored when studying massless balls.
Equation (3), , is given in the frame at absolute rest and indicates that adds once to and twice. In the wall’s inertial frame, the relative incident speed of the massless ball concerning the wall is , where is the speed of the wall in the opposite direction of the incident velocity ; in Figure 5, . The speed of the reflected massless ball is ; velocities and are equal in magnitude and opposite directions. In the frame at absolute rest, the speed of the reflected massless balls is , where is the speed of the wall in the direction of the reflected massless ball; in Figure 5, . The expression , where , yields the following equation:
Equation (4) offers the meaning of velocities and and provides the massless ball’s speeds reflected in the absolute frame where is the emitted velocity of the massless ball coming from any direction concerning the wall. The wall may have inclinations other than from the velocity . In this case, the angles of the incident speed and the reflected speed measured from the velocity are different from ; therefore, magnitudes of velocities and are different from of Figure 5.
Equation (4) applies to the reflection of hypothetical massless balls and light by a moving wall/mirror and with approximation to the reflection of balls with mass by a moving wall in an elastic collision when .
2.5. Elastic Reflection of a Ball by a Moving Wall
Figure 6 illustrates in the absolute frame a wall W traveling at a velocity and a ball traveling at a velocity hitting the wall in an elastic collision; the wall’s mass is much greater than the ball’s mass . The wall reflects the ball in the instance of collision at point of the wall in the wall inertial frame and its corresponding point in the absolute frame. The angle of velocity of the incident and reflected ball are equal and measured from the normal at the common points and at the collision instance according to the law of reflection. One second after the collision, the ball is at point and the wall is at .
This section employs Equation (4), , in which the speed of the ball replaces and the reflected speed of the ball in the absolute frame replaces :
In the inertial frame, the speed of the wall in the opposite direction of the incident ball is , and in the absolute frame, the speed of the wall in the direction of the reflected ball is . Another form of Equation (5) is
where angles and are measured counterclockwise from velocity .
In the absolute frame, the wall moved in one direction; however, the wall inclination reflects a ball in multiple directions. The velocity of the ball in the inertial frame of the wall is given by the vector subtraction of velocity and . The triangle represents the ball’s velocities at any time, and on another scale, the momentums triangle.
2.6. Emission, Propagation, and Reflection of Balls in the Absolute and an Inertial Frame
Figure 7 illustrates the same source of balls and the same rigid wall at rest in the absolute and an inertial frame. The source and wall have the same geometry and the source is at the origin of each frame.
In the absolute frame , the source at the origin emits a ball at an instant velocity at an angle from the axis . After time , the ball is at point on wall . At point , the ball is reflected in an elastic collision at a velocity and then travels along the path in time . The velocity and have the same magnitude . The ball travels paths and in time at speed . The ball continues to travel in the direction.
The inertial frame travels at velocity , and the source is at the origin . Origin and points and belong to the inertial frame and their instances in the absolute frame receive the corresponding index. The source at point emits a ball at the instant velocity in the direction at the angle from the axis . The ball inherits the velocity of the source. The ball travels on the path at the propagation velocity given by the vector sum of the emitted velocity and source velocity . The velocity does not change its direction and magnitude along path .
At point , the ball is at ; it has traveled, in the inertial frame, path at speed in time , and the direction makes angle from the axis . Path is path in the inertial frame, which is identical to in the absolute frame. If the source emits other balls between and , all balls are on the path .
In the elastic collision at point , the wall perceives only the magnitude and direction of the velocity of the emitted ball because both the ball and wall have the same velocity . The incident and reflected angles are measured from the normal to the wall at the collision point to the incident velocity and reflected velocity as in the absolute frame. After reflection, the velocity keeps the ball moving in the same direction with the same magnitude. The ball travels on the propagation path at the propagation velocity given by the vector sum of the reflected velocity and source velocity . The velocity does not change its direction and magnitude along the path . At point , the ball is at , the direction makes angle from axis , and the ball has traveled the path at speed in time and the path at speed in time . Path is the path in the inertial frame identical to that in the absolute frame. At point , the ball has traveled the paths and in time at speed , as in the absolute frame.
Newtonian mechanics formulates observations and experiments rationally understood in laws applicable to experiments, phenomena, and needs of everyday life. However, Newtonian laws state nothing about observing these phenomena.
3. Kinematics of Light
The kinematics of light based on the ballistic law arises from a series of articles [1,2,3,4,5,6,7,8,9,10,11,12,13] regarding light emission, propagation, and reflection applied to a few fundamental experiments. The reflection of light as a mechanical phenomenon [1,2,3] was the first step. The experiment regarding the reflection and emission of light [13] summarized in Appendix A was the turning point in our understanding of the kinematics of light.
Differing from Newtonian laws, we have used the expressions “observer in the absolute frame” and “observer in an inertial frame;” these hypothetical observers observe phenomena as they are in their frames. These terms may be eliminated to state directly how the phenomena are as in mechanics. The expression “local observer” is particularly essential. A local observer perceives the phenomena through light coming directly from a source or reflected by objects from the observer’s frame or others, as well as through partially reflected wavefronts of light by some particles of the transparent medium, such as air, through which light travels. In a vacuum, a beam of light is invisible except when it comes directly to the human eye. Furthermore, the human eye only observes the light emitted from a source and its reflection in a mirror, not necessarily light propagation. Therefore, a local observer perceives a physics phenomenon differently from the reality of Newton's laws. Nevertheless, we may better understand reality by applying Newtonian laws and local observations of light.
Electromagnetic theory gives the emitted speed of light by a source at rest or in motion in a vacuum of the absolute frame that is the universal constant . The speed of light behaves similarly to the speed of a ball, as presented in Subsections 2.5 and 2.6.
3.1. Ballistic Law Applied to Light Emitted by a Source in Motion
The ballistic law of massless balls applies to light: light inherits the velocity of its source in the absolute frame in the instance of emission. The mathematical expression of this law gives the propagation velocity of light (a wave’s wavefronts of light) in the absolute frame as a vector sum of the velocity in the emission instance and the source velocity , .
Suppose a source of light at rest in a vacuum of the absolute frame emits waves in all directions. The spherical wavefront has its center at the source at all times, waves are uniformly distributed in space concerning the source, and waves travel at the emitted speed with wavelength , period , and frequency in any direction. The phenomenon is a sphere with the center at source at rest continuously expanding with a radius increasing in time with . At each point of the spherical wavefront, a local observer observes the wavefront coming from the source with a delay according to the time from its emission. Waves travel at the speed , wavelength , period , and frequency .
Figure 8 illustrates the circular wavefronts emitted in the paper plane by the same source traveling at a velocity in the absolute frame. At the initial instance at point , the source emits the first spherical wavefront and at point the second spherical wavefront after a time s. Figure 8 presents the case when at a scale for m/s and m/s. Figure 8 shows the circle of the instant velocities with center at and at point the circle on which all velocities originating at land; both circles have a radius of m and are in the absolute frame. Each velocity applies on a wave wavefront in the absolute frame. For example, the ballistic law acts on the wave wavefront emitted in the direction and its velocity along the traveling path is the vector sum of velocity along and common velocity along ; all three vectors are shown in a thick line. The wave wavefront emitted by the source at point in the direction travels in the direction and arrives at point at time s from the initial instance at . Each illustrated can be singled out by the same reasoning in this multitude of lines.
Because the second wavefront is emitted after time s from the initial instance, the circle with the radius of m and the center at also represent the wavefront emitted at . At point after two seconds from the initial instance, the wavefront emitted has a radius of m and that emitted at has a radius of m. The vector velocities and circular wavefronts are shown in thin lines.
When the source is in motion at a velocity , each emitted wavefront of a wave inherits the velocity of the source in the absolute frame, such that the phenomenon in the inertial frame of the source is like that in the absolute frame when the source is at rest. In the source inertial frame, when the source emits light continuously, each wave travels at the emitted speed with wavelength , period , and frequency in any direction.
3.2. Reflection of Light by a Moving Mirror
Figure 9 illustrates the absolute frame in which a mirror travels at velocity and the source of coherent light is at rest. The wave wavefronts reflected at point of the mirror belong to the waves originating from the sequential points of the source.
This section employs Equation (4), , where the electromagnetic speed replaces and the reflected speed of the wavefront in the absolute frame replaces :
In the absolute frame, the speed of the mirror in the direction opposite to the incident light is , and the speed of the mirror in the direction of the reflected light is . Another form of Equation (7) is
where angles and are measured counterclockwise from velocity .
In the absolute frame, the mirror moves in one direction, but the inclination of the mirror reflects light in multiple directions.
A second after the collision at , the wave’s wavefront from is at and the mirror is at . The wavefronts reflected between and travel in the absolute frame in the direction at speed . In the inertial frame of the mirror, the wavefronts travel on the path , forming a continuous wave of light propagating at velocity , wavelength , period , and frequency . Velocity is given by the vector subtraction of velocity of the wavefronts and of source, and velocity does not change the direction and magnitude of the velocity . A local observer at point perceives the wavefront coming from .
The source may not be at rest; therefore, the speed of light propagation is in the absolute frame. In this case, the mirror may also perceive the source’s velocity not only the emitted velocity. In References 6 and 7, we approached this general consideration.
3.3. Emission, Propagation, and Reflection of Light as Mechanical Phenomena in the Absolute and an Inertial Frame
The study of the emission, propagation, and reflection of light is based on that of balls, as described in Subsection 2.6. The mechanical velocity is the same as that for balls with or without mass. The emitted velocity replaces the velocity for the balls.
Figure 10 illustrates the same light source and reflecting mirror at rest in the absolute and an inertial frame. The source and mirror have the same geometry and the source is at the origin of each frame.
In the absolute frame , the source at the origin emits a wavefront at velocity at an angle from the axis . After time , the wavefront is at point of the mirror . At point , the wavefront is reflected at velocity , then travels the path in time . The velocity and have the magnitude . The light travels paths and in time at speed , wavelength , period , and frequency .
The inertial frame travels at velocity , and the source is at the origin on the mirror. Origin and points and belong to the inertial frame, and their instances in the absolute frame receive a corresponding index. The source emits a wavefront at the velocity in direction at angle from axis . The wavefront travels on the propagation path at the propagation velocity given by the vector sum of the emitted velocity and source velocity . The velocity does not change its direction and magnitude along the path . At point , the wavefront is at ; it has traveled the path at speed in time , and the direction makes angle from axis . Path is path in the inertial frame, which is identical to in the absolute frame. The wave’s wavefronts emitted at point between and are on path .
At point of the reflection, the mirror perceives only the magnitude and direction of the emitted velocity because the wavefront and mirror have the same velocity . The incident and reflected angles are measured from the normal to the mirror at the collision point to the incident velocity and reflected velocity . After reflection, the velocity keeps the light moving in the same direction with the same magnitude. The wavefront travels on the propagation path at the propagation velocity given by the vector sum of the reflected velocity and source velocity . The velocity does not change its direction and magnitude along path . At point , the wavefront emitted from is at , the direction makes angle from axis , and the wavefront has traveled the path at speed in time and the path at speed in time . Path is the path in the inertial frame identical to that in the absolute frame. At point , light has traveled the path and in the time at speed , with wavelength , period , and frequency , as in the absolute frame. A local observer at point observes the light coming from the origin and another at point observes the light from point .
3.4. Discussions
The kinematics of light makes the difference between the emitted and propagated light speed. Maxwell’s equations give the instant emitted speed of light which is the universal constant by a source at rest or in motion in a vacuum of the absolute frame. When the source is at rest in the absolute or an inertial frame, the expression “emitted light speed” applies to waves that travel at speed with wavelength , period , and frequency . When the source is in motion at variable speed in the absolute or an inertial frame, the expression “emitted light speed” applies to wavefronts of a wave emitted at the instant speed in their frame. Therefore, we can say that the instant emitted speed of light is the constant independent of the source velocity. The wavefronts inherit the source speed and according to the ballistic law, their propagated speed in the absolute frame is given by . Therefore, we can think of the emitted light speed as waves when the source is at rest in the absolute and inertial frames and the propagated light speed as wavefronts of a wave when the source is in motion. Differently from the emitted light speed, the propagated light speed is variable according to the angle of the direction of the wavefronts made with the fixed direction of velocity .
In the inertial frame of a source, a mirror at rest perceives only the emitted directions of the waves that are then reflected accordingly. The reflected waves inherit the source’s velocity such that the waves in the source inertial frame are like when the source is at rest in the absolute frame having the same , , , and .
The ballistic law applicable to balls and light is embedded in mechanics because it is derived from mechanics. It works in the absolute frame which is the background of any source’s inertial frame and acts on each ball and light wave emitted by a source in motion creating in the source’s inertial frame a phenomenon identical to that in the absolute frame when the source is at rest. Therefore, the kinematics of light explains and confirms the principle of relativity, according to which no experiment in an inertial frame can prove its motion. It also explains why the laws of physics have the same form in each inertial frame, and why the speed of light is the constant in inertial frames when the source and reflected mirror are at rest.
It is convenient to compare the physical phenomena from inertial frames with the frame at absolute rest, which is a hypothetical inertial frame at zero speed. The phenomena in each inertial frame are similar to those in the frame at absolute rest. Therefore, each inertial frame can be considered a local frame at absolute rest for phenomena belonging to that inertial frame. The study of a physics system belonging to an inertial frame can be performed in another frame considered a stationary frame or a local absolute frame where the inertial frame travels at the relative velocity between the two frames.
3.5. Experiments and Observations that Support the Kinematics of Light
The kinematics of light explains experiments and local observations that supported special relativity due to insufficient and incorrect understanding.
3.5.1. Michelson‒Morley Experiment
Light travels through a transparent medium at a specific constant speed independent of the source speed. Michelson and Morley [14] approached their experiment considering the theory of fixed ether. Therefore, the speed of light emitted by a source and reflected by a mirror has the same magnitude in the hypothetical ether at rest in the absolute frame, regardless of whether the source and mirror are at rest or in motion. In ether theory, the speed of light is limited by the ether. The Michelson‒Morley experiment predicted a fringe shift that was not confirmed by the experimental results.
The kinematics of light proves that in an inertial frame where a source of light and a mirror are at rest the speed of light is the constant of electromagnetic nature. Therefore, the kinematics of light predicts a zero fringe shift in the Michelson‒Morley experiment, which agrees with the experimental results.
3.5.2. Experiment Performed at CERN, Geneva
Without rejecting Ritz’s ballistic theory, [15] the emission, propagation, and reflection of light in inertial frames [4] can explain the experiment performed at CERN, Geneva, in 1964. [16] Figure 11 illustrates this phenomenon using a simple approach.
When a boson of mass is accelerated at a mechanical speed near the constant speed of light , it decays into particle of mass and one massless photon. At speed , particle changes direction and the photon continues moving free at the mechanical speed . Bosons are just carriers that give photons their mechanical speed near the constant speed of light . Bosons are not sources of light and cannot give photons the speed of electromagnetic nature. This experimental result confirmed the ballistic law of light.
3.5.3. Observation of a Star in the Universe
Figure 12(a) illustrates the observation of a star in the universe according to the kinematics of light. Suppose that a star at point and the Earth at point travel at velocity . At the initial instance, the star emits a wavefront of light in the direction at the emitted speed .
After a certain time, the star travels the path and the Earth travels the path , which are of equal length . Ballistic law makes the wavefront emitted in the direction to propagate along . At , the local observer perceives the wavefront as coming from . Therefore, the star is observed at its actual location.
Figure 12(b) illustrates the observation of a star in the universe based on the hypothesis that the speed of light is independent of the source motion. Suppose a star at point and the Earth at point travel at velocity . At the initial instance, the star emits a wavefront of light in the direction at the emitted speed .
After a certain time, the star travels the path and the Earth travels the path , which are of equal length . The wavefront emitted in the direction reaches point , where a local observer perceives the wavefront coming from . Therefore, the star is observed at the initial location and not at its actual location, which means that the hypothesis of the constancy of the speed of light creates irregularities that are unobserved by astronomers. These irregularities differ from those that De Sitter incorrectly predicted. [17,18]
3.5.4. Observation of a Star’s Orbit
Light emission as a mechanical phenomenon [4] has been applied to star orbit observation. [5] Figure 13 depicts an actual star’s orbit with the center at point of radius in the plane of the paper and an imaginary circle of radius with the center at point and with its plane parallel to and in the front of the paper plane.
The distance is perpendicular to the orbit and imaginary circle planes. The observer at rest is located at point . The observed star orbit of the radius is centered on . The view is from the back right of the observer, enabling a clear image of the actual and observed orbits.
The distances in each set of ( and (), including all other similar distances corresponding to points , and are equal.
The waves emitted by the star in motion inherit the velocity of the star corresponding to each orbital point and travel through different paths to the local observer . At point , the star emits a wavefront of light at the velocity in the direction , but this wavefront travels along the path at the propagation velocity . At point , the observer observes the wavefront originating from point traveling at speed . At point , the star emits a wavefront of light at the velocity in the direction , , and this wavefront travels along the path , , at the propagation velocity . At point , the observer sees the wavefront coming from point traveling at speed along path . The observer perceives a similar observation for each point in the circular orbit.
Points , and give the corresponding points , and , which in this particular case give the observed orbit with the center at . The local observer sees the star’s orbit rotated; this orbit has a larger diameter than the actual orbit and the observed orbital speed is higher than that of . The speed of light from any point on the observed orbit to the observer is the constant . Therefore, no time irregularities exist to refute Ritz’s ballistic theory, [15] as De Sitter did. [17,18] Observing a star’s orbit supports our understanding of the kinematics of light based on the ballistic law.
3.5.5. Miller Experiment
Studying the emission, propagation, and reflection of light in inertial frames [4] helps us to predict zero fringe shifts for any location and altitude in Earth’s inertial frame. This explains Miller’s experiments [9,10] at the Cleveland Laboratory in 1924, [19] which employed light from local sources, as well as sunlight; the fringe shift with sunlight was of the order of . The fringe shifts of 0.08 in 1921 and 0.088 in 1925, recorded by Miller using local sources at a high altitude on Mount Wilson, remain unexplained.
3.5.6. Airy Experiment
In addition to the interactions of the emission and reflection of light with matter, there are other examples, such as the velocity of light through a moving medium [8] and the refraction of light when it travels from one medium to another, both at rest, according to Snell’s law. Airy’s experiment is an example of dragging light by a moving medium. Observing the star γ Draconis, Airy [20] expected to adjust the inclination of the telescope after introducing a tube with water along its axis; however, this was unnecessary. Considering the dragging of light by moving water and the experimental results, we obtained the Fresnel dragging coefficient from a mechanical perspective, where is the refractive index of the medium.
3.5.7. Majorana Experiment
Majorana’s experiment [21] in Earth’s inertial frame employs a fixed light source. The light travels through three stages, each consisting of one movable and one fixed mirror, and enters a Michelson interferometer with arms of unequal length. The movable mirrors are fixed on a rotational disk in both directions. A fringe image is observed when the disk is at rest. When the disk is rotated from maximum speed in one direction to another, a shift of 0.71 fringes is observed. Similar to the Michelson interferometer, Majorana’s experimental device offers an outstanding contribution to the physics of light, despite changes in the interpretation of the experiment over time. Majorana misunderstood the phenomenon within the device and the significance of the fringe shift observed during the experiment, explaining the fringe shift favorably to special relativity. The reflection of light as a mechanical phenomenon [1,2,3,4] applied to the Majorana experiment [21] shows that the speed of light changes after each stage, causing a fringe shift in the Michelson interferometer. Reference 12 approximates rotational mirrors as inertial frames and derives a shift of 0.27 fringes. However, the observed fringe shift of 0.71 confirms the kinematics of light, rejecting the constancy of light propagation.
3.6. Galilean Transformation
We studied the Galilean transformation for light like in mechanics that presents the physical phenomena as they are not observed.
When extended to infinite, all the inertial frames overlap. A phenomenon in an inertial frame is instantly shared with any other inertial frame. The inertial frame in which a phenomenon is shared is considered at relative rest/a stationary frame.
The Galilean transformation shows how the physical phenomenon of light emission is instantly shared from a stationary frame in an inertial frame. Figure 14 depicts a stationary frame in which an inertial frame travels at velocity along the axis, and the planes and are common. The drawing is at a scale for a time s.
The kinematics of light proves that a stationary frame/frame at relative rest can be considered a local frame at absolute rest; we do not assume this fact.
Origins and coincide at the initial instance when the source, belonging to the origin of the stationary frame, emits a spherical wavefront of light formed by the individual waves’ wavefronts. After time , the spherical wavefront of light has its center at , and the origin of the inertial frame is at a distance from . Galilean transformation provides in the inertial frame the coordinates of each point on the spherical wavefront. Figure 14 shows the waves’ wavefronts at points , , , and on the circular wavefront in the plane at time and their coordinates along the axis of the frame .
The Galilean transformation consists of four equations applicable to each point of the spherical wavefront that can be written as follows:
The wave’s wavefront emitted at the initial instance in the direction travels in this direction at all times. It is on this circular wavefront, which enlarges continuously. This wave’s wavefront travels the length in the inertial frame at propagation speed . The vector subtraction of velocity along and along gives the velocity illustrated along . This wave’s wavefront travels at the same angles and and speed for any other instance of the circular wavefront. Angle and speed are variables according to the angle . The speed of wavefronts varies from for to for and to for .
Figure 14 and the Galilean transformation applied to a hypothetical ball source when the source emits a circular ball front with the speed of the balls .
In Figure 14, the physical phenomenon consists of the source, the circular wavefront, and the light waves as , , , and ; all belonging to the stationary frame and none to the inertial frame. A phenomenon in an inertial frame is unique in the universe; it is independent of any other inertial frame and, though it is instantly shared in any other inertial frame through its coordinates, it is not duplicated. There are no transformations of phenomena that undergo changes from the stationary frame to the inertial frame that may or may not affect the laws of physics. The term "transformation" may be inappropriate; a better wording may be "Galilean coordinates.”
Discussions
In the Galilean coordinates shown in Figure 14, the phenomenon, which includes the light source, the circular wavefront, and the light waves as , , , and , belongs to the stationary frame. The circular wavefront has the center at the source located at the origin of the stationary frame. Each point of the circular wavefront is a coordinate to the origin of the inertial frame, given by Equation 9.
The ballistic law was unknown in Einstein’s time; therefore, he had to work with the above case and the following one: In Figure 14, if the source belongs to the origin of the inertial frame and the ballistic law is ignored, the phenomenon, which includes the light source, the circular wavefront, and the light waves as , , , and , belongs to the inertial frame. The circular wavefront has the center at the origin of the stationary frame and not at the source. Thus, the circular wavefront is common if the source belongs to either of the two origins. In the inertial frame, each point of the circular wavefront is given by Equation 9.
If the source belongs to the origin and applying the ballistic law, the phenomenon, which includes the light source, the circular wavefront of radius , and the light waves as , and , belongs to the inertial frame
Einstein hypothesizes that if the source belongs to either of two frames, the common circular wavefront is observed in the inertial frame as a circular wavefront with the center at its origin. To fulfill his hypothesis, he applies a mathematical transformation to the common circular wavefront, for both cases.
Understanding Einstein's approach to the two cases above the ballistic law is sufficient to reject special relativity. However, we chose to do so from within the special relativity presented in Section 4.
4. Einsteinian Theory of Special Relativity
4.1. Einstein Suggestions
In the first paragraph on page one of his manuscript “On the electrodynamics of moving bodies,” [22] Einstein writes the following: “It is known that Maxwell’s electrodynamics—as usually understood at the present time—when applied to moving bodies, leads to asymmetries which do not appear to be inherent in the phenomena. For example, consider the reciprocal electrodynamic action of a magnet and a conductor. The observable phenomenon here depends only on the relative motion of the conductor and magnet, whereas the customary view draws a sharp distinction between the two cases in which either one or the other of these bodies is in motion. If the magnet is in motion and the conductor is at rest, there arises in the neighborhood of the magnet an electric field with a certain definite energy, producing a current at the places where parts of the conductor are situated. However, if the magnet is stationary and the conductor is in motion, no electric field is generated in the neighborhood of the magnet. In the conductor, however, we find an electromotive force, to which in itself there is no corresponding energy, but which gives rise—assuming equality of relative motion in the two cases discussed—to electric currents of the same path and intensity as those produced by the electric forces in the former case.”
Einstein’s example describes a reciprocal experimental observation of a conductor and magnet in proximity when one is in motion/rest and another is at rest/in motion but only when the magnet is in motion an electrical field arises. He may suggest that observations are sufficient to accept reciprocal phenomena symmetrical even if an electromagnetic quantity, such as an electric field, does not occur when the magnet is at rest. Therefore, it is not necessary to rationally understand physical phenomena. Appendix B shows that in both cases an electric field arises in the conductor, making it an electrical source. Thus, Maxwell’s electrodynamics lead to symmetries when applied to moving bodies; each physical quantity involved in a phenomenon arises and the phenomena can be rationally explained.
Even if the reciprocal phenomena are explained, can we apply the symmetry of phenomena to the symmetry between two inertial frames? Einstein’s example has a magnet and conductor in proximity, and they have reciprocal electromagnetic properties. None of these characteristics applies to a stationary and inertial frame to support special relativity. Origins of the two frames depart from each other and remain nearby for a relatively short time. The frames, including the absolute frame, are hypothetical entities. These tools help us to study and understand physical phenomena. They have no physical properties to transform or duplicate a physical system from one frame to another.
By applying symmetry to two inertial frames, the main idea in special relativity, Einstein unrealistically creates duplicates that lead to irrational conclusions, which are discussed further.
From “Examples of this sort, together with the unsuccessful attempts to discover any motion of the earth relatively to the 'light medium',” Einstein concludes with three suggestions in the second paragraph of page 1:
- “… the phenomena of electrodynamics as well as of mechanics possess no properties corresponding to the idea of absolute rest.”
Einstein rejected the idea of absolute rest. However, the inertial frame considered stationary is a local frame at absolute rest for another inertial frame. The stationary frame was a convenient choice to present his transformational understanding of the phenomenon between the two inertial frames.
- 2.
- “… the same laws of electrodynamics and optics will be valid for all frames of reference for which the equations of mechanics hold good.”
The equations/laws of mechanics are valid for phenomena belonging to an inertial frame, but not for the coordinates of phenomena in another inertial frame. However, contrary to the second suggestion, special relativity forces the laws of electrodynamics and optics to hold good for coordinate observations, for which mechanics does not.
- 3.
- “… light is always propagated in a vacuum with a definite velocity , which is independent of the state of motion of the emitting body.”
In a stationary frame/local frame at absolute rest, the emitted wavefront from a source at rest travels at the velocity in all directions. The spherical wavefront has continuously its center at the source at rest. However, without considering the ballistic law of light, when the source is in motion at a velocity , the emitted wavefront at an initial instant location of the source travels in the stationary frame at the velocity . In this case, the spherical wavefront has the center at the initial instance location of the source, not at the actual source location. Therefore, there are differences in wave propagation if the source belongs to the stationary or inertial frame.
Without understanding the physical phenomena of his example and the comments from the above suggestions, Einstein has chosen to formulate hypotheses based on observations, elevating them to postulates.
4.2. Einstein Postulates
From the three suggestions, Einstein formulates two postulates:
- “The laws by which the states of physical systems undergo change are not affected, whether these changes of state be referred to the one or the other of two systems of co-ordinates in uniform translatory motion.”
- “Any ray of light moves in the “stationary” system of co-ordinates with the determined velocity , whether the ray be emitted by a stationary or by a moving body.”
A phenomenon in a stationary frame is independent of the inertial frame, although instantly shared with the latter through its coordinates. The first postulate forces the shared coordinates in the inertial frame to obey the same laws of physics as those applied in the stationary frame, thereby creating a fictive duplication of a phenomenon from a stationary frame into an inertial frame. The first postulate includes the phenomena of electrodynamics, optics, and mechanics in physical systems; see also Suggestion 2 of Subsection 4.1. However, in practice, special relativity is applied to light observation.
The second postulate indicates the comments regarding Suggestion 3 of Subsection 4.1 were not considered in Einstein’s study.
Einstein applied this transformation when the source belonged to a stationary or inertial frame. For clarity presentation, we consider the light source to belong to a stationary frame. If the source belongs to the inertial frame, then this frame is considered stationary. Einstein presented a transformation identical to the well-known Lorentz transformation. [23]
4.3. Lorentz Transformation and Einstein Transformation
Figure 15 depicts a stationary frame in which an inertial frame travels at a velocity along the axis, and the planes and are common. Origins and coincide at the initial instance when a light source belonging to the origin emits a spherical wavefront. After a time , the spherical wavefront expands in space with a radius of magnitude , and the origin is at a distance from . The drawing is at a scale for a time s.
In the theory of the ether at rest in the absolute frame, the speed of light is the constant . Observations and Michelson‒Morley’s experiment can be explained if the speed of light is the constant in inertial frames. With no explanation of the Michelson‒Morley experiment during his time, FitzGerald [24] wrote the following: “I would suggest that almost the only hypothesis that can reconcile this opposition is that the length of material bodies changes, according to their movement through the ether or across it, by an amount depending on the square of the ratio of their velocity to that of light.”
Lorentz considers the coordinates of the spherical wavefront of light from the stationary frame along the three axes of the inertial frame and applies his transformation only along the axis . The projection of each coordinate of the spherical wavefront gives in the inertial frame along the axis a length measured from to . Lorentz’s transformation hypothesizes that light travels each length at speed in a time and consists of four equations that apply to each point of the spherical wavefront as follows:
where is the Lorentz factor, which is comparable to the square of the velocity and ratio, as suggested by FitzGerald.
In Figure 15, the mechanical equation for the wavefront traveling the path is ⇒ ⇒ ⇒ with . In Lorentz’s transformation, the equation for is identical to that in mechanics for ; thus, both lengths have an equal absolute value. If we hypothesize the constancy of light speed, then from mechanics becomes the speed in the inertial frame and . Therefore, offers ⇒ which is the equation of time in Lorentz’s transformation. We obtained the following set of equations:
Multiplying and with factor we get Lorentz’s transformation. (10)
Substituting at point , is the absolute coordinate in the inertial frame, and is the hypothetical contracted time by given by Lorentz, in which the wavefront travels length at speed . , , and then , which verifies the constancy of light. Because for , the length is longer than , and point shifts to .
Substituting at point , is the absolute coordinate in the inertial frame, and is the hypothetical dilated time by given by Lorentz, in which the wavefront travels length at speed . , , and then , which verifies the constancy of light. Because for , the length is longer than , and point shifts to .
In the relativistic time of Lorentz’s transformation, the speed of light is the constant , and has the same absolute magnitude as in mechanics. Thus, the time contracts or dilates accordingly such that and for each spherical point stay constant, therefore, no length contractions or dilations exist.
The following numerical calculation employs the lengths shown in Figure 15 which all are of absolute values including the length offered by Lorentz’s transformation. The speed of light along each length given by the projection of each wave in any direction on the axis is constant according to the relativistic time in Lorentz’s transformation. For an angle and a time we can calculate , , , , , , and angle . Employing relativistic speed along , ⇒ . From the geometry of the triangle with absolute side lengths, the time the light travels along must equal the time the projected light travels . Therefore, the speed of light traveling is . Table 1 lists the numerical calculations for the and functions of angle at time s.
Table 1 confirms that Lorentz's transformation maintains the constancy of the speed of light for the waves in the direction and the opposite direction. However, the speed of every other wave direction varies converging to infinite. The second postulate asserts the constancy of the speed of light in the inertial frame regardless of its direction; whereas the transformation drastically concludes otherwise.
We can hypothesize that the speed of light along is constant , . In this case, we apply Lorentz’s transformation along as it is used along , at the same time , speed along , and speed along . In this case, the speed along is which when , and points , , and coincide, and for , point is at origin , point coincides with , , and .
The time the light travels the path at speed is , and the time the light travels path at speed is . The time the light travels the path at speed can be calculated with Lorentz’s equation where and are unchanged but and is ; therefore becomes . Times and calculate considering the light passes as absolute values yield the same time s and, applying Lorentz’s equation, time gives s. The time difference between and does not support the constancy of light along too.
Because for , the length is longer than , and points and shift to and , correspondingly. For angle , and . Thus, Lorentz’s transformation creates a duplication as an ellipsoid instead of a sphere. The time gives the time s, which confirm the hypothesis the speed of light is incorrect.
This case confirms the constancy of the speed of light for the waves in the direction and the opposite direction as Lorentz’s transformation does. However, the speed of every other wave direction varies but without converging to infinite.
4.4. Discussions
1. Is it rational to observe the circular wavefront with its center at the origin and to keep the speed of light constant along the axis in both directions or to have a theory that may or may not explain experiments and observations without understanding their physics phenomena? Furthermore, is it reasonable to force the circular wavefront and its observations to follow the same physical laws as those in the stationary frame? Einstein chose this approach, leading to an irrational world. Unlike special relativity, Newtonian laws present phenomena as they are, rationally understood by themselves, and not accepted by observations, hypotheses, or postulates.
2. What natural phenomena can transform each wave from a stationary frame into its unique form, as required by Lorentz’s transformation and shown in Figure 15? Other mathematical transformations can be considered, e.g., ignoring the Lorentz factor as discussed in Subsection 4.3, allowing the speed of light to be constant along each wave in the inertial frame, or having the time a constant and the speed of light variable according to its direction. [25] Could there be a phenomenon for each of these hypothetical mathematical transformations to explain the Michelson‒Morley experiment? If so, which one would be correct? If we try these transformations, we obtain a theory with irrational conclusions like that for special relativity.
3. A ruler identical to that in the stationary frame is required to measure the lengths involved in phenomena that belong to the inertial frame. We also must have two rulers with different scales required by Lorentz's transformation to measure the lengths along according to positive or negative, or considering other directions. The use of multiple rulers is unacceptable. The same conclusion applies to multiple synchronized clocks.
4. Suppose that the inertial frame also has a source at its origin. When the origins coincide, each source emits a circular wavefront of light. Whether or not we consider the factor , imagine the confusion in the inertial frames having two wavefronts, one of its own and another observed from the stationary frame.
5. When we observe a star that involves astronomical distances, as seen in the example in Subsection 3.5.4, we observe it in an enlarged orbit without irregularities; however, our observation does not change the actual orbit. There is no need to mention other observations close to our eyes that we know are not factual. These observations can be explained by laws of physics. However, we must distinguish between actual phenomena and their local observation. Therefore, we cannot rely solely on observations. Special relativity focuses on observations but makes no distinction between the emitted and propagated velocities of waves' wavefronts. It fails to consider that our eyes perceive only the direction of waves emitted by a source and reflected by a mirror, not the direction of wave propagation.
6. Figure 15 illustrates a case in which origins and coincide at the initial instance. However, origin may be far away from when the source emits a spherical wavefront at an initial instance. In this case, there is an interval of time when the circular wavefront does not include the origin , a time when the circular wavefront is at the origin , and an interval of time converging to infinite when the circular wavefront includes the origin . How is the circular wavefront observed at at these different times? Do we force the coordinates of the circular wavefront to be observed according to the Lorentz transformation with its center at at any time?
7. Suppose that a source of balls in the stationary frame emits balls of equal mass in all directions at a speed that is higher than the speed of the inertial frame . As for light, the coordinates of the spherical ball front in the inertial frame at a time are as in Figure 15. Mechanics does not and cannot force the coordinates of the circular ball front to have its center at ; in Einstein’s words, “the equations of mechanics do not hold good” in this case. However, special relativity does not respect Suggestion 2 of Subsection 4.1.
8. The first postulate indicates that the physical systems in the stationary frame change when they are transformed/duplicated into the inertial frame. The physical system mentioned in the first postulate has a source and light rays that create a circular wavefront. However, other systems may contain bodies and living beings involved in a phenomenon. Considering that the origin of inertial frames is relative, their origins can be at the origin of the stationary frame when the source emits a spherical wavefront of light. We can imagine what the physical systems’ duplication from a stationary frame in all other inertial frames means. Moreover, each inertial frame may be arbitrarily stationary; therefore, a phenomenon from another stationary frame can be duplicated in all other inertial frames. Do all these duplications occur just by choosing a stationary frame? All these duplications are irrational and are not observed in the universe or at a local scale.
9. In a stationary frame, as shown in Figure 15, the origin of the inertial frame may travel through a few consecutive points along the axis. Suppose that a phenomenon arises in the stationary frame when the origin coincides with each consecutive point. Each of these phenomena is thus transformed at the origin . Imagine all of these phenomena involving bodies and living beings at .
5. Lorents’s Transformation Derived from a Mechanical Perspective
In Figure 15, when the origins coincide, the light source emits in the stationary frame waves in all directions at speed , with wavelength , period , and frequency that are not disturbed by the inertial frame in which the wave propagation is observed. When the wavefront that travels along the axis arrives at point in time , the length is given by equation
Equation (12) can be written as which yields the same equation in another form
with variable speed according to the speed of the inertial frame. Introducing Equation (13) in Equation (12), Equation (12) can be rewritten as ⇒ where , , and are the numbers of wavelengths comprised in the lengths of , , and . For , we obtain a fractional relation of a rational number :
The number of wavelengths can be replaced with one as in the Detail of Figure 15 or with wavelength which gives , or the length which yields , or the speed which offers . As fractional relations, all these arrangements are correct and meaningful in mechanics.
When we replace with the time , the fractional relation
is susceptible to relativistic time interpretation. For and relation (14) can be written as a fractional time
The fractional term from relation (14) yields which is the equation for time in the set of Equations (11) of Lorentz’s transformation. For convenience, we prefer to use instead . As shown in detail in Figure 15, light travels the fraction of wavelength in time . This implies that, in the inertial frame, light travels one wavelength at period ⇒ , frequency , and speed , as in the stationary frame. Considering and as in mechanics, the set of Equations (11) of Lorentz’s transformation is complete, which gives in the inertial frame the absolute lengths , , , and fractional time as in Subsection 4.3.
We presented the mechanical derivation of Lorentz’s transformation identical to the hypothesized Lorentz transformation as in Subsection 4.3. Understanding the incorrectness introduced in this derivation, we know that of Lorentz’s.
For the wavefront in the direction , the division of as in Subsection 4.3 where we incorrectly considered it to verify Lorentz’s transformation. Here, the speed does not represent the speed of light in the inertial frame as Lorentz’s transformation and Einstein’s special relativity pretend because the equation is correctly an equation between different quantities that gives an absolute length but the term belongs to the fractional relation (14) for a quantity, which in this case is time . Indeed, the division can be written as ⇒ ⇒ as in mechanics with variable speed according to the speed of the inertial frame. The incorrectness in Lorentz’s transformation and Einstein’s special relativity not only refutes them but proves the constancy of time passage in the universe and the variability of light speed in the form of light propagation; light emitted by a source in motion is the constant in the absolute frame.
The following paragraphs show how different the Doppler observation in an inertial frame is from special relativity.
As shown in detail in Figure 15, light travels the fraction of wavelength in time . This means that, in the inertial frame, light travels one wavelength at period , speed , and frequency that is the observed frequency offered by the Doppler effect. The number of wavelengths comprising is .
In the direction, light travels the length in time and one wavelength at period , speed , and frequency that is the observed frequency offered by the Doppler effect. The number of wavelengths comprising is .
6. Conclusions
Lorentz's transformation is based on observations and duplicates the physics phenomena from a stationary frame into an inertial frame.
The transformation incorrectly provides the constant speed of light in both the moving and opposite directions of the inertial frame. Simultaneously, it varies in any other direction, converging to infinite. However, special relativity claims that the speed of light is constant in all directions.
The time contraction in the moving direction of the inertial frame differs from the time dilation in the opposite direction, requiring a ruler and time synchronization in both directions and any others.
There are no length contractions In Lorentz’s transformation to support this fundamental concept of special relativity.
The above unacceptable conclusions derived from calculations and discussions of Subsection 4.4 make the theory of special relativity rejectable.
The saga of special relativity started with FitzGerald’s statement that the length of material bodies changes based on a misunderstanding of the Michelson‒Morley experiment. Lorentz continued this with his transformation, and Einstein did so with an entire theory accepted by many others when there was no theory to explain experiments. Special relativity should not have been written or accepted.
Mechanics present phenomena as they are. Special relativity focuses on observations of phenomena instead of understanding them. In contrast to these two approaches, the article presents how the phenomena are, like in mechanics, and how a local observer perceives them, which helps us understand reality.
The kinematics of light explains why the speed of light is constant in any inertial frame in which a light source and reflective mirror are at rest, why the laws of physics have the same form in each inertial frame, and why no light experiment in an inertial frame can prove its motion.
Matter creates light and, as a mechanical phenomenon, the kinematics of light naturally presents light in its interactions with matter at emission and reflection, [1,2,3,4,5,6,7,9,10,12] refraction, [11] and when traveling through a moving medium. [8] The phenomena described in References [8] and [11] may be considered complementary, one approaches the longitudinal dragging [8] and the other the transverse dragging of light by a moving medium. Light and any other electromagnetic radiation can be considered massless matter/fields and the kinematics of light can thus be included in mechanics.
The following mechanical ballistic law governs the kinematics of balls and electromagnetic radiation: a ball or light emitted by a source inherits the velocity of the source in the absolute frame. The ballistic law has the mathematical expression given by a vector sum of velocities based on a physics phenomenon. It is reasonable, understandable without explanations, and fundamental in mechanics like the Newtonian laws.
The kinematics of light also presents the essential concept of how the human eye reacts to propagated and emitted light. The understanding that the human eye perceives only emitted velocity by a source and not its propagation is essential in understanding physics phenomena. Based on the ballistic law, the observation of a star’s orbit as in Subsection 3.5.4 and Reference 5 with no irregularity requires perceiving only emitted velocity . The peripheral vision may explain this perception. Light travels in its propagation direction and can be more or less perceived by the human eye. To have a good view, the eye has to adjust its direct vision with the direction of the velocity . The perception of the constant velocity of light emitted by a source in the absolute frame may be a topic for vision and optical science.
There are different theories of light, e.g., ether theory, special relativity theory, Ritz’s ballistic theory, and kinematics theory similar in concept to Ritz’s. We can consider criteria to distinguish which theory is acceptable. For example, a theory must be based on physical phenomena explainable by themself to which a mathematical expression may be applied, be rational according to human understanding, and explain observations and experiments realistically. The kinematics theory of light and the special relativity theory originated from Newtonian physics and Galilean transformation, but they are different in approach and results. Subsections 2.1-2.3 and 2.6 offer details regarding the discrete emission of balls with and without mass and Subsections 3.1 and 3.3 presents details related to the continuous emission of light. Discussion of Subsection 3.6 shows what Einstein had to deal with not knowing the ballistic law. Einstein eliminated the concept of the frame at absolute rest. He hypothesized that the speed of light is constant in each inertial frame when the source belongs to any inertial frame and without distinguishing between the emitted and propagation velocity. Einstein employed Lorentz’s transformation intending to obtain the constancy of light speed in inertial frames which the ballistic law does. The mathematical Lorentz’s transformation without the support of a physics phenomenon cannot deliver Lorentz’s and Einstein’s intent. Nevertheless, Einstein obtained Lorentz’s transformation in his special relativity. With the unintended irrational conclusions, the special relativity is self-negating.
Acknowledgments
I am grateful to the person who set me on the right path and inspired me to study emission, propagation, and reflection of light as mechanical phenomena.
Appendix A. Experiment on the Reflection and Emission of Light
Michelson derived the fringe shift in his interferometer by employing ether theory. The Michelson‒Morley experiment [14] was expected to yield a fringe shift. The experimental result was considered a failure. By employing ether theory, we derived in Reference 1 and 2 the fringe shift for a particular geometry of the Michelson‒Morley experiment in which the beam splitter has an angle of from the source rays, one opaque mirror is perpendicular to the source rays, and the other is parallel to them. In this case, the expected fringe shift is also .
References 1 and 2 present the reflection of light as a mechanical phenomenon and derive the speed of light reflected by a moving mirror for any angle of the incident light from the velocity of the mirror as well as for any inclination of the mirror. The light source is at rest in the inertial frame of the mirror. The speed of light is considered independent of the light source, as in ether theory. In this setting, the particular geometry predicts a zero fringe shift and the geometry of the Michelson‒Morley experiment predicts a fringe shift of . These theoretical results are consistent with the experimental results. To confirm or reject this conclusion, we searched for another interferometer.
Figure 16 illustrates the interferometer at rest in an inertial frame at velocity . [13] The beam splitter splits the light from the source. The transmitted rays travel from to opaque mirrors and , beam splitter , and screen . The reflected rays travel from to beam splitter and then to screen . All four mirrors have a 45° angle with the incoming rays.
Considering the light reflection as a mechanical phenomenon, the theoretical fringe shift derived in steps of is . [13] This predicted high fringe shift leaves no uncertainty regarding the experimental result of a zero fringe shift. Therefore, the hypotheses that light reflection is a mechanical phenomenon and that the speed of light is independent of the source speed are incompatible. If we only apply ether theory to this interferometer, the theoretical fringe shift is zero according to the experimental results.
Figure 16.
Schematic of the interferometer.
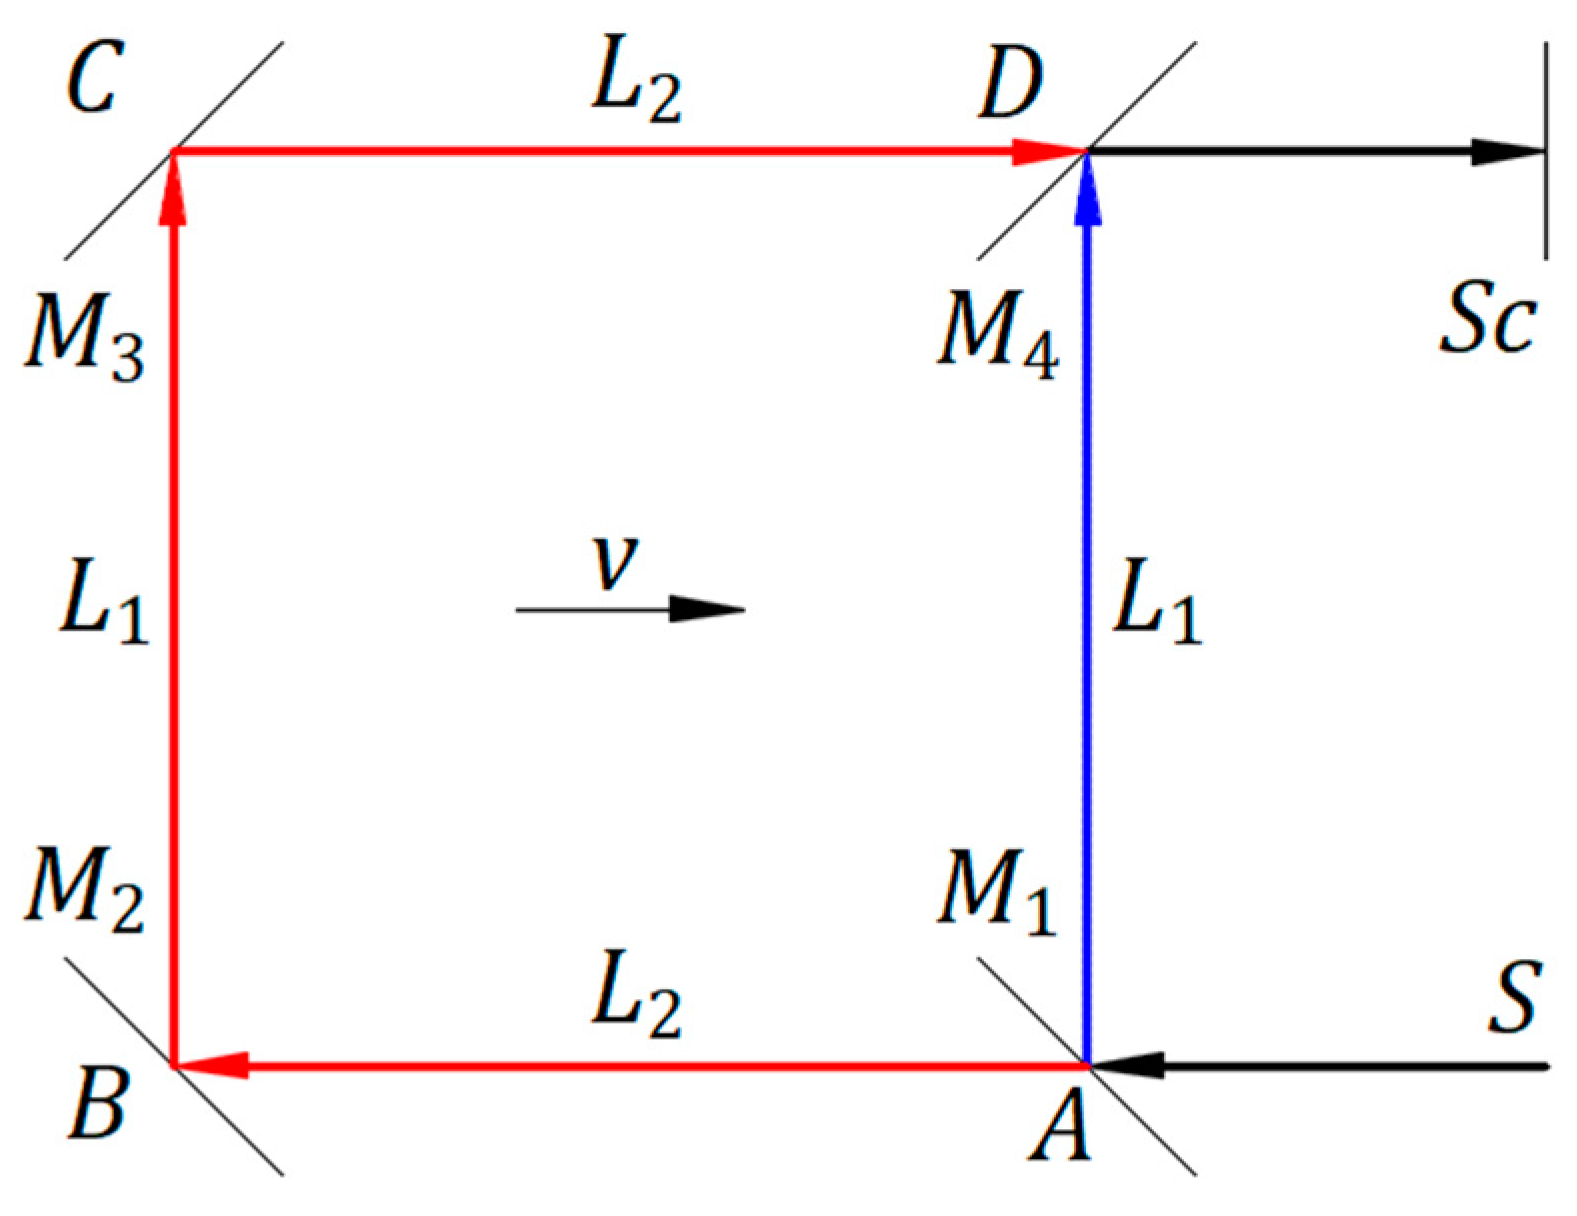
The ether theory and the combination of the two hypotheses that light reflection is a mechanical phenomenon and light speed is independent of the light source lead to theoretical results inconsistent with the experimental results; therefore, we have to reject these two options. This conclusion led us to consider the reflection and emission of light mechanical phenomena [4] that explain the Michelson‒Morley experiment and others presented in this article.
Appendix B. Reciprocal Electrodynamic Action of a Magnet and Conductor
In the magnetic field of a fixed magnet, Lorentz’s electromagnetic force is given by the vector product where is the velocity of a positive or negative electrical charge concerning the fixed magnetic field . When the electrical charge is at rest and the magnet is in motion at the velocity , the velocity of the charge at rest relative to the moving magnetic field is . Considering the velocity of the electrical charge in motion concerning the fixed magnetic field or relative to the moving magnetic field when the electrical charge is at rest, Lorentz’s electromagnetic force remains the same .
The expression has units of , which in physical quantities is that represents the total electrical charge in a conductor of length through which a constant current flows. Therefore, when the magnet is fixed, the Lorentz force becomes where is the current vector in the direction of positive charge flow. Lorentz’s electromagnetic force is when the magnet is in motion and the conductor is fixed.
Lorentz’s right-hand rule and Fleming’s right-hand and left-hand rules are replaced with the following rule derived from the vector product of for perpendicular vectors. The movable quantity rotated in the short direction over the fixed quantity yields the direction of Lorentz’s force.
Figure 17(a) shows a magnet with a magnetic field perpendicular from the front to the back of the paper plane and a conductor in the paper plane that can be connected to an electric current source. The magnet and conductor are in a state of equilibrium when they are at rest relative to each other and no current flows through the conductor.
Suppose the magnet is fixed and the conductor has a degree of freedom in the paper plane in both directions perpendicular to the conductor. Connecting the conductor to the source, the source's electric field forces current to flow through the conductor from top to bottom of the paper. The interaction between the magnetic field and current produces an electromagnetic force of reciprocal repulsion between the conductor and magnet. The Lorentz electromagnetic force is . In this case, of the movable conductor rotated in the short direction over of the fixed magnet gives the direction of the reciprocal repulsive electromagnetic force , which moves the conductor to the right. The inertial force of the conductor acts in the opposite direction of . When the conductor is disconnected from the source, the system enters a state of equilibrium.
Figure 17.
(a) Charged conductor in a magnet’s magnetic field. (b) Moving a conductor or magnet when they are in proximity.
Figure 17.
(a) Charged conductor in a magnet’s magnetic field. (b) Moving a conductor or magnet when they are in proximity.
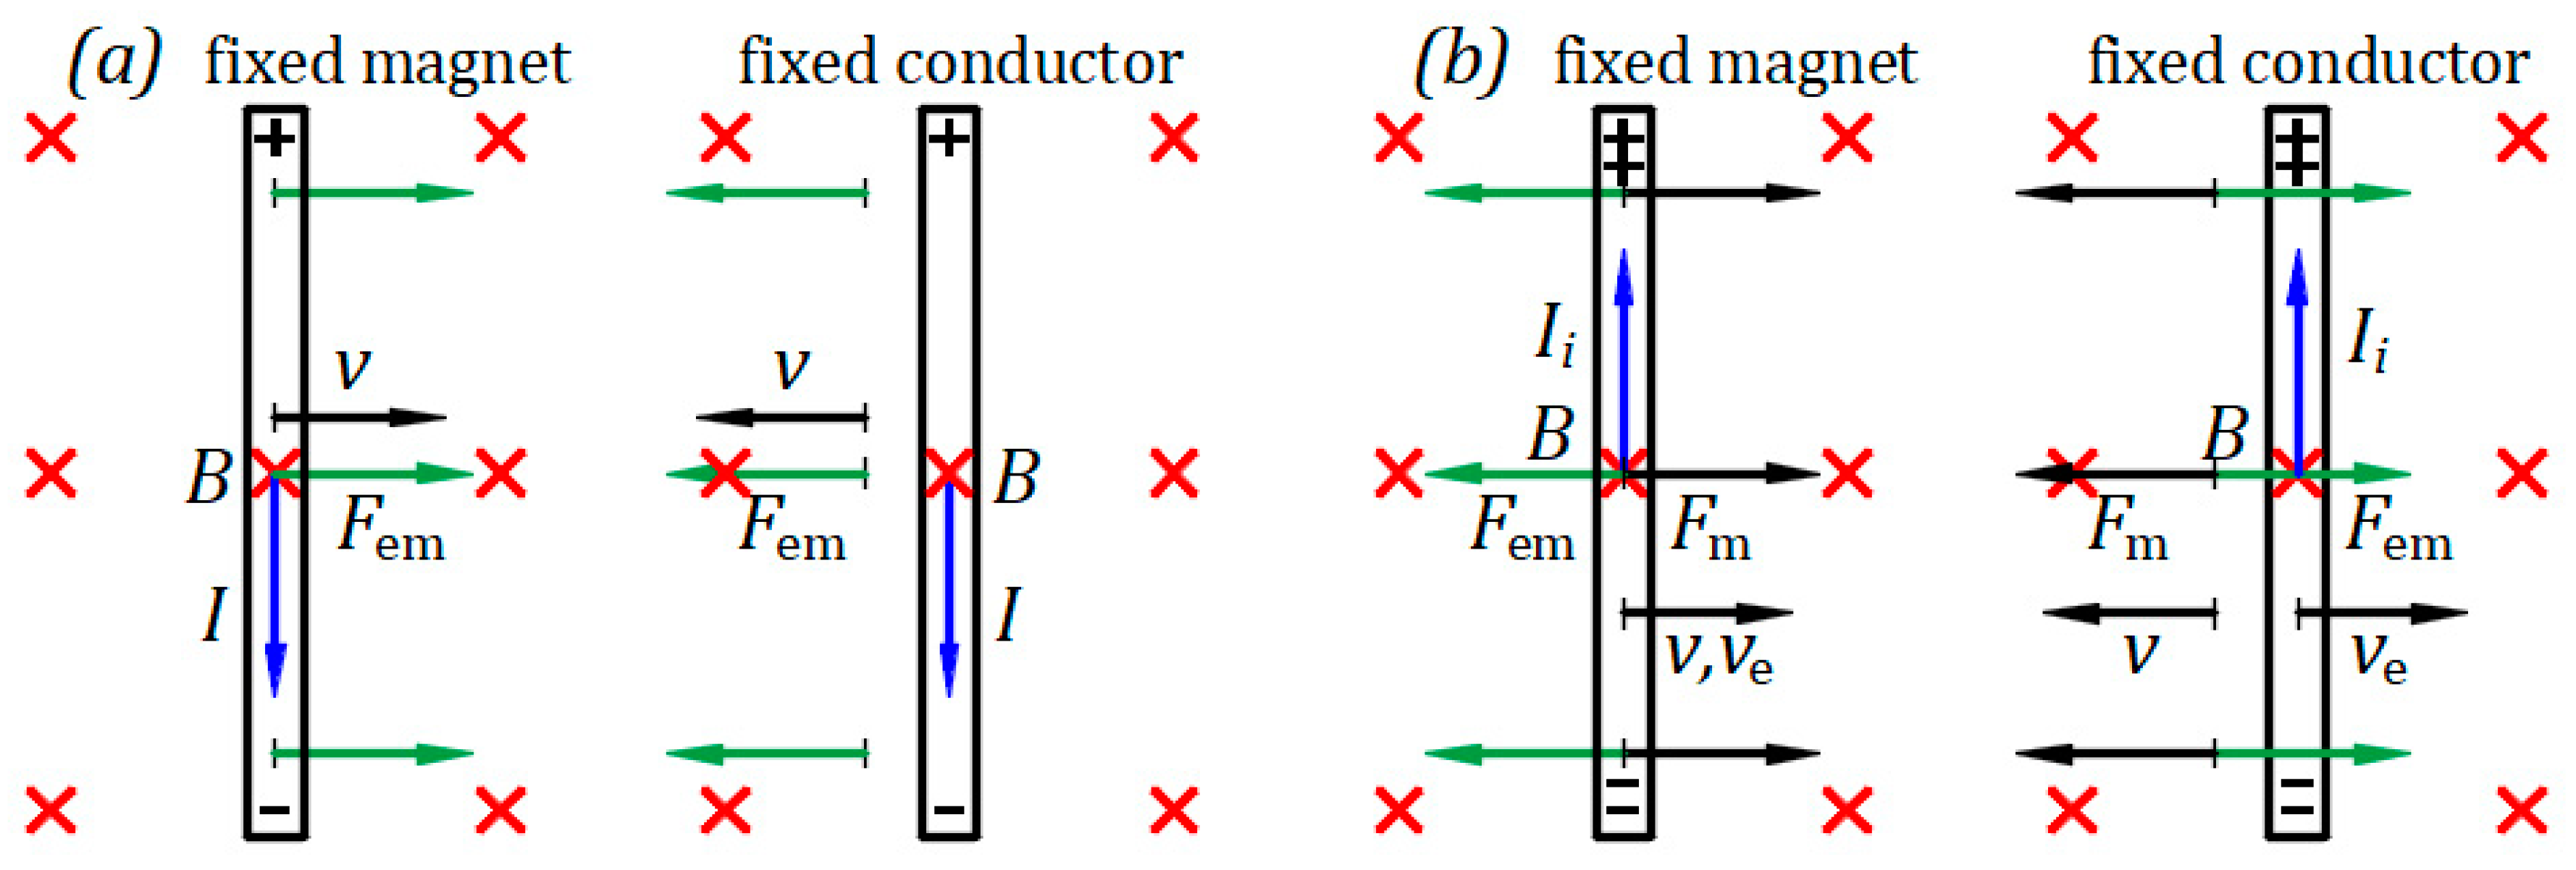
Suppose the conductor is fixed and the magnet has a degree of freedom in the paper plane in both directions perpendicular to the conductor. Connecting the conductor to the source, the source electric field forces current to flow through the conductor from top to bottom. The interaction between the magnetic field and current produces an electromagnetic force of reciprocal repulsion between the conductor and magnet. The Lorentz electromagnetic force is . In this case, of the movable magnet rotated in the short direction over of the fixed conductor yields the direction of the reciprocal repulsive electromagnetic force , which moves the magnet to the left. The inertial force of the magnet acts in the opposite direction of . When the conductor is disconnected from the source, the system enters a state of equilibrium. The motion of the movable magnet may not be visible because its mass is much greater than that of the conductor.
Figure 17(b) illustrates Einstein’s example. At rest or in motion, a magnet does not create an electric field without a conductor. The magnet and conductor must be in proximity and one must be in motion. Einstein understood that an electric field is generated in a fixed conductor in the neighborhood of a moving magnet. Here, we explain that an electric field also arises in a moving conductor near a fixed magnet.
Suppose the magnet is fixed and the conductor has a degree of freedom in the paper plane in both directions perpendicular to the conductor. The conductor connected to a galvanometer is forced to move to the right by a mechanical force at velocity , which is the velocity of electrons from within the conductor. Lorentz’s electromagnetic force is . The fixed magnetic field acts on the moving electrons within the conductor at velocity . The direction of electrons moving to the bottom end of the conductor can be obtained by applying the Lorentz right-hand rule. For this time, we employ the general rule. The velocity of quantity rotated in the short direction over of the fixed magnet gives the moving direction of a positive charge toward the top end of the conductor. The electrons as negative charges are moved to the bottom end of the conductor and the top end becomes positively charged creating an electromotive force (emf) within the conductor. The conductor acts as a source and the induced electric field from the positive to the negative end within the conductor creates an induced current that flows through the galvanometer from the top positive end to the bottom negative end of the conductor.
The interaction of the magnetic field and current produces an electromagnetic force . In this case, of the movable conductor rotated in the short direction over of the fixed magnet yields the direction of the electromagnetic force of reciprocal attraction that opposes . As long as moves the conductor at the velocity , the induced current flows through the galvanometer. When the mechanical force ceases, the system reaches a state of equilibrium with the conductor at rest.
Suppose the conductor connected to the galvanometer is fixed and the magnet has a degree of freedom in the paper plane in both directions perpendicular to the conductor. The magnet is forced to move to the left by mechanical force at velocity . Because the relative velocity of fixed electrons at rest within the conductor concerning the movable magnetic field is velocity , Lorentz’s electromagnetic force has the same form . Therefore, the induction phenomenon is similar to the previous one when the magnet is fixed and the conductor is forced to move. The magnetic field at relative rest acts on electrons within the conductor at the relative velocity . The relative velocity of quantity rotated in the short direction over of the relative fixed magnet gives the moving direction of a positive charge toward the top end of the conductor. The electrons as negative charges are moved to the bottom end of the conductor and the top end becomes positively charged creating an electromotive force (emf) within the conductor. The conductor acts as a source and the induced electric field from the positive to the negative end within the conductor creates an induced current that flows through the galvanometer from the top positive end to the bottom negative end of the conductor.
The interaction of the magnetic field with the current produces an electromagnetic force . In this case, of the movable magnet rotated in the short direction over of the fixed conductor provides the direction of the electromagnetic force of reciprocal attraction which opposes . As long as moves the magnet at the velocity , the induced current flows through the galvanometer. When the mechanical force stops, the system enters a state of equilibrium with the magnet at rest.
References
- Filipescu F. D. Reflection of Light as a Mechanical Phenomenon Applied to a Particular Michelson Interferometer. Preprints 2020, 2020090032. [CrossRef]
- Filipescu F. D. Opposing hypotheses of the reflection of light applied to the Michelson interferometer with a particular geometry. Phys. Essays 2021, 34, 3, 268-273. [CrossRef]
- Filipescu F. D. Opposing hypotheses of the reflection of light applied to the Michelson interferometer. Phys. Essays 2021, 34, 3, 389-396.
- Filipescu F. D. Emission, propagation, and reflection of light as mechanical phenomena in inertial frames. Phys. Essays 2021, 34 587-590. [CrossRef]
- Filipescu F. D. Observation of a star orbit based on the emission and propagation of light as mechanical phenomena. Phys. Essays 2022, 35, 2, 111. [CrossRef]
- Filipescu F. D. Emission, propagation, and reflection of light as mechanical phenomena. Preprints 2022, 2022040061. [CrossRef]
- Filipescu F. D. Emission, propagation, and reflection of light as mechanical phenomena: General considerations. Phys. Essays 2022, 35, 3, 266-269. [CrossRef]
- Filipescu F.D. Velocity of light through a moving medium applied to the Fizeau experiment. Phys. Essays 2023, 36, 1, 90-93. [CrossRef]
- Filipescu F. D. Reflection of light as a mechanical phenomenon applied to the Michelson interferometer with sunlight as a source. Preprints 2022, 2022080472. [CrossRef]
- Filipescu F. D. Reflection of light as a mechanical phenomenon applied to the Michelson interferometer with sunlight as a source. Phys. Essays 2023, 36, 2, 223-229. [CrossRef]
- Filipescu F. D. Airy’s experiment and the dragging of light by a moving medium. Phys. Essays 2023, 36, 3, 274-276. [CrossRef]
- Filipescu F. D. Emission, propagation, and reflection of light as mechanical phenomena applied to the Majorana experiment. Phys. Essays 2023, 36, 4, 361-368. [CrossRef]
- Filipescu F. D. Experiment on the reflection and emission of light. Phys. Essays 2024, 37, 1, 64-70. [CrossRef]
- Michelson A. A., Morley E. W. On the relative motion of the earth and the luminiferous ether. Am. J. Sci. 1887, s-3-34(203), 333–345.
- Ritz W. Recherches critiques sur l’Électrodynamique Générale. Ann. Chim. Phys. 1908, 8, 145. English translation: http://www.shadetreephysics.com/crit/1908a.htm.
- Alvager T., Farley F. J. M., Kjellman J., and Wallin L. Test of the second postulate of special relativity in the GeV region. Phys. Lett. A. 1964 12, 260-262. [CrossRef]
- De Sitter W. A proof of the constancy of the velocity of light. Proc. R. Neth. Acad. Arts and Sci. 1913, 15(II), 1297-1298.
- De Sitter W. On the constancy of the velocity of light. Proc. R.Neth. Acad. Arts and Sci. 1913, 16, 395-396.
- Miller D. C. Ether-Drift Experiments at Mount Wilson. Proc. Natl. Acad. Sci. U. S. A. 1925 11, 306-314. [CrossRef]
- G. B. Airy. On a supposed alteration in the amount of Astronomical Aberration of Light, produced by the passage of the Light through a considerable thickness of Refracting Medium. Proc. R. Soc. Lond. 1871, 20, 35.
- Majorana Q. On The Second Postulate of the Theory of Relativity: An Experimental Demonstration of the Constancy of the Velocity of Light Reflected by a Moving Mirror. Phys. Rev. 1918, 11, 411. [CrossRef]
- Einstein A. Zur Elektrodynamik bewegter Körper. AdP 1905 322 (10): 891921. English translation: https://www.fourmilab.ch/etexts/einstein/specrel/specrel.pdf.
- Lorentz H. A. The Relative Motion of the Earth and the Aether. Zittingsverlag Akad. V. Wet. 1892 (1), 74. https://en.wikisource.org/wiki/Translation:The_Relative_Motion_of_the_Earth_and_the_Aether.
- FitzGerald G. F. Letters to the editor. 1889. https://www.science.org/doi/10.1126/science.ns-13.328.390.a. [CrossRef]
- N. Bărbulescu, Physics foundations of Einsteinian relativity (St. & Enc. ed. Bucharest, Romania 1975), pp. 74-77.
Figure 1.
Balls brought from rest to a velocity .
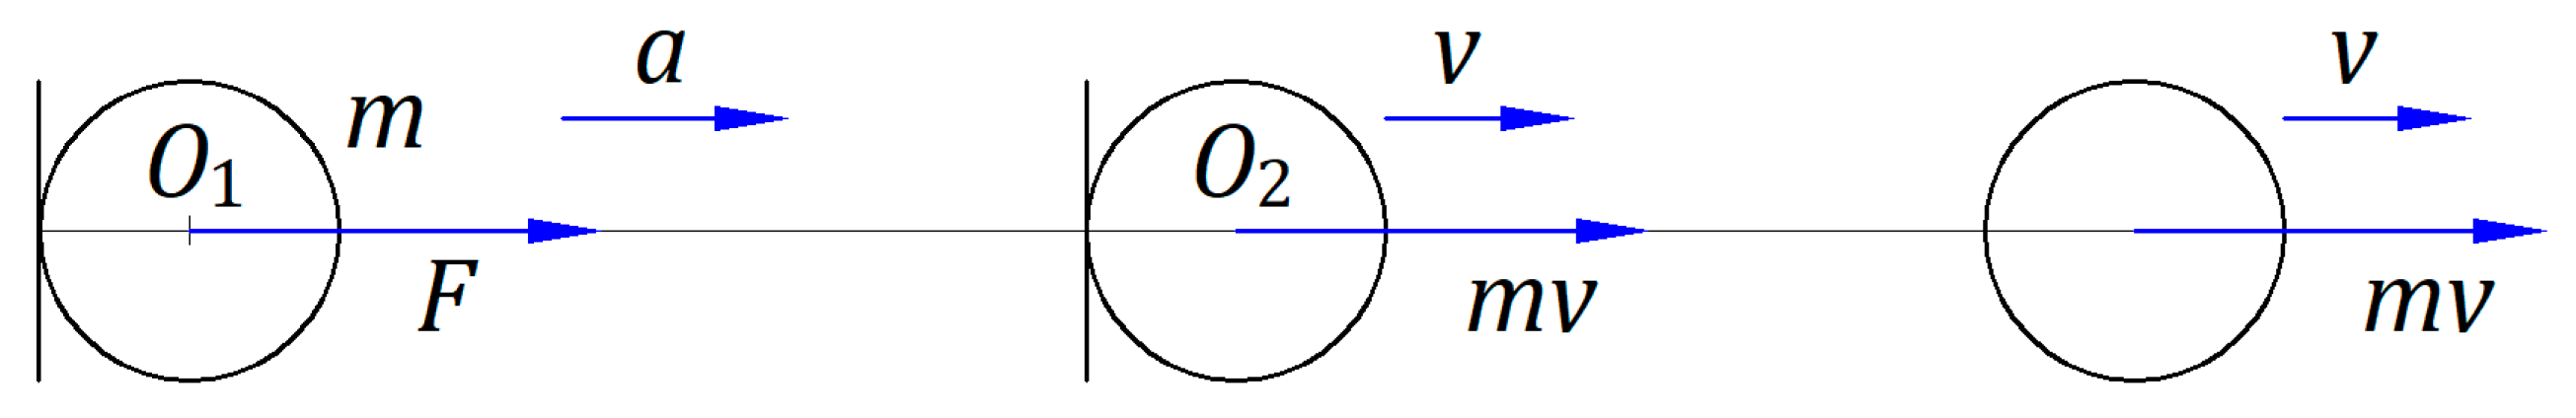
Figure 2.
Balls emitted at a velocity by a moving source at a velocity .
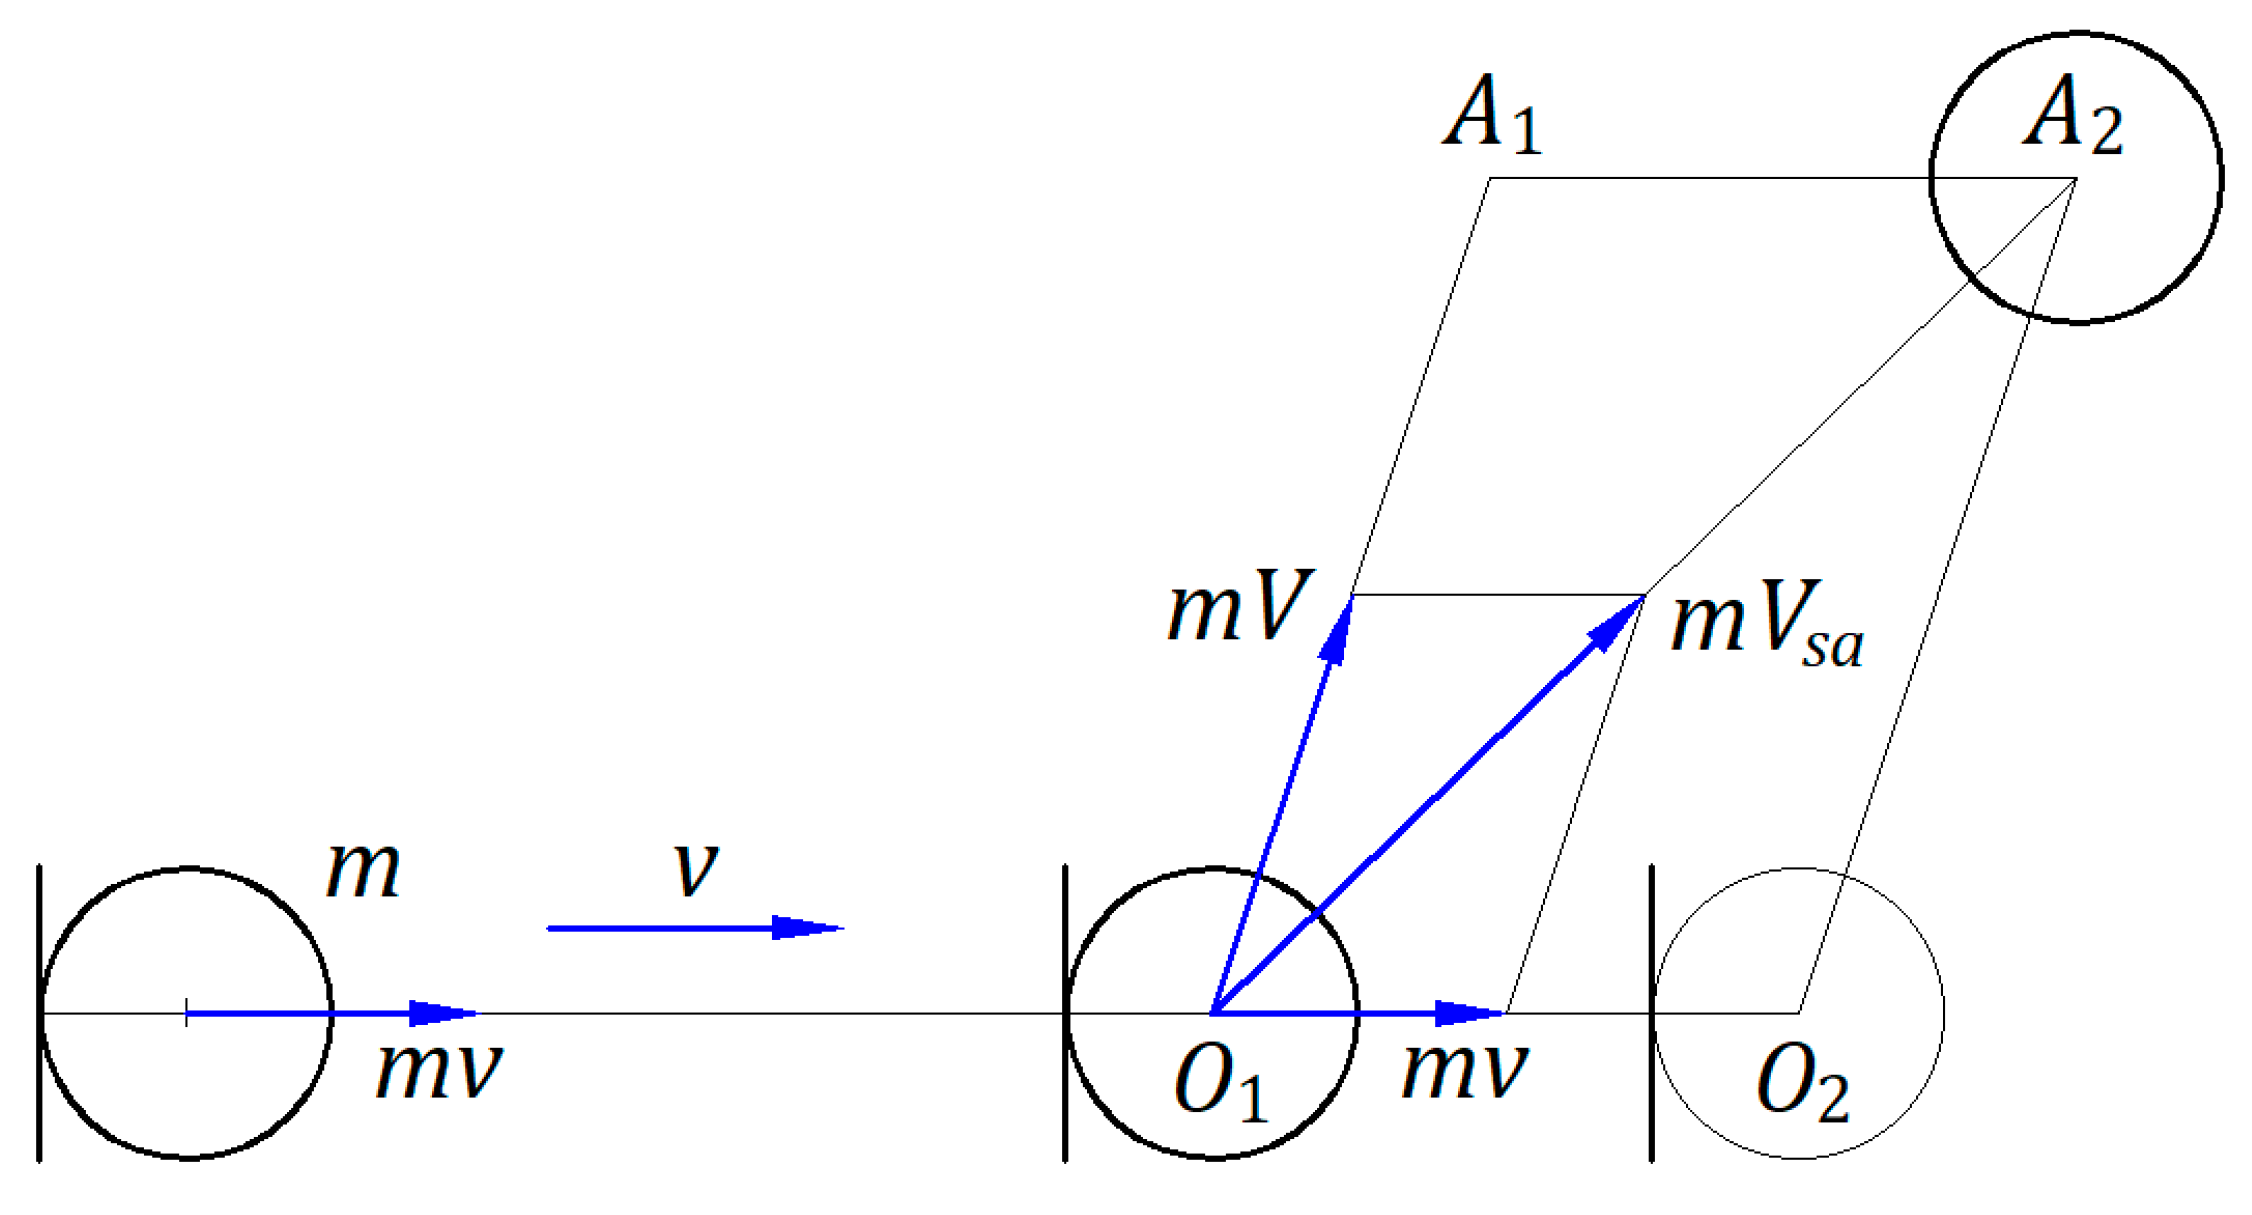
Figure 3.
Ballistic law applied to balls emitted by a source in motion.
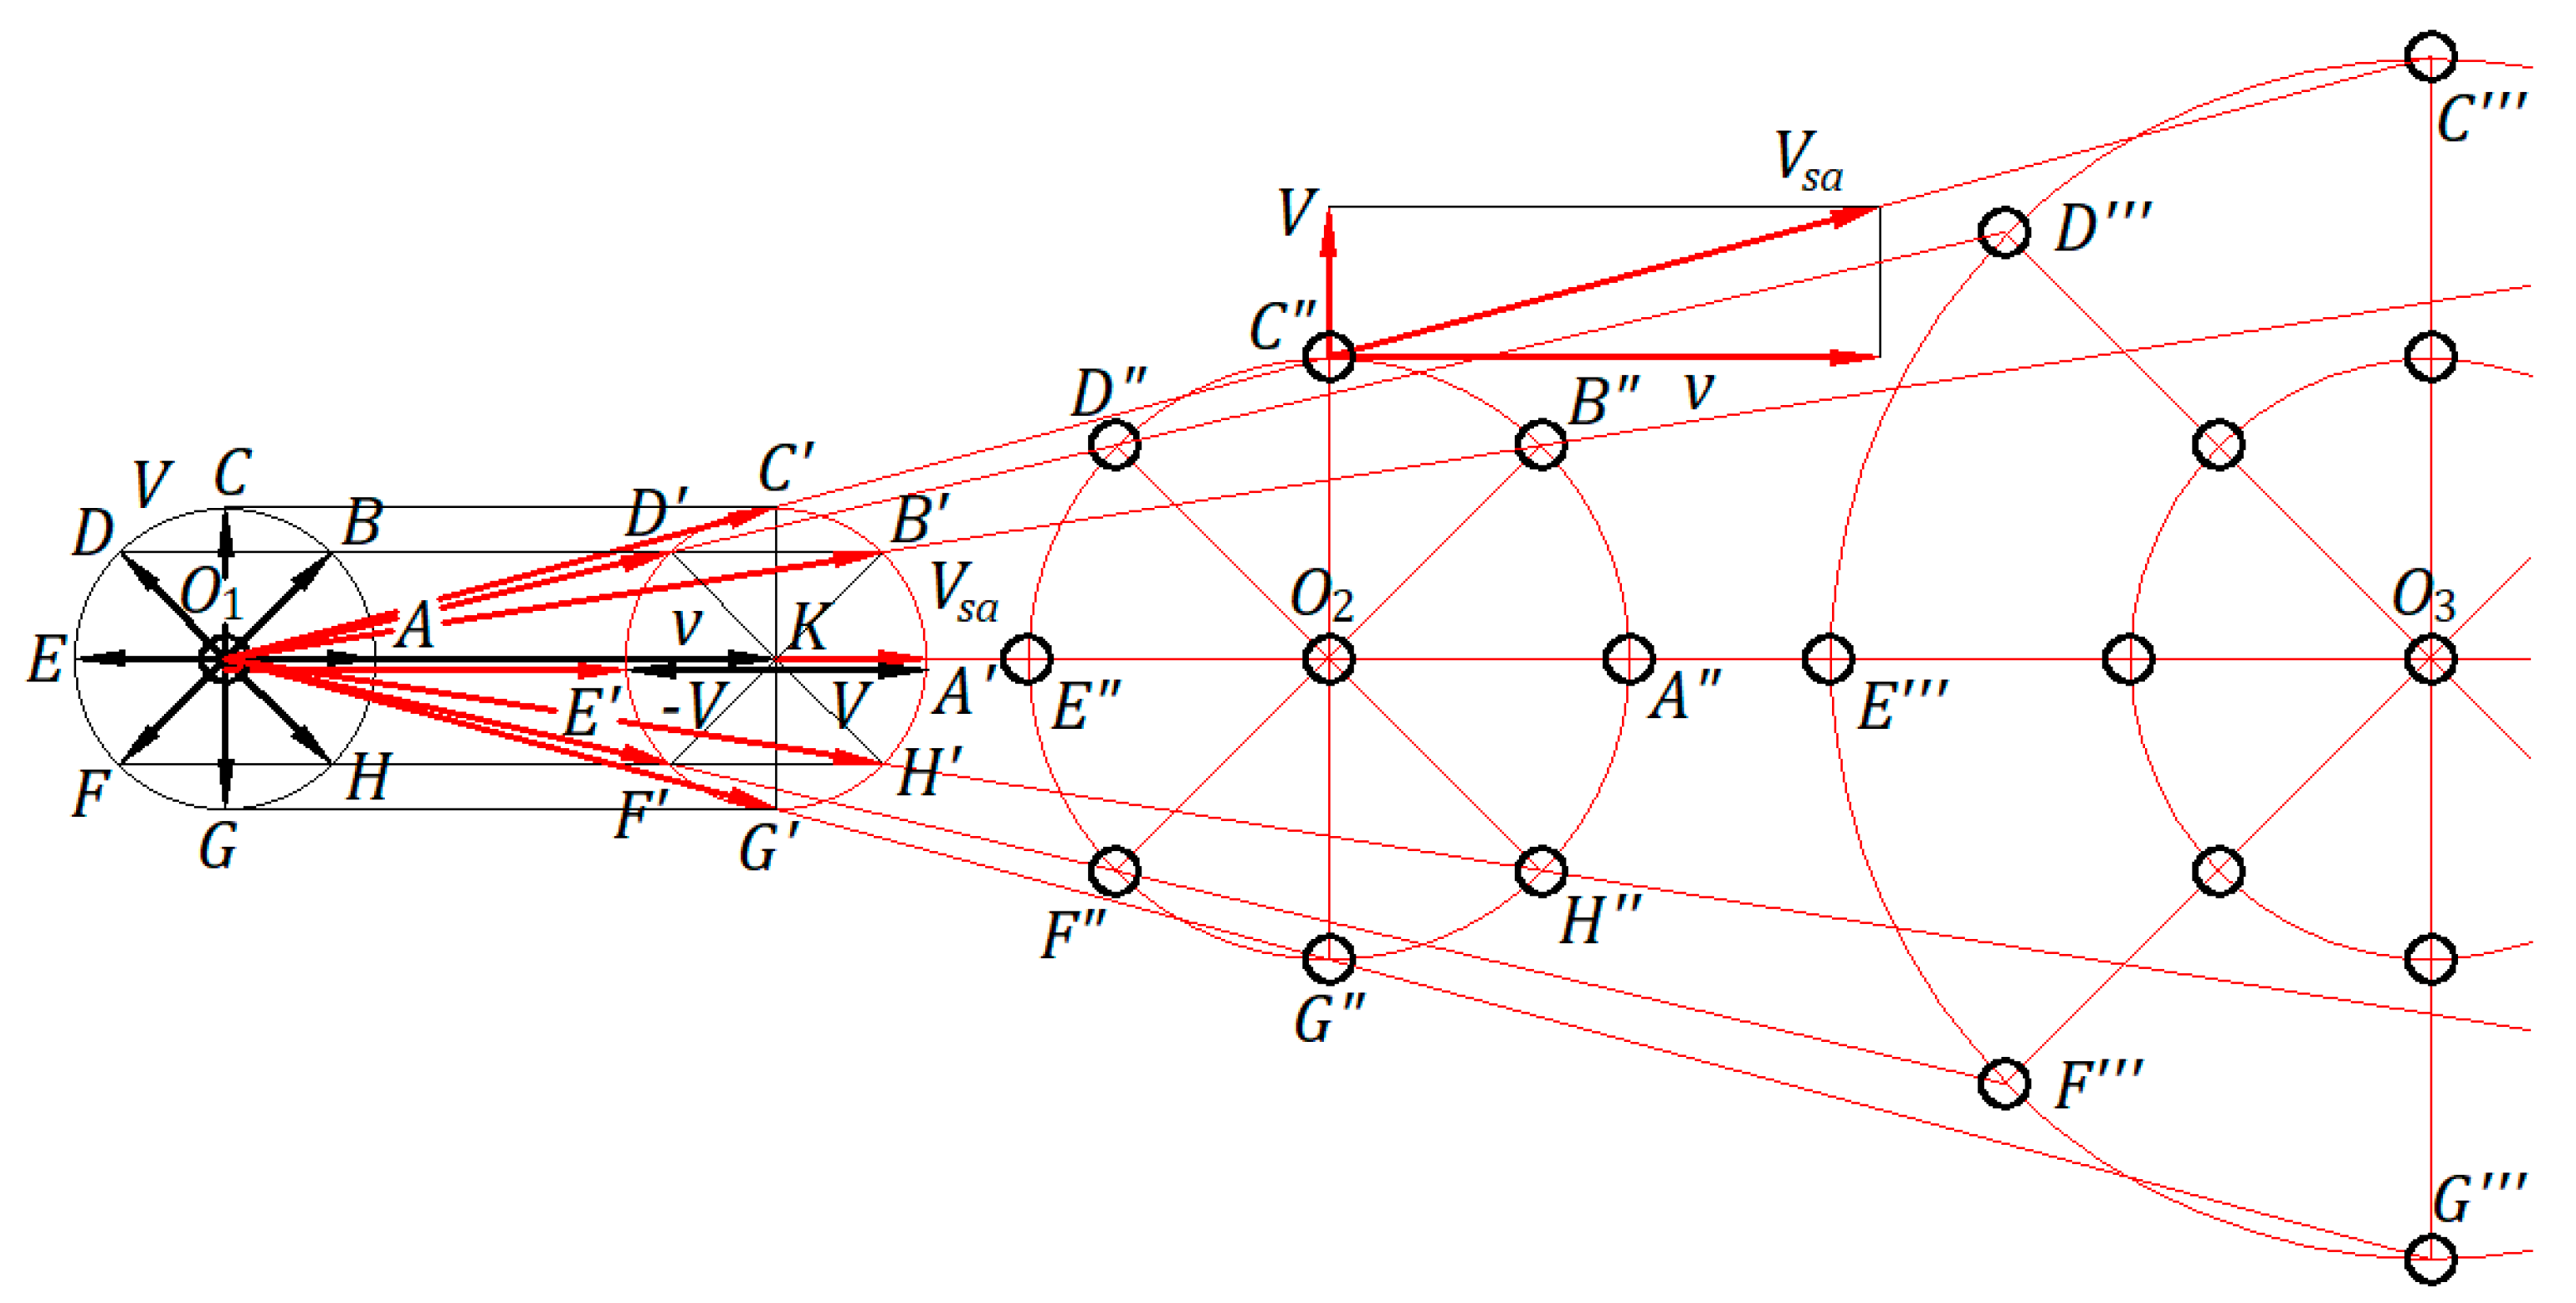
Figure 4.
Elastic collision of two balls moving in opposite directions.
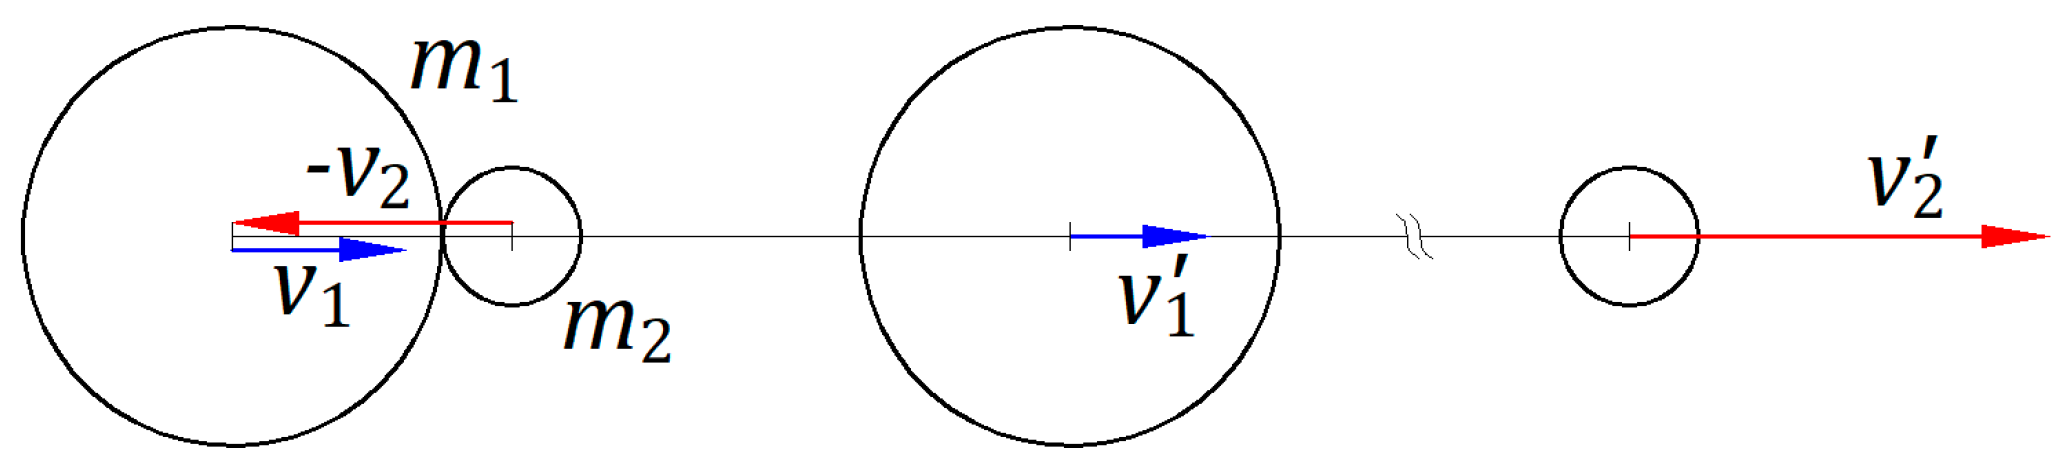
Figure 5.
Elastic collision of a wall and ball moving in opposite directions.
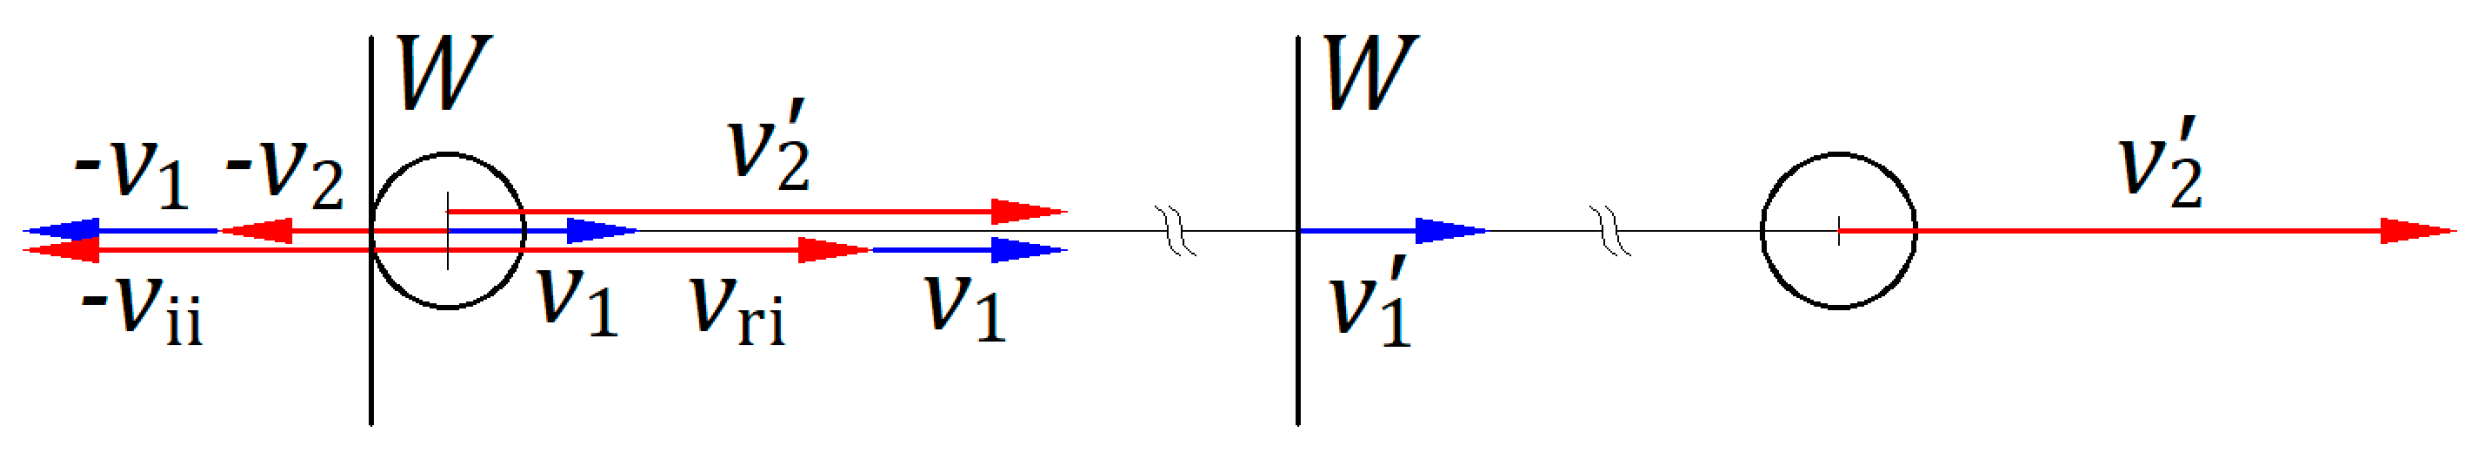
Figure 6.
Elastic reflection of a ball by a moving wall.
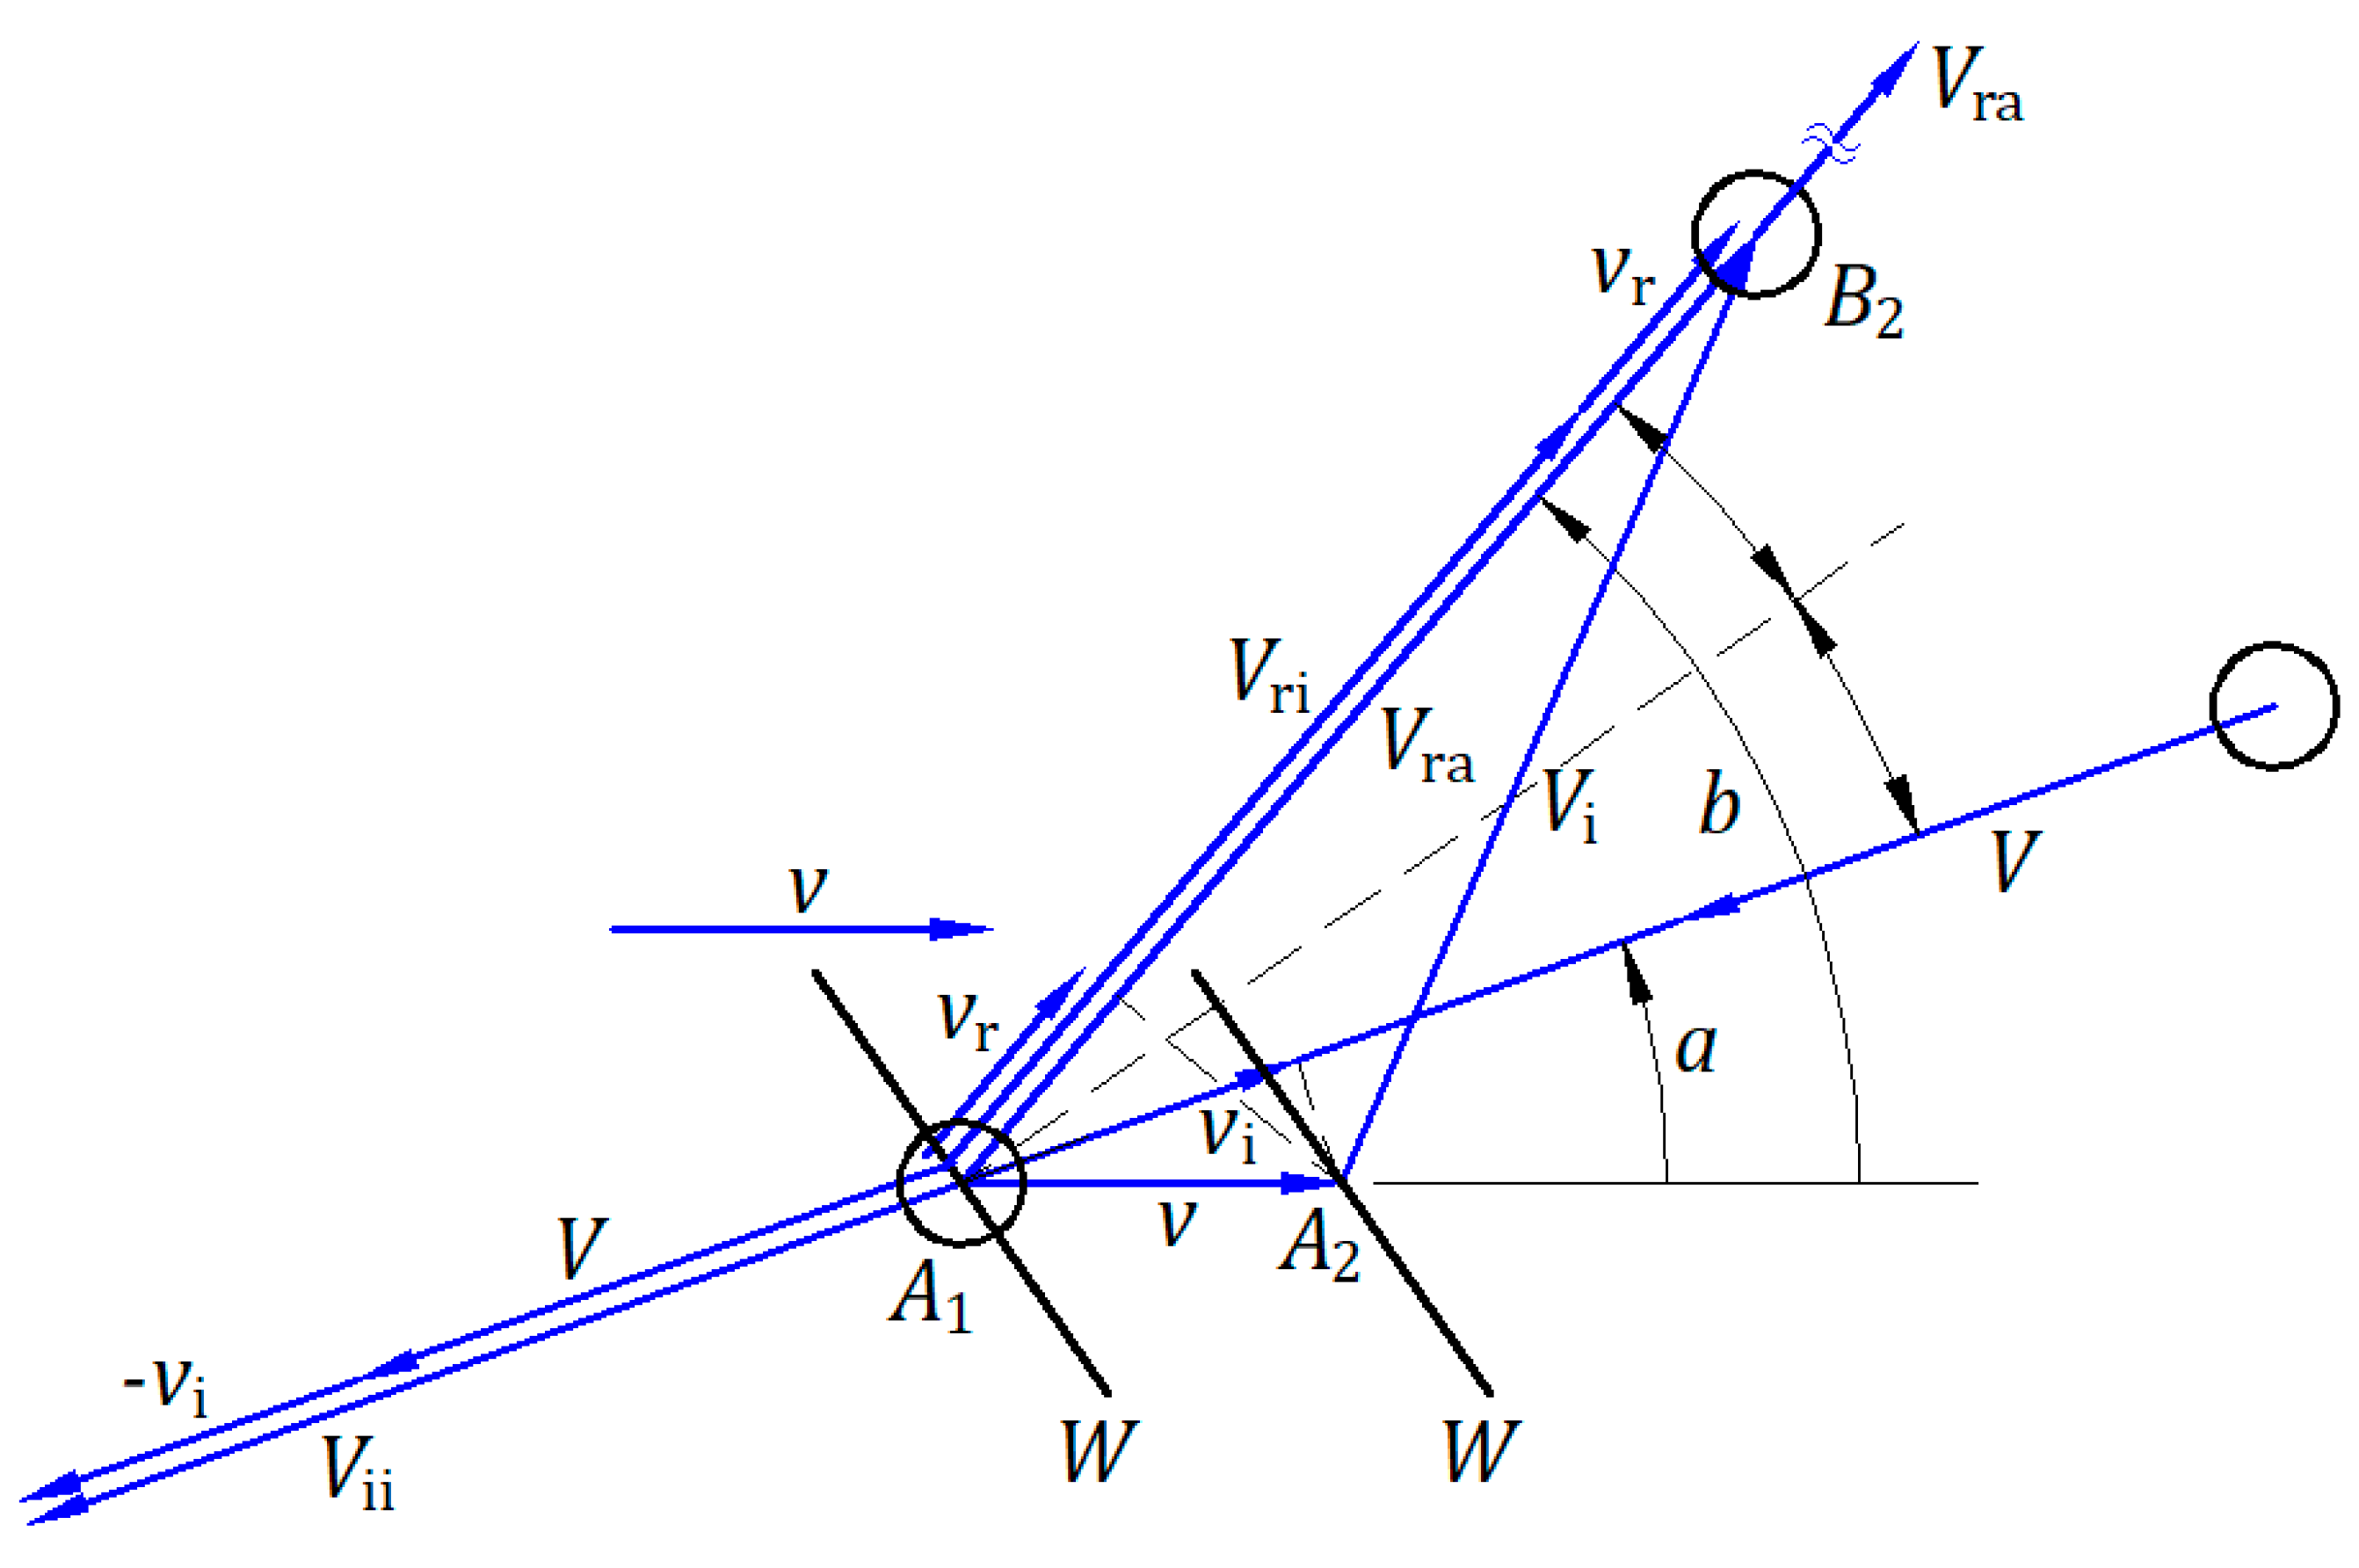
Figure 7.
Emission, propagation, and reflection of balls in the absolute and an inertial frame.
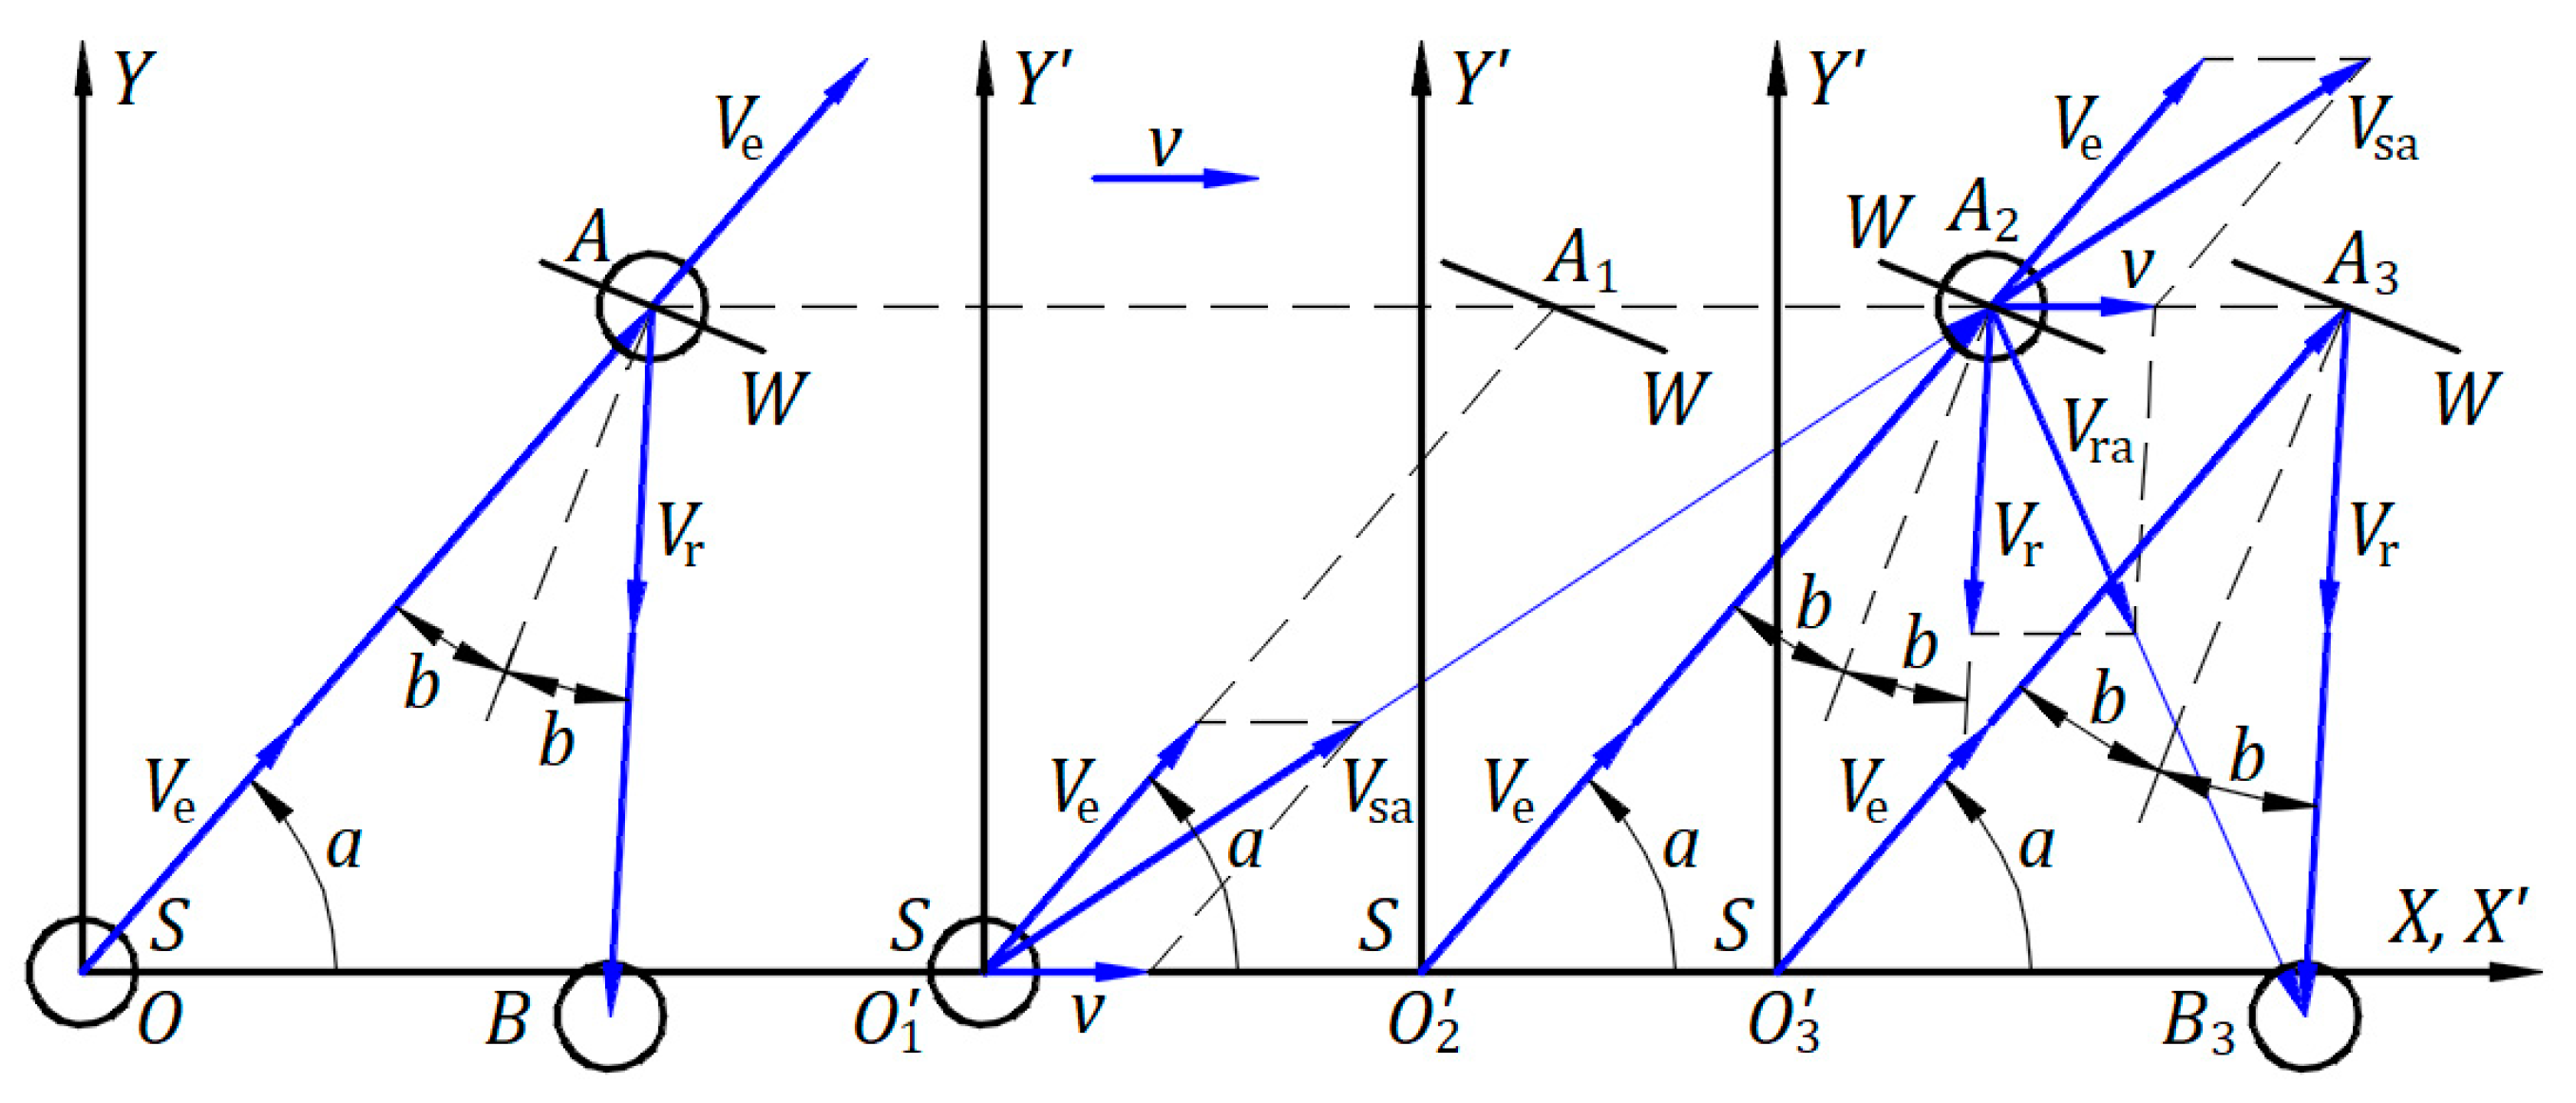
Figure 8.
Ballistic law applied to light emitted by a source in motion.
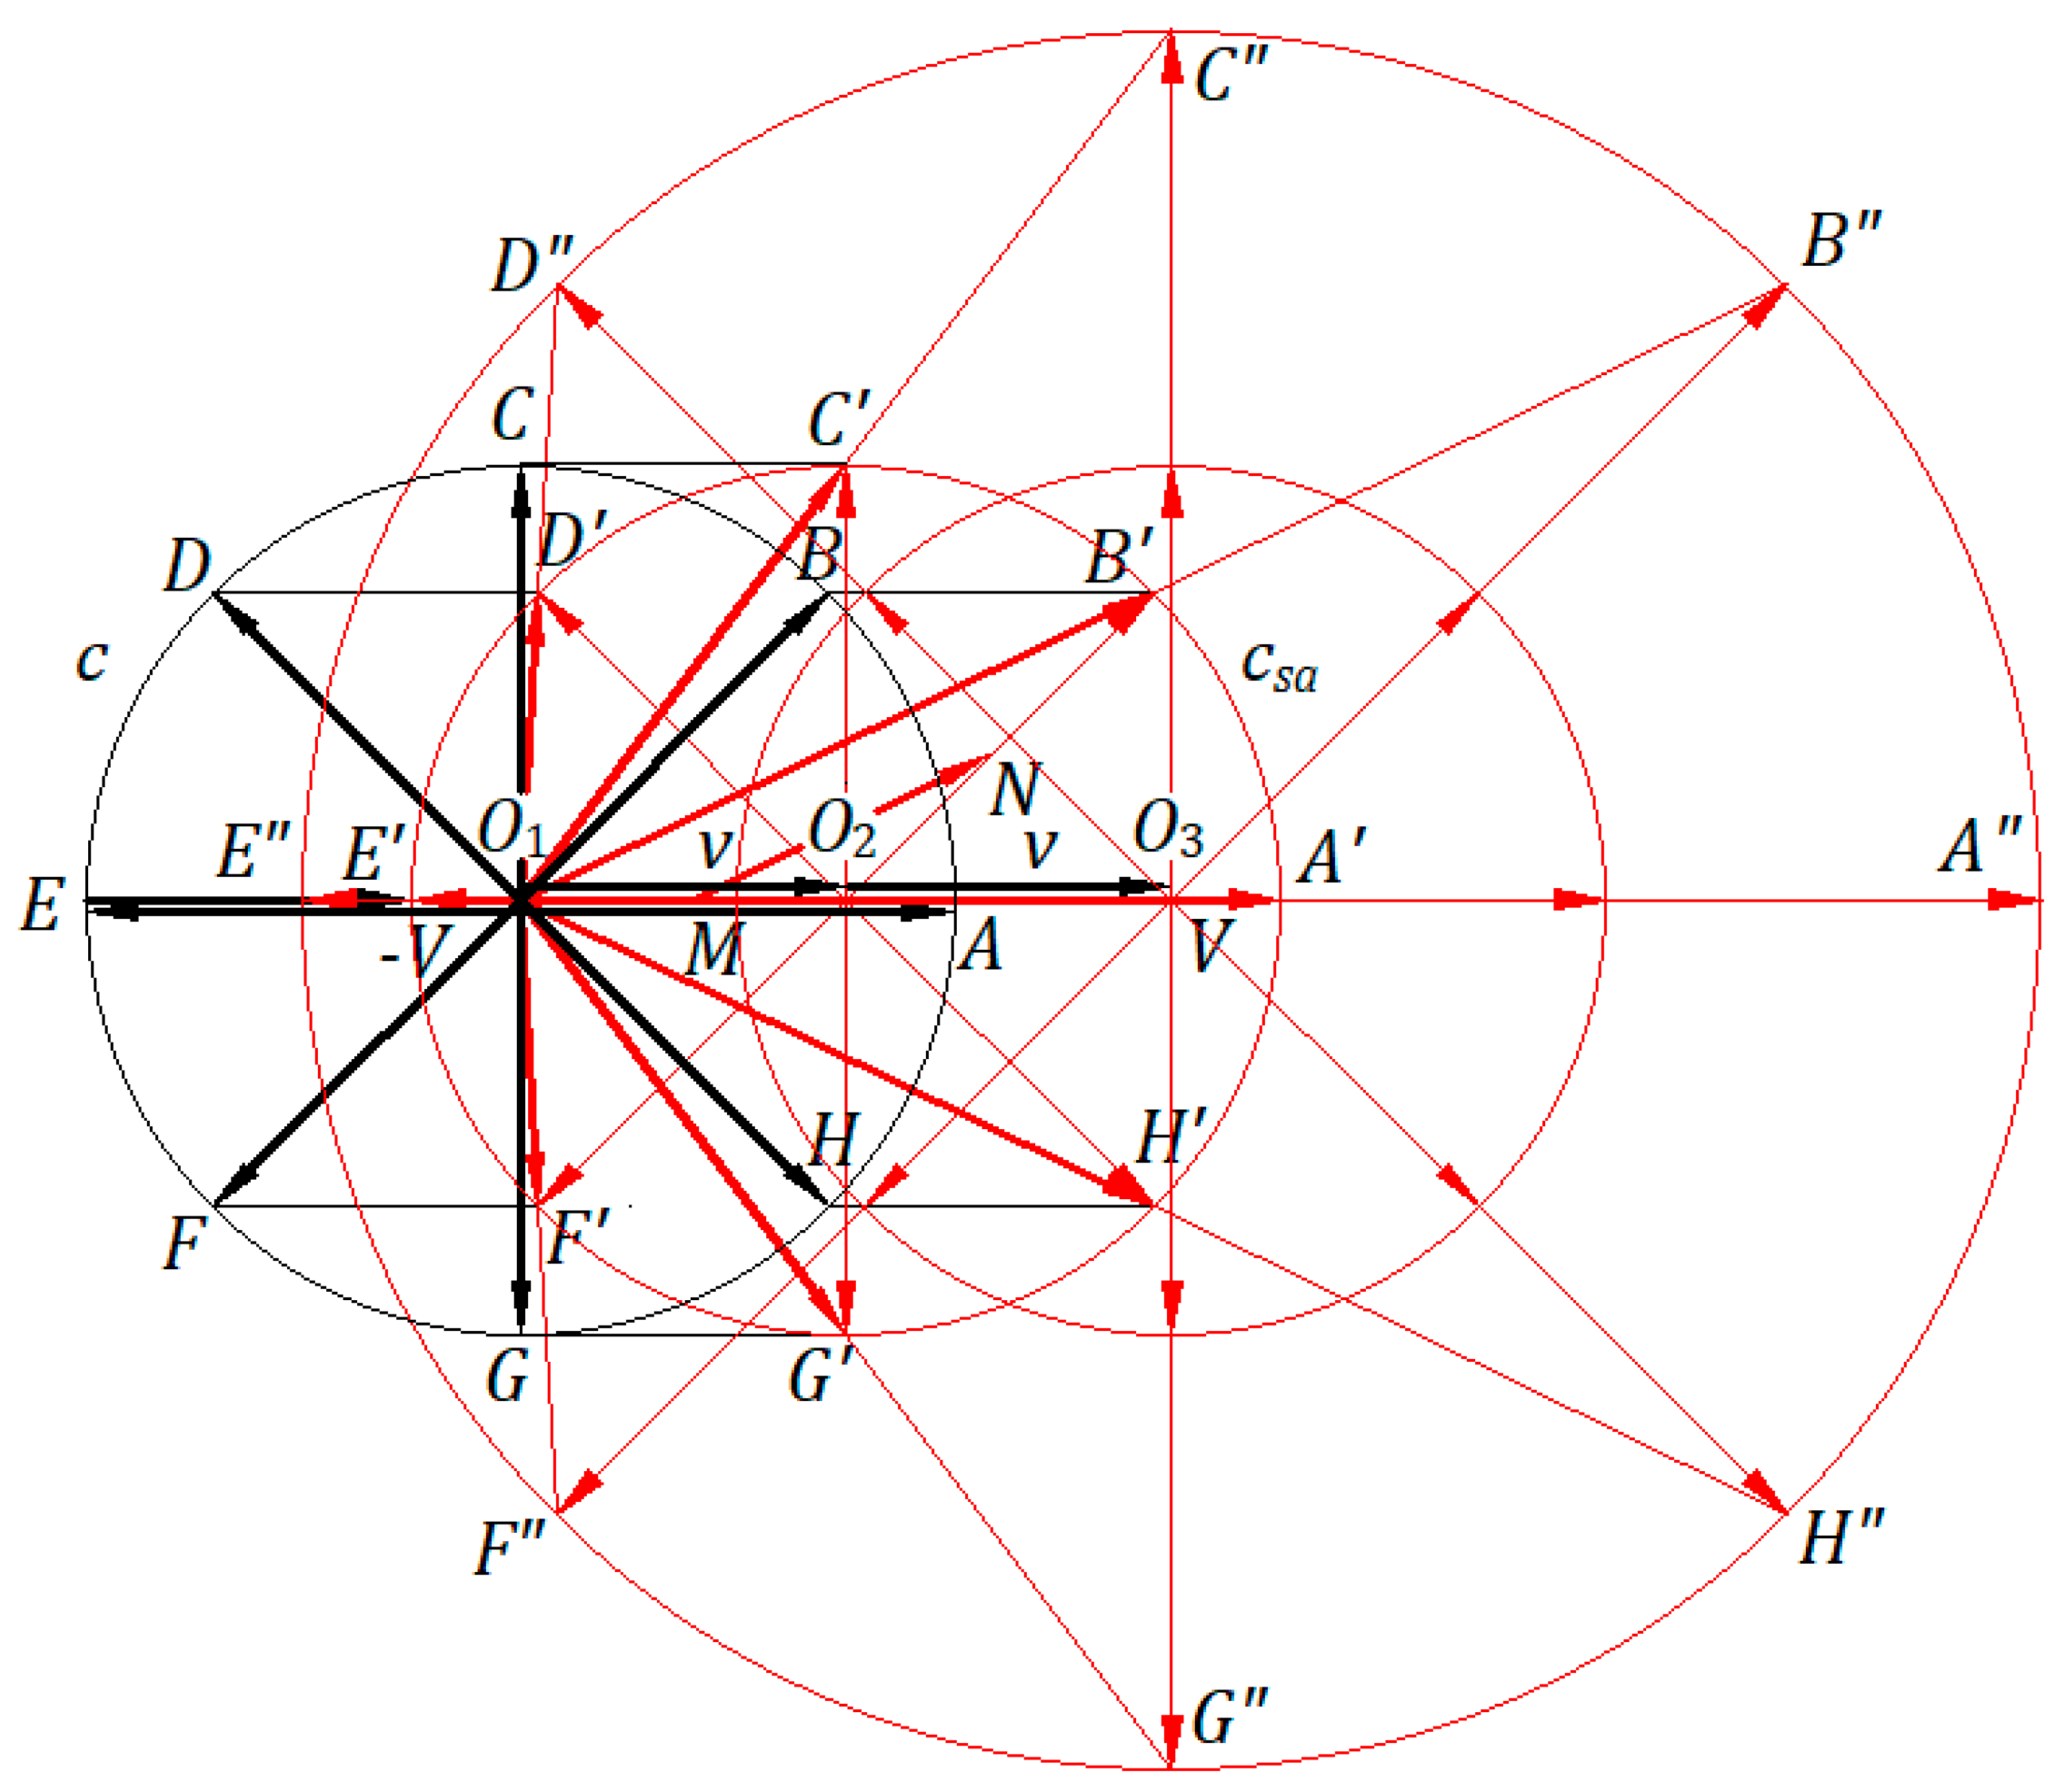
Figure 9.
Reflection of light by a moving mirror.
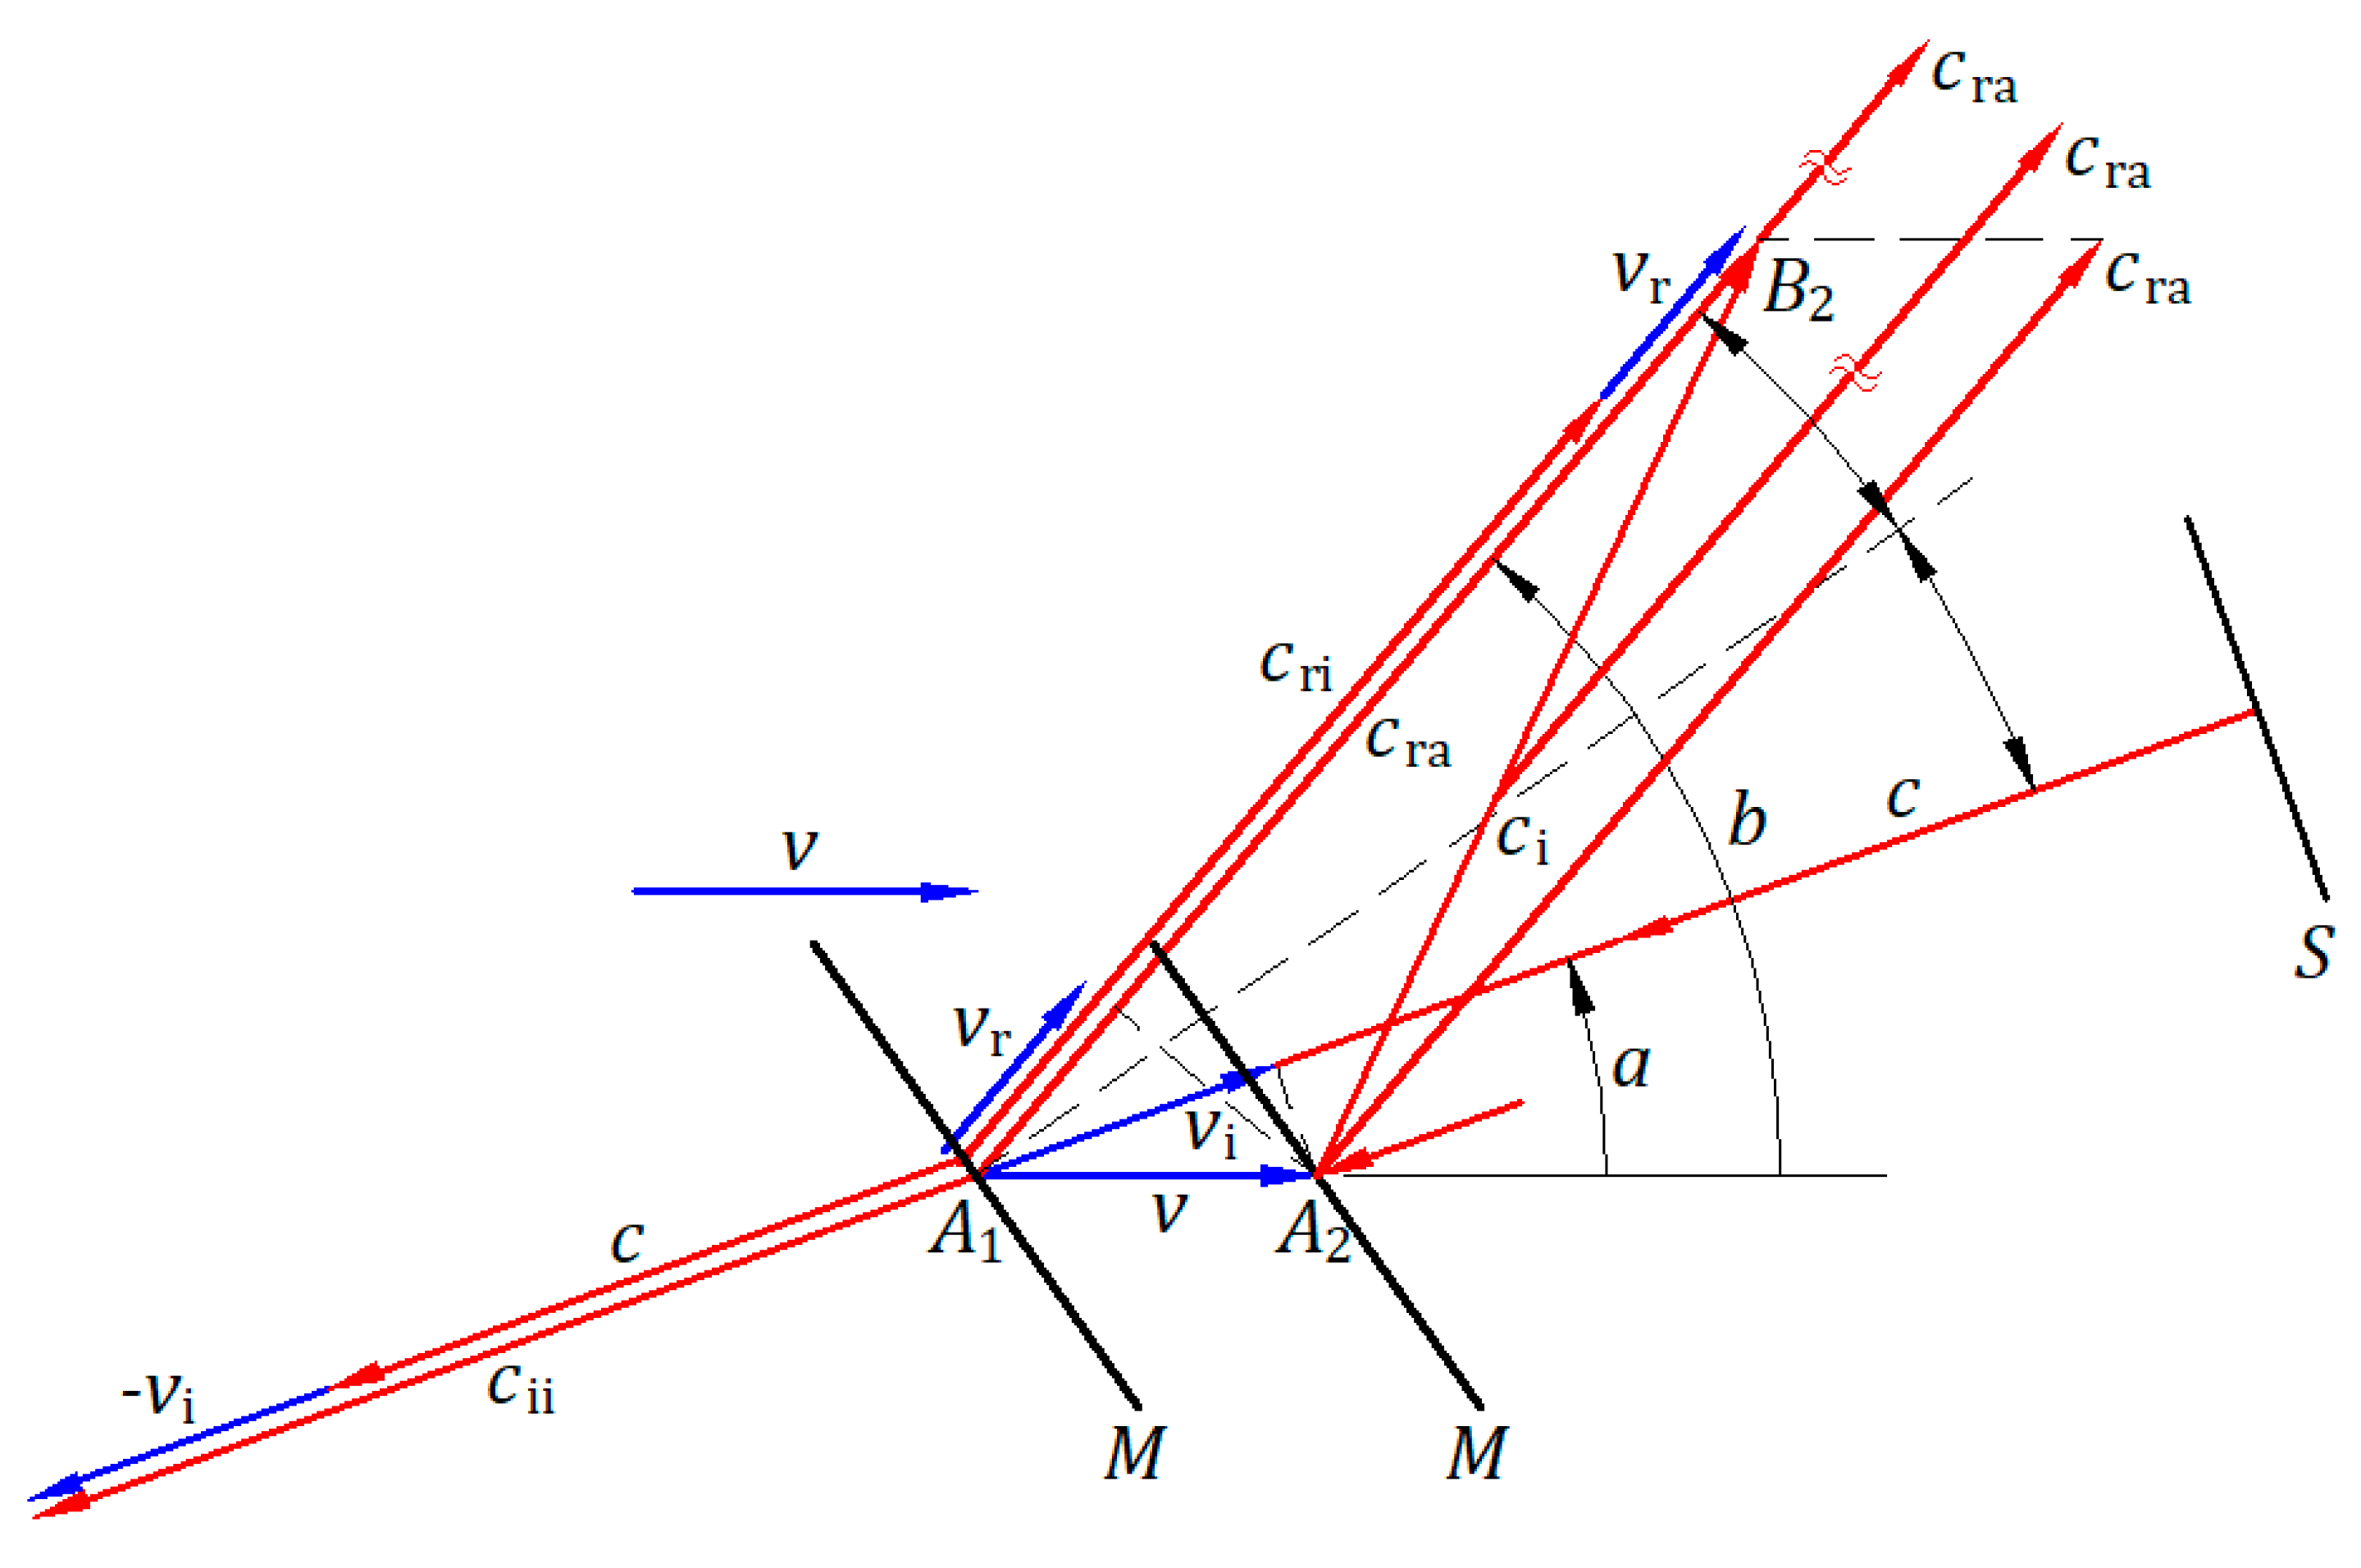
Figure 10.
Emission, propagation, and reflection of light in the absolute and an inertial frame.
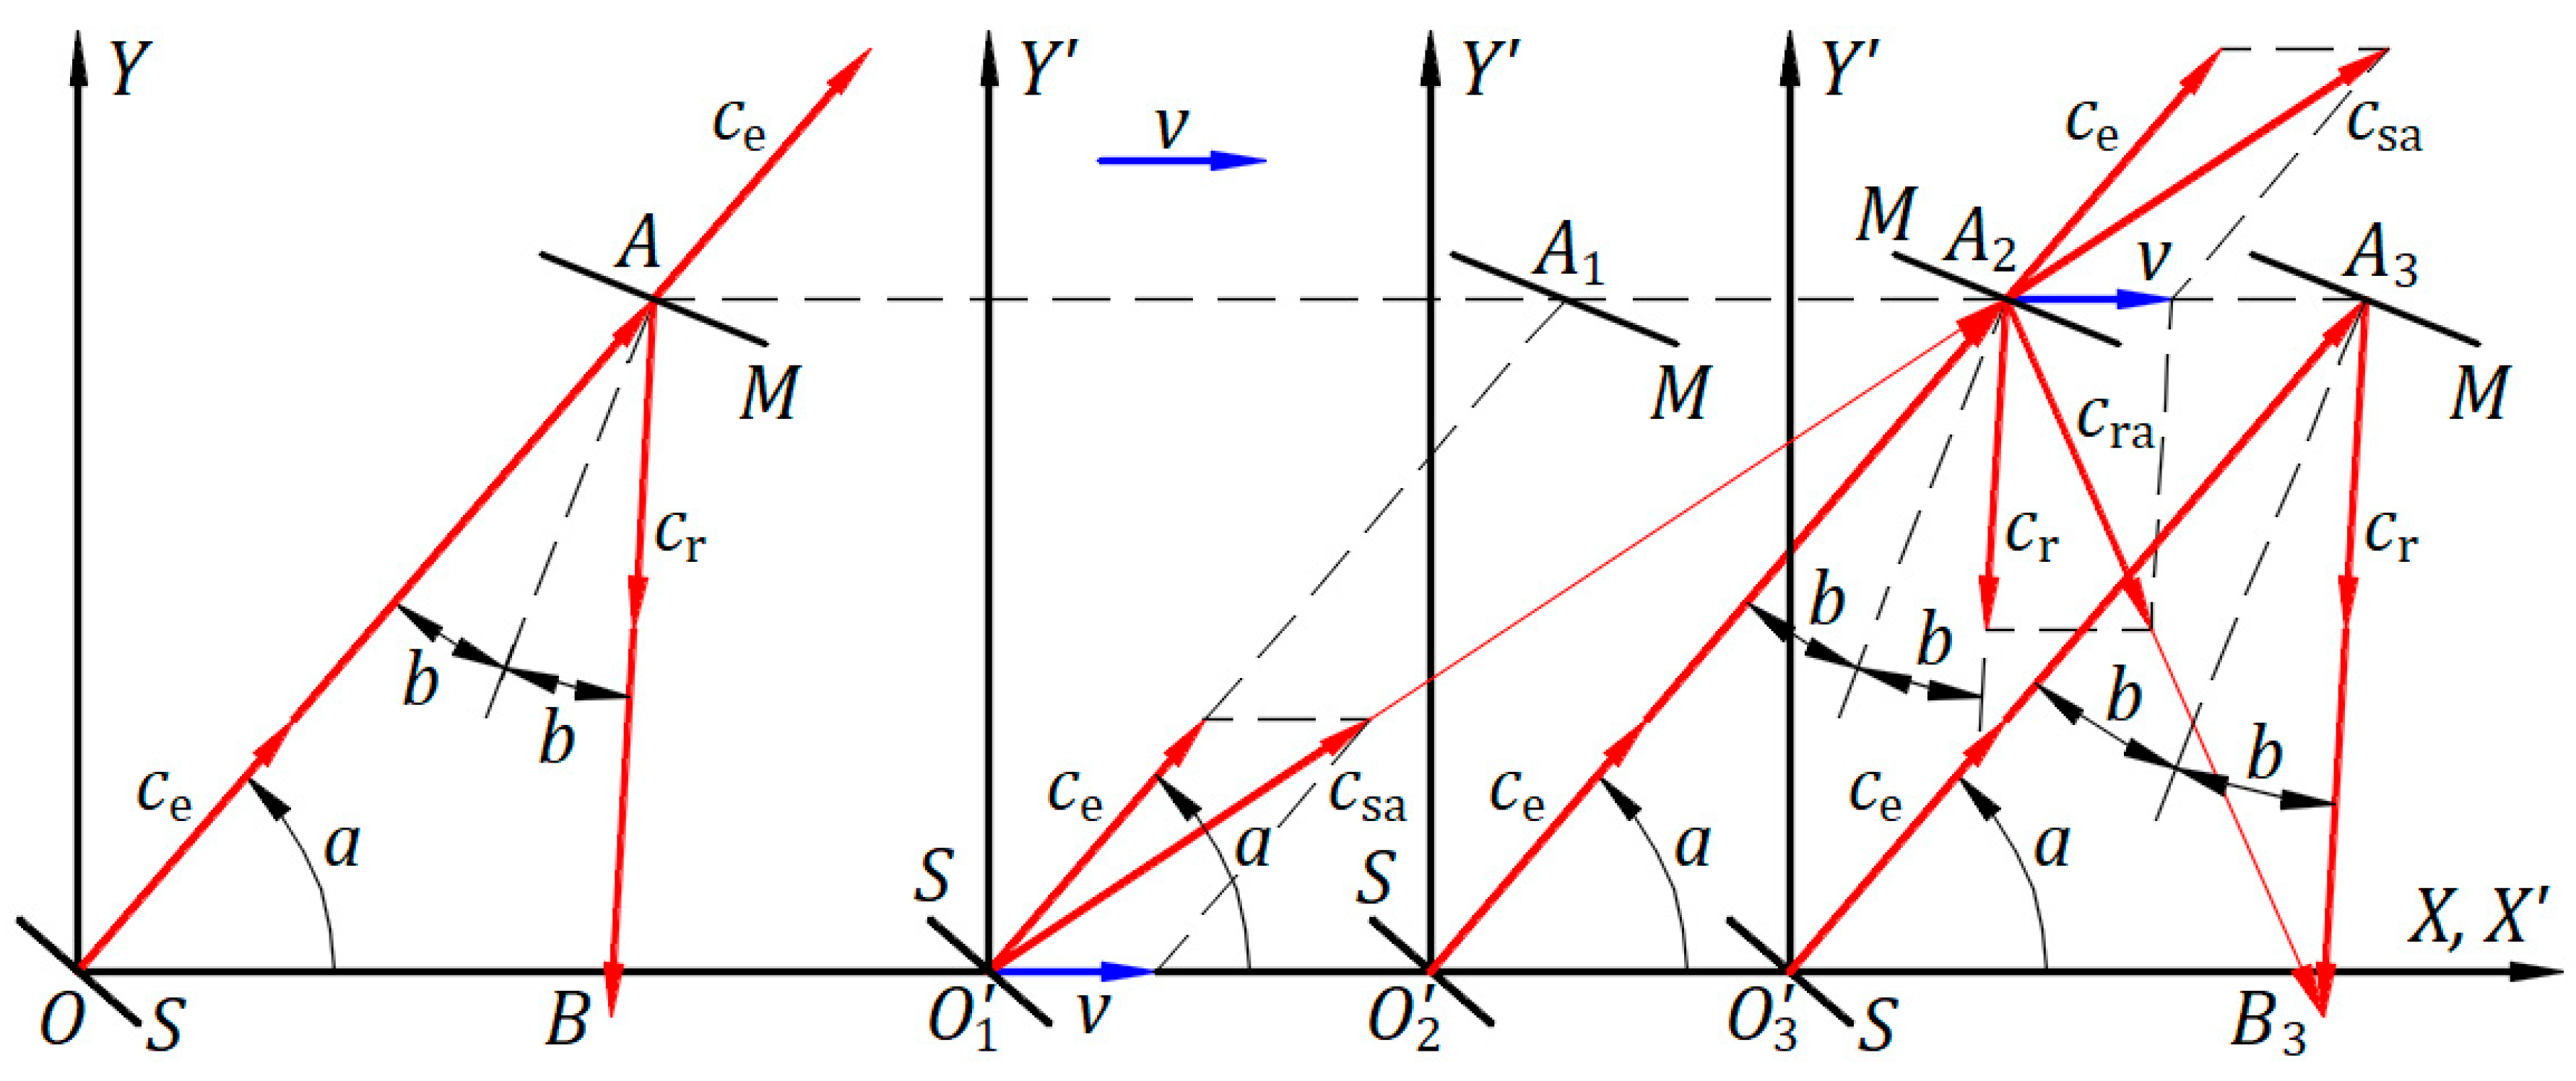
Figure 11.
A boson as a carrier decaying at a mechanical speed near the speed of light .
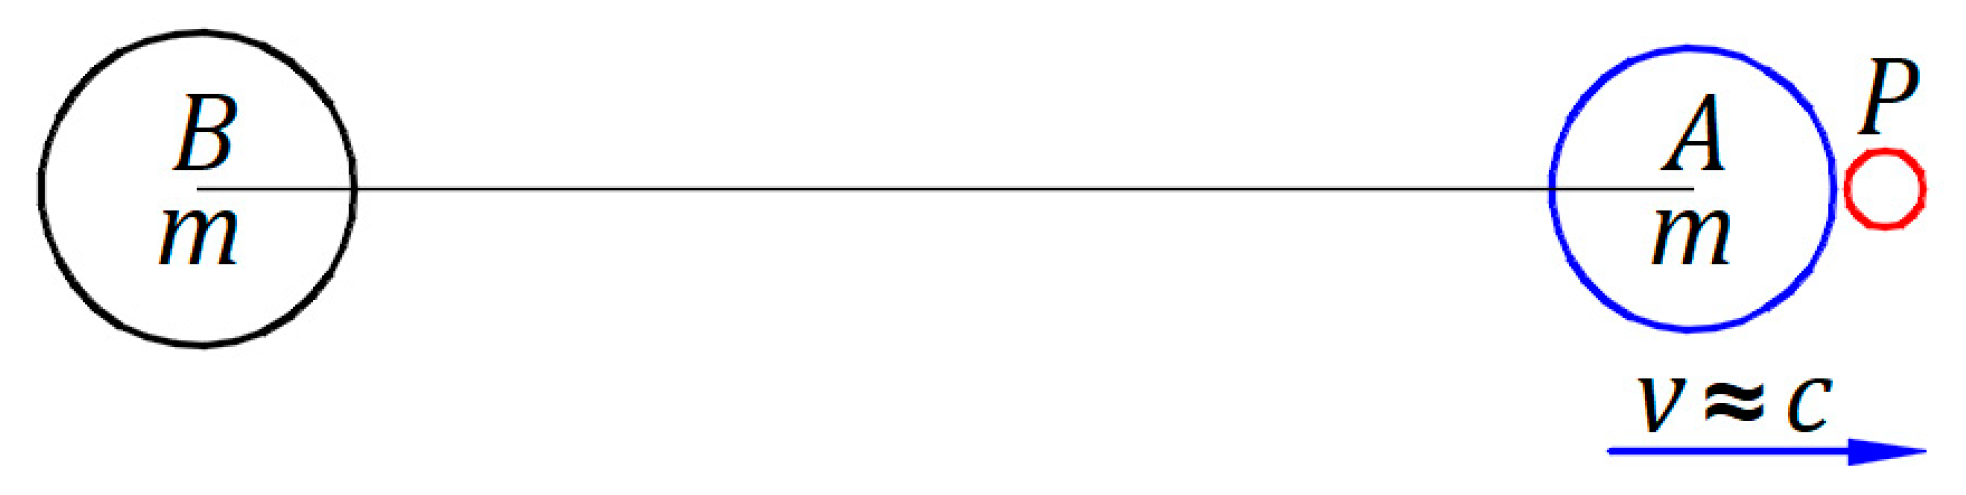
Figure 12.
Observation of a star in the universe considering (a) the dragging of light and (b) the constancy of light.
Figure 12.
Observation of a star in the universe considering (a) the dragging of light and (b) the constancy of light.
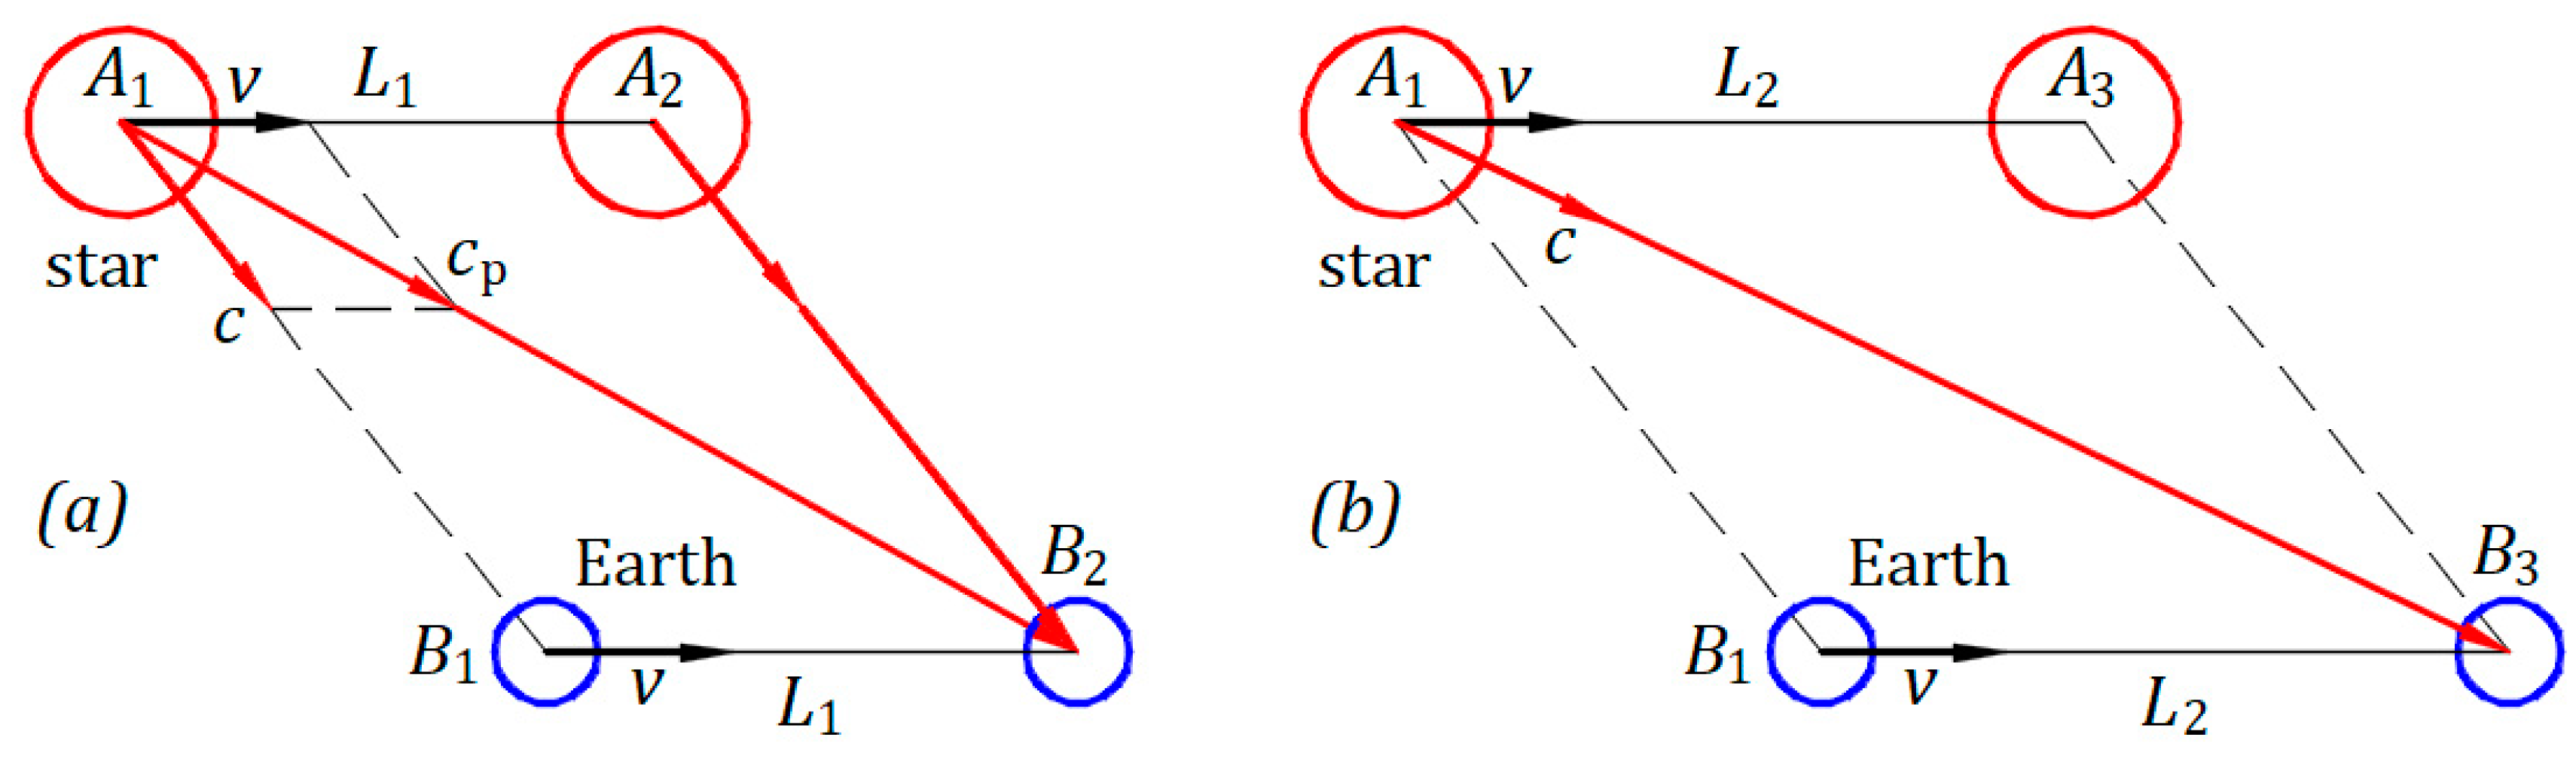
Figure 13.
Observation of a star’s orbit.
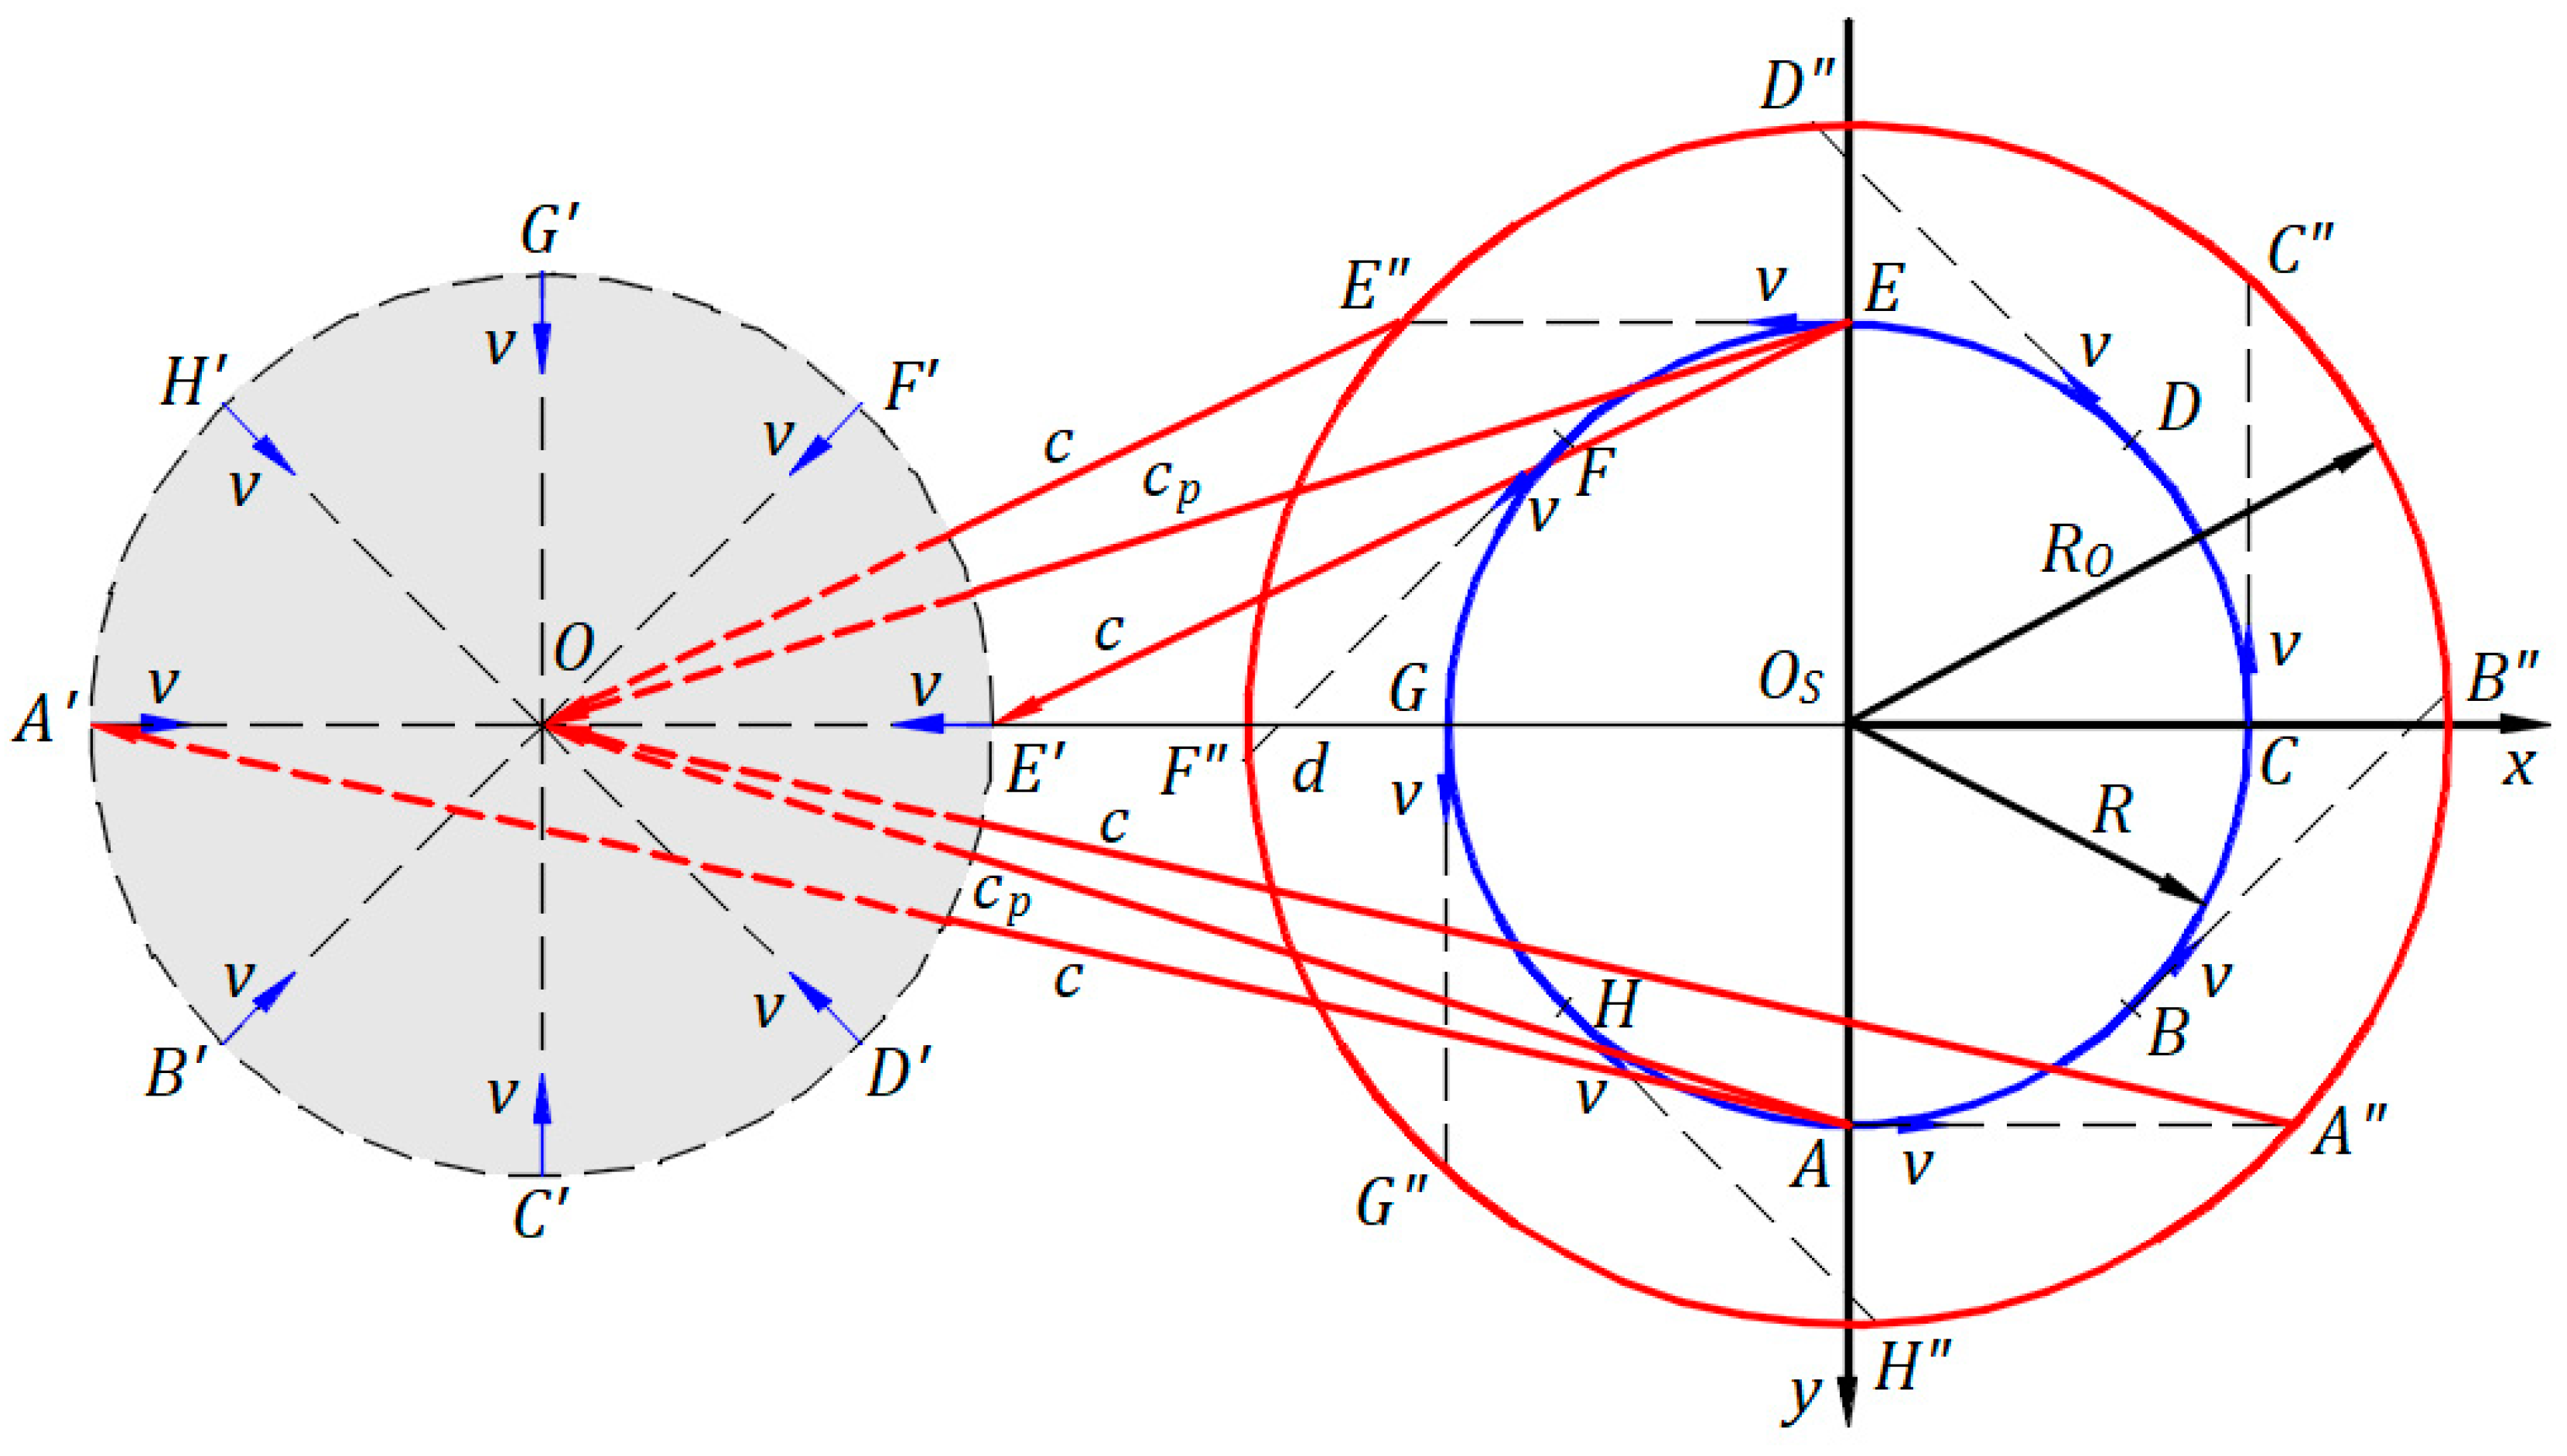
Figure 14.
Galilean coordinates of a spherical light wavefront from a stationary frame shared in an inertial frame.
Figure 14.
Galilean coordinates of a spherical light wavefront from a stationary frame shared in an inertial frame.
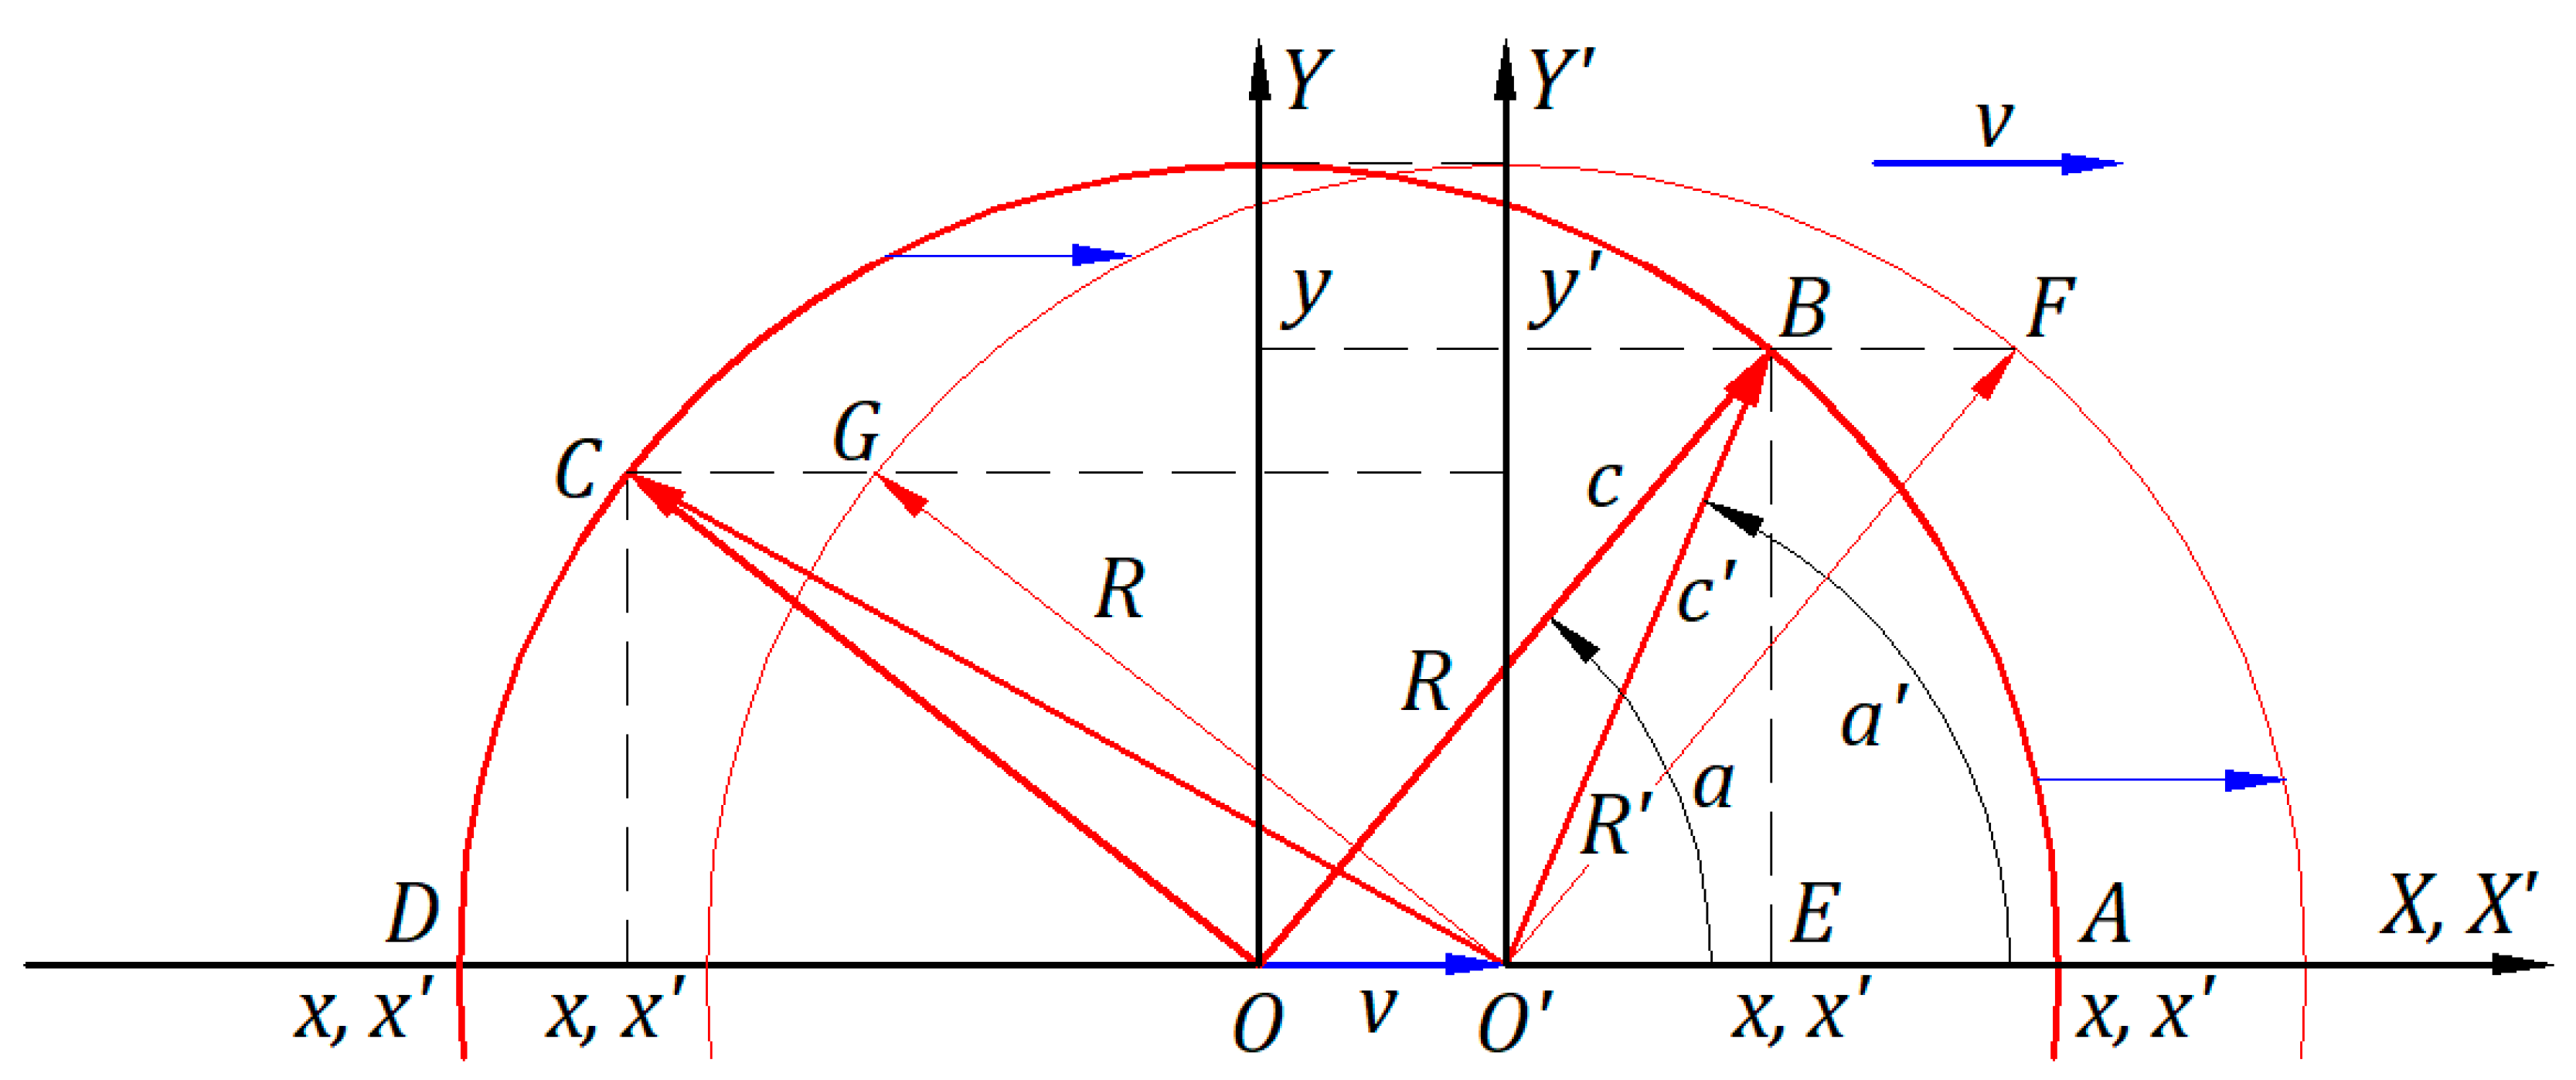
Figure 15.
Lorentz’s transformation applied to a circular wavefront of light from a stationary frame to an inertial frame.
Figure 15.
Lorentz’s transformation applied to a circular wavefront of light from a stationary frame to an inertial frame.
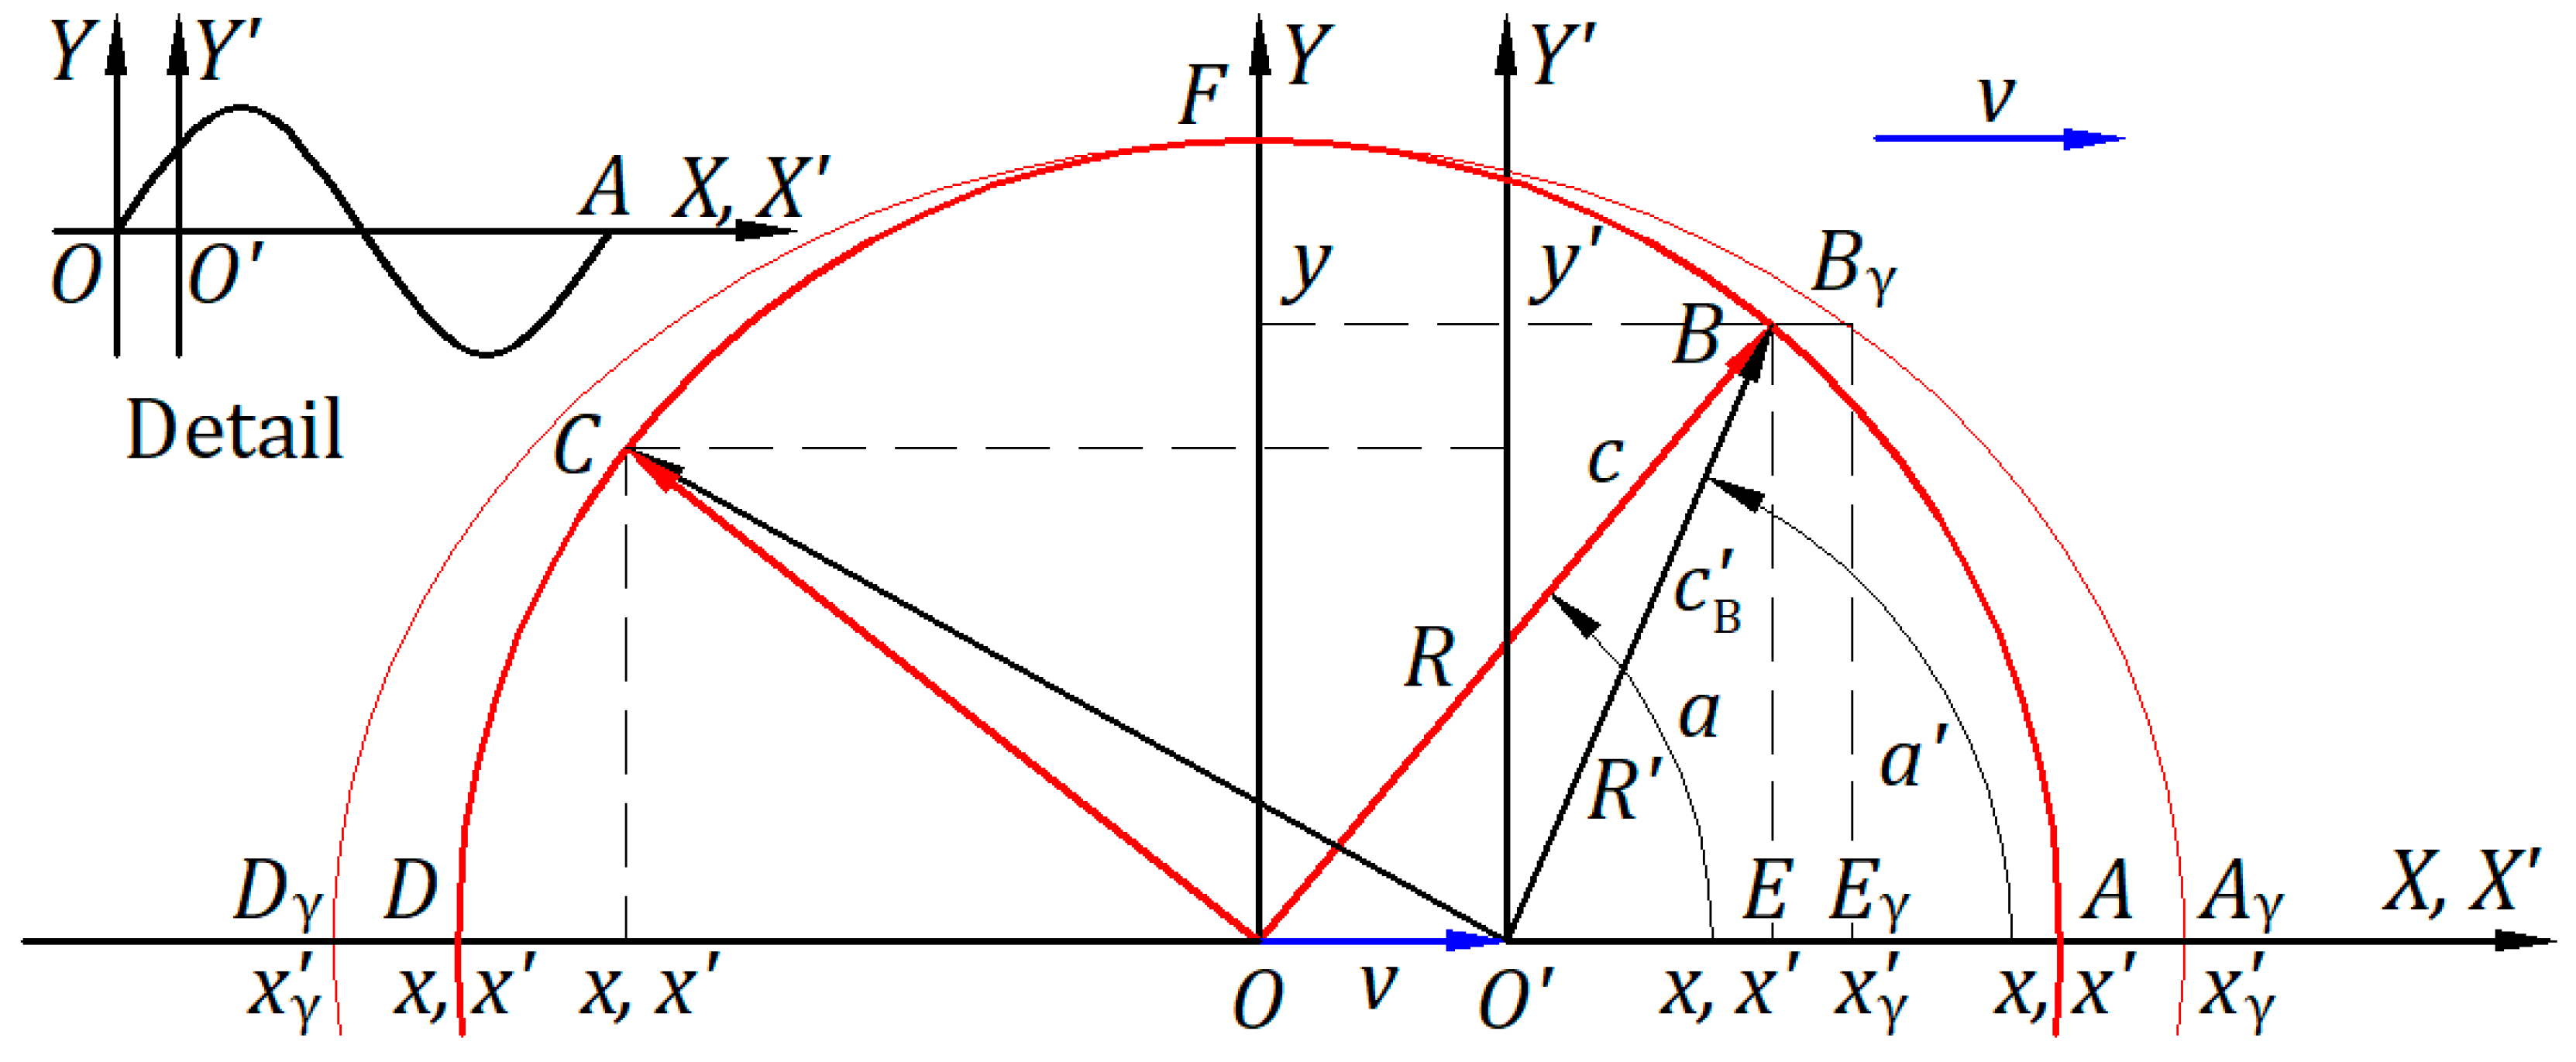

Table 1.
Numerical calculation for and at time s function of angle .
| [°] | 0 | 88 |
| [m] | 2.99970000000000E+08 | 1.04398490107503E+07 |
| [m/s] | 3.00000000000000E+08 | 8.62078429116235E+09 |
| 89.99 | 89.9942704220391 | 89.9942704220392 |
| 2.23598772940828E+04 | 2.41565430769697E-07 | –2.24728864850476E-07 |
| 4.02506676112310E+12 | 3.72569863424722E+23 | –4.00482597595470E+23 |
| 90 | 92 | 180 |
| –2.99999999999816E+04 | –1.04998490107502E+07 | –3.00030000000000E+08 |
| –3.00000001500184E+12 | –8.57158178682134E+09 | –3.00000000000000E+08 |
Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2024 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license (http://creativecommons.org/licenses/by/4.0/).
Copyright: This open access article is published under a Creative Commons CC BY 4.0 license, which permit the free download, distribution, and reuse, provided that the author and preprint are cited in any reuse.