

Submitted:
09 October 2026
Posted:
10 October 2026
You are already at the latest version
Abstract
Tilt-wing electric vertical take-off and landing (eVTOL) aircraft face distinctive safety challenges during transition due to configuration variations, highly nonlinear aerodynamics and coupled effects of distributed electric propulsion. These characteristics impose substantial design efforts when conventional envelope protection methods are applied. This paper proposes a transition-corridor-based protected control framework which is compatible with both nonlinear model-based control and conventional feedback control. First, a transition corridor prediction method incorporating electric propulsion constraints is presented, yielding pitch angle and pitch angular acceleration limits as limit commands. Second, a corridor-based protected control strategy is established and integrated into incremental nonlinear dynamic inversion (INDI) and proportional-integral-derivative (PID) controllers. Furthermore, a comparative study is conducted across different protection strategies and controllers to assess the proposed protected control method in safety-critical transition flight. Simulation results demonstrate that the proposed method provides effective protection while exploiting available maneuvering margins. Moreover, incorporating electric propulsion constraints improves the physical consistency of corridor prediction and envelope protection. Overall, this study provides a practical corridor-based protection framework that integrates transition corridor constraints into closed-loop flight control, enabling safer transition for tilt-wing eVTOL aircraft.
Keywords:
tilt wing eVTOL
; transition corridor
; flight envelope protection
; electric-propulsion constraints
; INDI
1. Introduction
Manned tilted-thrust eVTOL demonstrators represented by Airbus Vahana [1] and Joby Aviation [2] hold the promise of transformative urban air mobility (UAM) and have stimulated research interest in tilted-thrust eVTOL configurations. The advantages of tilt-wing configurations rely on the tilted-thrust mechanism, which gives rise to complex dynamic transients, pronounced aerodynamic nonlinearities [3] and strong aero-propulsive interactions [4]. These characteristics induce response deviations and diminished safety margins [5,6], posing substantial challenges to control design. Combined with its essential role in take-off and landing operations, the control challenges make transition a safety-critical flight phase. Therefore, transition control requires both satisfactory control performance and explicit safety guarantee.
The development of safe transition control techniques focuses on two aspects: more accurate prediction of admissible region and more effective flight-envelop-protection (FEP) control. For transition feasibility prediction, recent studies have progressed toward better practicality with multi-dimensional constraint integration [7] and dynamic reachability [8,9], focusing on the so-called transition corridors, which provided a solid basis for FEP, control strategy optimization [10,11] and trajectory optimization [7]. Meanwhile, different from conventional fuel-powered aircrafts, electric limitations jointly affect the safe boundaries of eVTOL [12]. Recent studies have increasingly incorporated electric constraints. Choi, Ogden et al showed that SOC and propulsion response delays reduce system bandwidth and phase margin, thereby degrading flight qualities [13,14]. Lu, Han, May et al further illustrated that motor and actuator dynamics modify the attainable moment set to affect controllable regions [15,16,17]. Moreover, instead of nominal-efficiency estimation [18], a component level electric constraint model should be introduced to capture the coupled drivetrain dynamics [19,20,21].
For FEP problems, flow separation is one of the most critical cases to be avoided for tilt-wing eVTOLs. A nose-up maneuver is required in later transition to build up lift and initial retransition to sustain flow attachment. This results in high risk in unexpected stall [22]. Hence, pitch protection has emerged as one of the most prevalent research themes. Regular protection adopts hard limitation which failed to accommodate envelope variations. Lombaerts et al applied online-estimated envelopes to constrain , pitch angle and roll angle by imposing command constraints on signal paths [23]. While problems including overshoot at bounds and heavy workload of gain scheduling at near-boundary conditions are difficult to avoid [24] because this kind of FEP is still a separate layer superimposed to the controller. This motivates the introduction of nonlinear FEP control method. Among them, INDI is particularly attractive for eVTOLs because of its reduced model dependence and capability of achieving unified control across highly varying flight conditions. Full-envelope INDI control architectures have been developed for eVTOLs [25] with robustness and stability demonstrated through analytical assessments [26], nonlinear simulations [25], and flight tests [27].
Stougie et al extended the NDI-based FEP proposed by Lombaerts to INDI-based FEP while essentially stayed at command limiting level [28]. Gabrys et al integrated the phase plane-based command limiting and virtual control limiting into reference model and utilized inner-loop dynamics to achieve desired behaviors [24]. For eVTOL applications, extending INDI-based FEP toward maneuverability awareness first requires more dynamic characteristics in boundary prediction. Recent studies have therefore focused on reachability-based dynamic corridor prediction. Hsu et al. constructed a dynamic envelope using HJ reachability [6], while May et al. combined DFOG and PCD for dynamic corridor prediction [8]. However, their integration with INDI-based FEP has yet to be sufficiently investigated. Beyond the boundary prediction, maneuverability-aware FEP is required to enforce the boundaries and reduce conservatism. Sun et al. employed a potential function to attenuate pilot commands when approaching boundary, reflecting an early thought of trade-off between protection and maneuvering [29]. Altunkaya et al. used an incremental attainable moment set (IAMS) to assess instantaneous controllability [30]. Lu et al. employed an ellipsoidal AMS to constrain infeasible virtual commands [31]. However, explicit integration of transition corridor with maneuverability-based FEP for eVTOLs remains largely unexplored. The gap motivates the research towards maneuverability-based protection method.
This study aims to develop a corridor-based protected control framework for tilt-wing eVTOLs. First, a transition trimming method incorporating practical constraints is constructed to define the admissible transition region. Next, a maneuverability-based protection strategy is developed. Instead of prescribing the allowable approach rate through conventional linear approximation, we derive the rate boundary from current recovery capability based on corridor margin. Its integration with INDI and PID controllers is then developed and evaluated. Primary contributions of this paper are:
- 1.
- Improving the physical fidelity of protection boundaries prediction by incorporating both aerodynamic and electric-propulsion constraints into transition corridor prediction, enabling physically consistent boundary generation.
- 2.
- Proposing a maneuverability-based protection strategy that determines the allowable approach rate limit from available maneuvering capability subject to corridor constraints, rather than relying on a prescribed linear formulation.
- 3.
- Extending the proposed protection strategy to both nonlinear model-based control and linear feedback control.
This paper is organized as follows. Section 2 establishes a 6-DOF dynamic model of tilt-wing eVTOL, which serves as the design basis for following sections. Section 3 proposes the corridor-protected methodology, including constrained prediction of 3-dimensions corridor and a maneuverability-based protection method. Section 4 illustrates the unified INDI controller and protection integration. Section 5 presents a protected control case, delivers nominal and perturbed profile simulation tests and highlights the protection performance. Finally, Section 6 summarizes this study.
2. Tilt-Wing eVTOL Model Description
2.1. Configuration
Take a 2000 kg tandem tilt-wing eVTOL with six propellers symmetrically distributed on the wing tips as an example. Figure 1 shows the configuration of the tandem tilt-wing eVTOL, the main components and illustration of body frame (with subscript ”b”) and propeller frame (with subscript ”p”).
2.2. Flight Dynamics
The rigid-body dynamics model of the tilt-wing eVTOL is established in body frame.
Where m is the mass of eVTOL, is the velocity components, is the angular rate components and denotes the angular momentum.
Ref. [32] focuses on a tilt-wing eVTOL with an aerodynamic configuration similar to the control subject of this paper, which provides the foundation of aerodynamic modelling for this study. The aerodynamic models for fixed-wing and multi-rotor phase are established by fitting CFD data:
Where are aerodynamic lift, side force and drag. are aerodynamic roll moment, pitch moment and yaw moment. The dominant parameters are airspeed , angle of attack , sideslip angle , non-dimensional angular rate , propeller rotational speed , tilt angle and deflection of elevator , aileron and rudder . Transition aerodynamic mechanism relies on the evolution of propeller-wing interference switching from downstream to slipstream, which is determined mainly by . Hence, a hyperbolic-tangent-based blending function scheduling by is introduced to realize smooth transition between multi-rotor aerodynamics and fixed-wing aerodynamics [33]. Based on the impact range of slipstream, selects as the start and end of blending.
Where
represents the weight of multi-rotor aerodynamics, k controls the slope of and controls the mid-point of blending function. Figure 2 shows the variation of with . Figure 3(a) shows variation with under different . Figure 3(b) shows variation with under different . It can be seen that the mixing method provides a smooth shift between fixed-wing and multi-rotor regimes which manifests as an evolution of pitch stability across varying .
2.3. Electric-Propulsive Dynamics
The electric propulsion unit consists of the battery pack, electric motors, electronic speed controllers (ESC) and propellers, which jointly form an energy conversion chain from electrical power to propulsive force and moment. A component-level electric-propulsive dynamics model is adopted to represent the powertrain dynamics.
For the propeller aerodynamics, the quadratic simplification form is adopted. The nominal thrust and torque coefficients are measured through experiments.
Where and are the thrust and torque of single propeller in propeller frame. is defined as for the vertical position and for the horizontal position. The propulsive force and moment components are given by:
Where is the number of propellers, is the mounting angle between thrust orientation and plane, is the mounting angle between thrust orientation and plane, is the components of thrust lever arm vector and is the rotational speed vector aligned with .
To further reflect the electric characteristics, motors, ESC and battery pack are represented by an equivalent circuit model (ECM) [34]. ESC adjusts the motor terminal voltage by modulating the duty cycle according to the error between rotational speed command and the measured rotational speed. With input voltage, the motor generates current to balance the back electromotive force (BEMF) and provides toque.
Where is the torque provided by motor, is motor-propeller shaft inertia, is duty cycle, is the current of motor, is the terminal voltage of motor, is the internal resistance of motor and are respectively the back electromotive force and torqe constant. For steady case analysis, the dynamic characteristics of motor response is neglected which leads to . Moreover, neglect the transmission power loss from motor to propeller, which yields [21].
The battery pack provides the energy for the entire powertrain. It typically consists of parallel strings, each containing cells in series. Considering the electrical topology, the terminal voltage of the battery pack can be expressed as:
Where is the current of battery pack and is the internal resistance of the battery pack. The formulation without polarization voltage state is adopted for open-circuit voltage [35]:
The coefficients are identified through battery charging experiments. represents the remaining charge of battery pack. The rate of change of battery charge is defined as:
3. Corridor-Protected Methodology
3.1. Transition Corridor and Protection Boundaries
The transition corridor represents an admissible set of flight states, in which eVTOLs can achieve successful configuration transition under specific constraints [8]. Specifically, the state boundaries for protection are lower-dimensional limit surfaces extracted from the multi-dimensional transition corridor and serve as control commands limits.
3.1.1. Constraints for Transition Corridor
Physical constraints arise from the requirements of flight and control. Flight constraints are mission-dependent thus adjustable, whereas control constraints represent hard physical limits of the aircraft.
- 1.
-
Fight ConstraintsIn this paper, nominal transition flight is expected to accelerate or decelerate with minimal altitude loss. Therefore, the external forces and moments should satisfy the following quasi-equilibrium constraints:Where is the flight path angle which is expected to be zero, S is the aerodynamic reference area and denotes the dynamic pressure at current altitude.
- 2.
-
Control ConstraintsWithin the state region feasible under the above flight constraints, the boundaries delineated by control constraints eventually form the transition corridor.Control constraints mainly arise from aerodynamic stability and electric-propulsion capability. Aerodynamic constraint is imposed on the effective angle of attack of the lifting surfaces. The stall limits preserve sufficient aerodynamic and control effectiveness [36] during transition.Where is the critical angle of attack when the wing or elevator enters a region of significant flow separation. Propeller aerodynamic constraint is imposed on the maximum blade-tip Mach number, which contribute to avoid excessive efficiency losses because of compressibility effect [37].Where a is the speed of sound at current flight altitude and is the freestream speed. A threshold of critical helical tip Mach number avoiding significant compressibility is 0.85, which applies to commonly used airfoils [38] thus can be applied to eVTOL as a conservative limit . Propulsion constraint is jointly determind by battery and motor, varying with electrical states of the powertrain, including maximum current, motor speed and power [21].Actuator constraints are also inviolable, which affects mainly the later transition and initial retransition in high airspeed.
3.1.2. Transition Corridor Construction
Based on the above constraints, the transition corridor is constructed in three dimensions of . For each candidate state, the required thrust and elevator deflection are solved subject to the quasi-equilibrium equations. A state is retained as feasible only when all aerodynamic, electric and propulsion constraints are simultaneously satisfied. Within the space S of all states, define the feasible region of forward and backward transition as:
Where contains all of the control constraints defined in the last section. In order to obtain , a cascaded longitudinal trim and bounded allocation procedure is employed.
For each prescribed , the aerodynamic forces and pitch moment are determined. The required thrusts are then solved based on the vertical and pitching equilibrium constraints. Since this is mostly a redundant allocation problem, the Moore–Penrose pseudo inverse is applied to compute the minimum-norm solution to meet the power minimization.
The effective matrix is of full row rank.
Where is the derivative of pitch moment with respect to thrust. Next, check if corresponding exceeds its limit. The saturated thrust is fixed on the nearest boundary as and the required thrust is redistributed.
With the candidate thrust , check if the acceleration constraint is satisfied. In low lift regime, the normal load is gradually increased until a positive is obtained, whereas is scanned in the high-lift regime to improve convergence and avoid unnecessary iterations. The candidate thrust is accepted only if the prescribed acceleration constraint is satisfied. The required elevator deflection is determined according to the pitch equilibrium demand. Finally, all trimmable states are filtered according to to form .
Every state within the intersection of and possesses both accelerate and decelerate ability, which implies reachability characteristics. This intersection is considered to be a safe region for transition since the states inside this region enable a revert maneuvering.
is defined as bidirectionally feasible corridor and serves for protection boundaries generation.
3.1.3. Protection Boundaries Generation
Protection boundaries are contracted based on . For nominal transition, is expected. Therefore, trimmable boundaries of for transition and retransition respectively serve as the pitch command limit for the two phases, with specific safety margin in consideration of the measurement uncertainties.
Furthermore, at each state , the maneuverability boundary is defined as the maximum angular accelerations at current state, which are determined by residual control resources beyond equilibrium requirement. Assume that initial rates are zero, the angular accelerations are calculated by rotational dynamics. Noted that different from conventional airplanes, is often unneglectable for eVTOL.
Define as one of the three angular rate components in body axis. In order to obtain the maximum angular accelerations as maneuverability boundaries , we construct a constrained nonlinear optimization problem as below:
The optimization problem is solved using a sequential quadratic programming (SQP) algorithm implemented in MATLAB.
3.2. Protected Control Strategy
The protection boundaries above determine the corridor-based protected control commands. First, it is used for command limit. Take pitch control as an example, should satisfy:
For inner-loop rate limiting, this paper proposes a maneuverability-based (MB) dynamic protection method. First is the formulation of and corresponding . In order to ensure , pitch rate should approach zero when . As approaches , the decay rate of q should be determined with reference to the maximum attainable pitch acceleration obtained from trim analysis. In other words, design the considering the maximum capability to terminate the pitching motion. This allows fully exploitation of the aircraft’s maneuverability. Define as the maximum recoverable rate, which is the final boundary where eVTOL is still capable of recovering the pitch angle onto its safe region:
At critical margin of , . At a certain , the safety margin of pitch rate is:
When , must hold. At the critical margin , if is allowed to rise to , then
Which implies that theoretically, if available opposing pitch acceleration is applied, the pitch rate can be reduced to zero exactly at . In steady straight transition flight, assume that and derive:
To avoid singularity of , introduce a small threshold in the denominator. Feedback control is required to guarantee that q stays below . Take the upper case as an example, the error between q and should satisfy:
Design the limit of as
This saturation law contributes to guarantee . Assume an error expression as:
At the bound where , the analytical solution is:
Where is defined to be positive. As the aircraft will not initiate flight with a boundary-exceed rate, always holds in practice. Thus, is guaranteed by the saturation law.
4. Controller Implementation
4.1. Unified Controller Structure
The multi-loop unified INDI controller structure is demonstrated in Figure 4. The objective of the velocity loop is to track specific commands, consists of reference model (RM) and error controller (EC). The objective of the attitude loop is to enhance attitude stability, consists of RM, EC and thrust vector command generation (TVCG). The objective of the inner loop is to optimize damping as well as roll convergence speed, consists of feedback control and control allocation (CA). Their structures are identical for all phases [1]. Through time-scale separation, the design of each loop becomes a dynamic-inversion problem for a first-order system, which simplifies the computation and enhances robustness.
4.2. Control Command
Throughout entire envelope, the dominant control objectives and maneuvering mechanisms vary significantly, which is the basis for control command selection.
In multi-rotor flight, powered-lift dominates the control authority, making precise hovering control the primary handling requirement [39]. Therefore, rate command, height hold and translational rate command response types are adopted for vertical and horizontal motion, respectively. In fixed-wing flight, aerodynamics dominate and the flight path is mainly changed indirectly through attitude-induced aerodynamic forces. Thus, attitude-hold commands are adopted, which should contribute to reducing the pilot’s workload [1].
In transition, smoothness assurance and stability augmentation are more important than precise position control because of its safety-critical characteristics. In forward transition, powered lift gradually shifts to aerodynamics, which is more similar to multi-rotor flight. Accordingly, the multi-rotor command structure is retained. Reverse transition follows the fixed-wing phase and exhibits its characteristics. Consequently, the control commands follow the fixed-wing mode [39]. The heading hold response type is adopted for all phases.
The unified control commands are summarized in Table 1.
4.3. Thrust Vector Command Generation
The desired translational motion is converted into thrust vector command, including the thrust orientation command and thrust magnitude command .
is defined to be and for multi-rotor phase and fixed-wing phase. In transition phase, is scheduled by forward velocity command according to predefined flight path.
is mapped from the desired accelerations utilizing longitudinal translational dynamics in multi-rotor phase [40].
Assume and obtain
Where denotes the propulsive specific forces in body frame. Combine equation (34)-(35) to obtain :
where . This transformation achieves the thrust distribution based on the force required for acceleration and the force required for altitude maintenance. There are 2 main concerns that needs special attention:
- 1.
- During hovering, the numerator approaches zero and causes an artificial jump.
- 2.
- During vertical take-off, K becomes singular when .
Therefore, tangent branch selsction and singularity protection are required. In transition phase, predefined pitch profile is adopted as . In fixed-wing phase, comes from manual input.
The acceleration in the thrust direction can serve as the thrust magnitude command , being calculated from velocity command, and .
4.4. Reference Model
Figure 5 shows the structure of reference models. Define the state variables with desird first-order response characteristics as and the state variables with desird second-order response characteristics as [41].
For velocity loop, the response of translational rates to thrust corresponds to first-order characteristics [40]. The pseudo input for attitude loop is:
Where denotes the bandwidth of forward and vertical velocity. Internal states of the reference model are denoted with subscript d. The expected bandwidth are determined referring to requirements for translational rate command response type in ADS-33E-PRF [42]: the translational rate response to step inputs shall have a qualitative first order appearance, and shall have an equivalent rise time no less than 2.5 seconds and no greater than 5 seconds. The equivalent rise time is defined to be the time when translational rate rises to 0.632 steady value.
Above all, the pseudo input for control allocation is:
For attitude loop, the response of roll angle and yaw rate to actuators correspond to first-order characteristics and the response of pitch angle corresponds to 2nd relative order [40]. The selection of bandwidth and damping of attitude loop is related to desired modal characteristics, which are also determined by handling quality requirements [42,43]: for Class I aircraft in Category C, the Level 1 requirements correspond to .
Utilizing rotational kinematics inversion to map to the inputs of inner loop [39]:
The control matrix is
For inner loop, the relative degree of angular rates exists as first-order. The pseudo commands for control allocation are:
Inner loop bandwidth are also determined by the modal requirements above.
4.5. Control Allocation
Control allocation undertakes the task of coordinating allocation strategies for different flight phases. control is primarily realized by propellers in multi-rotor phase, aerodynamic surfaces in fixed-wing phase, and their combination during transition. relies on propellers in all phases, yet only a subset of designated propellers is activated in fixed-wing phase for energy saving. Hence, a selection strategy is incorporated into allocation.
First, is partitioned by airspeed into contributions from propellers and surfaces. Define as the start and end of blending from power control to aerodynamically control.
Where
represents the thrust-borne control authority which decreases as dynamic pressure increases [5]. controls the shape of blending function. When , the blending function degenerates from quadratic to linear. Forward velocity is normalized as .
Second, and are allocated based on INDI. For surface allocation,
Where is control surfaces including , and . respectively denote the current surfaces deflection and rates. is the control allocation matrix which is obtained by an onboard plant model. Using difference instead of differential in order to adapt to the discrete computation [44].
For differential thrust allcation,
Where respectively denote the current surfaces deflection and states variables associated with . are diagonal matrices that respectively determine which propellers are activated and which pseudo inputs take part in allocation. The incremental control effectiveness matrix is . The formulation of each column is:
4.6. Linearized Error Controller
For relatively fast attitude loop, second-order reference model is adopted and an additional proportional error controller can be added to enhance the tracking performance. For the relatively slowest velocity loop, integrators can be added to optimize control performance while enhancing robustness. In this paper, the tracking error of forward and vertical velocity are mainly focused. The structure of error controller is shown in Figure 6.
4.7. Protection Integration
For INDI controller, it is natural to integrate the saturation of into attitude reference model and output into the pseudo input for control allocation. The associated gain adjustment work for is almost negligible relative to traditional PID. The controller structure with pitch angle protection is demonstrated in Figure 7.
For cascaded PID controller, the same protection control methor can be integrated. The control commands and control allocation scheme are similar as INDI controller. The multi-loop control law can be written as:
Where feedback error terms are . The required is then fed into control allocation.
The and saturation are incorporated into and , which are nominal and .
5. Simulation and Discussion
5.1. Transition Corridor and Protected Commands
Table 2 summaries the constraints considered in this case. All of the parameters selection herein are based on publicly available data.
The transition corridors of the exemplary eVTOL are demonstrated in Figure 8, incorporating velocity and pitch limit. In particular, Figure 8(a) shows that battery current limit serves as the decisive variable for transition boundary. While for retransition, the impacts of electric constraints on feasibility are relatively small, as shown in Figure 9. This is reasonable due to the deceleration operation leading to lower thrust requirement.
Figure 10 shows the intersection of transition and retransition corridors, which determines forward velocity limit during transition. Flight paths for transition and retransition should be selected within the intersected corridor.
Further, each path corresponds to an attainable maneuverability boundary which finally determines . Take the path in Figure 10 as an example. Figure 11(a) demonstrates the boundary associated with designated transition profile. generally increases in the later transition and peaks around middle transition, benefiting from rising dynamic pressure which decreases required power lift as well as increases aerodynamically control effectiveness. Figure 11(b) demonstrates the boundary associated with designated retransition profile, exhibiting a similar trend to that of the transition case.
Taking a linearized method as a baseline for comparison [24]:
Taking the exemplary predicted time to violate as , the protected commands are shown in Figure 12. Compared to the linear , the MB shows better adaptability to the instantaneous .
5.2. Profile Assessment for Protected Controller
This paper is not intended for comprehensive assessment. Instead, the primary objective is to evaluate the nominal performance and robustness of the protected control mechanism. For transition controller assessment, focusing on the ability to accomplish specific mission by mission task is considered more suitable than linearized evalution for individual conditions [47]. Therefore, nominal and perturbed profile simulation are conducted.
5.2.1. Nominal Profile Simulation
The design of mission profile should comprehensively reflect the following elements of eVTOL flight controller [48]:
- The adaptability of eVTOL operation in UAM environment.
- The attitude and altitude stability with sufficient and smooth actuators usage.
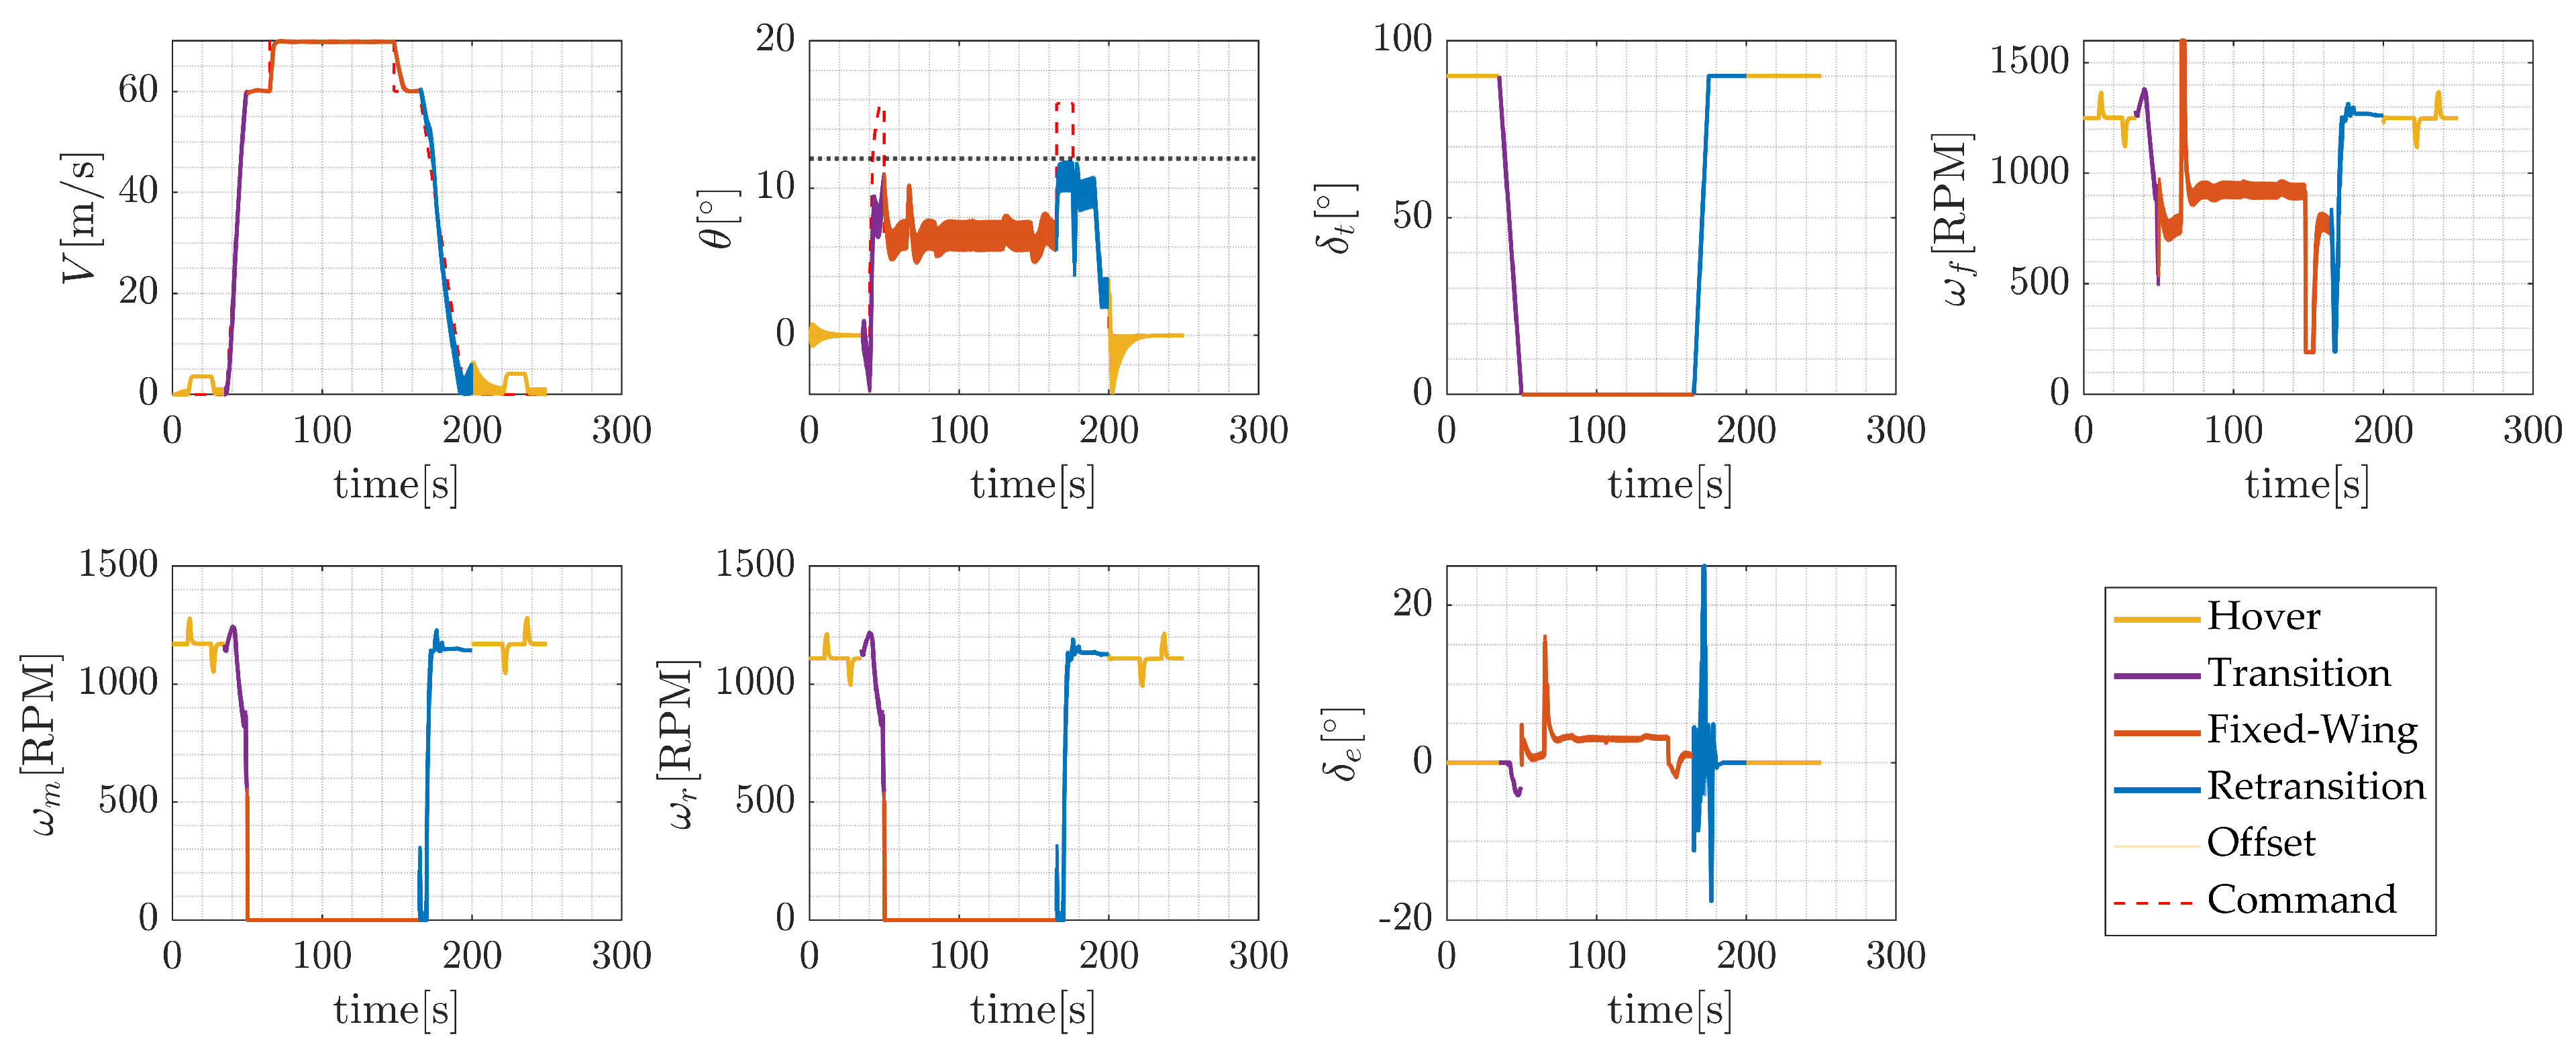
Based on this consideration, a mission profile is designed as shown in Figure 13. First, take off vertically from the initial point to the height of 50-80m and start hovering, which is an altitude above most of the buildings around airport. Then, start transition and tilt from to to accelerate from hovering to forward velocity of 60m/s before switching to fixed-wing mode. During cruising, the middle and rear propellers are deactivated. Accelerate to 70m/s and execute a roll maneuver to examine corresponding control channels. Finally, decelerate to 60m/s and enter retransition to continue deceleration to hovering, with tilt angle increases to . Height of 50-80m is still required to avoid obstacles. In the last, descending vertically to the landing site. Excessive nose-up commands are incorporated into the final transition and initial retransition to exhibit the protected control performance.
Figure 14 shows the response of protected PID and INDI controllers under the same mission profile and protection framework. The red line stands for PID and the blue line stands for INDI. Under excessive pitch command, both controllers successfully complete the transition mission without violation of pitch boundary. This demonstrates that the proposed protection strategy is compatible with both conventional feedback control and nonlinear model-based control architectures. The corresponding actuator responses in Figure 15 remain within the bounds without abrupt variations, further supporting the practical applicability of the proposed protection method. Moreover, when the protection remains inactive, the nominal control performance of both INDI and PID is well preserved, indicating that the protection introduces no apparent degradation to the baseline tracking performance.
Compared with PID, protected INDI as a nonlinear control method provides more consistent protected responses throughout the profile and makes better utilization of the available maneuvering margin with less tuning effort. This indicates that protected INDI has potential in releasing tuning workload for eVTOLs while maintaining superior protection performance.
5.2.2. Perturbed Profile Simulation
eVTOLs feature complex nonlinear dynamics in transition phases thus linear method is unable to cover the full-envelope control stability and robustness assessment. Stochastic method is therefore adopted to evaluate controller performance under practical uncertainties [49].
For nonlinear control method, monte-carlo can be used for evaluation. Taking PID controller as a benchmark, assume that INDI robustness performance is acceptable if it transcends PID [44].
During transition, uncertainties of control performance lie in prediction of nonlinear aerodynamics, sensor dynamics, actuator dynamics, stuctrural vibration and environmental disturbance [50]. Among these factors, aerodynamic model and measurement uncertainties are considered in the present study because they have pronounced effects on the proposed protection framework.
Aerodynamic modelling uncertainties parameters are selected according to the blending model rather than varying individual aerodynamic coefficients. A combined deviation of the mid-point and slope parameters k is performed. These two parameters possess non-negative physical bounds and their uncertainties are suitable to be characterized by relative errors. Thus multiplicative perturbation is adopted with a normal distribution, whose distribution parameters are [51].
For measurement uncertainties, deviation on pitch angle signal which directly influences the protection logic is mainly considered. Even when angular rate measurements are pre-calibrated, attitude errors may still arise from gyro bias and accelerometer errors, as well as residual errors after multi-sensor fusion [52]. Therefore, the perturbed pitch angle signal is represented by:
Where denotes the scale factor error, coming from manufacturing, temperature variations et al. Its uncertainties are suitable to be characterized by relative errors, thus multiplicative perturbation is adopted with a normal distribution, whose distribution parameters are . denotes the additive bias, coming from gyro bias, installation misalignment and calibration et al. Its uncertainties are suitable to be characterized by absolute errors, thus additive perturbation is adopted with a uniform distribution over [53].
According to ref [54], when the estimation accuracy and confidence level are both 0.01, the minimum number of pull biases is:
For perturbed simulation, the task follows the profile in Figure 13 with excessive nose-up commands injected in transition and retransition. The sum of absolute tracking errors of specific command across the flight profile serves as the dispersion indicator, normalized by the reference indicator of nominal profile.
For aerodynamic uncertainties assessment, Figure 16 shows the pertubed and aerodynamic coefficients.
Figure 18,Figure 20 show that protected INDI still exhibits satisfactory protection performance under aerodynamic model uncertainties or pitch measurement uncertainties. With the injection of an over-limit at , the pitch angle remains confined within safe boundary. Pitch angle measurement uncertainties have a more significant impact on protection performance because the protection mechanism relies on pitch angle signal and its deviation inevitably introduces the risk of constraint violation, which highlights the importance of reserving a safety margin based on hardware environment. Compared to INDI, PID also exhibits qualified disturbance rejection performance and effective protecion as shown in Figure 19,Figure 21.
Figure 17 illustrates that the protected INDI controller exhibits smaller deviations of pitch response and velocity response than PID, indicating lower sensitivity to model uncertainties and more consistent boundary protection performance than the protected PID controller. Therefore, the robustness performance of protected INDI controller proposed in this paper is satisfactory.
Figure 17.
Deviation result comparison of protected PID and INDI: (a) Aerodynamic modelling perturbation; (b) Pitch angle measurement perturbation.
Figure 17.
Deviation result comparison of protected PID and INDI: (a) Aerodynamic modelling perturbation; (b) Pitch angle measurement perturbation.
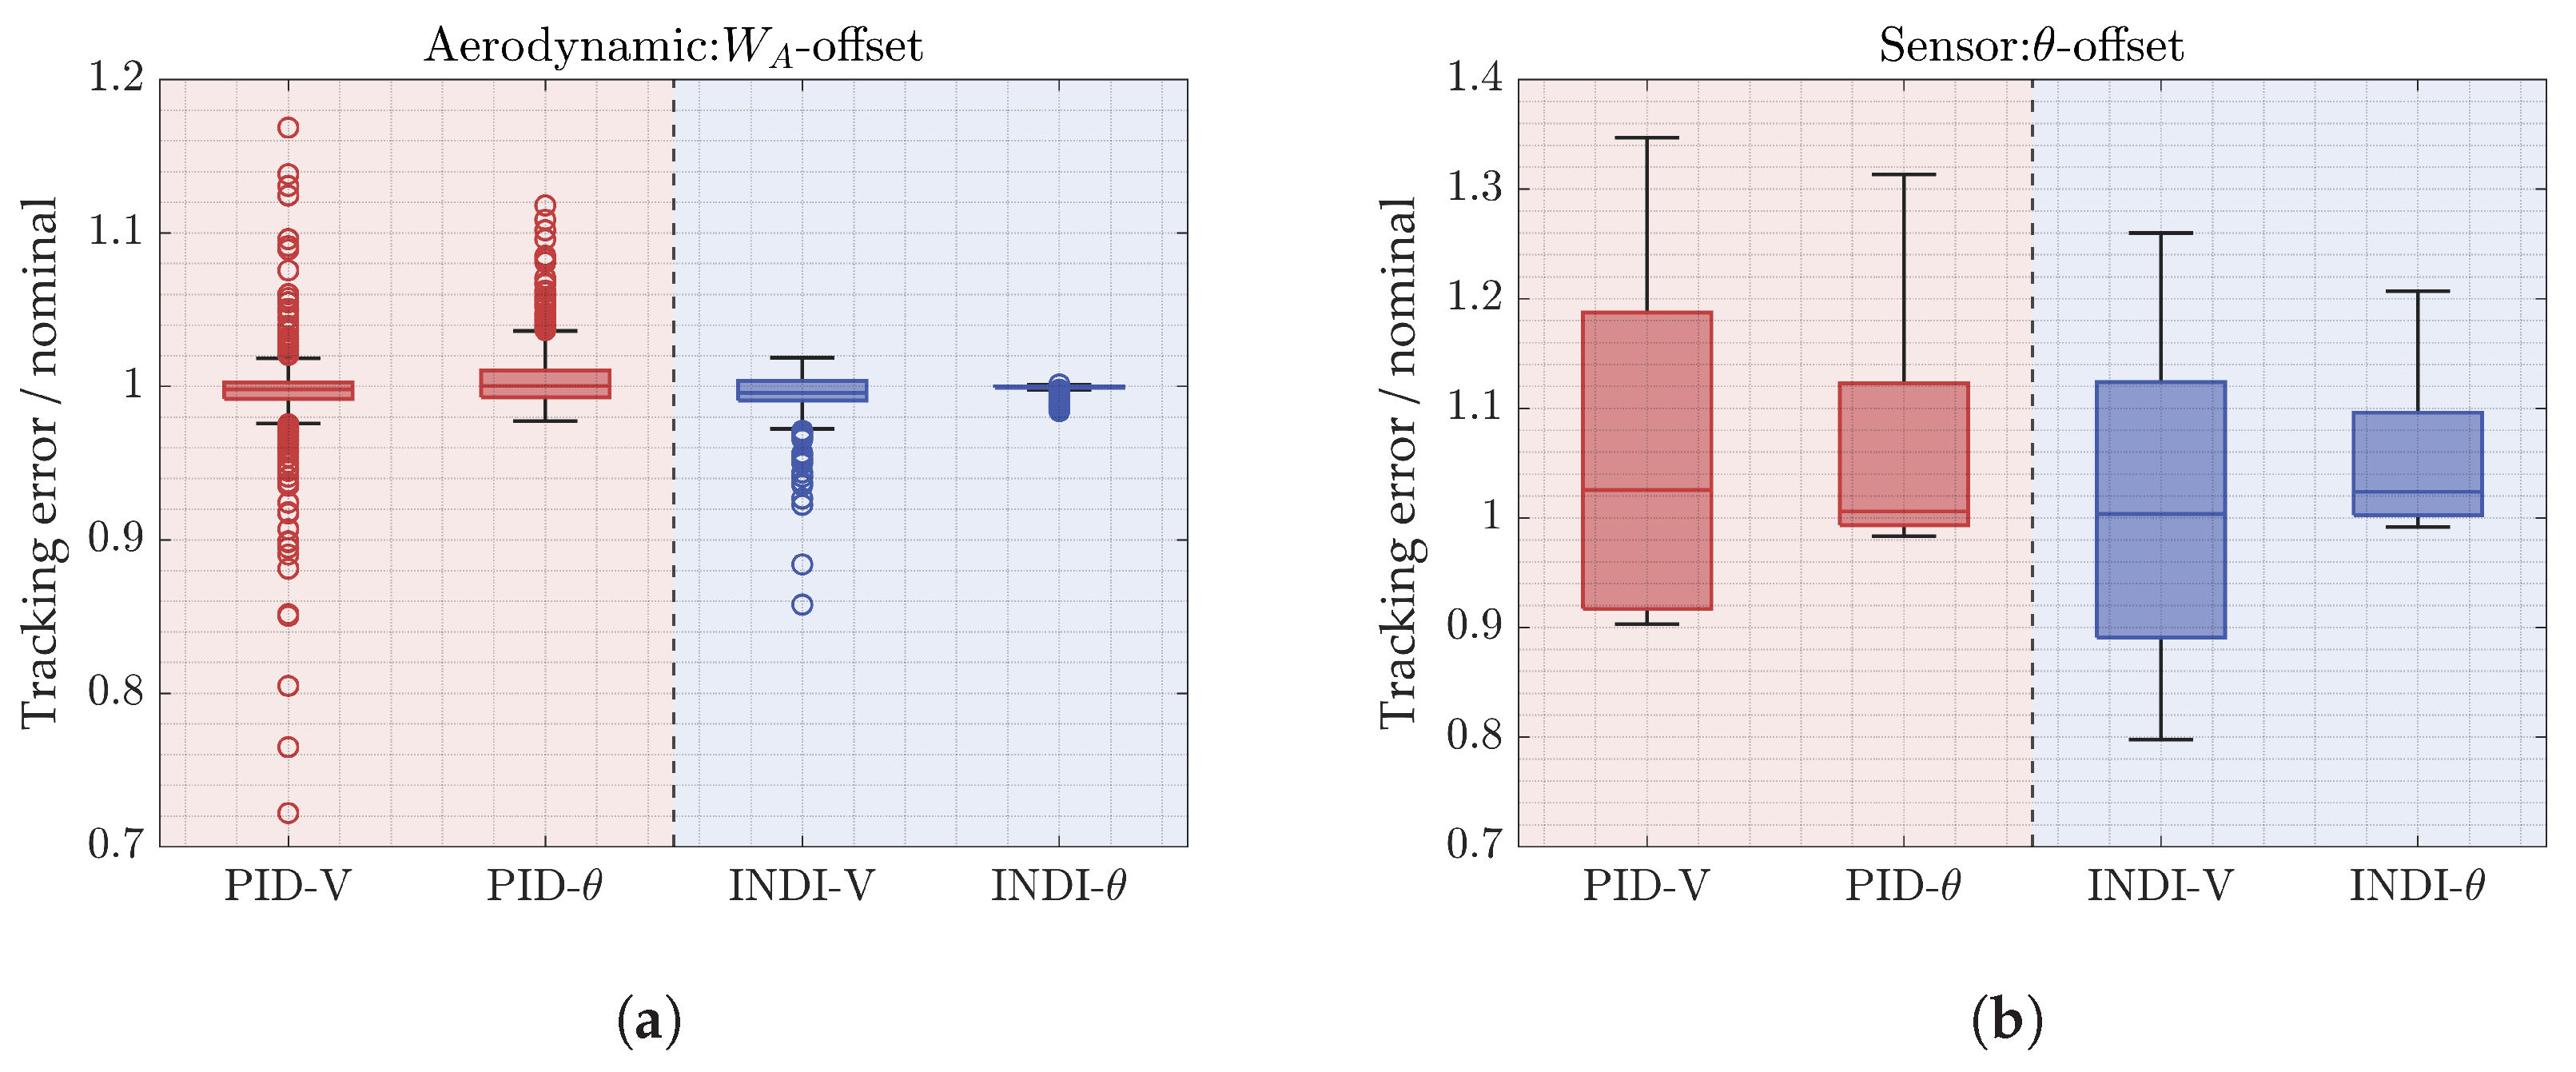
Figure 18.
Simulation results of protected INDI under uncertainties.
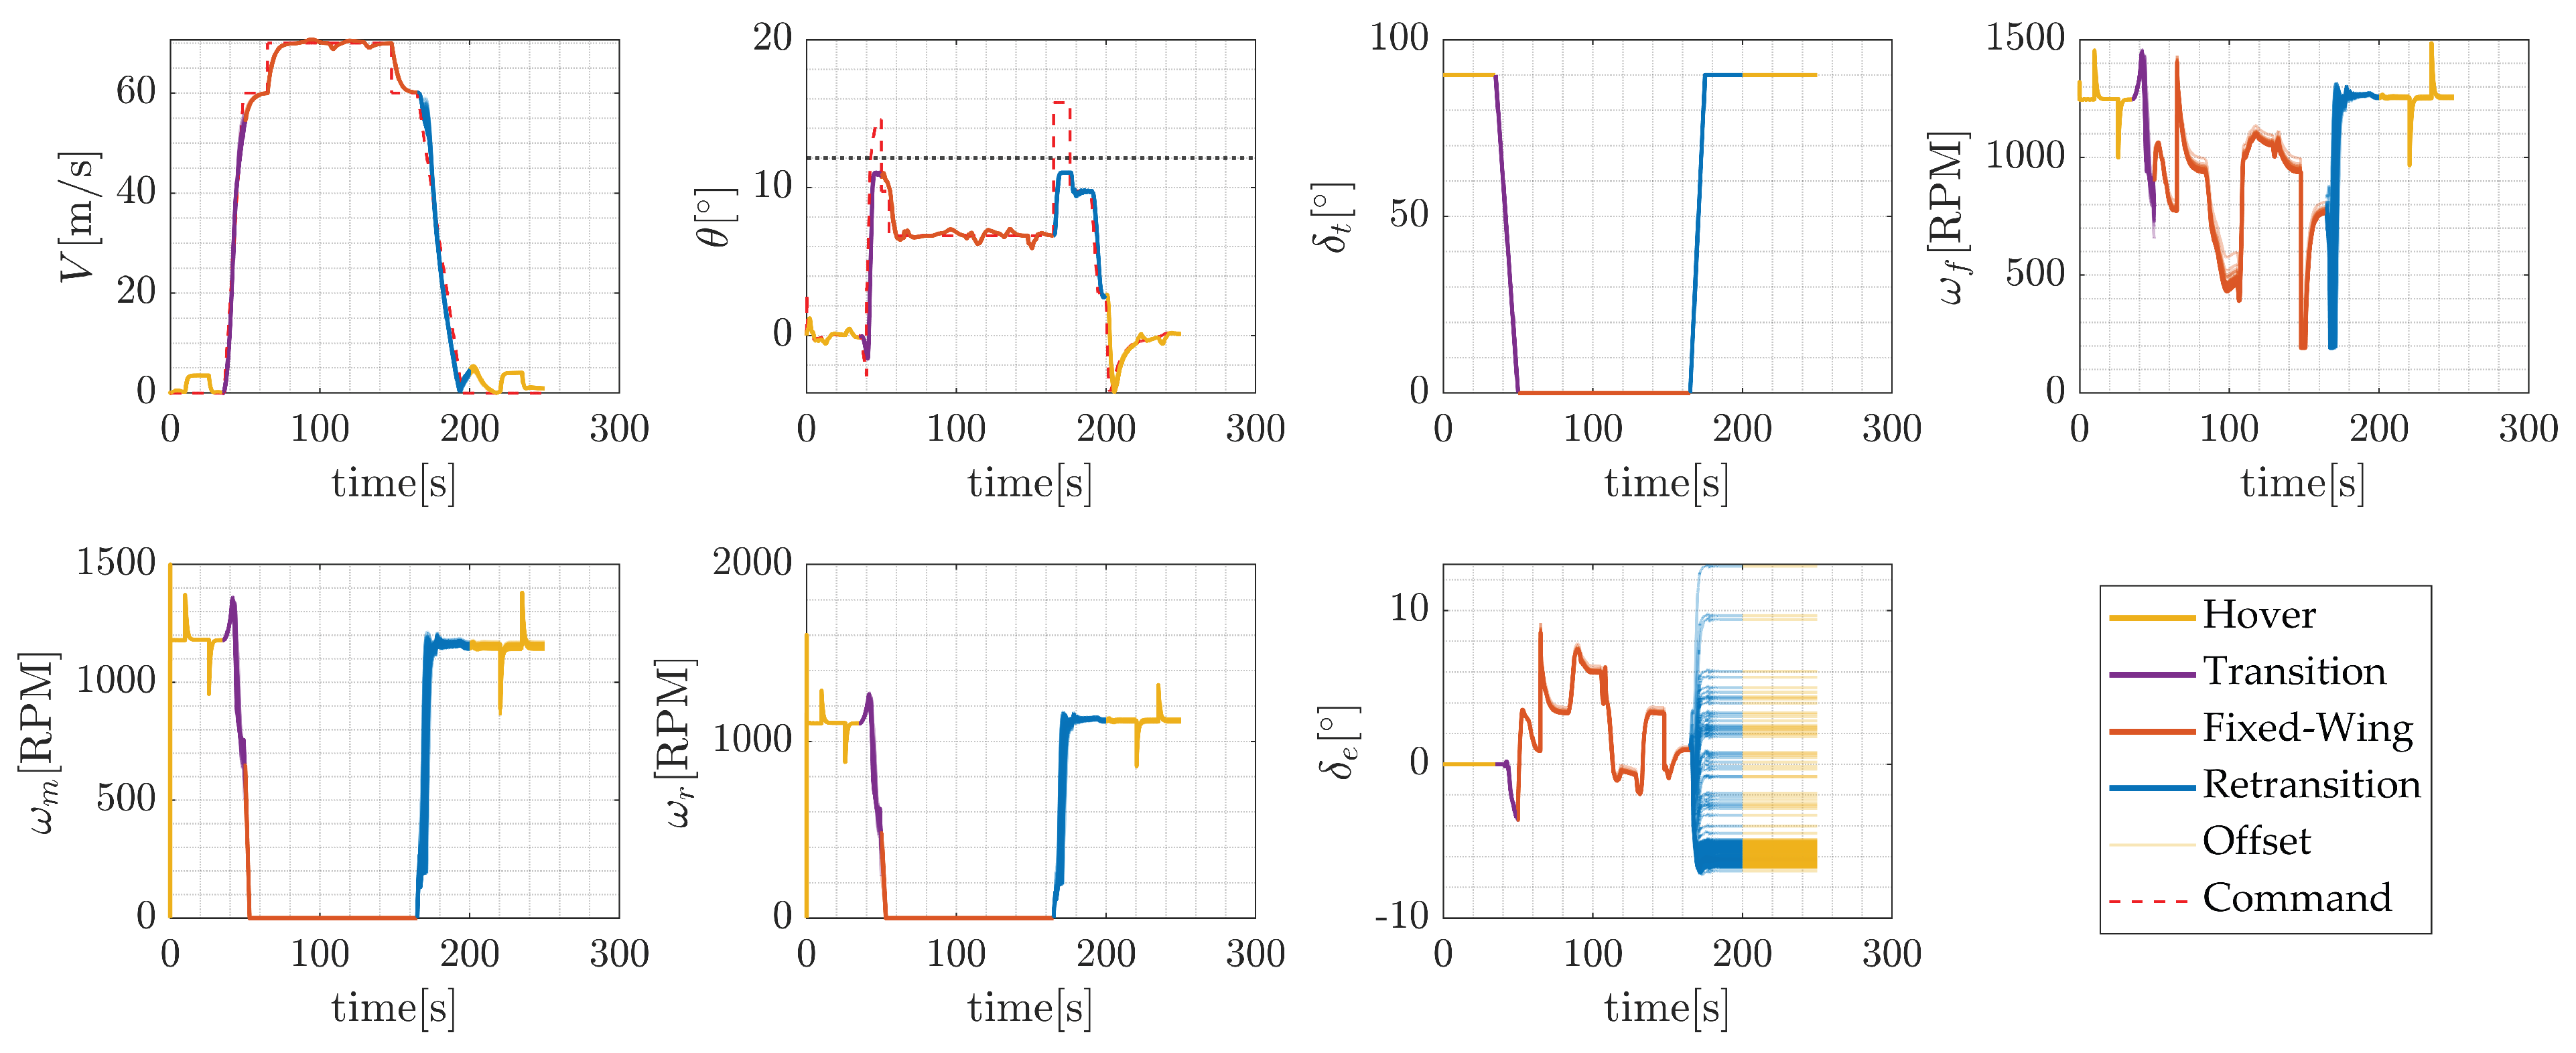
Figure 19.
Simulation results of protected PID under uncertainties.
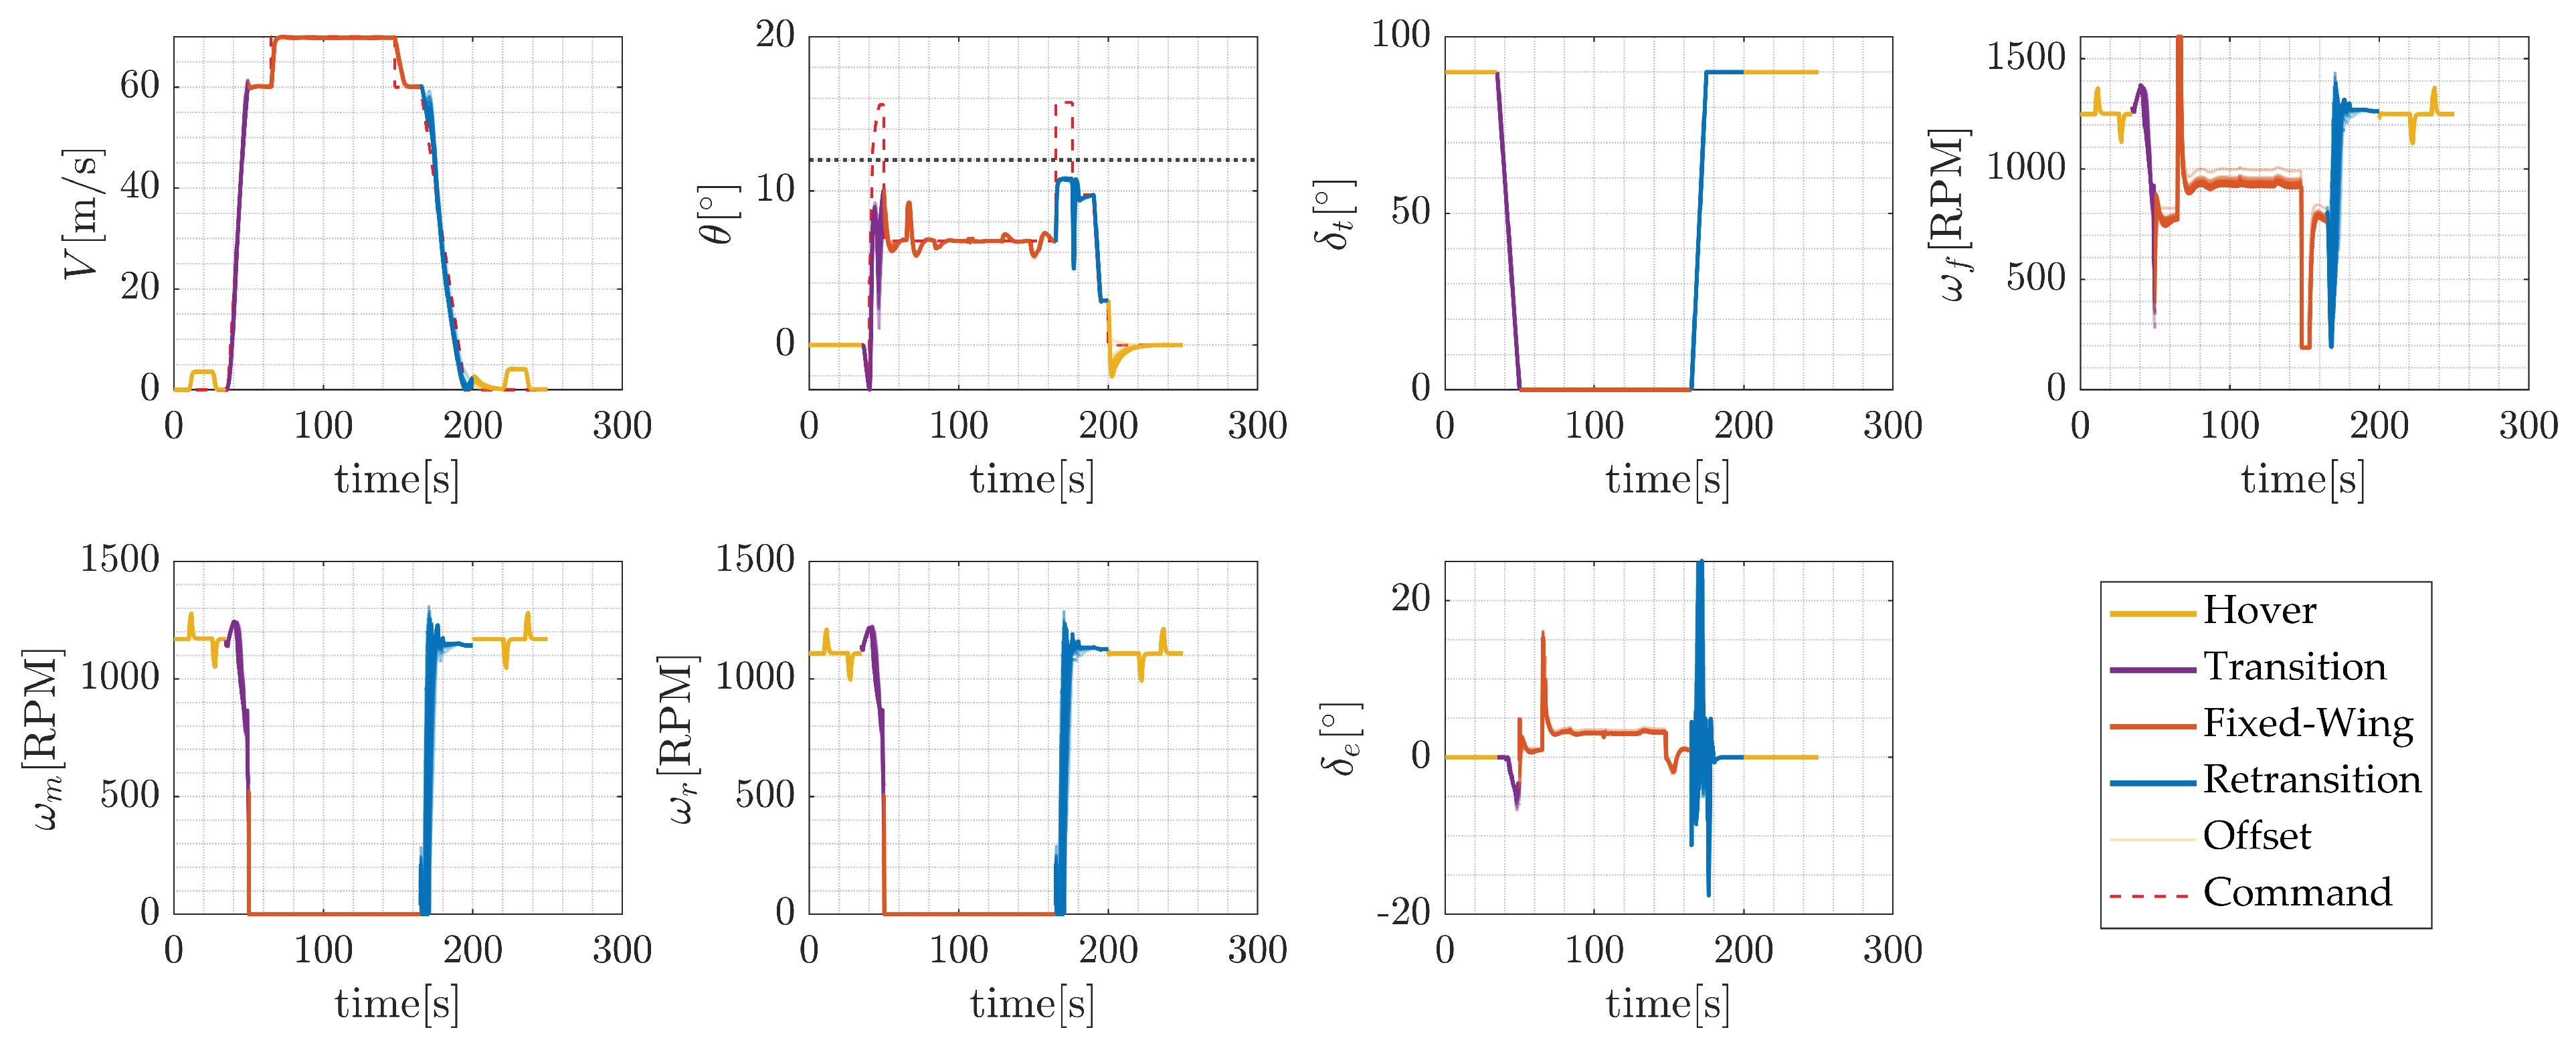
Figure 20.
Simulation results of protected INDI under measurement uncertainties.
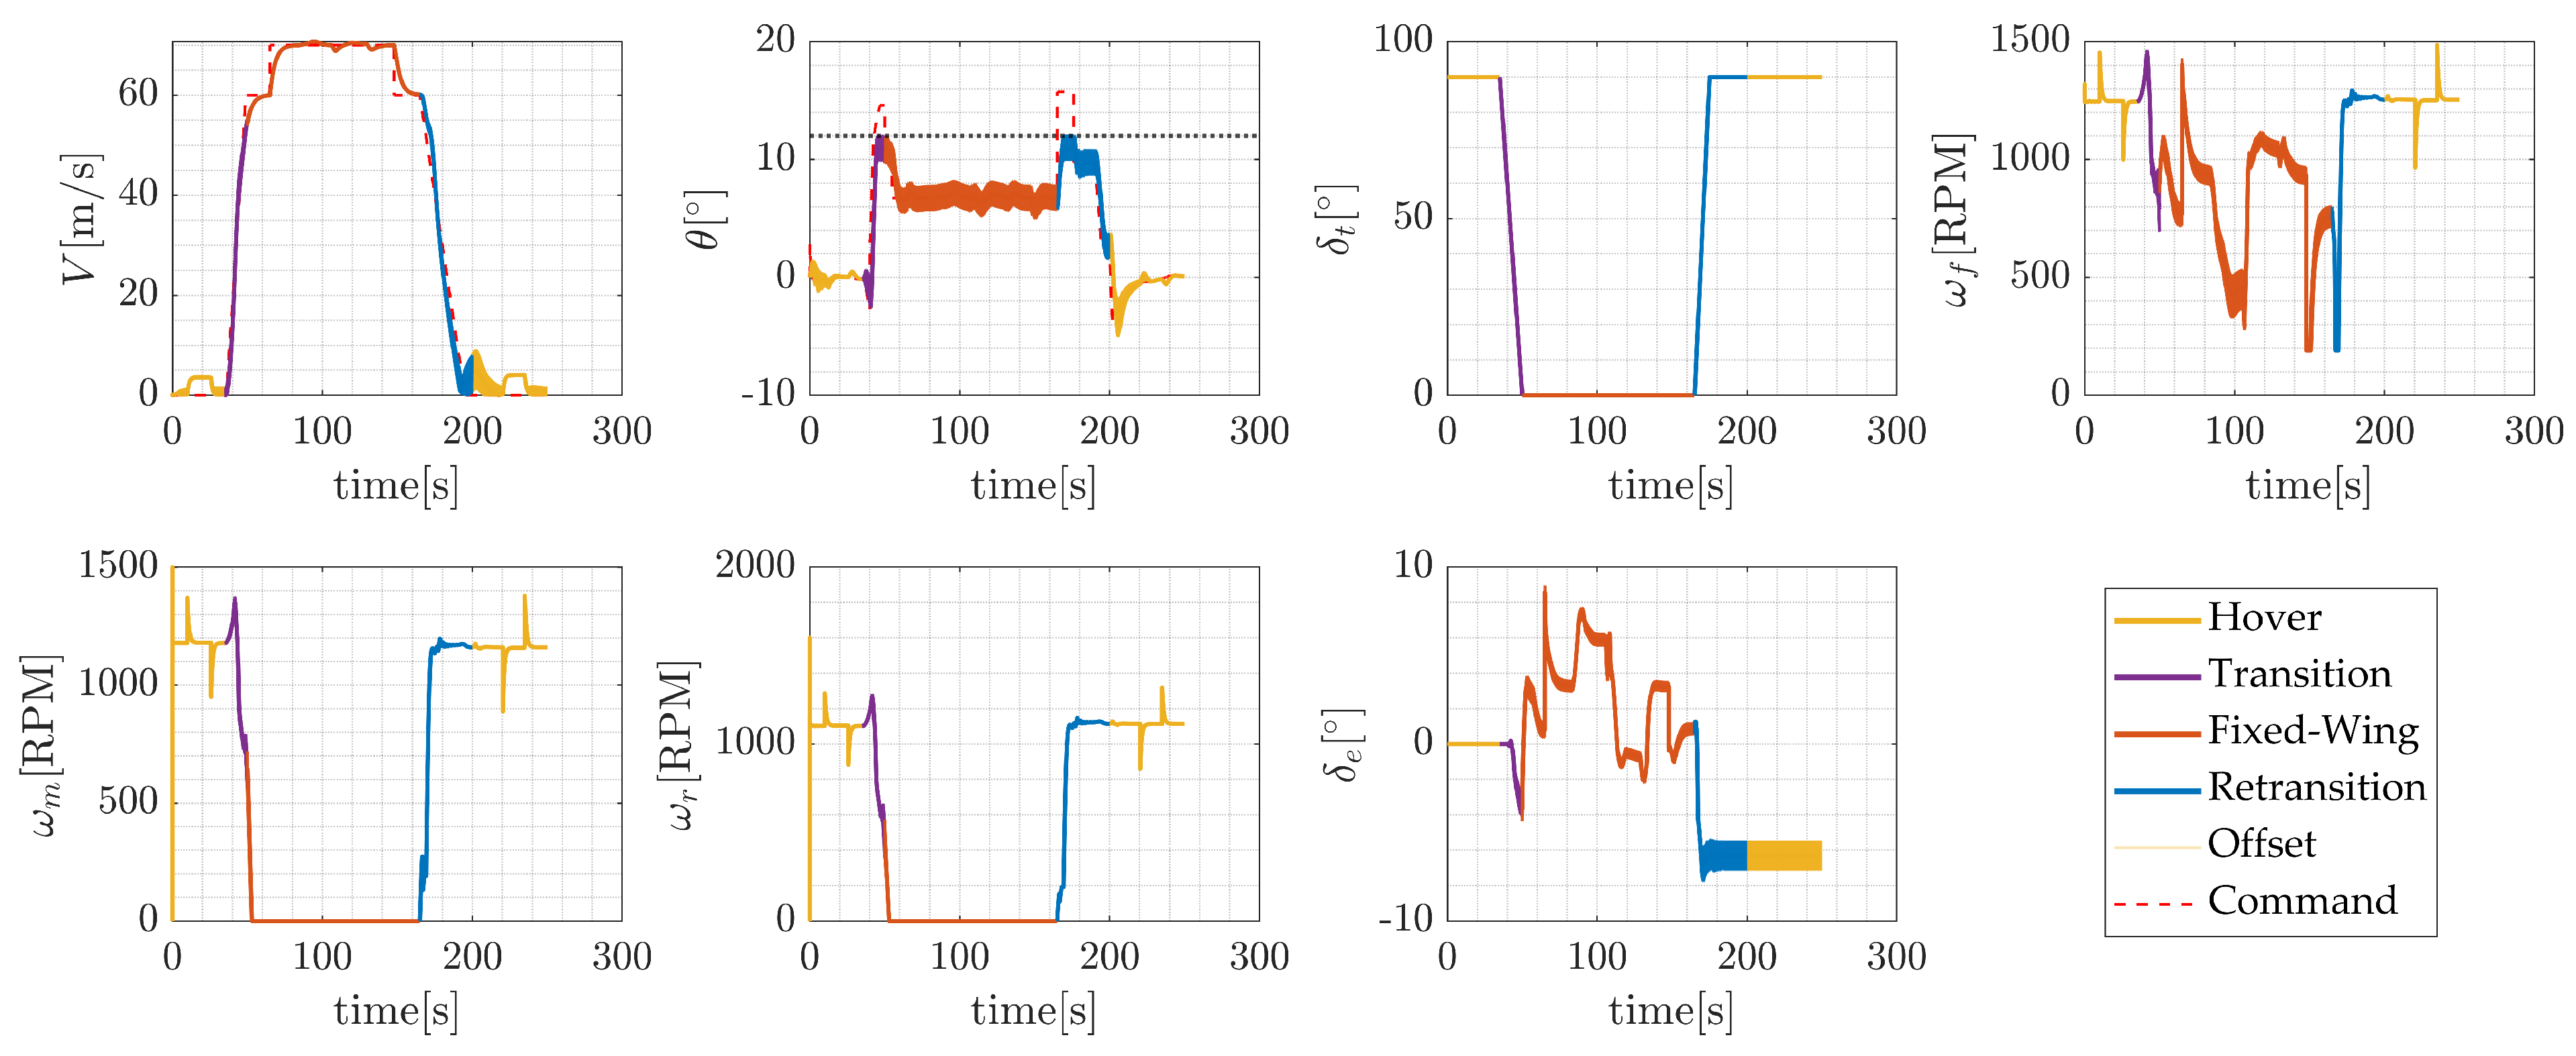
Figure 21.
Simulation results of protected PID under measurement uncertainties.
5.3. Comparison of Different Protection Strategy
The simulation task in this section follows the profile in Figure 13, with excessive pitch command injected only in forward transition.
Figure 22 demonstrates the performance of a pitch protected INDI controller. The blue line corresponds to the response without protection, which is apparently worse than the others. The red line corresponds to the maneuverability-based dynamic protection method proposed by this paper, staying between the green line which is the response with only limit and the purple and yellow line which are responses with limit and linear limit with different time constants. MB method can effectively constrain the state while fully utilizing control resources to track the command as well as possible within safe bounds. While for linear methods, different time constant selection greatly affects the protection effect, indicating that it can also achieve protecion but requires more unguided tuning workload.
6. Conclusions
This study developed a corridor-based protected control framework for tilt-wing eVTOL, including constrained corridor prediction, maneuverability-based pitch protecion and its integration with nonlinear model-based controller. The main contributions and findings of this study are summarized as follows:
- 1.
- A 6-DOF flight dynamics model of a tandemn tilt-wing eVTOL was established, incorporating aerodynamics and component-level electric propulsion dynamics. The model provides the foundation for validating tranistion corridor prediction, envelope protection and the control algorithms.
- 2.
- A corridor prediction method was proposed to ensure physical consistency. Aerodynamic, electric and propulsive constraint models consistent with practical requirements were established. Both acceleration and deceleration feasibility were considered without computationally intensive dynamic analysis. The results reveal that after incorporating these constraints, the predicted corridor reflects the practically available propulsion capability and directly provides the pitch protection boundaries.
- 3.
- A maneuverability-based protected control strategy was proposed and achieved satisfactory protection performance. The method automatically generates pitch rate and pitch angular acceleration limits according to the current control margin, rather than relying on simple linear pitch rate limitation. Nominal and perturbed profile simulations with excessive pitch commands were conducted to demonstrate stable protection performance with feasible and smooth control resource consumption.
- 4.
- The profile simulation results demonstrate that the proposed protection strategy is compatible with both conventional feedback control and model-based nonlinear control. When combined with nonlinear control methods such as INDI, it delivers better control performance with less tuning effort.
Generally speaking, the results indicate that the proposed protected control framework provides effective corridor-based protection without excessive loss of maneuverability. The study establishes a practical link between transition-corridor prediction, available maneuvering capability and closed-loop control protection for tilt-wing eVTOL transition flight.
Current work primarily focuses only on pitch protection. In addition, the robustness evalution does not yet cover comprehensive uncertainties. Future work will extend towards dynamically reachable flight boundaries, incorporate a broader range of uncertainties, disturbances and failure and generalize the protection framework to lateral-directional constraints. Furthermore, hardware-in-the-loop simulations and flight tests will be conducted to further validate the practical applicability of the proposed strategy.
References
- Milz, D.; Looye, G. Tilt-Wing Control Design for a Unified Control Concept. In Proceedings of the AIAA SCITECH 2022 Forum, San Diego, CA, USA and Virtual, January 2022. [Google Scholar]
- Joby, A. Joby Completes Piloted Electric Air Taxi Flight Across San Francisco Bay and Around the Golden Gate. Available online: https://ir.jobyaviation.com/news-events/press-releases/detail/177/joby-completes-piloted-electric-air-taxi-flight-across-sane (accessed on 13 March 2026).
- Du, S.; Zha, Y. Numerical simulation of the transition flight aerodynamics of cross-shaped quad-tiltrotor UAV. Sci. Rep. 2024, 14, 17878. [Google Scholar] [CrossRef] [PubMed]
- Erhard, R.M.; Alonso, J.J. A Comparison of Propeller Wake Models for Distributed Electric Propulsion and eVTOL Aircraft in Complex Flow Conditions. In Proceedings of the AIAA SCITECH 2022 Forum, San Diego, CA & Virtual, January 2022. [Google Scholar] [CrossRef]
- Ducard, G.J.; Allenspach, M. Review of designs and flight control techniques of hybrid and convertible VTOL UAVs. Aerosp. Sci. Technol. 2021, 118, 107035. [Google Scholar] [CrossRef]
- Hsu, T.W.; Choi, J.J.; Amin, D.; Tomlin, C.; McWherter, S.C.; Piedmonte, M. Towards Flight Envelope Protection for the NASA Tiltwing eVTOL Flight Mode Transition Using Hamilton-Jacobi Reachability. J. Am. Helicopter Soc. 2024, 69, 1–18. [Google Scholar] [CrossRef]
- Liang, Z.; Yang, X.; Liu, D.; Hou, Z.; Fan, L. Multi-objective constrained tilt corridor and transition trajectory strategy of a compound tilt-rotor UAV. Chin. J. Aeronaut. 2025, 103898. [Google Scholar] [CrossRef]
- May, M.S.; Milz, D.; Armanini, S.F. Transition Corridor Estimation for a Tilt-Wing Aircraft with Optimal Control-based Reachability Analysis. In Proceedings of the AIAA SCITECH 2026 Forum, Orlando, FL, January 2026. [Google Scholar] [CrossRef]
- Yue, H.; Gao, Z.; Liu, P.; Wang, Z.; Li, J.; Shao, X.; Li, S.; Zhao, W. Transition planning and control methods for a tilt-wing VTOL UAV: From hardware design to flight validation. Aerosp. Sci. Technol. 2026, 168, 111265. [Google Scholar] [CrossRef]
- Kang, N.; Lu, L.; Whidborne, J. Energy Optimization Strategies for Automatic Tiltrotor eVTOL Aircraft. J. Guid. Dyn. 2025. [Google Scholar] [CrossRef]
- May, M.S.; Milz, D.; Looye, G. Transition Strategies for Tilt-Wing Aircraft. In Proceedings of the AIAA SCITECH 2024 Forum, Orlando, FL, January 2024. [Google Scholar] [CrossRef]
- EPIC. Managing Range and Endurance of Battery Electric Aircraft; 2023.
- Choi, S.; Kang, Y.; Chang, S.; Koo, S.; Kim, J.M. Development and Conversion Flight Test of a Small Tiltrotor Unmanned Aerial Vehicle. J. Aircr. 2010, 47, 730–732. [Google Scholar] [CrossRef]
- Ogden, N.C.; Patterson, A. A Framework for Evaluating Distributed Electric Propulsion on the SUSAN Electrofan Aircraft. Number NASA/TM–20230009523. 2023.
- Lu, Z.; Zhang, J.; Li, H.; Holzapfel, F. An Adaptive Command Scaling Method for Incremental Flight Control Allocation. Actuators 2025, 14, 579. [Google Scholar] [CrossRef]
- Han, L.; Zhang, P.; Wang, Y.; Bian, Y.; Hu, J. A Computational Method for the Nonlinear Attainable Moment Set of Tailless UAVs in Flight-Control-Oriented Scenarios. Drones 2025, 9, 585. [Google Scholar] [CrossRef]
- May, M.S.; Milz, D.; Looye, G. Towards the Determination of the Dynamic Transition Corridor for Tandem Tilt-Wing Aircraft. In Proceedings of the AIAA AVIATION FORUM AND ASCEND 2024, Las Vegas, Nevada, July 2024. [Google Scholar] [CrossRef]
- Chauhan, S.S.; Martins, J.R.R.A. Tilt-Wing eVTOL Takeoff Trajectory Optimization. J. Aircr. 2020, 57, 93–112. [Google Scholar] [CrossRef]
- Kikumoto, C.; Urakubo, T.; Sabe, K.; Hazama, Y. Analysis and Enhancement of Steady Climb Performance with Control Input Redundancy for a Dual-Propulsion VTOL UAV. Aerospace 2026, 13, 316. [Google Scholar] [CrossRef]
- Li, W.; Cheng, R.; Huang, H.; Garg, A.; Gao, L. Energy consumption modeling and optimization of an eVTOL aircraft: Integrating weight, motor, and battery dynamics. Energy 2025, 325, 136229. [Google Scholar] [CrossRef]
- Wang, M.; Li, X.; Zhang, S. A Cascaded trim method of electric aircraft subject to propulsive constraints in wing-borne flight. Aerosp. Sci. Technol. 2026, 171, 111589. [Google Scholar] [CrossRef]
- May, M.; Milz, D.; Armanini, S.F. An Optimal Control Approach for Harmonizing Tilt-Wing Design and Operations. Aerospace Systems 2026. [Google Scholar] [CrossRef]
- Lombaerts, T.; Looye, G.; Ellerbroek, J.; Rodriguez, Y.; Martin, M. Design and Piloted Simulator Evaluation of Adaptive Safe Flight Envelope Protection Algorithm. In Proceedings of the AIAA Guidance, Navigation, and Control Conference, San Diego, California, USA, January 2016. [Google Scholar] [CrossRef]
- Gabrys, A.C.; Steffensen, R.; Cordeiro, R.D.A.; Azinheira, J.R.; Moutinho, A.; Holzapfel, F. Integration of Phase Plane Flight Envelope Protections in Cascaded Incremental Flight Control. IFAC-PapersOnLine 2019, 52, 429–435. [Google Scholar] [CrossRef]
- Bhardwaj, P.; Holzapfel, F. Unified Trajectory Control for Vertical Take-Off and Landing Transition Aircraft. In Proceedings of the AIAA AVIATION FORUM AND ASCEND 2024, Las Vegas, Nevada, July 2024. [Google Scholar] [CrossRef]
- Milz, D.; May, M.S.; Armanini, S.F.; Looye, G. Stability and Robustness of a Tandem Tilt-Wing VTOL With Dynamic Inversion Control Laws. In Proceedings of the AIAA SCITECH 2026 Forum, Orlando, FL, January 2026. [Google Scholar] [CrossRef]
- Binz, F.; Islam, T.; Moormann, D. Attitude control of tiltwing aircraft using a wing-fixed coordinate system and incremental nonlinear dynamic inversion. 2019, 11, 1756829319861370. [Google Scholar] [CrossRef]
- Stougie, J.; Pollack, T.; Van Kampen, E.J. Incremental Nonlinear Dynamic Inversion control with Flight Envelope Protection for the Flying-V. In Proceedings of the AIAA SCITECH 2024 Forum, Orlando, FL, January 2024. [Google Scholar] [CrossRef]
- Sun, D.; Li, X.; Jafarnejadsani, H.; Hovakimyan, N. A Flight Envelope Protection Method Based on Potential Functions. In Proceedings of the AIAA Guidance, Navigation, and Control Conference, Grapevine, Texas, January 2017. [Google Scholar] [CrossRef]
- Altunkaya, E.Ç.; Çatak, A.; Koyuncu, E.; Özkol, İ. Loss-of-Control Prevention of an Agile Aircraft: Dynamic Command Saturation Approach. J. Guid. Control Dyn. 2025, 48, 424–436. [Google Scholar] [CrossRef]
- Lu, Z.; Zhang, J.; Li, H.; Holzapfel, F. A virtual command protection strategy for pseudo-inverse flight control allocation. Aerosp. Sci. Technol. 2026, 168, 111134. [Google Scholar] [CrossRef]
- Huang, Q.; He, G.; Jia, J.; Hong, Z.; Yu, F. Numerical Simulation on Aerodynamic Characteristics of Transition Section of Tilt-Wing Aircraft. Aerospace 2024, 11, 283. [Google Scholar] [CrossRef]
- Enenakpogbe, E.; Whidborne, J.F.; Lu, L. Full Envelope Control of Over-Actuated Fixed-Wing Vectored Thrust eVTOL. Aerospace 2024, 11, 979. [Google Scholar] [CrossRef]
- Wang, M.; Diepolder, J.; Zhang, S.; Söpper, M.; Holzapfel, F. Trajectory optimization-based maneuverability assessment of eVTOL aircraft. Aerosp. Sci. Technol. 2021, 117, 106903. [Google Scholar] [CrossRef]
- Wang, M.; Luiz, S.O.D.; Zhang, S.; Lima, A.M.N. Desensitized Optimal Control of Electric Aircraft Subject to Electrical–Thermal Constraints. IEEE Trans. Transp. Electrif. 2022, 8, 4190–4204. [Google Scholar] [CrossRef]
- Panish, L.; Bacic, M. Tiltwing eVTOL Transition Trajectory Optimization. J. Aircr. 2025, 62, 81–93. [Google Scholar] [CrossRef]
- Jamaluddin, N.S.; Celik, A.; Baskaran, K.; Rezgui, D.; Azarpeyvand, M. Aerodynamic noise analysis of tilting rotor in edgewise flow conditions. J. Sound Vib. 2024, 582, 118423. [Google Scholar] [CrossRef]
- Sanchez-Carmona, A.; Sznajdrowicz-Rebisz, K.; Dominguez-Tuya, A.; Balsalobre-Alvarez, C.; Gandia-Aguera, F.; Cuerno-Rejado, C. Multi-Point Design of Optimal Propellers for Remotely Piloted Aircraft Systems. Aerospace 2025, 12, 860. [Google Scholar] [CrossRef]
- Milz, D.; May, M.; Looye, G. Tandem Tilt-Wing Control Law Design Using Hybrid Nonlinear Dynamic Inversion. J. Guid. Control Dyn. 2026, 49, 1566–1574. [Google Scholar] [CrossRef]
- Bhardwaj, P.; Raab, S.A.; Zhang, J.; Holzapfel, F. Integrated Reference Model for a Tilt-Rotor Vertical Take-Off and Landing Transition UAV. In Proceedings of the 2018 Applied Aerodynamics Conference, Atlanta, GA, USA, June 2018. [Google Scholar]
- Bhardwaj, P.; Raab, S.A.; Holzapfel, F. Higher Order Reference Model for Continuous Dynamic Inversion Control. In Proceedings of the AIAA Scitech 2021 Forum, VIRTUAL EVENT, January 2021. [Google Scholar] [CrossRef]
- United States Army Aviation and Missile Command Aviation Engineering Directorate. Aeronautical Design Standard, Performance Specification: Handling Qualities Requirements for Military Rotorcraft. ADS-33E-PRF, 2000.
- of Defense US Department. Flying Qualities of Piloted Aircraft, 1997.
- Li, X.; Xiong, Z.; Zhang, S. INDI Application in Flight Control Law Design of Civil Aircraft. J. Phys. Conf. Ser. 2025, 3044, 012002. [Google Scholar] [CrossRef]
- Halder, A.; Gandhi, F. Battery Aging Studies Under UAM Usage; West Palm Beach, FL, USA, May 2026. [Google Scholar] [CrossRef]
- SiCore. Redefining electric mobility with SiCore batteries. Available online: https://amprius.com/solutions/sicore/ (accessed on 28 September 2026).
- Díaz García, G.; Seiferth, D.; Meidinger, V.; Dollinger, D.; Nagarajan, P.; Holzapfel, F. Conduction of Mission Task Elements within Simulator Flight Tests for Handling Quality Evaluation of an eVTOL Aircraft. In Proceedings of the AIAA Scitech 2021 Forum, VIRTUAL EVENT, January 2021. [Google Scholar] [CrossRef]
- Zhao, Q.; Zhou, Z.; Wang, R. Modeling and Transition Flight Control of Distributed Propulsion–Wing VTOL UAV with Induced Wing Configuration. Aerospace 2024, 11, 922. [Google Scholar] [CrossRef]
- Autenrieb, J.; Shin, H. Complementary Filter-Based Incremental Nonlinear Model Following Control Design for a Tilt-Wing UAV. Int. J. Robust. Nonlinear Control 2025, 35, 1596–1615. [Google Scholar] [CrossRef]
- Wang, M.; Zhang, S.; Holzapfel, F.; Löbl, D.; Hellmundt, F. Probabilistic Assessment of a Safety-Critical Backup Controller by Subset Simulation. J. Guid. Control Dyn. 2019, 42, 1146–1156. [Google Scholar] [CrossRef]
- Wang, F.; Wang, P.; Deng, H.; Chen, B. Nonlinear Dynamic Inversion Control of VTOL Tilt-Wing UAV. In Proceedings of the 2018 Eighth International Conference on Instrumentation & Measurement, Computer, Communication and Control (IMCCC), Harbin, China, July 2018; pp. 1170–1174. [Google Scholar] [CrossRef]
- Mansoor, S.; Bhatti, U.I.; Bhatti, A.I.; Ali, S.M.D. Improved attitude determination by compensation of gyroscopic drift by use of accelerometers and magnetometers. Measurement 2019, 131, 582–589. [Google Scholar] [CrossRef]
- Technology, V. VectorNav’s VN-100 IMU/AHRS, the world’s most trusted surface mount solution. Available online: https://www.vectornav.com/products/detail/vn-100?utm_source=chatgpt.com (accessed on 28 September 2026).
- Shen, N.; Wang, X. Robustness Evaluation of Modern Fighter Aircraft Control System. Comput. Meas. Control 2011, 19, 350–353. [Google Scholar] [CrossRef]
Figure 1.
Exemplary tandem tilt-wing eVTOL in transition flight.
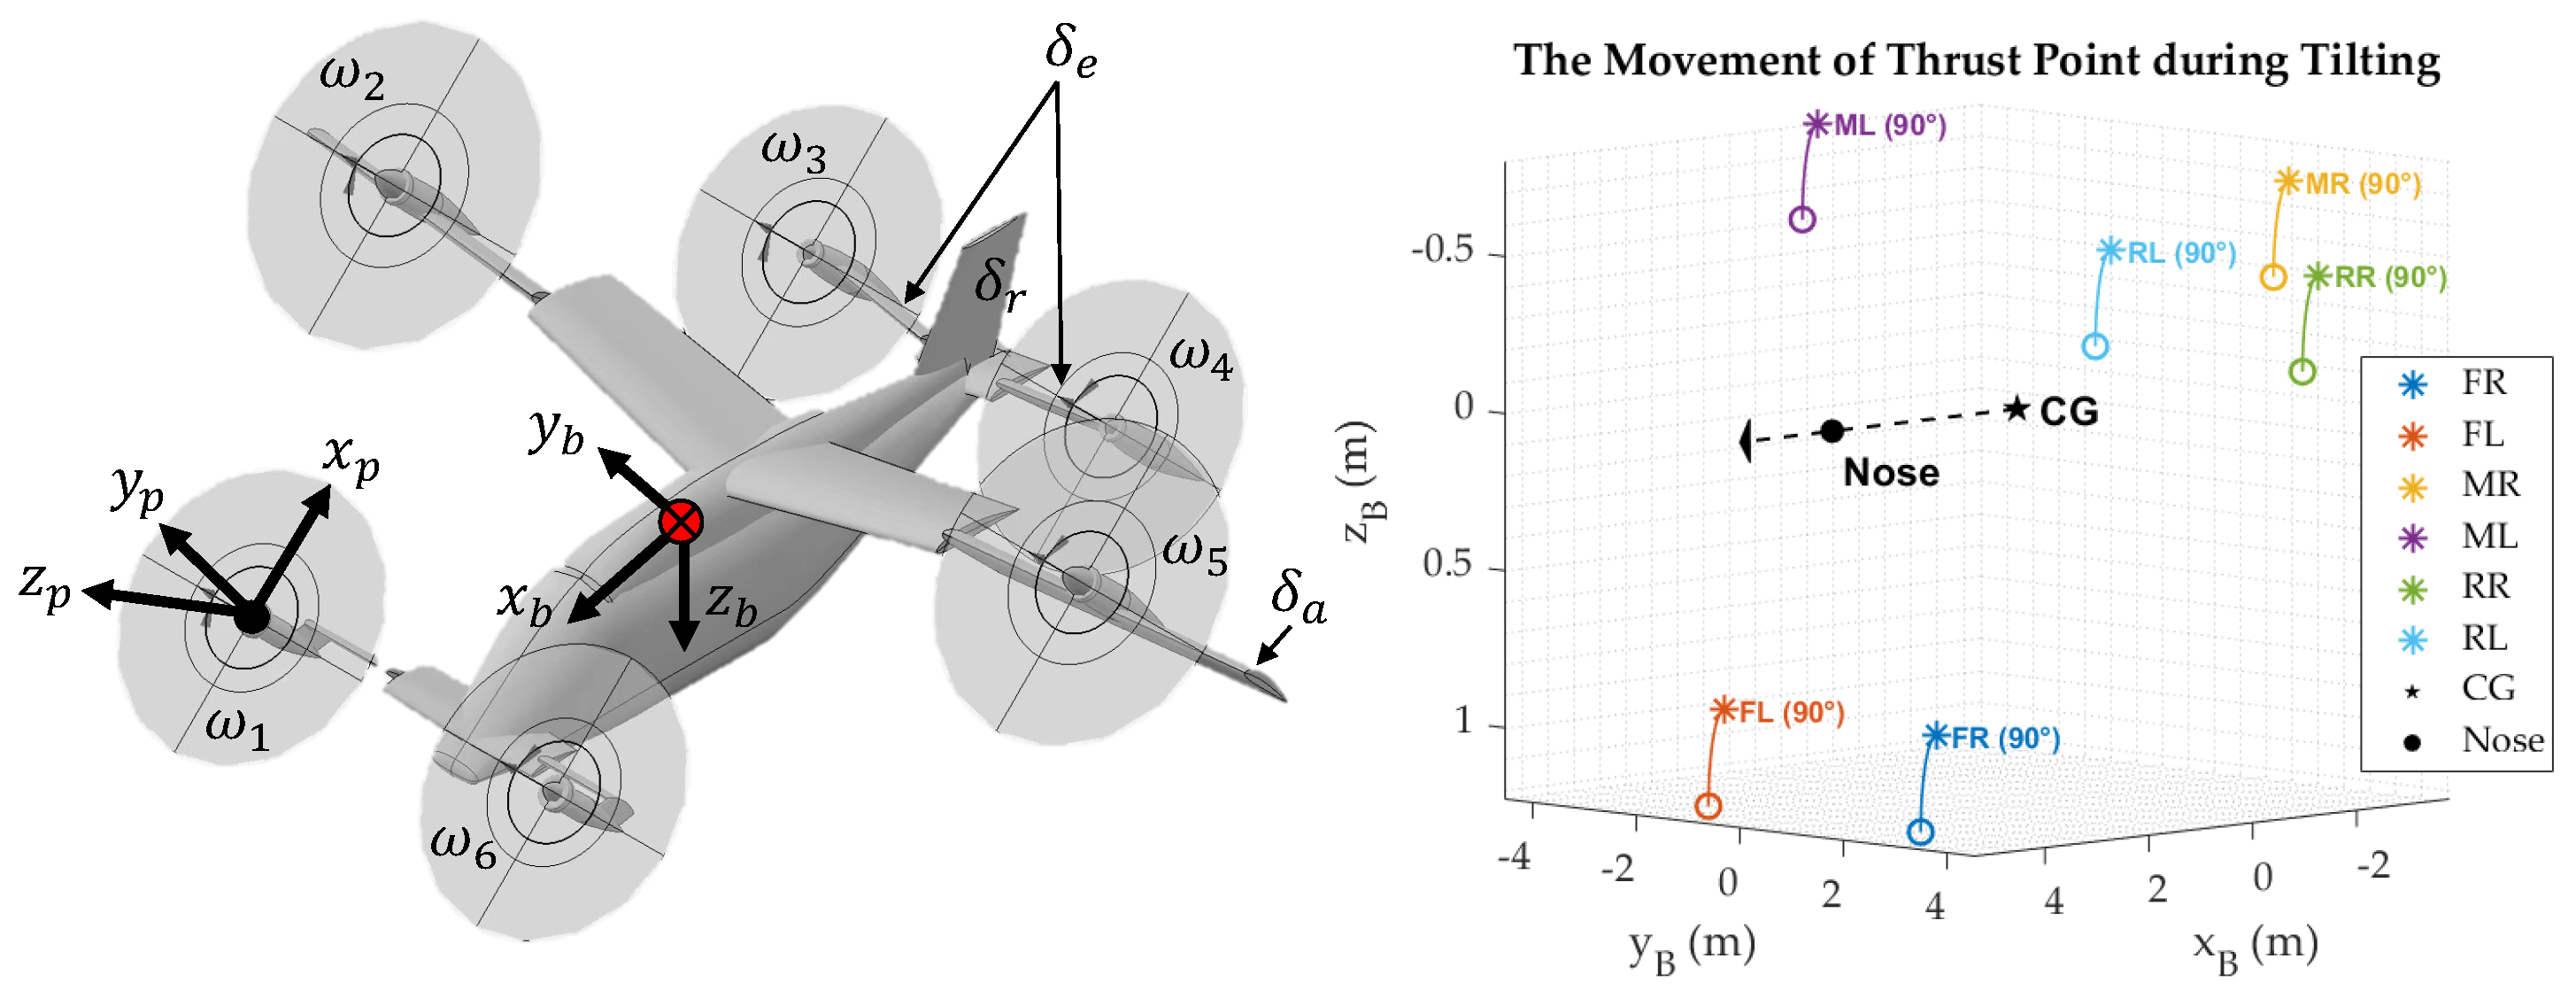
Figure 2.
Blending coefficient variation with tilt angle.
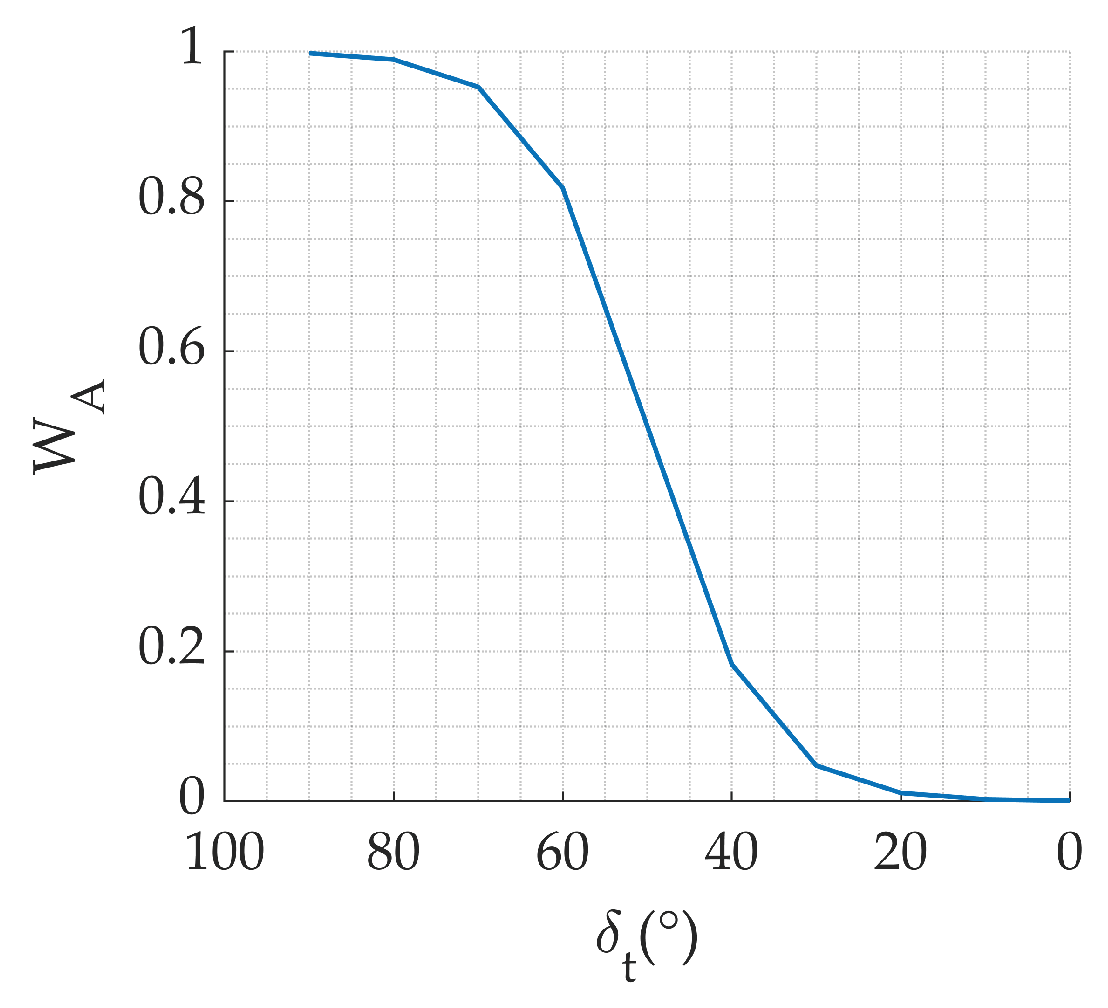
Figure 3.
Transition aerodynamics: (a) Variation of with ; (b) Variation of with .
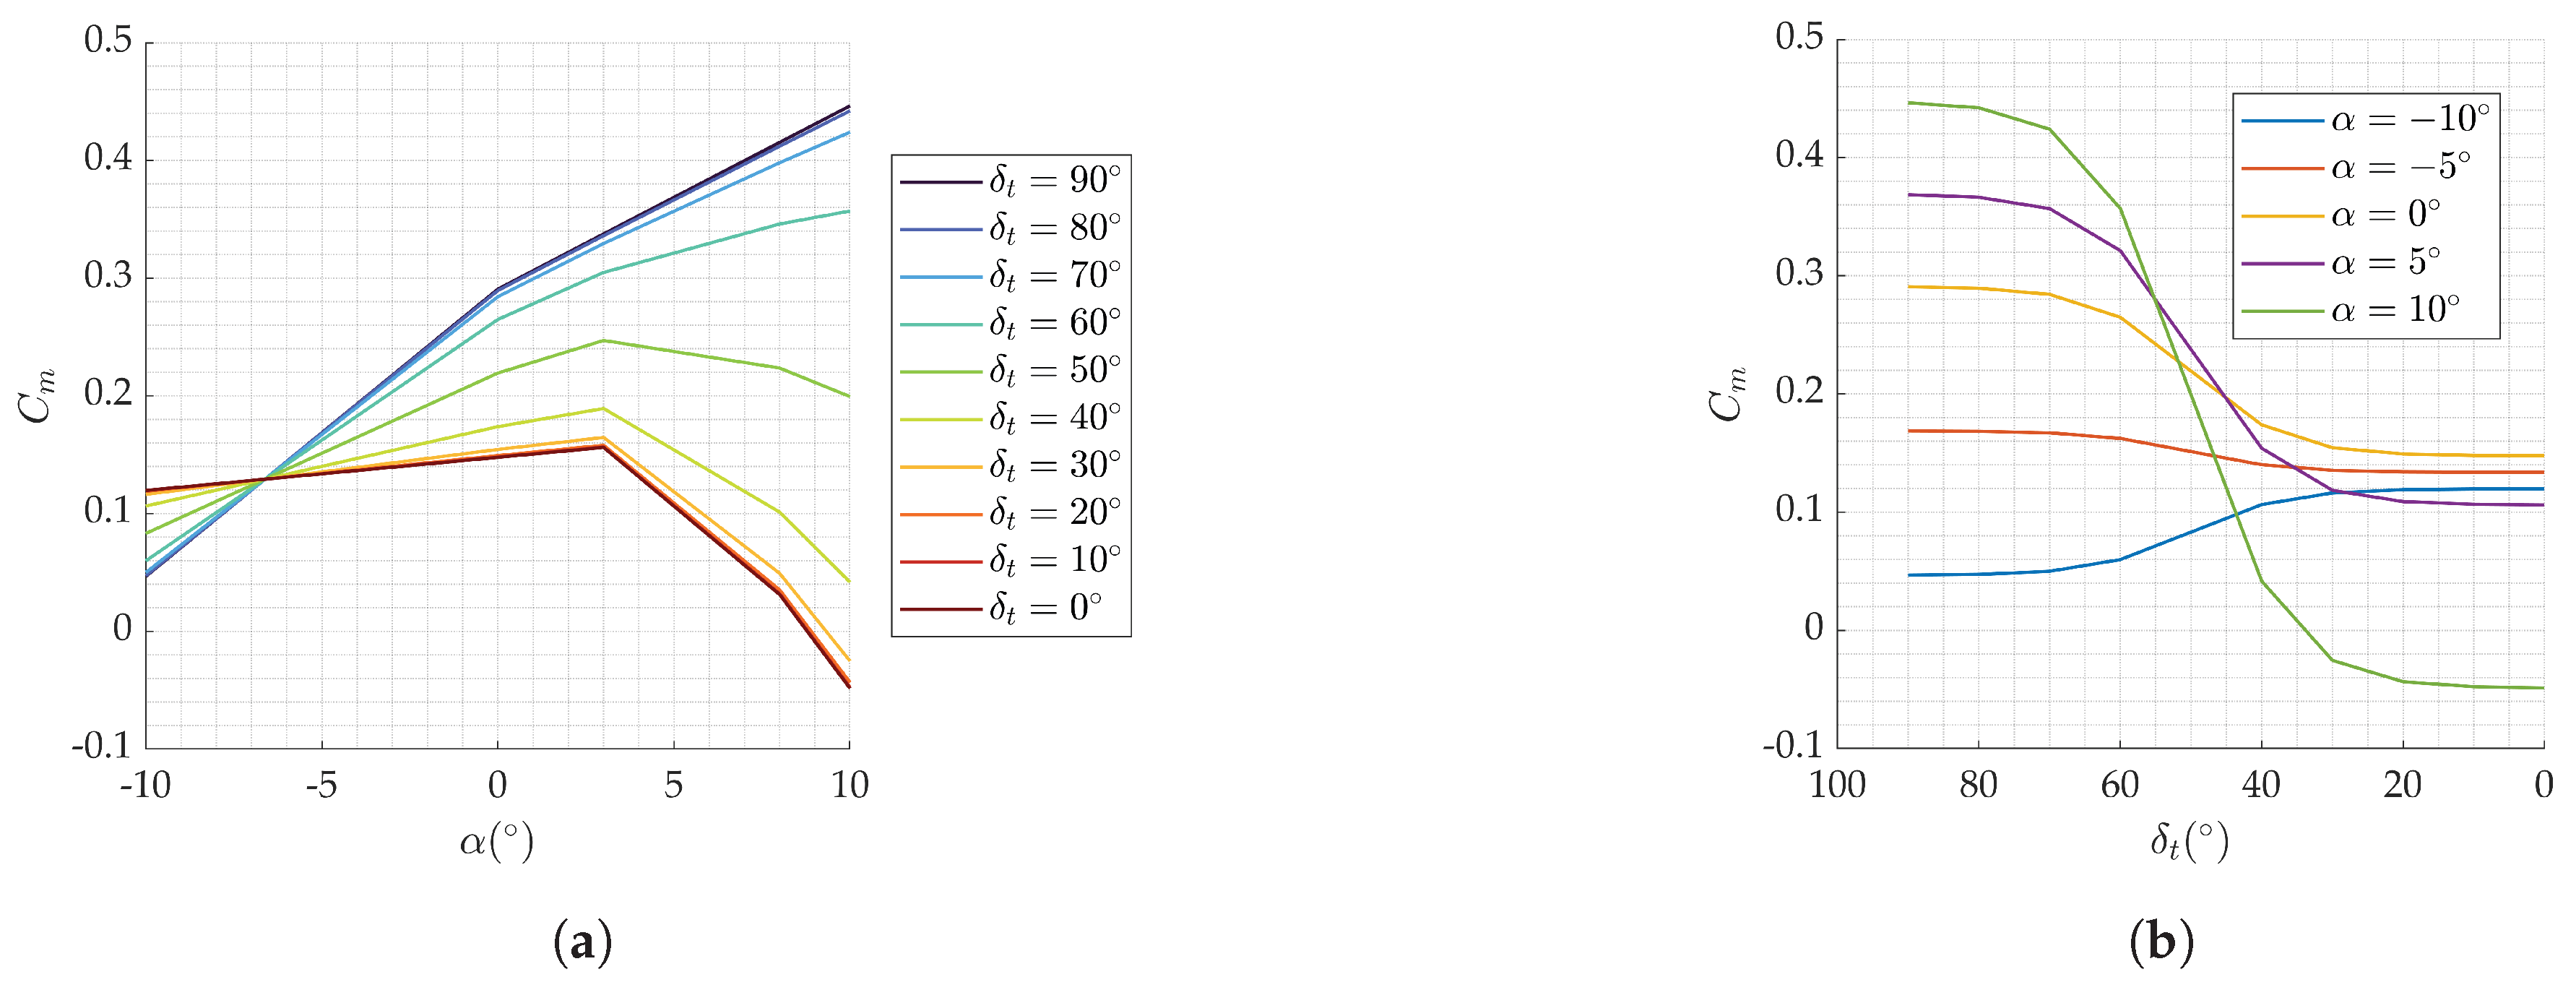
Figure 4.
Multi-loop unified controller structure.
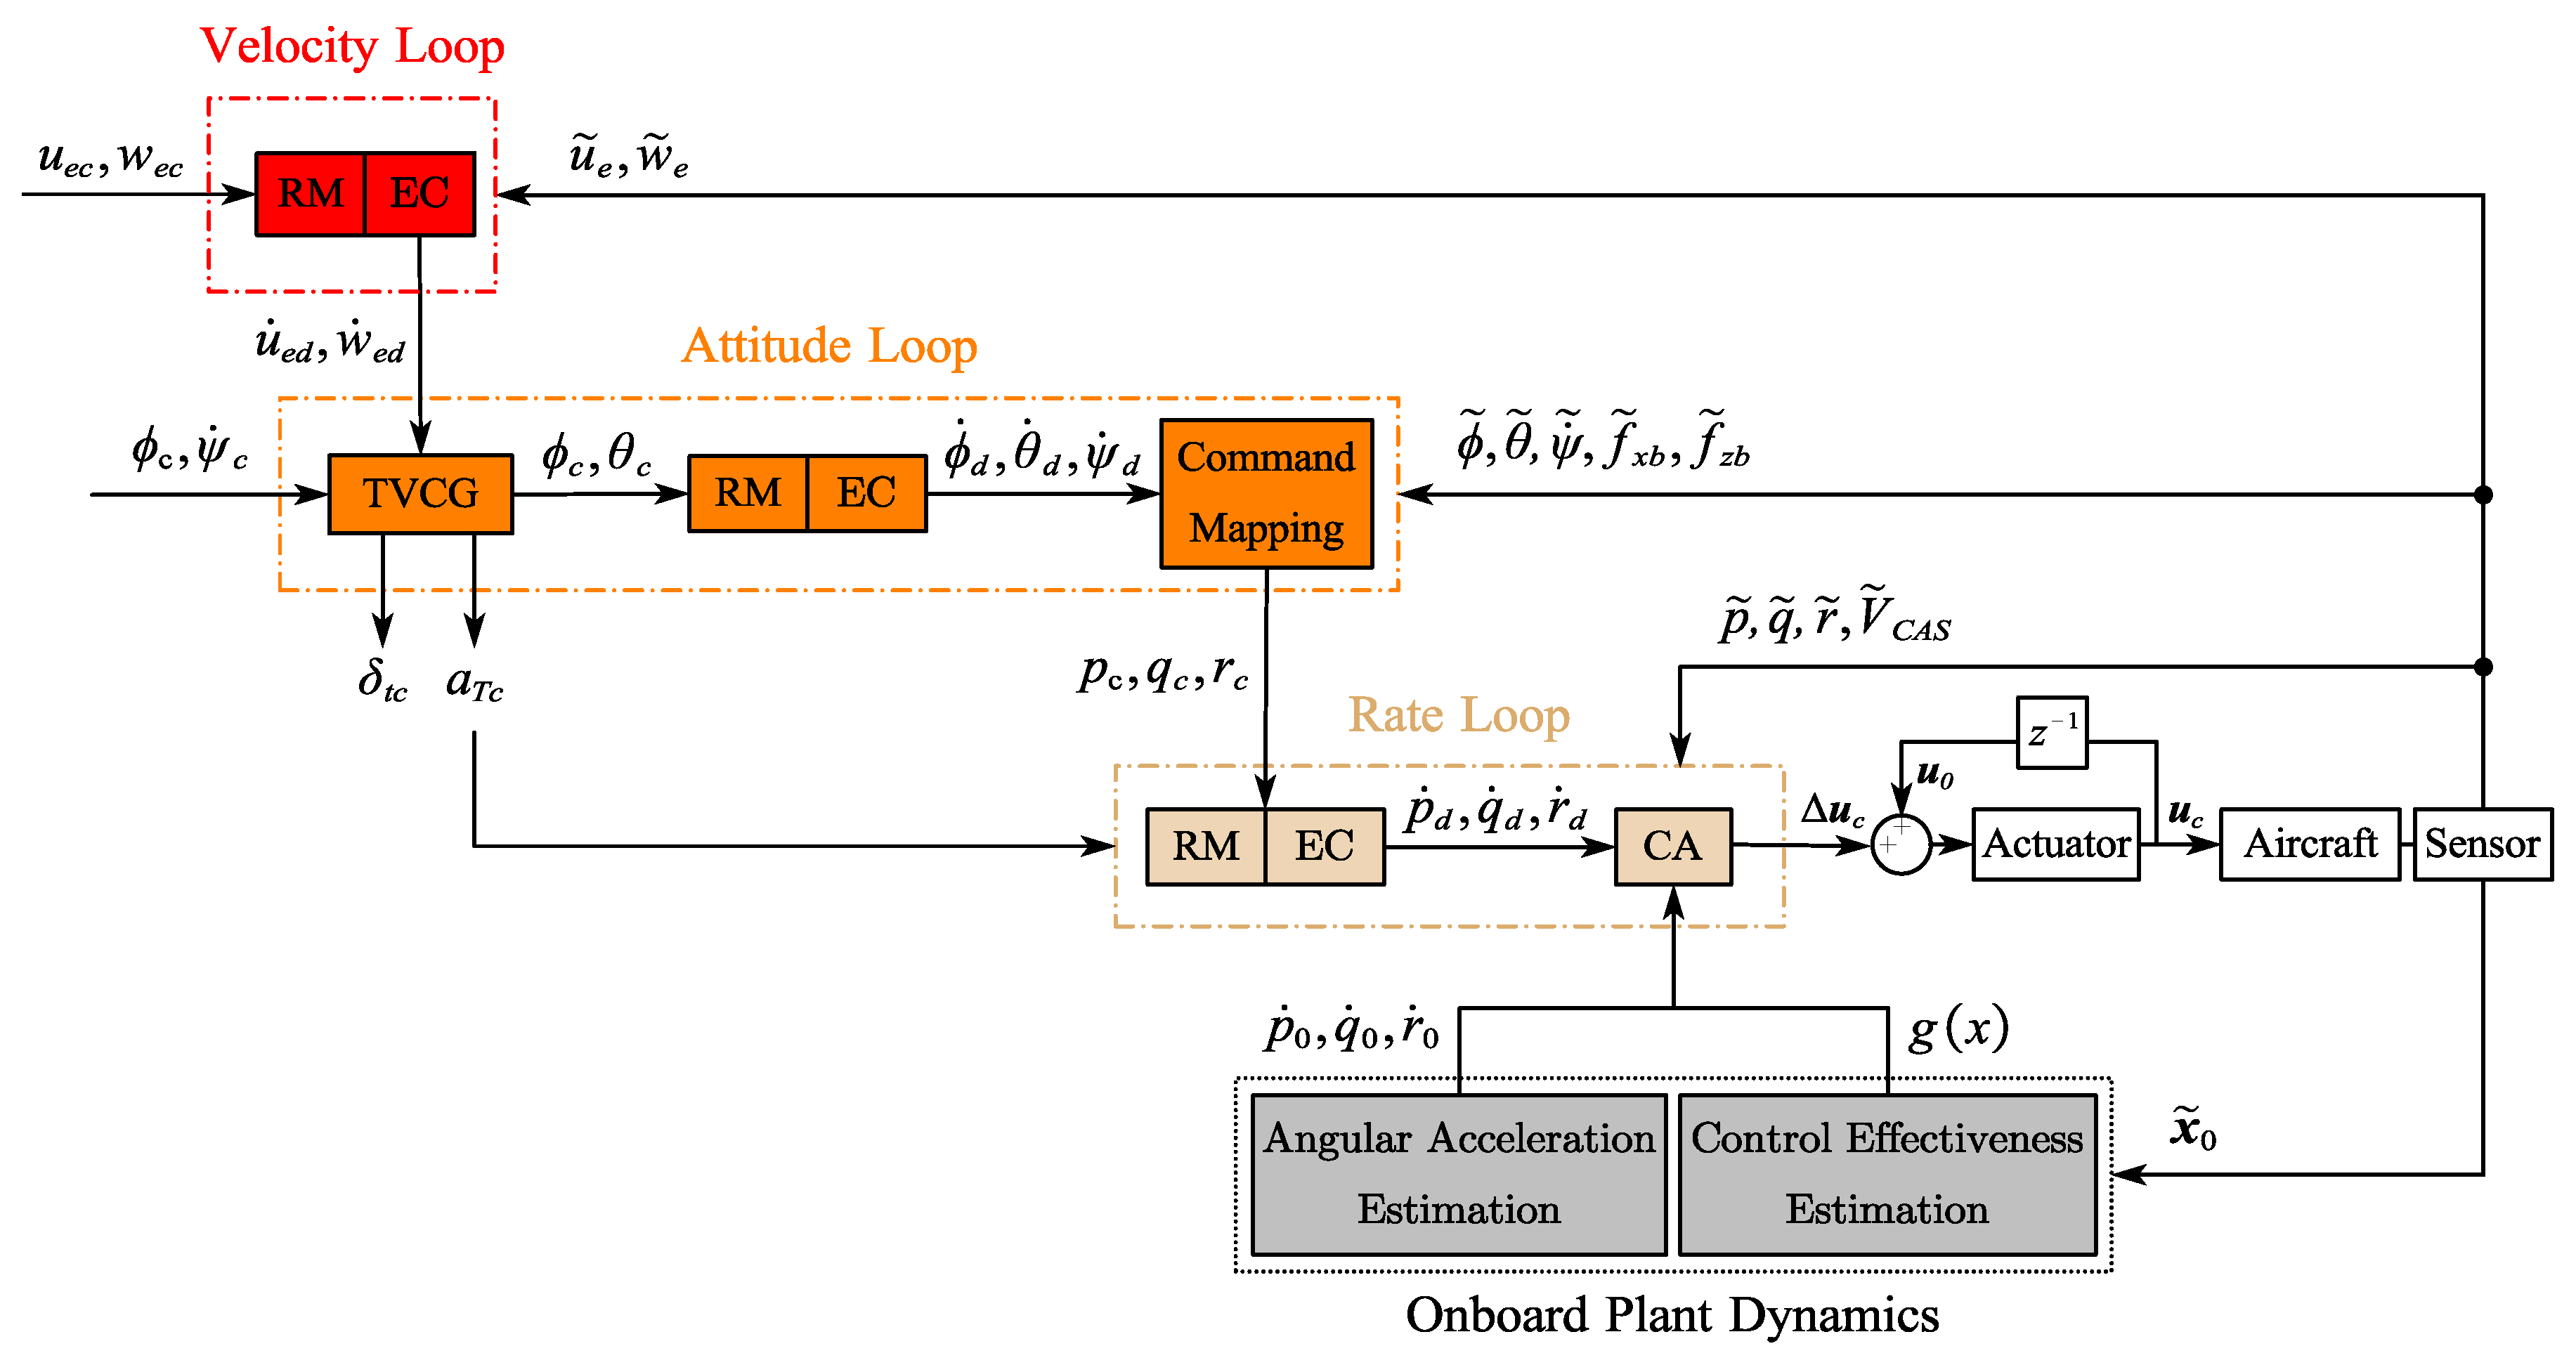
Figure 5.
Reference model structure: (a) Reference Model; (b) Reference Model.
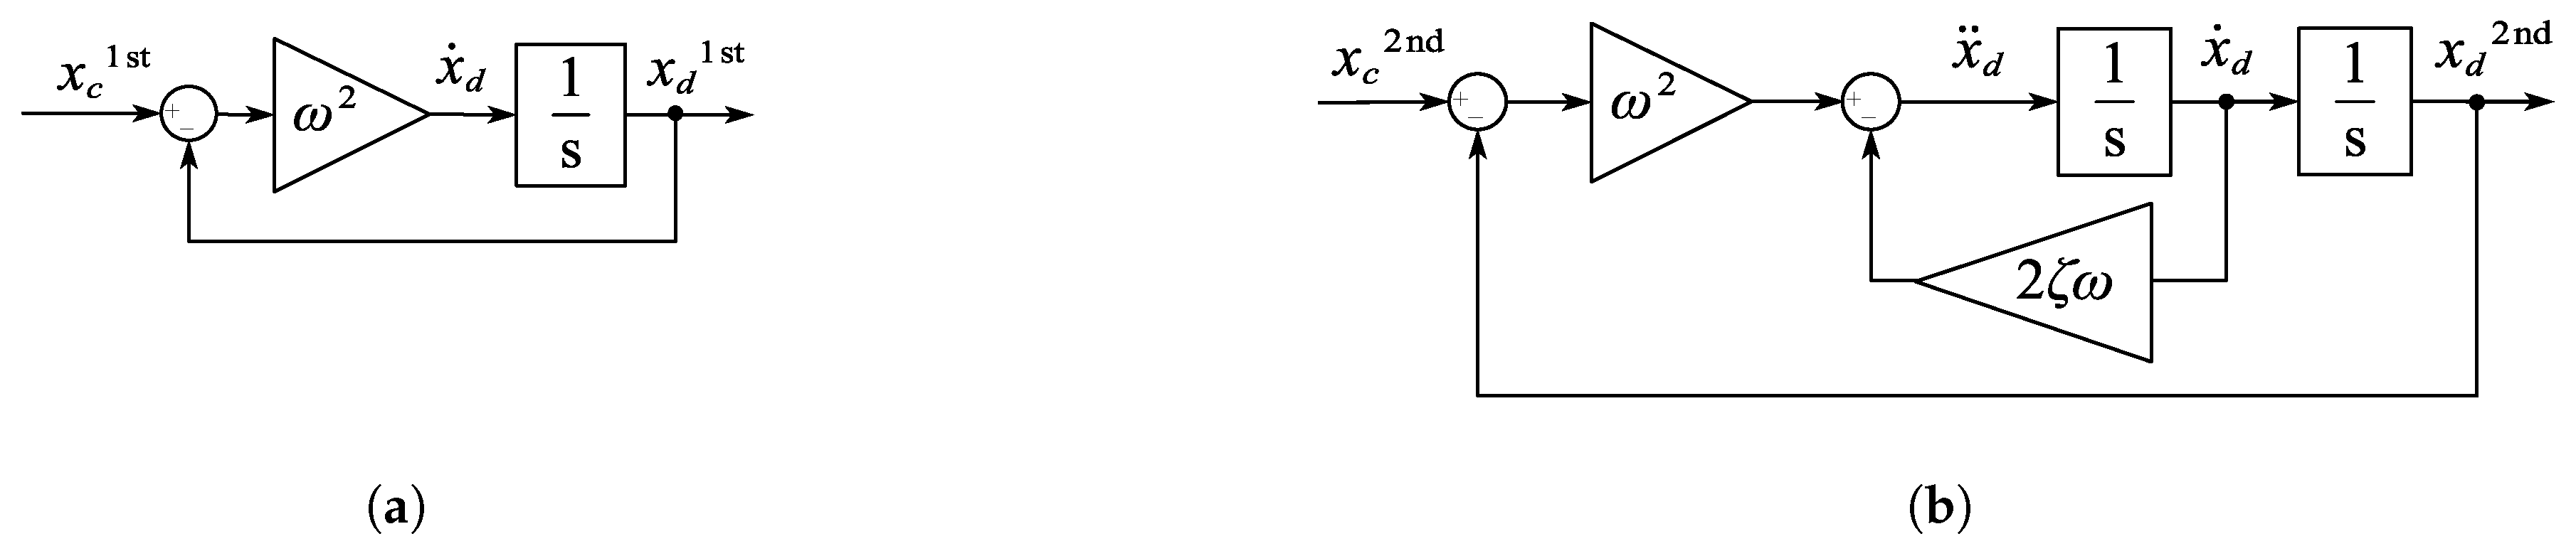
Figure 6.
Error controller structure.
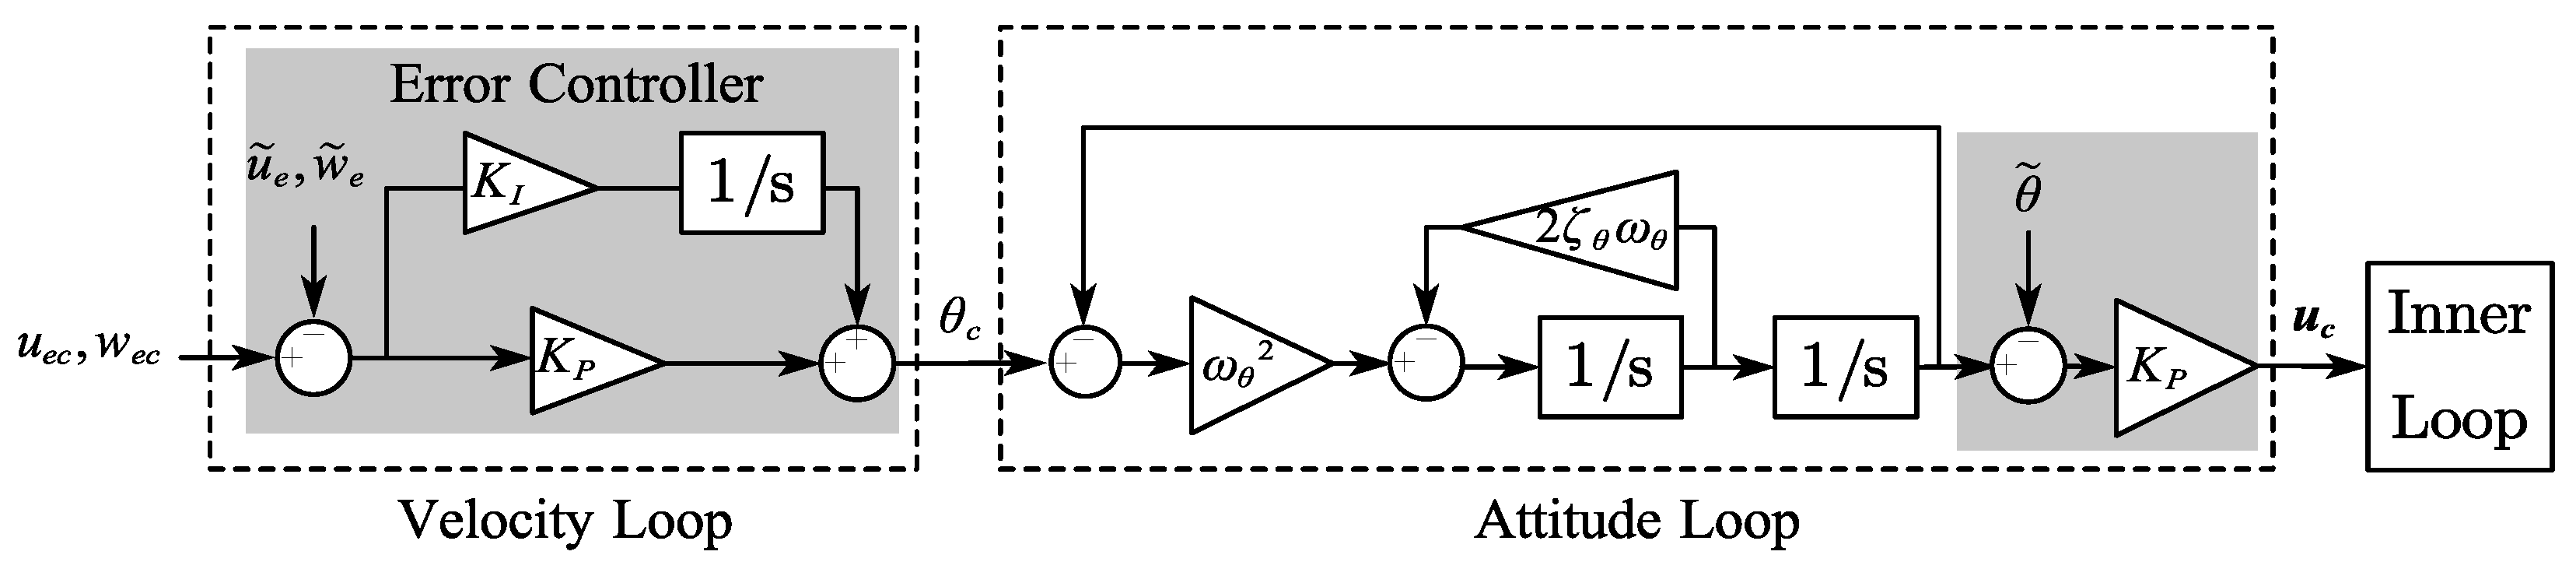
Figure 7.
Protected pitch angle controller structure.
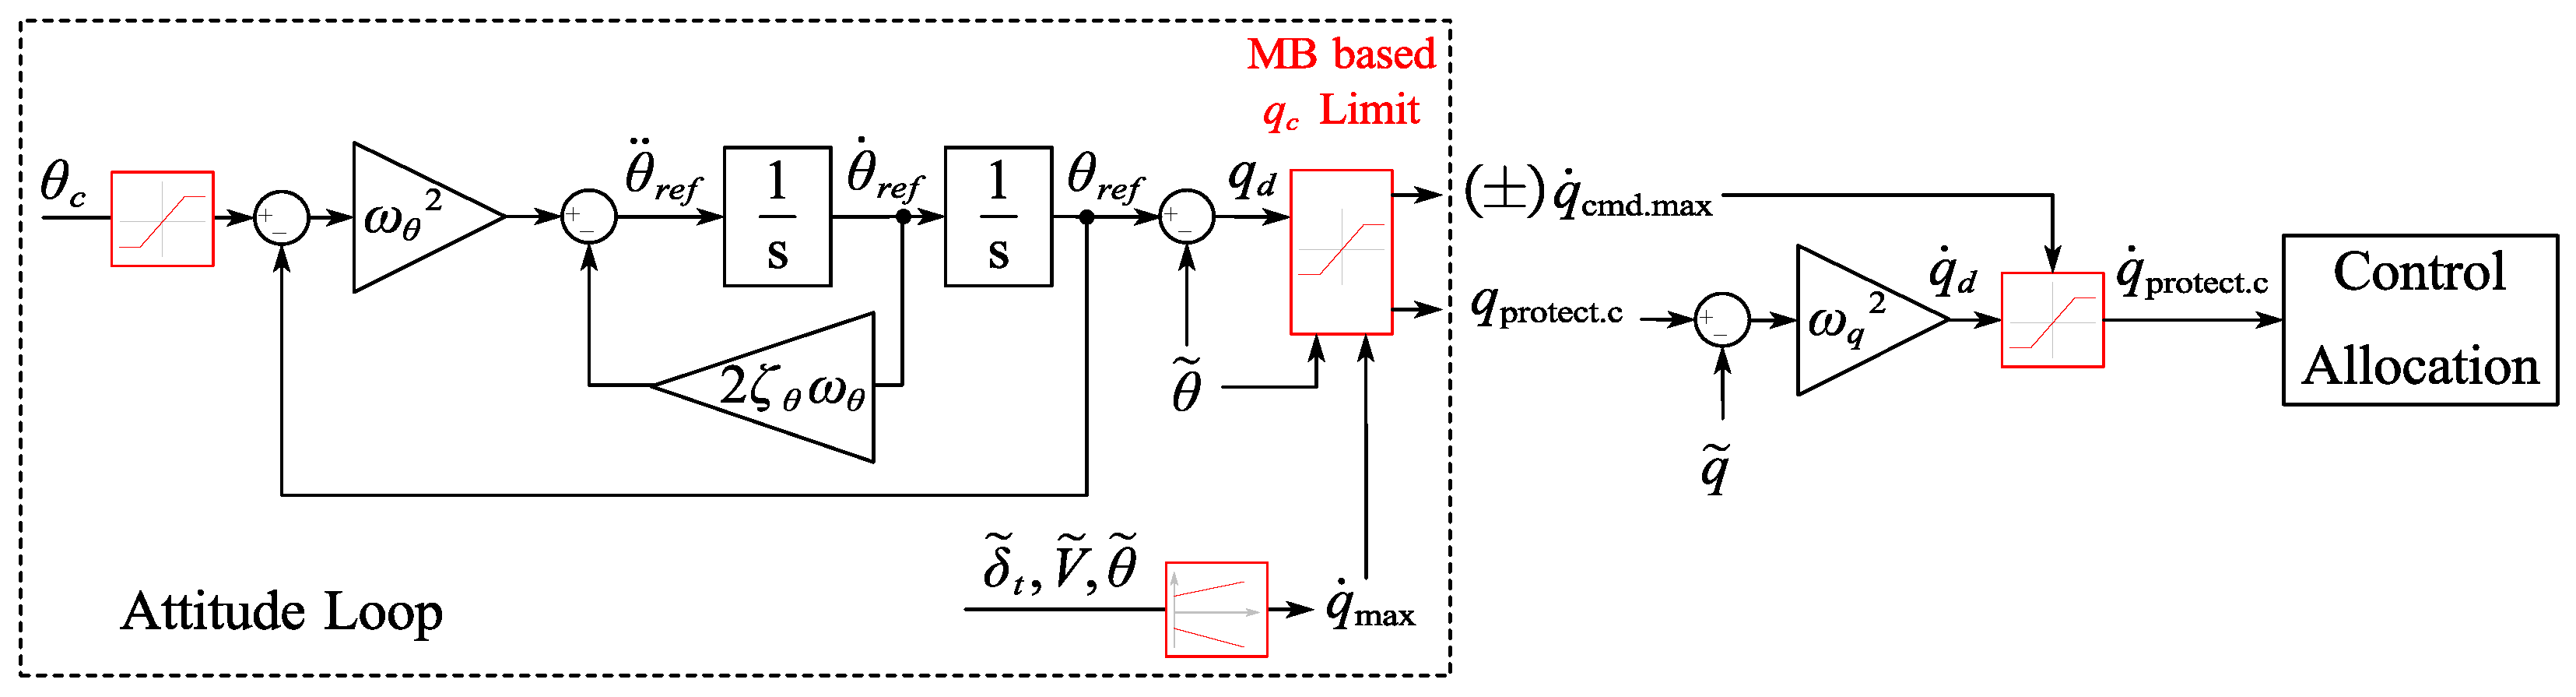
Figure 8.
Transition-capable boundary: (a) Minimum attainable pitch angle; (b) Maximum attainable pitch angle.
Figure 8.
Transition-capable boundary: (a) Minimum attainable pitch angle; (b) Maximum attainable pitch angle.
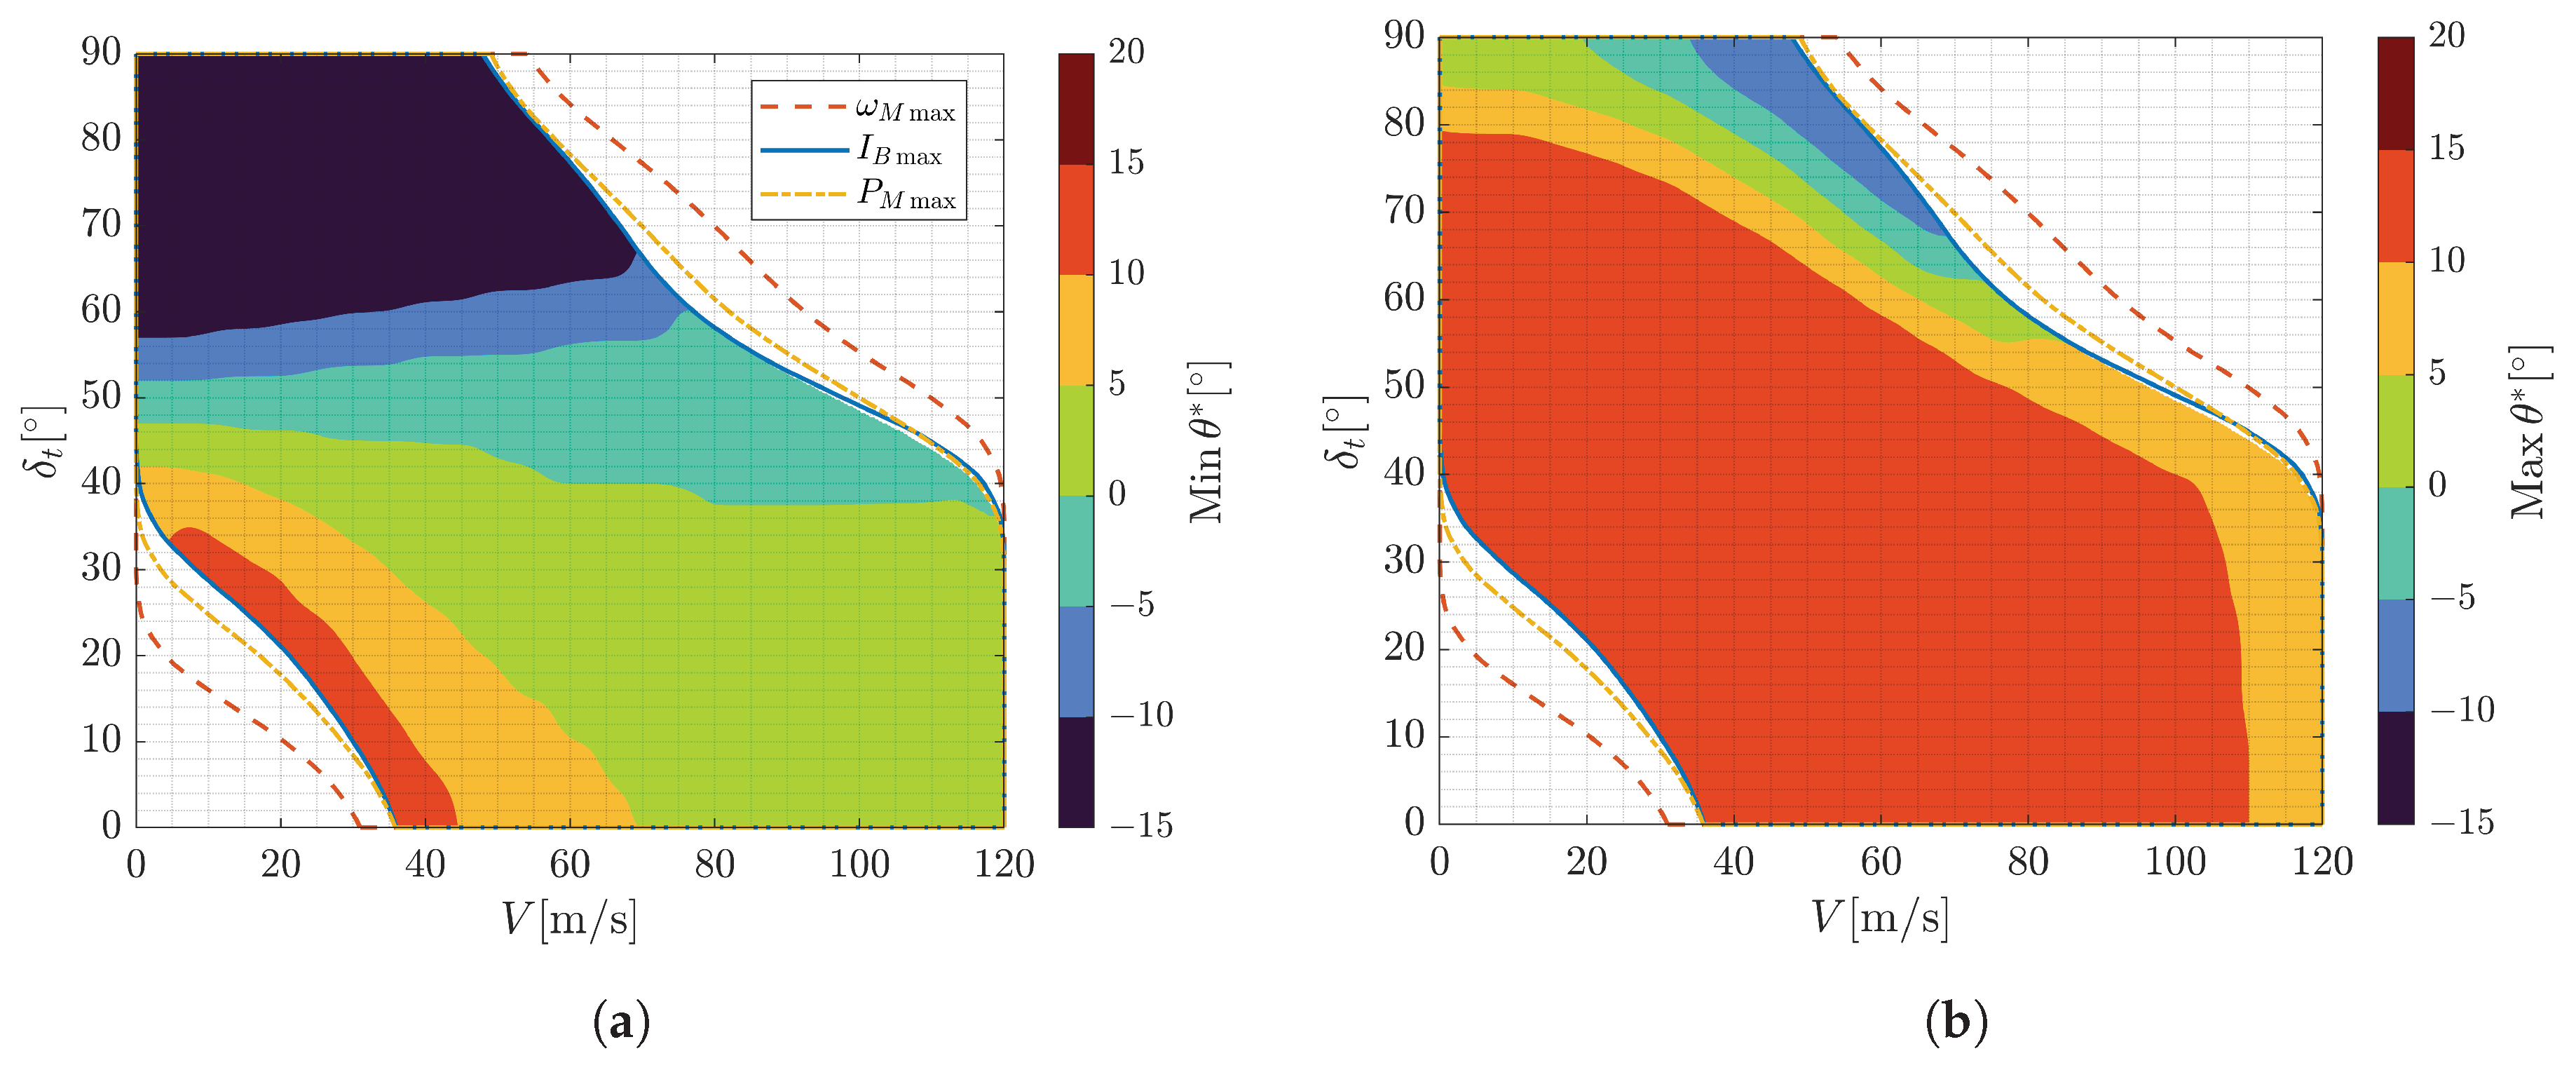
Figure 9.
Retransition-capable boundary: (a) Minimum attainable pitch angle; (b) Maximum attainable pitch angle.
Figure 9.
Retransition-capable boundary: (a) Minimum attainable pitch angle; (b) Maximum attainable pitch angle.
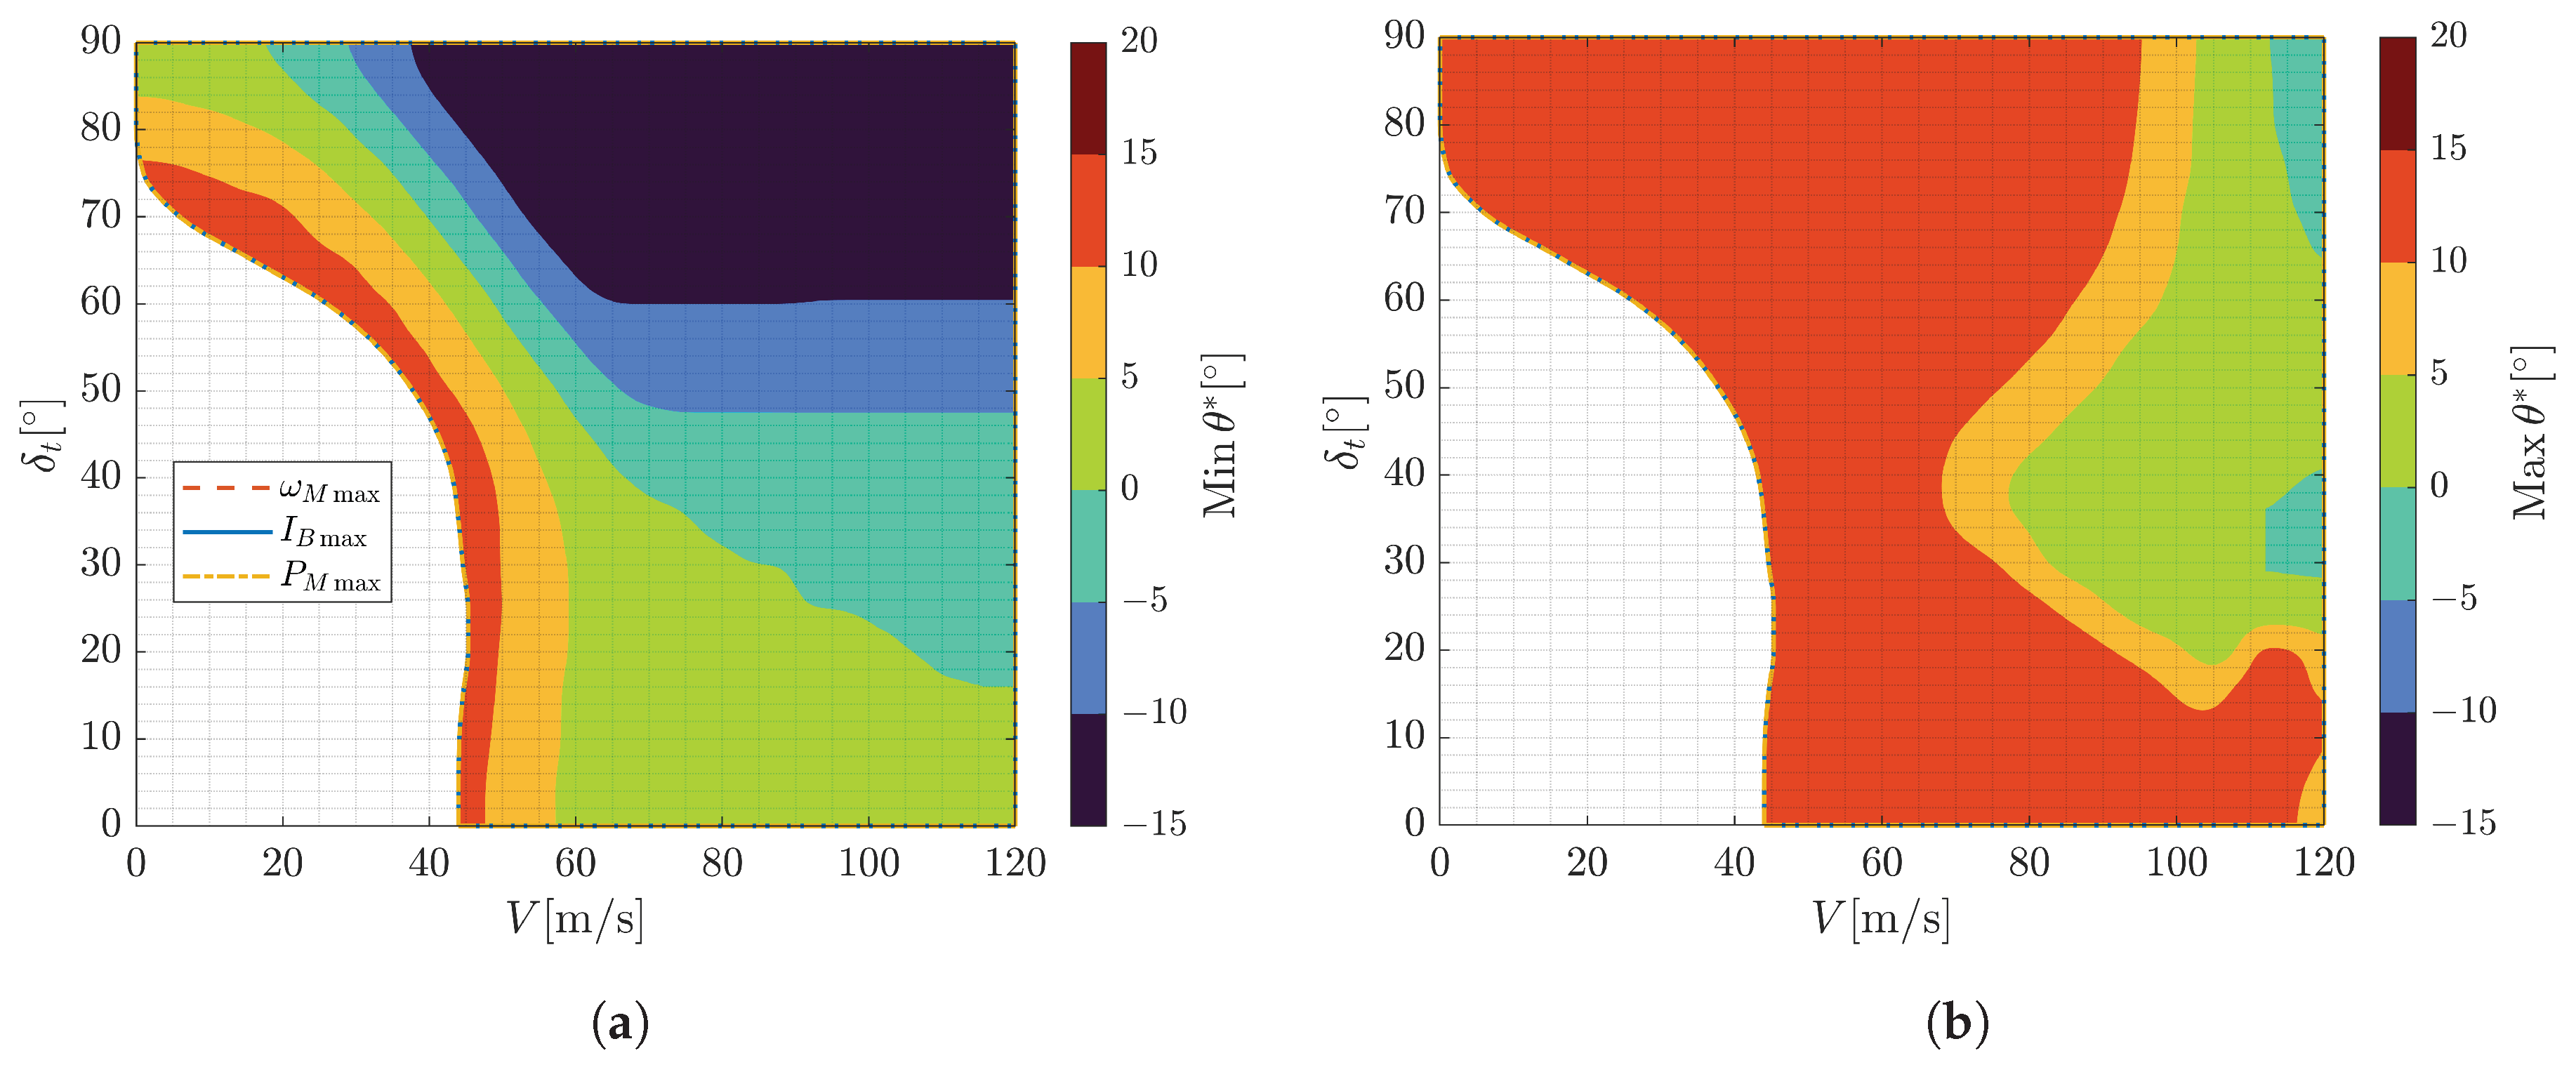
Figure 10.
Intersected transition boundary.
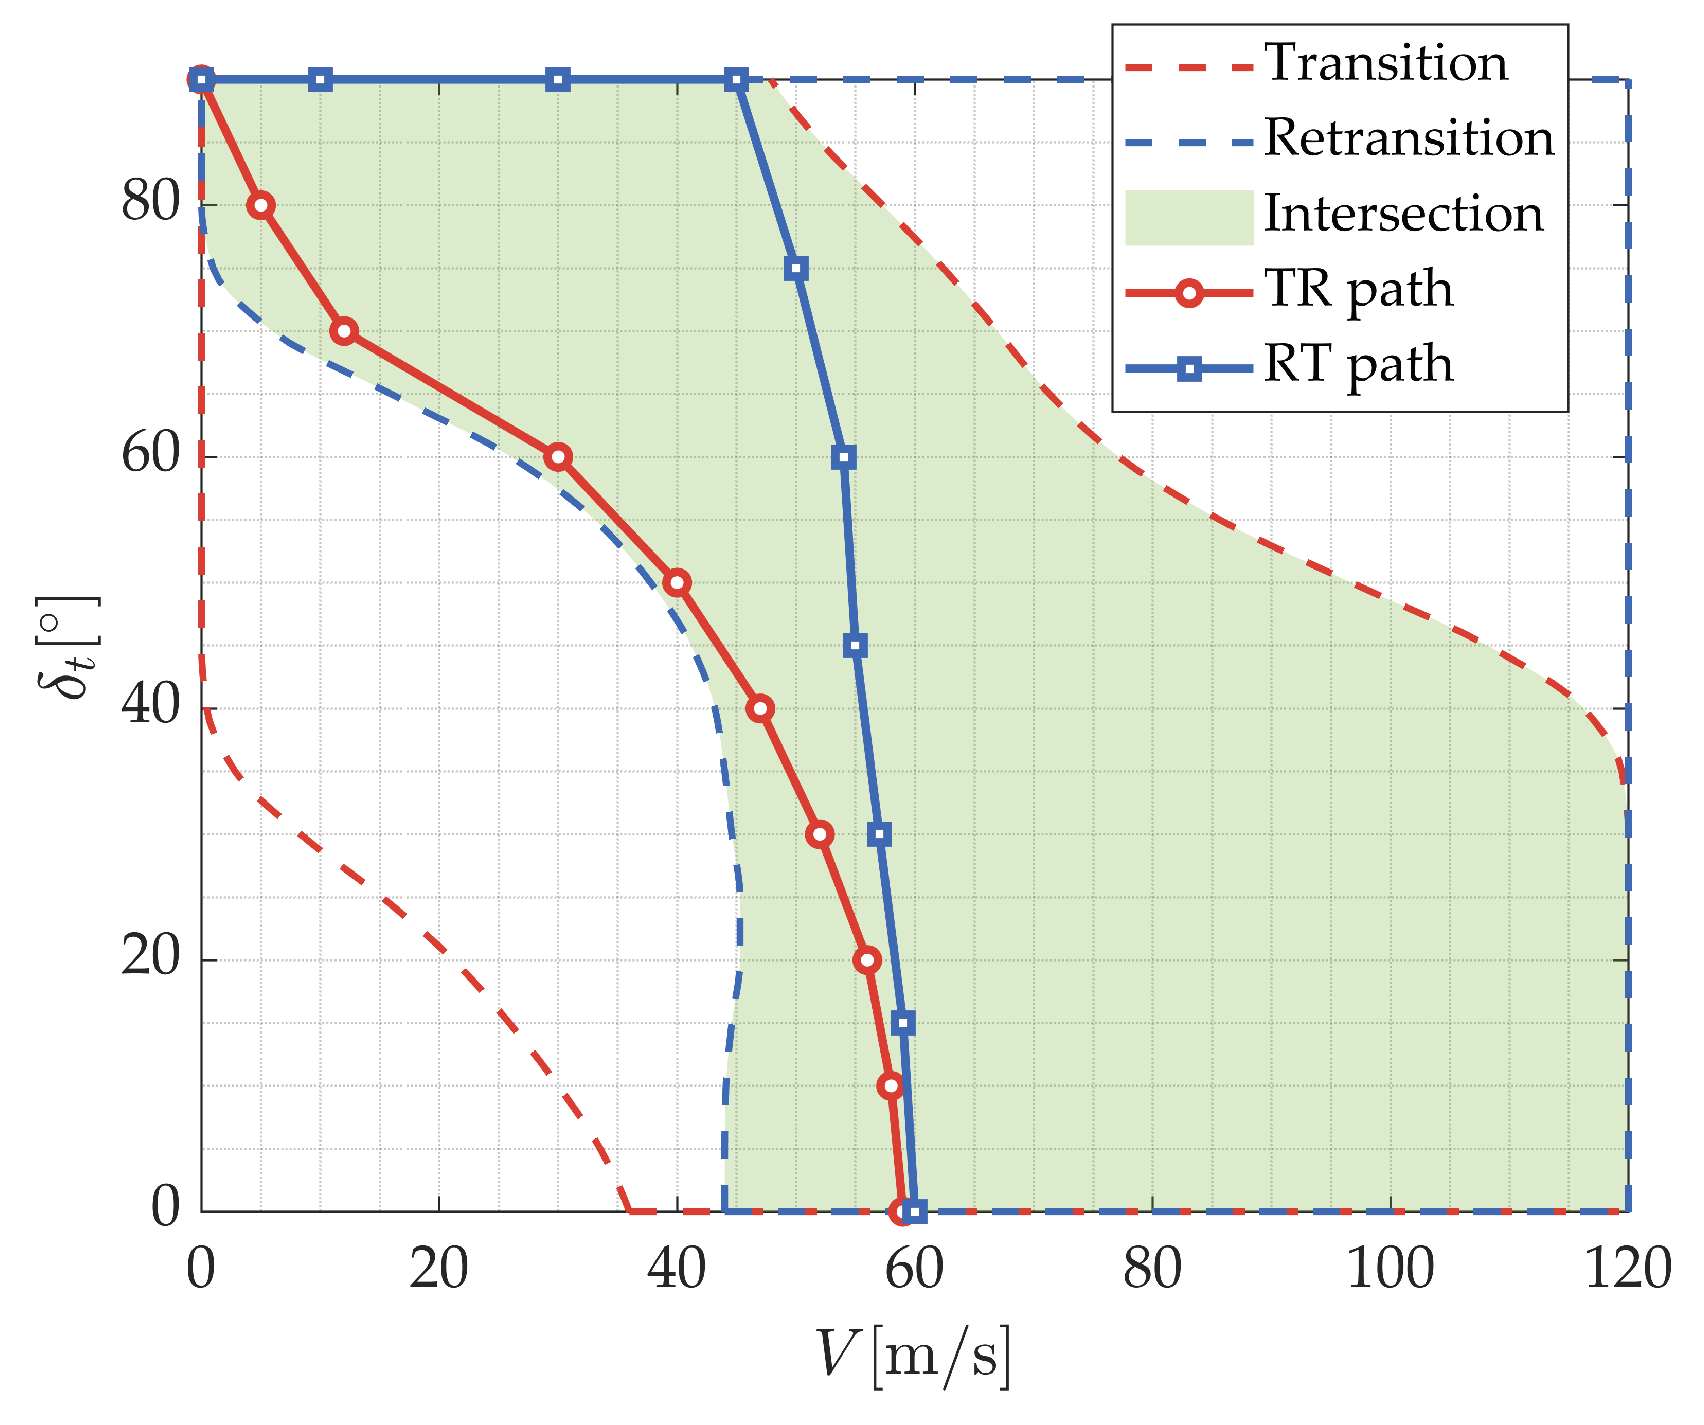
Figure 11.
Maneuverability boundary: (a) Maneuverability boundary of transition; (b) Maneuverability boundary of retransition.
Figure 11.
Maneuverability boundary: (a) Maneuverability boundary of transition; (b) Maneuverability boundary of retransition.
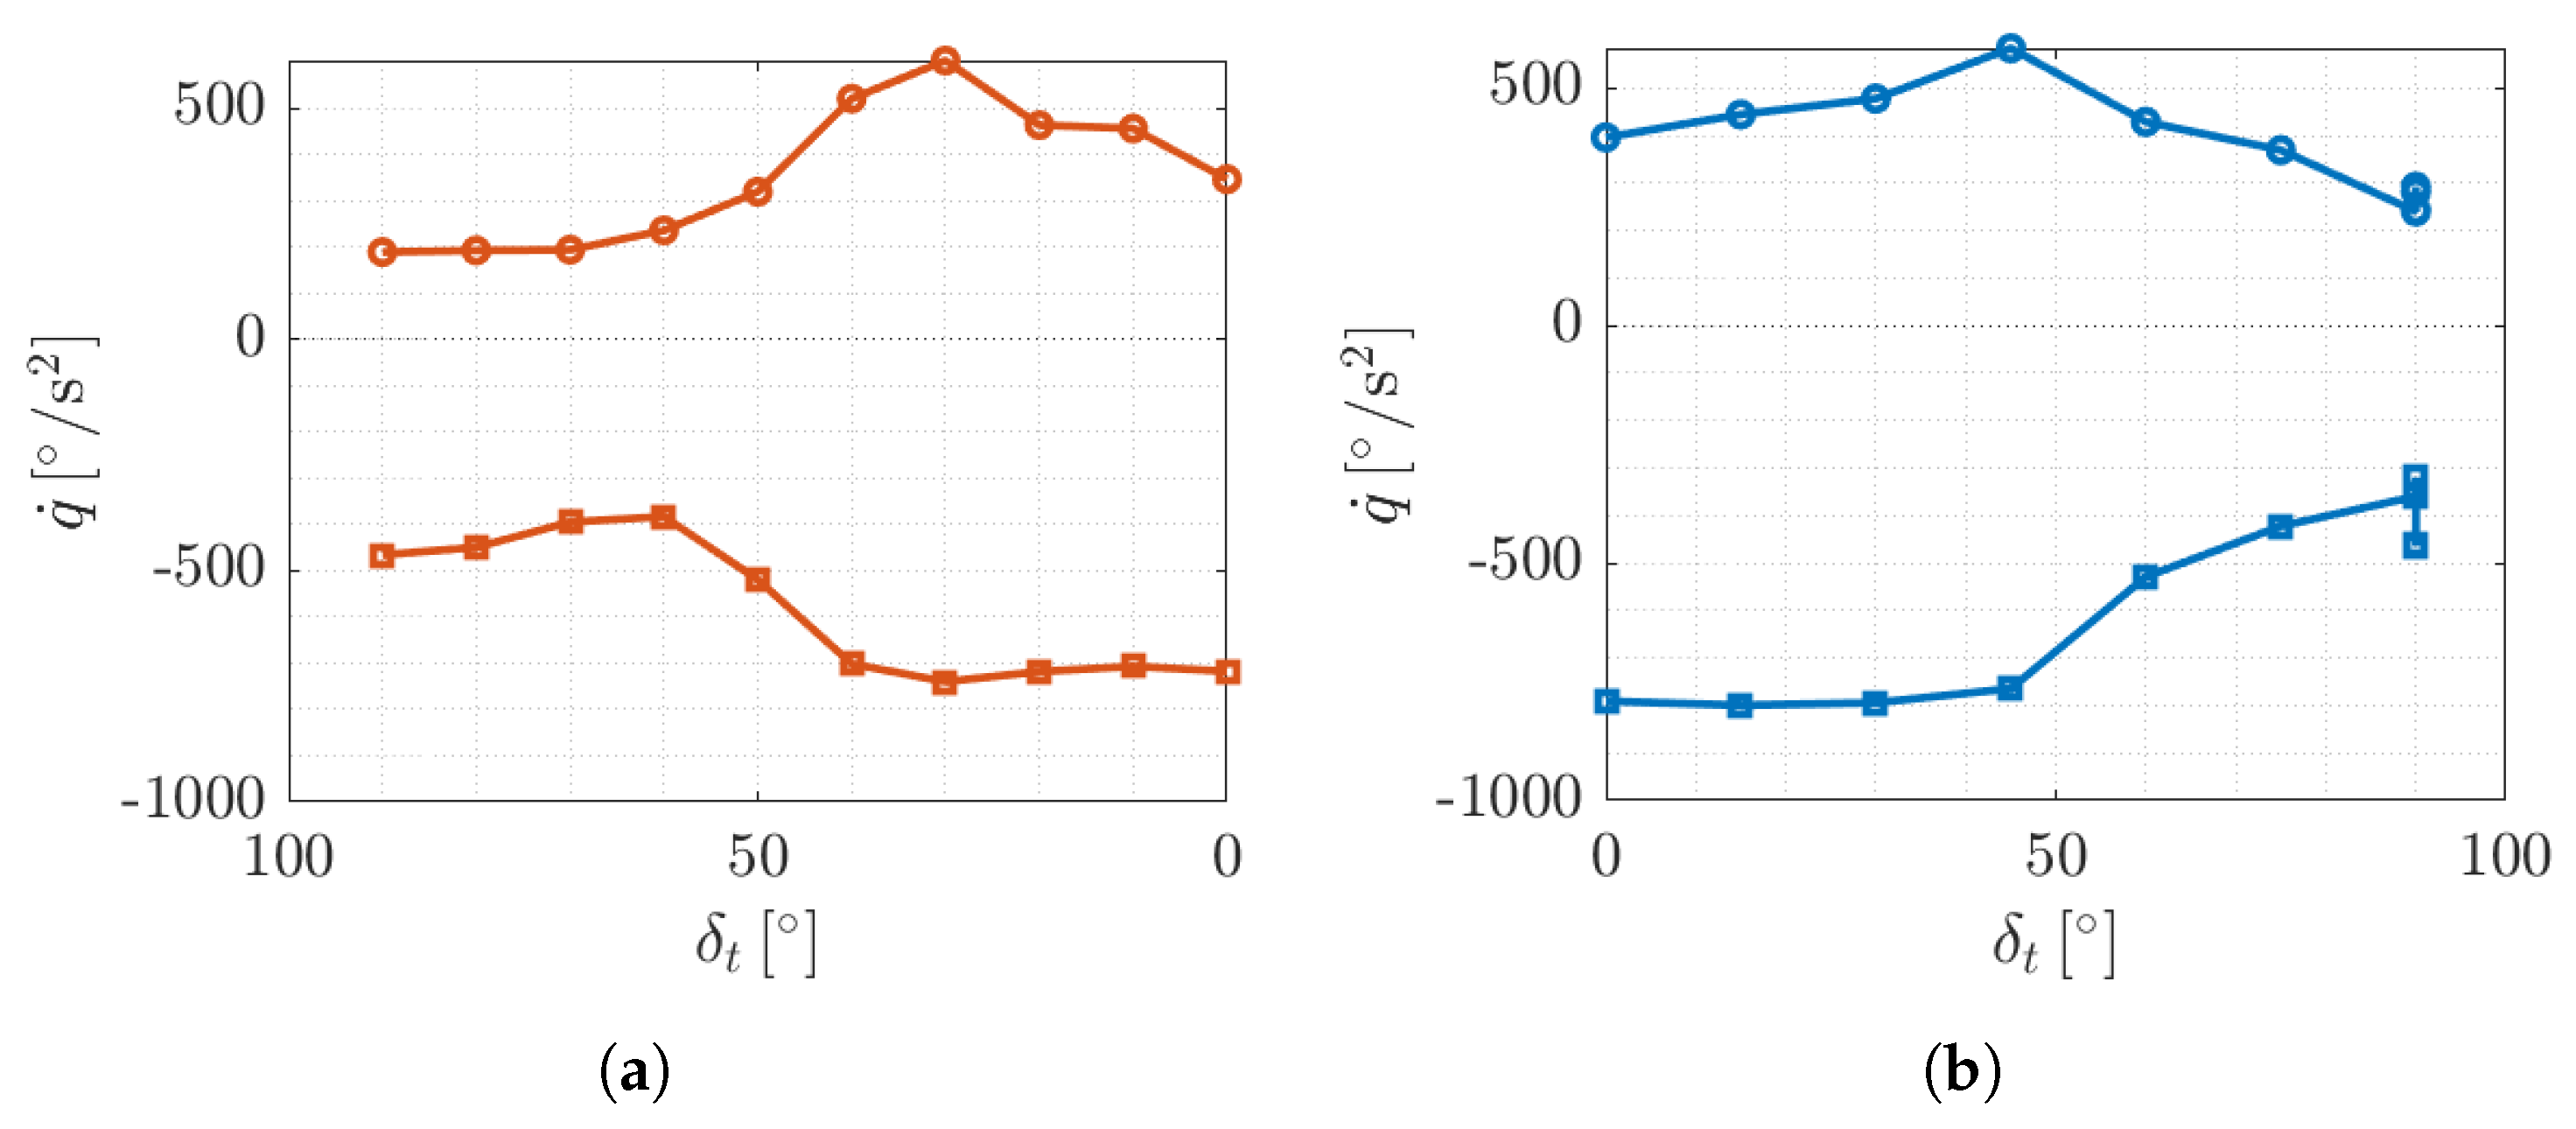
Figure 12.
Comparison of MB pitch rate limit and linear pitch rate limit: (a) Protected corresponding to transition boundary; (b) Protected corresponding to retransition boundary.
Figure 12.
Comparison of MB pitch rate limit and linear pitch rate limit: (a) Protected corresponding to transition boundary; (b) Protected corresponding to retransition boundary.
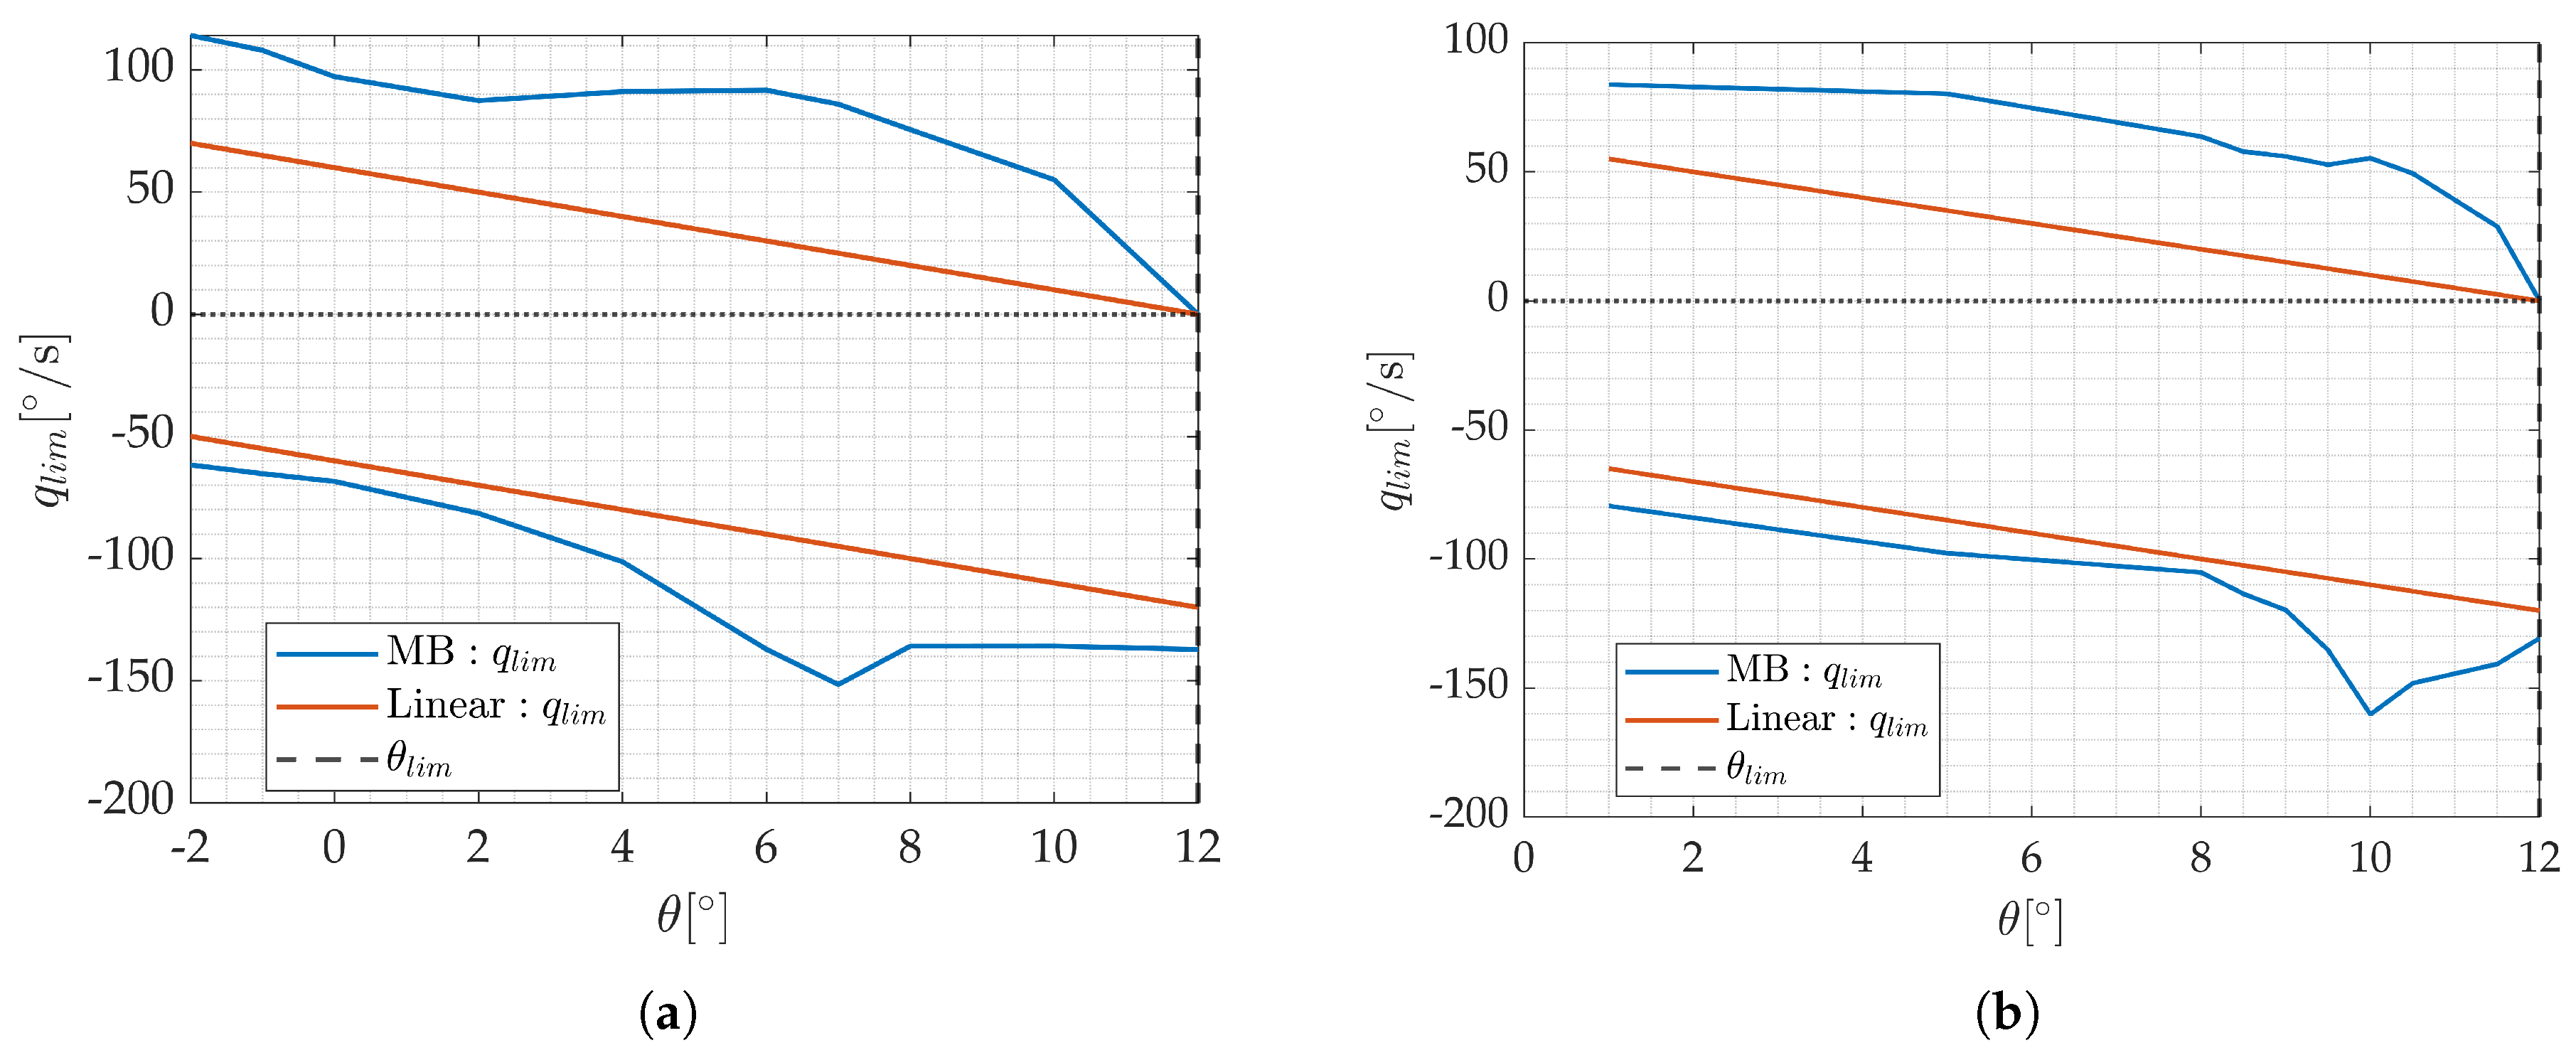
Figure 13.
Full mission profile for simulation.
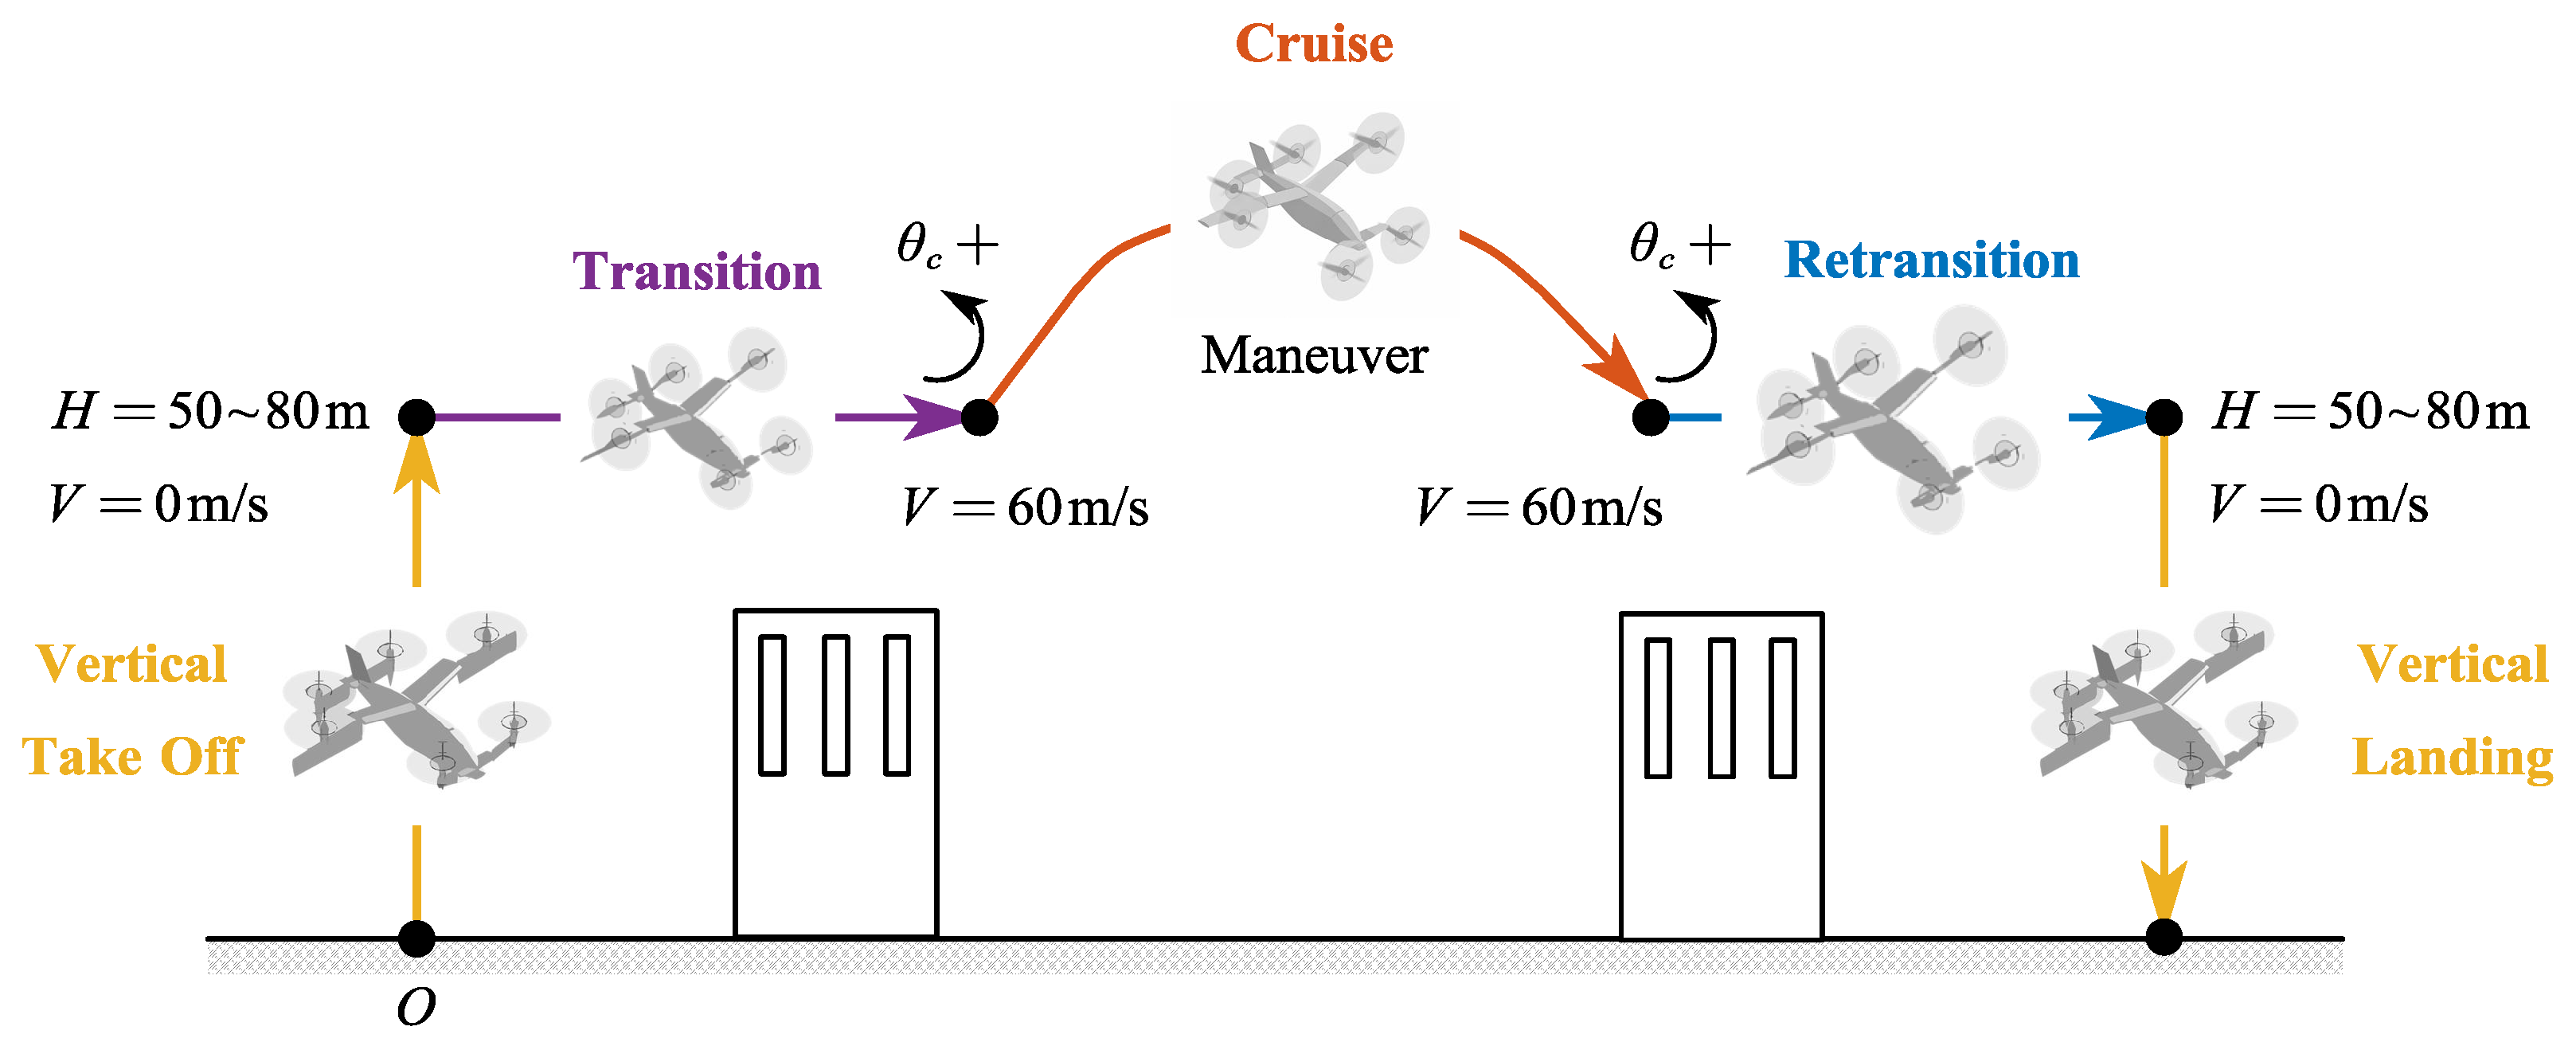
Figure 14.
Responses of INDI and PID controller.
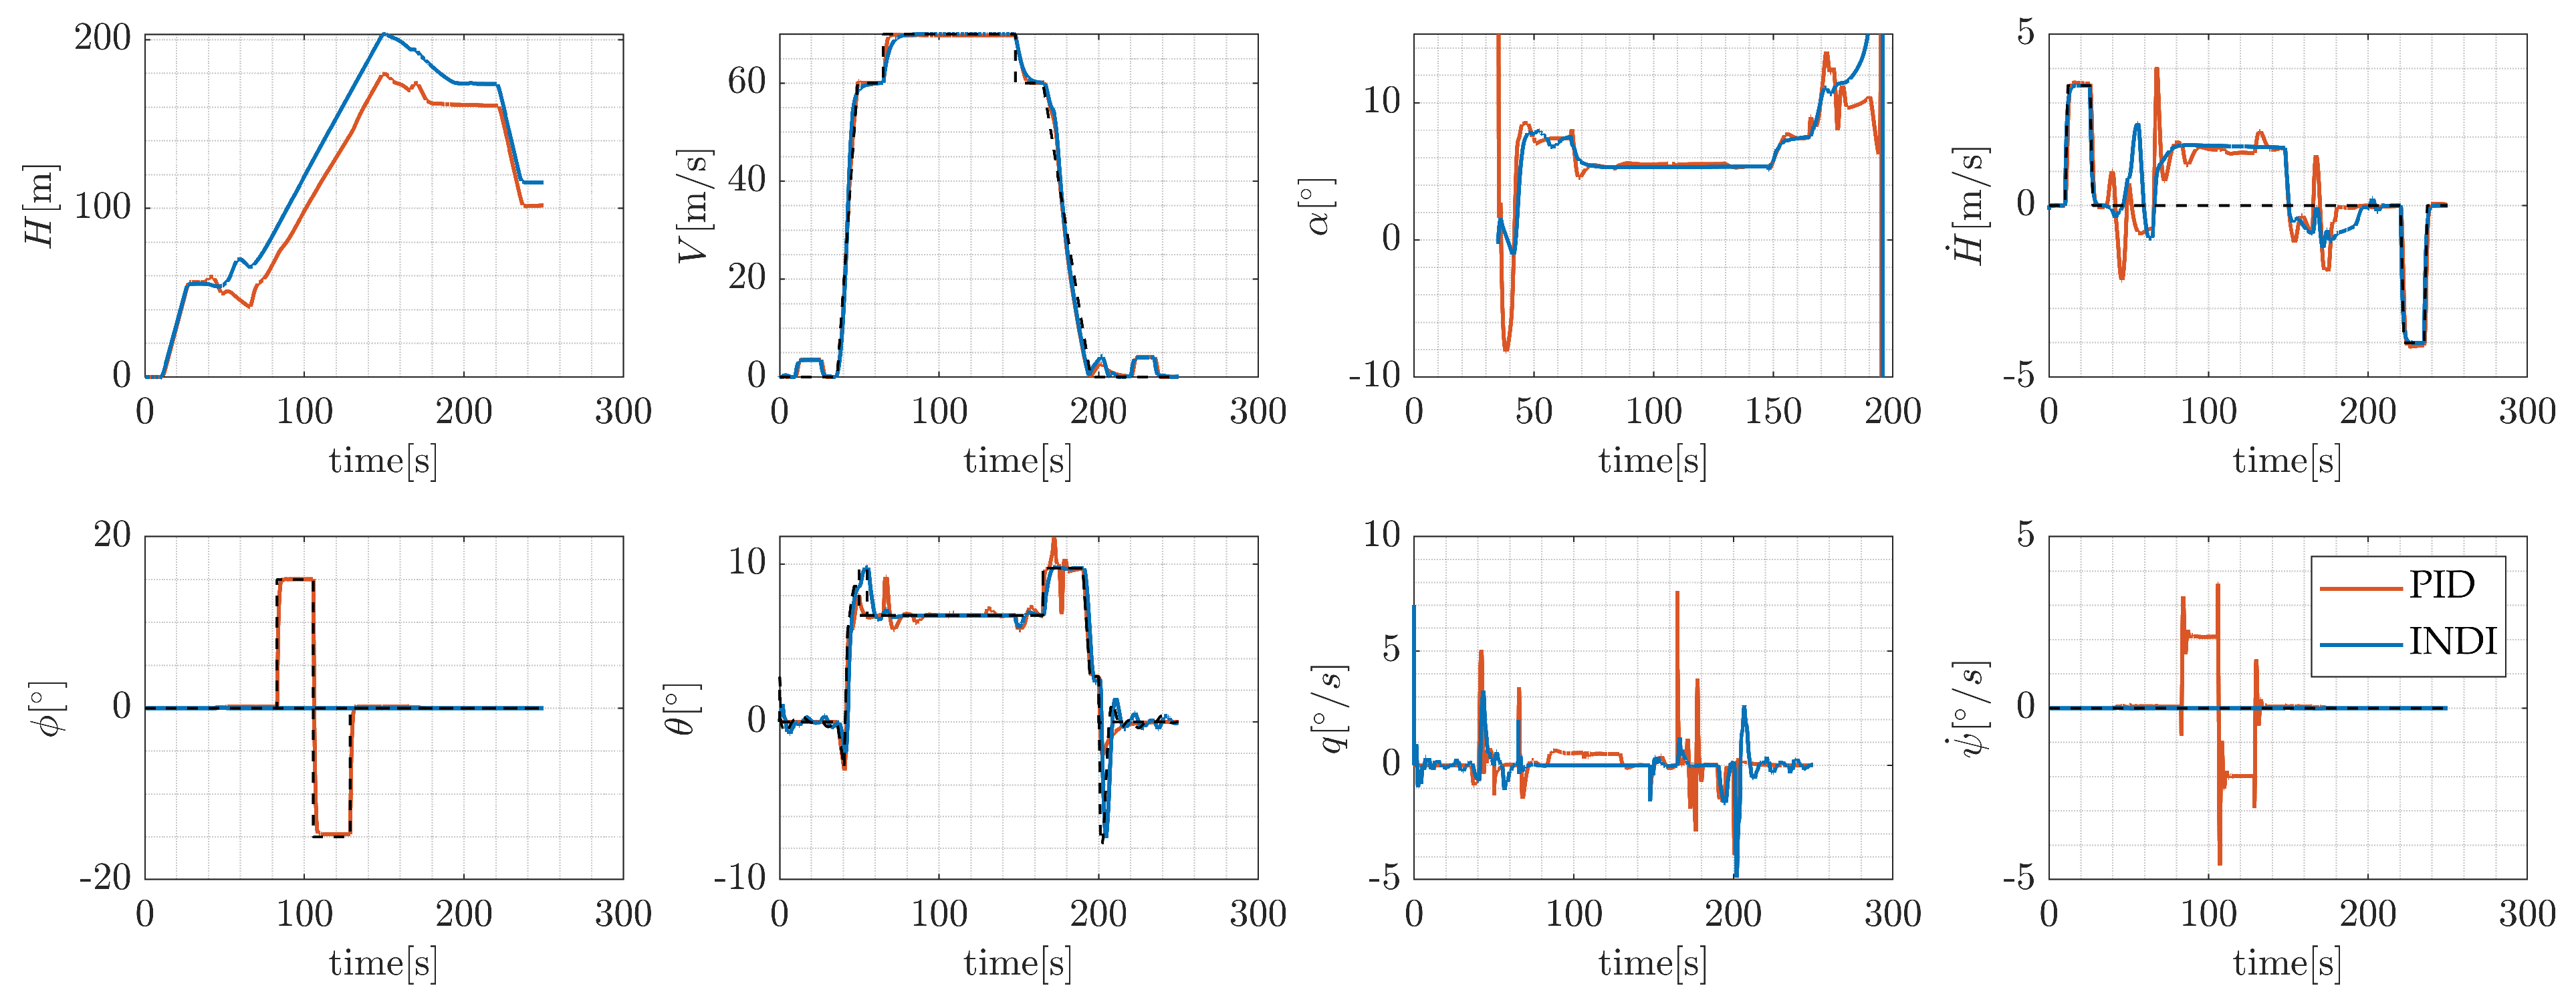
Figure 15.
Required Actuations of INDI and PID controller.
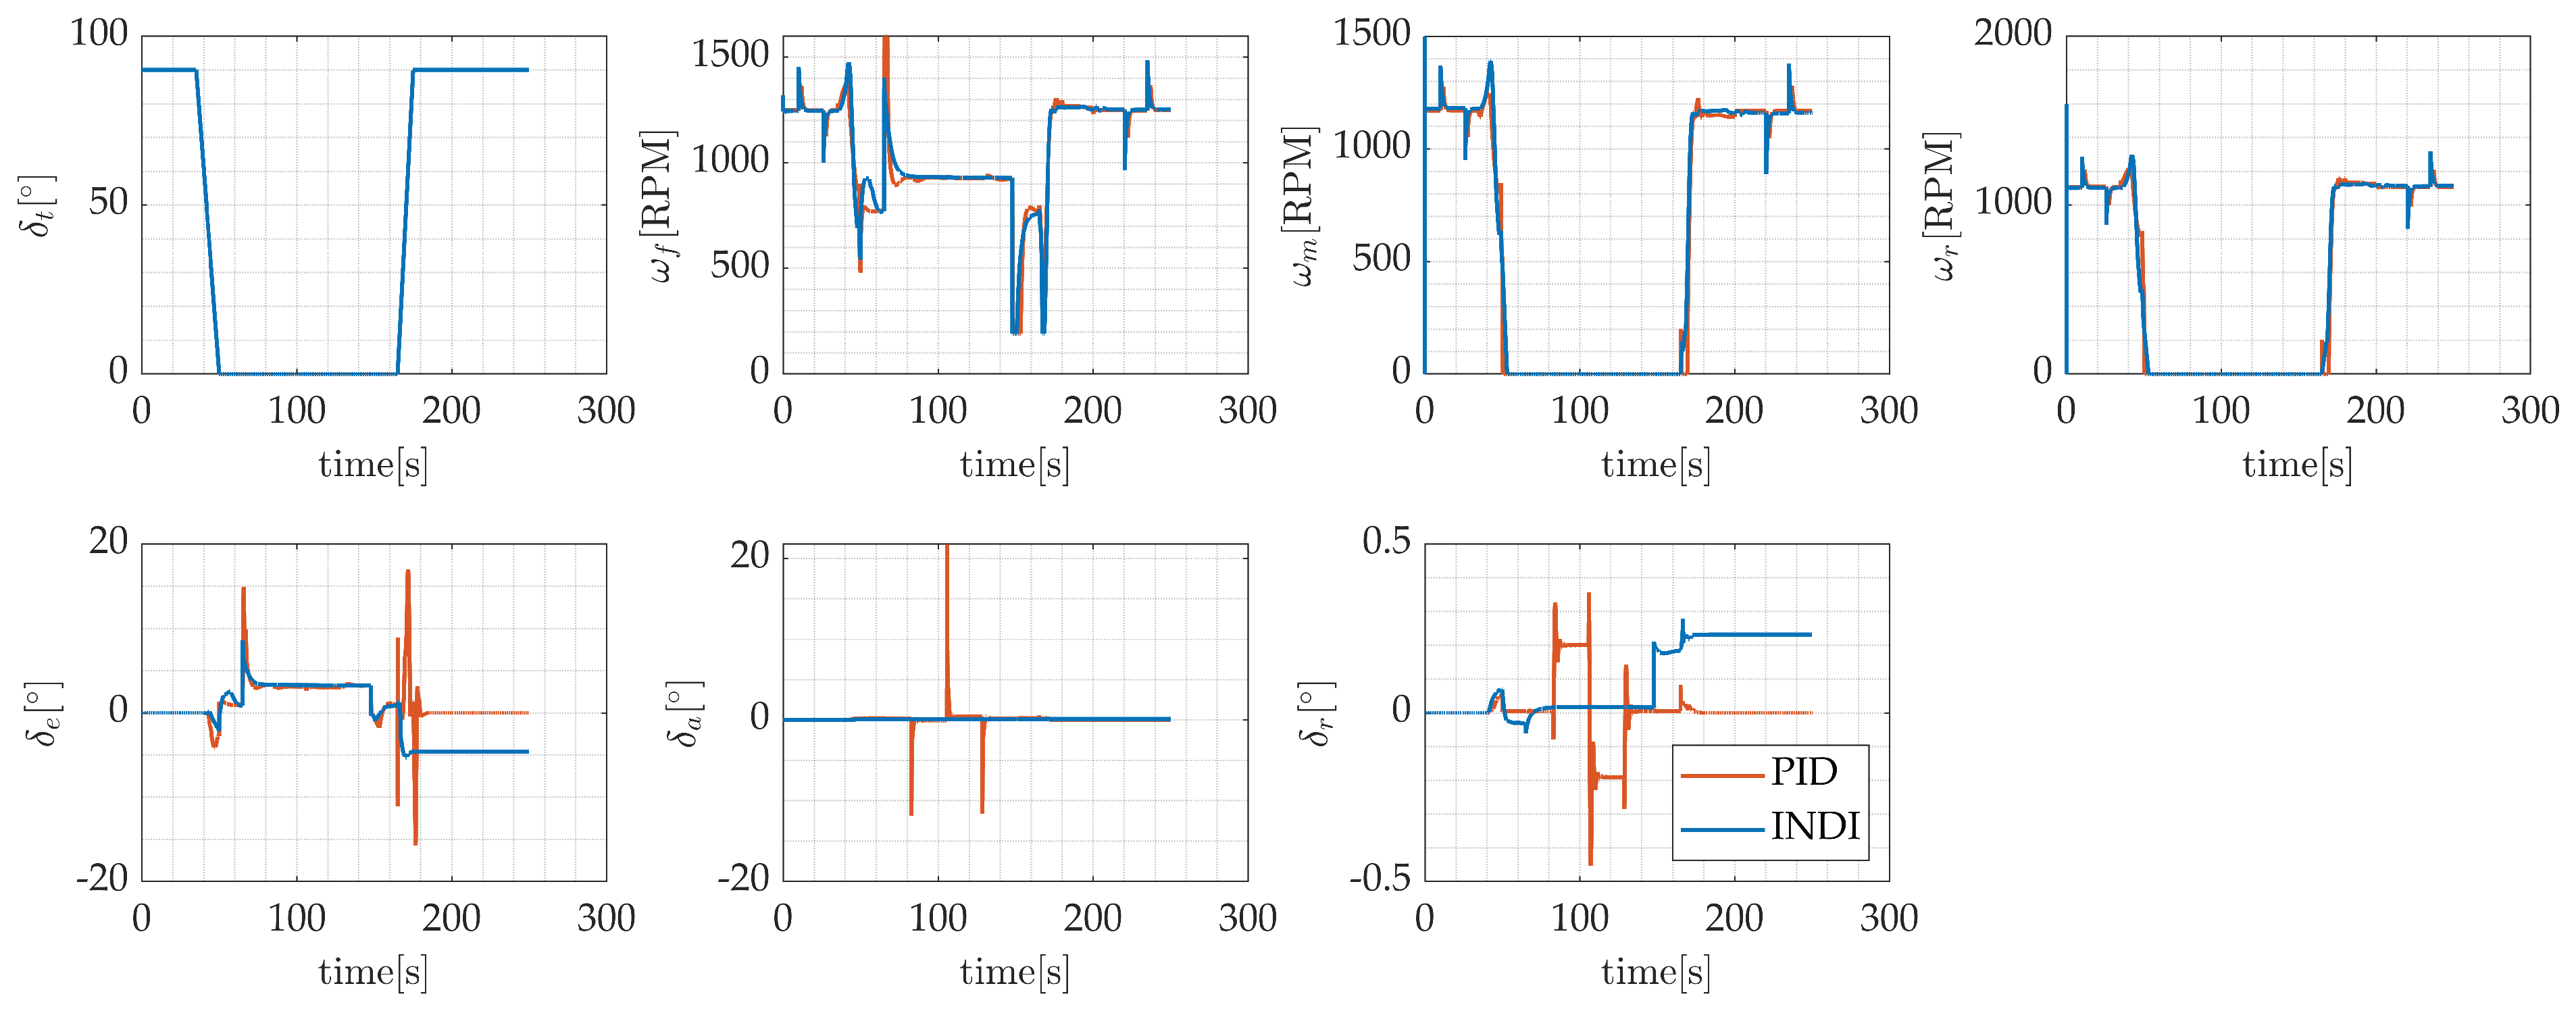
Figure 16.
Deviation and corresponding .
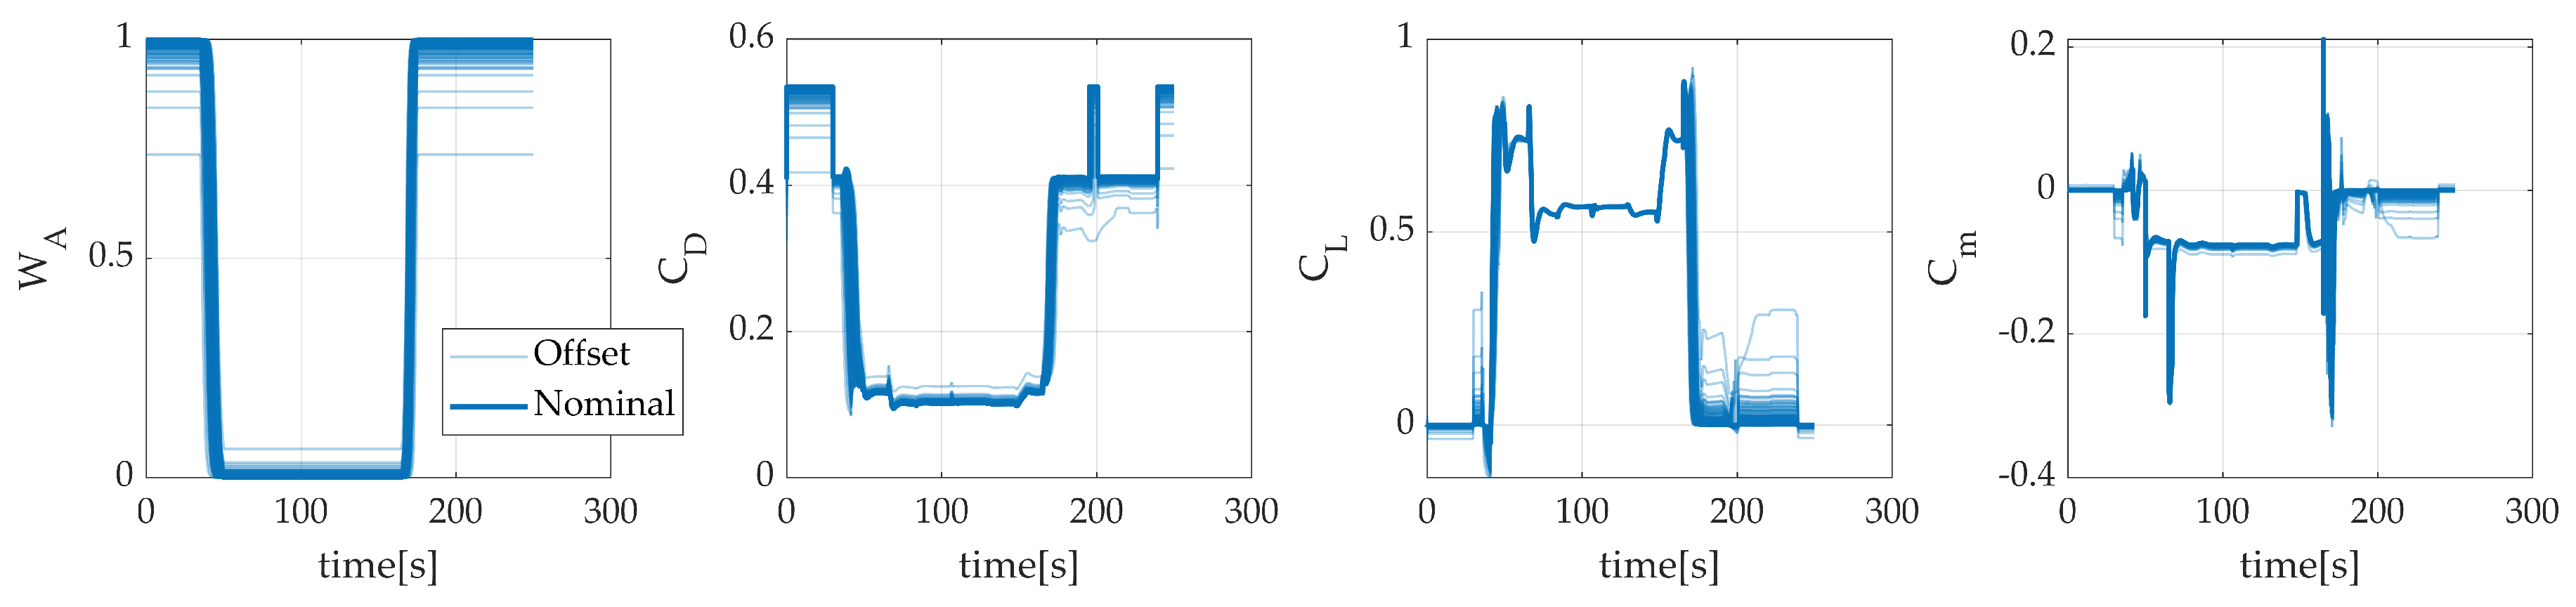
Figure 22.
Comparison of pitch rate limit generation methods on INDI controller.
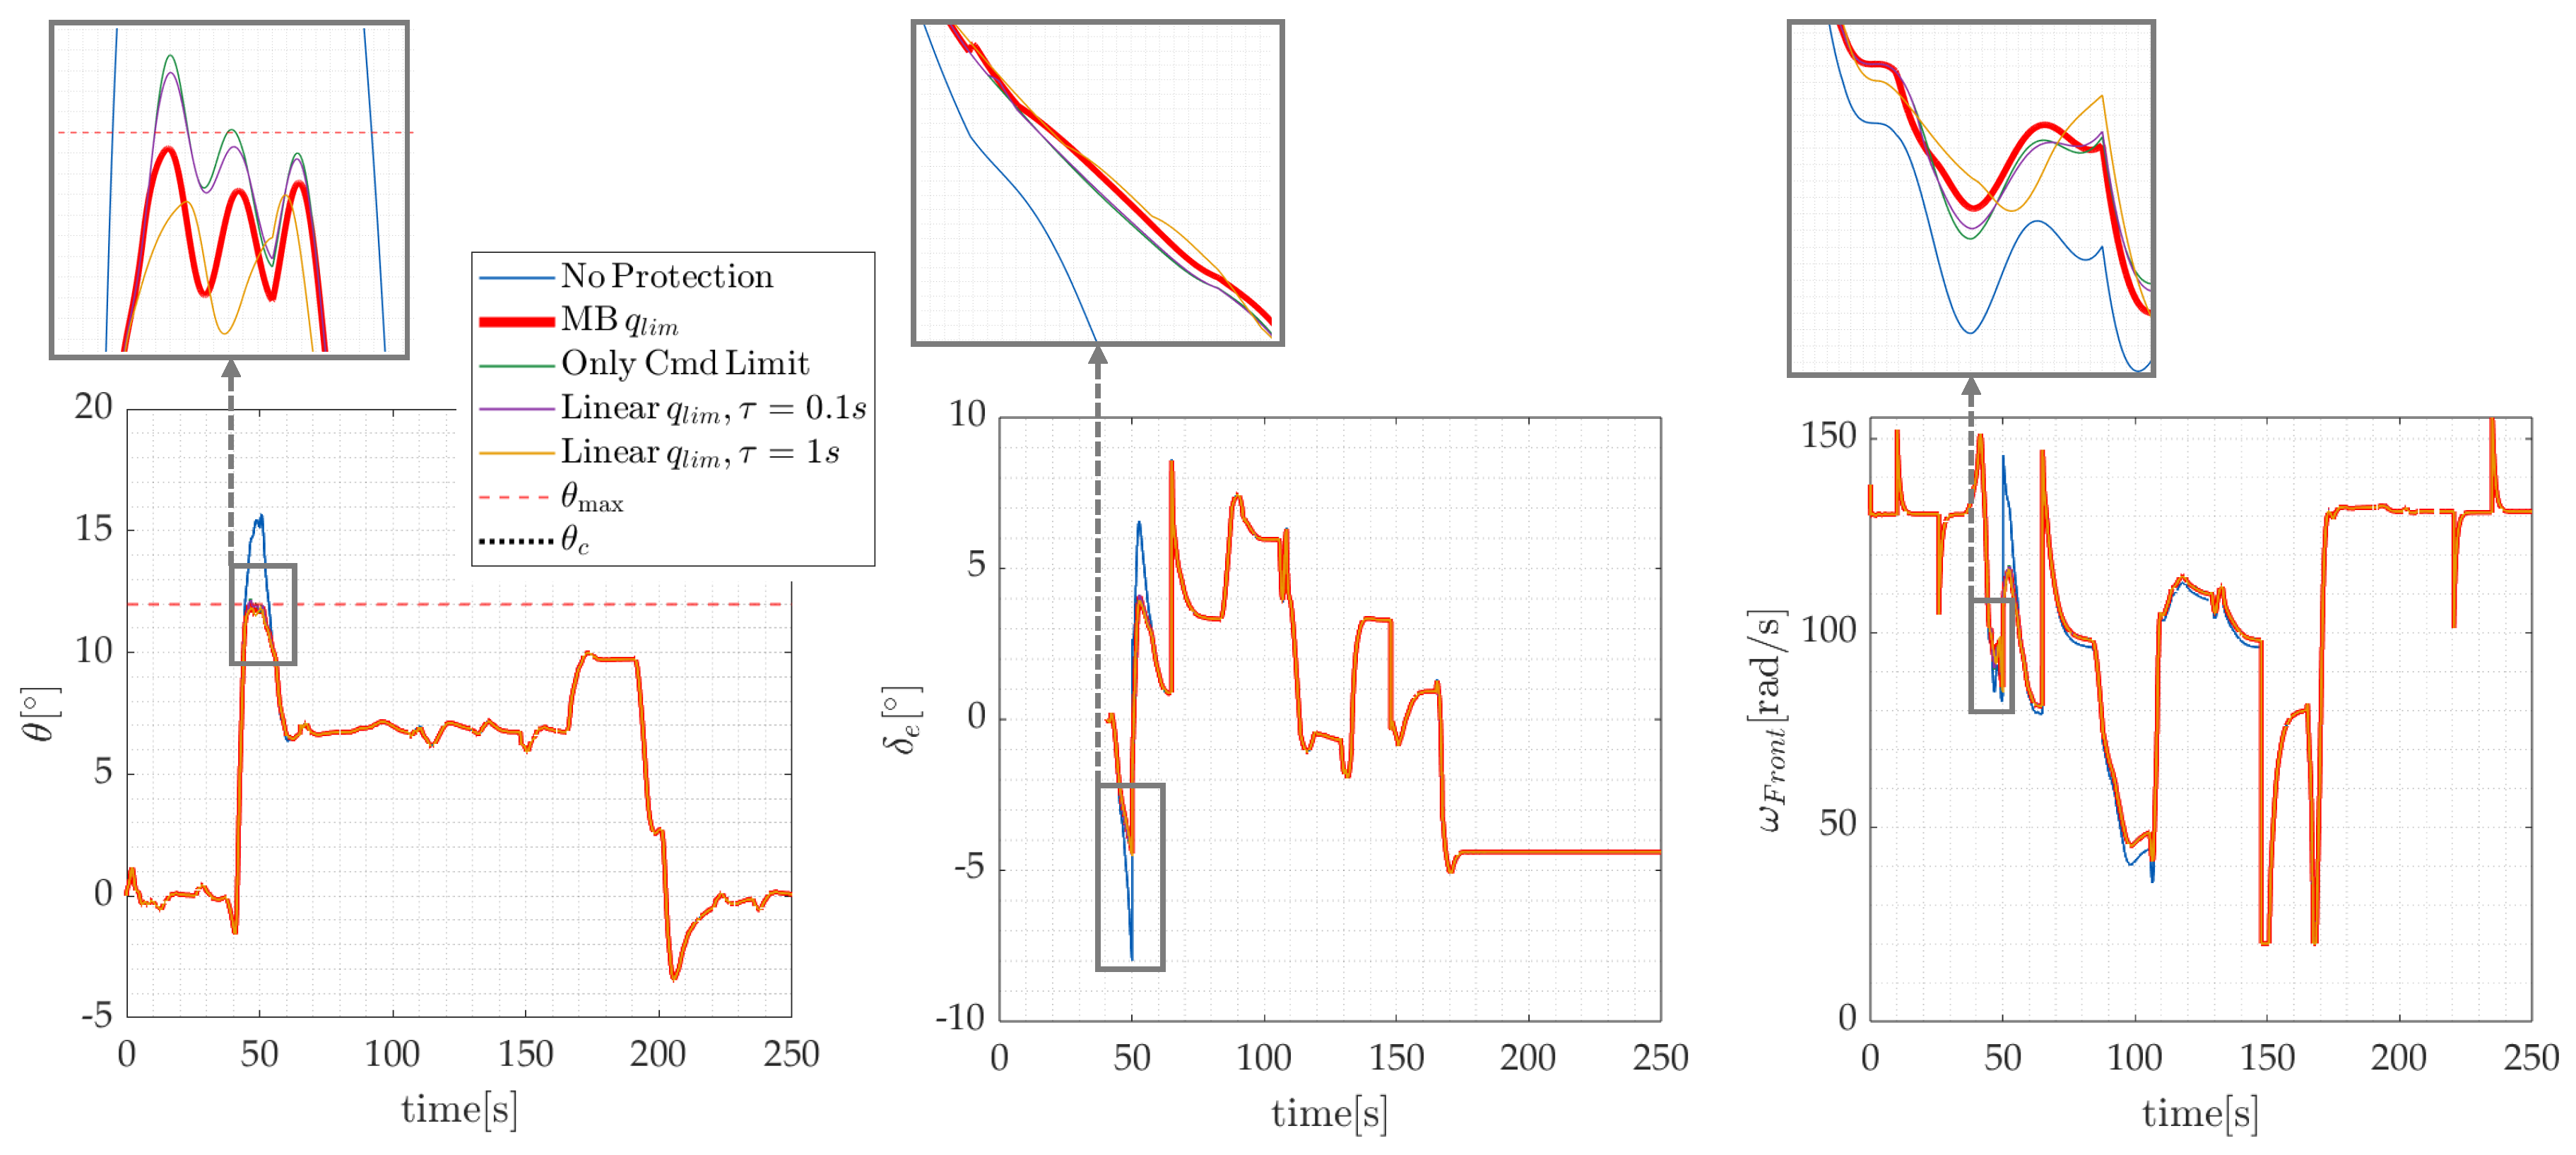

Table 1.
Control commands.
| Flight Phase | Throttle | Longitudinal | Lateral | Yaw |
|---|---|---|---|---|
| Multi-rotor | ||||
| Transition | ||||
| Fixed-wing | ||||
| Retransition |
Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license (http://creativecommons.org/licenses/by/4.0/).
Copyright: This open access article is published under a Creative Commons CC BY 4.0 license, which permit the free download, distribution, and reuse, provided that the author and preprint are cited in any reuse.