

Submitted:
29 September 2026
Posted:
01 October 2026
You are already at the latest version
Abstract
Floating photovoltaic (FPV) systems are an increasingly attractive route to large-scale solar deployment on water bodies, but their structural integrity and energy yield are threatened by the wave environments to which they are exposed at nearshore and offshore sites. Floating breakwaters (FBWs), and keeled geometries in particular, are a candidate protection system. Here we develop a smoothed particle hydrodynamics (SPH) model of a moored, keeled floating breakwater using the open-source solver DUALSPHYSICS, with waves generated and absorbed through the relaxation-zone method [1,2]. The model is assessed against wave-basin experiments in two stages: a verification stage under regular waves spanning six height–period combinations, and an assessment stage under irregular sea states (two JONSWAP spectra and a broadband white-noise excitation). We report the wave transmission and reflection behaviour, the breakwater motions and their response amplitude operators (RAOs), and find that there is reasonable agreement in the SPH simulations at longer wave length conditions.
Keywords:
floating photovoltaics
; floating breakwater
; CFD
; SPH
1. Introduction
As the global demand for renewable energy accelerates, floating photovoltaic (FPV) systems are emerging as a promising response to land scarcity and to the energy–water nexus, allowing solar capacity to be installed on reservoirs, lakes, nearshore and offshore waters [3,4]. Beyond avoiding competition for land, FPV can benefit from the cooling effect of the underlying water body, which raises module efficiency relative to equivalent land-based arrays [5]. The performance of an FPV installation is sensitive to a range of design and environmental parameters, including module layout, float geometry and the local meteo-ocean climate [6].
The transition from sheltered inland waters to open and coastal sites greatly increases the severity of the loading environment. Deployment in open water exposes the array to dynamic wind and wave conditions that threaten both its structural integrity and its energy yield [7,8]. Wave-induced motions drive fatigue at connectors and mooring attachment points, while wind- and motion-induced aerodynamic loads act on the tilted module surfaces [9]. Characterising and mitigating these loads is therefore central to making FPV viable in energetic sites. In practice, commercially deployed FPV systems are largely confined to sheltered inland waters, where the significant wave height rarely exceeds about 0.5 m; marine and near-shore deployments, by contrast, must contend with significant wave heights of the order of 1–2 m and peak periods of several seconds, well beyond the tolerance of most inland designs. Connector and mooring loads scale steeply with wave steepness and height, so even a modest increase in the incident sea state can raise fatigue and ultimate loads at the module interconnections by a large factor [4,7,8], which motivates the use of a dedicated protection structure.
Although FPV platforms can be designed to withstand a range of hydrodynamic conditions, it is often necessary to use floating breakwaters (FBWs) to shield them from the most critical waves that would otherwise endanger their integrity. Compared with fixed, bottom-founded structures, floating breakwaters are attractive because they can be deployed in deeper water, relocated, and tuned to a target sea state by allowing the structure to move and disperse the energy of incoming waves [10]. The design of FBWs frequently incorporates keels or downward-extending skirts, which enhance the structure’s ability to redirect near-surface currents and to further dissipate wave energy. The mechanical performance of an FBW is limited not only by its ability to attenuate waves, but also by the strength of its connection points, which concentrate the largest forces under hydrodynamic loading.
Smoothed particle hydrodynamics (SPH) is a Lagrangian, meshless computational fluid dynamics method well suited to free-surface flows and fluid–structure interaction [11,12]. Because the fluid is discretised into moving particles rather than a fixed grid, SPH naturally handles large free-surface deformation, fragmentation and the moving interfaces produced by floating bodies, situations in which grid-based multiphase approaches such as volume-of-fluid (VOF) can become inaccurate or expensive. SPH has historically been computationally demanding, but the wide availability of graphics processing units (GPUs) has made large simulations tractable. The open-source code DualSPHysics [13] has become a mature platform for GPU-accelerated SPH; it provides a range of SPH formulations together with floating-body dynamics and mooring-line modelling through a coupling to the lumped-mass mooring library MoorDyn(+) [14,15]. SPH has been applied extensively to wave breaking and surf-zone dynamics, building on earlier Eulerian work such as Lin and Liu [16], and increasingly to moored floating structures [15].
In this work we combine wave-basin experiments with numerical simulation to study the dynamics of a moored keeled FBW. We use both SPH (DualSPHysics) and, a finite-volume (FVM) solver (OpenFOAM) to assess the reliability and applicability of these techniques for reducing reliance on costly physical testing. The experiments cover both regular and irregular (JONSWAP and broadband) sea states; the regular cases are used to verify how closely the model can reproduce the measured response, and the irregular cases are then used to assess the model under realistic excitation.
2. Methodology
2.1. Parameter Space and Experiment Layout
The keeled floating breakwater shown in Figure 1 was tested in a wave basin and reproduced in a numerical wave tank. The breakwater is held in place by four soft, taut mooring lines (two per corner pair) whose properties are listed in Table 1; the fairleads attach to the body at and the anchors are fixed at , (model scale). The breakwater geometry and inertial properties, derived by Froude-scaling the full-size design, are summarised in Table 2. All quantities are reported at prototype scale under Froude similitude (length scale ) unless stated otherwise; the conversion factors are given in Section 2.3.1.
The breakwater is oriented broadside to the incoming waves (its long axis parallel to the wave crests). Consequently the wave-frequency response is dominated by sway (horizontal, in the wave-propagation direction), heave and roll; the surge, pitch and yaw responses are comparatively small. This naming convention (sway/heave/roll) is used throughout.
Two families of conditions were tested: a set of regular waves at different wave heights and periods (Section 2.1.1), and a set of irregular waves generated from a JONSWAP spectrum together with a broadband white-noise excitation (Section 2.1.2).
2.1.1. Regular Wave Tests
The regular-wave matrix (Table 3) spans six period–height combinations chosen to cover the operational and design sea states relevant to the protected FPV array. For each case the motions of the breakwater (sway, heave, roll), the surface elevation at wave gauges up- and down-wave of the structure, and the mooring-line tensions were recorded. These provide the reference quantities for verification: the incident wave amplitude, the transmission coefficient and reflection coefficient , and the breakwater motion amplitudes.
2.1.2. Irregular Wave Tests
The irregular matrix (Table 4) comprises two JONSWAP sea states of contrasting steepness and a broadband, near-white excitation that spans the full frequency band of interest. The white-noise case is used to recover the frequency-resolved response (RAOs) and transmission behaviour from a single test. For these cases the reference quantities are the wave spectra, the motion RAOs, and the frequency-dependent transmission coefficient.
2.2. Experimental Methodology Overview
The physical model was tested at a length scale in the wave-basin facility of MARIN (Maritime Research Institute Netherlands) publicly available experimental data was used for comparison. The data can be found in the repository [17]. Wave elevation was measured with an array of resistance-type wave gauges positioned up- and down-wave of the model, the six-degree-of-freedom rigid-body motion was tracked at the body centre of gravity, and the four mooring-line loads were measured at the fairleads.
Because the model was mounted at a heading relative to the solver’s reference frame, the basin-frame channels are mapped to the sway/heave/roll convention used here before comparison. A separate wave-calibration test (without the model present) provides the undisturbed incident spectrum used as the reference for the experimental RAOs, since the gauges nearest the model are locally disturbed by the radiated and diffracted field.
2.3. Numerical Modelling Methodology
2.3.1. Smoothed Particle Hydrodynamics
We model the hydrodynamic forces on the FBW with the weakly compressible SPH solver DualSPHysics (v5.4) [13]. In SPH the fluid domain is discretised into particles whose motion is governed by their mutual interactions. Each particle is advanced by integrating the discrete, weakly compressible form of the mass- and momentum-conservation equations [11,12]:
where and are the velocity and pressure of particle a, and are the mass and density of neighbour b, is gravitational acceleration and is the quintic Wendland kernel [18] with smoothing length in 3D, where is the initial inter-particle spacing. The term is an artificial-viscosity interaction with coefficient . A density-diffusion term following Fourtakas et al. (coefficient ) reduces pressure noise; particle shifting is not used. Closure is provided by the Tait equation of state with polytropic index :
where and is the numerical speed of sound, set to twenty times the maximum expected system speed so that density fluctuations remain below 1%. Time integration uses a Symplectic scheme with a Courant–Friedrichs–Lewy coefficient of . Solid boundaries use the modified dynamic boundary condition (mDBC) with a free-slip condition on the (depth-truncated) floor, which avoids forming a spurious viscous boundary layer on the bed.
All simulations are run at model scale and reported at prototype scale under Froude similitude (; gravity and density invariant). The conversion factors used are: length , time , velocity , acceleration 1, angle 1, frequency , force and mass . The resolution chosen for the simulation was of 0.05 m in particle diameter, which is just enough to resolve the narrowest details of the geometry of the FBW and enough to resolve the long wave lengths. Further refinement to particles of 0.03m was also included in cases with shorter waves to be able to resolve shallower heights at the shortest wave conditions. The full parameter set is summarised in Table 5.
Floating Body and Mooring Dynamics.
The breakwater is treated as a rigid floating body. The net fluid force and torque are obtained by summing the contributions of the boundary particles that discretise the body, and the rigid-body equations of motion are integrated to update its position and orientation [15]. The four mooring lines are resolved with the lumped-mass model MoorDyn+ coupled to DualSPHysics, which captures line inertia, stiffness, hydrodynamic drag and seabed contact [14,15]; the solver is advanced with its own time step of and an initial dynamic relaxation establishes the static line equilibrium before wave generation.
Wave Generation and Absorption.
Waves are generated with the relaxation-zone (RZ) method developed for SPH by Altomare et al. [1] and refined in Altomare et al. [2]. Rather than a moving wavemaker, a generation zone near the inlet has its velocity field driven towards the target theoretical solution and blended with the computed SPH field through a spatial weighting function, so that the target waves are imposed accurately while reflected waves travelling back into the band are absorbed [1,2,19]. Regular waves use the RZ regular-wave generator and the JONSWAP cases use the RZ spectral generator; the broadband white-noise case, for which no native flat-spectrum generator exists, is imposed through the RZ as a prescribed velocity time series. A start-up ramp and a drift correction are applied. Two passive damping zones confine the basin: one immediately behind the generation zone (absorbing energy travelling back towards the inlet) and one at the down-wave end (dissipating the transmitted and any reflected waves). The body co-settles with the fluid from .
2.3.2. Finite Volume Method
As an independent, mesh-based cross-check we reproduced a subset of the regular-wave cases with the open-source finite-volume library OpenFOAM [20]. The two-phase air–water flow is solved with the interFoam solver, which advances the incompressible Navier–Stokes equations for the two immiscible phases and captures the free surface with an algebraic volume-of-fluid (VOF) scheme [21], on a boundary-fitted mesh that conforms to the keeled hull. Regular waves are imposed and absorbed at the domain boundaries, and the breakwater is treated as a rigid six-degree-of-freedom body whose motion is integrated from the resolved pressure and viscous forces on the hull. The four mooring lines are represented with the same lumped-mass model as in the SPH setup, through the MoorDyn coupling [14], so that the geometry, mooring configuration and target waves are identical between the two solvers and the comparison isolates the effect of the discretisation. Only the regular-wave cases were run with the finite-volume model; the irregular sea states were not attempted. The boundary-fitted, fully resolved computations are substantially more expensive per case than the GPU-accelerated SPH simulations, which is the main reason the finite-volume model is used here as a comparison-driven complement rather than as the primary tool. To resolve the motion of the FBW, a mesh morphing technique was used such that the topology around the floating body remained constant and only the positions of the nodes changed, preserving the solid body boundary shape. OpenFOAM v2506 was used and the waves2foam wave generation tool was used at the boundaries to create waves. Simulations were done using a laminar viscous model.
Figure 2.
Plan view of the four-line mooring arrangement; colour indicates line tension. The breakwater long axis is aligned with the crests; waves propagate along x.
Figure 2.
Plan view of the four-line mooring arrangement; colour indicates line tension. The breakwater long axis is aligned with the crests; waves propagate along x.
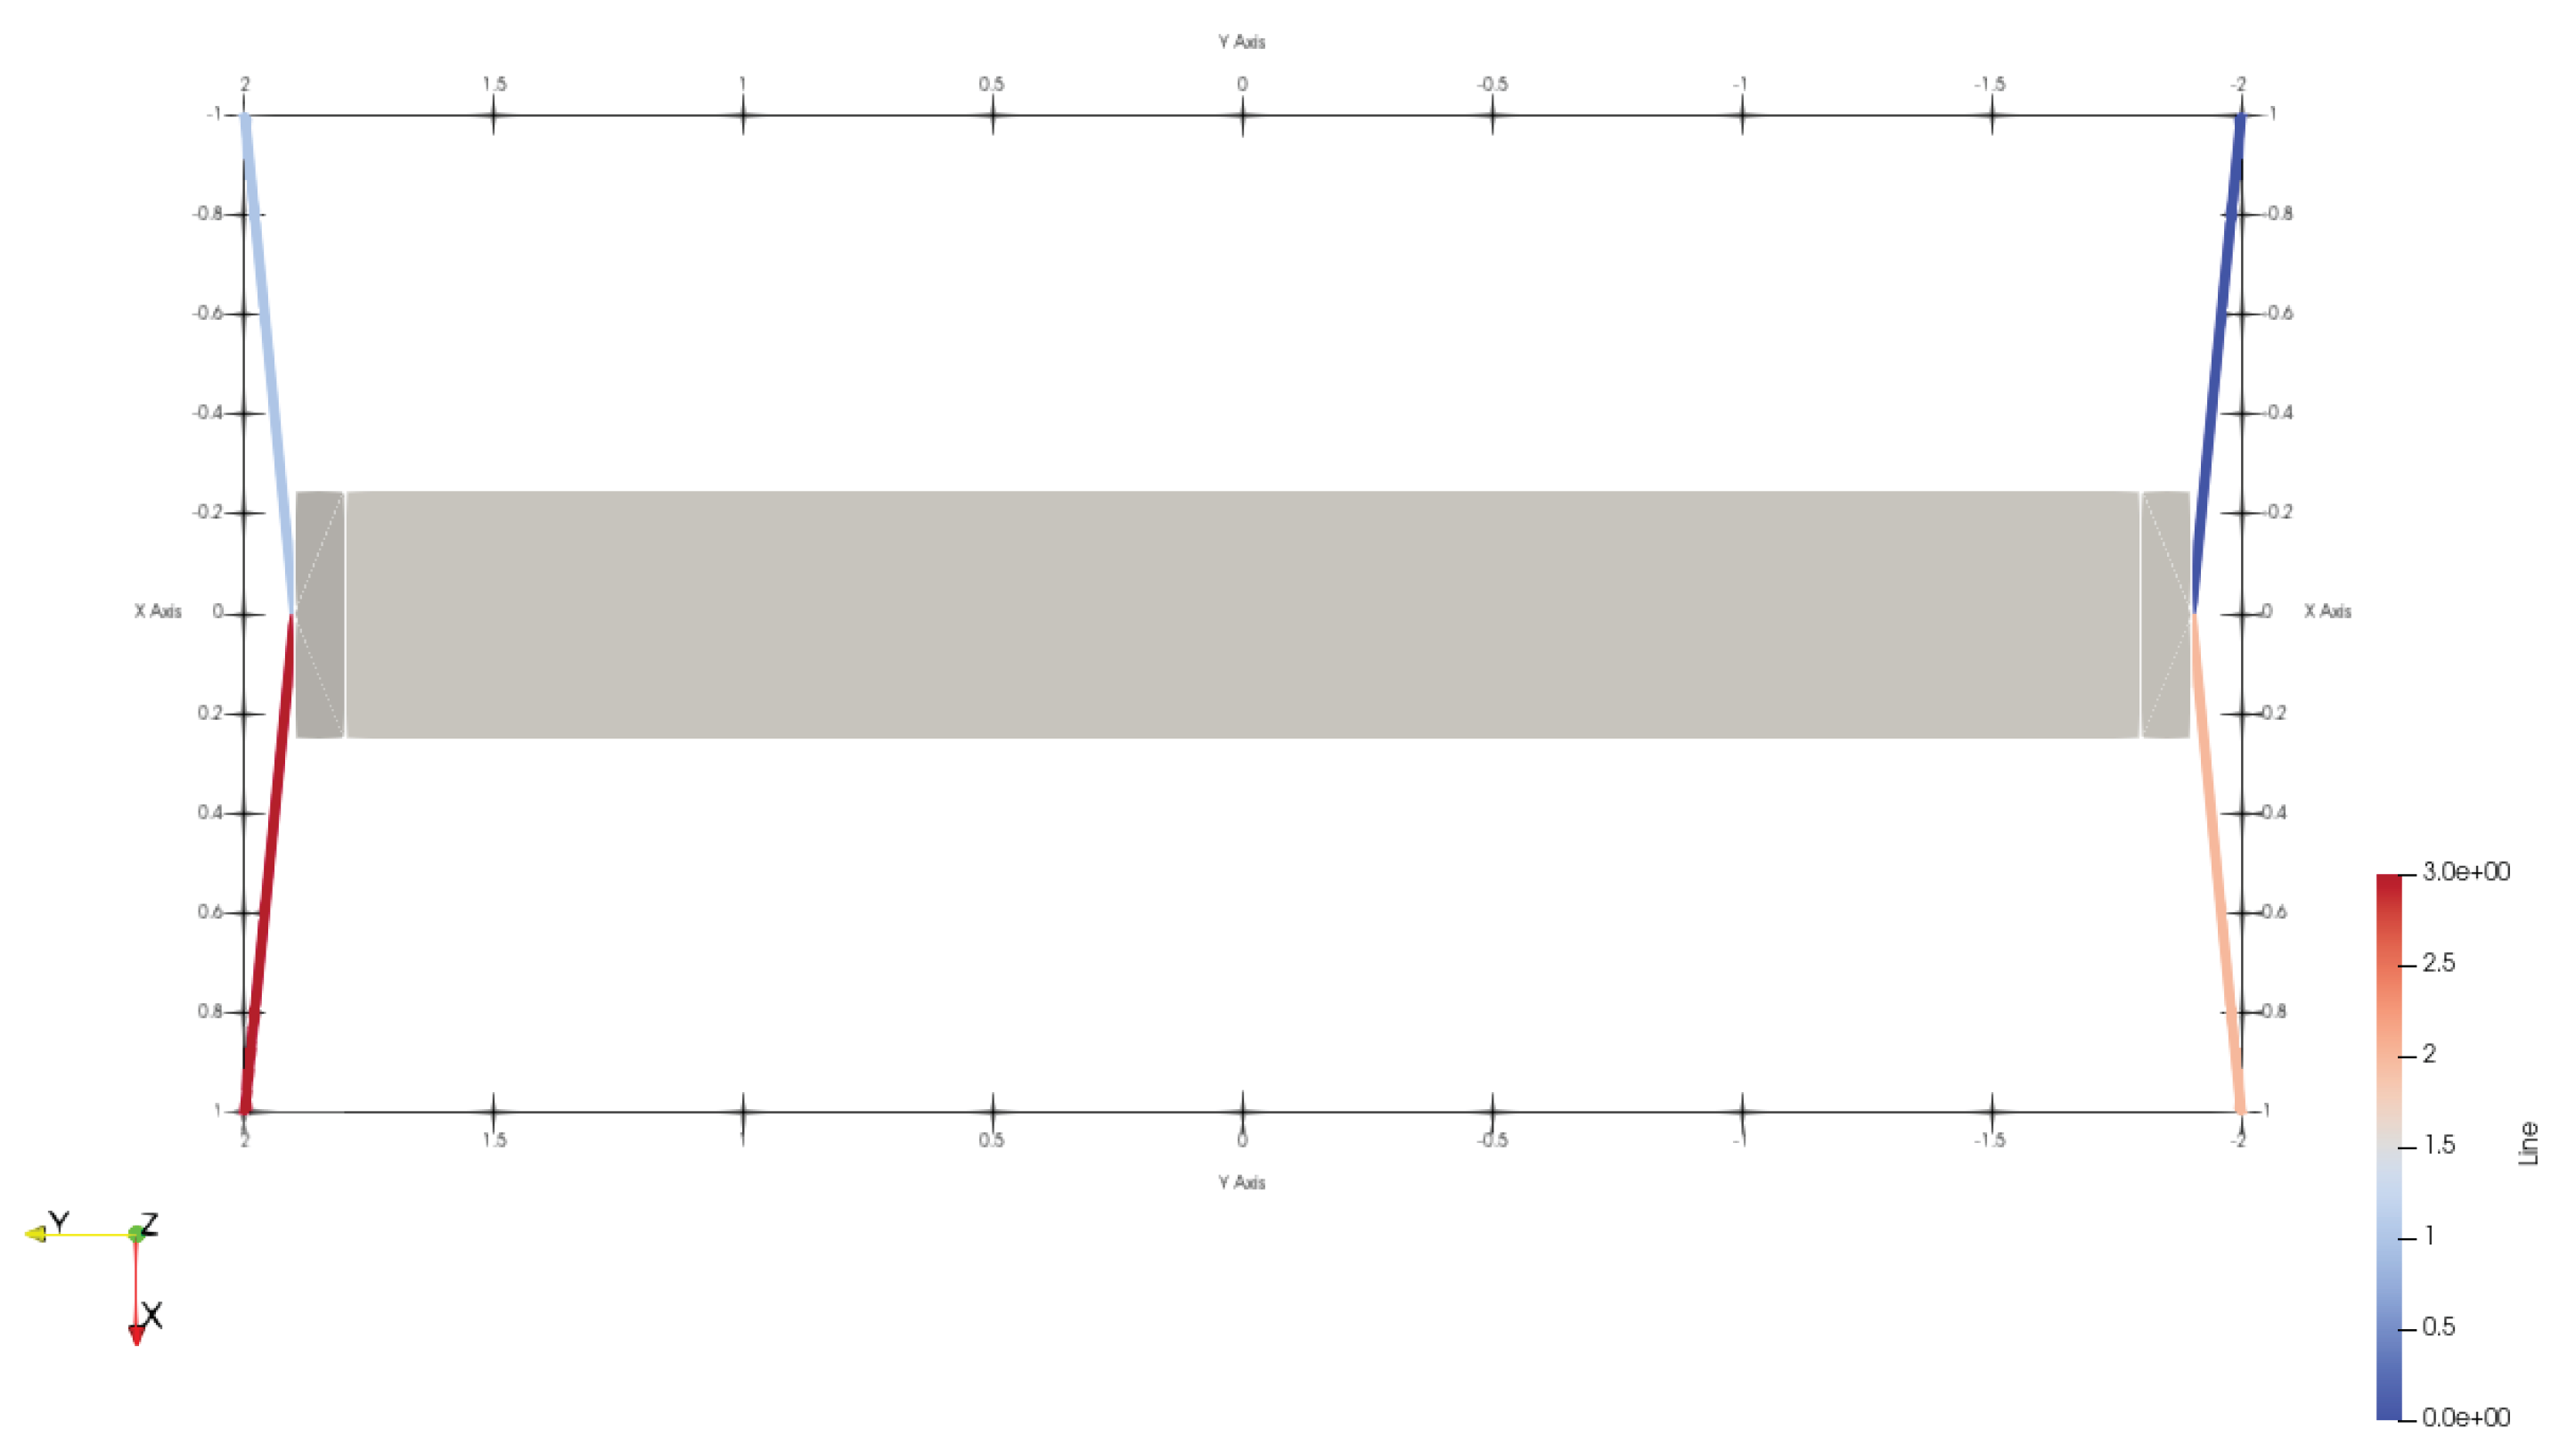
Figure 3.
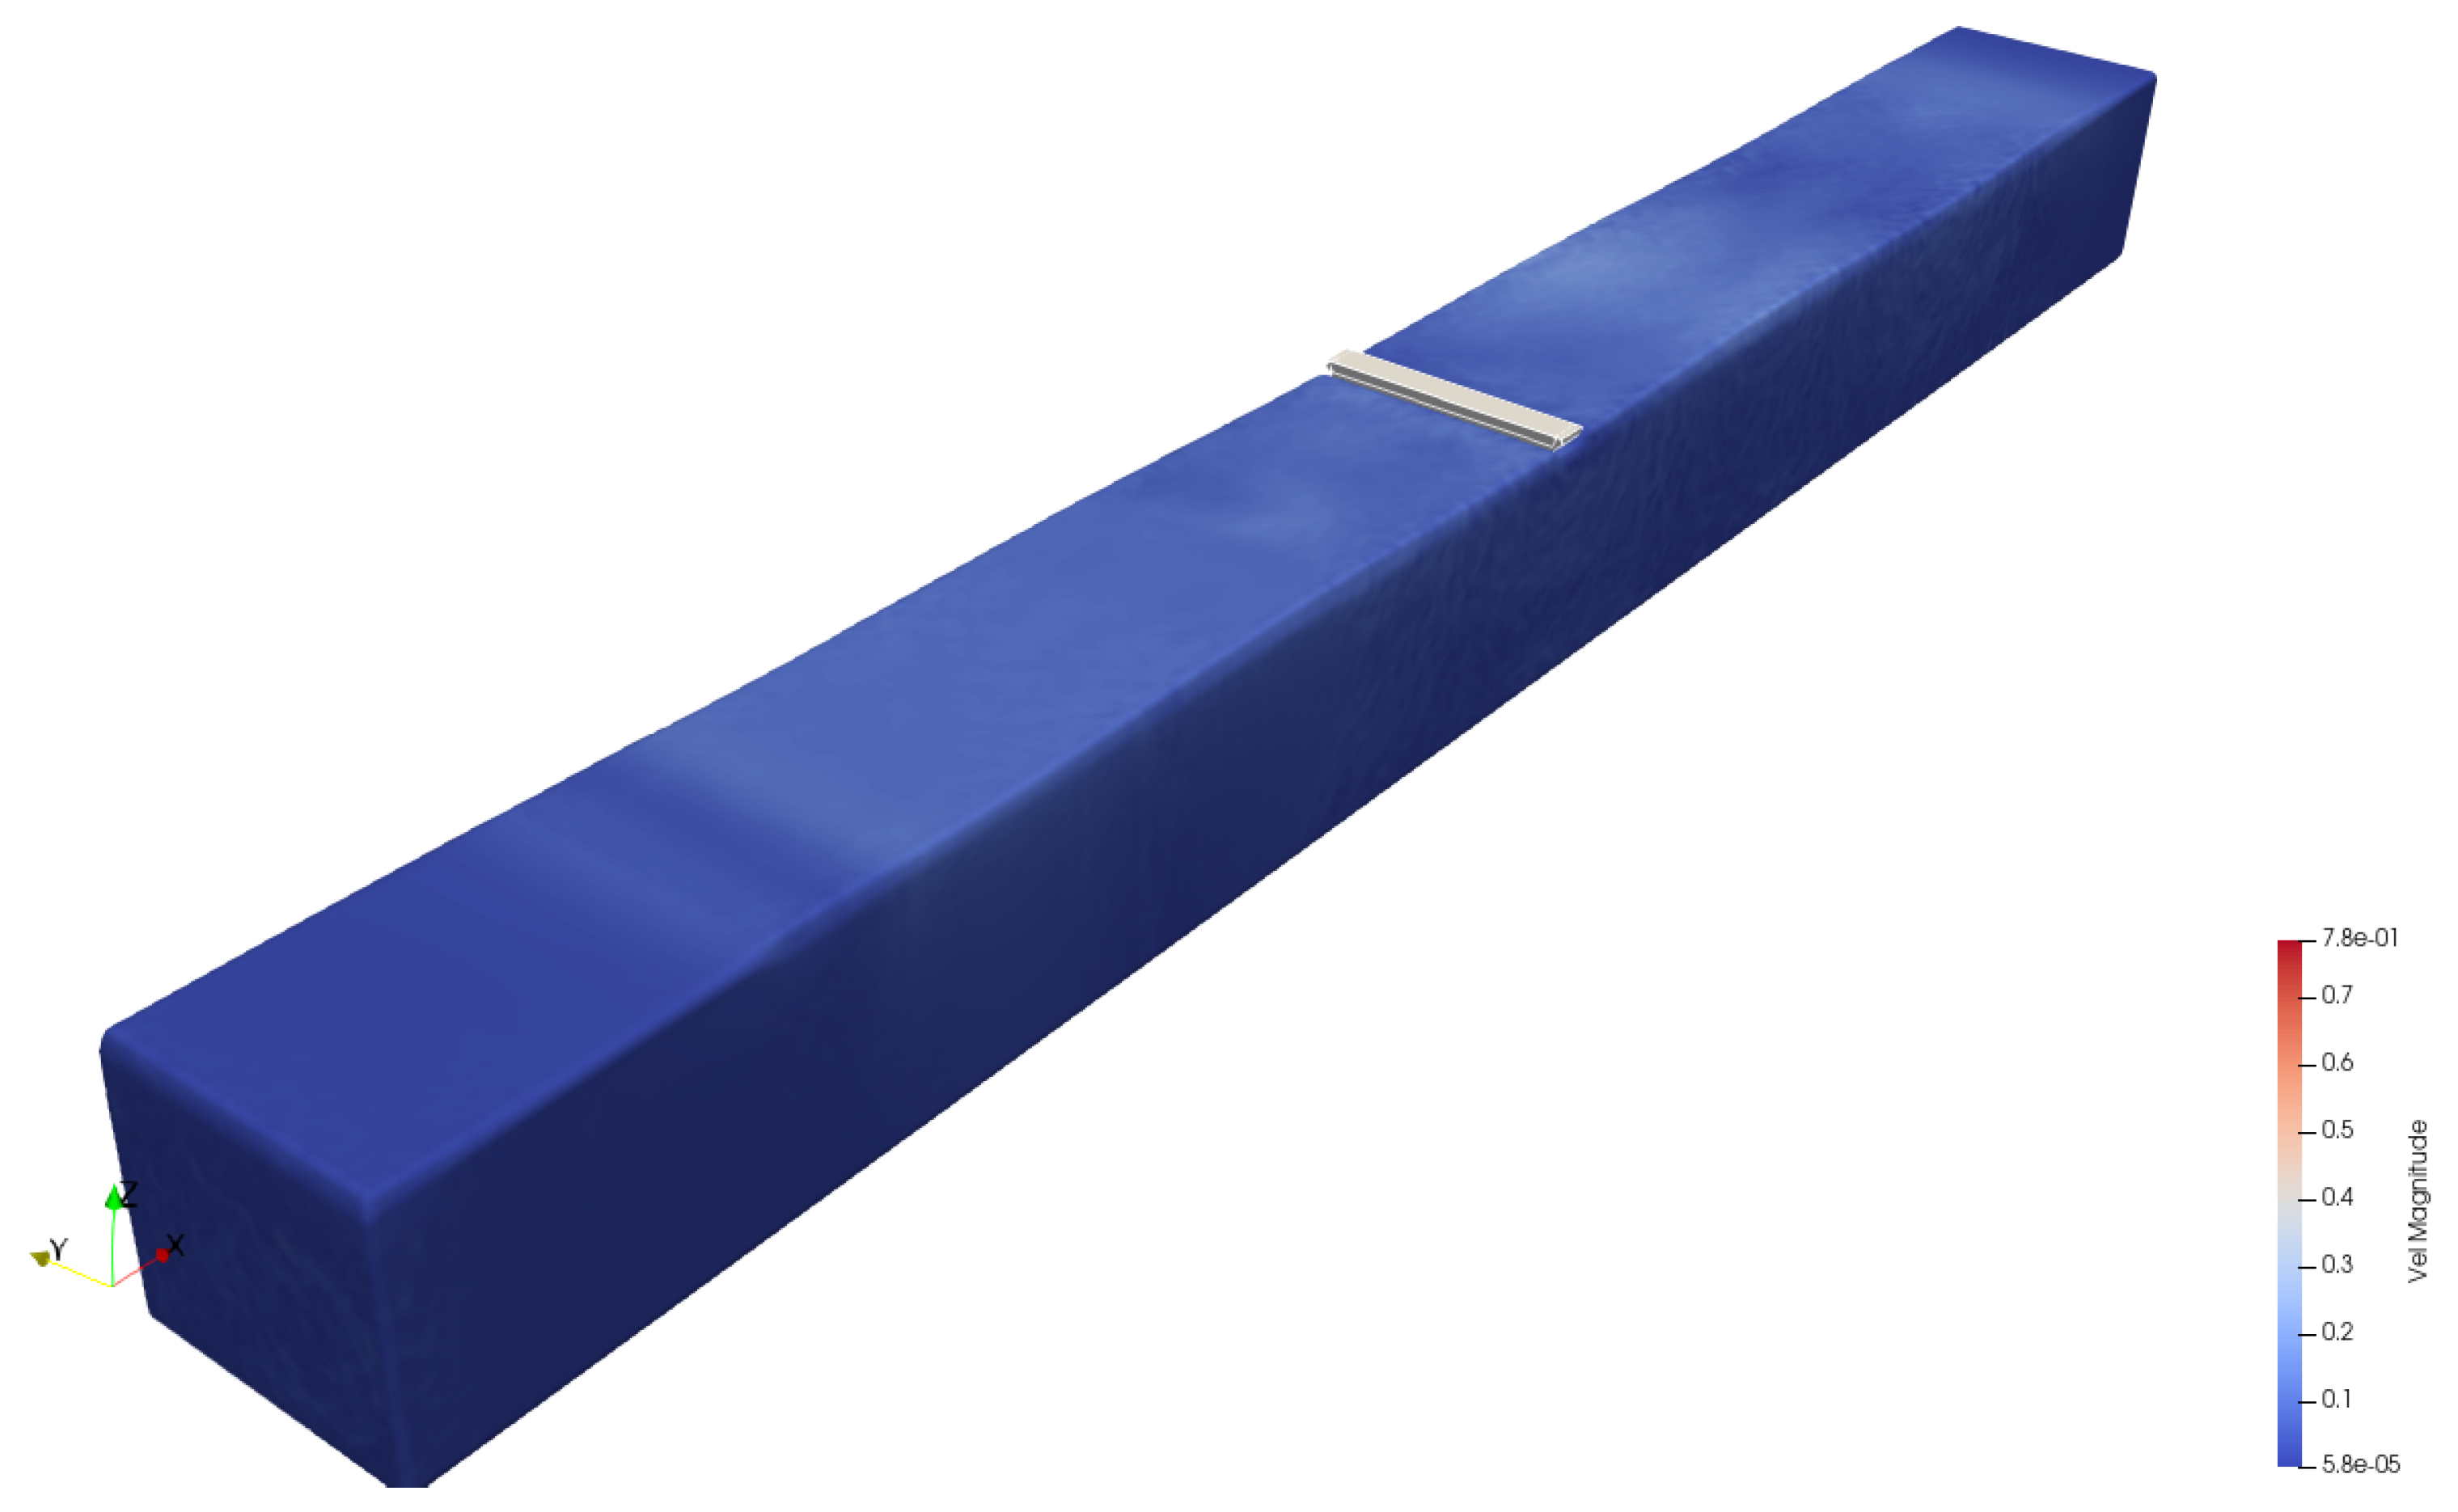
SPH numerical wave tank with the floating breakwater; colour shows velocity magnitude.
3. Results
3.1. Regular Wave Analysis
The regular-wave cases verify how closely the SPH model reproduces the measured response condition by condition. Figure 4 shows the wave generation: the incident wave amplitude recovered from a two-probe up-wave decomposition follows the target across the range (panel a), and the transmission coefficient rises with period while the reflection coefficient falls (panel b).
Figure 5 compares the wave-frequency (first-harmonic) response amplitudes for heave, roll and sway against the experiment, for both particle resolutions. The response approaches the measured amplitudes for the longer, better-resolved waves and is increasingly under-predicted towards the shortest periods, consistent with the short waves being resolved by only a few particle spacings.
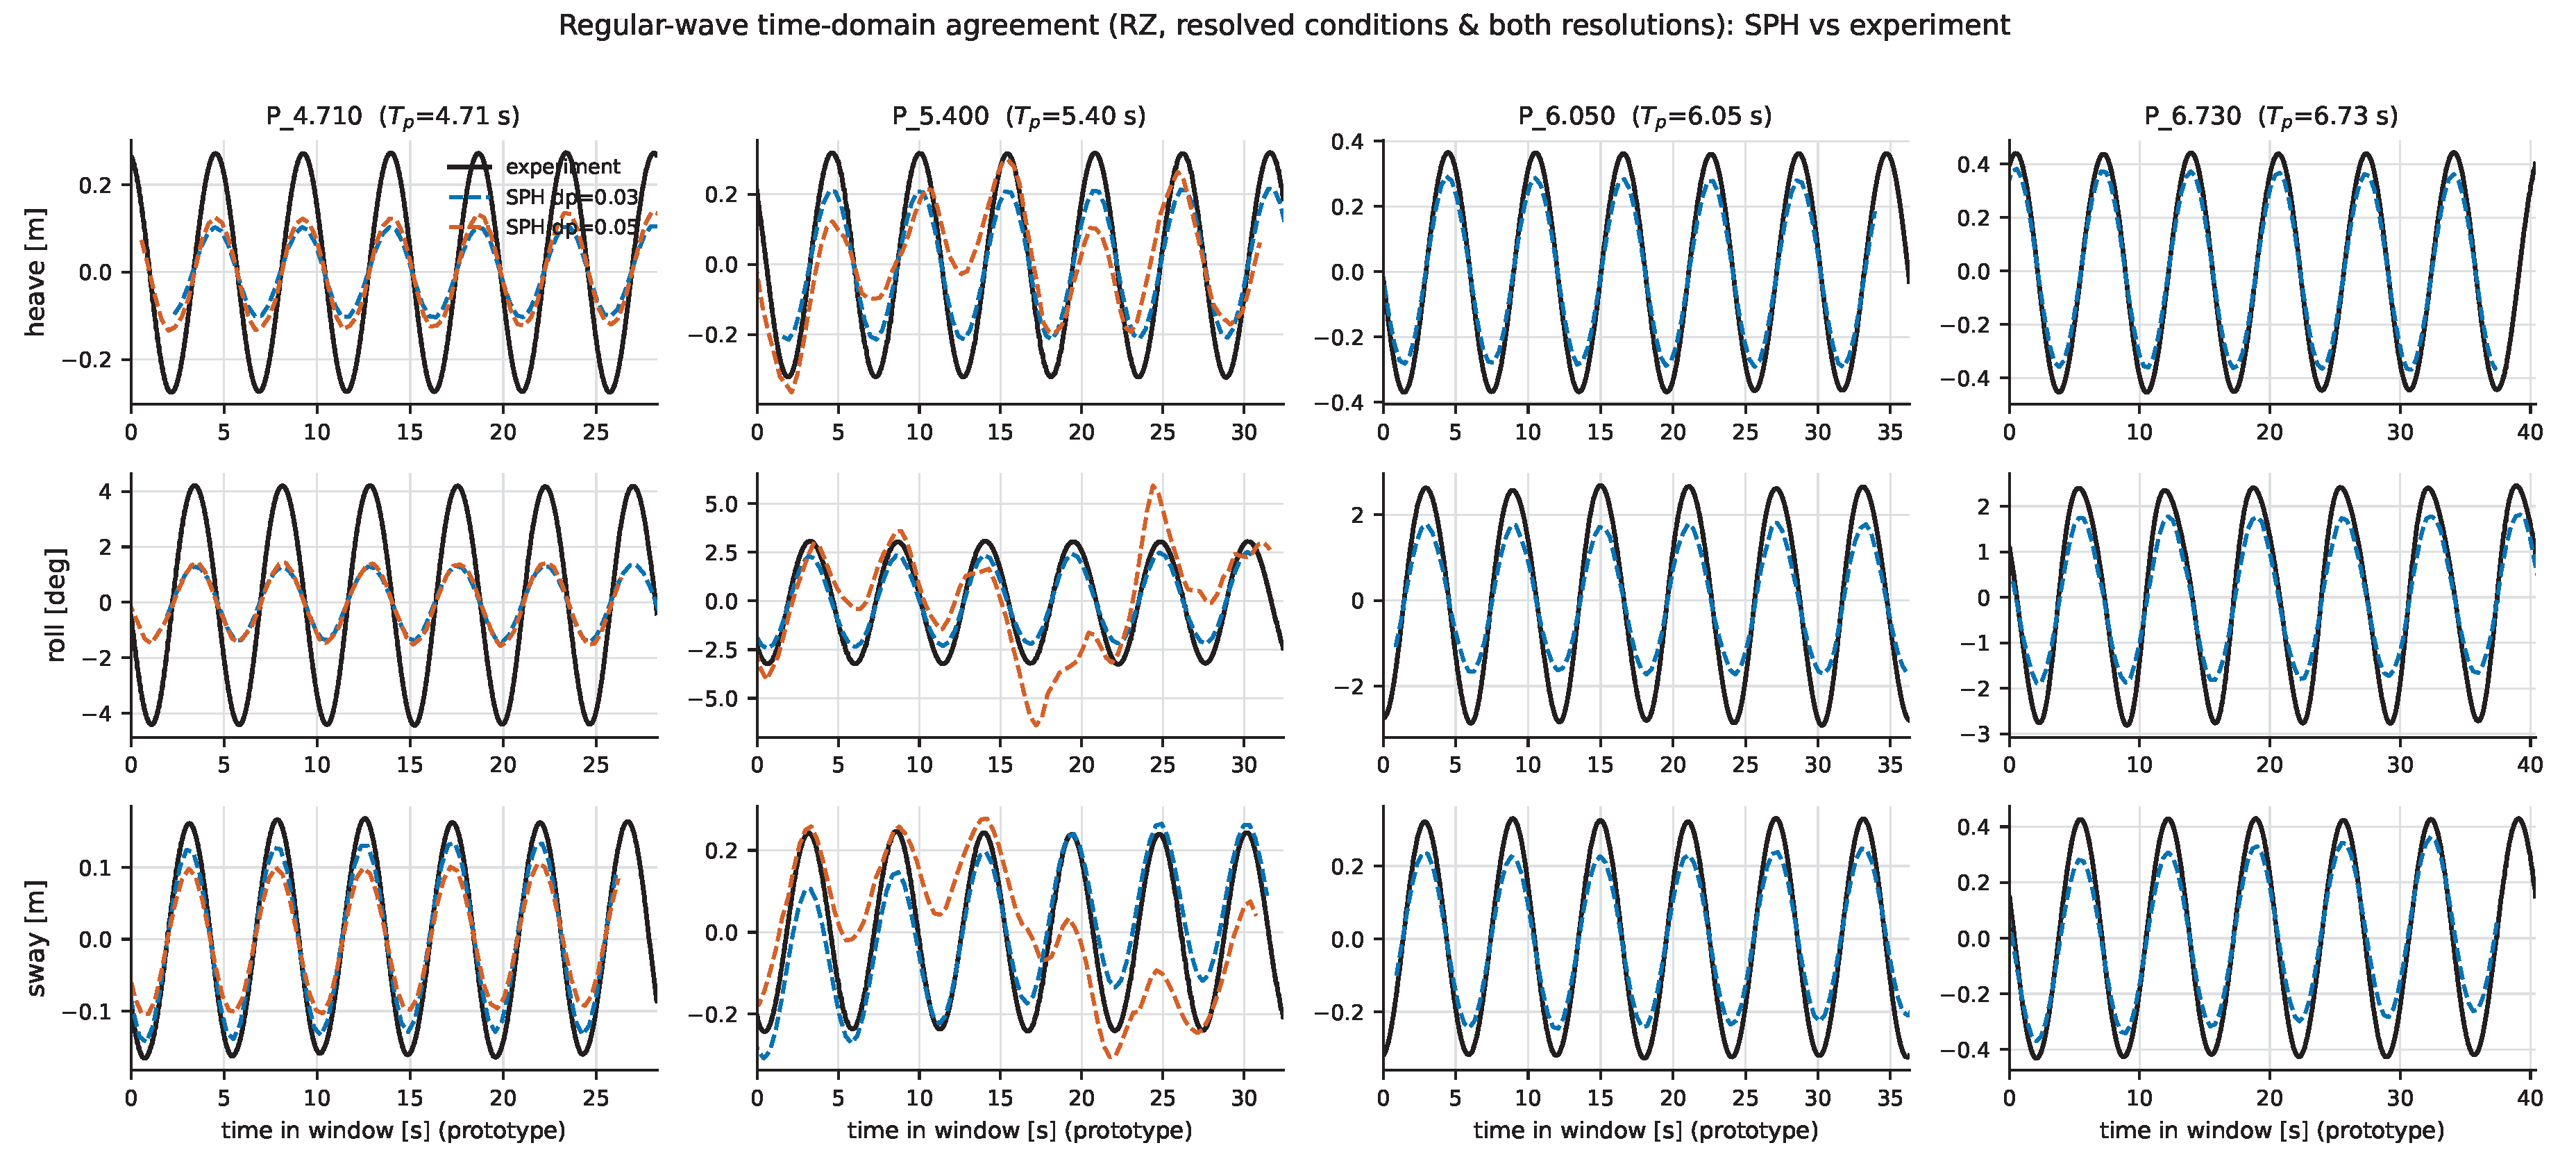
Figure 6 shows the phase-aligned time histories of heave, roll and sway for the well-resolved conditions (– ); A fuller overview across the resolved conditions at both particle resolutions is given in Figure 12. Phase agreement is close throughout, and the amplitude agreement is good for the longer periods.
3.2. Complementary Finite-Volume Results
As an independent cross-check on the SPH predictions, a subset of the regular-wave cases was reproduced with a boundary-fitted finite-volume (FVM) solver (OpenFOAM). Because the two solvers share the same geometry, mooring configuration and target waves, the comparison isolates the effect of the discretisation approach. The two methods are best viewed as complementary rather than competing, each being most reliable in a different part of the parameter space.
Figure 7 compares the wave-frequency motion amplitudes of experiment, SPH and FVM across the period range. At the longer, more energetic periods the SPH amplitudes approach the measured heave, roll and sway, and the FVM results lie close by. At the shortest periods the SPH model under-predicts the heave and, most markedly, the roll response, whereas the boundary-fitted FVM recovers them. This short-period deficit is a genuine feature of the present SPH configuration rather than a numerical artefact: it does not diminish under mesh refinement (the finer 0.03 m particle spacing gives essentially the same amplitudes as the coarser 0.05 m spacing), and the SPH incident wave at these periods is at or slightly above the target height, so the deficit reflects the modelled body response and not the wave input. To quantify the effect, at a prototype period of 4.71 s the roll amplitude is 4.31 deg in the experiment, 1.44 deg in SPH and 4.55 deg in FVM, while the corresponding heave amplitudes are 0.27, 0.13 and 0.29 m; at the shortest period with finite-volume data, 4.05 s, the roll is 5.77 deg measured, 1.05 deg in SPH and 3.87 deg in FVM. In other words the SPH model recovers only about one third of the measured short-period roll, whereas the finite-volume model recovers essentially all of it, although at a much higher computational cost..
Figure 8 shows the phase-aligned time histories at a prototype period of 4.71 s. The FVM waveforms lie almost on top of the measured heave and roll, while the SPH response is in phase with the experiment but of noticeably smaller amplitude, consistent with the short-period under-prediction noted above.
Figure 9 compares the wave-frequency amplitude of the fairlead line tension for the experiment and the FVM model; the FVM amplitude follows the measured trend across the full period range. The SPH mooring is omitted from this comparison because its lines are far less pretensioned than in the physical model and go slack within each wave cycle (snap loading), so its wave-frequency amplitude is not a like-for-like measure of the dynamic load. The mean pretension also differs between the numerical models and the experiment, a known offset, so only the dynamic, wave-frequency amplitude is compared here.
Because the boundary-fitted, fully resolved simulations are considerably more expensive than the GPU-accelerated SPH runs and were applied only to a subset of the regular-wave cases, their role is to bound the discretisation error and to show where the two approaches agree and diverge. The motion comparison of Figure 7 is therefore shown alongside the SPH-only result of Figure 5
3.3. Irregular Wave Analysis
The irregular sea states assess the model under realistic, broadband excitation. Figure 10 shows the response amplitude operators (RAOs) for heave, roll and sway, extracted from the irregular records as the ratio of the response to the incident-wave spectrum, with the three sea states overlapping where their frequency ranges meet. Roll is reported in the non-dimensional form . The experiment shows a heave/roll resonance near –; the SPH RAOs are smoother and monotonic over the resolved band, while sway decays monotonically in both.
Figure 11 shows the frequency-dependent transmission coefficient : the SPH result is compared with the experimental transmission and with the reference curve of Ruol et al [22] . The SPH transmission tracks the reference and the experimental roll-off closely.
Figure 12.
Supplementary: regular-wave time-domain agreement for the resolved conditions at both resolutions ( m in blue, in vermillion), SPH versus experiment.
Figure 12.
Supplementary: regular-wave time-domain agreement for the resolved conditions at both resolutions ( m in blue, in vermillion), SPH versus experiment.
4. Discussion
Taken together, the results indicate that the SPH model reproduces the most important sea states with reasonable accuracy, and that its strongest, most decision-relevant result is the wave transmission: across the assessed conditions the transmission coefficient tracks both the reference theory and the experiment closely. This matters because, for the protected FPV array, the frequency-dependent transmission is the key performance metric. The breakwater passes most of the long-period energy but strongly attenuates the short, steep waves that are the most damaging to the module interconnections, so it is most effective precisely in the band where the array is most vulnerable.
The breakwater motions are also captured reasonably well, but with a clear resolution dependence. The agreement is best for the longer, well-resolved waves and degrades towards the high-frequency, short-wavelength conditions, where the wave is represented by only a few particle spacings. Refining the particle size yields only a minor improvement, which suggests that the short-period shortfall is not a simple matter of numerical convergence. The natural frequencies of the system are nonetheless recovered, and the predicted motions fit the measurements with reasonable accuracy despite the limited resolution; the main casualty is the resonant amplification seen in the experiments, which the present setup does not reproduce. Heave is somewhat under-predicted, and this may stem as much from imperfect wave generation by the relaxation-zone method, or from under-resolved reflection, as from the body response itself.
The mooring and connector loads deserve particular attention because they are the design-limiting quantity for the protected array. The fairlead dynamic tension grows steeply with wave period (Figure 9), and the finite-volume model reproduces this measured dynamic load across the full period range. The SPH mooring, however, is far less pretensioned than in the physical model and its lines go slack within each wave cycle (snap loading), so it cannot represent the wave-frequency tension on a comparable basis. Reliable mooring-load estimates therefore rest on the taut-line behaviour captured by the finite-volume model and the experiment, and the SPH mooring would need to be re-pretensioned before it is used for load prediction.
Finally, the behaviour observed here is consistent with the keel playing a central role in dissipating near-surface wave energy. Building on earlier Eulerian free-surface modelling of surf-zone dynamics [16], the present results suggest that the keel redirects and dissipates the incident energy rather than simply reflecting it, and it is this mechanism that allows the structure to attenuate the shorter, steeper waves so effectively.
5. Conclusions
An SPH model of a moored keeled floating breakwater was built in DualSPHysics with relaxation-zone wave generation [1,2] and assessed against wave-basin experiments under both regular and irregular sea states. The model reproduces the principal motions of the breakwater and, most importantly, the wave transmission with reasonable accuracy, although the reliability of these predictions is confined to the well-resolved sea states: the high-frequency, low-energy conditions remain challenging, and the limited resolution of short, shallow waves can reduce the accuracy with which resonant states are reproduced.
The most consequential limitation is at the short periods, where the model recovers only about a third of the measured roll and heave and does not reproduce the experimental resonance. This deficit is a genuine feature of the modelled body response: it neither improves appreciably with mesh refinement nor arises from an under-generated incident wave. A boundary-fitted finite-volume model (OpenFOAM), run on a subset of the regular cases, recovers the short-period roll and heave that the SPH model under-predicts, which confirms that the short-period motion gap is a discretisation effect rather than an error in the shared geometry, mooring or wave definition. The finite-volume model also reproduces the dynamic mooring load, which the present SPH setup cannot, its under-pretensioned lines going slack within each cycle. The finite-volume computations are, however, considerably more expensive per case, so the GPU-accelerated SPH model remains the more practical tool for surveying a broad matrix of sea states, with the finite-volume model reserved as a targeted, higher-fidelity check where short-period accuracy is critical.
For design use, the SPH model is therefore well suited to predicting wave transmission and the principal motions in the operational, longer-period band, while short-period motion and peak mooring-load estimates should be cross-checked against a mesh-based method or against experiment.
Acknowledgments
The present study is part of the SUREWAVE project, Funded by the European Union with GA No. 101083342. Views and opinions expressed are however those of the author(s) only and do not necessarily reflect those of the European Union. Neither the European Union nor the granting authority can be held responsible for them.
References
- Altomare, C.; Domínguez, J.M.; Crespo, A.J.C.; González-Cao, J.; Suzuki, T.; Gómez-Gesteira, M.; Troch, P. Long-crested wave generation and absorption for SPH-based DualSPHysics model. Coastal Engineering 2017, 127, 37–54. [CrossRef]
- Altomare, C.; Tagliafierro, B.; Domínguez, J.M.; Suzuki, T.; Viccione, G. Improved relaxation zone method in SPH-based model for coastal engineering applications. Applied Ocean Research 2018, 81, 15–33. [CrossRef]
- Liu.; et al. Review of recent offshore floating photovoltaic systems. Energies / Review 2024.
- Djalab, A.; et al. A comprehensive review of floating photovoltaic systems: technological advances and marine environmental influences. Renewable and Sustainable Energy Reviews 2024.
- Nysted.; et al. Floating photovoltaics: modelled and experimental operating temperatures and the impact of wind speed. Solar Energy 2024.
- C, J.; et al. Design study on the parameters influencing the performance of floating solar PV. Renewable Energy 2024.
- Mut.; et al. Numerical simulation of extreme wave-wind conditions effects on a real field floating photovoltaic plant. Ocean Engineering 2024.
- Zhang.; et al. Development of a compliant modular floating photovoltaic farm for coastal conditions. Ocean Engineering 2024.
- Zhang.; et al. Aerodynamic effects of an offshore floating photovoltaic platform undergoing pitch and heave motions. Renewable Energy 2024.
- Panjwani, M.K. Assessment of breakwater as a protection system against aerodynamic loads acting on the floating PV. Energies 2024.
- Monaghan, J.J. Smoothed particle hydrodynamics. Annual Review of Astronomy and Astrophysics 1992, 30, 543–574. [CrossRef]
- Monaghan, J.J. Simulating free surface flows with SPH. Journal of Computational Physics 1994, 110, 399–406. [CrossRef]
- Crespo, A.J.C.; Domínguez, J.M.; Rogers, B.D.; Gómez-Gesteira, M.; Longshaw, S.; Canelas, R.; Vacondio, R.; Barreiro, A.; García-Feal, O. DualSPHysics: Open-source parallel CFD solver based on Smoothed Particle Hydrodynamics (SPH). Computer Physics Communications 2015, 187, 204–216. [CrossRef]
- Hall, M.; Goupee, A. Validation of a lumped-mass mooring line model with DeepCwind semisubmersible model test data. Ocean Engineering 2015, 104, 590–603. [CrossRef]
- Domínguez, J.M.; Crespo, A.J.C.; Hall, M.; Altomare, C.; Wu, M.; Stratigaki, V.; Troch, P.; Cappietti, L.; Gómez-Gesteira, M. SPH simulation of floating structures with moorings. Coastal Engineering 2019, 153, 103560. [CrossRef]
- Lin, P.; Liu, P.L.F. A numerical study of breaking waves in the surf zone. Journal of Fluid Mechanics 1998, 359, 239–264. [CrossRef]
- van der Zanden, J. SUREWAVE Basin Test Results, 2025. [CrossRef]
- Wendland, H. Piecewise polynomial, positive definite and compactly supported radial functions of minimal degree. Advances in Computational Mathematics 1995, 4, 389–396. [CrossRef]
- Altomare, C.; et al. DualSPHysics modelling of sea waves: new developments, capabilities and practical examples. In Proceedings of the Proceedings of the SPHERIC Workshop, 2023. Tutorial / state-of-the-art review.
- Weller, H.G.; Tabor, G.; Jasak, H.; Fureby, C. A tensorial approach to computational continuum mechanics using object-oriented techniques. Computers in Physics 1998, 12, 620–631.
- Hirt, C.W.; Nichols, B.D. Volume of fluid (VOF) method for the dynamics of free boundaries. Journal of Computational Physics 1981, 39, 201–225.
- Ruol, P.; Martinelli, L.; Pezzutto, P. Formula to predict transmission for π-type floating breakwaters. Journal of Waterway, Port, Coastal, and Ocean Engineering 2013, 139, 1–8.
Figure 1.
Geometry of the keeled floating breakwater (model scale): top, plan view; bottom left, cross-section showing the keel; bottom right, perspective view. Axis units in metres.
Figure 1.
Geometry of the keeled floating breakwater (model scale): top, plan view; bottom left, cross-section showing the keel; bottom right, perspective view. Axis units in metres.
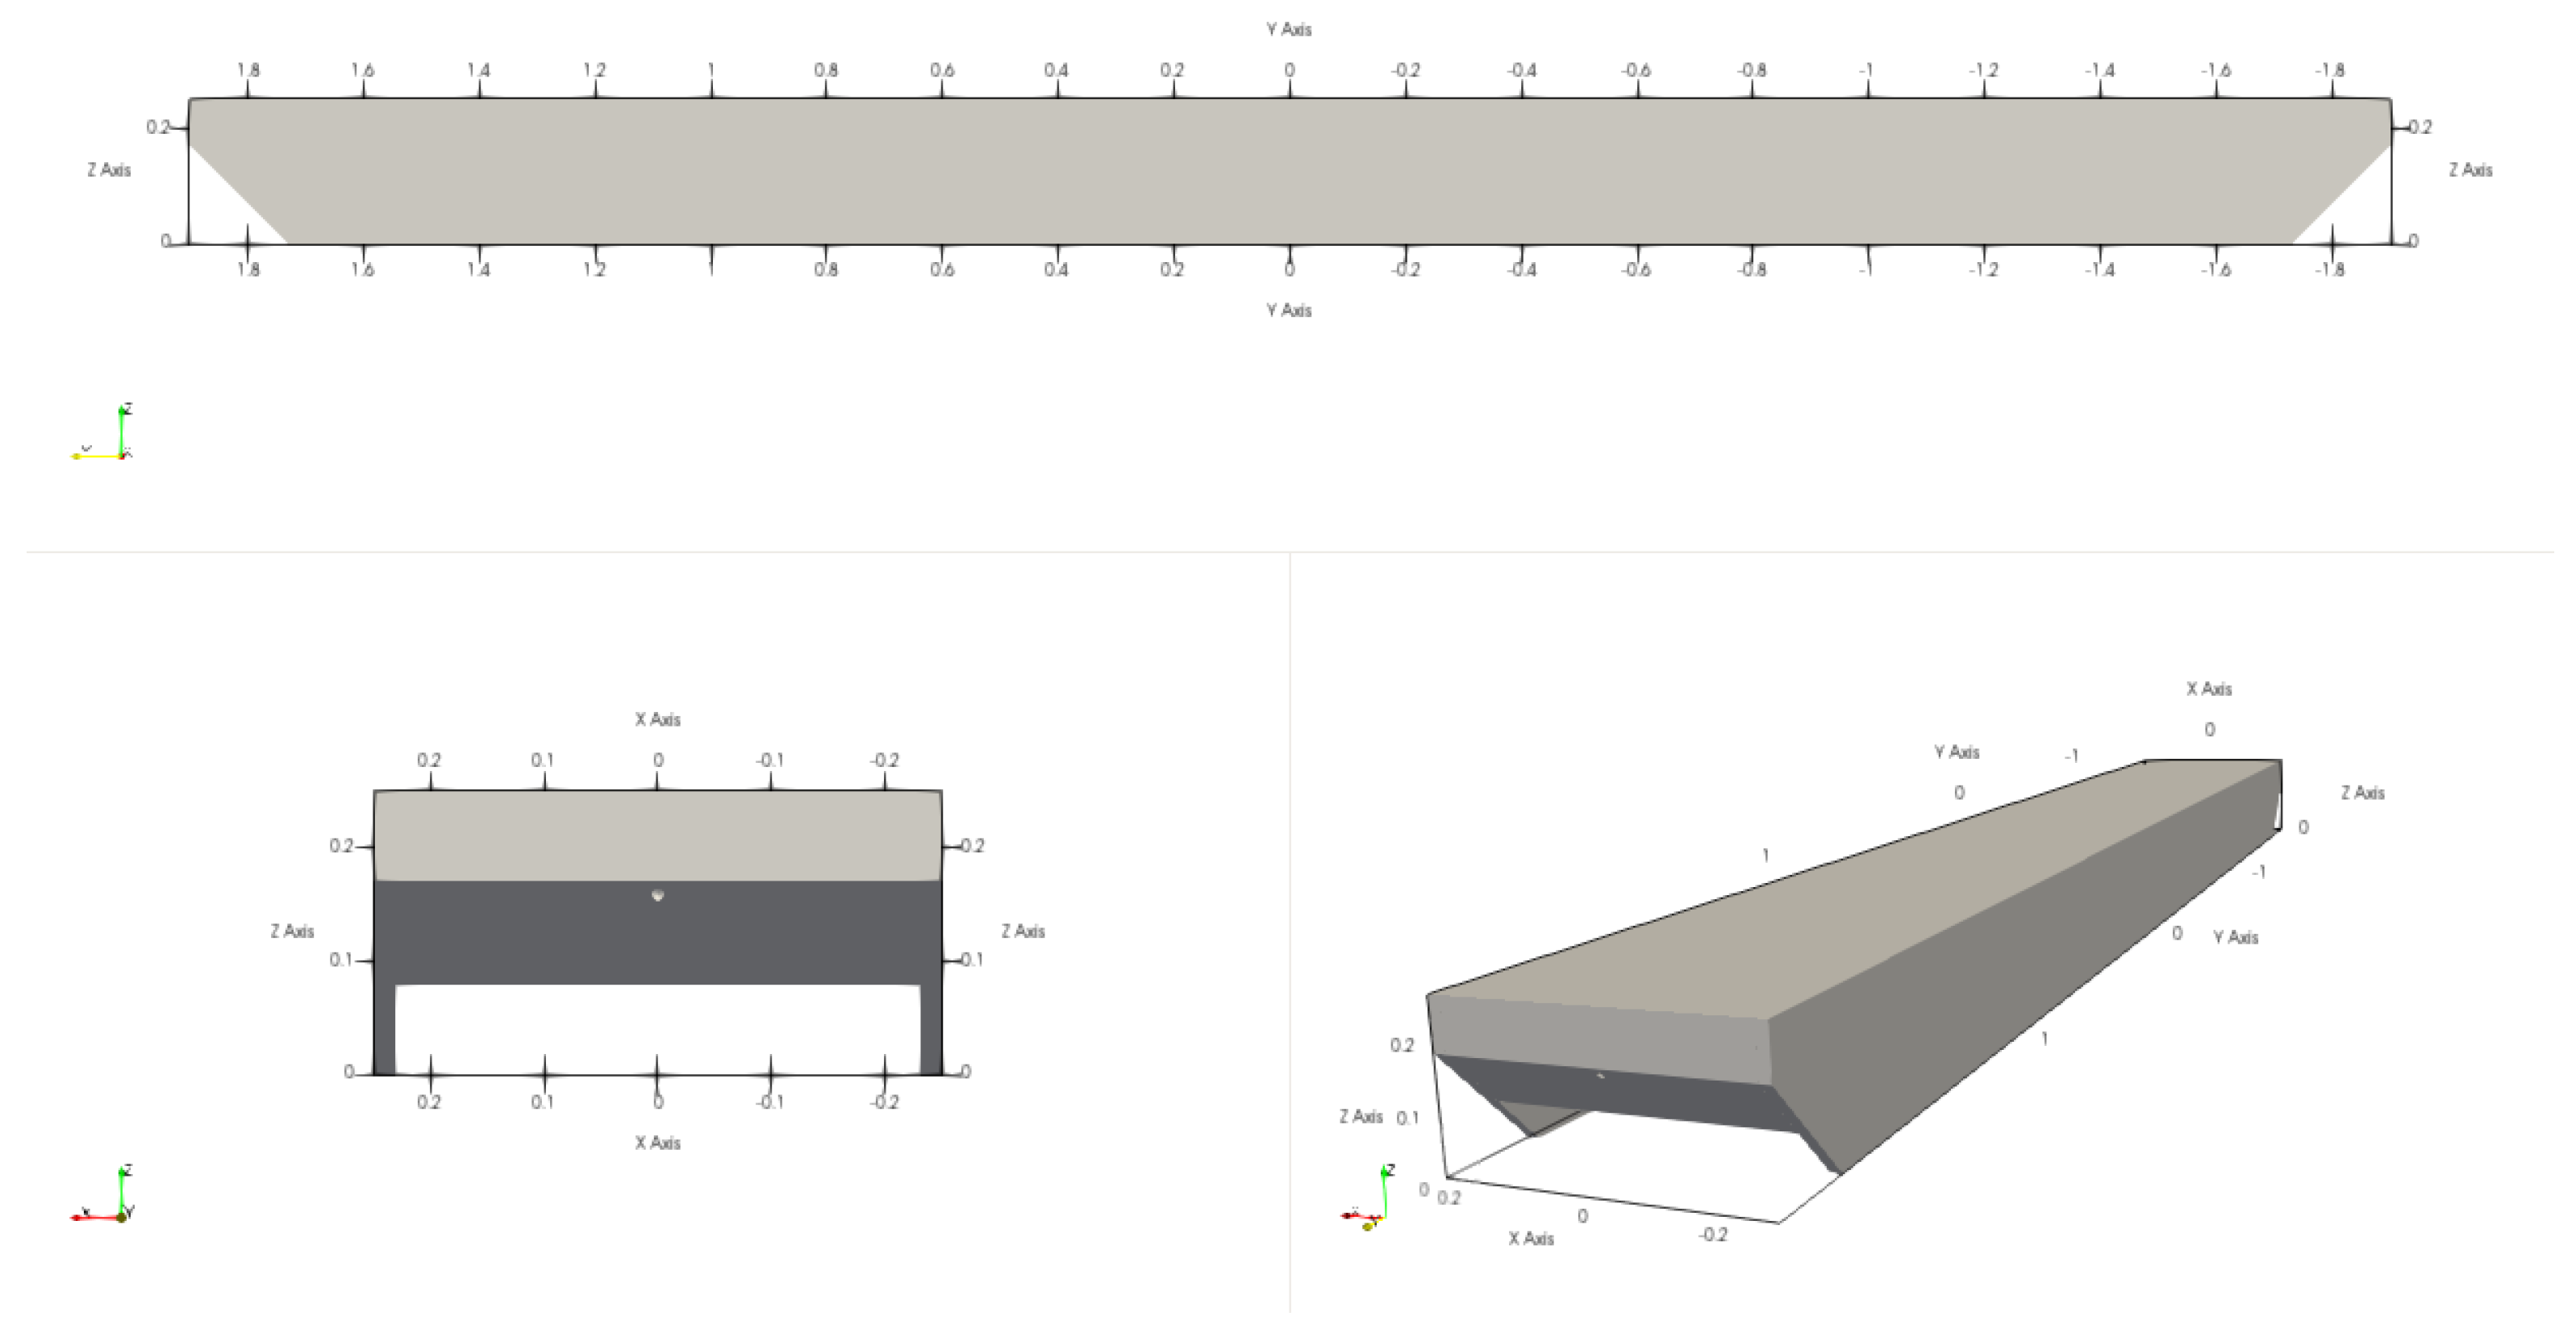
Figure 4.
Regular-wave generation. (a) Incident wave amplitude from a two-probe decomposition of the SPH free surface versus the target; (b) transmission () and reflection () coefficients. Prototype scale.
Figure 4.
Regular-wave generation. (a) Incident wave amplitude from a two-probe decomposition of the SPH free surface versus the target; (b) transmission () and reflection () coefficients. Prototype scale.
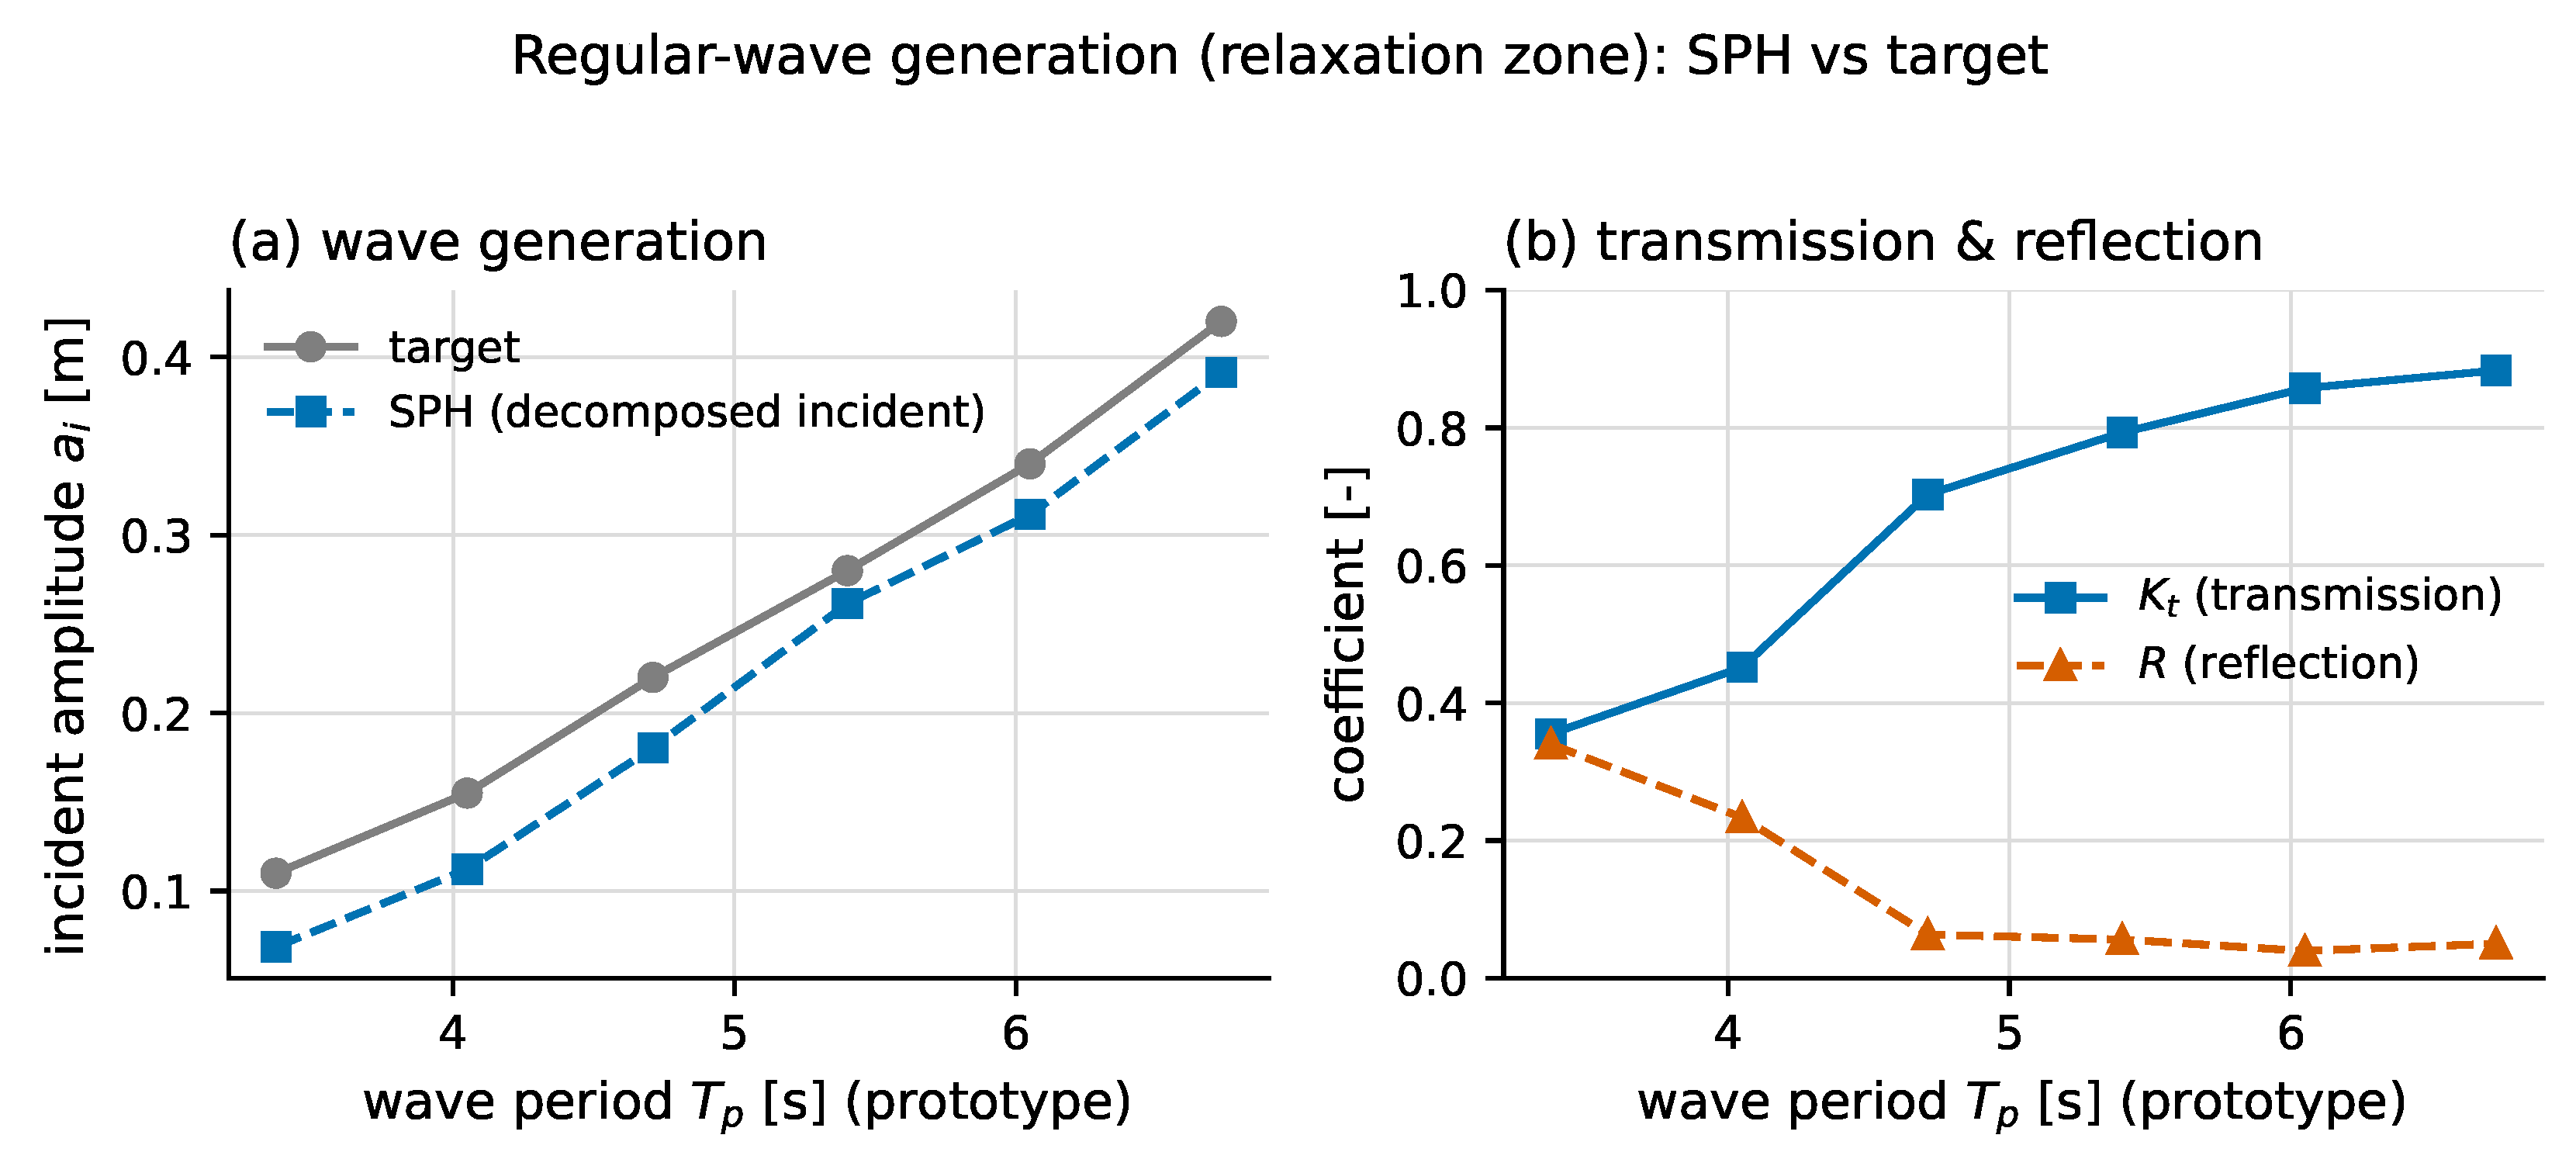
Figure 5.
Regular-wave motion response: wave-frequency amplitude of heave, roll and sway, SPH versus experiment, at both resolutions ( and ). Prototype scale.
Figure 5.
Regular-wave motion response: wave-frequency amplitude of heave, roll and sway, SPH versus experiment, at both resolutions ( and ). Prototype scale.
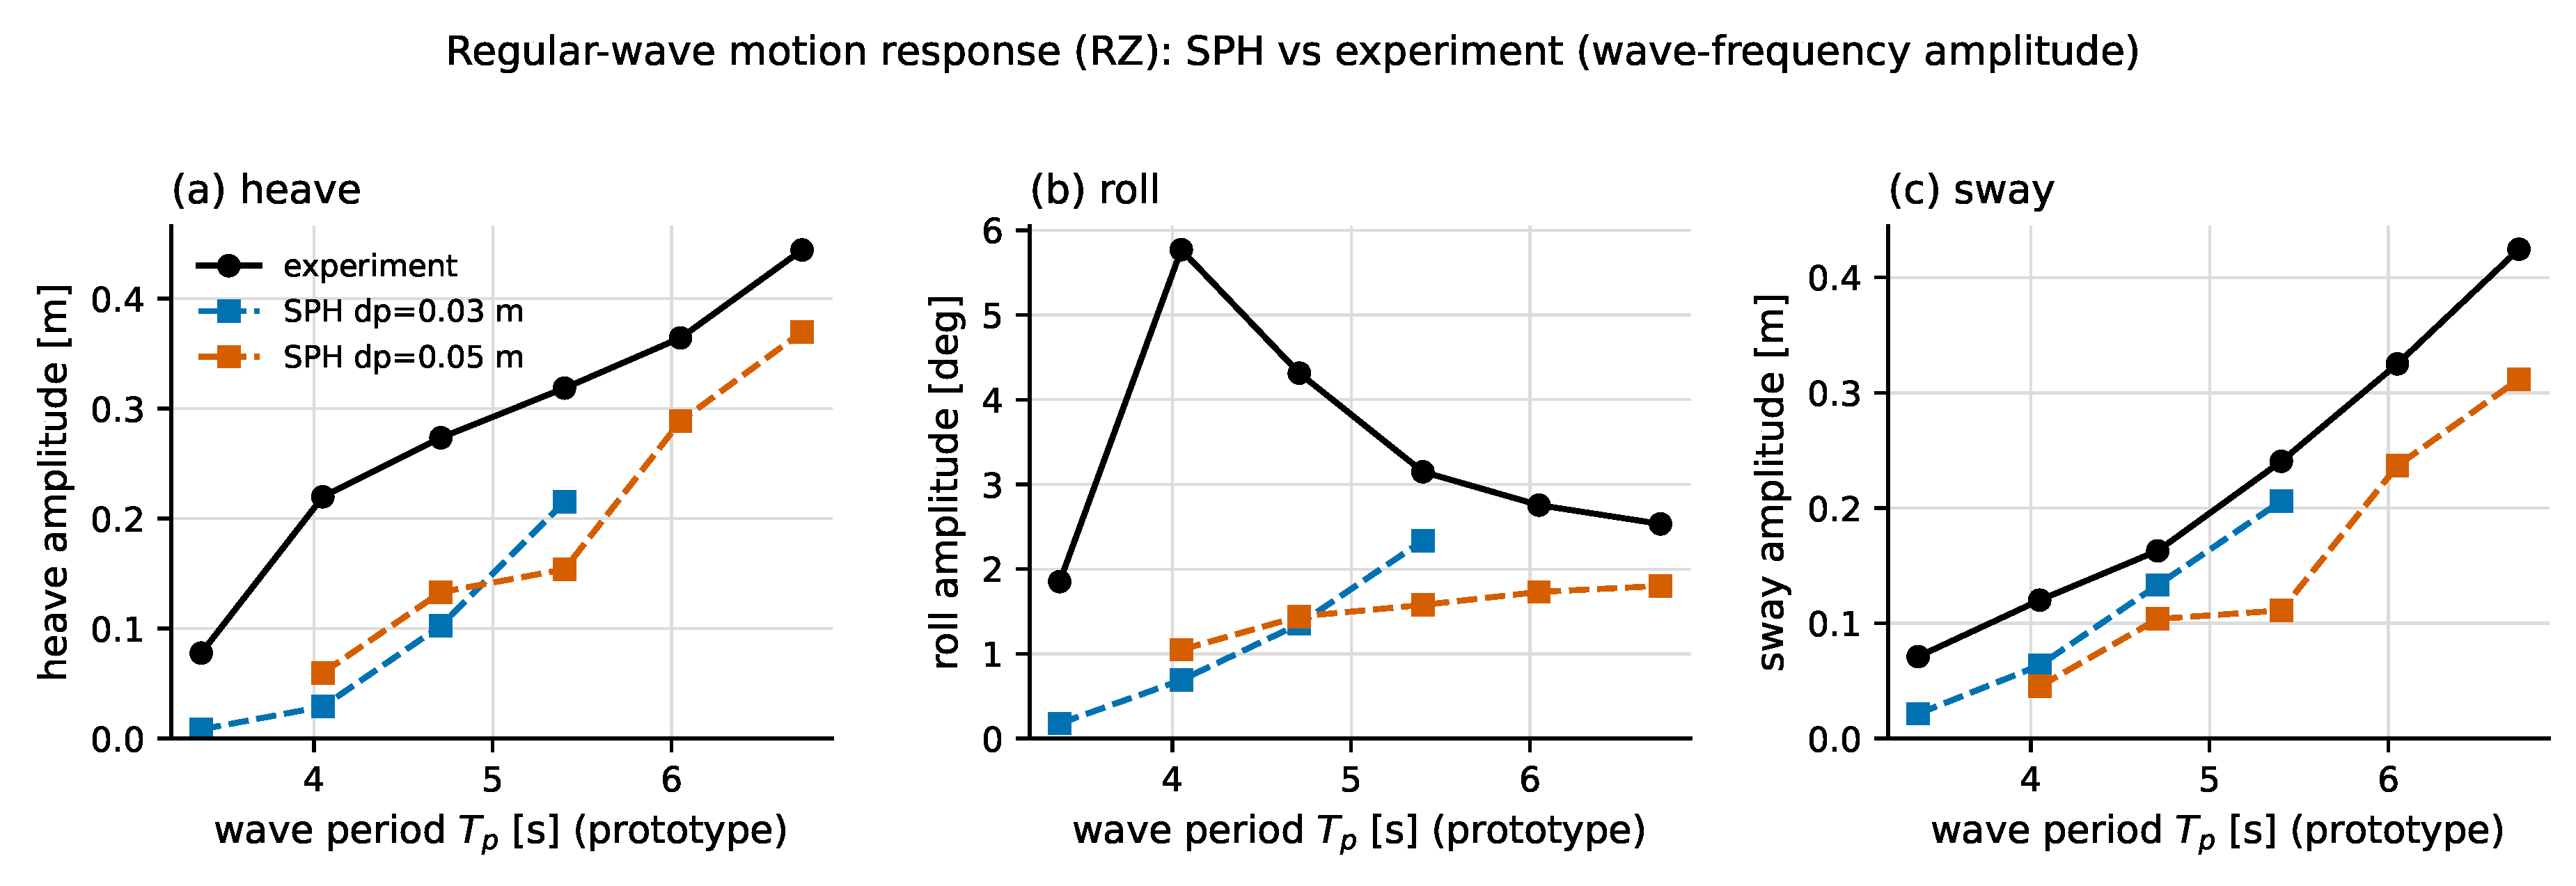
Figure 6.
Regular-wave time-domain agreement for the selected well-resolved conditions (, , , ): phase-aligned heave, roll and sway, SPH versus experiment. Prototype scale.
Figure 6.
Regular-wave time-domain agreement for the selected well-resolved conditions (, , , ): phase-aligned heave, roll and sway, SPH versus experiment. Prototype scale.
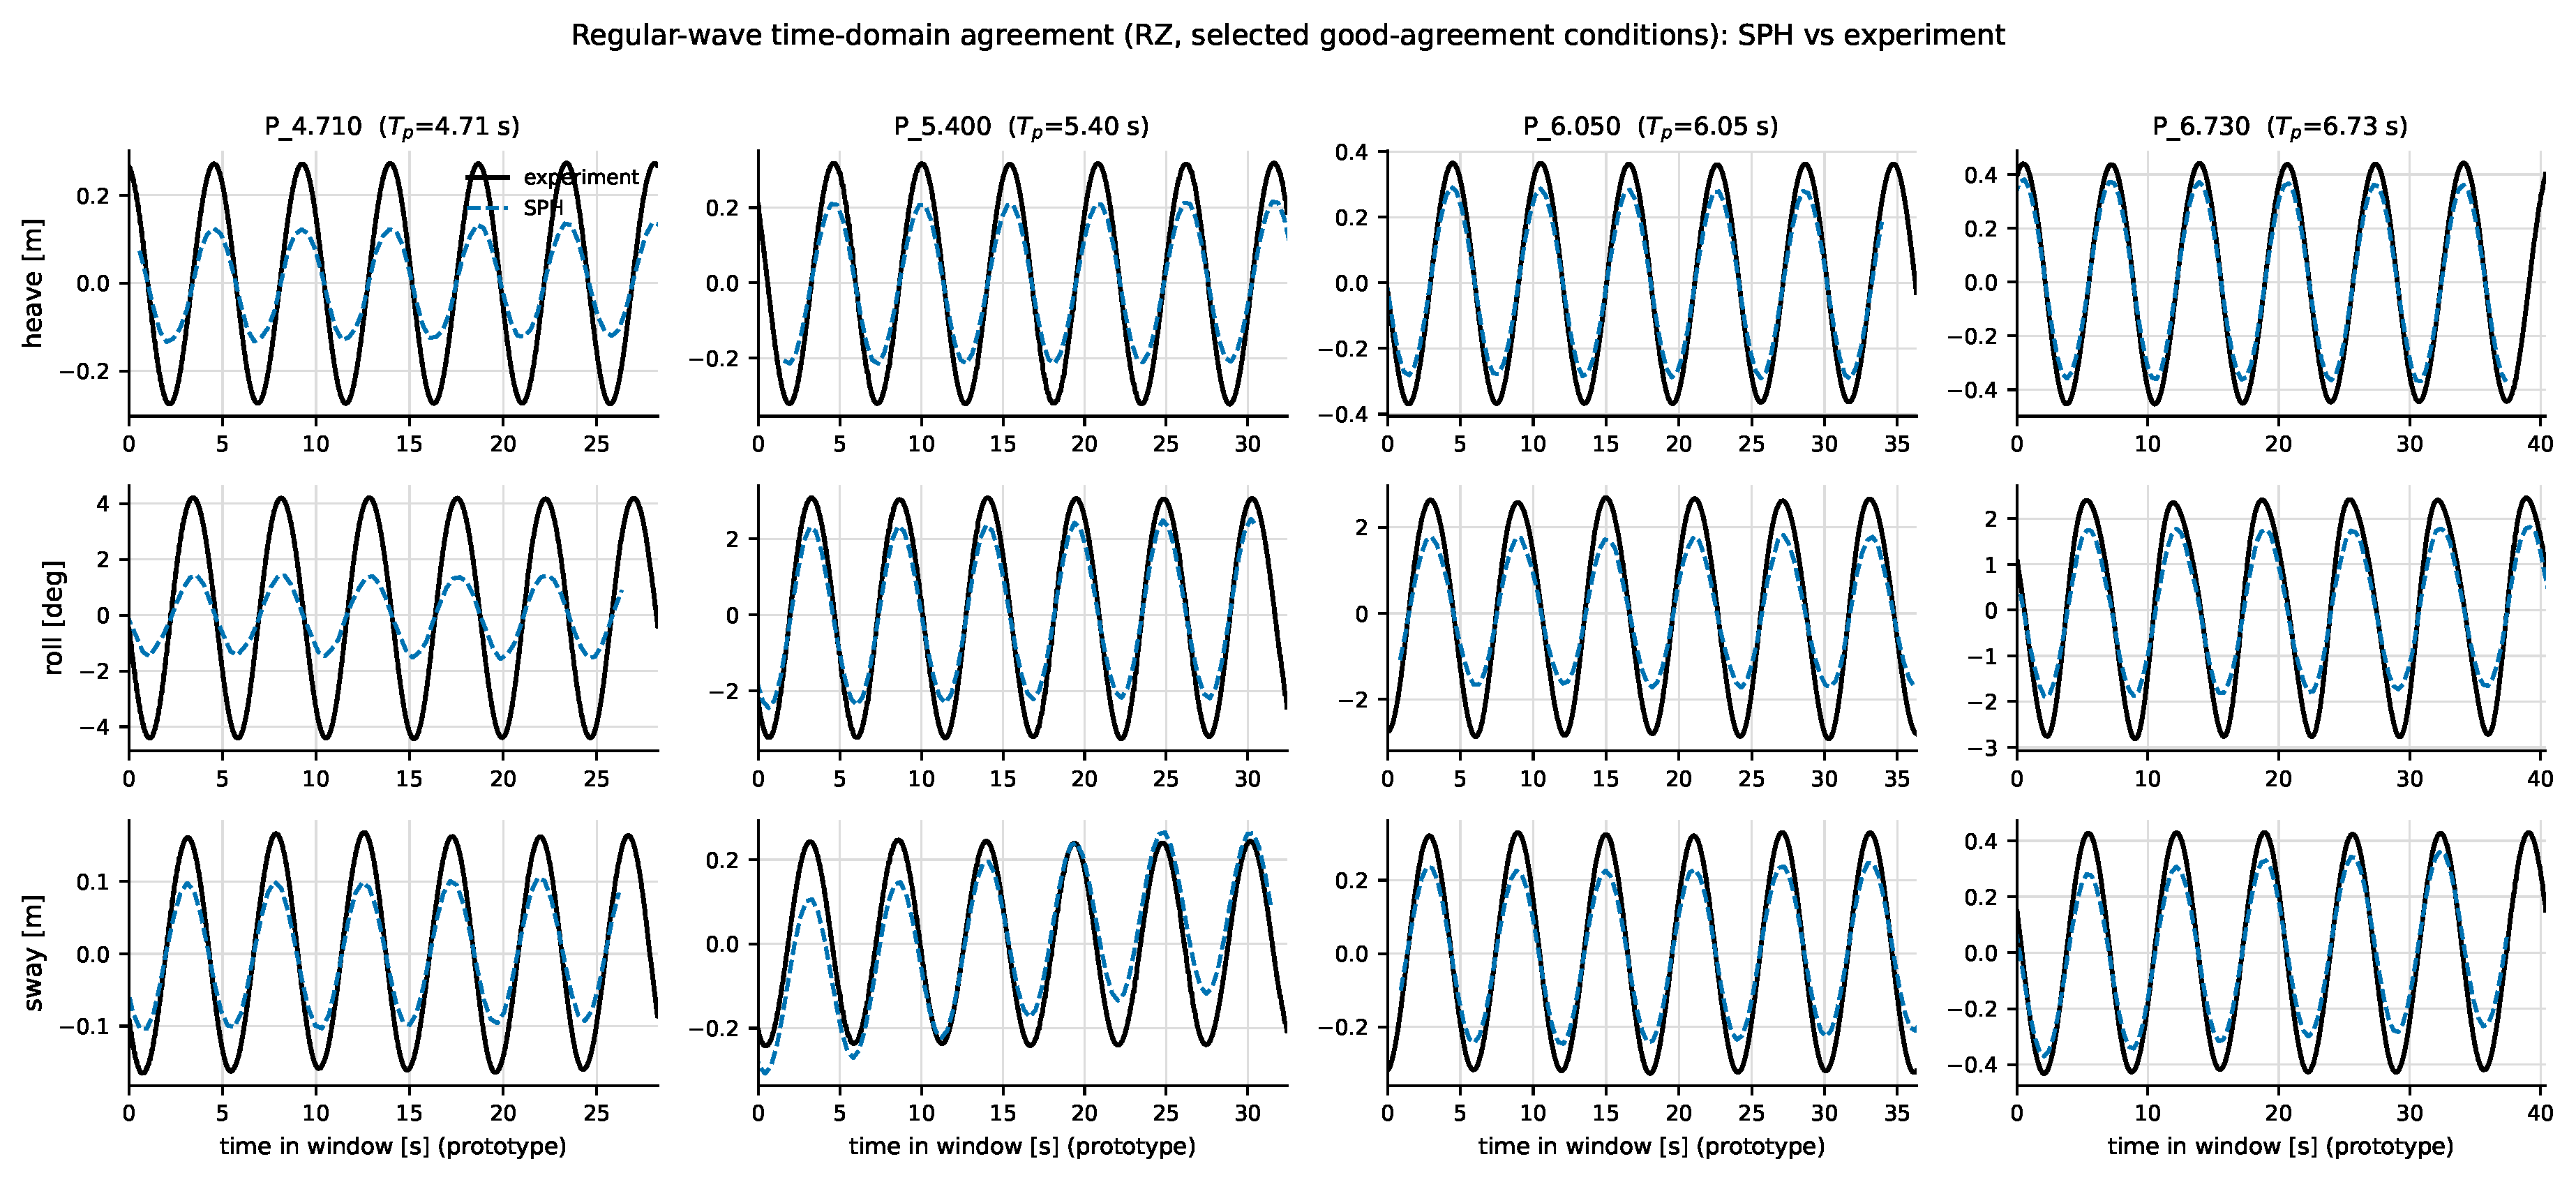
Figure 7.
Regular-wave motion response: wave-frequency amplitude of heave, roll and sway from experiment, SPH and FVM (OpenFOAM). FVM motion data are available at three periods (prototype 4.05, 4.71 and 6.73 s). Prototype scale.
Figure 7.
Regular-wave motion response: wave-frequency amplitude of heave, roll and sway from experiment, SPH and FVM (OpenFOAM). FVM motion data are available at three periods (prototype 4.05, 4.71 and 6.73 s). Prototype scale.
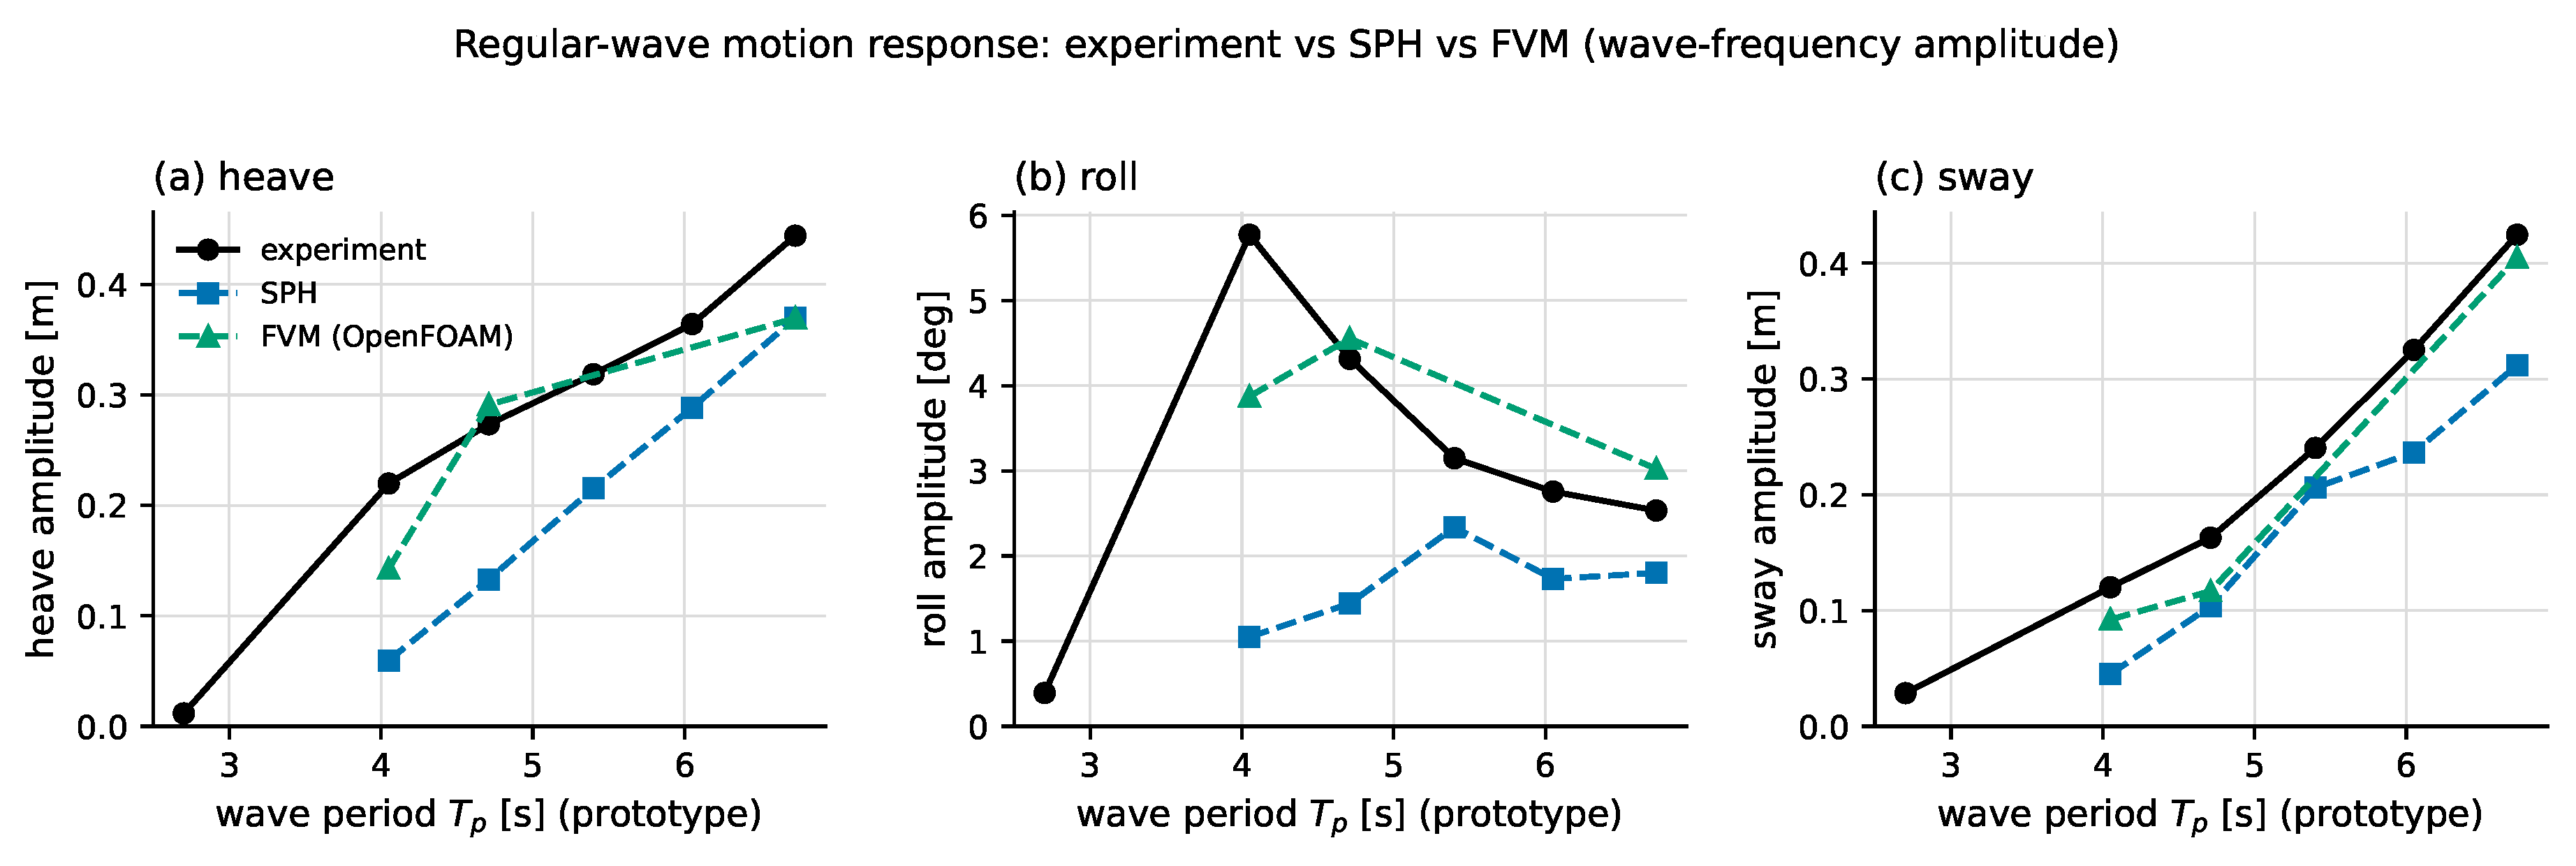
Figure 8.
Regular-wave time-domain agreement at a prototype period of 4.71 s: phase-aligned heave, roll and sway from experiment, SPH and FVM (OpenFOAM). The FVM waveforms overlay the measurement; SPH is in phase but of smaller amplitude. Prototype scale.
Figure 8.
Regular-wave time-domain agreement at a prototype period of 4.71 s: phase-aligned heave, roll and sway from experiment, SPH and FVM (OpenFOAM). The FVM waveforms overlay the measurement; SPH is in phase but of smaller amplitude. Prototype scale.
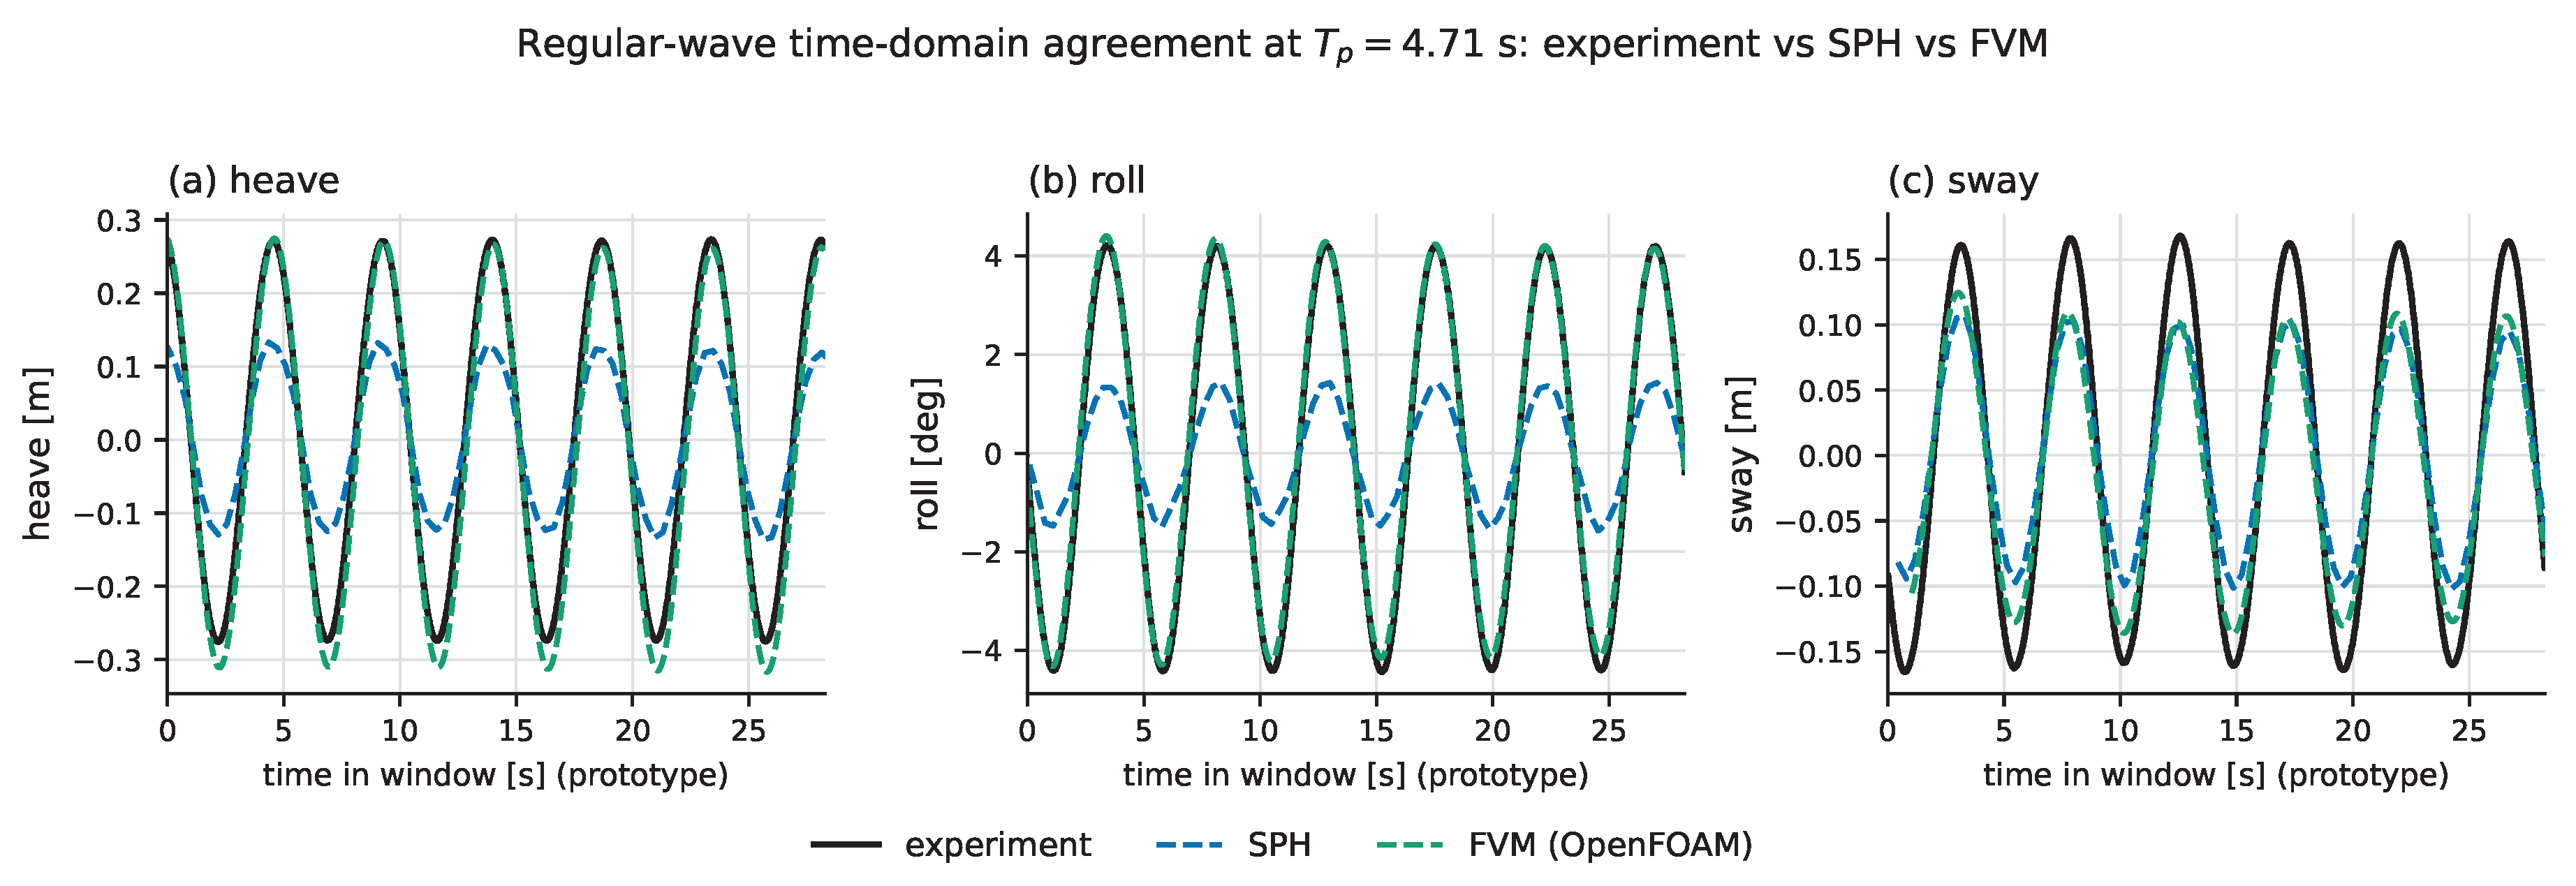
Figure 9.
Fairlead mooring-line load: wave-frequency (dynamic) tension amplitude versus wave period, from experiment and FVM (OpenFOAM). SPH is omitted because its mooring lines go slack within each cycle (snap loading), so its wave-frequency amplitude is not comparable; the mean pretension also differs between the models and the experiment. Only the dynamic amplitude is compared. Prototype scale.
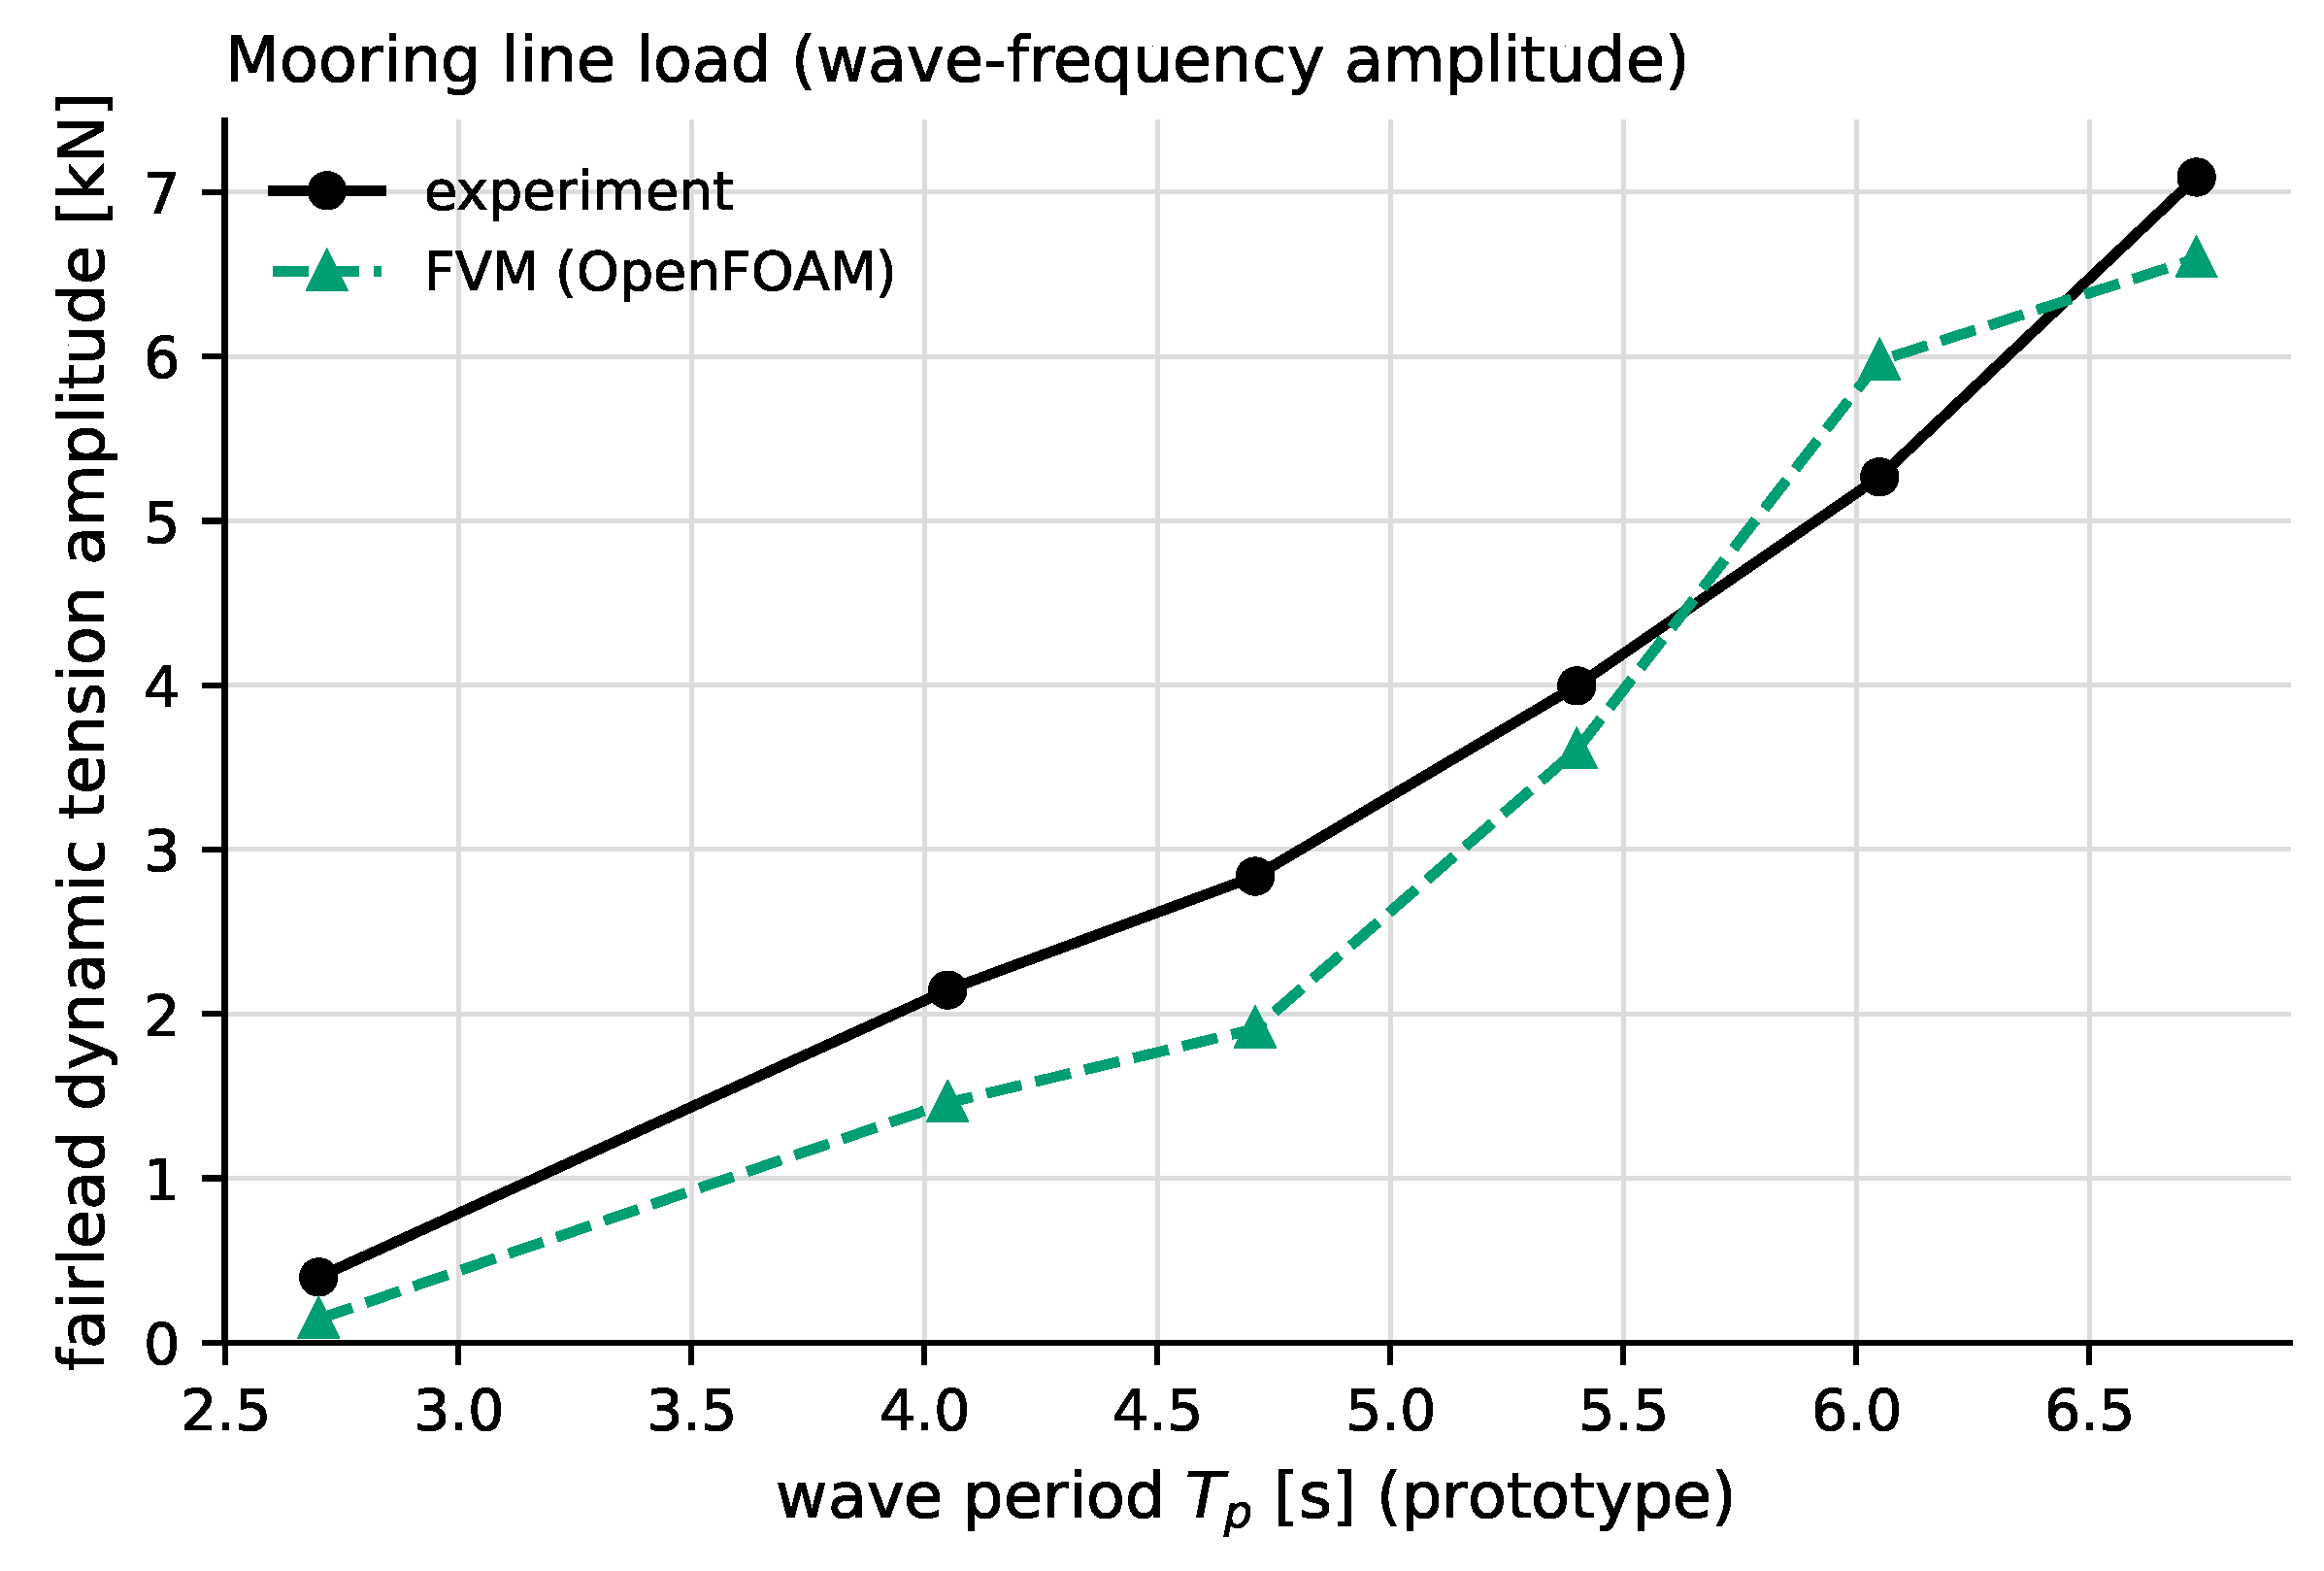
Figure 10.
Response amplitude operators from the irregular sea states: heave, roll [] and sway, SPH (solid) versus experiment (dashed). Prototype scale.
Figure 10.
Response amplitude operators from the irregular sea states: heave, roll [] and sway, SPH (solid) versus experiment (dashed). Prototype scale.
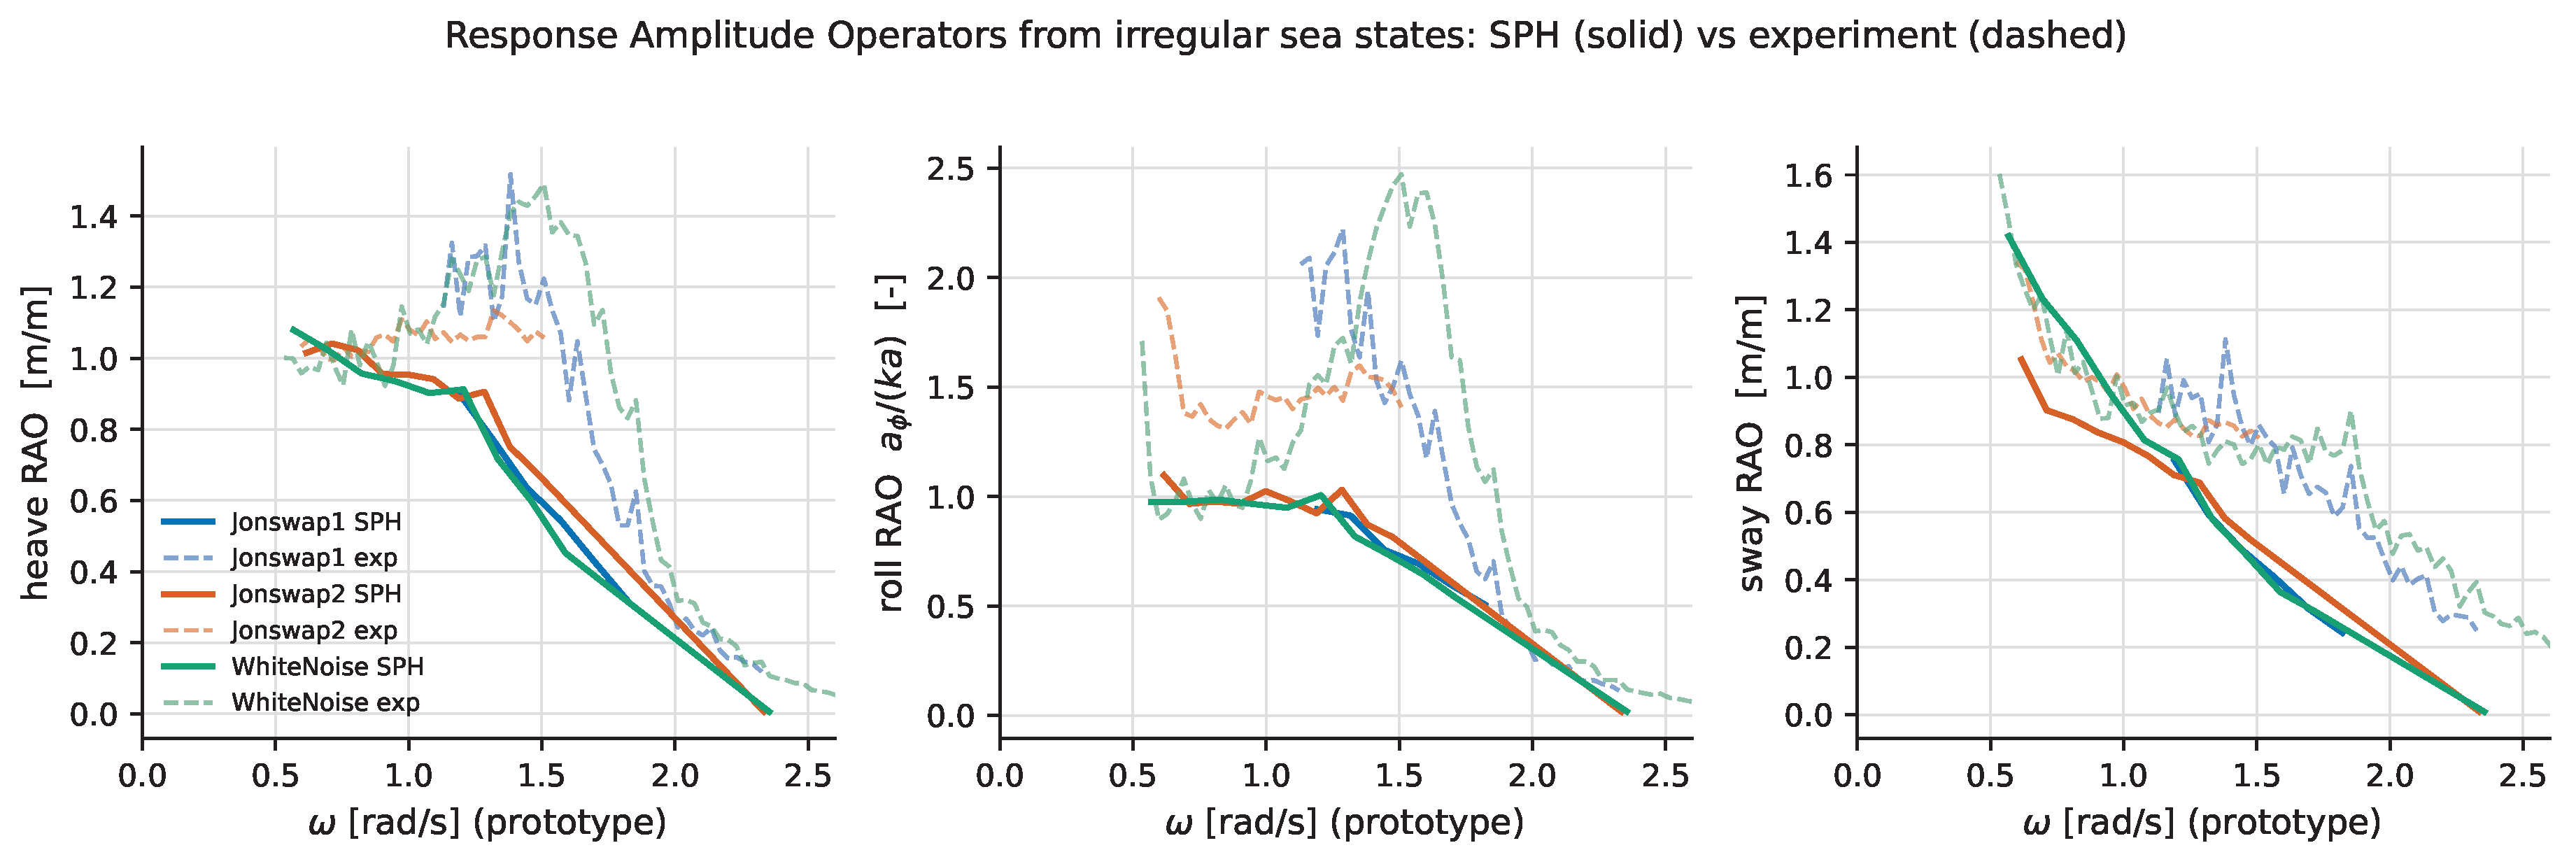
Figure 11.
Frequency-dependent transmission coefficient for the irregular sea states: SPH versus experiment and a literature reference. The experimental and reference curves are approximate (digitized). Prototype scale.
Figure 11.
Frequency-dependent transmission coefficient for the irregular sea states: SPH versus experiment and a literature reference. The experimental and reference curves are approximate (digitized). Prototype scale.
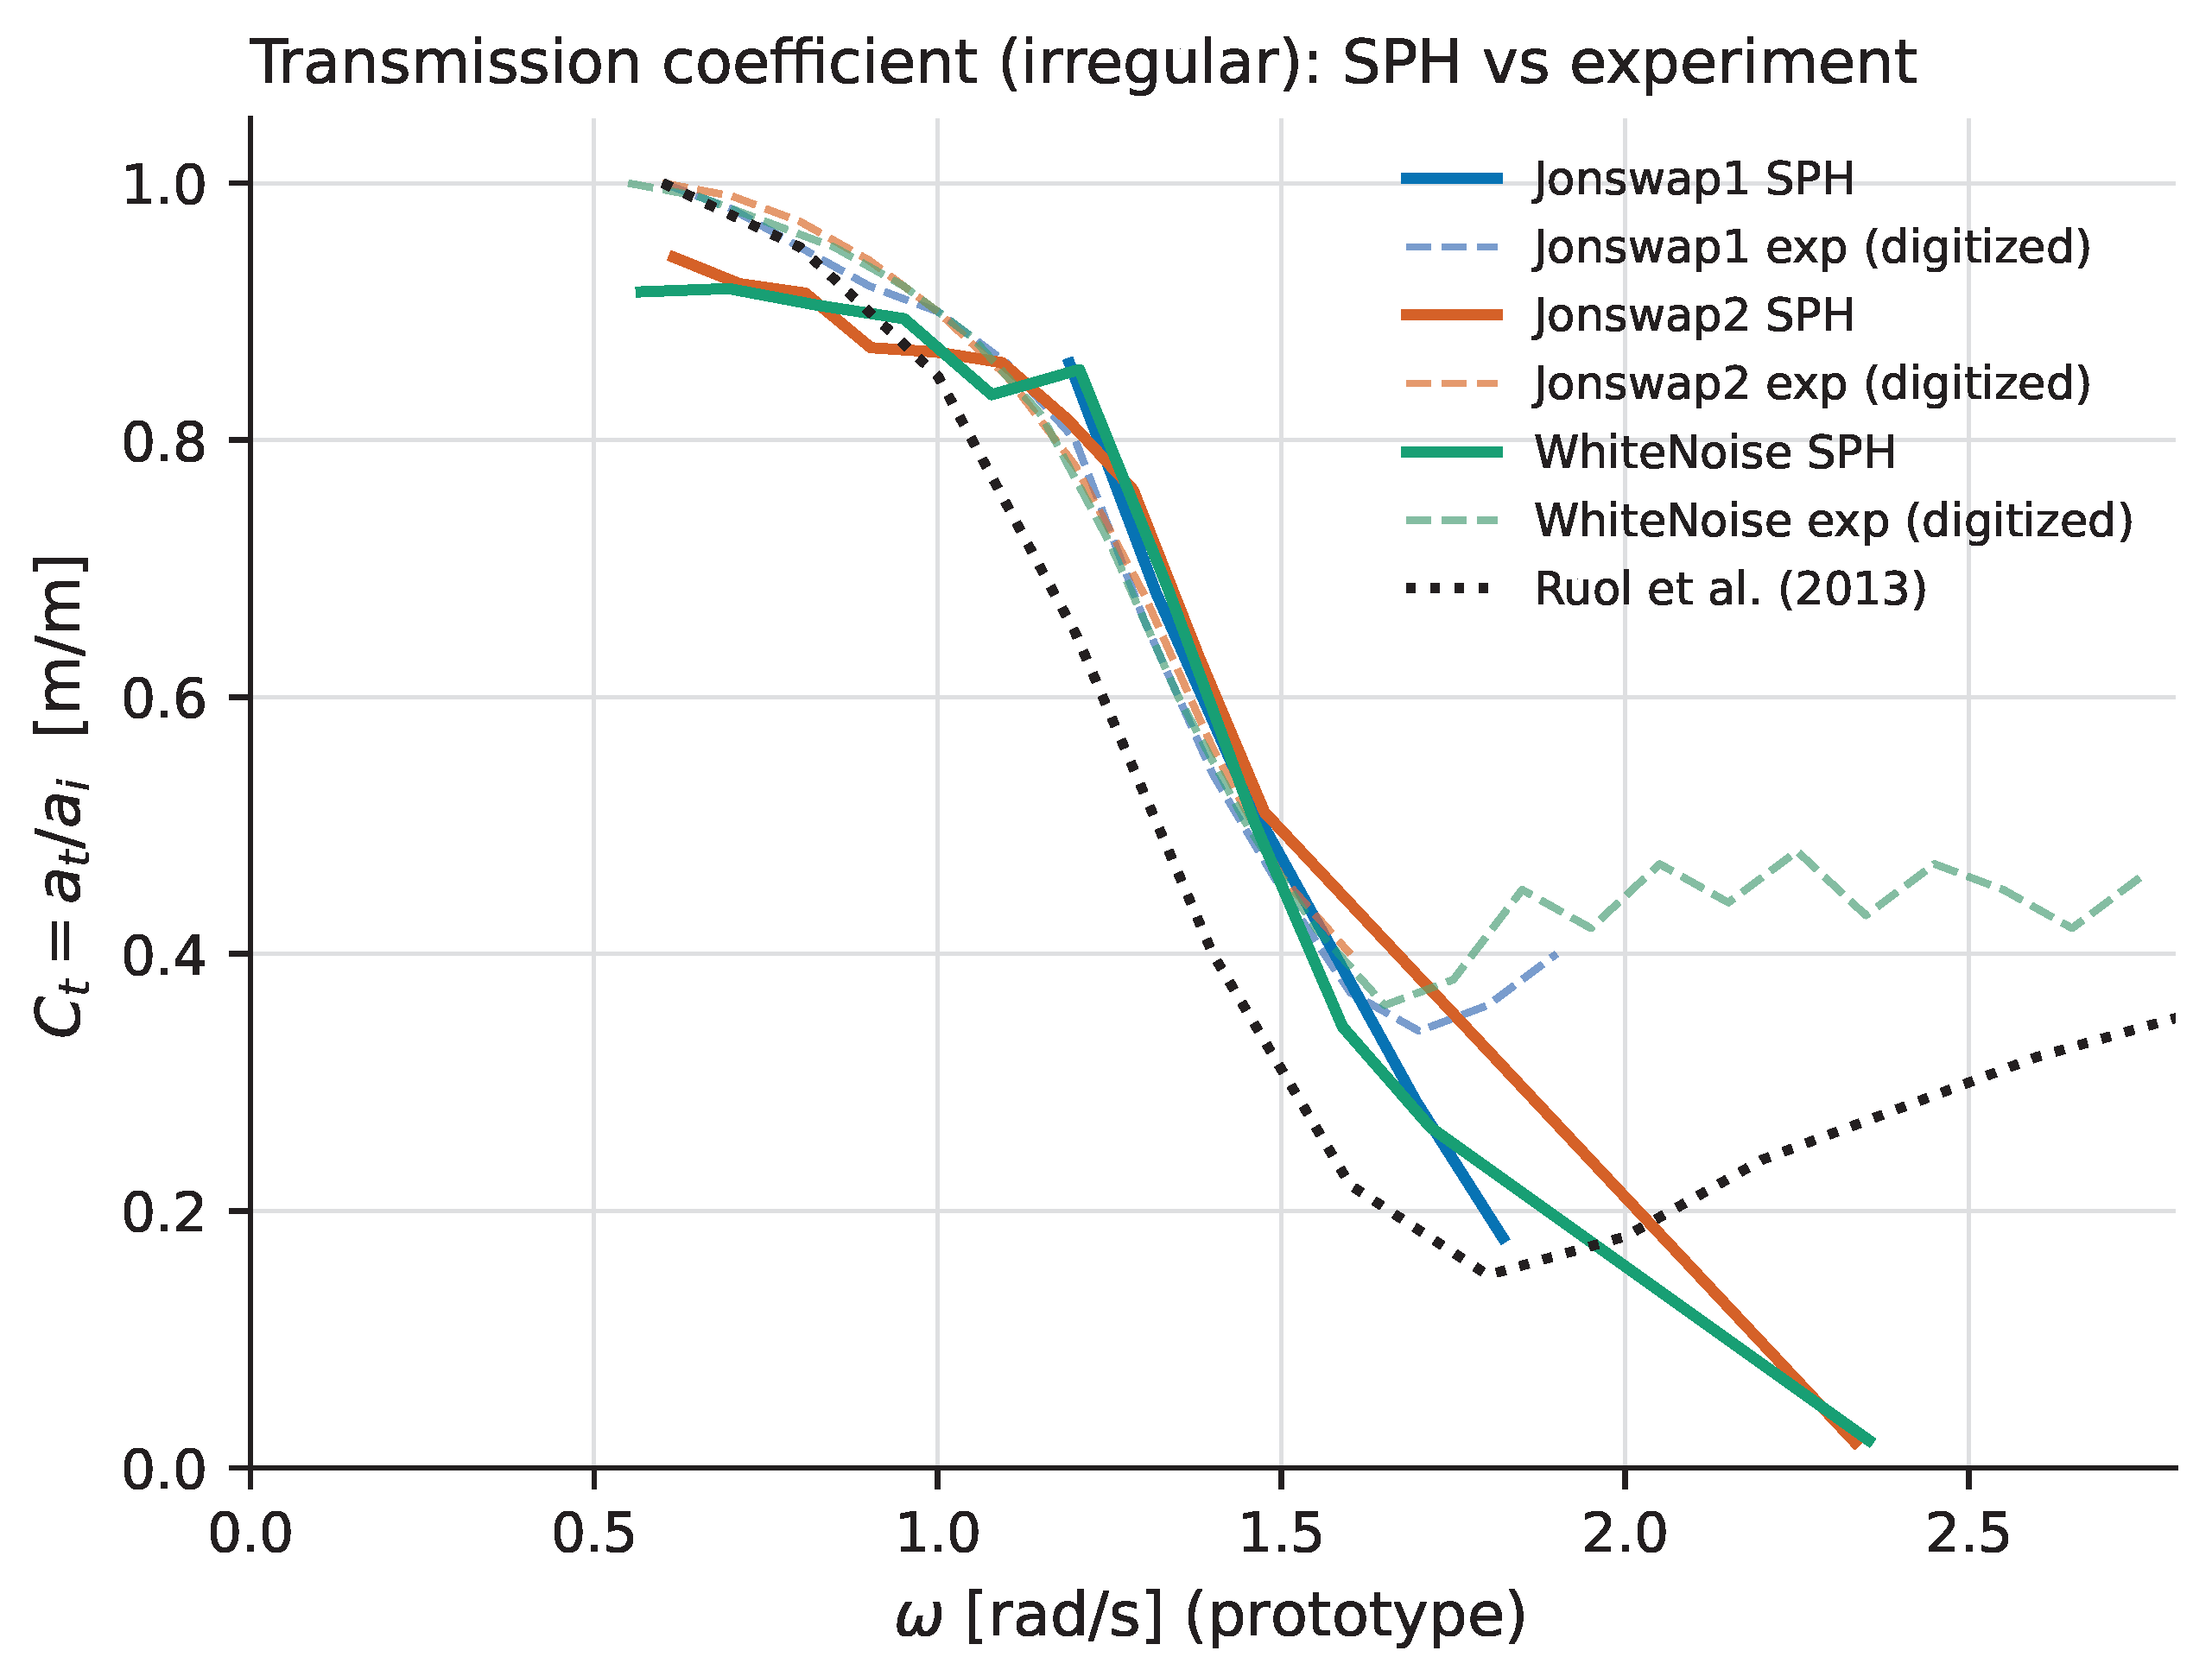

Table 1.
Mooring-line properties (MoorDyn+ lumped-mass model), as run at model scale. All four lines share the same properties.
Table 1.
Mooring-line properties (MoorDyn+ lumped-mass model), as run at model scale. All four lines share the same properties.
| Property | Symbol | Value (model) |
|---|---|---|
| Unstretched length | ||
| Axial stiffness | 150 | |
| Equivalent diameter | D | |
| Mass per unit length (air) | w | / |
| Internal damping () | – | |
| Transverse drag coeff. | 2.4 | |
| Tangential drag coeff. | 0.05 | |
| Transverse added mass | 1.0 | |
| Segments per line | – | 1 |
| Number of lines | n | 4 |
Table 2.
Floating breakwater inertial properties (model scale).
| Property | Symbol | Value |
|---|---|---|
| Mass | m | 238 |
| Centre of gravity (above keel) | – | |
| Width | B | meter |
| Length | L | |
| Keel depth | ||
| Inertia () | – | |
| Inertia () | – | |
| Inertia () | – |
Table 3.
Regular-wave test matrix (prototype scale). T is the wave period, H the wave height.
| Case | T () | H () |
|---|---|---|
| R1 | 3.37 | 0.22 |
| R2 | 4.05 | 0.31 |
| R3 | 4.71 | 0.44 |
| R4 | 5.40 | 0.56 |
| R5 | 6.05 | 0.68 |
| R6 | 6.73 | 0.84 |
Table 4.
Irregular-wave test matrix (prototype scale). is the peak period, the significant wave height and the JONSWAP peak-enhancement factor. The white-noise case is a broadband excitation covering the period band .
Table 4.
Irregular-wave test matrix (prototype scale). is the peak period, the significant wave height and the JONSWAP peak-enhancement factor. The white-noise case is a broadband excitation covering the period band .
| Case | Spectrum | () | () | |
|---|---|---|---|---|
| J1 | JONSWAP | 4.0 | 1.0 | 4.00 |
| J2 | JONSWAP | 7.5 | 3.1 | 2.34 |
| W | white noise | – | 0.67 | – |
Table 5.
Numerical parameters of the SPH model.
| Parameter | Value |
|---|---|
| Solver | DualSPHysics v5.4 (GPU) |
| Initial particle spacing 0.05 m (baseline); 0.03 m (short-period regular refinement) | |
| Smoothing-length coefficient | |
| Kernel | Wendland (quintic) |
| Viscosity treatment | Artificial, |
| Density diffusion | Fourtakas, |
| Particle shifting | disabled |
| Reference density | 1000/ |
| Speed-of-sound coefficient | 20 |
| Time integration | Symplectic |
| CFL number | 0.2 |
| Boundary condition | mDBC, free-slip floor |
| Rigid-body algorithm | SPH (regular) / Chrono (irregular) |
| Wave generation | relaxation zone |
| Mooring model | MoorDyn+, |
| Froude length scale | 10 |
| Number of particles | 4M |
Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license.
Copyright: This open access article is published under a Creative Commons CC BY 4.0 license, which permit the free download, distribution, and reuse, provided that the author and preprint are cited in any reuse.