

Submitted:
13 August 2026
Posted:
14 August 2026
You are already at the latest version
Abstract
This study numerically investigates the analogy between laser shock (LS) and projec-tile-based hypervelocity impact (HVI) for composite and hybrid spacecraft shielding materials and proposes a methodology for determining the equivalent LS parameters corresponding to a given HVI event. Numerical HVI models were developed in LS-DYNA and validated against published experimental data for two shielding con-figurations: (a) a CFRP bumper and (b) an Al/CFRP/Al/CFRP/Al hybrid shield, with emphasis on crater formation and damage morphology. An LS model was subse-quently calibrated through iterative adjustment of the pressure amplitude and pulse duration to reproduce the damage induced by HVI. The ablation-pressure scaling laws of Grün, Dautray, Pirri, and Phipps were then inverted to estimate the laser intensity and energy required for experimental implementation. Excellent agreement between the HVI and LS responses was achieved in terms of crater morphology, hole size, de-lamination, and damaged area. The predicted laser intensities (498–1424 GW/cm²) and energies (42–1049 J) fall within the validated range of the Grün and Phipps scaling laws and the capabilities of existing laser facilities, demonstrating that the proposed HVI–LS analogy is both physically consistent and experimentally feasible.
Keywords:
laser shock
; hypervelocity impact
; analogy
; CFRP
; hybrid laminate
; spacecraft shielding
; crater
; numerical simulation
1. Introduction
The rapid growth of human space exploration activities has significantly increased the threat to satellite and spacecraft operation due to the exponential rise in Micro-Meteoroid and Orbital Debris (MMOD). Space debris comprises objects of varying size and trajectory that originate either from human activities or natural extraterrestrial source [1,2,3] At orbital velocities, typically ranging from 1 to 15 km/s, collisions between these objects and spacecraft constitute Hypervelocity Impacts (HVI), capable of causing severe structural damage or even catastrophic failure.
Spacecraft protection against MMOD generally relies on two complementary strategies: active and passive protection. Active protection includes collision avoidance maneuvers together with debris mitigation and removal techniques. Passive protection is based on shielding systems designed to protect spacecraft from meteoroids and debris particles that cannot be tracked. To reduce the risks associated with MMOD, a wide range of shielding concepts has been developed and progressively refined. Modern spacecraft shielding systems include multilayer configurations, such as double- and triple-wall shields, stuffed Whipple shields, and advanced concepts incorporating composite materials, fabrics, foams, or functionally graded layers [4,5,6]. Among these, the Whipple shield remains one of the most effective shielding concepts. It consists of a thin bumper and a rear wall separated by a standoff distance, allowing the projectile to fragment into a debris cloud that disperses the impact energy over a larger area [7,8]. However, in applications such as extravehicular activities, volume constraints often prevent the use of external bumpers, requiring the structural panel itself to withstand the hypervelocity impact of MMOD.
Experimental investigations of hypervelocity impacts on shielding systems have traditionally relied on projectile launch facilities, including single- and two-stage light-gas guns, powder guns, and electrostatic accelerators [8,9,10]. However, these facilities offer limited control over projectile size, impact velocity, and testing frequency, while also involving high operational costs.
Laser-induced shock (LS) has emerged as a promising alternative for reproducing the damage associated with HVI events, providing a flexible and cost-effective experimental approach for investigating material behaviour under extreme loading rates [11,12,13,14,15,16,17]. By focusing high-energy laser pulses onto a target surface, the upper micrometres of the material are rapidly vaporized, generating a plasma that expands violently and exerts a high-pressure pulse on the target.
As illustrated in Figure 1, this process shares fundamental similarities with the shock-wave propagation produced during HVI events. It generates intense shock waves with pressure amplitudes and rise times comparable to those produced during actual impacts, while offering improved experimental control, repeatability, and diagnostic accessibility.
The potential analogy between HVI and LS loading was first proposed by Pirri in 1977 [18]. His approach was based on the principle of late-stage equivalency, which states that when two distinct impact events generate identical flow and pressure fields before material strength and strain effects become dominant, they will produce equivalent craters. Accordingly, it was proposed that the flow and pressure conditions characteristic of a particle impact could be reproduced by applying impulsive loading to a material using a pulsed laser [19]. Subsequent theoretical and experimental studies further explored this concept, highlighting similarities in shock-wave propagation, spallation phenomena, and damage mechanisms [20,21,22]. Nevertheless, the validity and limitations of this analogy remain the subject of ongoing investigation.
Within this context, the present study numerically investigates the validity and applicability limits of the analogy between hypervelocity impact (HVI) and laser shock (LS) loading for space-related structural configurations. The analysis considers different material systems and loading conditions, with particular emphasis on spacecraft shielding applications. Specifically, two representative cases are examined: (i) an aluminium projectile impacting a carbon-fiber-reinforced polymer (CFRP) plate, and (ii) a Mylar projectile impacting an Al/CFRP/Al/CFRP/Al multilayer shield. By comparing the structural response, damage patterns, and stress-wave propagation under HVI and equivalent LS loading, this study aims to determine under which conditions, and to what extent, laser-driven testing can serve as a reliable surrogate for conventional hypervelocity impact experiments.
2. Materials and Methods
2.1. Materials and Shield Configurations
Based on the study by Wicklein et al. [23], the carbon-fiber-reinforced polymer (CFRP) used in Experiment 236 was selected as a representative material for satellite structural components. The laminate consists of Tenax UMS2526 high-performance carbon fibers embedded in a Krempel BD System 120 °C epoxy resin matrix. The fibers exhibit a tensile modulus of 395 GPa and a tensile strength of 4.56 GPa, while the laminate has a fiber volume fraction of 52%. The CFRP face sheet has a total thickness of 1.37 mm and follows a symmetric stacking sequence of [0/45/-45/-45/45/0]. The analyzed impact case corresponds to a projectile velocity of 4.935 km/s. This experiment was selected as a benchmark for numerical model validation, providing ultrasonic measurements of the delamination front together with hole dimensions and post-impact photographs.
The second experimental case, reported by Wan et al. [24], investigates the shielding performance of a hybrid Al/CFRP/Al/CFRP/Al multilayer configuration. The hybrid laminate consists of a five-layer alternating stack of 2024 aluminium alloy and CFRP, which was shown to significantly reduce the peak shock pressure generated during hypervelocity impact. Each aluminium and CFRP layer has a thickness of 1 mm, resulting in a total shield thickness of 5 mm. The CFRP layers were manufactured using a vacuum-assisted resin transfer moulding (VARTM) process with Bisphenol A epoxy resin and T300 carbon fiber fabric, achieving a fiber volume fraction between 45% and 50%. The Mylar projectile has a diameter of 10 mm, a thickness of 0.1 mm, and an impact velocity of 9.2 km/s. Both configurations are presented in Figure 2.
2.2. HVI-LS Analogy Framework
To enable a direct comparison with HVI, the LS loading is treated as an impulsive mechanical load, and the material response under both loading conditions is assumed to be governed by the same constitutive models, while thermal effects associated with laser irradiation are neglected. The adopted procedure for identifying an equivalent laser shock loading consists of calibrating the pressure pulse parameters to reproduce the response obtained from hypervelocity impact simulations. Initially, an HVI numerical model is developed and validated against experimental data. The validated model is subsequently used as the reference case, from which key quantities, including peak pressure, stress-wave propagation, delamination, and crater characteristics, are extracted. A series of LS simulations is then performed by varying the pressure amplitude and pulse duration.
An initial approximation of the equivalent laser parameters is obtained using Pirri's one-dimensional assumptions, according to which the laser focal spot diameter is primarily related to the projectile diameter, the laser pulse duration corresponds to the projectile length, and the laser intensity is associated with the projectile velocity [18]. An iterative procedure is subsequently employed to adjust the LS loading parameters until comparable cross-sectional damage and crater formation are achieved. Figure 3 illustrates the pressure profile employed in the numerical modelling of laser-driven shock-wave propagation.
The ablation pressure, , generated by direct laser irradiation depends on the absorbed laser intensity, , the laser wavelength, , the pulse duration, , the focal spot radius, , and the target material properties, characterized by the atomic number, , and mass number, . Several scaling laws have been proposed in the literature to estimate the peak ablation pressure. Among the most widely used, the formulations of Grün, Dautray, Pirri, and Phipps are adopted in the present study, as summarized in Table 1.
Where is expressed in GPa, in , in nm, in ns, and in m. In the present work, these formulations are used inversely to establish a numerical analogy between HVI and LS loading. The peak HVI-equivalent laser shock pressure is used as input to determine the equivalent laser intensity by rearranging each scaling law. For instance, the Grün formulation yields:
Analogous inversions are applied to the remaining three scaling laws. The use of multiple formulations provides a range of predicted intensities, reflecting the inherent uncertainty in ablation pressure estimation across different laser regimes. The Grün and Pirri formulations are generally considered reliable at moderate intensities ( ), while the Dautray formulation is better suited to ultra-high intensities ( ). Dynamic equivalence is ensured by also selecting the laser pulse duration equal to the effective duration of the HVI pressure pulse. The laser focal spot diameter is taken equal to the effective impact diameter obtained from the HVI simulation. The corresponding laser energy is finally obtained from
where is the laser spot area. This procedure enables the translation of HVI-induced loading conditions into equivalent, experimentally achievable laser shock parameters, ensuring consistency in peak pressure, pulse duration, and spatial extent of the applied load.
*LOAD_ERODING_PART_SET was used to reproduce the laser-induced shock in LS-DYNA which applies the calibrated ablation pressure pulse directly onto the surfaces of the irradiated target. Unlike a conventional pressure load defined on a fixed set of segments, this keyword continues to load the newly exposed surfaces that are revealed as the outermost layer of elements is progressively eroded and deleted during the simulation. This behavior is essential for replicating laser shock loading, where the ablation pressure is sustained on the receding free surface created by the vaporization and removal of the upper layer of material, rather than vanishing once the initially loaded elements fail.
The LS focal spot is defined geometrically by specifying a point in space together with a half-angle, , as illustrated in Figure 4. The pressure is assumed to originate from point and is projected onto the target surface, forming a circular loading area whose diameter, , is determined by the position of point relative to the surface and the cone half-angle, . As the surface progressively erodes, the pressure continues to be projected from point onto the newly exposed crater surface, thereby maintaining a physically consistent loading area throughout the duration of the applied pulse.
3. Numerical Modelling
3.1. CFRP Plate
A Lagrangian finite element method (FEM) was employed for both the projectile and the target using hexahedral solid elements. For the CFRP plate, a refined mesh, shown in Figure 5(a), was adopted with a characteristic element size of 0.14 mm in the impact region to ensure mesh convergence and accurately capture delamination. The plate edges were constrained in all translational directions.
The aluminium projectile was modelled using a spherified cube mesh comprising 395 elements, as shown in Figure 5(b). This meshing approach provides a more uniform element distribution along the sphere radius and improved element aspect ratios around its circumference compared with the default spherical mesh available in LS-DYNA [27].
To model the interaction between the aluminium projectile and the CFRP plate, the *CONTACT_ERODING_SURFACE_TO_SURFACE keyword was employed, with the projectile defined as the master surface and the CFRP plate as the slave surface. In addition, to account for internal spallation of both the projectile and the plate, which may cause newly created internal surfaces to come into contact during material erosion, the *CONTACT_INTERIOR keyword was applied to the entire set of solid elements. This contact algorithm automatically detects and enforces contact between internal surfaces generated as elements are progressively eroded during the simulation.
To capture the anisotropic behaviour and progressive damage of the CFRP laminate, the *MAT_162_COMPOSITE_MSC_DMG material model was adopted. This constitutive model enables the simulation of damage initiation and evolution in both unidirectional (UD) and plain-weave (PW) composites, allowing the representation of the principal failure mechanisms observed in CFRP laminates, including fibre fracture, matrix cracking, and delamination initiation [28]. The material properties of the CFRP laminate are summarized in Table 2.
To accurately simulate the high-strain-rate response (>10⁵ s⁻¹) associated with hypervelocity impact events, the aluminium projectile was modelled using the Johnson–Cook (J–C) strength model coupled with the Mie–Grüneisen equation of state (EOS).
The J-C model is an ideal rigid-plastic constitutive relationship that accounts for strain hardening, strain rate strengthening, and thermal softening, as defined by:
In this formulation, represents the initial yield strength, while and are the strain-hardening constant and exponent, respectively. The influence of the strain rate is captured by the coefficient referencing the plastic strain rate against the reference rate . Thermal softening is accounted for by the index and the homologous temperature defined as where is the ambient temperature and is the material melting point. To characterize the hydrodynamic pressure response, the Mie-Grüneisen Equation of State was implemented. For materials under compression ( ), the pressure is governed by:
Conversely, for expanded states (), the relationship simplifies to:
In these equations, denotes the initial material density, represents the bulk speed of sound, and is the Grüneisen coefficient. The parameters , , and correspond to the Hugoniot slope coefficients, while indicates the internal energy per unit volume. The nominal strain is defined by the ratio of current density to initial density as . The material properties of the aluminum projectile, along with the corresponding Mie-Grüneisen parameters are summarized in Table 3.
While the Johnson–Cook (J–C) model effectively captures the influence of temperature and strain rate on the yield stress, it does not account for the high-pressure hydrodynamic effects that dominate hypervelocity impact events. Therefore, the Mie–Grüneisen equation of state (EOS) was employed to describe the pressure–volume relationship under both compression and expansion. With regard to material failure, the J–C failure model was used to simulate compressive failure. However, a major challenge in modelling hypervelocity impacts is the accurate representation of spallation, which occurs when compressive stress waves reflect from free surfaces as high-amplitude tensile waves. Since the J–C failure model cannot independently capture spall failure, and the Grady–Spall model is not available in LS-DYNA, a maximum tensile stress failure criterion was implemented as an appropriate approximation [29]. Following established numerical benchmarks [30], a tensile failure threshold of 2.6 GPa was adopted to accurately reproduce the internal spallation of the aluminium projectile.
3.2. Al-CFRP-Al-CFRP-Al Shield
The alternating Al/CFRP/Al/CFRP/Al shield configuration is shown in side view in Figure 6(a) and in isometric view in Figure 6(b). To accurately capture the compressible, fluid-like behaviour of the Mylar projectile under hypervelocity loading, a Smoothed Particle Hydrodynamics (SPH) formulation was adopted for its modelling. The multilayer shield was discretized using hexahedral solid elements with in-plane dimensions of 150 mm × 150 mm and a total laminate thickness of 5 mm. Both the SPH particle spacing and the finite element characteristic length were set to 0.25 mm.
To model the interaction between the SPH particles and the finite element mesh, the *CONTACT_ERODING_NODES_TO_SURFACE keyword was employed using a node-to-surface erosion contact formulation. In this definition, the SPH particles, represented as single nodes, were assigned as the slave nodes, while the finite element mesh was defined as the master surface. Due to the absence of the material parameters required by *MAT_162, whose calibration would require extensive experimental characterization, *MAT_59_COMPOSITE_FAILURE_SPH_MODEL was adopted as a more practical alternative. This orthotropic composite material model in LS-DYNA captures the principal failure mechanisms relevant to hypervelocity impact, including compressive, shear, and delamination failure modes. Its constitutive formulation of the deviatoric stress–strain response, together with the associated damage criteria, provides an adequate representation of the composite behaviour without requiring an additional equation of state. The elastic properties and damage model parameters for the T300 woven CFRP are summarized in Table 4.
To model the delamination between adjacent CFRP and AL2024 layers, four zero-thickness cohesive interfaces were introduced using the *MAT_138_COHESIVE_MIXED_MODE material model. This model implements a bilinear traction–separation law, as illustrated in Figure 6.
Figure 6.
Schematic representation of the mixed-mode bilinear traction-separation law [22].
Figure 6.
Schematic representation of the mixed-mode bilinear traction-separation law [22].
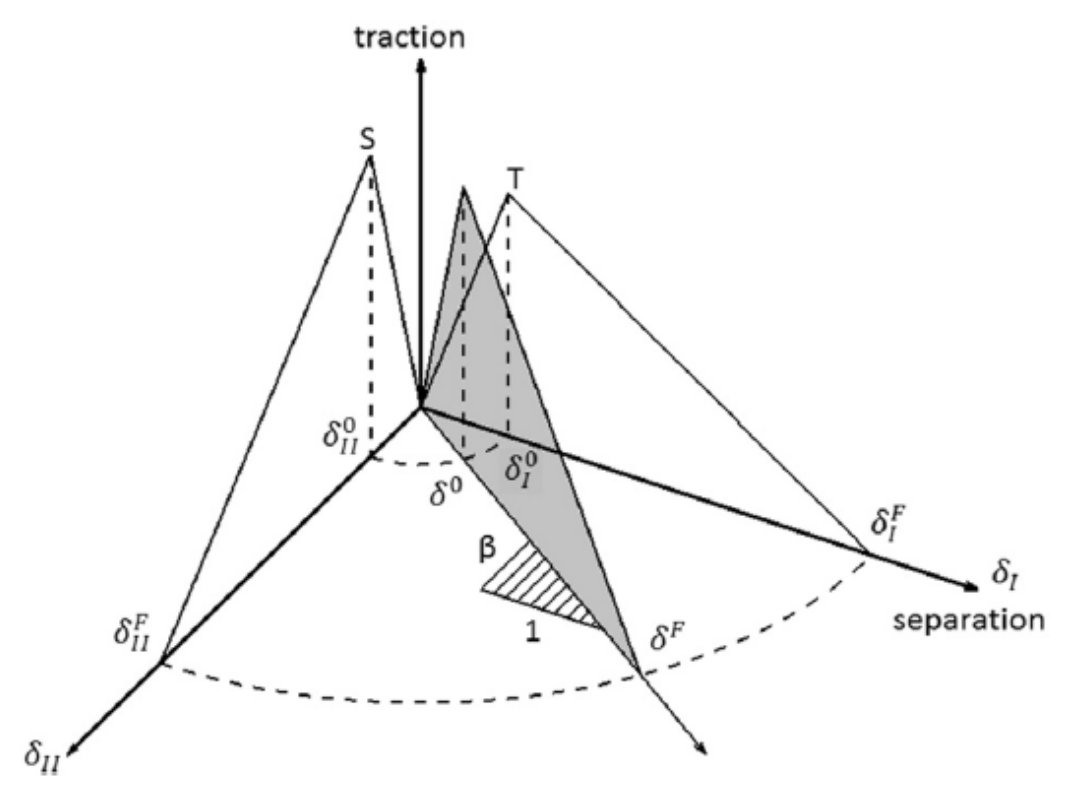
The cohesive parameters that have been used are presented in Table 5. The ultimate mixed-mode displacement, for the power law were calculated by
where is the mode-mixity, is the onset relative displacement, EN and ET are the normal and in-plane cohesive stiffness, respectively and XMU is the exponent of the mixed-mode criterion. For the simulations ==1E6 N/mm and XMU value equals 2.
The behaviour of the polymeric Mylar projectile is governed primarily by impact-induced pressure, making its mechanical properties of secondary importance. Consequently, its response can be adequately described using only an equation of state (EOS). As in the previous simulation, the Mie–Grüneisen EOS was employed to capture the evolution of pressure, internal energy, and density during shock-wave propagation. The material density was defined using the *MAT_NULL keyword in LS-DYNA. Similarly, the aluminium layers were modelled using the Johnson–Cook strength model coupled with the Mie–Grüneisen EOS to accurately represent their constitutive response under hypervelocity loading. The material properties and EOS parameters for both Mylar and aluminium are summarized in Table 6.
4. Results
4.1. CFRP Plate
4.1.1. Hypervelocity Impact Response and Model Validation
Initial model validation is performed based on two available criteria, provided in the Wicklein et al. experimental series. Those include the generated hole diameter, that is observed in the FE model as the diameter of the model’s deleted elements, and the delamination area. Since the ultrasonic non-destructive testing of the experimental result is not able to identify the delamination in a 3D space, the top view of all the layers is compared.
In Figure 7 the top view of the experimental delamination area is compared to the predicted delamination area bounded by isocurves. The colour graph is an index describing the percentage of damage of the elements in the interface between plies. In Figure 8 the hole that was generated by the experiment 236 of Wicklein et. al. is compared with the predicted hole generation by visualizing the deleted elements at the point of impact. The top view is also compared, different coloured elements indicate deleted elements of different plies.
4.1.2. Laser Shock Response and Analogy Assessment
After establishing a hyper-velocity impact model that is capable of producing valid results, the same simulation is conducted for 1.5 km/s and 3 km/s creating damage area data. Using the same target geometry, laser shock simulations are conducted for ablation pressures of 25 GPa and 50 GPa, varying the pulse duration. Delamination area is indicated based on the total surface of inter-ply elements that predict matrix failure (the standard way that *MAT162 indicates delamination), while total damage area also includes the area of deleted elements to represent the hole generation in the comparison. Figure 9 is a bar chart representing the delamination and total damage area of each model. Colored boxes highlight agreement between LS and projectile damage, indicating analogy between them. A comparable damage area is apparent between an LS shot with pulse duration of 7 ns that results in 25 GPa ablation pressure and 1.5 km/s HVI (Figure 9(a) - black box), while for a 13.3 ns pulse a comparison with 3 km/s HVI can be made (Figure 9(a) - green box). Additionally, the 50 GPa using a 7 ns pulse ablation pressure simulation indicates comparative damage area to the 3 km/s HVI (Figure 9(b) - green box).
For the matching damage area analogies, delamination patterns and crater formations are compared for both a top and side cross-sectional views. Figure 10 presents the top and cross-sectional comparison of the 1.5 km/s projectile speed HVI simulation with the 25 GPa LS simulation, while Figure 11 presents the comparison of the 3 km/s projectile speed HVI simulation with the 50 GPa LS simulation.
4.2. Hybrid Al-CFRP-Al-CFRP-Al Shield
4.2.1. Hypervelocity Impact Response and Model Validation
Figure 12 presents the cross-sectional damage of the hybrid shield at the end of the simulation alongside the corresponding experimental cross-section reported by Wan et al. [22]. In both cases, the first four plies are completely perforated at the impact centre. The rearmost aluminium ply undergoes plastic bulging without perforation, in good agreement with the experimental observations. Delamination between the CFRP plies and the adjacent aluminium layers is evident in both the numerical and experimental cross-sections, although the numerical model slightly underestimates the magnitude of the back-face displacement. Despite these discrepancies, the simulation successfully reproduces the principal features of the experimentally observed damage morphology and predicts a normalized crater diameter of , providing a reliable reference baseline for the subsequent laser shock analogy assessment.
4.2.2. Laser Shock Response and Analogy Assessment
The laser shock simulation was performed using the same five-ply finite element model, with the Mylar projectile replaced by the laser shock pressure pulse shown in Figure 13, having a peak pressure of 40 GPa and a pulse duration of 15 ns. The resulting normalized crater diameter was . The close agreement in crater dimensions, delamination, and overall damage morphology demonstrates that the calibrated laser pressure pulse successfully reproduces the essential damage characteristics of the hypervelocity impact event in the multilayer hybrid shield. These results support the validity of the proposed HVI–LS analogy for this structural configuration.
5. Discussion
After validating the numerical models and identifying the pressure profiles required to reproduce each HVI event, the corresponding experimental laser parameters were determined to assess whether the resulting loading conditions can be achieved using existing high-power laser facilities. Table 7 summarizes the operating envelope of representative laser shock (LS) facilities.
As the millimetre-scale focal spots achievable with current laser facilities cannot match the projectile diameter considered in the shielding case, the loading diameter must be geometrically scaled down to remain within the experimentally accessible range. Nevertheless, the planar loading condition is preserved at these reduced spot sizes, since the lateral rarefaction release time (47.7–238.5 ns) remains significantly longer than the applied pulse duration , ensuring essentially one-dimensional shock loading. Consequently, the dimensionless equivalence established for (D_0 = 10) mm is expected to remain valid for geometrically scaled configurations with smaller loading diameters, thereby enabling experimental validation of the proposed analogy under laboratory conditions. Table 8 summarizes the required laser intensity, , and energy, , predicted by the four ablation-pressure scaling laws for Cases 1–4 described in Section 2.2.
It can be observed that the predicted values of intensity differ considerably depending on the scaling law used as these laws were developed under distinct assumptions and originally validated over different intensity ranges. Grün's law was fitted experimentally on planar laser-driven shocks in the range W/cm² at with 4 ns pulses on CH disks and depends only on the ablation pressure [43].
The formula proposed by Dautray also accounts for the effects of laser wavelength and target composition and is derived within the Inertial Confinement Fusion (ICF) regime asymptotic limit, making it better suited for very high laser intensities . Therefore, in this case it underpredicts the intensity required and should be regarded as a lower-bound estimate.
Pirri's law is derived analytically assuming a quasi-steady, isothermal plasma with inverse-bremsstrahlung absorption, and it introduces a spot-radius dependence () which reflects two-dimensional plasma expansion effects for finite focal spots, with only the effective plasma optical depth α calibrated to the impulse-coupling data of Gregg and Thomas [16,44]. Phipps’ law includes dependance on pulse duration, wavelength, and target atomic and mass number (, ). It was calibrated against a compiled experimental database spanning approximately 7 orders of magnitude in the parameter laser intensities from MW/cm² to TW/cm², pulse durations from 1.5 ms to 500 ps, wavelengths from 248 nm to 10.6 µm, and pulse energies from 100 mJ to 10 kJ, on metallic and endothermic non-metallic surface-absorbing planar targets. It applies at or above the peak-coupling intensity where dense-plasma formation mediates the laser-target interaction and assumes approximately one-dimensional plasma expansion [45]. The four cases considered in the present work ( = 25-50 GPa, = 7-15 ns, =1064 nm) require intensities in the range 250-1900 GW/cm², which lie fully inside the validated envelope of both Grün's and Phipps' laws and within the multi-facility validation range recently reported by Hebert et al. [33], who confirm the findings of Grün and Phipps. Therefore, these laws are adopted as the primary predictors of the required experimental laser parameters, and the resulting intensities and energies confirm that all four cases fall within the operating envelope of existing LS facilities.
6. Conclusions
In this study, the analogy between hypervelocity impact (HVI) and laser shock (LS) loading for spacecraft shielding materials was investigated numerically. The analysis was performed for two representative configurations: a CFRP bumper and an Al/CFRP/Al/CFRP/Al hybrid shield. A numerical methodology for modelling LS loading in LS-DYNA was developed, in which the ablation pressure pulse is applied to the target surface while the loaded area is continuously updated as the outermost material is progressively eroded. A baseline framework was also proposed for determining the experimental LS parameters required to reproduce a given HVI event. The numerical results showed good agreement with the corresponding experimental data, accurately reproducing crater morphology, hole size, delamination, and the extent of the damaged area. The proposed framework can also be applied in the reverse direction to determine the equivalent projectile conditions corresponding to a given laser shock experiment. Finally, the predicted laser intensity and energy requirements for all investigated cases fall within the operating envelope of contemporary high-power laser facilities, confirming that the proposed HVI–LS analogy is not only physically consistent but also experimentally feasible.
Author Contributions
Conceptualization, K.T.; methodology, G.F, P.K and P.R..; software, G.F, P.K and P.R.; validation, G.F, P.R. and P.K; formal analysis, P.R.; writing—original draft preparation, G.F, P.K and P.R.; writing—review and editing, K.T.; visualization, G.F, P.R and P.K.; supervision, K.T.; project administration, G.F. All authors have read and agreed to the published version of the manuscript.
Funding
This research received no external funding.
Conflicts of Interest
The authors declare no conflicts of interest.
Abbreviations
The following abbreviations are used in this manuscript:
| Al | Aluminum |
| CFRP | Carbon Fiber Reinforced Polymer |
| EOS | Equation of State |
| FEM | Finite Element Method |
| HVI | Hypervelocity Impact |
| ICF | Inertial Confinement Fusion |
| J-C | Johnson-Cook |
| LS | Laser Shock |
| MMOD | Micro-Meteoroid and Orbital Debris |
| PW | Plain Weave |
| SPH | Smoothed Particle Hydrodynamics |
| UD | Uni-Directional |
| VARTM | Vacuum Assisted Resin Transfer Molding |
References
- Space Debris by the Numbers 2023.
- Piekutowski, A.J.; Poormon, K.L.; Christiansen, E.L.; Davis, B.A. Performance of Whipple Shields at Impact Velocities above 9km/s. Int. J. Impact Eng. 2011, 38, 495–503. [Google Scholar] [CrossRef]
- Adushkin, V.V.; Aksenov, O.Yu.; Veniaminov, S.S.; Kozlov, S.I.; Tyurenkova, V.V. The Small Orbital Debris Population and Its Impact on Space Activities and Ecological Safety. Acta Astronaut. 2020, 176, 591–597. [Google Scholar] [CrossRef]
- Pai, A.; Divakaran, R.; Anand, S.; Shenoy, S.B. Advances in the Whipple Shield Design and Development: A Brief Review. J. Dyn. Behav. Mater. 2022, 8, 20–38. [Google Scholar] [CrossRef]
- Chen, Y.; Tang, Q.; He, Q.; Chen, L.; Chen, X. Review on Hypervelocity Impact of Advanced Space Debris Protection Shields. Thin-Walled Struct. 2024, 200, 111874. [Google Scholar] [CrossRef]
- Rakib, M.A.; Smith, S.T.; Tafsirojjaman, T. A Review of Shielding Systems for Protecting Off-Earth Structures from Micrometeoroid and Orbital Debris Impact. Acta Astronaut. 2024, 223, 404–425. [Google Scholar] [CrossRef]
- Whipple, F.L. Meteorites and Space Travel. Astron. J. 1947, 52, 131. [Google Scholar] [CrossRef] [PubMed]
- Rogers, J.A.; Bass, N.T.; Wiest, M.L.; Wantz, Z.; Wilkerson, J.W.; Lacy, T.E. The Pursuit of Hypervelocities: A Review of Two-Stage Light Gas Gun Aeroballistic Ranges. Int. J. Impact Eng. 2024, 185, 104861. [Google Scholar] [CrossRef]
- Liu, S. Ballistic Range. In Hypervelocity Launchers; Seiler, F., Igra, O., Eds.; Springer International Publishing: Cham, 2016; pp. 23–52. ISBN 978-3-319-26016-7. [Google Scholar]
- Veysset, D.; Lee, J.-H.; Hassani, M.; Kooi, S.E.; Thomas, E.L.; Nelson, K.A. High-Velocity Micro-Projectile Impact Testing. Appl. Phys. Rev. 2021, 8, 011319. [Google Scholar] [CrossRef]
- Hoffman, J. The Effect of Recoil Pressure in the Ablation of Polycrystalline Graphite by a Nanosecond Laser Pulse. J. Phys. Appl. Phys. 2015, 48, 235201. [Google Scholar] [CrossRef]
- Balageas, D.; Deom, A.; Devezeaux De Lavergne, D.; Demange, D. Hypervelocity Erosion of Carbon-Carbon Composites by Laser Simulation. In Proceedings of the 18th Thermophysics Conference, July 1 1983; American Institute of Aeronautics and Astronautics: Montreal,Canada. [Google Scholar]
- Jaulin, V.; Hébert, D.; Aubert, B.; Rullier, J.-L.; Malaise, F.; Lescoute, E. Laser-Induced Cratering of a 3DCC Material at Mesoscale: Experiments and Simulations. EPJ Web Conf. 2018, 183, 01028. [Google Scholar] [CrossRef]
- Aubert, B.; Hébert, D.; Rullier, J.L.; Lescoute, E.; Videau, L.; Berthe, L. Laser Simulation of Hypervelocity Impact into Porous Graphite. Int. J. Impact Eng. 2025, 206, 105474. [Google Scholar] [CrossRef]
- Seisson, G.; Prudhomme, G.; Frugier, P.-A.; Hébert, D.; Lescoute, E.; Sollier, A.; Videau, L.; Mercier, P.; Boustie, M.; Berthe, L. Dynamic Fragmentation of Graphite under Laser-Driven Shocks: Identification of Four Damage Regimes. Int. J. Impact Eng. 2016, 91, 68–79. [Google Scholar] [CrossRef]
- Kormpos, P.; Unaldi, S.; Berthe, L.; Tserpes, K. A Laser Shock-Based Disassembly Process for Adhesively Bonded Ti/CFRP Parts. Processes 2023, 11, 506. [Google Scholar] [CrossRef]
- Tserpes, K.; Kormpos, P. Detailed Finite Element Models for the Simulation of the Laser Shock Wave Response of 3D Woven Composites. J. Compos. Sci. 2024, 8, 83. [Google Scholar] [CrossRef]
- Pirri, A.N. Theory for Laser Simulation of Hypervelocity Impact. Phys. Fluids 1977, 20, 221–228. [Google Scholar] [CrossRef]
- Nebolsine, P. Laser Simulation of Hypervelocity Impact. In Proceedings of the 14th Aerospace Sciences Meeting, January 26 1976; American Institute of Aeronautics and Astronautics: Washington,DC,U.S.A. [Google Scholar]
- Borodziuk, S.; Kasperczuk, A.; Pisarczyk, T.; Rohlena, K.; Ullschmied, J.; Kalal, M.; Limpouch, J.; Pisarczyk, P. Application of Laser Simulation Method for the Analysis of Crater Formation Experiment on PALS Laser. Czechoslov. J. Phys. 2003, 53, 799–810. [Google Scholar] [CrossRef]
- Morena, A.; Peroni, L. Numerical Simulations of Laser-Induced Shock Experiments on Graphite. Materials 2021, 14, 7079. [Google Scholar] [CrossRef] [PubMed]
- Hébert, D.; Bras, C.L.; Reynier, B.; Aubert, B.; Chevalier, J.-M.; Lescoute, E.; Boutoux, G.; Jodar, B.; Géral, T.; Loison, D.; et al. Momentum Transfer During Laser-Driven Cratering Experiments. In Proceedings of the 2024 17th Hypervelocity Impact Symposium, September 13 2024; American Society of Mechanical Engineers: Tsukuba, Japan; p. V001T06A001. [Google Scholar]
- Wicklein, M.; Ryan, S.; White, D.M.; Clegg, R.A. Hypervelocity Impact on CFRP: Testing, Material Modelling, and Numerical Simulation. Int. J. Impact Eng. 2008, 35, 1861–1869. [Google Scholar] [CrossRef]
- Wan, H.; Bai, S.; Li, S.; Mo, J.; Zhao, S.; Song, Z. Shielding Performances of the Designed Hybrid Laminates Impacted by Hypervelocity Flyer. Mater. Des. 1980-2015 2013, 52, 422–428. [Google Scholar] [CrossRef]
- Tserpes, K.; Papadopoulos, K.; Unaldi, S.; Berthe, L. Development of a Numerical Model to Simulate Laser-Shock Paint Stripping on Aluminum Substrates. Aerospace 2021, 8, 233. [Google Scholar] [CrossRef]
- Gakias, C.; Lamprou, A. 2022. [CrossRef]
- Haque, B.; Gillespie, J., Jr. Rate Dependent Progressive Composite Damage Modeling Using MAT162 in LS-DYNA. In Proceedings of the Proceedings of the 13th International LS-DYNA Users Conference, 2014; Livermore Software Technology Corporation. [Google Scholar]
- He, Q.-G.; Chen, X.; Chen, J.-F. Finite Element-Smoothed Particle Hydrodynamics Adaptive Method in Simulating Debris Cloud. Acta Astronaut. 2020, 175, 99–117. [Google Scholar] [CrossRef]
- Papadopoulos, K.; Tserpes, K. Analytical and Numerical Modeling of Stress Field and Fracture in Aluminum/Epoxy Interface Subjected to Laser Shock Wave: Application to Paint Stripping. Materials 2022, 15, 3423. [Google Scholar] [CrossRef] [PubMed]
- Fowler, K.; Teixeira-Dias, F. Optimisation of Hybrid Composite Shields for Hypervelocity Micro-Meteoroid and Orbital Debris (MMOD) Impact. Adv. Space Res. 2024, 73, 6194–6208. [Google Scholar] [CrossRef]
- Floros, I.S.; Tserpes, K.I.; Löbel, T. Mode-I, Mode-II and Mixed-Mode I+II Fracture Behavior of Composite Bonded Joints: Experimental Characterization and Numerical Simulation. Compos. Part B Eng. 2015, 78, 459–468. [Google Scholar] [CrossRef]
- Al-Azzawi, A.S.M.; McCrory, J.; Kawashita, L.F.; Featherston, C.A.; Pullin, R.; Holford, K.M. Buckling and Postbuckling Behaviour of Glare Laminates Containing Splices and Doublers. Part 1: Instrumented Tests. Compos. Struct. 2017, 176, 1158–1169. [Google Scholar] [CrossRef]
- Li, Y.; Chen, L.; Chen, M.; Liu, F.; Gu, Y.; Guo, B.; Hua, J.; Huang, T.; Leng, Y.; Li, F.; et al. High-Intensity Lasers and Research Activities in China. High Power Laser Sci. Eng. 2025, 13, e12. [Google Scholar] [CrossRef]
- Jungwirth, K.; Cejnarova, A.; Juha, L.; Kralikova, B.; Krasa, J.; Krousky, E.; Krupickova, P.; Laska, L.; Masek, K.; Mocek, T.; et al. The Prague Asterix Laser System. Phys. Plasmas 2001, 8, 2495–2501. [Google Scholar] [CrossRef]
- Danson, C.N.; Haefner, C.; Bromage, J.; Butcher, T.; Chanteloup, J.-C.F.; Chowdhury, E.A.; Galvanauskas, A.; Gizzi, L.A.; Hein, J.; Hillier, D.I.; et al. Petawatt and Exawatt Class Lasers Worldwide. High Power Laser Sci. Eng. 2019, 7, e54. [Google Scholar] [CrossRef]
- Central Laser Facility Annual Report 2020–2021 2021
- Bagnoud, V.; Aurand, B.; Blazevic, A.; Borneis, S.; Bruske, C.; Ecker, B.; Eisenbarth, U.; Fils, J.; Frank, A.; Gaul, E.; et al. Commissioning and Early Experiments of the PHELIX Facility. Appl. Phys. B 2010, 100, 137–150. [Google Scholar] [CrossRef]
- Hopps, N.; Oades, K.; Andrew, J.; Brown, C.; Cooper, G.; Danson, C.; Daykin, S.; Duffield, S.; Edwards, R.; Egan, D.; et al. Comprehensive Description of the Orion Laser Facility. Plasma Phys. Control. Fusion 2015, 57, 064002. [Google Scholar] [CrossRef]
- Zhu, J.; Zhu, J.; Li, X.; Zhu, B.; Ma, W.; Lu, X.; Fan, W.; Liu, Z.; Zhou, S.; Xu, G.; et al. Status and Development of High-Power Laser Facilities at the NLHPLP. High Power Laser Sci. Eng. 2018, 6, e55. [Google Scholar] [CrossRef]
- Grun, J.; Decoste, R.; Ripin, B.H.; Gardner, J. Characteristics of Ablation Plasma from Planar, Laser-Driven Targets. Appl. Phys. Lett. 1981, 39, 545–547. [Google Scholar] [CrossRef]
- Dautray, R.; Watteau, J.-P. La Fusion Thermonucléaire Inertielle Par Laser; Commissariat à l’Energie Atomique, 1993; ISBN ISBN 2-7272-0170-2. [Google Scholar]
- Vasilyan, S.; Fröhlich, T.; Manske, E. Total Momentum Transfer Produced by the Photons of a Multi-Pass Laser Beam as an Evident Avenue for Optical and Mass Metrology. Opt. Express 2017, 25, 20798. [Google Scholar] [CrossRef] [PubMed]
- Phipps, C.R.; Turner, T.P.; Harrison, R.F.; York, G.W.; Osborne, W.Z.; Anderson, G.K.; Corlis, X.F.; Haynes, L.C.; Steele, H.S.; Spicochi, K.C.; et al. Impulse Coupling to Targets in Vacuum by KrF, HF, and CO2 Single-Pulse Lasers. J. Appl. Phys. 1988, 64, 1083–1096. [Google Scholar] [CrossRef]
Figure 1.
Similarity between typical Laser Shock and Hypervelocity Impact shockwave propagation phenomenon.
Figure 1.
Similarity between typical Laser Shock and Hypervelocity Impact shockwave propagation phenomenon.
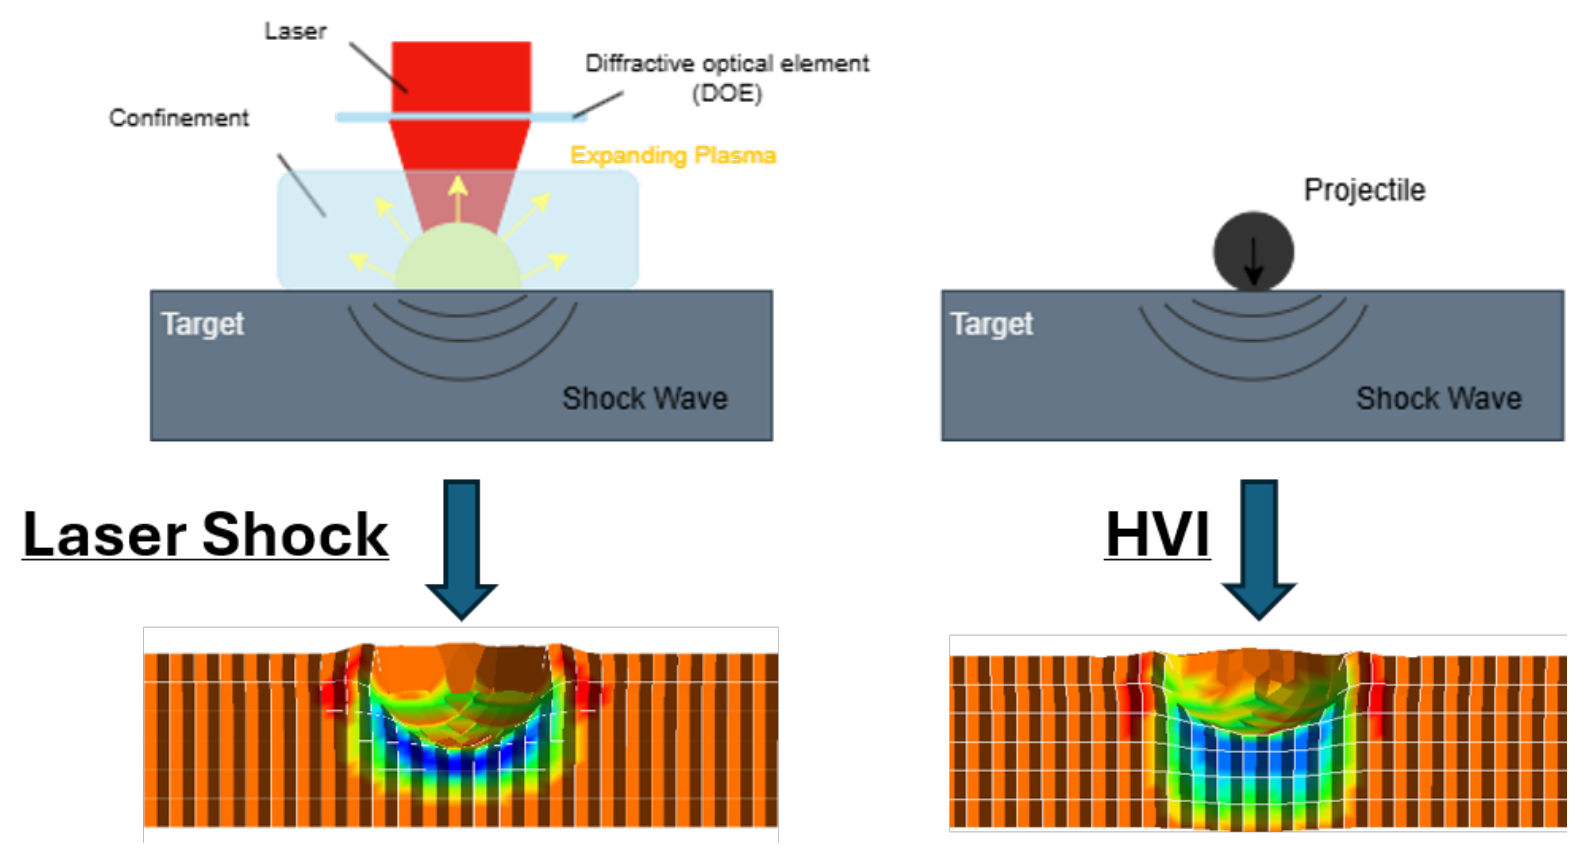
Figure 2.
Impact configurations examined in this study (a) Aluminum projectile impacting CFRP plate; (b) Mylar flyer impacting hybrid Al-CFRP-Al-CFRP-Al shield.
Figure 2.
Impact configurations examined in this study (a) Aluminum projectile impacting CFRP plate; (b) Mylar flyer impacting hybrid Al-CFRP-Al-CFRP-Al shield.
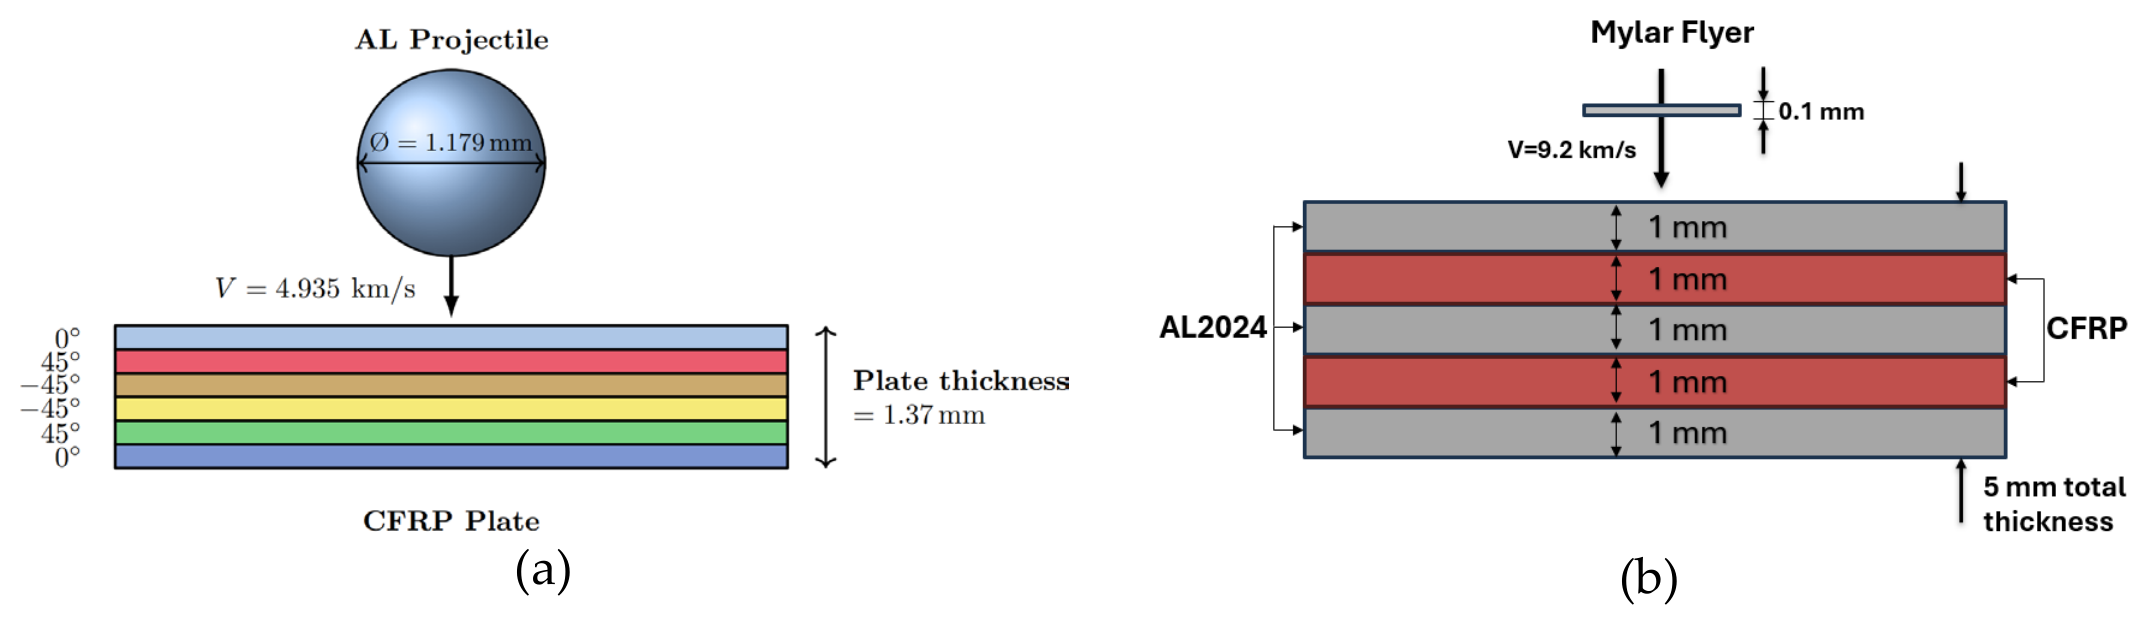
Figure 3.
Typical pressure loadings onto targets used for laser shock simulations [25].
Figure 3.
Typical pressure loadings onto targets used for laser shock simulations [25].
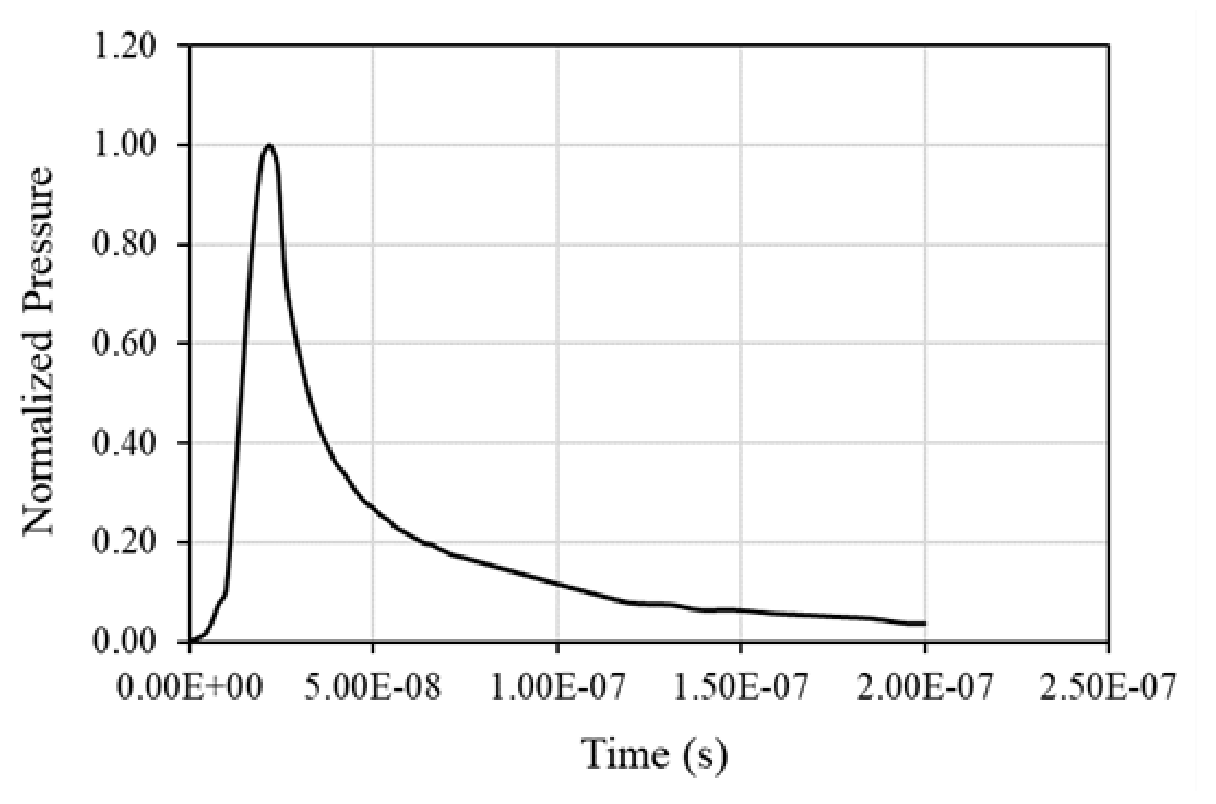
Figure 4.
Schematic of the laser shock loading applied through the *LOAD_ERODING_PART_SET keyword.
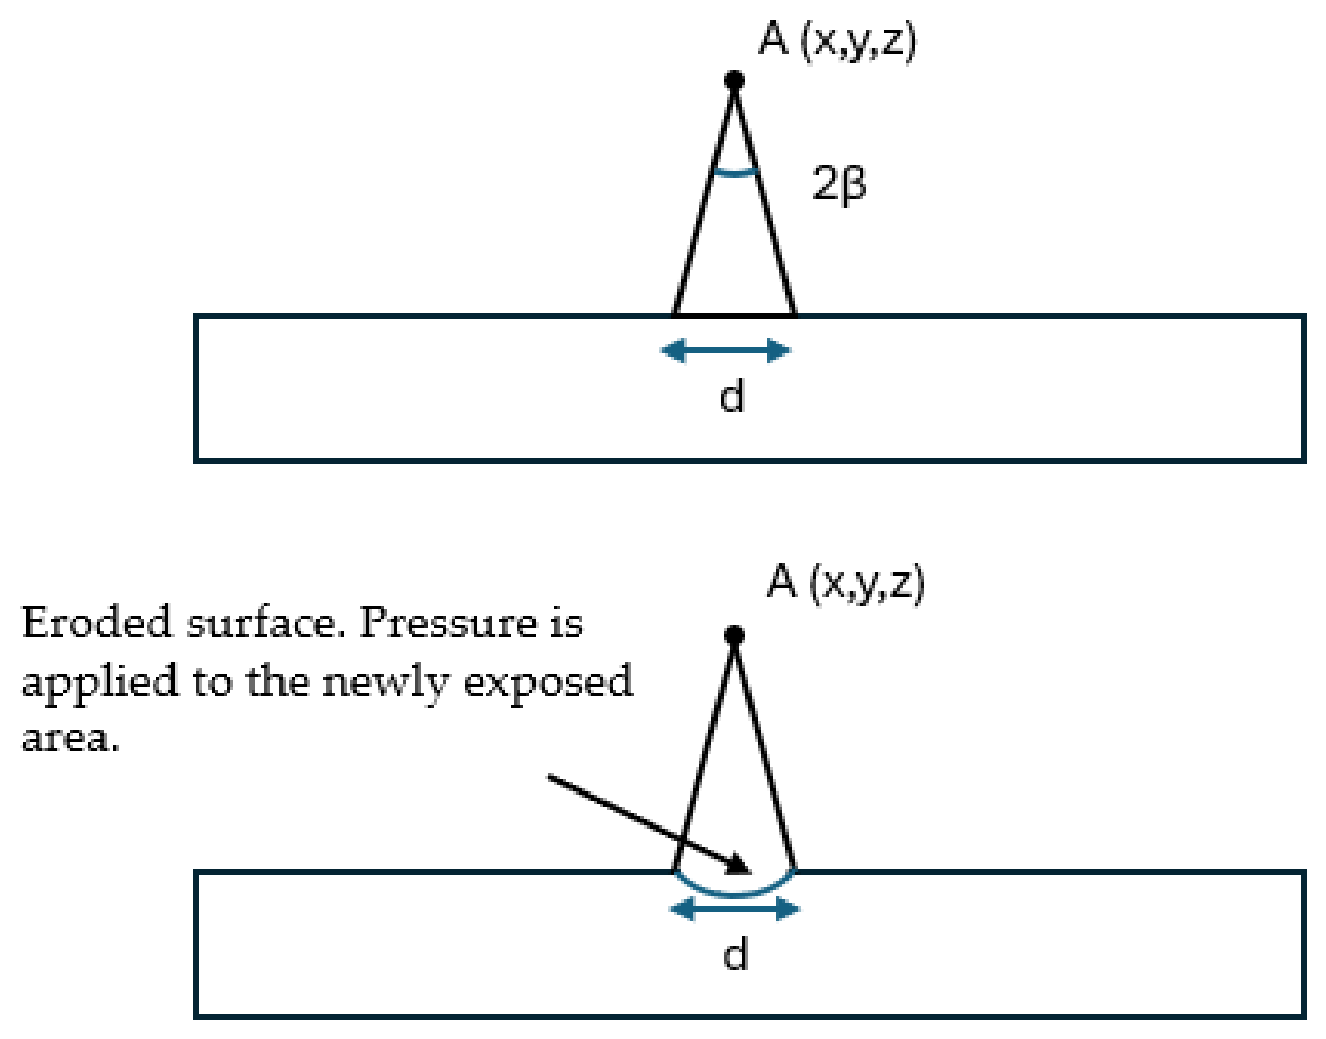
Figure 5.
Numerical model: (a) Plate refined mesh Isometric View; (b) Projectile spherified cube mesh cross-section view.
Figure 5.
Numerical model: (a) Plate refined mesh Isometric View; (b) Projectile spherified cube mesh cross-section view.
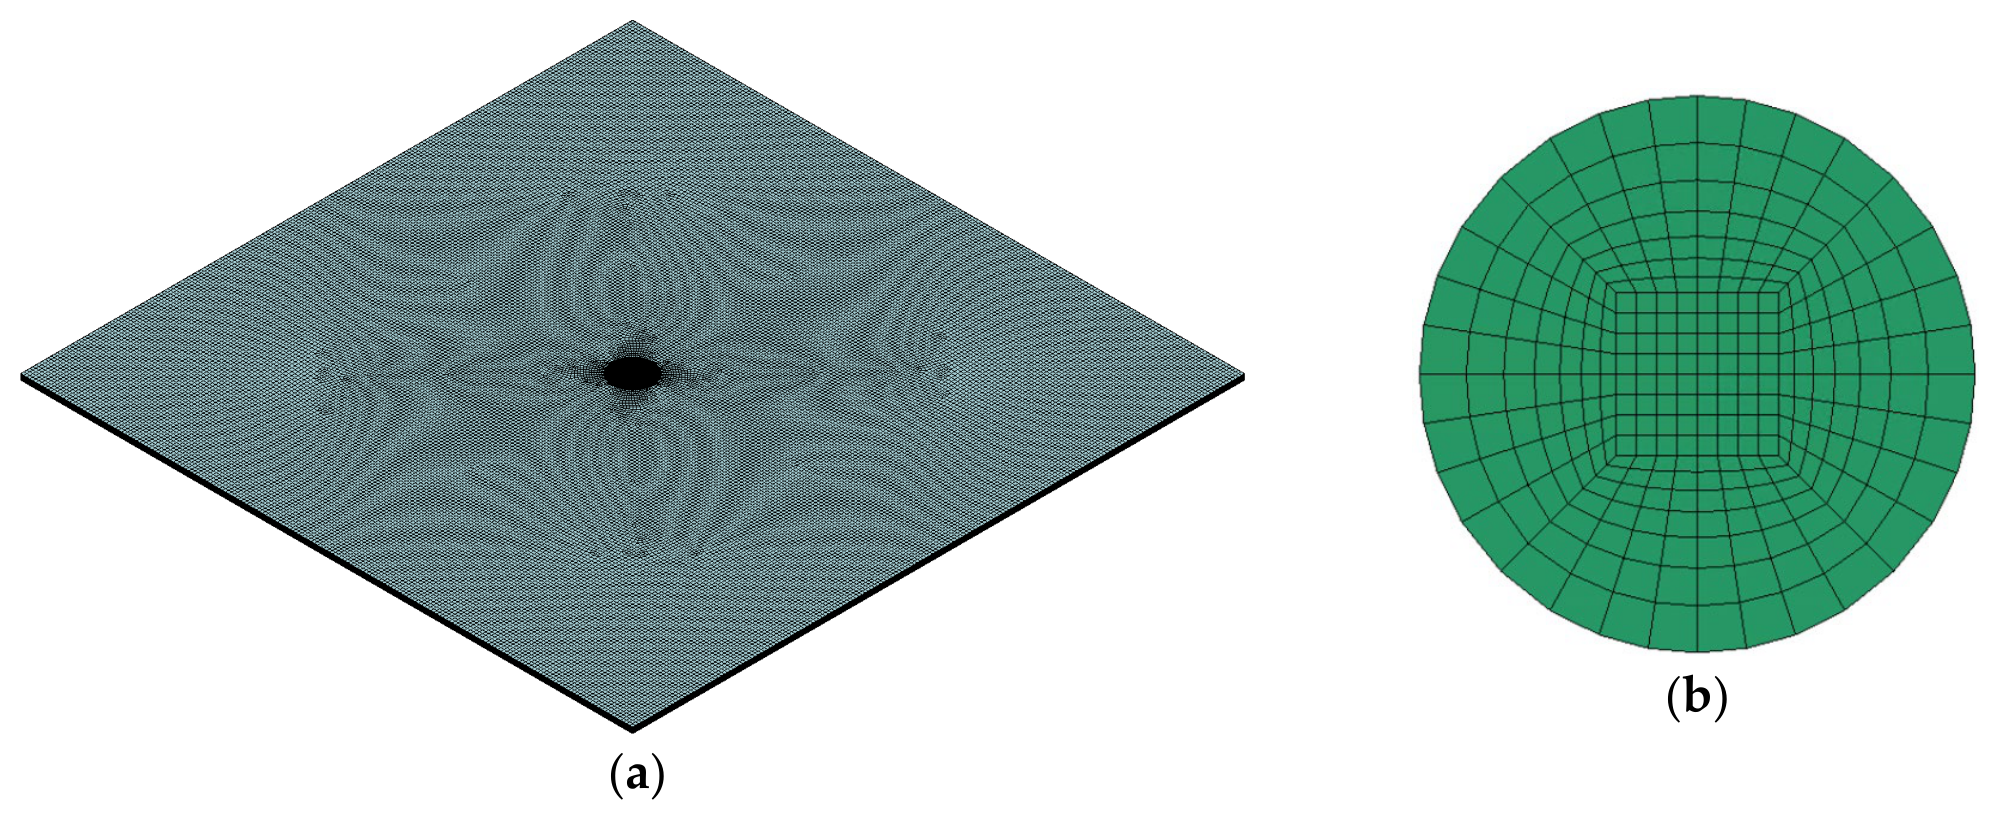
Figure 6.
FEM-SPH numerical model: (a) side cross-sectional view. (b) Isometric view.
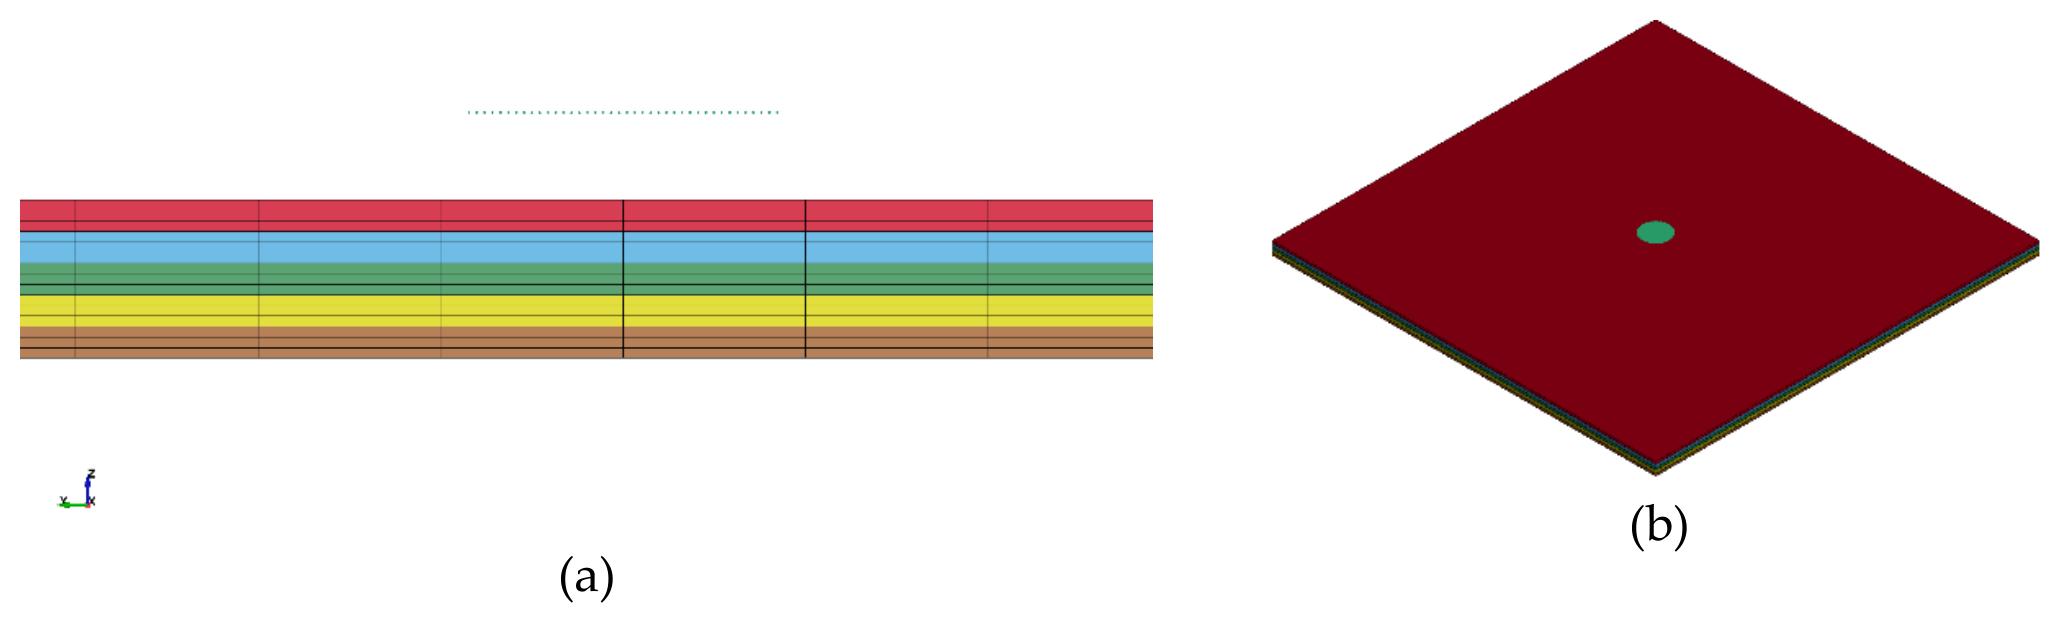
Figure 7.
Model validation in terms of delamination (a) Ultrasonic testing of the experimental impact; (b) Simulation results - top view.
Figure 7.
Model validation in terms of delamination (a) Ultrasonic testing of the experimental impact; (b) Simulation results - top view.
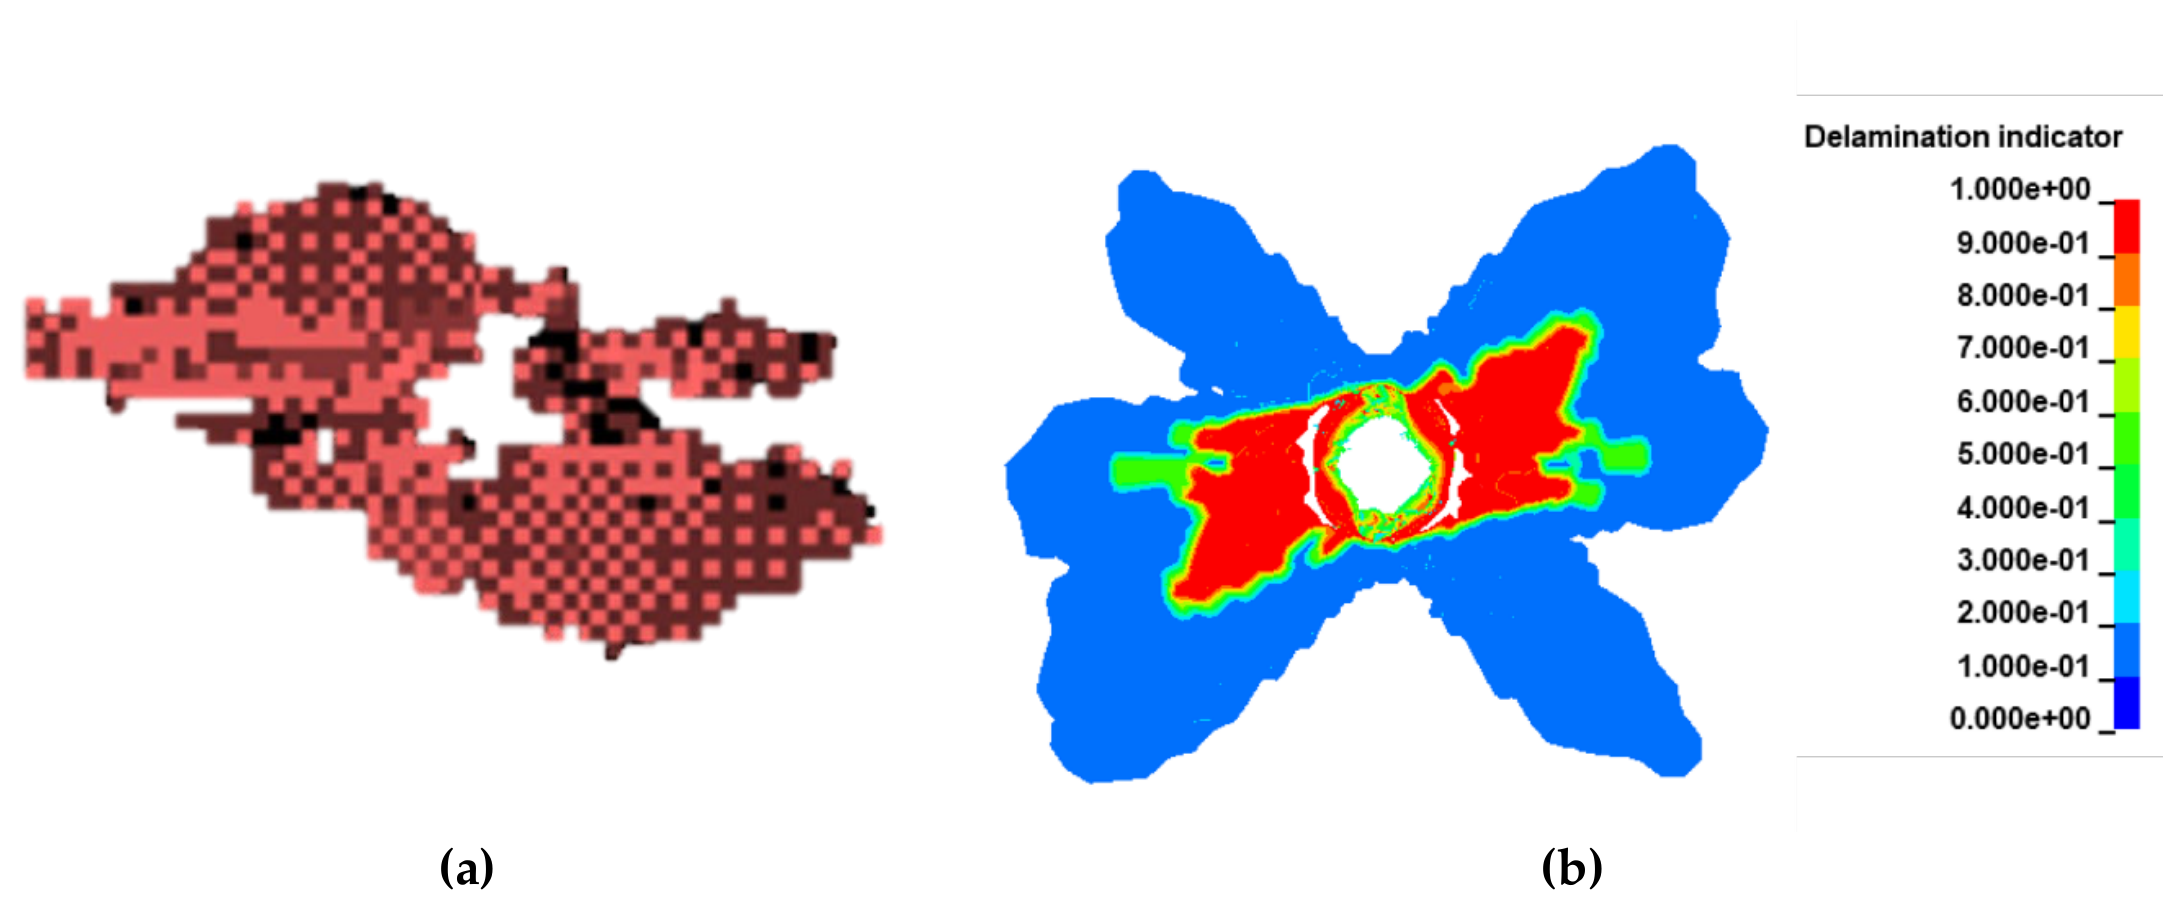
Figure 8.
Model validation in terms of hole generation (a) Photograph of the experimental hole; (b) Deleted elements of the simulation.
Figure 8.
Model validation in terms of hole generation (a) Photograph of the experimental hole; (b) Deleted elements of the simulation.
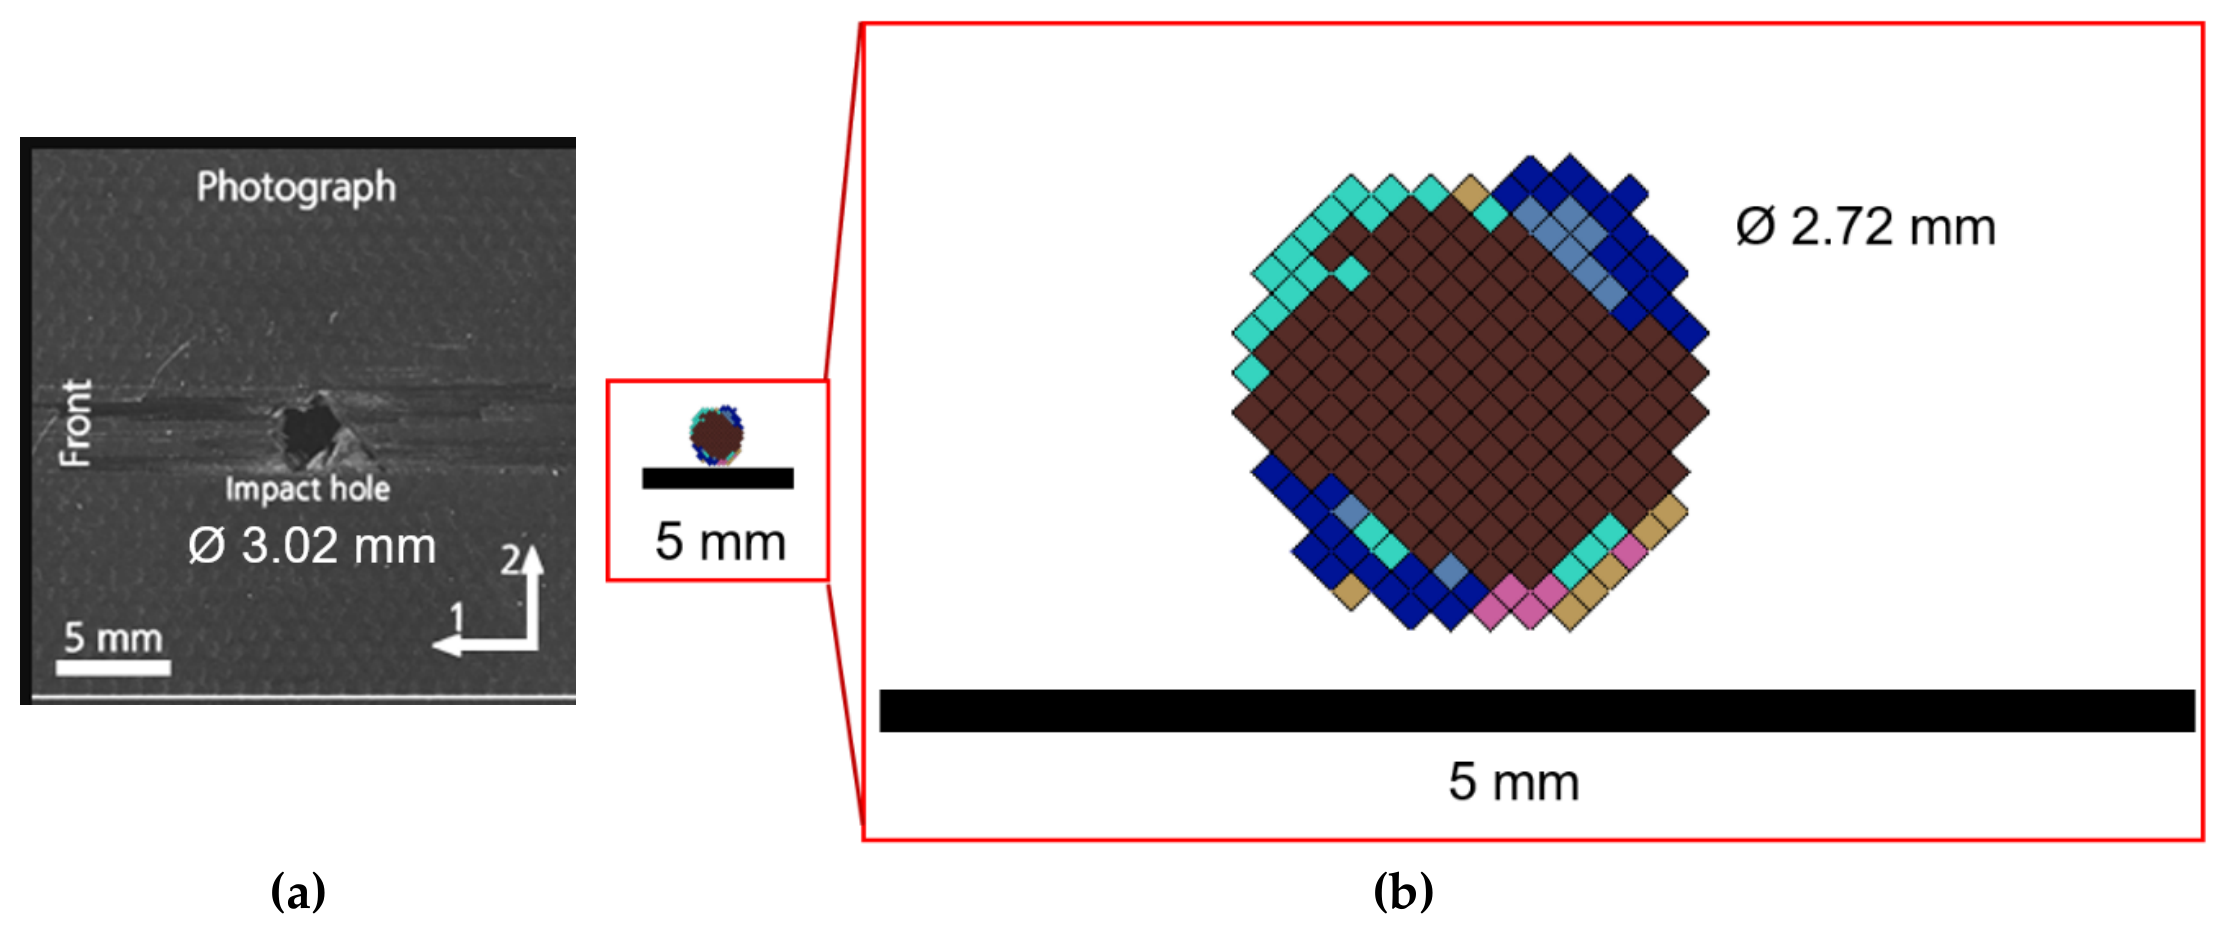
Figure 9.
Damage area comparison between LS and HVI projectile simulations. Pulse duration sensitivity analysis for ablation pressure of (a) 25 GPa and (b) 50 GPa.
Figure 9.
Damage area comparison between LS and HVI projectile simulations. Pulse duration sensitivity analysis for ablation pressure of (a) 25 GPa and (b) 50 GPa.
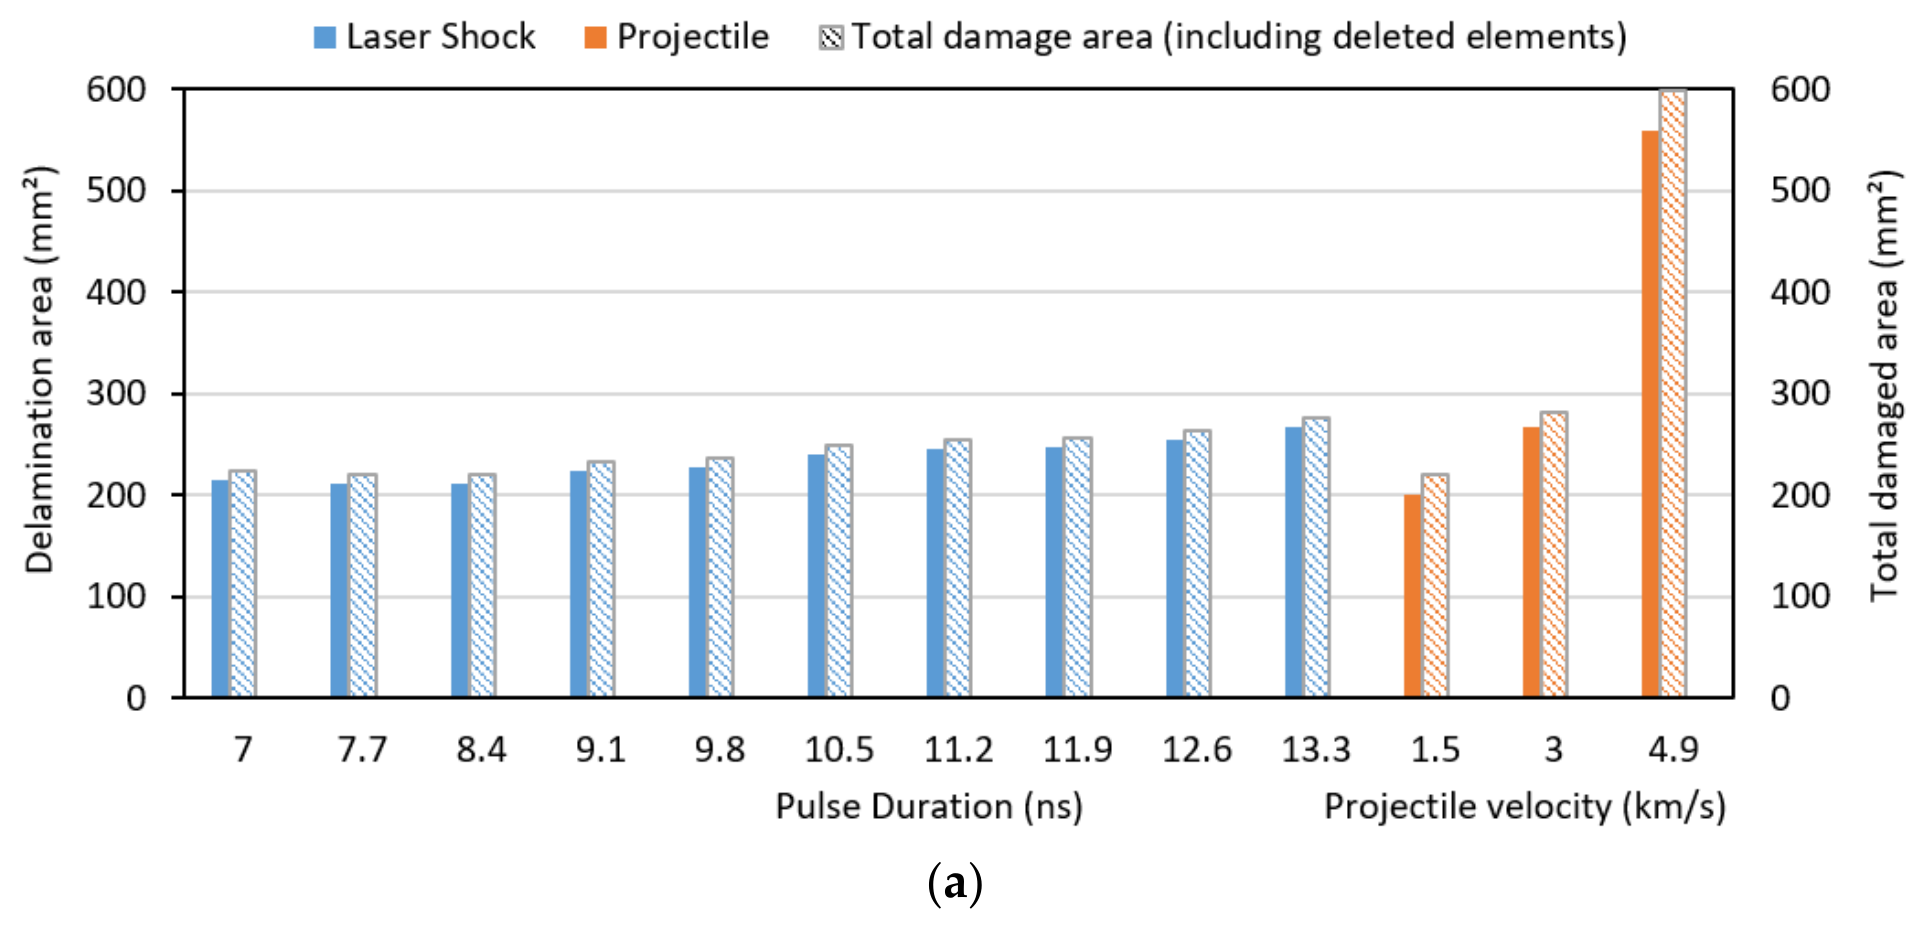
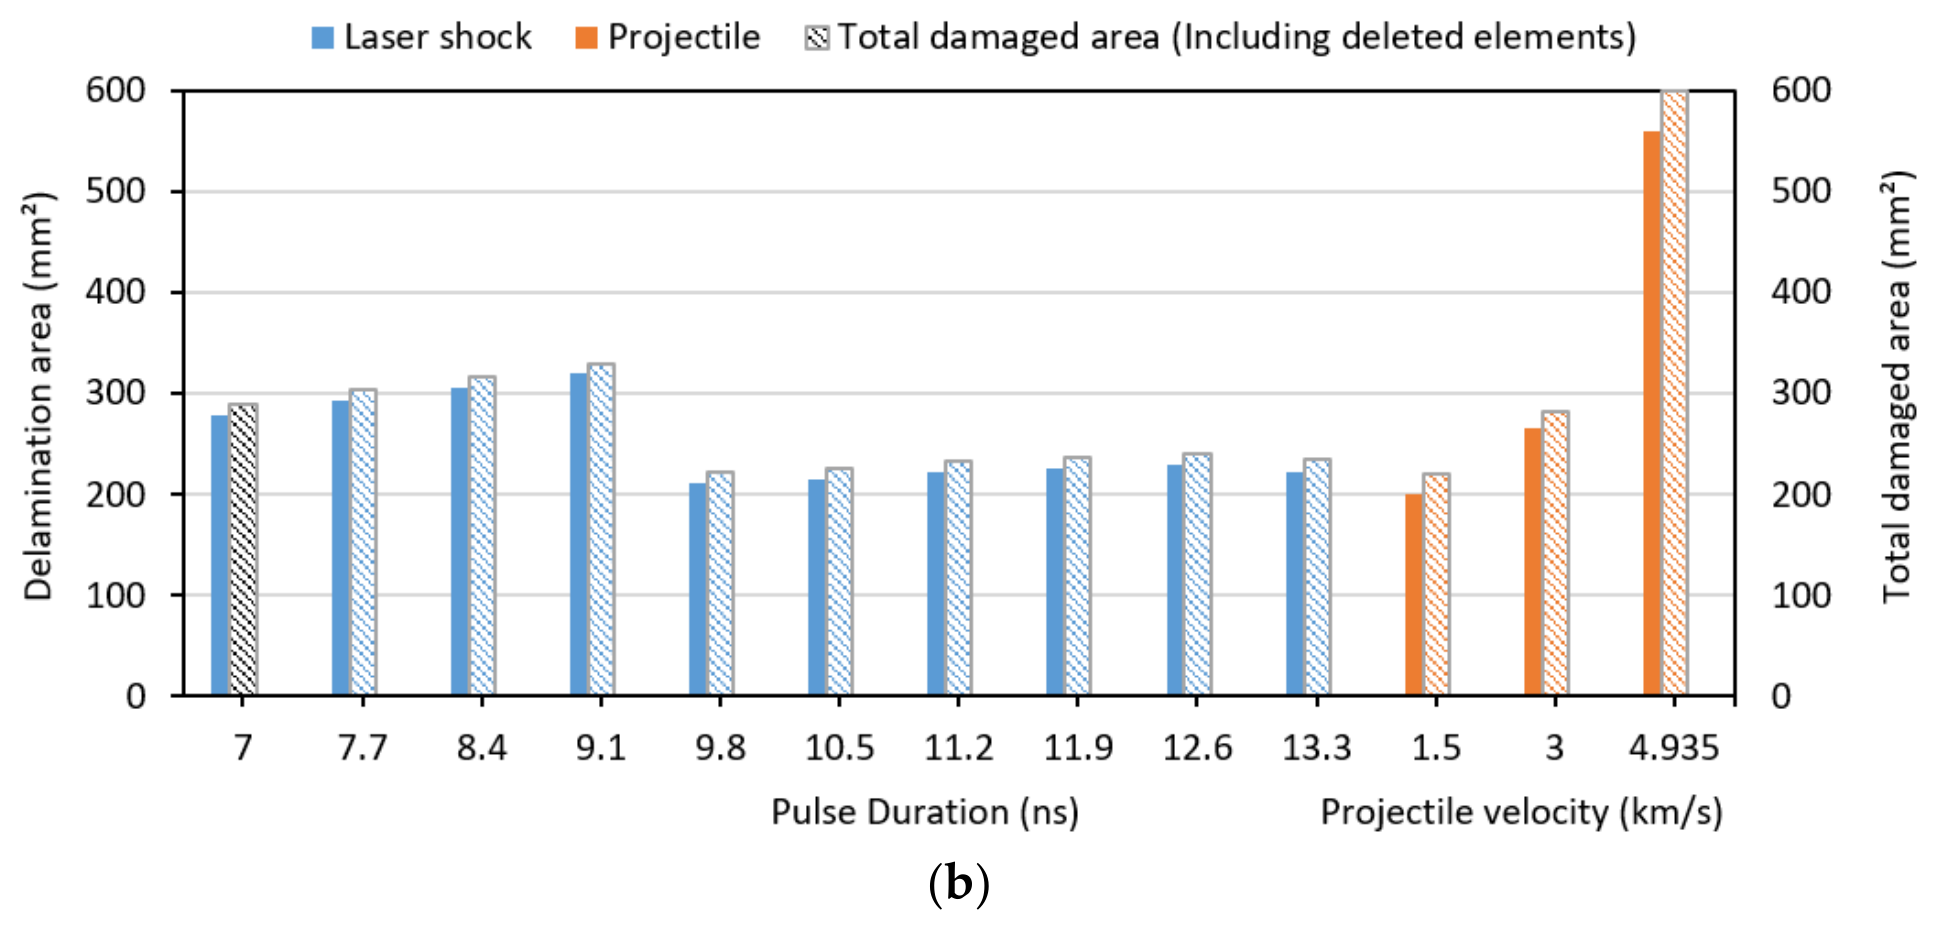
Figure 10.
Comparison of 1.5 km/s projectile speed HVI simulation with an LS simulation using 7 ns pulse duration with 25 GPa ablation pressure. (a) Top view comparison showing deleted elements for comparison. (b) Side cross-sectional view for crater comparison.
Figure 10.
Comparison of 1.5 km/s projectile speed HVI simulation with an LS simulation using 7 ns pulse duration with 25 GPa ablation pressure. (a) Top view comparison showing deleted elements for comparison. (b) Side cross-sectional view for crater comparison.
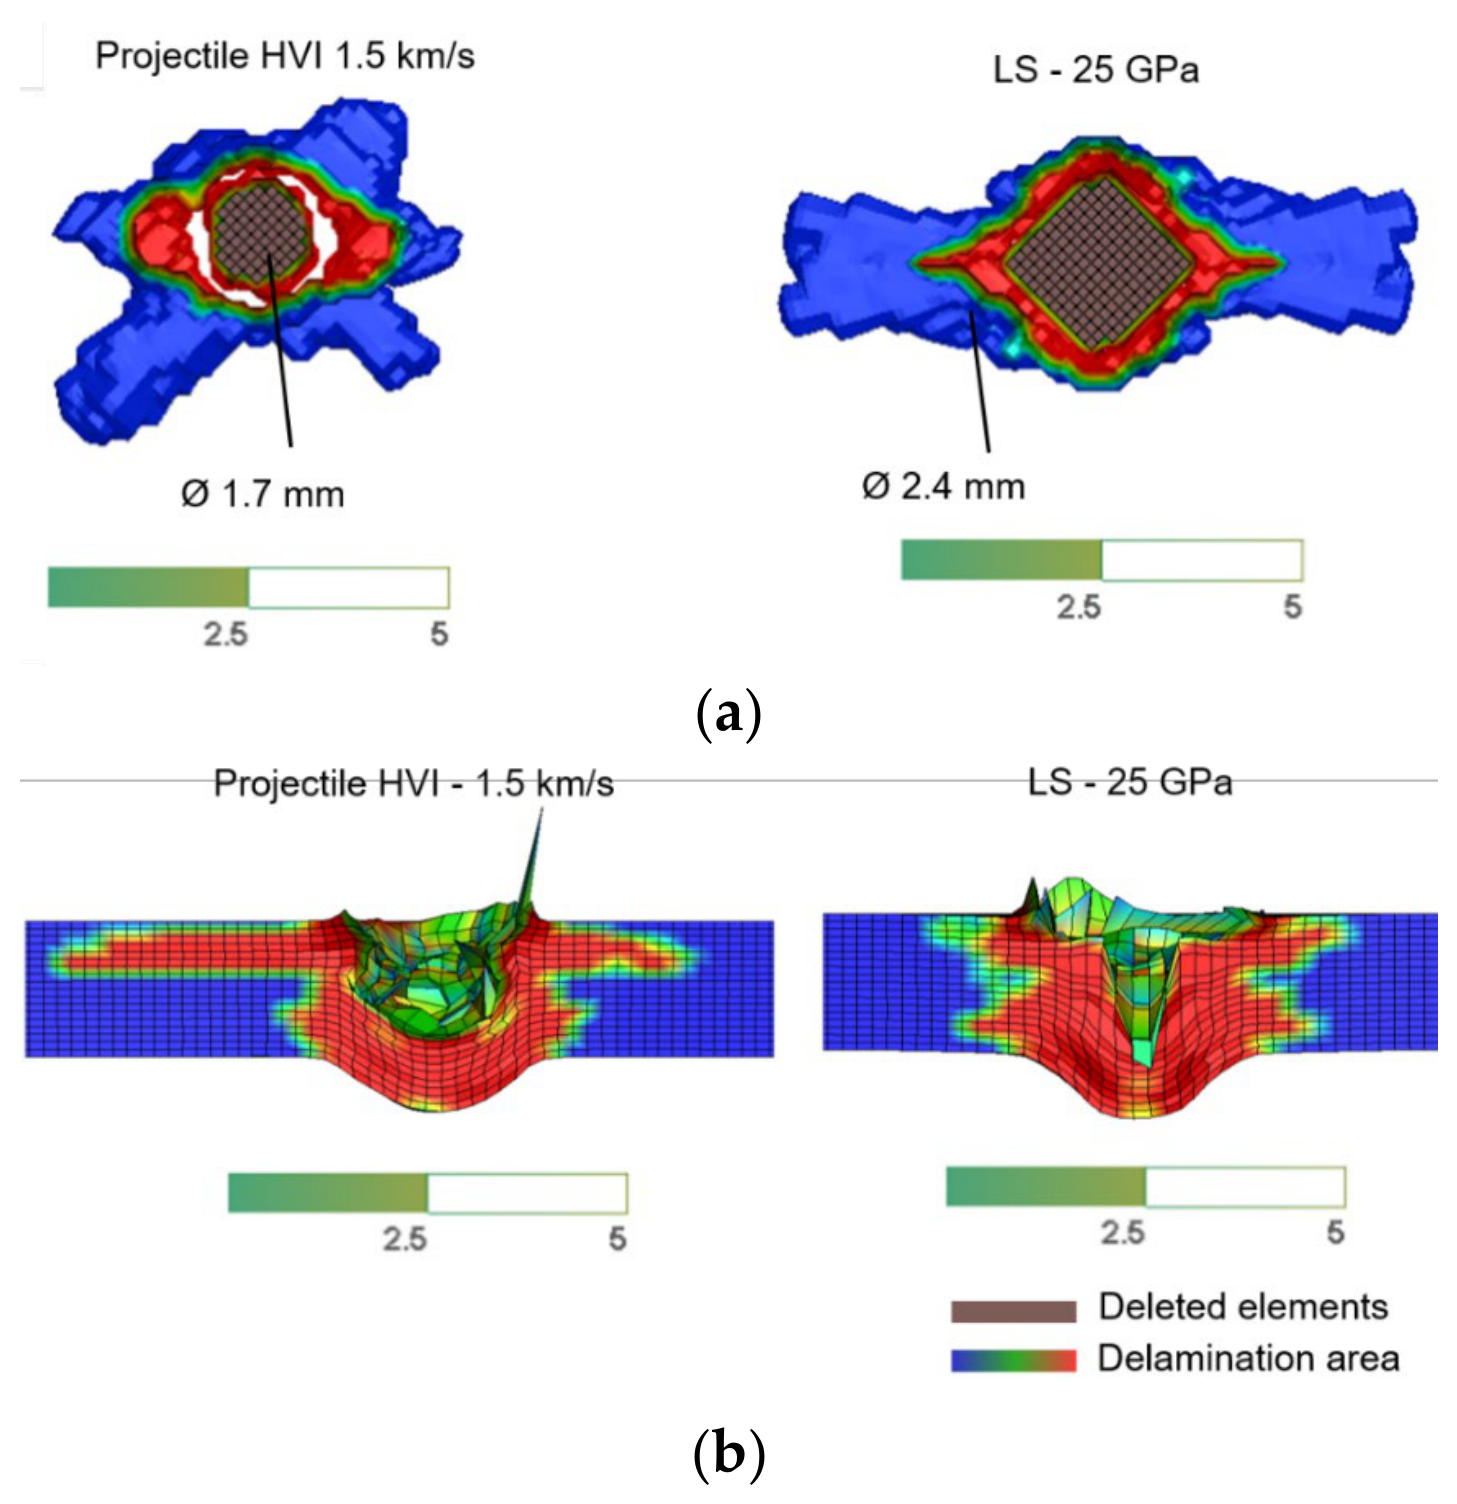
Figure 11.
Comparison of 3 km/s projectile speed HVI simulation with an LS simulation using 7 ns pulse du-ration with 50 GPa ablation pressure. (a) Top view comparison showing deleted elements for comparison. (b) Side cross-sectional view for crater comparison.
Figure 11.
Comparison of 3 km/s projectile speed HVI simulation with an LS simulation using 7 ns pulse du-ration with 50 GPa ablation pressure. (a) Top view comparison showing deleted elements for comparison. (b) Side cross-sectional view for crater comparison.
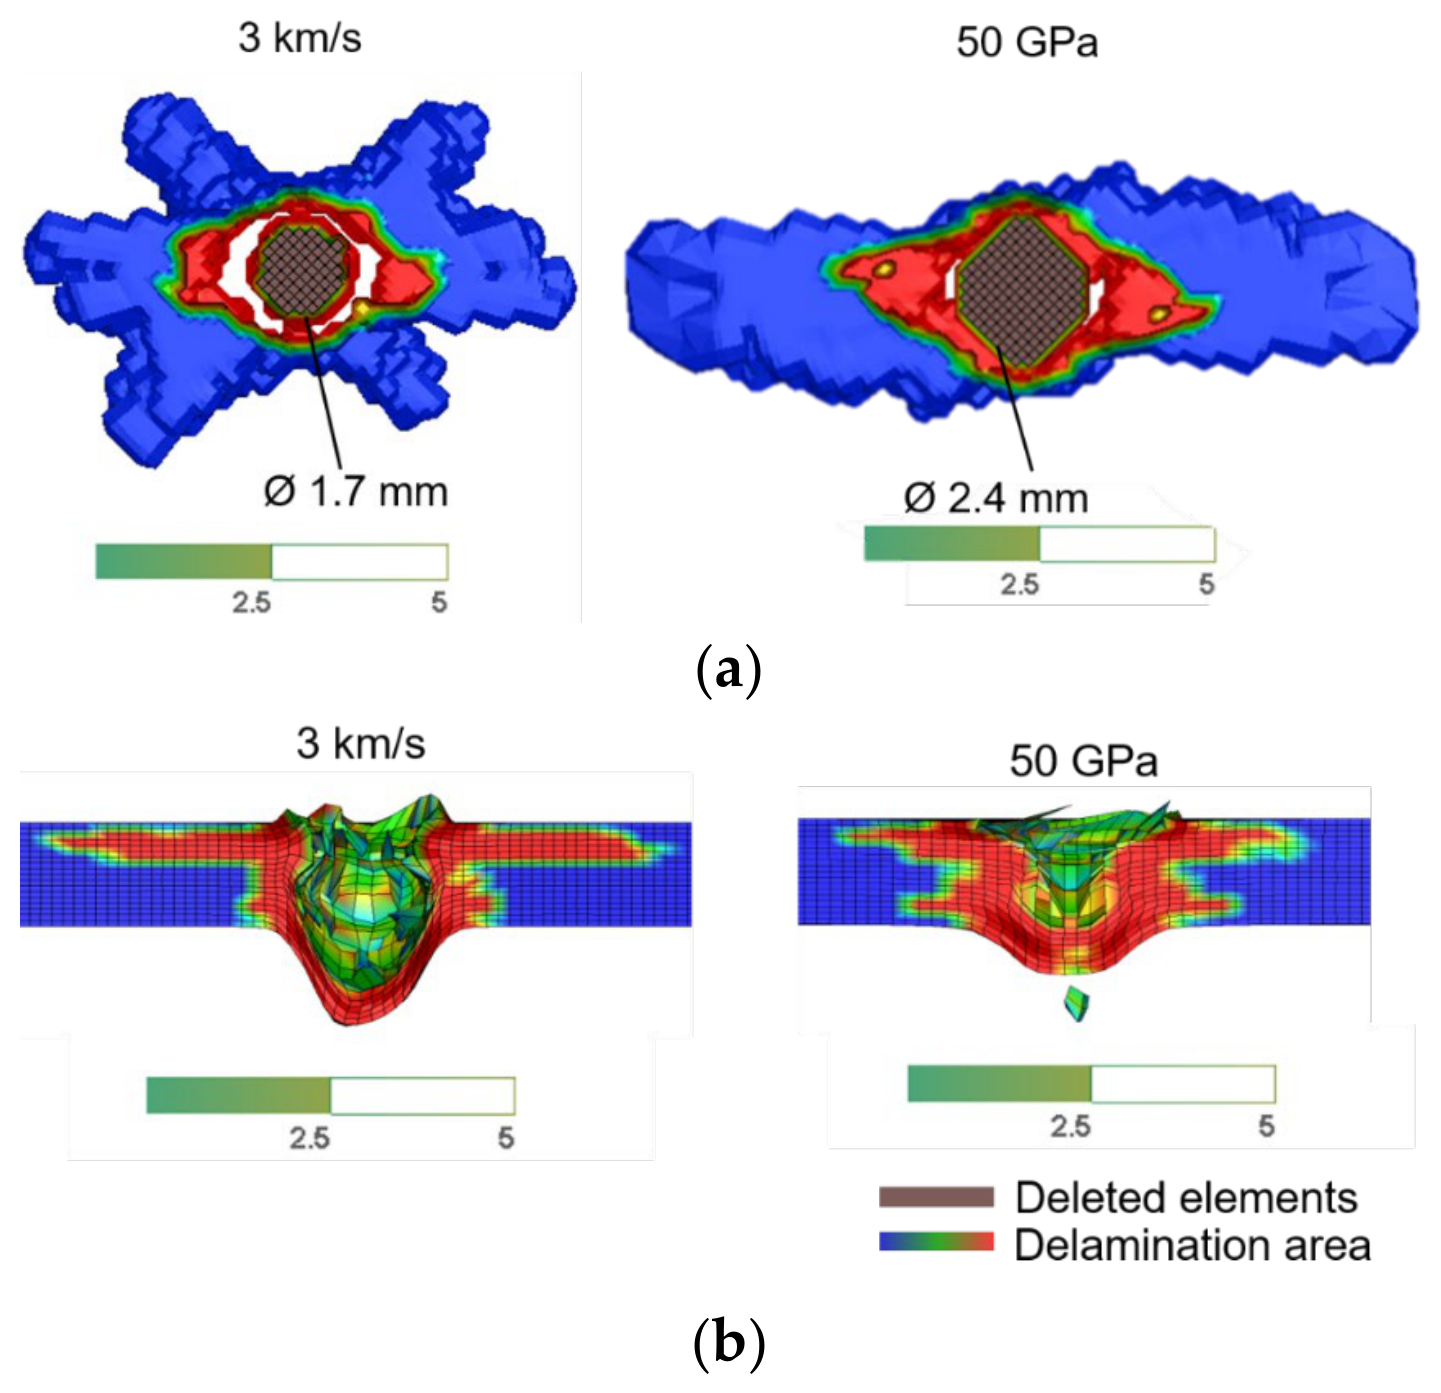
Figure 12.
Comparison of cross-sectional damage in the numerical model and the experiment: (a) Numerical model. (b) Experiment [24].
Figure 12.
Comparison of cross-sectional damage in the numerical model and the experiment: (a) Numerical model. (b) Experiment [24].
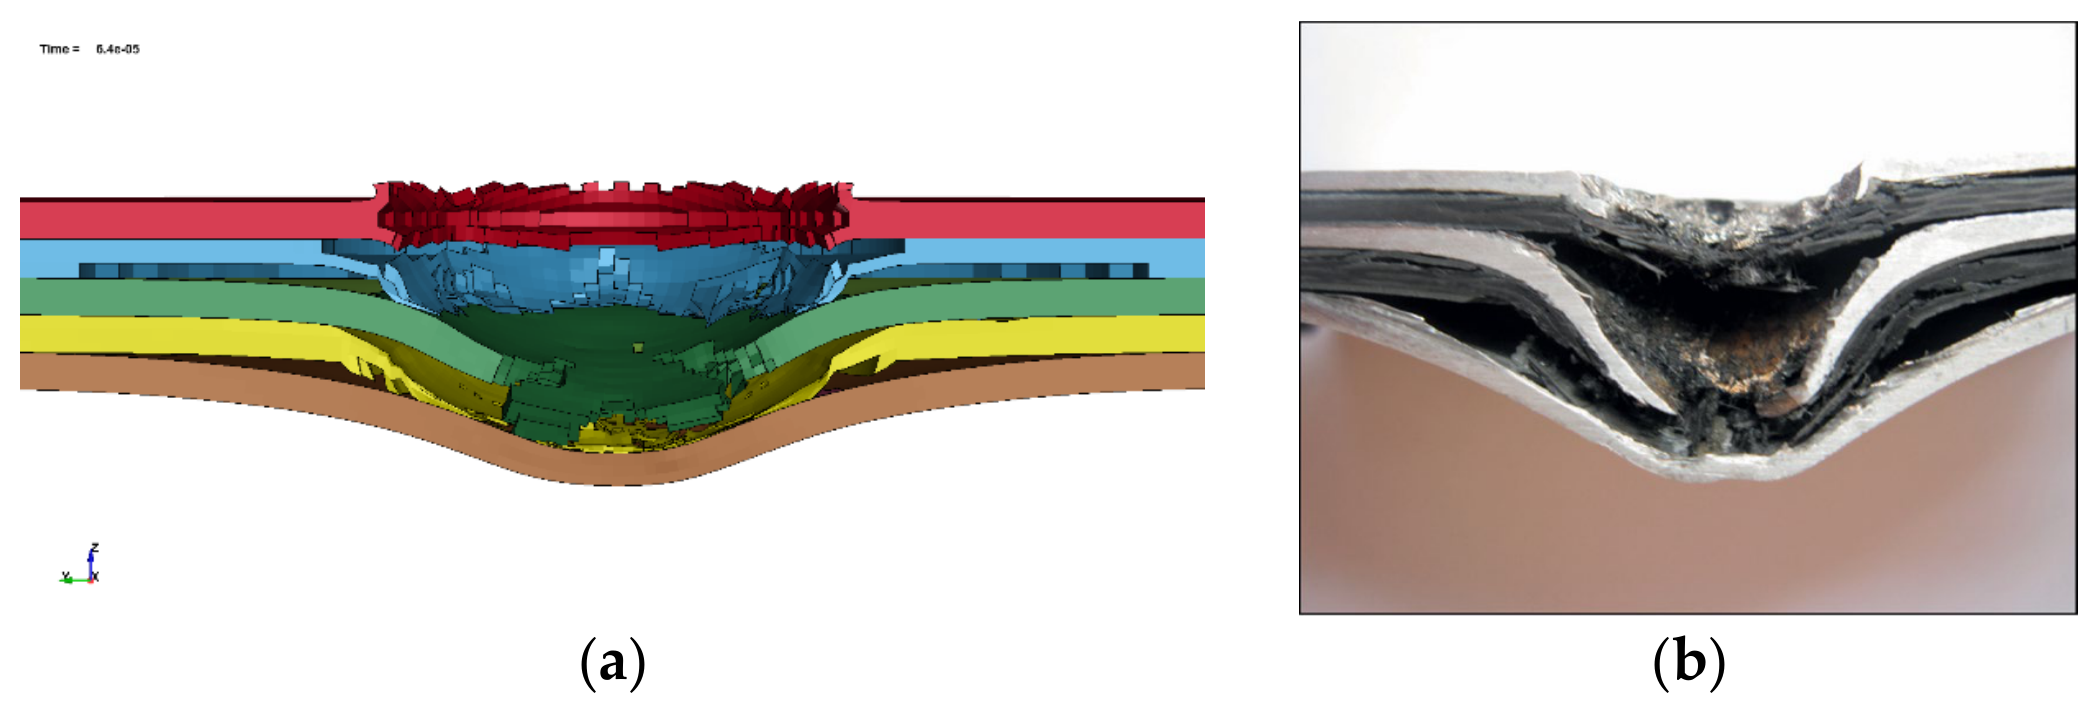
Figure 13.
Cross-sectional damage comparison between (a) the laser shock simulation with 40 GPa peak pressure and 15 ns pulse duration, and (b) the hypervelocity impact simulation at 9.2 km/s.
Figure 13.
Cross-sectional damage comparison between (a) the laser shock simulation with 40 GPa peak pressure and 15 ns pulse duration, and (b) the hypervelocity impact simulation at 9.2 km/s.
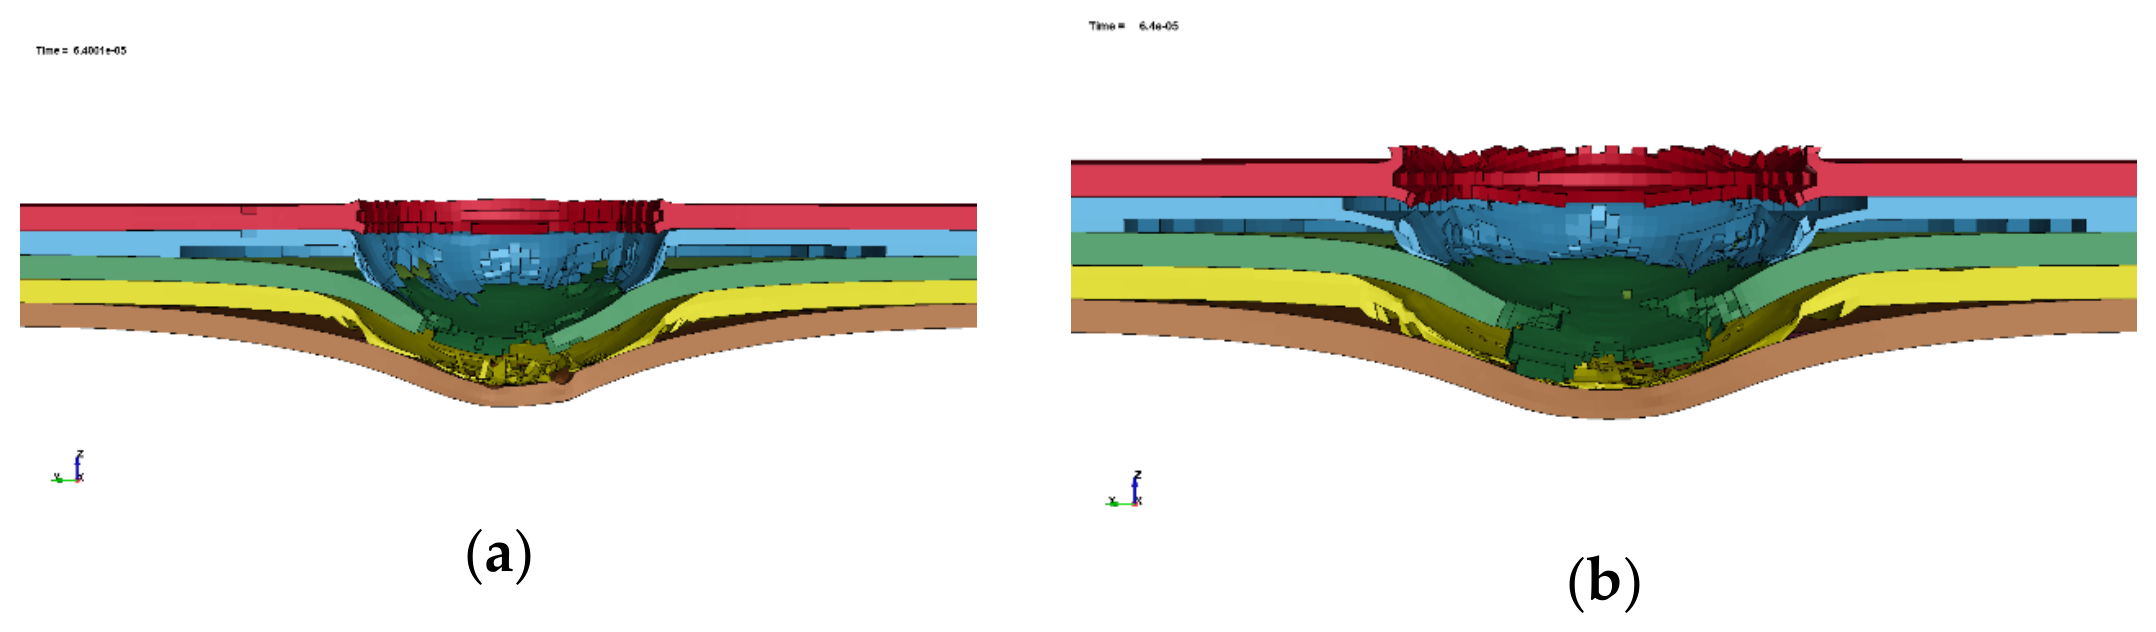

Table 1.
Laser ablation pressure scaling laws for direct irradiation in vacuum [26].
Table 1.
Laser ablation pressure scaling laws for direct irradiation in vacuum [26].
| Scaling Law | Equation |
| Grün | |
| Dautray | |
| Pirri | |
| Phipps |
Table 2.
Data set of CFRP material model [23].
Table 2.
Data set of CFRP material model [23].
| Equation of state: ortho | Strength: orthotropic yield | Failure: orthotropic softening | |||
| Reference density [g/cm³] | 1.563 | A11 | 0.025 | Tensile failure stress 11 [MPa] | 619 |
| Young's modulus 11 [GPa] | 72.90 | A22 | 1 | Tensile failure stress 22 [MPa] | 195 |
| Young's modulus 22 [GPa] | 22.89 | A33 | 0.660 | Tensile failure stress 33 [MPa] | 245.7 |
| Young's modulus 33 [GPa] | 9.07 | A12 | -0.1285 | Maximum shear stress 12 [MPa] | 280.5 |
| Poisson's ratio 12 | 0.77 | A13 | 0 | Maximum shear stress 23 [MPa] | 39.0 |
| Poisson's ratio 23 | 0.55 | A23 | -0.473 | Maximum shear stress 31 [MPa] | 47.5 |
| Poisson's ratio 31 | 0.0187 | A44 | 3.157 | Fracture energy 11 [J/m²] | 1E-6 |
| Shear Modulus 12 [GPa] | 48.35 | A55 | 2.128 | Fracture energy 22 [J/m²] | 1E-6 |
| Shear modulus 23 [GPa] | 0.558 | A66 | 0.061 | Fracture energy 33 [J/m²] | 333.5 |
| Shear modulus 31 [GPa] | 0.873 | [MPa] | 120.025 | Fracture energy 12 [J/m²] | 1E-6 |
| Bulk modulus A1 [GPa] | 25.04 | [MPa] | 238.825 | Fracture energy 23 [J/m²] | 1378 |
| Parameter [GPa] | 0 | 0 | Fracture energy 31 [J/m²] | 747 | |
| Parameter [GPa] | 0 | 0.00155 | Damage coupling coefficient | 0.2 | |
| Parameter | 1.098 | ||||
| Parameter | 1.098 | ||||
| Parameter [GPa] | 25.04 | ||||
| Parameter [GPa] | 0 | ||||
Table 3.
JC material model [31].
Table 3.
JC material model [31].
| Parameters | Symbol | 2024-T3 | 6061-T6 | |
| Johnson-Cook model parameters | ||||
| Density [kg/m³] | RO | 2770 | 2770 | |
| Poisson's ratio | PR | 0.33 | 0.33 | |
| Shear modulus [GPa] | G | 27.6 | 27.6 | |
| Static yield limit [MPa] | A | 265 | 290 | |
| Strain hardening modulus [MPa] | B | 426 | 203 | |
| Strain hardening exponent | n | 0.34 | 0.35 | |
| Strain rate coefficient | C | 0.015 | 0.011 | |
| Spall type | SPALL | 3 | 3 | |
| Failure parameters | D1 | 0.8 | 1 | |
| Failure parameters | D2-5 | 0 | 0 | |
| Mie-Gruneisen EOS parameters | ||||
| Constants | C | 5386 | 5386 | |
| Constants | S1 | 1.339 | 1.339 | |
| Constants | GAMAO | 1.97 | 1.97 | |
Table 4.
Material properties and damage model parameters of quasi-isotropic CFRP [32].
Table 4.
Material properties and damage model parameters of quasi-isotropic CFRP [32].
| Elastic material properties | ||||||||||||
| Density [kg/m3] | Elastic moduli [GPa] | Poisson’s ratios | Shear moduli [GPa] | |||||||||
| 1600 | 41 | 41 | 3.4 | 0.03 | 0.23 | 0.23 | 3.6 | 2.5 | 2.5 | |||
| Damage model parameters | ||||||||||||
| Tensile Strengths [MPa] | Compressive strengths [MPa] | Shear strengths [MPa] | ||||||||||
| 351 | 351 | 51 | 402 | 402 | 149 | 171 | 54 | 54 | ||||
Table 5.
Ply interface cohesive parameters [33].
Table 5.
Ply interface cohesive parameters [33].
| Interlaminar fracture strengths [J/m2] | Failure strengths [MPa] | ||
| Mode I, | Mode II, | Normal, | Shear, |
| 450 | 1000 | 40 | 40 |
Table 6.
JC constitutive law model and damage model parameters for AL2024 and Mie-Gruneisen EOS parameters of AL2024 and Mylar [32].
Table 6.
JC constitutive law model and damage model parameters for AL2024 and Mie-Gruneisen EOS parameters of AL2024 and Mylar [32].
| Elastic properties (AL2024) | |||
| Shear modulus, | 26.9 | GPa | |
| Poisson’s ration, | 0.3 | - | |
| Elastic modulus, | 69.9 | GPa | |
| JC constitutive model parameters (AL2024) | |||
| 167 | MPa | ||
| 684 | MPa | ||
| 0.551 | - | ||
| 0.001 | - | ||
| 0.859 | - | ||
| JC damage model parameters (AL2024) | |||
| 0.112 | - | ||
| 0.123 | - | ||
| 1.500 | - | ||
| 0.007 | - | ||
| 0.0 | - | ||
| Equation of state (AL2024, Mylar) | |||
| AL2024 | Mylar | ||
| Density, | 2785 | 1400 | kg/m3 |
| Grüneisen constant, | 1.97 | 0.76 | - |
| 1.4 | 1.56 | - | |
| Wave speed, | 5240 | 2270 | m/s |
| Volume correction factor, | 0.48 | 0 | - |
Table 7.
Laser facilities and their operating energy capabilities.
| Facility | Location | Ref. | |
| GCLT | CEA Le Barp (FR) | 150 J | [34] |
| National Ignition Facility (NIF) | LLNL, Livermore (US) | 2 MJ | [35] |
| LULI2000 | LULI, Palaiseau (FR) | 800-1600 J | [34] |
| GEKKO XII | ILE Osaka Univ. (JP) | 20 kJ | [36] |
| PALS | Prague (CZ) | 1.2 kJ | [37] |
| OMEGA EP (LP) | LLE Rochester (US) | 2.1 kJ | [38] |
| Vulcan (LP) | CLF-RAL (UK) | 2.6 kJ/beam (8 beams) | [39] |
| PHELIX | GSI Darmstadt (DE) | 1 kJ | [40] |
| ORION (LP) | AWE Aldermaston (UK) | 5 kJ | [41] |
| SG-II 9th beam | NLHPLP Shanghai (CN) | 5.13 kJ | [42] |
| SG-II UP | NLHPLP Shanghai (CN) | 8.5 kJ | [42] |
Table 8.
Required laser parameters across four impact cases CFRP, AL-CFRP-AL-CFRP-AL, assuming λ=1064 nm.
Table 8.
Required laser parameters across four impact cases CFRP, AL-CFRP-AL-CFRP-AL, assuming λ=1064 nm.
| Parameter / Projectile diameter () | Scaling Laws | ||||
| Grün | Dautray | Pirri | Phipps | ||
| Case 1:= 25.0 GPa, =7.7 ns,=1.179mm | |||||
| Required intensity [GW/cm²] | 792 | 310 | 1176 | 498 | |
| Required energy [J] | 67 | 26 | 99 | 42 | |
| Case 2:= 25.0 GPa,=13.3 ns,=1.179mm | |||||
| Required intensity [GW/cm²] | 792 | 310 | 1176 | 546 | |
| Required energy [J] | 115 | 45 | 171 | 79 | |
| Case 3:= 50.0 GPa,=7.0 ns,=1.179mm | |||||
| Required intensity [GW/cm²] | 1883 | 876 | 2868 | 1236 | |
| Required energy [J] | 144 | 67 | 219 | 94 | |
| Case 4:= 40.0 GPa,=15.0 ns, | |||||
| Required intensity [GW/cm²] | 1424 | 614 | 1269-1598 | 1135 | |
| Required energy [J] () | 42 | 18 | 37 | 33 | |
| Required energy [J] () | 168 | 72 | 165 | 134 | |
| Required energy [J] () | 378 | 163 | 394 | 301 | |
| Required energy [J] () | 671 | 290 | 729 | 535 | |
| Required energy [J] () | 1049 | 453 | 1176 | 836 | |
Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license (http://creativecommons.org/licenses/by/4.0/).
Copyright: This open access article is published under a Creative Commons CC BY 4.0 license, which permit the free download, distribution, and reuse, provided that the author and preprint are cited in any reuse.