
Submitted:
03 November 2026
Posted:
06 November 2026
You are already at the latest version
Abstract
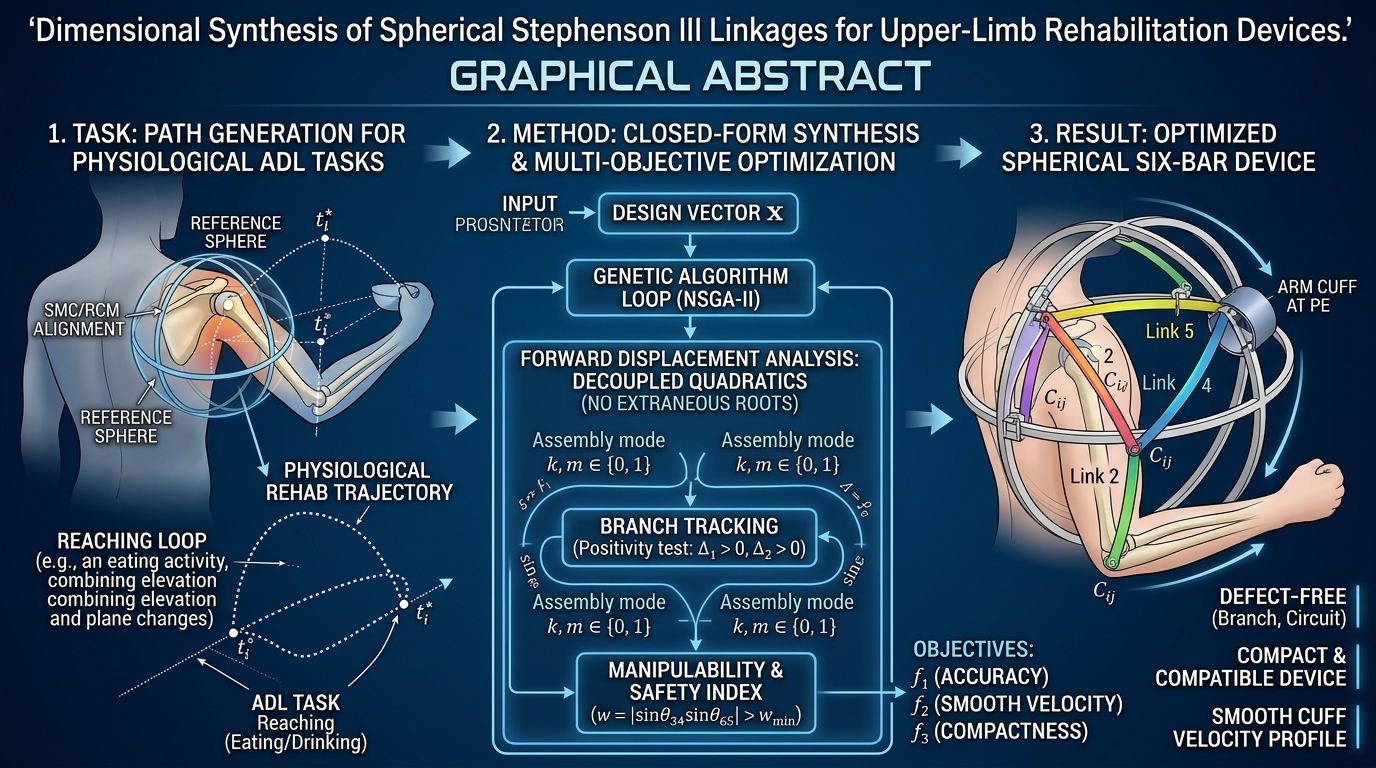
Robot-assisted shoulder rehabilitation benefits from mechanisms that guide the arm along physiological paths about a Remote Center of Motion (RCM) aligned with the shoulder. Single-actuator spherical linkages are an attractive low-cost option, but their dimensional synthesis is hindered by branch, circuit, and order defects. This paper proposes a design-optimization procedure for an actuated spherical Stephenson III linkage used as a single-drive upper-limb rehabilitation device. The displacement problem is decoupled into a base four-bar loop and a closing dyad, solved by two nested quadratic equations that give exactly the four assembly modes in closed form. The two discriminants are shown to coincide with the singularity conditions of the velocity equations, so a single positivity test detects both branch crossing and toggle configurations, while a two-bit label tracks one assembly mode along the workspace. Velocity coefficients, expressed in closed form via triple products, provide a dimensionless manipulability index for discarding candidate designs. The procedure is applied to a reaching task, and yields a defect-free, compact device with smooth velocity profiles and is compared with a previously published optimization-based synthesis of the same mechanism.
Keywords:
upper limb
; rehabilitation device
; remote center of motion
; spherical linkage
; Stephenson III
; dimensional synthesis
Copyright: This open access article is published under a Creative Commons CC BY 4.0 license, which permit the free download, distribution, and reuse, provided that the author and preprint are cited in any reuse.