

Submitted:
03 November 2026
Posted:
04 November 2026
You are already at the latest version
Abstract
Surrogate safety measures (SSMs), such as time-to-collision (TTC) and deceleration rate to avoid a crash (DRAC), are widely used as safety proxies when crash statistics are insufficient. However, SSMs are applied pairwise and have no formal link between the micro- and macro-levels; moreover, fixed thresholds (e.g., TTC = 3 s) lose discriminative power in dense traffic. This paper proposes a two-layer model of conflict metrics. Layer 1 is environment-specific: it contains the movement models and the micro-level metrics that reflect the physics of a given environment. Layer 2 is universal: it defines a three-level system of metrics - the pairwise index \( \psi(P) \), the meso-level share \( \Psi_{\text{frame}}(P) \), and the macro-level share \( C \) - and is independent of the environment. The basic aggregation inequality \( \max_P \Psi_{\text{frame}}(P) \le C \le \sum_P \Psi_{\text{frame}}(P) \) provides a formal micro-macro link and yields two state parameters: the limiting conflict \( M \) and the boundary gap \( \Delta \), with the integral metric \( r=\sqrt{M^2+\Delta^2} \). The control objective for conflict is formulated as \( (M\to 0,\ \Delta\to 0) \), i.e., \( r\to 0 \). The TTC threshold is calibrated per lane on the longest continuous interval with at least three vehicles per frame, using the 5th percentile of the empirical TTC distribution. The model is applied to a real HDV stream from the UTE dataset: calibrated thresholds range from 0.78 s to 11.57 s across the analysed lanes (lane 0 is excluded), and the most conflicting pairs reach \( \psi=0.915 \).
Keywords:
surrogate safety measures
; time-to-collision
; conflict metrics
; micro–macro link
; trajectory data
; road traffic
1. Introduction
A traffic stream is a multi-agent system in which agents compete for a limited environmental resource – a lane, a fairway, a safe gap. Conflict is not a property of an individual vehicle: it is an emergent property of the system, arising from local interactions between agents. In the terminology of multi-agent systems, ensuring safety therefore reduces to managing an emergent property, which requires (a) a formal link between the local rules of the agents (the micro-level) and the macroscopic conflict of the stream (the macro-level), (b) a single control strategy, (c) an account of the dynamic constraints of the agents, and (d) a metric system that is invariant to the type of environment. Requirements (a) and (b) correspond to gaps acknowledged in the literature; (c) and (d) are addressed in this work.
Existing methods analyse conflict separately for each environment and each class of moving objects. This prevents the analysis and control of conflict from being combined into a single system that is invariant to the type of environment within the classes considered (road, water): results obtained for one environment do not transfer to another, and the micro- and macro-levels of conflict are not formally linked. Conflict is usually measured through surrogate safety measures (SSMs), such as time-to-collision (TTC) and deceleration rate to avoid a crash (DRAC) [1,2,3], but SSMs are applied pairwise and fixed thresholds (e.g., TTC = 3 s) do not adapt to the traffic phase and lose discriminative power in dense traffic [1,2].
The problem is therefore not the absence of metrics or methods as such, but the absence of an intermediate link – a diagnosis of the stream structure – that would connect the observed macro-state to specific groups of agents and make the choice of control strategy a consequence of measurement rather than an external decision. This paper provides such a link. Its contributions are threefold. (i) A two-layer model in which Layer 1 is environment-specific (movement models and micro-level metrics defined per environment) and Layer 2 is a universal three-level metric system (, , C) with a basic aggregation inequality that formally links the meso- and macro-levels. (ii) The state parameters M, , and r derived from Layer 2; the pair provides the diagnosis of the stream structure, and r is the integral criterion for choosing a control strategy. (iii) A per-lane TTC threshold calibration procedure based on the 5th percentile of the empirical TTC distribution, applied to a real HDV stream from the UTE dataset.
2. Two-Layer Model
2.1. Layer 1: Environment-Specific Movement Models and Metrics
Layer 1 is environment-specific: both the movement models and the micro-level metrics are defined per environment and reflect its physics. For road traffic, movement is described by car-following models such as the Gipps model [4], and the micro-level conflict is measured by time-to-collision (TTC) and deceleration rate to avoid a crash (DRAC). For other environments, Layer 1 contains the models and metrics appropriate to that environment.
2.1.0.1. Environment invariance of Layer 2.
Layer 1 depends on the environment: both the set of movement models and the values of their parameters, as well as the choice of micro-level metrics, are determined by the physics of the environment. Layer 2, by contrast, is invariant by construction: its metrics (, , C, M, , r) are defined only through the observable quantities and and contain no parameters that depend on the environment. It is precisely this separation that allows the same system of metrics to be applied to different environments: specificity is “hidden” in Layer 1, while Layer 2 remains universal. In this work, Layer 2 is validated on a real road HDV stream.
2.2. Layer 2: Universal Conflict Metrics
Layer 2 is environment-invariant. The state of a leader–follower pair at time t is given by , where s is the gap and is the relative speed (with ). Two boundaries are introduced:
A frame is conflicting if both conditions hold: and.
The pair type P is determined by the nature of the leader and the follower. P can be any classification of a pair that is relevant to the application. For road traffic, examples include or vehicle-class combinations such as or . The specific set of types is environment-specific and application-specific; Layer 2 does not depend on it, and the basic aggregation inequality holds for any finite set of types.
The three levels take the form:
2.2.0.2. Basic aggregation inequality.
The levels are related by
Proof sketch. Let F be the set of frames and, for each frame f, let be the set of pair types in conflict in f. By definition, , where , and . For the lower bound, every conflicting frame contains at least one pair type P, hence ; therefore, . The bound is attained when all conflicting frames belong to a single pair type. For the upper bound, , hence . This bound is loose: the sets may overlap, so the sum can exceed C and can be greater than 1. The inequality is also checked computationally on the UTE sample; see [9] for test cases.
2.2.0.3. State parameters.
From the meso-level metrics, two state parameters are introduced:
where M is the limiting conflict (the contribution of the dominant pair type) and is the boundary gap (structural heterogeneity). The pair forms a two-dimensional coordinate of the meso-level distribution: M measures dominance (how much one pair type prevails), and measures excess (how much the other types add to the sum ). Although is computed from M and S, the two parameters are not equivalent: for a fixed M, an increase in means that conflict is distributed among several types rather than concentrated in one. This is why the pair is more informative than the single number S: it distinguishes “conflict concentrated in one type” () from “conflict distributed among types” (). The pair is precisely the diagnosis of the stream structure: it tells which groups of agents shape the macro-state, and therefore which control action is appropriate. The integral distance to the target state is
The control objective for conflict is , which is equivalent to .
3. Metrics and Calibration
The TTC threshold is calibrated per lane on the longest continuous interval in which every frame contains at least three vehicles; the 5th percentile of the empirical TTC distribution over active pairs within this interval is used as the threshold. This adapts the threshold to the traffic phase and preserves discriminative power at different densities. The DRAC threshold is fixed at m/s2. An active pair is a pair of adjacent vehicles in the same lane (ordered by longitudinal position) with and m. The analysis in Section 4 uses the same interval-based calibration as the analyze_frenet.py script of the conflict-metrics library [9]; the public API compute_conflict_metrics calibrates on the whole lane and is therefore intended for custom subsets rather than for reproducing the per-lane thresholds below.
Table 1 reports the calibrated thresholds for the ten lanes of the UTE sample. Lanes 8–9, in the merging zone, have the lowest thresholds ( s and s); lanes 3–4, in free flow, have the highest ( s and s). Lane 0 has an anomalously high threshold ( s) with a small number of calibration pairs; it is excluded from further analysis (marked by a footnote in the table).
4. Application to Real Traffic (UTE)
4.1. Data and Preprocessing
The real-traffic example uses a sample of the Ubiquitous Traffic Eyes (UTE) dataset [6,7], provided as frenet.csv. The sample contains 1 043 909 rows, 900 vehicles, 19 763 frames, and lanes 0–9; the segment length is 140 m and the time step is s. Pairs are formed per frame and per lane by sorting vehicles by longitudinal position; every adjacent pair with and m is active. The same set of unique pairs as in the library is used; pairs with are filtered out before ranking.
4.2. Most Conflicting Pairs
Table 2 lists the most conflicting pairs. The highest index belongs to pair in lane 9 (), followed by in lane 8 () and in lane 7 (). Pair in lane 1 reaches , but only over 22 frames; its statistics are noisy and it is reported for completeness. Pair in lane 0 has over 77 frames, but belongs to the excluded lane 0 and is reported for reference. Lanes 2–6 show low conflict (–), consistent with their high thresholds.
4.3. Leader Attractors and High- Followers
Table 3 lists five leaders with max , sorted by max . Leaders with but max (e.g., 258, 143, 442, 394) are omitted: they are often approached but not in conflict; leader 417 (, max ) is at the threshold boundary and is also omitted. Leader 492 is the most popular (14 followers) and at the same time the most conflicting (max ), but its mean is only : the conflict is concentrated in a few followers rather than distributed over all 14. Leader 839 has fewer followers (8) but a comparable max . The number of pairs measures popularity, not danger: leaders with but max are often approached but not in conflict, and are omitted from the table.
4.4. Per-Lane Conflict
Table 4 reports over 10-second windows for all ten lanes, ordered by mean. The hot-lane share (median over 10-second windows) is in lane 8; lanes 7 and 9 have zero median but non-zero mean ( and ), reflecting the bursty nature of conflict. Across all lanes the median is 0: for nine of the ten lanes (all except lane 8) the median is zero.
The 10-second window is chosen as a compromise between temporal resolution and statistical stability. Shorter windows (1–5 s) produce many windows without conflicts even on hot lanes, making the median uninformative; longer windows (30–60 s) smooth the bursty pattern that is the object of interest. The 10-second window preserves individual bursts as separate observations while accumulating enough frames (600 at 60 FPS) for a stable estimate of . This choice is consistent with the 10-second conflict window used in trajectory-based conflict identification [8].
Why the median is zero while the mean is positive. For lanes 7 and 9, more than half of the 10-second windows contain no conflicting frames, so the median is zero. The mean is positive because the remaining windows contain bursts of conflicting frames; these bursts are rare (fewer than half of the windows) but intense (many conflicting frames within a window) and pull the mean upward. The standard deviation is correspondingly large because the distribution is bimodal: most windows are zero, a few are substantially above zero. Therefore median and mean are reported side by side: they describe different properties of the same distribution. The median indicates the typical window (without conflict), while the mean and standard deviation quantify the burst regime. A zero median does not mean that the metric is insensitive; it means that conflict on these lanes is concentrated in time rather than uniformly distributed. This is the same bursty character that motivates the 10-second window: a longer window would mix bursts with quiet periods and would obscure the difference between lanes 7–9 and lanes 0–6.
4.5. Correlations
Table 5 reports Spearman correlations between pair features and . Conflict is associated with follower behaviour (high , small gap) rather than leader jitter: mean_dv , mean_gap , , . Leader acceleration variability is weakly correlated (, ).
4.5.0.4. Practical recommendations.
(i) Warn followers for pairs with and (priority: , , , ). (ii) Warn the slow leader 492 () via VMS. (iii) Monitor lane 8 as a hot lane. (iv) Use “slow leader / high- follower” scenarios as test cases for ADAS/V2X.
5. Discussion
5.0.0.5. What the metrics show.
The three-level system (, , C) and the state parameters (M, , r) provide not merely “how many conflicts” but where exactly they are concentrated. On the real UTE data this is visible in three places. First, M and separate the “dominant type” from “structural heterogeneity”: in an HDV-only stream by definition, but in a stream with several pair types indicates that conflict is distributed among several types rather than concentrated in one. The pair thus acts as a diagnosis of the stream structure, linking the macro-state to specific groups of agents. Second, reveals the temporal structure: zero median with positive mean (lanes 7 and 9) means bursty rather than uniform conflict – which is exactly what the 10-second window was designed to reveal (Figure 1b). Third, per-lane TTC calibration explains why M values across different lanes are not directly comparable: a lane with a high threshold may show simply because its threshold is large. This is a limitation of the metric, not of the data, and it is explicitly stated in Section 3.
5.0.0.6. What the correlations show.
Table 5 shows that conflict is associated with follower behaviour (high , small gap) rather than leader jitter: mean_dv , mean_gap , , , with near-zero correlations for and . This is a statistical, not causal, relationship (see limitation (iii)), but it supports the practical recommendations: warn followers rather than leaders; monitor slow leaders; consider “slow leader / high- follower” scenarios as tests for ADAS/V2X (Figure 2).
5.0.0.7. Limitations.
(i) Validation is performed on a single environment (road, HDV-only stream). (ii) The data cover a single segment ( 140 m, merging zone, evening peak, min) and a sample of 900 vehicles. (iii) The observed correlations are not causal. (iv) The 5th percentile is a choice; other percentiles would change . (v) There is no crash-based validation; conflict is a proxy. (vi) The metrics M, , C are aggregate state parameters and geometric coordinates of the meso-level distribution; they are not information-theoretic measures of synergy, and their interpretation is limited to the described state-space geometry. (vii) The model focuses on conflict only; coordination, communication, and role compliance are out of scope. (viii) The extension to other environments is a matter of instantiating Layer 1 with the appropriate movement models and metrics; Layer 2 itself does not change.
5.0.0.8. Open questions.
Long-term effects (conflict accumulation, driver adaptation), the dependence of the TTC threshold on density, and the economic/legal aspects of deployment remain for future work.
6. Conclusion
The paper proposes a two-layer model of conflict metrics with a universal three-level system (, , C), a basic aggregation inequality that formally links the micro- and macro-levels, and the state parameters that provide a diagnosis of the stream structure. The control objective for conflict is formulated as , i.e., . The TTC threshold is calibrated per lane on the longest continuous interval with at least three vehicles per frame, using the 5th percentile of the empirical distribution. Applied to a real HDV stream from the UTE dataset, the model yields thresholds of 0.7811.57s across the analysed lanes (lane 0 excluded), identifies the most conflicting pairs (up to for pairs with ) and leader attractors, and shows that conflict is associated with follower behaviour rather than leader jitter. The metric system is independent of the environment and applies to any trajectory table; the environment-specific part is confined to Layer 1.
Funding
This research received no external funding.
Author Contributions: A. V. Chernyshov
conceptualization, methodology, software, validation, formal analysis, writing – original draft. The author bears sole responsibility for the content of the work.
Institutional Review Board Statement
Not applicable.
Informed Consent Statement
Not applicable.
Data Availability Statement
The UTE dataset is available at SEU Traffic (http://seutraffic.com). The frenet.csv sample used here is not distributed with the repository; it is used only for the analysis example. The conflict-metrics library is available at https://github.com/andreychernyshov5-beep/conflict-metrics.
Acknowledgments
The author thanks the developers of the UTE dataset for making the data available.
Conflicts of Interest
The author declares no competing interests.
Abbreviations
The following abbreviations are used in this manuscript:
| SSM | Surrogate Safety Measure |
| TTC | Time-to-Collision |
| DRAC | Deceleration Rate to Avoid a Crash |
| HDV | Human-Driven Vehicle |
| UTE | Ubiquitous Traffic Eyes |
References
- Gettman, D.; Head, L. Surrogate safety measures from traffic simulation models. Transp. Res. Rec. 2003, 1840, 104–115. [Google Scholar]
- Laureshyn, A.; Svensson, Å.; Hydén, C. Evaluation of traffic safety, based on micro-level behavioural data: Theoretical framework and first implementation. Accid. Anal. Prev. 2010, 42, 1637–1646. [Google Scholar] [CrossRef] [PubMed]
- Zheng, L.; Ismail, K.; Meng, X. Traffic conflict techniques for road safety analysis: Open questions and some insights. Can. J. Civ. Eng. 2014, 41, 633–641. [Google Scholar] [CrossRef]
- Gipps, P.G. A behavioural car-following model for computer simulation. Transp. Res. Part B Methodol. 1981, 15, 105–111. [Google Scholar] [CrossRef]
- Treiber, M.; Hennecke, A.; Helbing, D. Congested traffic states in empirical observations and microscopic simulations. Phys. Rev. E 2000, 62, 1805–1824. [Google Scholar] [CrossRef] [PubMed]
- Feng, R.; Zhu, H.; Sze, N.N.; Wang, S.; Li, Z. Ubiquitous Traffic Eyes: Trajectory dataset focus on multiple traffic states and state transition on urban expressways. Transp. Lett. 2026, 18, 446–462. [Google Scholar] [CrossRef]
- Feng, R.; Li, Z.; Liu, B.; Ding, Y. A joint spatiotemporal prediction and image confirmation model for vehicle trajectory concatenation with low detection rates. IEEE Trans. Intell. Transp. Syst. 2024, 25, 11701–11715. [Google Scholar]
- Wu, D.; Wu, G. Enhancing real-time conflict identification using trajectory data: Exploring the impact of interactions among traffic flow state variables. Traffic Inj. Prev. 2025, 26, 182–190. [Google Scholar] [PubMed]
- Chernyshov, A.V. conflict-metrics: Conflict metrics for traffic streams. GitHub repository, version v1.0. Available online: https://github.com/andreychernyshov5-beep/conflict-metrics (accessed on 1 October 2026).
Figure 1.
Per-lane calibration and conflict share. (a) TTC threshold calibrated as the 5th percentile of the empirical TTC distribution; lanes 8–9 (merging zone) have the lowest thresholds, lanes 3–4 (free flow) the highest. (b) Mean with standard deviation and median: zero median with positive mean on lanes 7 and 9 reflects the bursty nature of conflict.
Figure 1.
Per-lane calibration and conflict share. (a) TTC threshold calibrated as the 5th percentile of the empirical TTC distribution; lanes 8–9 (merging zone) have the lowest thresholds, lanes 3–4 (free flow) the highest. (b) Mean with standard deviation and median: zero median with positive mean on lanes 7 and 9 reflects the bursty nature of conflict.
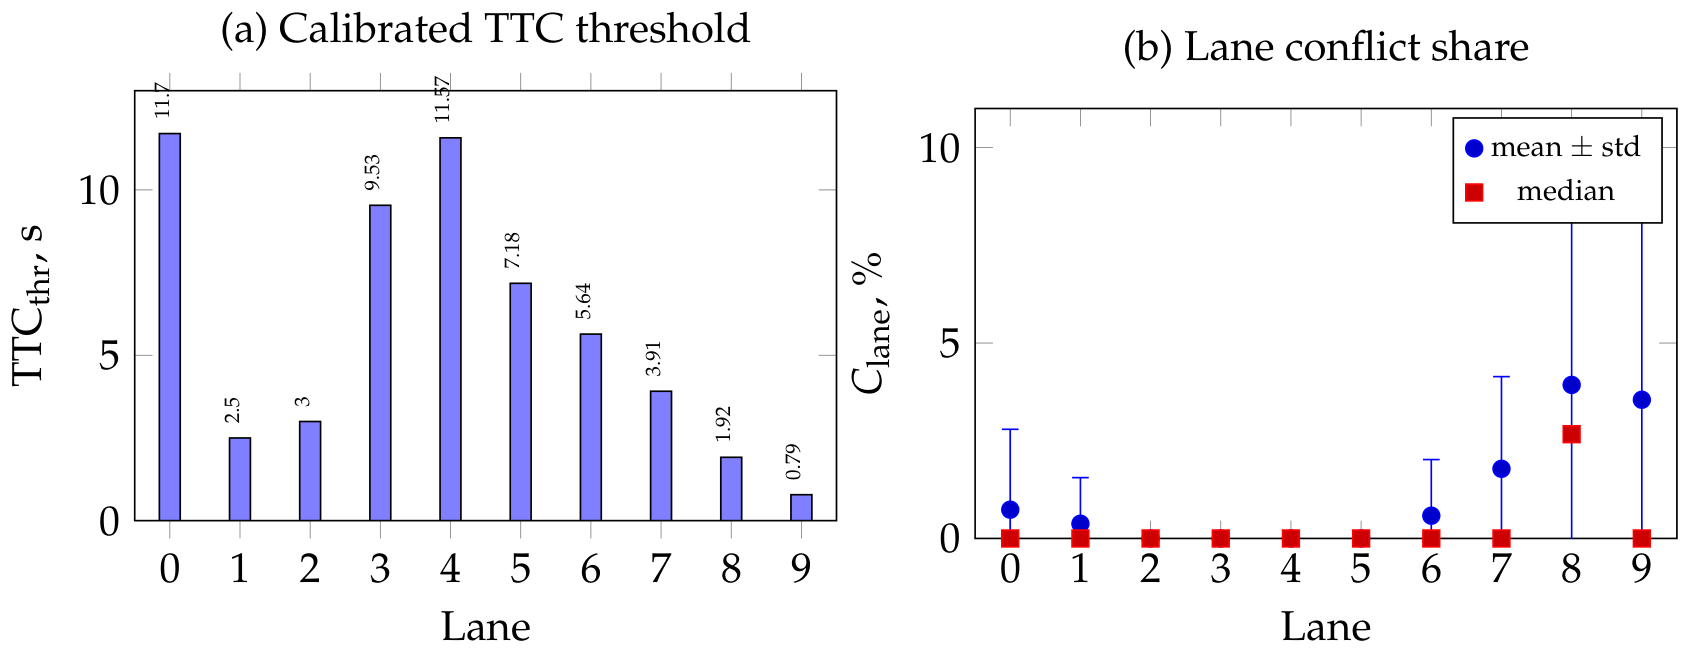
Figure 2.
Top-10 conflicting pairs ranked by . The pair reaches on only 22 frames and is shown for completeness; the pair belongs to the excluded lane 0 and is shown for reference. The remaining pairs concentrate on lanes 7–9 (merging zone), consistent with their low calibrated TTC thresholds (Figure 1a).
Figure 2.
Top-10 conflicting pairs ranked by . The pair reaches on only 22 frames and is shown for completeness; the pair belongs to the excluded lane 0 and is shown for reference. The remaining pairs concentrate on lanes 7–9 (merging zone), consistent with their low calibrated TTC thresholds (Figure 1a).
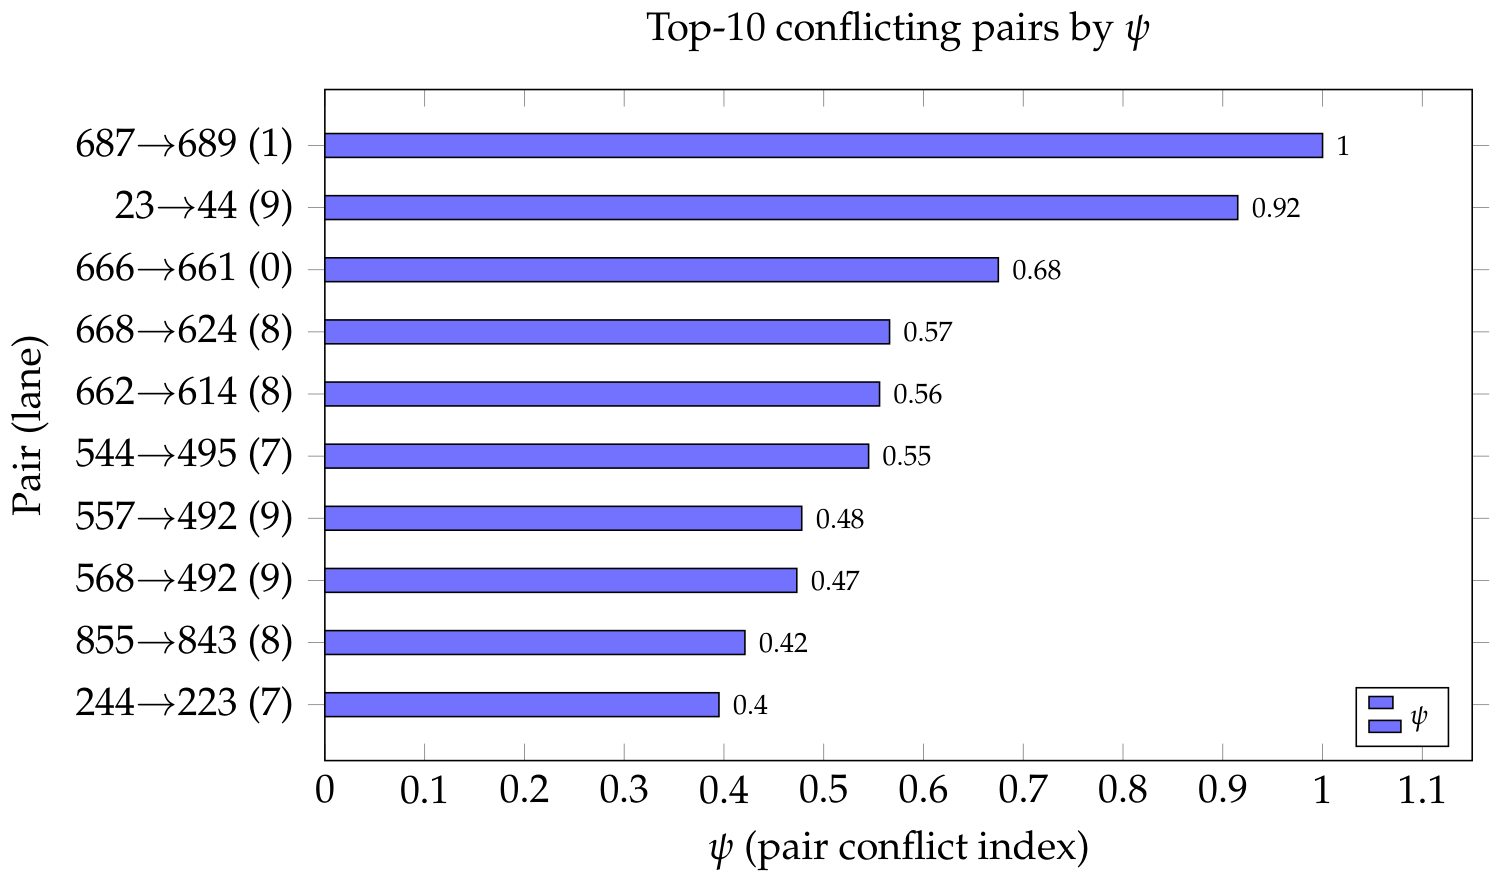

Table 1.
Per-lane TTC calibration for the UTE sample. “Interval, frames” is the length of the longest continuous interval in which every frame contains at least three vehicles; TTC is calibrated on this interval. is the number of calibration pairs.
Table 1.
Per-lane TTC calibration for the UTE sample. “Interval, frames” is the length of the longest continuous interval in which every frame contains at least three vehicles; TTC is calibrated on this interval. is the number of calibration pairs.
| Lane | , s | Interval, frames | |
|---|---|---|---|
| 0 | 11.704 | 5 483 | 1 620 |
| 1 | 2.499 | 12 550 | 3 080 |
| 2 | 2.998 | 16 809 | 3 487 |
| 3 | 9.534 | 17 374 | 5 209 |
| 4 | 11.574 | 6 467 | 1 998 |
| 5 | 7.177 | 154 558 | 19 172 |
| 6 | 5.640 | 172 464 | 19 015 |
| 7 | 3.913 | 184 733 | 18 739 |
| 8 | 1.916 | 28 100 | 5 852 |
| 9 | 0.785 | 12 970 | 2 909 |
1 Lane 0 is excluded from further analysis: anomalously high threshold with a small number of calibration pairs.
Table 2.
Most conflicting pairs (by ). Pair has ; with fewer than 50 frames the estimate is noisy and is reported only for completeness. Pair belongs to the excluded lane 0 and is reported for reference.
Table 2.
Most conflicting pairs (by ). Pair has ; with fewer than 50 frames the estimate is noisy and is reported only for completeness. Pair belongs to the excluded lane 0 and is reported for reference.
| Lane | Pair | , m/s | Gap, m | Frames | |
|---|---|---|---|---|---|
| 1 | 1.000 | 4.95 | 1.18 | 22 | |
| 9 | 0.915 | 10.73 | 4.68 | 47 | |
| 0 | 0.675 | 6.93 | 4.84 | 77 | |
| 8 | 0.566 | 4.59 | 2.57 | 53 | |
| 8 | 0.556 | 6.81 | 8.05 | 54 | |
| 7 | 0.545 | 4.45 | 1.87 | 55 | |
| 9 | 0.478 | 10.57 | 8.45 | 90 | |
| 9 | 0.473 | 7.14 | 5.88 | 91 | |
| 8 | 0.421 | 9.09 | 14.50 | 183 | |
| 7 | 0.395 | 5.27 | 8.43 | 76 |
Table 3.
Leader attractors with max , sorted by max . Leaders with but max (e.g., 258, 143, 442, 394) are omitted: they are often approached but not in conflict; leader 417 (max ) is omitted as borderline. is the mean leader speed converted from m/s to km/h.
Table 3.
Leader attractors with max , sorted by max . Leaders with but max (e.g., 258, 143, 442, 394) are omitted: they are often approached but not in conflict; leader 417 (max ) is omitted as borderline. is the mean leader speed converted from m/s to km/h.
| Leader | Lanes | mean | max | , km/h | |
|---|---|---|---|---|---|
| 492 | 14 | [9] | 0.186 | 0.478 | 5.82 |
| 839 | 8 | [7,8] | 0.048 | 0.380 | 16.02 |
| 224 | 9 | [0,1,2] | 0.030 | 0.273 | 27.11 |
| 575 | 8 | [7,8] | 0.039 | 0.210 | 8.50 |
| 595 | 8 | [7,8] | 0.033 | 0.150 | 7.99 |
Table 4.
Per-lane conflict (10-second windows), ordered by mean. The median is zero for all lanes except lane 8, because more than half of the 10-second windows contain no conflicting frames. Non-zero mean and standard deviation reflect the bursty nature of conflict.
Table 4.
Per-lane conflict (10-second windows), ordered by mean. The median is zero for all lanes except lane 8, because more than half of the 10-second windows contain no conflicting frames. Non-zero mean and standard deviation reflect the bursty nature of conflict.
| Lane | , s | Median, % | Mean ± std, % |
|---|---|---|---|
| 8 | 1.916 | 2.667 | |
| 9 | 0.785 | 0.000 | |
| 7 | 3.913 | 0.000 | |
| 0 | 11.704 | 0.000 | |
| 6 | 5.640 | 0.000 | |
| 1 | 2.499 | 0.000 | |
| 2 | 2.998 | 0.000 | |
| 3 | 9.534 | 0.000 | |
| 4 | 11.574 | 0.000 | |
| 5 | 7.177 | 0.000 |
Table 5.
Mean Spearman correlation with across lanes.
| Feature | Mean |
|---|---|
| mean_dv | |
| mean_gap | |
Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license (http://creativecommons.org/licenses/by/4.0/).
Copyright: This open access article is published under a Creative Commons CC BY 4.0 license, which permit the free download, distribution, and reuse, provided that the author and preprint are cited in any reuse.