

Submitted:
20 September 2026
Posted:
23 September 2026
You are already at the latest version
Abstract
Why does space have three dimensions? We study a recognizer with finitely many independent binary distinctions, one changed by each elementary act. Its states form a cube graph, and a shortest closed run through every state realizes a circle. We require a second recognition trajectory to represent a nonzero integral first-homology class in the complement of that circle. For a closed connected orientable smooth substrate with vanishing first integral homology, this requirement holds exactly in dimension three. The substrate is then an integral homology sphere, and the complementary class is measured by the linking number. We prove the converse for every substrate in this class and show that closedness and ambient first-homology vanishing are sharp hypotheses. A refinement construction supplies an explicit substrate from weighted binary records. The result concerns homological records; identifying this substrate with observed physical space is a further physical claim. The proof uses classical Alexander–Lefschetz duality.
Keywords:
dimensionality of space
; recognition
; Alexander–Lefschetz duality
; thom isomorphism
; hypercube graph
; Hamiltonian cycle
; homology 3-spheres
1. Introduction
1.1. The Argument on One Page
Here is the whole argument in four steps. The rest of the paper makes each step precise and proves it.
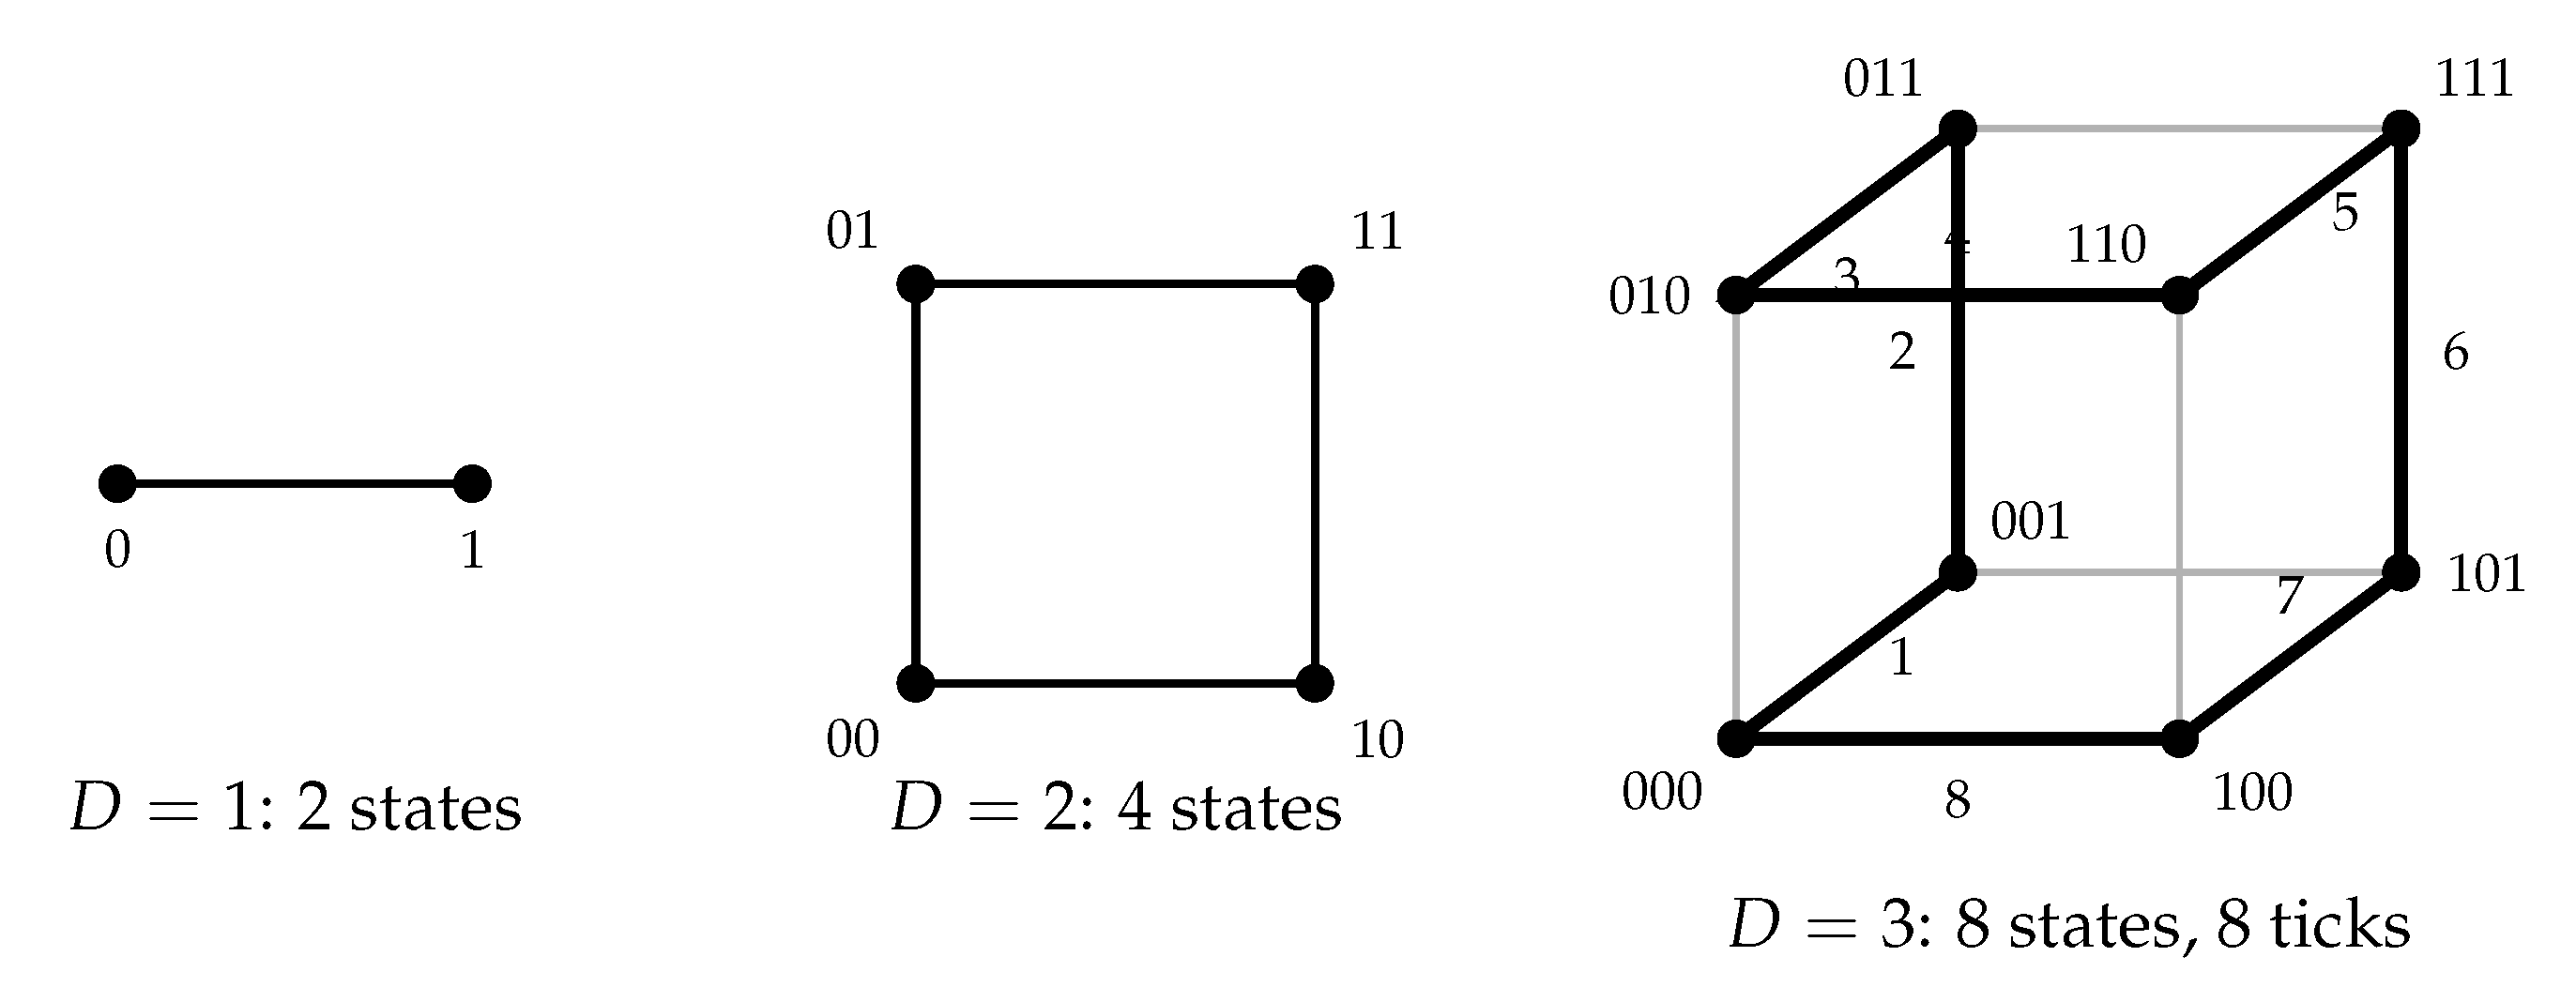
- A recognizer’s states are the corners of a cube. Suppose a system tells configurations apart by D independent yes-or-no distinctions. Then it can be in states, one for each pattern of answers, and a single elementary act changes exactly one answer. Draw the states as points and join two of them when one act separates them: the picture is the D-dimensional cube with its edges (Figure 3). For it is the ordinary cube, eight corners and twelve edges.
- A complete run is a loop. A run that visits every state and returns home is a closed path along the edges of the cube. The shortest such run visits each corner once, so it is a single closed loop with no self-crossing: for , eight steps around the cube (Section 3). Whatever space the cube is drawn in, the path the run sweeps is a circle.
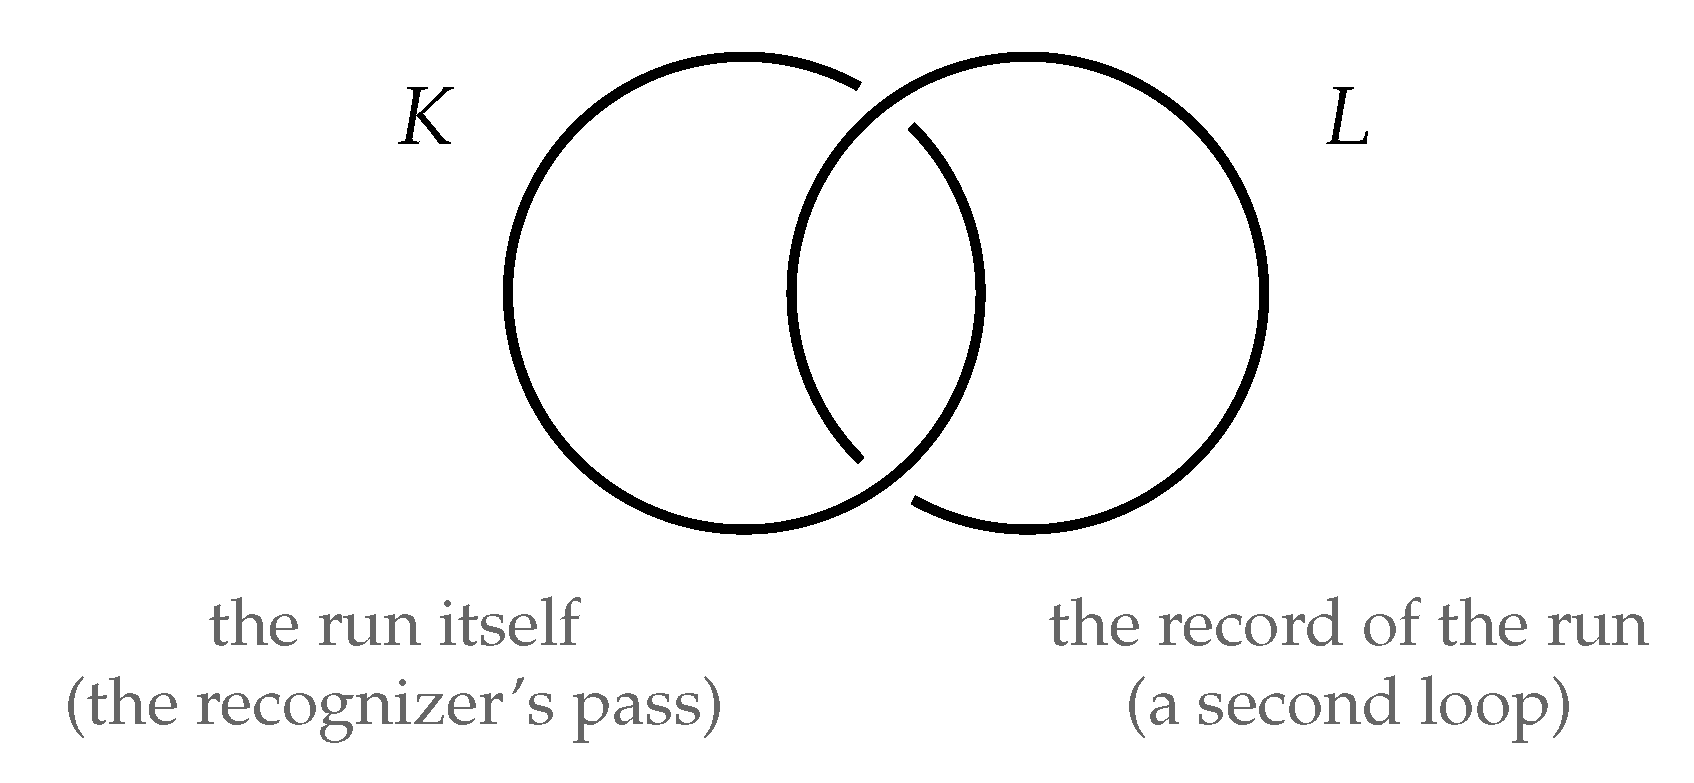
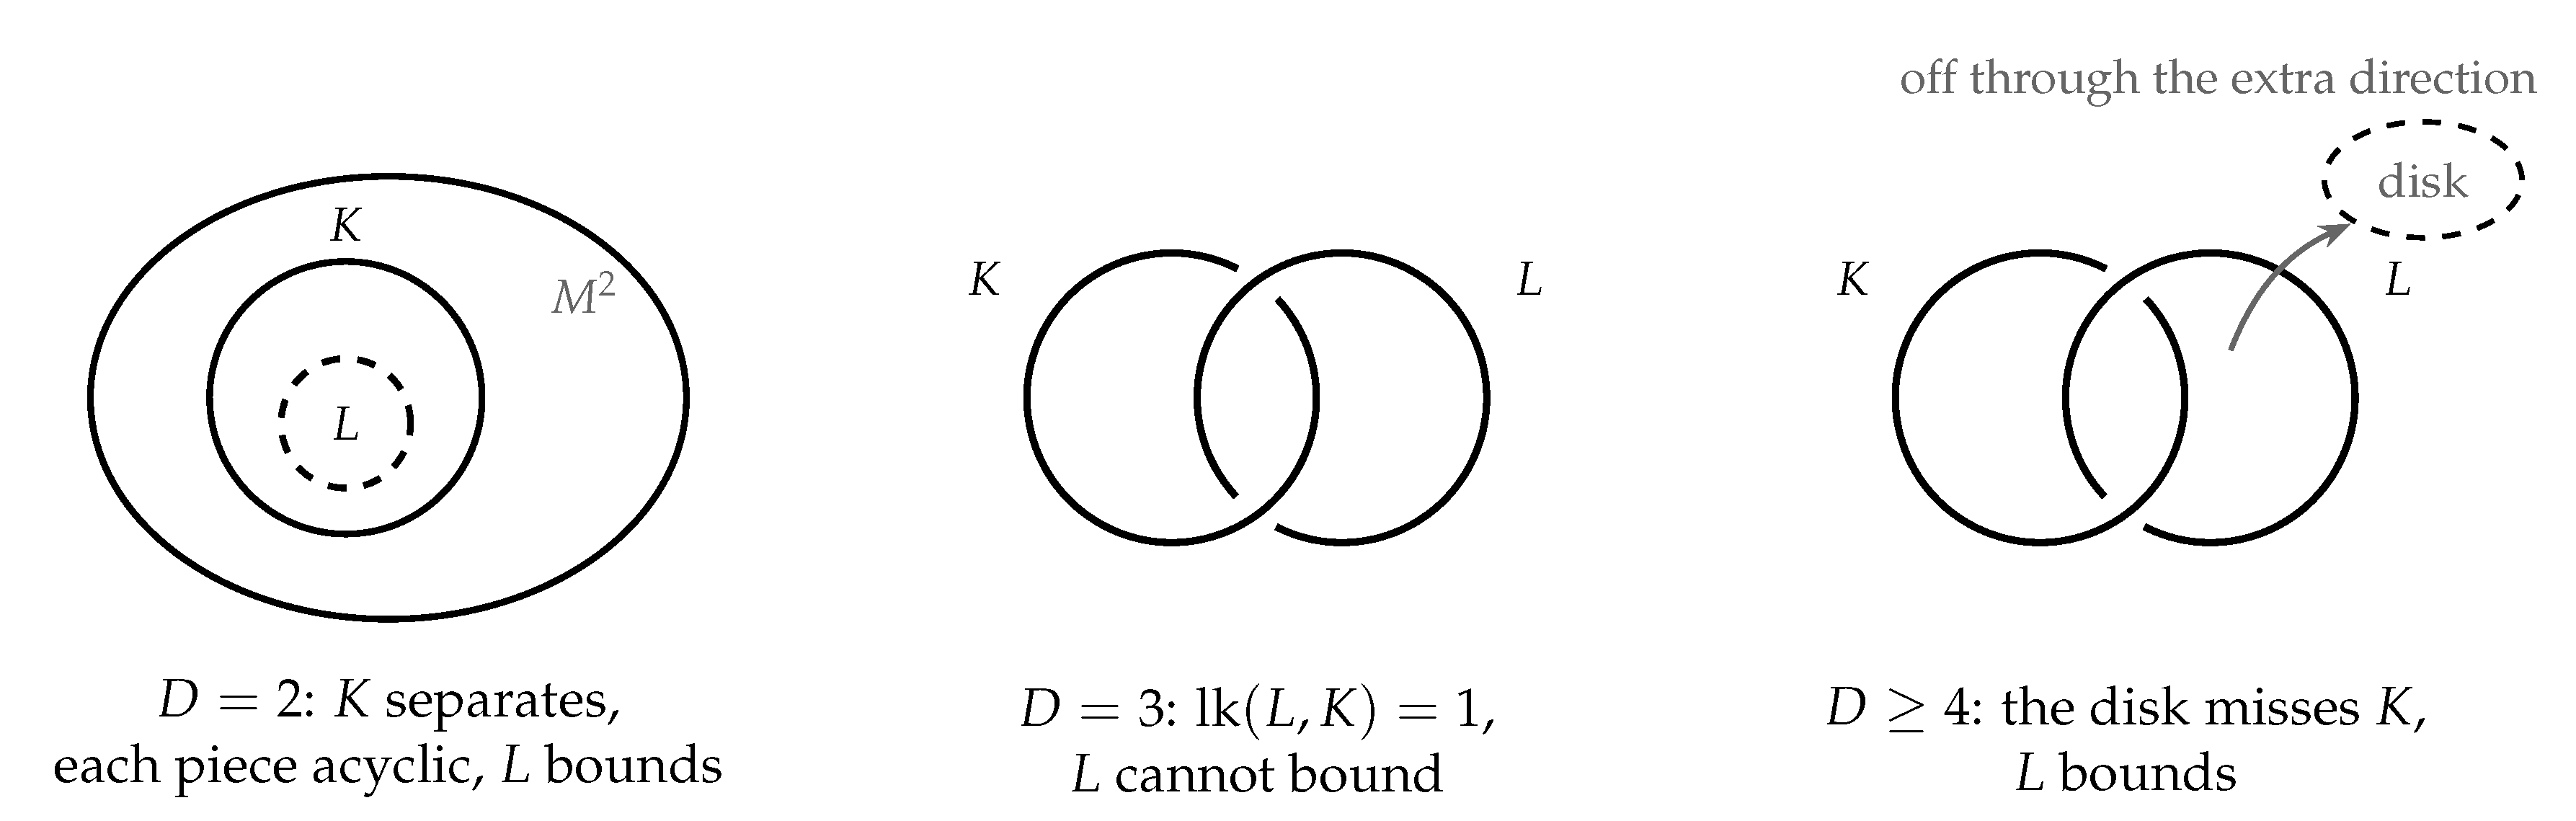
- The requirement: space keeps the completed run. We ask that once the run is complete, the fact that it happened is kept by something the space can hold, namely a second loop locked to the first (Figure 1). Here “locked” means that the second loop has nonzero integral first homology in the complement of the first. This obstructs every isotopy to a loop that bounds there. Homological locking is the record studied here; other obstructions to isotopy need not be detected by it (Section 4).
- Two loops lock only in three dimensions. A loop is one-dimensional; a bounding oriented surface, possibly mapped into the substrate, is two-dimensional. In a space of dimension D, two objects of dimensions a and b placed in general position meet, if at all, in something of dimension . When that number is negative they can always be made disjoint. For a loop and a bounding surface, : in four or more dimensions general position makes the surface miss the loop, so this homological record vanishes; in three they meet in isolated points, and the signed count of those points is what locks the two loops; in two they would meet along a curve, and in fact the first loop cuts the surface in two and the second loop bounds on its own side, so again nothing is locked (Section 5, Figure 8). The only dimension in which the requirement can be met is three (Section 6). This needs the space to be closed and to have no one-dimensional holes of its own; Section 7 shows what goes wrong without either.
The ambient dimension is not prescribed. The value three follows from the dimensions of a loop and a bounding surface , together with the stated substrate and ownership hypotheses. The cube graph and its complete runs do two jobs and no more: they say what kind of object the recognizer’s path is (a circle) and that the record is an object of the same kind. Once that is known, no further feature of the cube enters the dimension argument, and the recognized circle may as well be an unknotted loop in a small ball (Remark 15). Everything else in the paper is the work of checking that these are the right objects and that nothing was slipped in: that the run really is a circle (Section 3), that “space” can be taken to be a manifold at all (Section 2 and Section 2.3), that the requirement has to be read as locking and not as something weaker (Section 4), that the argument reverses (Section 7), and exactly which properties of space the answer depends on (Section 9 and Section 10).
Figure 1.
The requirement, drawn. A recognizer completes a run through all its states; the path it sweeps is the loop K. The fact that the run happened is kept by a second loop L that is locked to K. Being locked means: every surface with boundary L meets K (in the exact form, L is not null-homologous in the complement of K), so no motion of L that avoids K can pull it free. In a closed connected orientable manifold with vanishing first integral homology, such a pair exists exactly in three dimensions (Theorem 5), and the number that records the lock is the linking number.
Figure 1.
The requirement, drawn. A recognizer completes a run through all its states; the path it sweeps is the loop K. The fact that the run happened is kept by a second loop L that is locked to K. Being locked means: every surface with boundary L meets K (in the exact form, L is not null-homologous in the complement of K), so no motion of L that avoids K can pull it free. In a closed connected orientable manifold with vanishing first integral homology, such a pair exists exactly in three dimensions (Theorem 5), and the number that records the lock is the linking number.
Words Used in This Paper
Every technical word coined here is listed in Table 1 with the mathematical object it names and a plain gloss. Ordinary mathematical words (manifold, homology, embedding) are used in their standard senses and recalled where they first matter.
One word in the table does double duty. In the ledger sense a record is the tuple of tallies the accounts present, as in the refinement records of Section 2.3 and the record reading of a vertex (Remark 1); the companion paper fixes this sense for the word. In the requirement sense the record of a run is the probe loop itself and what it keeps, one integer, the linking number. The two senses are identified in the companion paper: the balance of the probe’s account against the recognized circle is the linking number.
1.2. What Is Settled Before This Paper, and What It Adds
The recognizer comes from an account of recognition as double-entry bookkeeping [1]: to recognize is to register a distinction, and each registration is posted as an entry in a ledger of binary accounts. Two facts from that account are used here, both elementary. A recognizer with D independent binary tests has states, and one act moves one test. Nothing else from the bookkeeping is needed, and in particular no cost function and no dynamics.
The word act is used at two levels that must be kept apart. An entry is the elementary act: one posting at one of the recognizer’s binary accounts, which flips one coordinate of its state and traverses one edge of the state graph. A completed act, or completed recognition, is a closed sequence of entries: a pass that returns the recognizer to the state it started from, so that every account has been debited as often as credited and the recognizer’s own books close. The requirement of this paper concerns the completed act. Its two halves are the pass itself, the locus the recognizer sweeps in the substrate, and a loop run elsewhere that registers the pass. The completed act is a recognition only if those two halves remain distinguishable once posted: if the registering loop could always be deformed away from the swept locus, nothing about the act would survive as a distinction. So we require that it cannot: some loop a recognizer can run, in the complement of the locus the recognizer itself traverses, is not null-homologous there.
Both halves of that sentence carry weight. “Not null-homologous” says the act leaves a distinction behind. “A recognizer can run” says the distinction belongs to recognition: a space can carry undeformable loops for reasons that have nothing to do with any recognizer, and a demand met by those, or a demand about a loop no act could execute, would be a fact about the background rather than about the act. The requirement is an adopted premise here. A companion paper [2] shows it is equivalent, over the recognizer’s ledger, to the statement that a completed recognition remains distinguishable from its own reversal by something the space can hold: the primitive tally increments of a closed pass agree with those of its reversal, although both columns grow. Under the additional reading that a registration is a phase account on the complement of a recognized trajectory, a nonzero balance exists exactly when a second loop is homologically linked to the first. This is a statement about the specified aggregate accounts; an ordered posting history can retain the direction of a run. That paper also explains why a pass is a loop and not a surface. Here both are taken as given: the pass is a closed walk, and the requirement is stated in the form the topology consumes.
One identification should be refused at the outset. The two halves of the completed act are two loops, not the two columns of a ledger: a debit and credit posted at one account cancel in the state the ledger presents, and posted at two accounts they move two coordinates at once, the diagonal of a square rather than an edge, so a balanced pair traverses no edge at all. What traverses an edge is a single entry; the ledger’s two columns re-enter in the companion paper, which develops this refusal (a simultaneous debit–credit pair has an even endpoint displacement, so a record observed only at such endpoints meets at most half the states) and puts the columns to work in the cost accounting.
1.3. What Is Proved
Two steps of different kinds carry the conclusion, and neither names the integer on its own.
The first step is about the recognizer. Its state graph is the cube graph , which is one-dimensional, so the path swept by a pass is at most one-dimensional, and the shortest pass sweeps a circle (Propositions 3 and 4). The same fact, applied to the probe, fixes the degree in which the complement is read: a circle carries a fundamental class in degree one and no other. This is the only step at which a feature of the recognizer constrains a dimension, and it uses no algebraic topology.
The second step is classical. A circle tamely embedded in a closed connected orientable smooth D-manifold with vanishing first integral homology has nonvanishing first complement homology if and only if (Theorem 5). Linking of loops is a codimension-two phenomenon. We prove it under 1-acyclicity rather than the usual homology-sphere hypothesis, and again in Appendix A by general position.
Composing them gives the main theorem, and the rest of the paper audits it. In plain clauses:
- The recognized locus is a circle; this is proved, not assumed (Section 3).
- The requirement forces , and the space is an integral homology 3-sphere, and the first homology of the designated complement is ; its homological record is a single integer, the linking number (Theorem 6, Corollary 2).
- The implication reverses: with the structural premises, the requirement is equivalent to (Proposition 13).
- The requirement is a genuine input. The structural premises alone have models in every , and the requirement fails in all of them except at three (Proposition 16).
- Of the properties demanded of the space, exactly two do work: that it is closed (compact, without boundary) and that it has no first homology of its own. Each is sharp. Drop compactness and the plane satisfies the requirement at ; drop boundarylessness and the disk does; drop acyclicity and does at (Proposition 17).
- Most of the space can be built from the recognizer’s data rather than posited. Measuring the distance between two records by the number of acts between them, and asking that a finer record never move a coarser one, forces the metric up to units; the completion is a solid D-cube of dimension exactly D, with no one-dimensional holes, and the embedding of the cube graph in it is tame by construction (Proposition 1, Proposition 2). Two things the construction does not supply: that each distinction refines along a line rather than, say, a tree, which is a clause of the definition of a record; and closedness, which is imposed by discarding the cube’s boundary and adding one point at infinity. The result is , and the closing is a separate step the space premise still asks for.
- Of five parameters one might vary, only two move the answer: the dimension p of the swept locus (giving ) and the degree q in which the record is read (giving ); and the requirement’s own wording forces . The coefficient ring, the choice of invariant, and the regularity of the locus leave three unchanged (Theorems 8 and 9).
- The requirement must be read homologically. “The record cannot be shrunk to a point” is weaker and selects no dimension (Proposition 6).
- Downstream: a complete pass at takes exactly eight steps, and a run of eight has none to spare, so it flips one distinction per step (Section 11).
The classical inputs, Poincaré and Alexander–Lefschetz duality, transversality, and the tubular neighbourhood theorem, enter as named theorems rather than as steps proved here.
1.4. Scope
What is proved is a statement about the manifold in which a recognizer’s state graph is realized: that manifold has dimension three and is an integral homology 3-sphere. Reading it as the space one observes is an identification the mathematics does not supply, and the opening question is answered here only to the extent that a recognizer’s substrate is that space. Nothing below depends on the identification, and no argument is offered for it.
The chain constrains the dimension of the substrate directly: every argument goes through with in place of D and concludes . The clause that identifies the substrate dimension with the number of primitives, one spatial direction per independent distinction, is what carries the conclusion across to the primitive count (Remark 4); under a different alignment the same proofs give . On the stage constructed in Section 2.3 the alignment is a theorem.
No premise beyond the structural layer and the requirement enters the main theorem. Section 10.1 lists every premise together with what would refute it. The companion paper adds two premises of its own, a single-valued record and least cost, and uses them only to select among the shapes a pass could have.
How to Read This Paper
A reader who wants the theorem and its proof needs Section 2, Section 3, Section 4, Section 5 and Section 6, about a third of the paper. Section 2.3 shows the space can be built rather than assumed and can be skipped on a first pass. Section 7 to Section 10 answer the questions a careful reader will have asked by then: is the requirement satisfiable, is it independent, which of its clauses carry the integer, and what would change if a clause were worded differently. Section 12 places the argument beside the older ones for three dimensions.
2. The Recognition Data and the Substrate
Two kinds of data enter: the combinatorial structure through which a recognizer distinguishes configurations, which is where D comes from, and the topological substrate in which that structure is realized, which is where a dimension can be spoken of at all. Nothing here constrains the dimension, and that is the point: these axioms have models in every .
Start with the smallest cases (Figure 3). A system with one yes-or-no test has two states, and one act carries it from one to the other: two points joined by a segment. A system with two independent tests has four states, and since one act changes one answer, the state 00 is adjacent to 01 and 10 but not to 11: the four states and four moves form a square. Three tests give eight states and twelve moves, the corners and edges of a cube. The pattern continues: D tests give the D-dimensional cube graph , whose vertices are the answer patterns and whose edges join patterns differing in one answer. This section says exactly what is assumed about the system for this picture to be the right one, and then what is assumed about the space the picture is drawn in.
2.1. Binary Recognizer Factorization
A recognizer is binary if its event space has two elements, distinguish or do not distinguish; formally a map on a configuration set C. Composing D of them gives , , and the recognition quotient, where iff .
Definition 1
(Jointly independent binary primitives). A family isjointly independentif the product map is surjective.
Joint independence is strictly stronger than nontriviality of each : two recognizers assigning identical bits to every configuration have image and produce a quotient of size 2 rather than 4. Surjectivity gives .
Axiom 1
(Binary factorization; the cube premise). A composite recognizer admits D jointly independent binary primitives. Its recognition quotient is in bijection with , and itsrecognition cycleis a minimal-length closed walk in the Boolean cube graph visiting every state at least once. Here has vertex set and an edge between vertices differing in exactly one coordinate.
In plain terms. The premise says three things. The system’s states are the answer patterns, so there are of them. A single act changes one answer, so the moves are the edges of the cube. And a completed recognition is a run that visits every state and comes home in as few moves as possible.
Remark 1
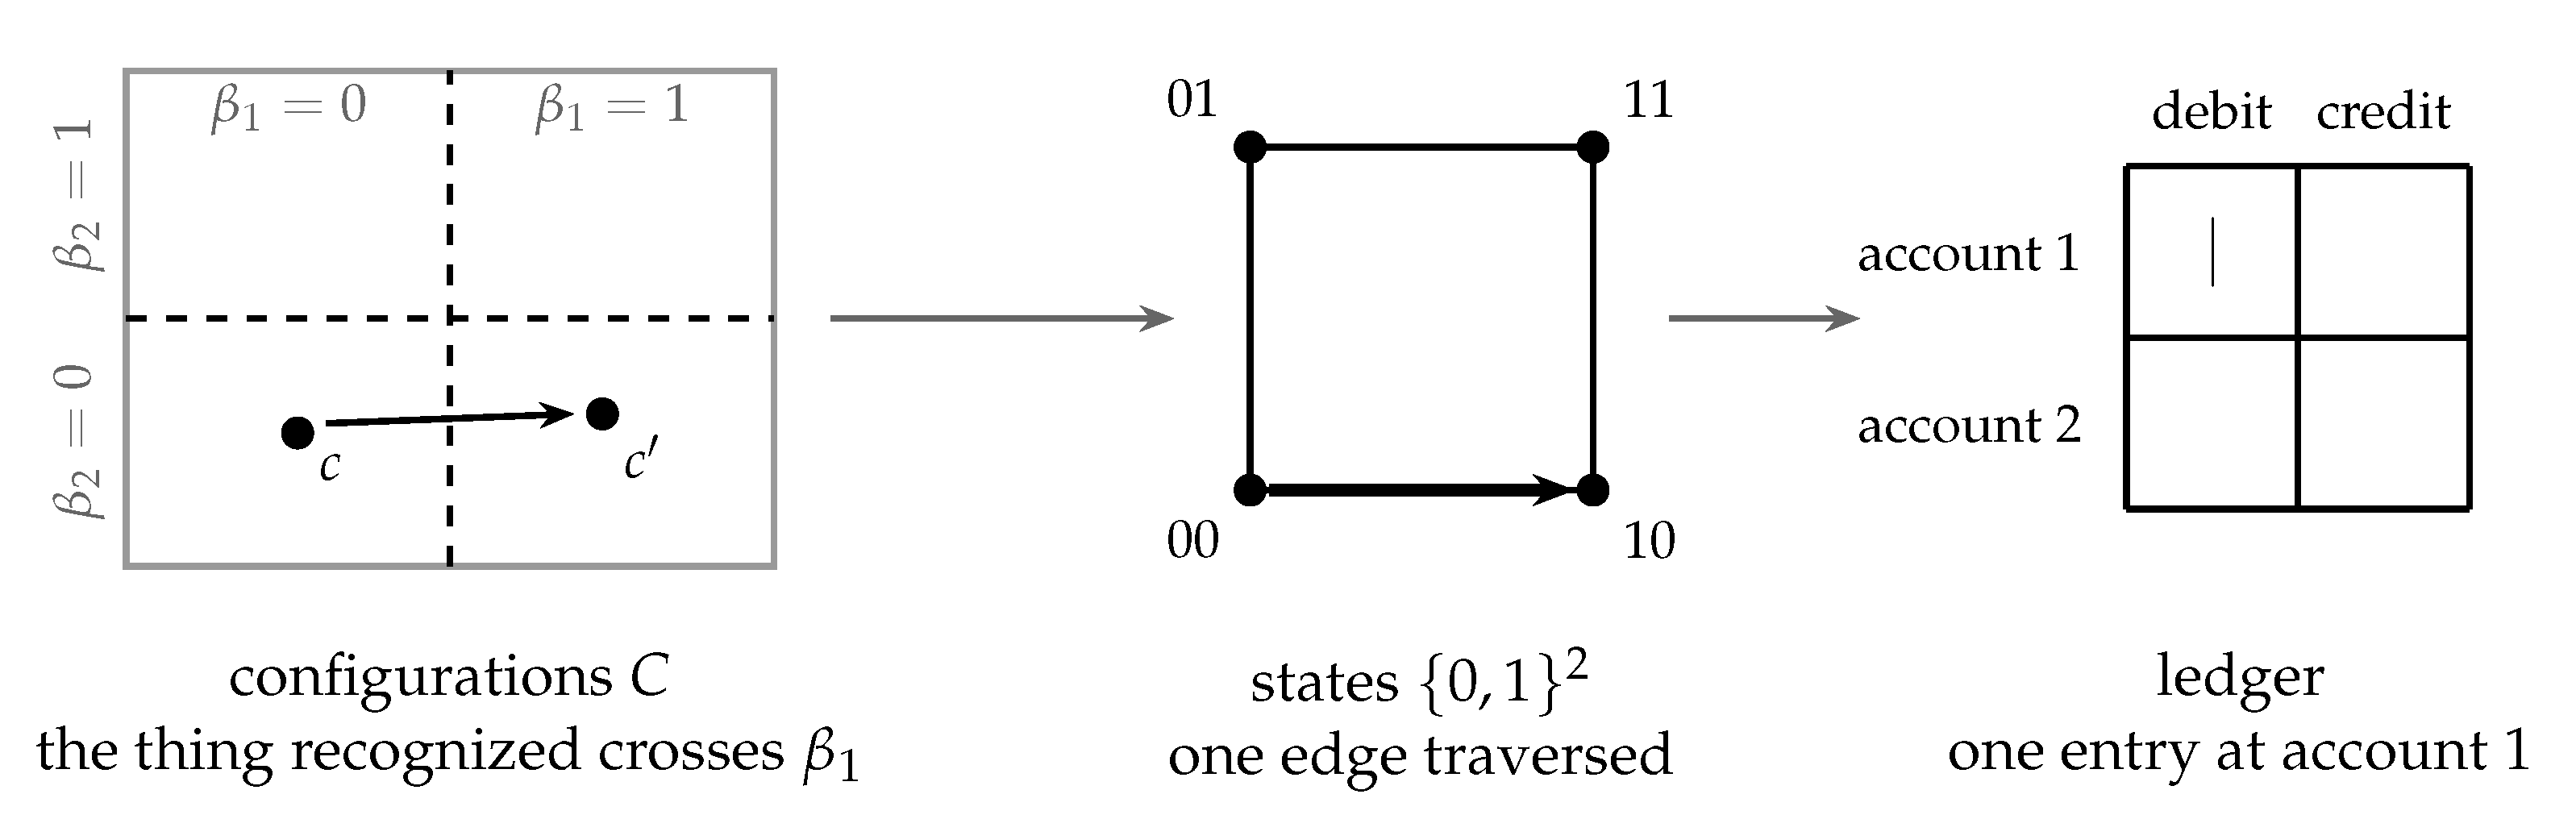
(What a vertex is, and what an edge asserts). A vertex of can be read in two ways, and the two must be tied together by a definition rather than by the coincidence that both are elements of . On thequotientreading a vertex is a class of the recognition quotient , and an edge means that the configuration under recognition has crossed exactly one primitive . On therecordreading a vertex is the state the recognizer’s own books present, the parity of debits against credits at each of its D accounts, and an edge means that the recognizer has posted one entry at one account; nothing in C is mentioned. The tie is the definition of an entry:an entry is posted at account i exactly when the configuration under recognition crosses .A recognizer that posts on this rule is said totrackits configuration. Under tracking, starting from a record whose parities are , an induction on the entries shows that the state the record presents after any history is for the configuration c currently under recognition, so the two readings of a vertex name one object, and the two readings of an edge are one statement: the class moved in primitive i if and only if the recognizer posted at account i. The primitive crossed by a one-step move is unique, so the entry is determined by the move and a move that crosses no primitive posts nothing. What is being recognized when the recognizer steps to an adjacent vertex is therefore the crossing of one binary distinction by the thing under recognition, and the record is its running account of which side of each distinction that thing is on.
Figure 2.
One move, read three ways. Left: the configuration under recognition crosses the first threshold . Middle: the recognizer’s state moves along one edge of the cube graph, from 00 to 10. Right: the recognizer posts one entry at account 1. The definition of an entry ties the three together: an entry is posted at account i exactly when the configuration crosses , so the state the books present is always the pattern of answers for the configuration currently under recognition (Remark 1).
Figure 2.
One move, read three ways. Left: the configuration under recognition crosses the first threshold . Middle: the recognizer’s state moves along one edge of the cube graph, from 00 to 10. Right: the recognizer posts one entry at account 1. The definition of an entry ties the three together: an entry is posted at account i exactly when the configuration crosses , so the state the books present is always the pattern of answers for the configuration currently under recognition (Remark 1).
Remark 2
(The complete pass is a premise). The clause of Axiom 1 that the recognition cycle visits every state is a premise about which closed histories count as completed recognitions, and it is not forced by the rest of the axiom. Tracking says what an entry records; it says nothing about why the configuration under recognition moves, or why its motion should ever meet every class. Closed histories that balance every account without visiting every state exist at every : at a six-step closed walk around a face-and-back, or any closed walk confined to a proper subcube, balances its books and leaves two or more classes unvisited. Everything below that uses the cardinality of the pass, in particular the length of Lemma 3 and its consequence that a complete pass at takes eight steps, rests on this clause. What Lemma 3 proves is that a closed walk which does visit every state has length at least with the bound attained; it does not prove that a recognition must be such a walk. The linking argument of Section 5 and Section 6 uses the recognized locus only as an embedded circle, which the complete pass supplies through Proposition 4; any closed walk that revisits no vertex before its return sweeps such a circle, so the dimension theorem is insensitive to the length of the pass, while the cadence of eight (Section 11) is not. The companion process paper [2] replaces this clause with a definition: a recognition is completed when the scale above can read its history as one unit, an address after one halving, and the positions sharing an address are exactly one full set of states. Under that definition the full pass is a theorem and a closed walk on one proper face, balanced as it is, completes nothing. What the definition still leaves open is why the configuration moves at all; that remains the process postulate.
Remark 3
(Which recognition is meant). The wordrecognitionis used throughout in the operational sense of the cost-first discrete-ledger framework of [1]: to recognize is to distinguish by ratio-based comparison of positive quantities, and the events of recognition are recorded in a minimal ledger as atomic postings. The cost of such a comparison is fixed in that framework and is used by the companion paper; nothing in the present paper depends on its form. The present paper takes one demand from that framework: the two sides of a completed act must remain distinguishable once posted (Axiom 4). The companion paper [2] develops the bookkeeping itself, the ledger, the single-valued record, and the cost of a pass, and shows that, once a record of a completed act is read as an account kept against the act’s path, the axiom is equivalent to the demand that the act remain distinguishable from its own reversal; the double-entry bookkeeping of [1] is adapted there to binary tallies, an edge being traversed by a single posting rather than a balanced pair. No other sense of recognition (statistical classification, pattern matching, perceptual identification) is used anywhere below: a recognizer is exactly a device that registers distinctions in a record, and the recognition quotient and recognition cycle above are its combinatorial shadow.
A closed walk with and its geometric realization, the map carrying affinely onto the closed 1-cell of the edge , are denoted by the same letter throughout; which is meant is fixed by the context.
Figure 3.
The state graphs for . A composite recognizer with D jointly independent binary primitives has recognition quotient (Axiom 1), and a complete pass is a closed walk of minimal length visiting every state, which is (Lemma 3). At the pass shown is a Gray cycle: eight steps, one primitive flipped per step, home at the eighth. Its swept locus is the recognized circle of Proposition 4.
Figure 3.
The state graphs for . A composite recognizer with D jointly independent binary primitives has recognition quotient (Axiom 1), and a complete pass is a closed walk of minimal length visiting every state, which is (Lemma 3). At the pass shown is a Gray cycle: eight steps, one primitive flipped per step, home at the eighth. Its swept locus is the recognized circle of Proposition 4.
2.2. The Substrate
The recognition quotient is a finite discrete set, naturally the 0-skeleton of . A nonempty finite discrete set has covering dimension zero; this does not determine the dimension of an ambient space. To ask how many dimensions the recognizer’s space has, the cube graph must be drawn inside a space, and that space must be regular enough for “dimension” to mean one thing. A dimension argument therefore needs an ambient manifold, so the passage to a topological object is an explicit assumption, separated into two clauses with distinct jobs. The assumption is partly discharged for one stage and retained for the rest: Section 2.3 constructs, from the refinement data alone, a stage on which the dimension, the tameness and the absence of holes are theorems, while closedness is imposed by one explicit closing step; the axioms name the general class in which the sharpness questions of Section 9.2 are posed.
Definition 2
(Cellular completion of ). Acellular completion of in dimension Dis a pair consisting of a closed connected orientable smooth D-manifold together with a topological embedding realizing the geometric realization of as atame 1-dimensional subcomplex: the restriction of ι to each closed 1-cell is a smooth regular embedding, and each vertex v admits atopologicalchart, a homeomorphism φ of an open neighbourhood onto an open subset of with , carrying onto a union of radial segments issuing from the origin in pairwise distinct directions.
Tameness excludes wild embeddings by requiring the image to be locally cone-like. It is deliberately not phrased as local flatness of manifold pairs, and cannot be: at a vertex of degree at least three, which is every vertex once , the space is not a manifold, so no neighbourhood is homeomorphic to a linear pair. The chart is topological by necessity rather than by generosity. Two smooth edges meeting with opposite tangents form a curve that is but in general not at the vertex, and the preimage of a straight line under a diffeomorphism is smooth, so no smooth chart radializes every vertex the axiom must admit. A topological chart always exists when the incident edges leave in pairwise distinct tangent directions (Lemma 7), and it can be taken smooth away from the vertex itself. Local flatness is used below only for embedded spheres, where the source is a manifold and the notion is standard [3]; all sphere embeddings occurring below are smooth, so it is automatic.
Axiom 2
(Completion and alignment; the space premise). There exists a cellular completion of in dimension D, where D is the binary-primitive count of Axiom 1. We call therecognition substrateand ι thecube-graph embedding.
Axiom 3
(No holes: integral 1-acyclicity). The recognition substrate satisfies .
In plain terms. The space premise says: there is a space, it is finite in extent and has no edge (closed), it has a consistent notion of inside and outside for small spheres (orientable), it is smooth, its dimension equals the number of yes-or-no tests, and the cube graph sits inside it without pathology (tame: near each corner the edges look like straight segments leaving in different directions). The no-holes premise says: every closed loop in the space, on its own, bounds. The space has no first homology of its own, so if a loop in it later fails to bound, that failure was caused by something placed in the space, not by the space. Neither premise mentions the number three, and both are satisfied by spaces of every dimension from two upward, for example by every sphere with .
Remark 4
(The alignment is a stipulation). Two a priori unrelated integers are called D: the number of binary primitives and the topological dimension of the substrate. Axiom 2 identifies them. On the constructed stage the identification is a theorem with its premises in view: with separation measured by acts and refinement changing no separation, the metric on the records is forced up to units (Lemma 1), and the completion it determines has covering and Hausdorff dimension exactly D, one dimension per independent primitive because an act moves one primitive at a time, the dimension being the primitive count rather than the state count, 3 against 8 at (Proposition 1). Uniqueness of completion alone would not carry this: completions are unique for a uniformity already fixed, and it is the act structure that fixes it. The premise that does the work sits in Definition 3: each primitive refines along a line of dyadic tallies , so that one distinction contributes one real coordinate. Had a distinction refined along a binary tree instead, the completion would be a Cantor set of dimension zero, and no alignment would follow. The linear-tally clause is therefore the alignment stated at the level of records, and the proposition shows that it yields dimension D rather than . For a substrate given without the construction the identification is the dimensional-alignment hypothesis of the framework. The clause is load-bearing in an unusual way, entering no homological or geometric step and being instead what makes the conclusion a statement about the recognizer at all. Under an alignment every lemma below holds verbatim with in place of D, concluding and hence ; the main theorem is therefore stated in two steps.
Remark 5
(Why there is no retraction clause). A retraction with , expressing that the substrate carries no information beyond the state space, is inconsistent with Axiom 3: it makes a split injection, so 1-acyclicity would force , whereas is a connected graph with vertices and edges, so with , vanishing only at , itself excluded by Axiom 3. The pair would be unsatisfiable in every dimension, and Definition 2 retains only the embedding.
Remark 6
(1-acyclicity is the load-bearing clause). Wording the substrate axiom as “ is an integral homology D-sphere” packages four clauses: closedness, orientability, integral 1-acyclicity, and acyclicity in degrees . The first two come from Axiom 2, the third is what Theorem 5 consumes, and the fourth is used nowhere. Axiom 3 keeps the third and discards the fourth, so the admissible class is larger than the homology D-spheres, containing for , products with , and every closed simply-connected orientable smooth D-manifold. At the weakening is vacuous by Lemma 5, so the admissible substrates are exactly the integral homology 3-spheres; what it enlarges is the field of boundary-case substrates in dimensions against which the selection of 3 must hold up. The clause earns its place: by Proposition 17 it is what makes the requirement a statement about the recognized locus rather than about the ambient topology.
In dimension 1 there are no models, the only closed connected 1-manifold being with ; this is the source of the standing hypothesis . In every models are plentiful, and Section 7.1 constructs them where the converse needs them.
2.3. The Stage the Data Constructs
The finite records and the completed stage should be distinguished. Every record at a fixed refinement level is finite, and the union over levels is countable. The continuum enters through metric completion under the stated linear-refinement and separation premises. Completion points need not be finite posted records; uniqueness here is uniqueness of the completion of that specified metric system.
The axioms name what the argument needs; this subsection derives a stage from the stated refinement and separation premises and then imposes closedness by an explicit compactification. The idea is simple. A recognizer at one resolution has states, two tally values per primitive. A finer recognizer, one that has halved each of its thresholds, has three tally values per primitive and so records, the coarse states among them as the extreme values; halving again gives five values and records, and after n halvings (Figure 4). Each refinement keeps every record already posted and adds new ones between them. If the distance between two records is measured by how many acts it takes to get from one to the other, and if refining never moves a record already posted, then the tower of ever finer records has a limit, and that limit is a continuous solid cube of dimension D. The space is not chosen: it is what the recognizer’s own records fill in. The construction is the refinement limit: between any two records a recognizer can post a finer one, and the continuum is what the tower of refinements converges to. One trap must be named first, because falling into it would cost the subsection its point. If the records were placed in a metric cube by fiat, the uniqueness of metric completion would hold of the uniform structure so chosen, and the alignment of dimension with primitive count would have been smuggled in with the placement rather than derived. So the records are kept abstract, the only structure taken from recognition being which records a single act converts into which, and the separation of two records is measured by the acts between them. Lemma 1 shows this forces the metric up to a choice of D units, and the cube then appears as the completion the acts determine rather than as a container chosen in advance.
Definition 3
(Refinement records, acts, and sites). Fix . Alevel-n recordassigns to each of the D primitives a tally ; thevalueof the tally is , tally over resolution. Level 0 is the state space, its records being the vertices of . Onerefinement stepreads every level-n record as the level- record of doubled tallies , doubling the resolution, changing no value, and moving no existing record; thesitesof the ledger are the records of all levels under this identification, a countable set carrying no geometry yet. Alevel-n actconverts a level-n record into one differing in exactly one primitive by exactly one tally. That acts move one primitive at a time is the joint independence of Axiom 1 read at finite resolution, and the level-0 acts are exactly the edges of .
Two readings connect the acts to a geometry, and they are the only premises of the construction. First, the separation of two sites is what the ledger can measure between them: the least total displacement of a chain of acts converting one into the other, each act carrying a positive weight, its displacement. A weight depends on the act’s level and its primitive and on nothing else. This is a premise, not a symmetry: a chain of tallies has ends and a middle, and nothing forbids a ledger from pricing the first tally step differently from the fifth. What the premise says is that the ledger prices an act by what it does, move one tally at one primitive at one resolution, and not by where on the tally line it does it. Second, refinement moves no record in the quantitative sense: a level-n act and the two-act chain that is the same move read one level finer are the same displacement, so re-reading a pair of records at a finer level changes no separation. Neither premise mentions a cube, a norm, or a dimension.
Lemma 1
(The separation metric is forced up to units). Under the two premises above:
- (i)
- the weight of a level-n act at primitive i is for constants , theunits;
- (ii)
- the separation of two sites x and y iswhere is the value of the ith tally;
- (iii)
- any two choices of units yield uniformly equivalent metrics, and each is uniformly equivalent to the sup metric on values. The separation structure of the sites is therefore determined by the act structure up to the units, and by nothing else.
Proof. (i) Write for the common weight of the level-n acts at primitive i. The act between tallies j and at level n joins the same two records as the chain read at level , so the second premise gives , and induction gives with .
(ii) A level-m act at primitive i changes the value by exactly , changes no other value, and carries weight , so along any chain of acts the total weight is at least , coordinatewise by the triangle inequality. Conversely, read both sites at a common level N and move one primitive at a time monotonically: primitive i takes acts of weight , totalling . The lower bound is attained, so the infimum is the sum.
(iii) Two choices of units give metrics differing by factors between and , and on values, so all these metrics are bi-Lipschitz equivalent, hence uniformly equivalent, with one completion up to uniform isomorphism. □
The lemma is where the definition’s abstinence pays. The cube below is not a stage the records were placed on but the completion their acts force, and the only choices left, the units, are consumed by no later clause: the dimension, the acyclicity, and the compactification of Proposition 1 are unchanged under the bi-Lipschitz equivalences just proved. We take , the isometric normal form.
Proposition 1
(The stage is determined by its records). Fix , give the sites of Definition 3 the separation metric of Lemma 1 at units , and write for the solid cube. The value map carries the sites bijectively onto the dyadic points of A, isometrically for the metric and uniformly for the sup metric.
- (i)
- (Existence and uniqueness.)The sites are dense in the compact A, so A is a completion of the site family; any two completions of one uniform space are uniformly isomorphic, and by Lemma 1 the uniformity itself is determined by the act structure, so the countable record data determines the continuum stage with nothing left to choose beyond the units, which nothing below consumes. The dyadic scheme is immaterial: any dense refinement family has the same completion.
- (ii)
- (Alignment.)The covering dimension of A is exactly D, and so is its Hausdorff dimension for the metric the acts force: the stage carries one dimension per independent primitive because an act moves one primitive at a time, and the dimension is the primitive count, not the state count, 3 against at .
- (iii)
- (1-acyclicity.)A is convex, hence contractible, so : every cycle posted on the stage bounds. The property is not idle, the circle carrying a nonbounding cycle, .
- (iv)
- (The closed substrate.)The interior of A is homeomorphic to , whose one-point compactification is . The sphere on which Proposition 9 realizes the cube-graph embedding is therefore the compactified stage, and the embedding may be taken to place on records of the stage itself, the corners of the interior dyadic subcube .
Proof. (i) Given and , choose n with and take the level-n record with value at the ith primitive; it lies within of x in every coordinate. The cube is compact, hence complete, and a dense uniform inclusion into a complete space is a completion of the induced uniformity, which by Lemma 1 is the separation uniformity; any two completions of one uniform space are uniformly isomorphic by the universal property ([4]). Only density of the sites was used, so the last clause follows for any dense family.
(ii) The covering dimension of the D-cube is D, an integer by definition ([5]). For the metric notion: A has nonempty interior in , and Hausdorff dimension is monotone and equals D on nonempty open subsets of ([6]), so ; since the act metric is bi-Lipschitz to the Euclidean one (Lemma 1), this is the Euclidean fact carried over, and it says only that the completion is a genuine D-dimensional body rather than a thinner set such as a Cantor set or a curve. The forcing chain itself consumes only the manifold dimension of the substrate, an integer by definition. Finally for every .
(iii) Convexity gives a straight-line contraction, and a contractible space has vanishing reduced homology ([7]); is standard.
(iv) Coordinatewise, is homeomorphic to , carrying the open cube onto , and the one-point compactification of is by stereographic projection. Choosing the coordinatewise homeomorphism to carry onto , the embedding of Proposition 9 pulls back to the 1-skeleton of , whose vertices are level-2 records and whose edges run along sites of every finer level. □
Proposition 1(iv) put the cube graph on the stage, and a placement is a choice. Definition 2 asks for more than a placement: it asks that the realization be tame, and that is not automatic, a topological embedding of a graph in a manifold being capable of wildness, as the arc of Fox and Artin is in [8]. On the constructed stage the choice is not available, because an edge of is not a curve drawn on the stage but a level-0 act, and an act refines. Write for the ith standard basis vector of .
Definition 4
(The refinement of an act). Let a be the level-0 act moving primitive i at the record p. Read at level n in the sense of Definition 3, a is the chain of level-n acts that move primitive i one tally at a time and move nothing else, passing through the records whose ith tally runs over the values between the act’s two endpoints. Write for the set of sites those chains visit, over all levels.
The construction’s third and last premise says where an act goes: the realization of an act is the closure of . It adds nothing about recognition to the two premises stated before Lemma 1. It says that a stage realizing the records puts an act where the act’s own refinements go, and to reject it is to place an edge where no chain of acts arrives, which is to stop reading the placement off the records at all.
Lemma 2
(The cell an act forces). Let a move primitive i at the record p, and give A the metric of Lemma 1. Then
the straight segment of the stage through p in the direction of primitive i. It is the affine segment between the act’s two endpoints, carried by a parametrization of constant velocity .
Proof.
Write C for the right-hand side. Every site of has jth value that of p for each , so ; and C is closed, being an intersection of preimages of points under the continuous coordinate maps, so . Conversely let and . Choose n with and let m be the integer part of , which lies between 0 and because . The level-n record of the chain whose ith tally is m lies in , agrees with x exactly at every , and differs from it at i by less than , so its distance from x is less than ; hence . The two endpoints of a have equal jth values for and ith values 0 and 1, so C is exactly the affine segment between them, and the affine parametrization has derivative at every parameter. □
Proposition 2
(Tameness on the constructed stage). The straight realization in , rescaled into and placed in the compactified interior of the cube, is a cellular completion in the sense of Definition 2. Before rescaling:
- (i)
- each closed 1-cell is carried affinely onto a straight segment, hence by a smooth regular embedding;
- (ii)
- at a vertex , the incident cells issue along , , which are linearly independent and pairwise distinct;
- (iii)
- for every r with the ball of radius r about a vertex meets the realization in exactly the union of the D radial segments of parameter range issuing from that vertex.
After rescaling, the same radial statement holds for . Ambient Euclidean charts around the rescaled vertices give the charts the definition requires. Thus the constructed closed substrate satisfies the tameness clause of Axiom 2.
Proof.
Part (i) is Lemma 2. For (ii), the act at primitive i has outgoing direction at vertex v. Distinct primitives give distinct signed basis vectors, and these are linearly independent; this is the joint independence of Axiom 1 read on the stage, one primitive per act becoming one axis per edge.
For (iii), fix a vertex v and an act a at a record q moving primitive i, and suppose the cell of a does not contain v. Then v and q differ at some primitive , and both values are vertex values, hence 0 and 1 in some order, so they differ by exactly 1. Every point of the cell of a has jth value that of q, so its distance from v is at least 1, which is at least r. The ball of radius r therefore meets only the cells containing v; there are exactly D of these, one per primitive, since a cell through v is determined by the primitive it leaves free. By Lemma 2 the cell through v at primitive i is , whose points within r of v are exactly , a single radial segment because one of the two signs leaves the cube.
The realization is injective: two acts with the same free primitive and records agreeing elsewhere are the same edge of , and cells with different free primitives meet only where all coordinates are determined, which is at a shared vertex. A continuous injection of a compact space into a Hausdorff one is an embedding.
Proposition 1(iv) places the realization on the corners of rather than on the level-0 records, so that it lies in the interior and survives the compactification. That placement is the image of the one above under the coordinatewise affine map , which carries sites to sites and is a diffeomorphism, and both clauses of Definition 2 are preserved under one. □
Remark 7
(Tameness is the independence of the primitives and the cost floor). The two clauses of Definition 2 have two sources, and neither is new. The radial picture at a vertex is the independence of the primitives: an act moves one primitive, so an edge runs along one axis, and the primitives being independent, the axes are. The local cone structure away from the vertices is finiteness, and finiteness is the cost floor. Two different quantities are attached to an act and must not be confused here. The weight of Lemma 1 is displacement, how far an act moves a record, and it halves with each refinement, so displacement has no positive floor. The cost meant in this remark is the accounting charge for posting: one entry per record-changing act, at whatever level the act is posted, the unit the companion paper’s ledger fixes. Reading a posted act at a finer level moves no record (Definition 3) and registers no distinction, so it posts nothing and costs nothing; posting a distinction that is not a refinement of one already posted changes the record and costs at least one entry. A pass therefore posts finitely many acts and, by Lemma 2, sweeps a finite union of straight segments, a finite 1-dimensional polyhedron, which is locally cone-like at each of its points [9]. For this realization, tameness follows from the straight-cell refinement rule and the finite number of posted acts. More generally, if every new act costs at least , a budget B allows at most new acts. This cost inequality alone does not classify arbitrary embeddings as tame or wild; the straight-cell rule is the geometric input used here.
Remark 8
(What the construction supplies, and what the axioms retain). For the constructed stage, Lemmas 1 and 2 with Propositions 1 and 2 discharge the dimension clause of Axiom 2, its tameness clause, the alignment (Remark 4) and the acyclicity of Axiom 3: the completion the records force is the solid cube , of dimension exactly D and with , and the cube-graph embedding it carries is not chosen but read off the acts, one straight cell per act, radial and independent at every vertex. The derivation consumes exactly three recognitional premises: separation is measured by acts, refinement changes no separation, and an act is realized where its own refinements go; and one clause of the definition of a record, that each primitive refines along a line. These premises specify the class of refinement systems being constructed; other ledger geometries need not satisfy them. Within this class the metric is derived from the act weights, and changing the positive units leaves the dimension and homology conclusions unchanged.
What the construction does not discharge is closedness. The solid cube is a manifold with boundary, and the boundary consists of posted records, the corner and face tallies. Proposition 1(iv) discards that boundary and adds one point at infinity to obtain ; that is a closing step, not a completion, and it is the step the space premise asks for (Figure 4). It is also one closing among several: identifying opposite faces gives the torus , which has holes of its own and fails Axiom 3, while doubling the cube gives by another route. Proposition 17(ii) shows the closing is not idle: the unclosed cube, like the disk, satisfies the requirement at , with the boundary in the role of the third object that holds the record. On the constructed stage, then, closedness stands as a premise exactly as it does on a general substrate, and the argument for it is the one Figure 10 draws: it is the demand that the record be carried by the two loops alone.
Two things are deliberately not claimed. The theorems of the paper quantify over every substrate in the axiomatic class and not only the constructed one, and the sharpness results of Section 9.2 need that generality, being statements about which clauses of the general demand may be dropped; the axioms therefore stand as stated. And reading observed space as the constructed stage remains the identification of Section 1.4, which no construction can supply.
3. The Recognized Locus Is a Circle
The first genuine constraint comes from the recognizer, and at this stage it constrains not the ambient dimension but the dimension of the object the recognizer presents to the substrate. That object is the recognized locus, the path swept by the recognizer’s own cycle, along which Section 4 will demand distinguishability. Its dimension p is what the codimension count converts into D, and it is not a free parameter.
The reason is elementary. Look again at the Gray cycle drawn on the cube in Figure 3: eight steps along eight edges, each corner visited once, back to the start. Whatever space the cube is drawn in, that path is a closed curve that never crosses itself, which is to say a circle. A run along edges could never sweep a surface or anything of higher dimension, because edges are one-dimensional. The two propositions below say this carefully, first the upper bound (a walk on a graph sweeps something of dimension at most one) and then the exact value (the shortest complete run sweeps exactly a circle).
Proposition 3
(The transition structure is one-dimensional). Let and let be the cube graph of Axiom 1. Then:
- (i)
- is a finite 1-dimensional CW complex, of covering dimension exactly 1, and the image of any closed walk in is a finite CW subcomplex of covering dimension at most 1;
- (ii)
- no closed walk in has image homeomorphic to for any , and the same holds for the image of a closed walk under any topological embedding ι of into a space, Axiom 2 in particular.
Consequently any recognized locus arising from the recognizer’s combinatorial data and homeomorphic to a sphere is a circle.
Proof. (i) By Axiom 1, has only vertices and edges, so is the CW complex with one 0-cell per vertex and one 1-cell per edge; it has no cells of dimension , so its covering dimension is at most 1, and for it has an edge, so the dimension is exactly 1. A closed walk with has image the union of the 0-cells of the and the closed 1-cells of the traversed edges, a finite subcomplex. The covering-dimension facts used here, namely topological invariance, , and agreement of covering and cellular dimension for finite CW complexes, are standard [5].
(ii) Covering dimension is a topological invariant and , so a space of covering dimension at most 1 is not homeomorphic to for . An embedding is a homeomorphism onto its image and so preserves covering dimension. □
So is derived rather than stipulated. The proposition is not deep, its content being that a graph is one-dimensional; what makes it load-bearing is its position, being the only step of the forcing argument at which a feature of the recognizer, rather than of the substrate or a classical theorem, constrains a dimension. The companion paper reaches the same value from the arity of an act, which is why the two are counted once.
The proposition bounds the locus from above; the minimality clause of Axiom 1 pins it exactly. Figure 5 shows what the clause rules out. Nonminimal covering walks need not have circular images: a walk traversing every edge sweeps the whole graph. Minimality guarantees a circle, but is not necessary for a circular image; running twice around a Hamiltonian cycle leaves its image unchanged.
Definition 5
Lemma 3
(Minimal covering walks are Hamiltonian cycles). For every : (i) is a sequence of distinct vertices in which consecutive entries, including the wraparound, differ in exactly one coordinate; (ii) any closed walk in visiting every vertex has length at least , and a walk of that length visits every vertex exactly once. Hence the recognition cycle of Axiom 1 has length exactly and passes through each state exactly once. For it is a Hamiltonian cycle, its edges being distinct as well by Proposition 4(i), whose proof of that clause uses only the vertex statement proved here. At it is the walk , which meets both states once but traverses the single edge twice; the case is vacuous for the substrate, being the only closed connected 1-manifold and having .
Proof. (i) Induct on D. The base case is immediate. For the step, the length doubles by construction; entries with leading bit 0 form the first half and those with leading bit 1 the second, distinct within each half by induction and across halves by the leading bit; consecutive entries within a half share the leading bit and differ in one suffix coordinate by induction; at the junction the last entry of the first half is and the first of the second is ; and at the wraparound the last entry of the second half is against the first entry .
(ii) A closed walk with visits , and while surjectivity requires , so . If then , forcing pairwise distinct. Such a walk exists by (i). □
Proposition 4
(The minimal cycle realizes as a tame circle). Let , let satisfy Axiom 2, and let be a minimal-length recognition cycle of , read as its own geometric realization. Then:
- (i)
- γ visits every vertex exactly once and traverses pairwise distinct edges;
- (ii)
- the image is homeomorphic to ;
- (iii)
- is a topological embedding of into , and there are a tame, locally flat embedded circle , smooth away from the traversed vertex images, and an ambient isotopy of through homeomorphisms carrying onto K. If the vertex charts of the completion may be taken smooth, as in the affine models of Proposition 9, then K may be taken smooth; and at it may always be taken smooth, a locally flat circle in a 3-manifold being tame and ambient isotopic to a smooth one [12].
Proof. (i) Hamiltonicity is Lemma 3. For edge-distinctness write with indices modulo and suppose with . Then either , excluded by Hamiltonicity, or and ; since is a bijection, the latter gives and , hence and .
(ii) By (i) the image is a CW complex with 0-cells and 1-cells, each attached to consecutive 0-cells in cyclic order: the standard cell structure of . Explicitly, the map sending the arc of the unit circle from to linearly onto the kth traversed edge is a continuous bijection from a compact space to a Hausdorff one, hence a homeomorphism.
(iii) The restriction of to the closed subspace is an embedding, so composing with the homeomorphism of (ii) gives a topological embedding of whose image is a simple closed curve, smooth away from the traversed vertices.
At each traversed vertex, the chart of Definition 2 carries the two incident traversed edges to two distinct radial segments. Their union is a locally flat arc: in the plane spanned by the rays, a homeomorphism straightens the corner, and its product with the identity on the complementary coordinates gives local flatness in . Thus the original image itself can serve as K, with the identity ambient isotopy. It remains smooth away from the original vertex images by the edge regularity assumption.
If the vertex charts are smooth, corners can be rounded within disjoint chart balls, giving a smooth representative by an ambient isotopy. With merely topological charts this argument proves local flatness, not smoothness in the given smooth structure. At the cited smoothing theorem for tame circles supplies a smooth representative [12]. □
Without a minimality hypothesis, a circular image is not guaranteed: the walk has image an interval, and a walk traversing every edge of has image all of , whose first Betti number is 5. At the single edge is traversed twice, which is why is assumed; the restriction costs nothing, as Axiom 3 already excludes .
Remark 9
(What actually pins p). Replacing the binary primitives by k-ary ones, or letting transitions flip coordinates at once, leaves the transition structure a graph and . Enlarging that structure to the k-skeleton of the D-cube, or to the whole cube complex, does introduce embedded k-spheres, the boundary of a -subcube being one, and still leaves , since those spheres are carried and traversed by nothing: a complete pass visits every state and a -subcube has only (Theorem 7, Proposition 15). What moves p is the dimension of the process a pass runs on, which Axiom 1 sets at one by making a pass a closed walk, so is derived from the sequential character of recognition; the companion paper states the falsifier and prices the alternative.
4. The Requirement
The recognizer must be able to tell the two sides of a completed act apart, and both the thing told apart and the thing that tells it must be acts of recognition. The objects the demand quantifies over are fixed by the second half, so we name them first.
Before the definitions, the picture. A recognizer completes a run whose image is a circle K. A second trajectory L is run in . The requirement is that L bound no integral two-chain in this complement, equivalently no mapped compact oriented surface there. Every isotopy in the complement preserves that homology class, so a nonzero class cannot become zero by such a motion. The converse implication from an isotopy obstruction to nonzero homology does not hold: homology records only the abelian part of the topological obstruction (Proposition 6).
Here a recognition-free motion is an isotopy avoiding K; a strand passage through K is classified as a recognition event (Remark 10). The definitions specify which loops recognition can run and why the witnesses are disjoint (Figure 6).
Definition 6
(Recognition trajectory). Let be a cellular completion of in dimension D and let be a recognition cycle of . Therealized trajectoryof the pair is the image . Arecognition trajectoryin is a subspace ambient isotopic to a realized trajectory; it issmoothwhen it is a smooth tame embedded submanifold in that ambient-isotopy class. Anown trajectoryof the recognizer is a realized trajectory of the cube-graph embedding ι of Axiom 2 together with any recognition cycle of .
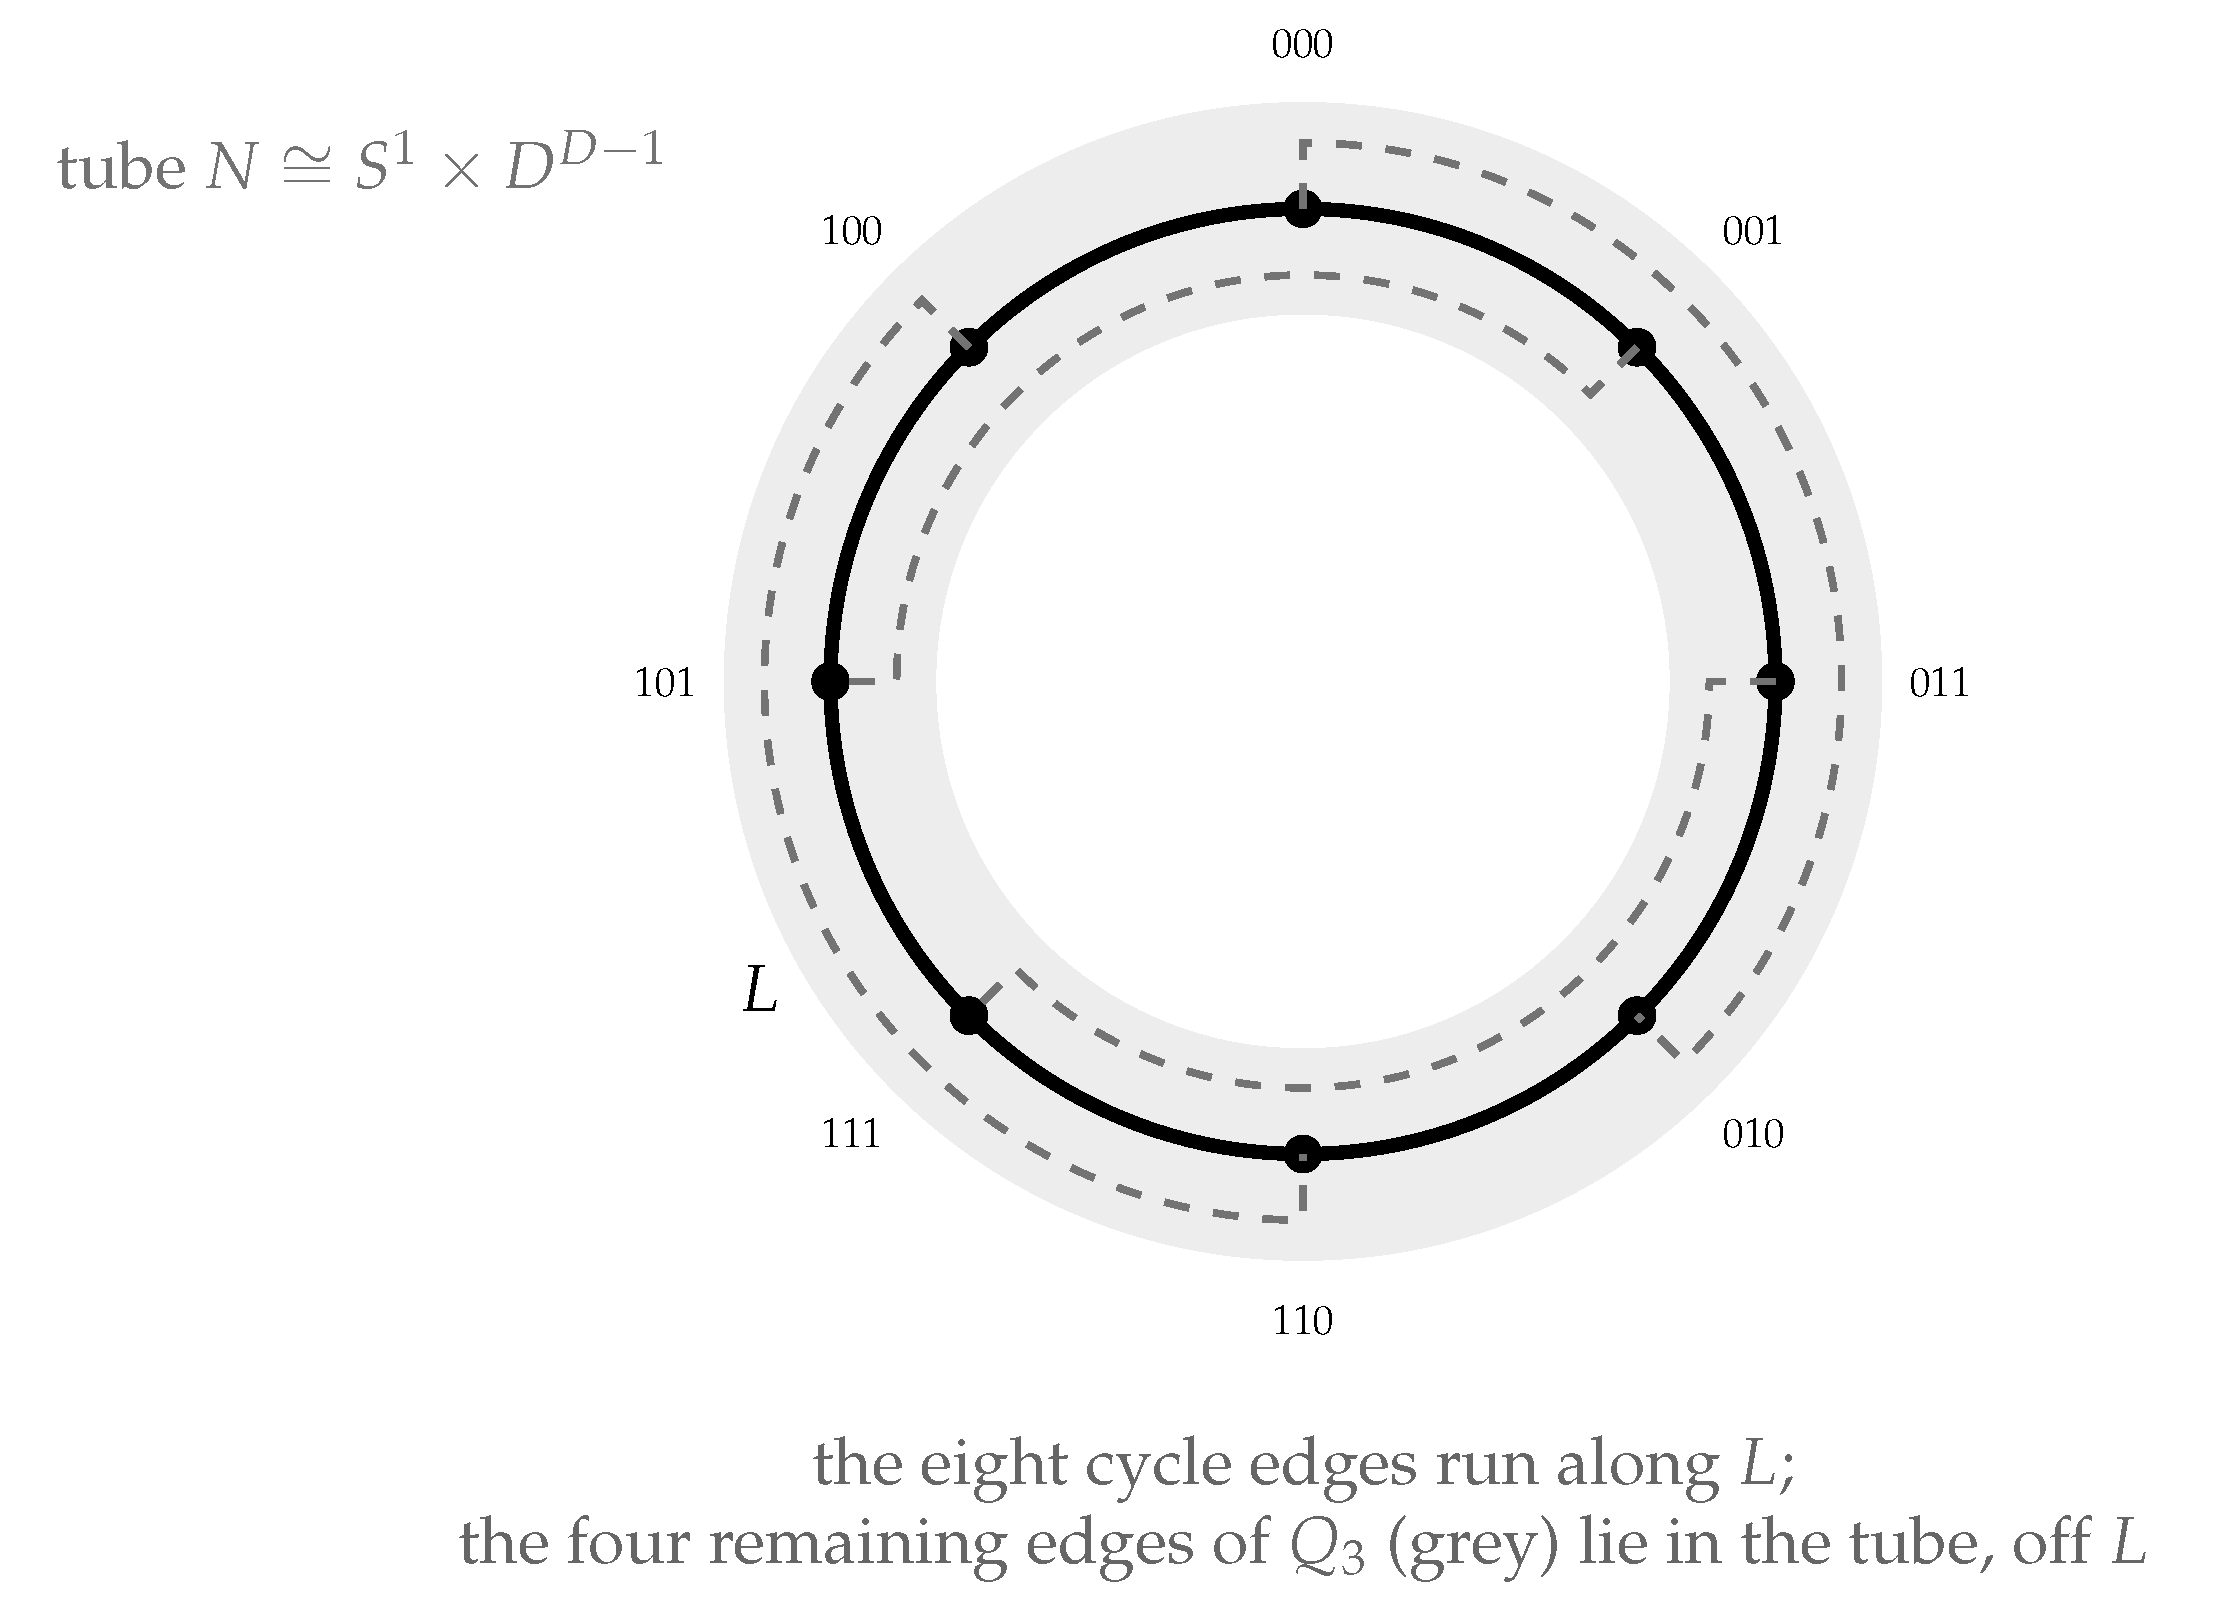
In plain terms. A recognition trajectory is a loop that some recognizer living in this space could sweep on a complete run: not necessarily the recognizer doing the demanding, and not necessarily one that exists, only one the space admits. Figure 7 shows why the class of such loops is large: given any smooth circle, one can draw a cube graph in a thin tube around it whose complete run is exactly that circle. So “a loop some recognizer could run” means, in practice, “a smooth circle,” and the definition’s work is to say this in a way that respects corners (the isotopy clause) and does not force the record to share corners with the run (the quantifier over completions).
Three features of the definition are forced rather than chosen.
- “Any recognition cycle,” not a distinguished one. For different recognition cycles sweep different loci, and nothing below needs a particular one, every realized trajectory being a tame circle by Proposition 4(iii).
- The quantifier over completions. Any two cycles of one fixed embedded meet in all vertex points (Figure 6). Read over a single completion, the requirement below would ask for a witness in the complement of a locus that contains it, and would be unsatisfiable in every dimension. The quantifier therefore ranges over the recognizers the substrate admits, not over the one doing the demanding: a recognition trajectory is a locus some recognizer in the substrate could sweep, not one being swept. This is the widest reading of “something the substrate can run”; the narrowest, the recognizer’s own completion, is the unsatisfiable one just excluded. The width costs nothing: Proposition 10 shows that every reading between “a probe accompanied by the entire recognizer that runs it” and “a probe some recognizer could run” selects the same dimension.
- Ambient isotopy, not equality. A realized trajectory is cornered at the vertices it passes through, so equality would fail except when the corners happen to be straight. The isotopy must be topological rather than smooth: a diffeomorphism carries tangent cones by , and a linear isomorphism carries a union of two distinct rays to a line only if it was one already, so no smooth map straightens a corner.
Figure 7.
Any smooth circle is a run some recognizer could make (Lemma 8). Given a smooth circle L in the space, place the states at equal angles along it, let the Gray-code cycle’s edges be the arcs of L between them, and route the remaining edges of the cube graph through a thin tube around L. The result is a cube graph embedded in the space whose complete run is exactly L. This is why the record loop in the requirement can be any smooth circle in the complement of K, and why the requirement is a statement about the space rather than about which recognizer happens to be present.
Figure 7.
Any smooth circle is a run some recognizer could make (Lemma 8). Given a smooth circle L in the space, place the states at equal angles along it, let the Gray-code cycle’s edges be the arcs of L between them, and route the remaining edges of the cube graph through a thin tube around L. The result is a cube graph embedded in the space whose complete run is exactly L. This is why the record loop in the requirement can be any smooth circle in the complement of K, and why the requirement is a statement about the space rather than about which recognizer happens to be present.
Axiom 4
(Recognition distinguishability; the requirement). What the recognizer traverses is distinguishable from its complement, and the distinction is registered by something the substrate can run. Precisely, there are a smooth recognition trajectory K ambient isotopic to an own trajectory of the recognizer and a smooth recognition trajectory such that L is not null-homologous in : the image of the fundamental class of L under is nonzero. We call the last condition theseparation clause, and the demand that K and L be recognition trajectories, the first of them the recognizer’s own, theownership clause.
In plain terms. “Not null-homologous in the complement of K” is the exact form of “locked to K”: there is no surface with boundary L that stays away from K. Every deformation of L that avoids K preserves this, so once the pair is in place, no record-free motion can separate them. The separation clause is the keeping; the ownership clause says both loops are things recognition does, so that the keeping is a fact about the act and not about the shape of the background. Notice that the axiom names no dimension and no number: what kind of object K and L are, and in which degree “bounds” is read, both follow from the fact that a recognizer runs closed walks.
The axiom is stated in the form the topology consumes, and it is an adopted premise of this paper. The companion paper shows it equivalent, over the ledger and one further reading, to the persistence of the completed act, whose statement carries no manifold, no homology and no dimension. The reading is that a record of the completed act is an account kept on a region of the space against the act’s own path, its key the phase around that path; the companion states this as a premise, not a theorem. Under it, each topological noun above has a bookkeeping source: the circle from minimality, the complement from the account-domain reading, the class from the arithmetic of accounts, the nonvanishing from the act’s difference from its own reversal. The equivalence relocates the premise; it does not remove it.
The axiom names no integer: it neither quantifies over the dimension of the recognized locus nor chooses a homological degree, both being inherited from what a recognition trajectory is, since the image of a closed walk in a graph is at most one-dimensional (Proposition 3) and is in fact a circle (Proposition 4), and a circle carries a fundamental class in degree one and no other. Section 7.2 shows that this costs nothing, the demand so worded being equivalent to the ambient statement .
Without the ownership clause the demand could be met by tame spheres of any dimension sitting anywhere, which would be a fact about the substrate rather than about recognition, and Remark 11 measures how much weaker that is. The clause names a recognition cycle in the sense of Axiom 1 rather than an arbitrary closed walk, which is more than Theorem 6 uses (Remark 14), so the theorem holds under the weaker reading too; the axiom is stated in the faithful form because that is the object the recognizer has.
Remark 10
(Disjointness is the persistence clause). The probe is read in the complement because the invariant is the homology class there. In an oriented homology 3-sphere, a deformation keeping the two circles disjoint preserves their linking number. A single transverse strand passage between the components changes it by or . If such passages are allowed without a recorded event, linking is no longer protected. This observation concerns complementary homology; it does not assert that arbitrary loops in every ambient manifold can be unlinked. Classifying a passage through the recognized locus as a registration event is the geometric reading adopted here, distinct from the theorem that disjoint deformations preserve the class.
Proposition 5
(Equivalent forms of the requirement at ). Let be a closed connected orientable smooth D-manifold with and let be a smooth tame embedded circle; write . The following are equivalent.
- (i)
- .
- (ii)
- There is a loop L in X, which for may be taken to be a smooth embedded circle disjoint from K, whose class in is nonzero.
- (iii)
- , read componentwise as over the path components of X.
If in addition and , these are further equivalent to
- (iv)
- the linking homomorphism is not identically zero.
Clause (iv) draws on Lemma 5 and Theorem 5, neither of which uses this proposition, so the forward reference introduces no circularity.
Proof. (i) ⇔ (ii). is the direct sum of the over path components, so a nonzero class has a nonzero summand in some component; choose such a component and represent that summand by a loop there ([7]), whose class in X is the chosen summand, hence nonzero. Conversely a loop with nonzero class witnesses nonvanishing. For the loop may be taken smooth by approximation and then embedded, a generic smooth loop in a D-manifold having no self-intersections, the expected dimension of the self-intersection locus being ([13]).
(i) ⇔ (iii). Hurewicz gives for each path component ([7]), and is the direct sum of these. The componentwise reading is needed only at , where the complement of a circle in a surface may be disconnected; for removing a tame submanifold of codimension at least 2 from a connected manifold preserves path-connectedness.
(iv) at . The linking homomorphism is well defined here: given , vanishing of places in the kernel of the Hurewicz map, the commutator subgroup, so L is homotopic to a product of commutators and bounds a map of a compact oriented surface with one boundary circle; the map may be taken smooth and transverse to K ([13]), and is independent of F, since two choices differ by a 2-cycle, which bounds because by Lemma 5. If then some class is nonzero, giving (i). Conversely (i) with forces generated by a meridian m (Theorem 5 and its proof), and since a meridian disk meets K once transversally. □
Proposition 6
(Non-contractibility is a different and weaker demand).
- (i)
- Let , where is the Poincaré homology 3-sphere, and let be a smooth embedded circle contained in a coordinate ball. Then is a closed connected orientable smooth 5-manifold satisfying Axiom 3, the complement contains loops that are not null-homotopic, and yet .
- (ii)
- Let be an unknotted 3-sphere. Then while ; here , whereas the codimension count of Lemma 6 gives .
Consequently a requirement worded as “some probe cycle in the complement cannot be contracted” is satisfied in dimensions that Axiom 4 excludes, and it selects no dimension.
Proof. (i) The product of closed connected orientable smooth manifolds is one, and by Künneth , so Axiom 3 holds. The circle K has codimension 4, and removing a smooth closed submanifold of codimension at least 3 leaves the fundamental group unchanged: general position makes every loop miss K, giving surjectivity, and every null-homotopy miss K, giving injectivity, the expected intersection dimensions being and ([13]). Hence , the binary icosahedral group of order 120, so X carries loops that do not contract. That group is perfect, its abelianization being trivial because , so by Hurewicz; independently this follows from Theorem 5, as .
(ii) The complement of an unknotted in deformation retracts onto , here . So , generated by the Hopf map, while . □
Part (ii) also fixes the form in which the requirement may be perturbed. For the homotopy and homology readings genuinely differ, the Hurewicz map being neither injective nor surjective in general, so Axis P of Section 10 is carried out homologically throughout; at the two agree after abelianization, which is Proposition 5.
Remark 11
(What the separation clause gives on its own). Deleting the ownership clause deletes what fixed the two loci, so the demand then asserts only thatsometame p-sphere, of any dimension and sitting anywhere, has nonvanishing p-th complement homology. Under the degree-specific acyclicity that is equivalent to (Lemma 6), hence satisfiable at with , at with , and so on, an unknotted witnessing each. Without that clause, which the axiom system does not contain, it is satisfiable in even dimensions too: for the manifold is closed, connected, orientable and 1-acyclic, and the complement of retracts onto .
So the separation clause with the substrate axioms constrains D only to , and the two exclusions have different sources: , where the no-holes premise has no models, and , where it forces and the Jordan curve theorem kills while no with embeds with nonempty complement. What excludes the rest is the ownership clause with Proposition 3, which make both loci circles and move the question into the one degree the no-holes premise controls. That is the exact measure of ownership’s contribution, from to , and it is where both integers of the chain go (Section 7.2).
Lemma 4
(Ambient isotopy invariance). Let Y be a space and subspaces with for some homeomorphism h of Y, in particular when for an ambient isotopy. Then h restricts to homeomorphisms and , so for every q and every coefficient ring R.
Proof.
A bijection of Y carrying A onto B carries bijectively onto ; the restrictions of h and are continuous, so both are homeomorphisms, and singular homology is a homeomorphism invariant. □
5. The Codimension Theorem
We now prove the classical fact that converts a statement about a circle into a statement about the dimension of the space containing it. Its substance is a codimension count: a bounding surface has dimension 2 and the recognized circle dimension 1, so the two can be forced to meet only when . Duality is the packaging, and Appendix A exhibits the count without it.
The count is worth holding in mind as a rule of thumb before the proof. In a space of dimension D, two generic objects of dimensions a and b meet in something of dimension ; when that number is negative they can be pushed apart, and when they can be forced to meet. A bounding surface () and a loop () therefore meet unavoidably only when . Below three the loop is too big for the space: at it cuts the surface in two, and any second loop lies in one piece and bounds there. Above three, a bounding surface can be put in general position disjoint from the loop (Figure 8). Three is the one dimension where a loop is neither a wall nor a hair.
Figure 8.
The codimension count behind Theorem 5. A cycle that bounds does so across a surface of dimension 2, and the recognized locus has dimension 1, so a forced crossing needs . Below three there is no room: the locus already separates a 1-acyclic substrate, and every probe bounds inside its piece. Above three there is too much room: a generic spanning surface misses the locus, so every link slips apart. At the meridian of K survives, and the obstruction it carries is the linking number.
Figure 8.
The codimension count behind Theorem 5. A cycle that bounds does so across a surface of dimension 2, and the recognized locus has dimension 1, so a forced crossing needs . Below three there is no room: the locus already separates a 1-acyclic substrate, and every probe bounds inside its piece. Above three there is too much room: a generic spanning surface misses the locus, so every link slips apart. At the meridian of K survives, and the obstruction it carries is the linking number.
Lemma 5
(1-acyclic closed orientable 3-manifolds are homology 3-spheres). Let be a closed connected orientable smooth 3-manifold. If then , so is an integral homology 3-sphere. More generally, for a commutative ring R with , if then .
Proof.
Connectedness makes free, killing the Ext term, and the hypothesis kills the Hom term. Since for a closed connected orientable 3-manifold, is an integral homology 3-sphere.
For general R the manifold is R-orientable, so by the same sequence. The hypothesis says , the Tor term vanishing as is free. Now is finitely generated, and a free summand would contribute , so it is a finite sum of cyclic groups with ; choosing u with , any r with satisfies , so . Hence , and no hypothesis on R beyond is used. □
Theorem 5
(Codimension theorem). Let be a closed connected orientable smooth D-manifold with , and let be a smooth tame embedding of . Then
so if and only if . The generator at is identified in Corollary 2.
Proof.
Setup. As a smooth closed submanifold, K has a tubular neighbourhood N diffeomorphic to the total space of its normal disk bundle , a -disk bundle over ([13]). It is orientable: from and the Whitney sum formula, . By the Thom isomorphism ([14]) with excision of ,
which is for and 0 otherwise; the homology of the base is unreduced, as the Thom isomorphism is stated, and for .
The same group is computed without the normal bundle by Poincaré–Alexander–Lefschetz duality, K being compact and locally contractible in the closed orientable :
([14],[Thm. VI.8.3, [15], [Thm. 6.2.17], [7], [Thm. 3.44]), Čech cohomology agreeing with singular by local contractibility, again unreduced and nonzero exactly for . This route consumes only compactness and local contractibility of K, which is why the theorem survives the removal of tameness (Theorem 9(iii)).
The exact sequence. Exactness of
gives
Case . By (1) at the relative term is , since , so .
Case . The relative term is the unreduced , and by Lemma 5, so has trivial domain and .
Case . Closed connected orientable surfaces are classified by genus ([16]) with , so the hypothesis forces , and the Jordan curve theorem in homological form ([7]) gives and for . In the language of (3) the relative term is , nonzero, but is onto, so the cokernel vanishes. This is the one case in which , rather than the vanishing of the relative term, does the work.
Case . The hypothesis is unsatisfiable, so the case is vacuous. □
Three of the four hypotheses can be dropped, and the proof used them at identifiable points: smoothness of the substrate only for the tubular neighbourhood, which (2) replaces; smoothness and tameness of the circle at the same point; and connectedness nowhere.
Corollary 1
(Topological form). Let be a closed orientable topological D-manifold, not assumed connected or smooth, with , and let be any subspace homeomorphic to . Then if and vanishes otherwise.
Proof.
A closed manifold has finitely many components, each open and closed. Let be the one containing the connected set K and the rest; then , and both and vanish because splits over components. So it suffices to treat , which is closed, connected, orientable and 1-acyclic.
The proof of Theorem 5 applies with (2) in place of (1): that computation needs only that be a closed orientable manifold and K compact and locally contractible, and it returns the same tally, , nonzero exactly for ; the sequence (3) is formal. Of the cases, and use nothing further, uses Lemma 5, which asks for no smooth structure, and uses the surface classification and the Jordan curve theorem in the form cited, which holds for arbitrary topological embeddings. □
The body retains the smooth formulation because the tubular-neighbourhood proof and the transversality argument of Appendix A are stated in it, and because the recognizer’s own locus is a polyhedron that Proposition 4(iii) smooths; the corollary shows that none of that is load-bearing.
The general-p statement is recorded with the hypotheses it needs, because the recognized-locus dimension will be varied. It is not used in the forcing chain, where Proposition 3 pins .
Lemma 6
(Codimension count at general p). Let , let be a closed connected orientable smooth D-manifold with , and let be a smooth tame embedding of . Then the hypotheses force , and
the group being when .
Proof.
. Invariance of domain gives . If then is open by invariance of domain and closed by compactness, hence all of by connectedness, so , contradicting the hypothesis. If then , again a contradiction. So .
Setup. As in Theorem 5, the normal disk bundle of is orientable and Thom with excision gives .
The sequence at . Both hypotheses enter, one at each end of
so ∂ is an isomorphism and , nonzero exactly when , that is or , the latter excluded above. □
Remark 12
(How the two statements differ). At , Lemma 6 assumes , more than Axiom 3 supplies, and it is the second clause that excludes ; Theorem 5 assumes only the first and dispatches by surjectivity of instead. At the selected dimension the discrepancy disappears, by Lemma 5.
6. Dimension forced
Theorem 6
(Dimension forced). Assume Axioms 1, 2, 3 and 4. Then the recognition substrate satisfies ; hence by the dimensional-alignment clause of Axiom 2, and the recognition quotient has states.
Proof.
Step 1: . If then and , contradicting Axiom 3.
Step 2: both loci are circles, and the degree is 1. By the ownership clause the witnesses K and L are recognition trajectories, so each is ambient isotopic to the image of a closed walk in under a cellular completion; by Lemma 4 each is homeomorphic to such an image, by Proposition 3 no such image is homeomorphic to with , and by Proposition 4(ii) each is homeomorphic to . Hence the recognized locus is a circle, and the separation clause, being the nonvanishing of the image of the fundamental class of the circle L, is a statement about .
Step 3: . The recognized locus is a tame embedded circle K in the closed connected orientable smooth 1-acyclic , and Step 2 gives , so Theorem 5 gives . The smoothness of K is supplied by the axiom’s wording and is not needed at this step: Corollary 1 gives the same conclusion for any subspace homeomorphic to a circle, so the requirement fails in every dimension other than three for a reason of dimension and not of regularity.
Step 4: transfer. The alignment clause identifies the substrate dimension with the primitive count, giving , and Axiom 1 then gives states. □
In plain terms. The proof has exactly the shape of the four steps on page one, and Figure 9 lays it out. The recognizer supplies the cube and the fact that a run is a loop. The space premise supplies a place to draw the loop. The requirement asks that a second loop be locked to the first. The codimension theorem says that can happen only in three dimensions. No step other than the last mentions a number, and the last one mentions three only because a loop has dimension one and a bounding surface has dimension two.
Corollary 2
(The substrate is a homology 3-sphere and the distinction is one integer). Under the hypotheses of Theorem 6, M is an integral homology 3-sphere: and . Moreover , generated by the meridian μ of the recognized circle K, which may and will be oriented so that ; the class of a probe cycle c in is then . Hence is an isomorphism, the identity on the basis , so the linking number is a complete invariant of the registered distinction and no finer invariant of the complement in degree one exists. The requirement is therefore satisfied exactly by the recognition trajectories of nonzero linking number with K, and the credit-debit distinction is carried by that single integer.
Proof.
Theorem 6 gives , and M is closed, connected, orientable and 1-acyclic, so Lemma 5 gives and .
The case of Theorem 5 computes , which (1) identifies with generated by the class of a normal disk fibre ; the connecting map sends that generator to , so generates. A meridian disk meets K once transversally, so in the sense of Proposition 5(iv); replacing by its reverse if necessary, which negates its class and hence its linking number, orient it so that . Since is a homomorphism on , writing gives : the homomorphism reads off the coefficient in the chosen basis and is an isomorphism. □
Remark 13
(The minimal record is a unit). The requirement asks only for a nonzero class, but the nonzero classes are with , and the least absolute linking number is : the minimal registered distinction is the meridian class itself, one unit of linking. Nothing in the requirement prefers one n over another; what prefers the unit is cost. The companion paper identifies the charge of a probe as the balance of an account kept against the recognized circle, posted once per passage of phase, so a record carrying charge n costs at least units and the floor among nonzero charges is uniquely attained at ; the same least-cost principle that selects the process dimension there selects the unit record. The preference is realized, the Hopf witness of Proposition 13 having .
Proposition 7
(Connected graph loci). Let , let be a closed connected orientable smooth manifold with , and let be a nonempty connected finite tamely embedded graph. Then
Proof.
Indeed, at the vanishing of and reduces the pair sequence to by Equation 2. At , the term vanishes. At the substrate is , and Alexander duality gives . Thus a connected graph with a cycle still selects three, while a tree supplies no first-homology record. □
Proposition 8
(Separating the record from ambient homology). Let , let be a closed connected orientable smooth manifold, and let be a smooth embedded circle with in . Put . Then
Thus one can remove ambient first homology by restricting the detector to classes that vanish on inclusion, instead of requiring all ambient first homology to vanish.
Proof.
The pair sequence and Equation 2 identify the displayed kernel with the cokernel of
For the target is zero. At it is , and the orientation class of the closed surface maps to a generator, so the cokernel is zero. At the target is ; the first map evaluates a 2-cycle’s intersection number with K. This pairing depends only on , so the null-homology assumption makes the map zero and its cokernel is . □
This is a different detector from Axiom 4: it asks that the probe’s class be nonzero in the complement but zero in the ambient manifold. It gives a stronger ambient generality for null-homologous recognized circles, including every circle contained in a coordinate ball. The sharpness of 1-acyclicity in Proposition 17 concerns the unfiltered requirement actually adopted in this paper; it is not a necessity theorem for every possible way of separating an act’s record from background topology.
Remark 14
(Which hypotheses the proof uses). Axiom 1 enters only through Proposition 3, and the alignment clause only in Step 4. Within the rest, exactly two ingredients force the value: Proposition 3, which pins from the recognizer’s transition structure, and Theorem 5, which converts that into ; the 1-acyclicity of Axiom 3 is the only acyclicity used. Nothing needs the Gray code, the binary alphabet, or the unit Hamming width: the walks enter only through the dimension of their images and through minimality, which is what makes those images circles and so gives the separation clause a fundamental class to speak of. An arbitrary closed walk can have a graph as its image rather than a manifold. Proposition 7 treats that extension: a connected graph with a cycle still selects three, whereas a tree supplies no first-homology record. Minimality is needed for the circle formulation, not for that graph-valued dimension conclusion.
7. The Converse and the Models
An implication whose hypotheses cannot be met proves nothing. This section settles satisfiability, disposes of the one bookkeeping question the equivalence raises, whether the tracked degree is a second stipulation beside the dimension of the locus, and then reverses the implication.
7.1. Models of the Substrate Axioms
Proposition 9
(Consistency of the substrate axioms). For every the standard sphere admits a cellular completion of in dimension D and satisfies Axiom 3. The same holds for every closed connected orientable smooth 1-acyclic D-manifold. In each case the full structural layer is modelled: Axiom 1 is witnessed by the configuration set with reading the i-th coordinate, so that β is the identity, and by a Gray cycle (Lemma 3) as the minimal-length closed covering walk. For no substrate satisfies Axiom 3.
Proof.
For the sphere is closed, connected, orientable and smooth with for ([7]). Realize in by sending each vertex to the point with the same coordinates and each edge to the straight segment between its endpoints: the image is the 1-skeleton of the unit cube, whose segments meet only at common endpoints, so is a continuous injection of a compact space into a Hausdorff one, hence an embedding; each closed 1-cell is carried affinely onto a straight segment, and each vertex has its D incident edges carried onto segments issuing in D pairwise distinct axis directions, so the affine chart exhibits the radial configuration required by Definition 2. For a general 1-acyclic , the construction lies in , which after rescaling lies in any prescribed open ball, so composing with a chart gives a tame 1-dimensional subcomplex. The identity on is surjective, so its coordinates are jointly independent (Definition 1), and Lemma 3 supplies the covering closed walk of length , which is minimal. The final assertion is . □
Remark 15
(How little of the recognizer survives). In these witnesses lies inside one chart, so all its cycles bound in the substrate, as 1-acyclicity requires. Nothing in Axiom 2 prevents this, so the recognized circle may always be taken unknotted in a ball, and then no feature of beyond its being a graph containing a cycle survives into the dimension argument; Remark 14 records the same fact from the other side. The combinatorial apparatus makes the recognition reading concrete; it is not what makes the dimension three.
7.2. The Tracked Degree Is Not a Second Choice
Reading the complement of a p-dimensional locus in degree q selects (Theorem 8), so would select four dimensions and the question is not cosmetic. Two statements show that the degree is not a parameter of the demand at all: a trajectory can present a class only in degree one, and every class in degree one is presented by a trajectory, the second being why the first costs nothing.
Lemma 7
(Simultaneous straightening of arcs with distinct tangents). Let and let be smooth regular embeddings with , pairwise disjoint except at 0, whose tangent directions are pairwise distinct. Then there are , , and a homeomorphism Φ of the closed ball onto itself, fixing 0, preserving every sphere about 0, and smooth on , such that for every i and every with , where is smooth and increasing. Each arc becomes the radial segment along its own tangent. No diffeomorphism can do this in general: two of the arcs may have opposite tangents, and their union is then a curve that is but need not be at the origin, while the preimage of a straight line under a diffeomorphism is smooth.
Proof.
Reparametrize each by arclength, so and . From and ,
for all small , so there is on which every is smooth and strictly increasing, with smooth inverse . The tails are compact and avoid 0; choose below their distance to 0 and below every . Then for each arc meets the sphere in the single point , and
is smooth on with as , since . For each fixed r the points are pairwise distinct, the arcs being disjoint away from 0.
The are pairwise distinct, so there are pairwise disjoint open disks about the ; shrinking , we have for all and all i. For close enough to there is a diffeomorphism of , supported in , with , depending smoothly on p: in a chart carrying into with at the origin, the time-one flow of the field , for a bump supported in the chart with near 0, carries 0 to a point depending smoothly on with derivative the identity at , so for p near there is a smooth whose flow carries to p, and is its inverse; this is the standard homogeneity construction [17]. Shrinking once more so that every lies in the range of the construction, set
a diffeomorphism of with for every i, the supports being disjoint, and smooth in jointly, as is the family of inverses. Define
Each sphere is carried onto itself bijectively, so is a bijection of onto itself with inverse ; both are smooth away from 0 and continuous at 0, since , no convergence of as being needed. For t with , writing ,
so each arc is carried onto the radial segment along its own tangent, with radial parameter . □
Lemma 8
(Every complement class is a recognition trajectory). Let , let be a closed connected orientable smooth D-manifold, let be a smooth tame embedded circle, and let . Then there is a smooth recognition trajectory whose fundamental class maps to c; and the realizing completion may be chosen with its entire image inside any prescribed neighbourhood of L.
Proof.
Represent c by an embedded circle. Every class of is represented by a loop ([7]); the loop lies in the open manifold , and for smooth approximation and a generic perturbation make it a smooth embedded circle L, the expected dimension of the self-intersection locus being ([13]).
A product neighbourhood.L is a compact smooth submanifold of the open manifold , so it has a tubular neighbourhood , and shrinking the fibre radius places N inside any prescribed neighbourhood of L, which gives the final clause, the whole construction below lying in N; the normal bundle is orientable, since with orientable and trivial, and an orientable vector bundle over is trivial, so with .
Realize in N with L as its recognition cycle. Fix the Gray-code Hamiltonian cycle of Lemma 3, a recognition cycle by Proposition 4(i). Put with , and realize each Hamiltonian edge as the arc of L between consecutive vertices, so those edges sweep out exactly L. For a unit vector u in the fibre disk let
a half-open annulus meeting L in its boundary circle; two such pages meet exactly in L. Each of the remaining edges is assigned its own direction u, possible because makes the unit sphere of the fibre infinite, and is realized inside its page as a smooth arc leaving radially, running at small constant radius, and returning radially to . Such an arc meets L only at its endpoints, and arcs in distinct pages meet only in L, hence only at shared endpoints.
The result is a cellular completion. Each closed 1-cell is carried onto a smooth arc by a regular embedding. At a vertex the incident edges are the two Hamiltonian arcs, leaving along , and the page arcs, each leaving radially along its own u, so the D incident arcs have pairwise distinct tangent directions, the antipodal pair included. Read in the product chart of N, they are finitely many smooth arcs meeting at a point with pairwise distinct tangent directions, which Lemma 7 carries simultaneously onto straight radial segments by a homeomorphism of a small ball, smooth away from the vertex; the ball is taken small enough to miss the finitely many edges not incident to the vertex, which are compact and avoid it, so that the chart sees only the incident arcs. Composing the chart with that homeomorphism is the topological chart required by Definition 2. So is a cellular completion of , its realized trajectory is L, and L is a smooth tame embedded circle whose fundamental class maps to c. □
The lemma is the exact converse of Remark 15: for the recognition trajectories in a substrate are, up to ambient isotopy, precisely its smooth tame embedded circles. Two claims must be kept apart here, because the lemma proves the weaker and only the weaker: that a probe is run by a recognizer, and that a probe admits a recognizer built to run it. The construction closes the distance between them as far as mathematics can, exhibiting the recognizer rather than positing it, with its entire apparatus confined to any prescribed neighbourhood of the probe, so the probe arrives carried and not merely carriable in principle; what no construction settles is whether that recognizer is present, which is the same modality already carried by the quantifier over completions in Definition 6 and named there. The right response is not to pick a reading but to show the selection indifferent to the choice, which is the next proposition. What the ownership clause contributes is then exactly this: the witnesses are swept circles, carrying their classes in degree one and in no other, and that contribution is the same under every reading.
Proposition 10
(The selection is stable across readings of ownership). Assume Axioms 1, 2 and 3. Call areadingof the ownership clause any rule that, for the substrate and each smooth recognition trajectory K ambient isotopic to an own trajectory, admits some class of subspaces of as probes, subject to two constraints:
- (a)
- every admitted probe is a recognition trajectory of : no reading admits what no recognizer sweeps;
- (b)
- a smooth tame embedded circle is admitted whenever some cellular completion realizes L as its trajectory with image contained in a prescribed neighbourhood of L in : no reading refuses a probe that arrives together with the entire recognizer running it.
Then the demand that there be such a K and an admitted smooth probe with nonzero class in holds if and only if . By contrast the same-completion reading, under which both loci are realized trajectories of the recognizer’s own embedding ι, is satisfiable in no dimension.
Proof.
Let the demand hold under some reading. By (a) the probe L is a recognition trajectory, hence a circle (Propositions 3 and 4(ii)), and its nonzero class makes with K a smooth tame embedded circle, so Theorem 5 gives . Conversely let . Own trajectories exist and may be taken smooth (Lemma 3, Proposition 4(iii)), giving K; Theorem 5 gives ; and Lemma 8 realizes a nonzero class by a smooth tame embedded circle L whose completion lies in a tubular neighbourhood of L, which (b) obliges every reading to admit. For the last assertion, recognition cycles are minimal covering walks, hence Hamiltonian (Lemma 3), so any two realized trajectories of one embedding contain all vertex images and are never disjoint. □
Said plainly, the proposition is not a robustness result over a wide range of readings, because Lemma 8 leaves the range narrow: for every smooth circle in the complement is a trajectory some recognizer could run, so “a loop a recognizer could run” means “a smooth circle,” and readings (a) and (b) admit the same loops. What the ownership clause contributes is exactly that both loci are circles, which is what moves the selection from (Remark 11) to . Below reading (b) sits only the same-completion reading, excluded by intersection; above (a) sits a probe that no recognizer sweeps, and the demand would then be about subsets rather than recognition. Between them there is one reading, and it selects three.
Proposition 11
(The operational demand is the homological one). Assume Axioms 1, 2 and 3, and let K be any smooth recognition trajectory ambient isotopic to an own trajectory. Then Axiom 4 holds if and only if . In particular the right-hand condition is the same for every such K.
Proof.
Suppose Axiom 4 holds with witnesses and L. Then L is a circle by Proposition 4(ii), so the image of its fundamental class lies in and is nonzero. The given K need not be , since distinct recognition cycles need not sweep ambient isotopic loci, and the transfer is made by Theorem 5: is a smooth tame embedded circle in a substrate satisfying Axiom 3, so nonvanishing forces , and the same theorem applied to K returns . This is also what makes the condition independent of the choice of own trajectory.
Conversely suppose . Axiom 3 excludes , and at forces , where the Jordan curve theorem makes the hypothesis unsatisfiable. So , and Lemma 8 applied to a nonzero class produces a smooth recognition trajectory not null-homologous there. □
Proposition 12
(The tracked degree is not an independent stipulation). Assume Axioms 1, 2, 3 and 4. Then:
- (i)
- the recognized locus is one-dimensional and the complement is read in degree one, both as consequences of the ownership clause with Propositions 3 and 4, and neither as a wording of the axiom;
- (ii)
- the demand so worded is equivalent to , so fixing the degree this way excludes no witness;
- (iii)
- consequently in every model of the axioms, and it is not an independent parameter of the chain.
Proof. (i) is Step 2 of Theorem 6: both witnesses are circles, and the fundamental class of a circle lives in degree one. (ii) is Proposition 11. For (iii), by (i) both the locus dimension and the tracked degree equal the dimension of what a recognizer runs, which is 1. □
7.3. Equivalence
Proposition 13
(The requirement is equivalent to ). Assume Axioms 1, 2, 3 and . Then Axiom 4 holds if and only if .
Proof.
Forward is Theorem 6. Conversely let and let be a minimal-length recognition cycle of , which exists by Lemma 3. By the clause of Proposition 4(iii) there are a smooth tame embedded circle and an ambient isotopy carrying onto K, so K is a smooth recognition trajectory ambient isotopic to an own trajectory. By Theorem 5, , and Lemma 8 realizes a generator as a smooth recognition trajectory , which is therefore not null-homologous there. By Lemma 4 the group would have been the same for any other smoothing, any two being ambient isotopic to and hence to one another. □
The hypothesis costs nothing: at no substrate satisfies Axiom 3, so both sides fail. Both directions are non-vacuous, with the completion of Proposition 9 satisfying the substrate axioms and the Hopf link exhibiting a linked pair, while the requirement fails at each other dimension for its own reason: no models at , acyclic complements at , a bounding surface perturbable off a curve at . Every other ingredient in the chain is dimension-uniform, so “one recognition act can be linked by another” is a recognition-theoretic characterization of dimension three.
8. What a Recognizer Merely Carries
The forcing argument is complete, so the question is no longer what the chain concludes but where in it the integer was chosen. One candidate can be disposed of within the present paper: the skeletal dimension of the transition structure, which cannot move the answer. The remaining candidates, the dimension of the process a pass runs on and the arity of an act, can move it; the companion paper [2] prices them and selects, and nothing in Theorem 6 depends on either.
A recognizer may be given more than a graph: alongside its transitions one may record the 2-cells witnessing that two flips commute, the 3-cells witnessing coherence among those, and so on up to the whole D-cube. That is the one variation with any claim on the dimension, since a complex of dimension k contains embedded k-spheres, which for a graph does not.
The worry, in plain terms, is this. The argument used the fact that a run sweeps a circle because a run moves along edges. But a recognizer that knows two of its flips commute has, in effect, a square face between the four states involved, and a recognizer that knows all its flips commute has the whole solid cube. Does a recognizer that carries faces sweep surfaces, and so change the count? The answer is no, and the reason is the difference between carrying and running: the faces are facts about the cube, but a completed act is still a sequence of single flips, and a sequence of single flips is a walk along edges (Theorem 7). What would change the count is a recognizer whose acts themselves were two-dimensional, and that is the variation the companion paper prices.
Definition 7
(Transition complex). Atransition complexfor the recognizer of Axiom 1 is a finite CW complex whose 0-skeleton is the state set and whose 1-skeleton is ; itsskeletal dimensionis . The graph is the case , the k-skeleton of the D-cube the case , the cube complex the case . Acellular completion of in dimension Dis a pair with a closed connected orientable smooth D-manifold and a topological embedding whose restriction to is a cellular completion in the sense of Definition 2.
Proposition 14
(Every skeletal dimension is completed). Let and let be any subcomplex of the D-cube containing , the cube complex included. Then every closed connected orientable smooth 1-acyclic D-manifold admits a cellular completion of in dimension D.
Proof.
The realization used in Proposition 9 is the restriction to the 1-skeleton of the affine homeomorphism carrying the cube complex onto , so its restriction to is a continuous injection of a compact space into a Hausdorff one, hence an embedding, and its restriction to is the completion built there. The image is compact, so rescaling into a chart of any 1-acyclic finishes the argument as before. □
Theorem 7
(The skeletal dimension is not a parameter). Let , let be a transition complex, and let be a cellular completion of in dimension D with . Then every recognition trajectory in is a tame circle, and Axiom 4 holds if and only if . Neither conclusion depends on .
Proof.
A recognition cycle is a closed walk in , so its image lies in , and restricted to is a cellular completion of ; Proposition 4 therefore applies verbatim to that restriction, so the realized trajectory is homeomorphic to and locally flat, smooth away from its vertices; at it is ambient isotopic to a smooth circle. This holds for every completion. The pair satisfies Axioms 2 and 3, so Theorem 6 gives the implication from Axiom 4 to and Proposition 13 the converse; both precede this section and neither uses it. The cells of above dimension one enter nothing: the requirement reads the complement of the image of a walk, and no group computed in Theorem 6 is taken relative to any other part of . □
The theorem is not deep, its content being that a walk stays a walk when cells are built around it; what makes it load-bearing is that it keeps the skeletal dimension out of the answer. It is conditional on a completion existing, which is the only thing enlarging the transition structure can affect, cells above dimension D admitting no embedding into a D-manifold at all; for the structures at issue it does not (Proposition 14).
Remark 16
(Carrying a cell is not running it). Take the cube complex itself, realized affinely in a chart. At this is a solid cube in : the recognizer carries its six faces and its interior as well as its twelve transitions, and the requirement still selects three, because what it runs is still an eight-step cycle through its eight states.
A reading in which the skeletal dimension does move the answer must take the recognized locus to be a maximal sphere of rather than the locus of a pass. That reading is available as mathematics, and the codimension count evaluates it at ; it is not available as a statement about a recognizer.
Proposition 15
(A maximal sphere is not an act). Let , let be the k-skeleton of the D-cube, and let be the boundary of a -dimensional subcube, a subcomplex homeomorphic to .
- (i)
- C meets exactly of the states.
- (ii)
- If then , so C misses a state and is the image of no recognition cycle.
- (iii)
- If in addition and , then Axiom 4 fails in every cellular completion of in dimension .
Proof. (i) A -subcube is cut out by fixing coordinates, so it has vertices, and every vertex of a cube of dimension at least one lies in its boundary.
(ii) is , and a recognition cycle visits every state.
(iii) By Theorem 7 every recognition trajectory is a tame circle, and by Theorem 5 the complement of a tame circle in such a substrate has vanishing first homology whenever ; since for , the separation clause has no witness. □
Part (iii) is the substance. In the dimension that the maximal-sphere reading selects, the recognizer’s own act meets no requirement at all, running a circle whose complement has every circle bounding. That reading describes not a recognizer distinguishing the two sides of its act in five dimensions, but one that cannot distinguish them anywhere, together with a subcomplex, traversed by nothing, that would if it were run.
9. What the premises force, and what they do not
What remains before the integer can be located is to price the premises: to show that the requirement is not a repackaging of the structural layer, and to account for the substrate hypothesis clause by clause.
9.1. The Requirement Is a Genuine Input
Proposition 16
(The structural layer does not force the requirement). For every there is a model of Axioms 1, 2 and 3 in dimension D. In every such model with , Axiom 4 fails. In particular, at the sphere with the completion of Proposition 9 satisfies the whole structural layer and carries a realized recognition cycle whose complement has vanishing first homology.
Proof.
Existence of models is Proposition 9. Let and suppose Axiom 4 held with witnesses K and L. Both are recognition trajectories, hence circles by Propositions 3 and 4(ii), and K is a smooth tame embedded circle by the smoothness clause of Axiom 4 itself (Definition 6). But Theorem 5 gives for , so the fundamental class of L maps into the zero group, contradicting the separation clause. □
So the structural layer is satisfiable in every dimension from 2 upward, and adding the requirement removes every dimension but one. Read through the companion paper’s derivation, what the models with witness failing is the persistence demand: in each of them the recognizer’s completed pass admits no registration distinguishing it from its reversal, every account against its locus balancing to zero.
9.2. Every Substrate Clause, Accounted for
Definition 2 asks the substrate to be closed, connected, orientable and smooth, and Axiom 3 asks it to be integrally 1-acyclic. Exactly two of the five do work, and each is sharp; of the other three, one follows from a clause already present and two are not logically necessary for the forcing argument.
Lemma 9
(Orientability is implied). Every closed topological n-manifold M with is orientable.
Proof.
Orientability is the vanishing of , which classifies the orientation double cover ([7]). Universal coefficients gives
and a closed manifold has finitely many components, each open, so is free and the Ext term vanishes while the hypothesis kills the Hom term. Hence . □
For the integral-coefficient statements, orientability may therefore be deleted as a separate hypothesis. It remains an independent hypothesis in the coefficient-ring variation of Theorem 9. The two clauses that do the work cannot be deleted.
Proposition 17
(Necessity of closedness and of 1-acyclicity).
- (i)
- (Closedness: compactness.)Let and let realize the 4-cycle as a smooth embedded circle K. Then is a boundaryless connected orientable smooth 1-acyclic 2-manifold, K is the realized recognition cycle, and . Every hypothesis except compactness holds, Axiom 4 is satisfied with K as the recognized locus and a second realized 4-cycle encircling it as witness, and .
- (ii)
- (Closedness: emptiness of boundary.)Let , the closed unit disk, and let ι realize as a smooth embedded circle K concentric with the boundary and interior to it. Then is a compact connected orientable smooth 1-acyclic 2-manifold with boundary, and . Every hypothesis except emptiness of boundary holds, Axiom 4 is satisfied with a second realized 4-cycle between K and the boundary as witness, and . Closedness is therefore two sharp conditions and not one: the plane deletes compactness alone, the disk deletes boundarylessness alone, and either deletion admits .
- (iii)
- (1-acyclicity.)Let with the completion of Proposition 9. Then is a closed connected orientable smooth 4-manifold, and foreverysmooth tame embedded circle , . Every hypothesis except holds, Axiom 4 is satisfied with the realized recognition cycle as witness, and .
Proof. (i) The plane is a connected orientable smooth surface with vanishing reduced homology, and is a 4-cycle whose realization is a circle embedding smoothly in the plane; its minimal recognition cycle is the 4-cycle itself, so the realized locus is K. By the Jordan curve theorem the complement has two components, an open disk and an unbounded component retracting to a circle, so . The generator is realized by a recognition trajectory without appeal to Lemma 8, which needs : a second embedding of as a large square surrounding K is a cellular completion with the closedness clause deleted, and that square has winding number one about the bounded component.
(ii) The disk is compact, connected, orientable, smooth and contractible, so 1-acyclic. Its interior is a chart, and the realization of Proposition 9 placed there, rescaled so that K separates a concentric inner disk from a half-open collar of the boundary circle, is a smooth embedded circle. The complement has two components, the open disk inside K and the collar, which deformation retracts to a core circle, so ; a second realized 4-cycle drawn in the collar, concentric with K, has winding number one about the inner component and carries the generator, as in (i).
(iii) The product is closed, connected, orientable and smooth, and the completion of Proposition 9 uses only a chart. Let K be any smooth tame embedded circle; it has codimension 3, so removing it changes neither path-connectedness nor the fundamental group, general position pushing loops and null-homotopies off K, the expected intersection dimensions being and ([13]). Hence and by Hurewicz. The circle , pushed off K, carries a generator, and Lemma 8 makes it the realized trajectory of a second recognizer in the complement, so the separation clause holds, while the ownership clause holds with the realized recognition cycle as recognized locus. Finally by Künneth, so Axiom 3 fails, as it must. □
Figure 11.
Why the space must have no one-dimensional holes of its own. Schematic of Proposition 17(iii), where the space is and the annulus stands for the factor. A loop L around the hole is not null-homologous, so the separation clause is satisfied at ; but it is satisfied whether or not the run K is there. L records the shape of the background, not the act. The no-holes premise makes every loop null-homologous in the ambient space. Any surviving first-homology class in the complement is therefore an obstruction created by removing K.
Figure 11.
Why the space must have no one-dimensional holes of its own. Schematic of Proposition 17(iii), where the space is and the annulus stands for the factor. A loop L around the hole is not null-homologous, so the separation clause is satisfied at ; but it is satisfied whether or not the run K is there. L records the shape of the background, not the act. The no-holes premise makes every loop null-homologous in the ambient space. Any surviving first-homology class in the complement is therefore an obstruction created by removing K.
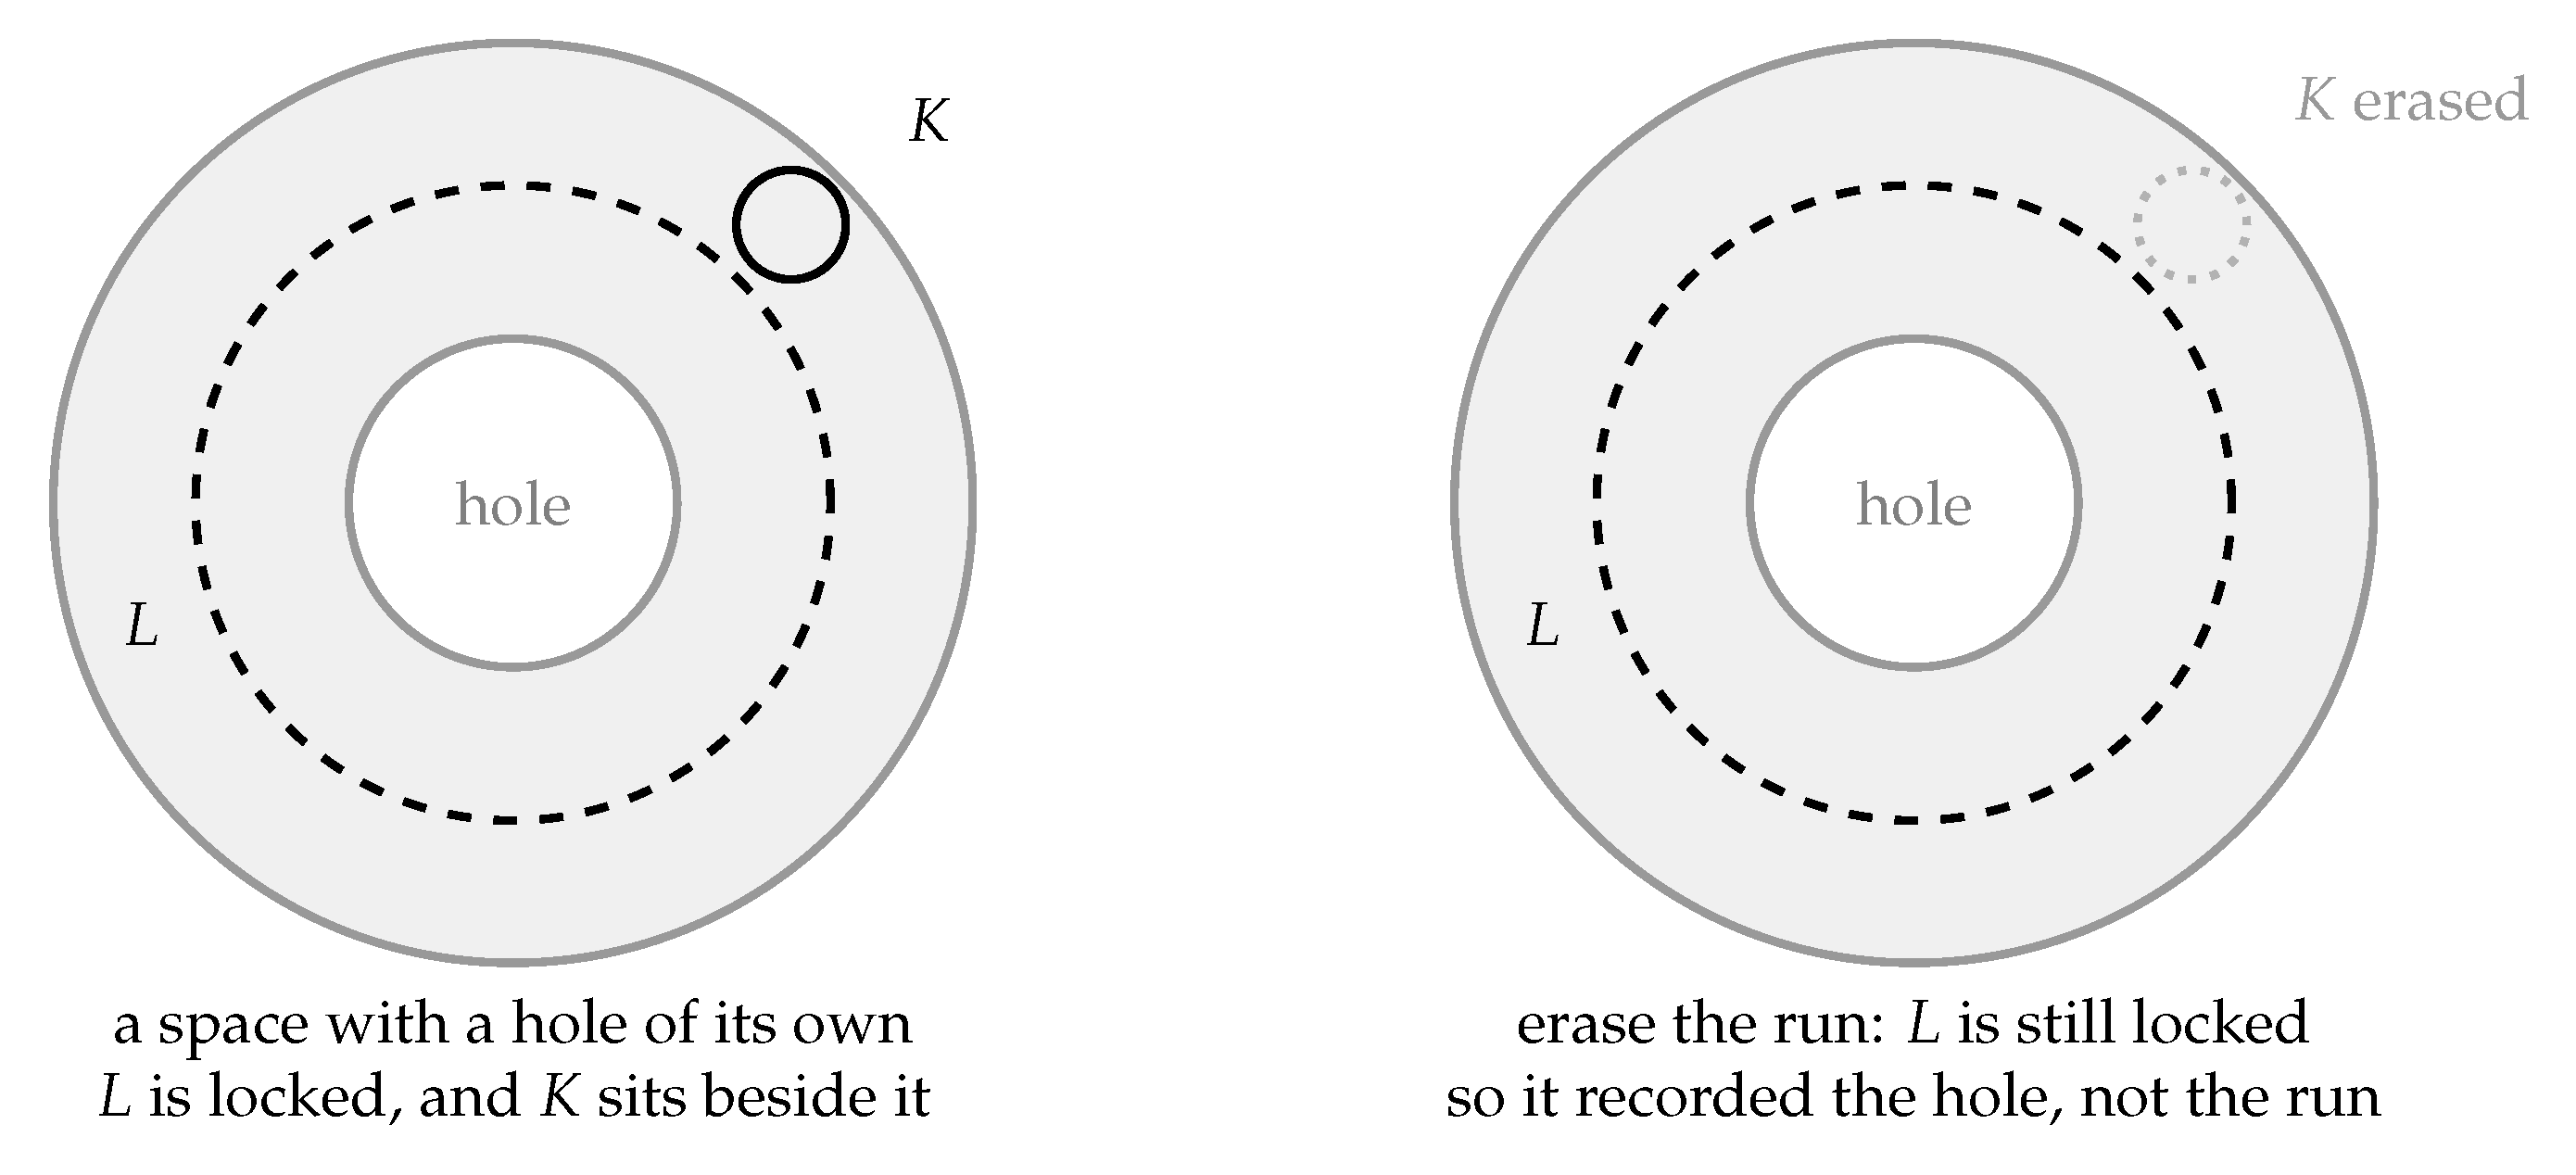
Parts (i) and (ii) have a common reading, drawn in Figure 10. The plane and the disk satisfy the requirement at because each has a marked exterior, the point at infinity or the boundary circle, and a loop around K is held in place by being between K and that exterior. One may interpret the exterior as additional background participating in this record. Filling it changes the complementary homology and removes the planar witness. These examples motivate closedness for the proposed record model and prove its sharpness for the stated requirement; they do not prove that every record carried by two objects requires a closed substrate.
Part (iii) says more than necessity. Without integral 1-acyclicity the requirement is satisfied at by every recognition cycle at once (Figure 11), the witnessing class being supplied by the ambient topology and never meeting the recognized locus. The clause is what makes the requirement a statement about the act: it removes every class in the tracked degree that the substrate carries on its own, so that a surviving class in the complement can only have come from the recognized locus. Read that way it carries the formal content of “the credit is distinguishable from the debit” rather than from the background.
Remark 17
(The acyclicity degree is the tracked degree). Axiom 3 names an integer, which looks like a third place where the chain chooses, alongside the dimension of the locus and the degree of the reading. It is not. The clause is consumed at exactly one point of the proof of Theorem 5, the right-hand term of the exact sequence above (3), and the degree of that term is the degree in which the complement is read; its vanishing is what makes the connecting map onto, hence what turns a class of the complement into a class of the pair, that is, into something the recognized locus carries. So the degree of the clause is fixed by the degree of the requirement, which Proposition 12 fixes in turn, and in the general-p counterfactual of Lemma 6 it moves with p for the same reason. One count does change along the way, and it should be said plainly: at general p the transposed hypothesis is a pair of vanishings, , while Axiom 3 at names one, the second being a theorem there rather than an assumption, since duality and universal coefficients derive from (Lemma 5). The transposed requirement with its substrate pair is therefore the requirement’s transpose, not literally the same axiom re-read, and Lemma 6 states the pair it consumes explicitly.
The matching cannot be relaxed. Imposing vanishing in a degree other than the one read leaves the requirement satisfiable by the background alone: has and by Künneth, so it meets a degree-two acyclicity demand while the requirement is read in degree one, and by Proposition 17(iii) it then admits with every recognition cycle at once. A mismatched degree does not weaken the conclusion, it deletes it.
Remark 18
(Connectedness and smoothness are not logically necessary). Connectedness enters no step of Theorem 6. A closed manifold has finitely many components, each open and closed, so the pair is the disjoint union of , where carries K, and of ; additivity gives , the absolute groups split as direct sums, and forces of every component to vanish, which is what Lemma 5 and the surface classification consume at and ; at a disjoint union of circles has . The clause is carried in the statements because Definition 2 supplies it and the duality theorems are quoted that way, but it is consumed at exactly one point, and that point is downstream of the dimension, upgrading Corollary 2 from a statement about the component carrying the locus to one about M. Smoothness of enters at one point, the tubular neighbourhood of (1), and (2) computes the same group on any closed orientable topological manifold. Both weakenings are carried out in Corollary 1.
So the substrate hypothesis reduces to two conditions that carry weight, closedness and integral 1-acyclicity, and both are sharp, closedness in each of its halves separately.
10. Where the Integer Enters
Changing a parameter and finding that D moves identifies a place where the integer is chosen; changing one and finding D unchanged identifies a place where it is not. Five parameters can be varied: two concern what is measured, two how it is measured, and one the regularity of the object measured. Figure 12 previews the outcome: two of the five move the answer, and those two are tied to each other by the requirement’s own wording, so there is one integer in the chain and it is the dimension of what a recognizer runs.
- P, recognized-locus dimension
- the dimension p of the locus the recognizer traverses, which Proposition 3 pins at 1. The perturbation is realized by one variation of the recognizer and one only, a process of dimension p; enlarging the transition structure leaves (Theorem 7).
- Q, tracked degree
- the degree q in which complement homology is required to be nontrivial. Axiom 4 does not set it: by Proposition 12 it is the dimension of what the recognizer runs, hence equal to p in every model. The axis is retained because it answers a definite question, what the chain would conclude if the complement were read in a degree no recognizer can present.
- C, coefficient ring
- the ring R in which homology is read, jointly with the matching form of the substrate hypothesis; the two are one parameter because the acyclicity clause exists only to feed the sequence in which the tracked homology sits.
- I, tracked invariant
- the functor expressing distinguishability: besides , the candidates are and . The linking homomorphism is not among them (Remark 21).
- E, regularity
- the regularity demanded of the recognized locus, weakened from a smooth tame embedded circle to an arbitrary topological one.
Least cost is not among these five, and neither is the single-valued record; both belong to the companion paper, where a process dimension other than one is in question, and Theorem 6 uses neither. Both are independent of the requirement and of the substrate axioms, dropping least cost admitting the five-dimensional model the companion paper exhibits, and the record axiom being consumed only inside its cost bounds, here it buys that a cost can be counted at all.

Table 2.
The five axes of the demand and what each perturbation does to the selected dimension (Theorems 8 and 9). Only the first two rows move the answer.
Table 2.
The five axes of the demand and what each perturbation does to the selected dimension (Theorems 8 and 9). Only the first two rows move the answer.
| Axis | Perturbation | Effect on D | Reason |
|---|---|---|---|
| P | , with the acyclicity clause adjusted to degrees | codimension count; selecting, and realized only by a process of dimension p | |
| Q | with , at , on a homology D-sphere substrate | codimension identity ; selecting, but unavailable: no recognizer presents a q-cycle | |
| C | commutative with , jointly in tracked homology and acyclicity | unchanged | duality available over R; |
| I | or | unchanged | Hurewicz; the tracked group is free of rank one |
| E | smooth tame arbitrary topological circle | unchanged | Čech–Alexander duality for compact subsets |
Remark 19
(What the selecting rows change, exactly). RowsPandQare counterfactual families rather than single-variable perturbations. RowPreplaces the recognizer by one whose process has dimension p, so that a pass sweeps a p-sphere; it moves the tracked degree with it, both witnesses being p-spheres (Proposition 12); and it replaces the acyclicity clause by . That last adjustment is necessary rather than convenient, since without it at satisfies the substrate axioms and the requirement while (Remark 11), and it is not a free hand, the degree being fixed by the degree the requirement reads (Remark 17). RowQholds and tightens the substrate clause to a homology D-sphere, which makes the exact sequence collapse in all degrees at once; at this costs nothing, the two substrate classes coinciding at (Remark 6). It also detaches the degree from the locus, which the ownership clause forbids, so the row measures a counterfactual about the requirement rather than a choice left open inside it. What is proved below is that these two families move the answer and the other three do not, not that the five are independent coordinates.
Remark 20
(The dimension-neutral detector). RowQhas a limiting reading under which it selects nothing. The normal sphere of the recognized circle, the boundary of a normal disk fibre, is an , and on a homology D-sphere substrate it generates in every dimension D by Alexander duality: read in the degree the codimension offers, the complement always has a nonzero class. A detector that works in every dimension detects nothing about the dimension. The requirement escapes this trap only because the tracked degree is fixed internally, by what a recognizer can run (Proposition 12), and not by the codimension of the locus; the identity has content precisely because q is forbidden to track D.
Theorem 8
(The selecting axes).
- (i)
- Axis P.Under the replacement described in Remark 19, the requirement holds if and only if ; in particular recovers and gives .
- (ii)
- Axis Q.Holding and tracking a degree q with on a homology D-sphere substrate, the requirement holds if and only if ; more generally for a recognized and a tracked degree q in that range it holds if and only if . So recovers and selects . The range restricts no counterfactual that matters: the identity with places in of itself, so every solution is inside the range, and what the range excludes is only and , at which the requirement fails for a circle in any case.
The two axes are not independent. By Proposition 12 the ownership clause forces in every model, both being the dimension of what a recognizer runs, so the family of counterfactuals a recognizer can inhabit is the single family ; the integer is located in one place, the value supplied by Axiom 1.
Proof. (i) is Lemma 6. The perturbation must be carried out homologically: by Proposition 6(ii) the homotopy reading is satisfied at for , so it obeys no such identity.
(ii) The argument of Lemma 6 runs at a general tracked degree, and the range is what lets it. On a homology D-sphere for , so for such q both and vanish and the segment
makes ∂ an isomorphism. With , Thom and excision as in Lemma 6 give , nonzero precisely when , that is or ; the second is excluded by , and at the first the group is . At this reads . The range is consumed here: at and the substrate’s own reduced homology no longer vanishes at both ends. A witness at is an unknotted , whose complement has while , in accordance with Theorem 5. □
Theorem 9
(The three parameters that leave unchanged). Assume Axioms 1, 2, 3 and the ownership clause of Axiom 4 with Proposition 3, with D free and , so that the witness is an embedded circle . The separation clause is deliberately not assumed, each item supplying a perturbed form of it; where an item also replaces a clause of the structural axioms, as item (i) replaces the acyclicity clause by its R-form, the replacement is in force instead. Item (iii) suspends the ownership clause as well, and must, a wild circle not being ambient isotopic to a realized trajectory; it is accordingly a strengthening of Theorem 5 rather than a variation of Axiom 4, establishing that the codimension count and not the regularity of the locus selects the dimension. Then each of the following perturbed requirements holds if and only if .
- (i)
- Axis C. for a commutative ring R with , with Axiom 3 replaced by .
- (ii)
- Axis I.Nonvanishing of , or of .
- (iii)
- Axis E. where K is any subspace homeomorphic to , with no tameness, local flatness or smoothness assumed.
Proof. (i) Repeat the proof of Theorem 5 over R. Each input is available: the Thom isomorphism for an orientable disk bundle ([14]), the long exact sequence, functorial in the coefficient module, and Poincaré duality on a closed connected orientable 3-manifold. At the hypothesis fails, since . At the surface classification gives , vanishing only at , so , and the Jordan curve theorem gives with free, whence by universal coefficients. At Lemma 5 over R gives , so the relative term survives and . At the relative term is . No hypothesis on R beyond is used, so rings with zero divisors such as are included; and since every R-homology D-sphere is R-1-acyclic, the familiar tightenings of the substrate clause are covered.
(ii) For this is Proposition 5(iii). For the passage from homology to cohomology is not a formal consequence of universal coefficients, a nonzero torsion group having vanishing into , so the cohomological form of a demand is in general strictly stronger. What is available is the computed value. Write ; by Theorem 5 and its proof, when and vanishes otherwise, while for and is free of rank one at . So in
the Ext term vanishes in every dimension, giving , which is at and 0 elsewhere. The cohomological form selects the same dimension, and it does so because the group it reads is free of rank one rather than by any general implication.
(iii) This is the clause about K in Corollary 1: the tubular neighbourhood is the one point at which the proof of Theorem 5 consumes tameness, and (2) computes the same relative group from compactness and local contractibility. It is the duality proof and not the transversality proof of Appendix A that survives here, the latter requiring K to be a smooth submanifold. This perturbation simplifies the hypotheses rather than complicating them: with topological witnesses admitted, the realized cycle is itself a witness, the ownership clause may be stated with literal equality of subspaces, and the corner-smoothing of Proposition 4(iii) becomes unnecessary. The body retains the smooth formulation, under which the tubular-neighbourhood proof is stated. □
Remark 21
(The linking number is a consequence, not a test; and higher homotopy is not a substitute). The linking homomorphism is the most vivid reading of the requirement and is deliberately absent from AxisI. An invariant can be tested in every dimension only if the question it answers can be posed there, and this one cannot: its defining count pairs a bounding 2-chain with a 1-cycle in complementary dimensions only when . Even there its well-definedness is a conclusion rather than a convention: the bounding chain is ambiguous by a 2-cycle, so the count is single-valued exactly when every 2-cycle meets K trivially, and vanishing of supplies that twice over, the probe bounding because its class dies and the ambiguity pairing to zero against the null-homologous K; the condition , here a consequence (Lemma 5), is a sufficient route to the same end and not a necessary one. And where a surrogate is posed at its domain is already trivial by Theorem 5, so it vanishes for want of anything to measure. A row recording that it selects would record the conclusion rather than test it; its place is downstream, in Corollary 2. Pairing complement classes with one another gives nothing either, and not merely by evaluating to zero: the mutual linking of two disjoint loops is not a function of their homology classes, two homologous copies of a loop clasping a second loop arbitrarily often, so no two-variable form on is defined for the axis to test; and on the representatives that generate the group the count vanishes besides, every class being carried by meridian circles disjoint from a given one.
The higher homotopy groups for are absent for a different reason: they detect higher-dimensional separation rather than distinguishability of the recognized loop, and by Proposition 6 the homotopy reading is not equivalent to the homological one even in the degree matching the locus. This is not AxisQ, which varies the degree in which ordinary homology is read and selects ; that perturbation is coherent, and what rules it out is not a mathematical obstruction but the ownership clause, a q-cycle with being something no recognizer can run.
10.1. Statement of the Location
The framework through the substrate axioms is dimension-agnostic: the binary factorization admits any , the completion clause aligns the substrate dimension with the primitive count without pinning it, and the acyclicity clause excludes and nothing else. So the structural layer narrows D to and no further.
The dimension is forced by two ingredients. Proposition 3 forces , because what a recognizer runs is a closed walk and covering dimension is preserved by embeddings; this is internal to the framework and independent of which cells the transition structure records. Theorem 5 then converts into , the classical computation that selects the integer being the cohomology of the circle, duality being background machinery uniform in p. The ownership clause belongs alongside these, being what takes the demand from to (Remark 11), and it carries both integers of the chain at once, the locus and the probe being the same kind of object because both are acts. The acyclicity degree is the third place an integer is named and names the same one, being consumed at the term of the exact sequence sitting in the tracked degree; mismatching it deletes the conclusion rather than weakening it. Perturbing the tracked degree away from the locus dimension shifts the answer to , but no recognizer inhabits that perturbation.
What is left is one integer, and it is not a feature of space. The chain reads where p is the number of parameters a pass runs on (Lemma 6), and Axiom 1 sets by making a pass a closed walk. The structure above that walk is free: a recognizer may record its commuting flips, their coherences, and every cell of its cube, and the answer is still three, because those cells are carried and not run (Theorem 7). One further stipulation carries dimensional weight, and only in the last step: the alignment , which converts the dimension the argument forces into a count of primitives and selects neither (Remark 4); on the constructed stage it is a theorem from two named recognitional premises, separation measured by acts and refinement moving no record (Lemma 1, Proposition 1).
The premises are few enough to list, each with what would refute it. Nothing is assumed that is not on the list.
- Axiom 1, binary factorization
- supplies D as a primitive count and, by making a pass a minimal covering walk, sets the process dimension at one. Refuted by a composite recognizer admitting no such factorization, or by a pass that is not a walk, the second being the perturbation the companion paper prices.
- Axiom 2, completion and alignment
- supplies the ambient manifold, one spatial direction per primitive, and the tameness of the realization. On the constructed stage these three are proved and closedness is imposed by the closing step of Proposition 1(iv) (Remark 8); the first two follow from the premises of Lemma 1 together with the linear-tally clause of Definition 3 (Proposition 1) and the third from the fact that an act is realized where its refinements go, whose cell is the straight segment between the act’s endpoints (Lemma 2, Proposition 2); the pairwise-distinct directions the tameness clause asks for are the independence of the primitives, and the local cone structure is the cost floor (Remark 7). Refuted by an alignment , under which the same proofs give .
- Axiom 3 and closedness
- the two substrate conditions that carry weight, each sharp: dropping acyclicity admits , and dropping either half of closedness, compactness on the plane or emptiness of boundary on the disk, admits , in each case with the recognizer’s own cycle as witness (Proposition 17). The other three clauses are implied or unused (Lemma 9, Remark 18).
- Axiom 4, the requirement
- takes the demand from to , and is a genuine input for the structural layer (Proposition 16). It is not a primitive of the account: the companion paper shows it equivalent, over the ledger and the reading of a record as an account kept against the act’s path, to the persistence of the completed act, whose statement carries no topological vocabulary; the dictionary there is the closing of the books, the cost of changing a record, and that reading, which the companion adopts as a premise. Refuted by a recognizer whose completed acts need not remain distinguishable from their reversals, which is a recognizer whose recognitions its own bookkeeping erases. Weakening it to non-contractibility selects no dimension (Proposition 6); weakening it to the separation clause alone gives only (Remark 11); the reading of its ownership clause, between a probe carried by its own recognizer and a probe some recognizer could carry, does not move the selection (Proposition 10).
The forcing of in Theorem 6 uses these four and nothing else. The companion paper compares process dimensions using a sequential record, additive tally pricing, spherical loci with same-process ownership, the corresponding ambient homology vanishings, and least cost . Its separate persistence equivalence uses a registration read as a phase account on the complement of a recognized trajectory; this domain restriction is not inferred from the aggregate ledger alone.
11. Downstream of three
Once the dimension is three, two further facts follow with no extra input: how long a complete run is, and what kind of space the recognizer lives in.
The length of a complete pass is a consequence of the dimension. By Axiom 1 the recognition quotient has states and by Lemma 3 a closed walk visiting every state has length at least , with the Gray code attaining the bound, so at the forced dimension a complete pass takes exactly eight steps and eight is sharp. The discipline of those steps is forced with the count: a complete pass of exactly eight steps has none to spare, so it visits each state once and flips exactly one coordinate per step, a Gray cycle. This is arithmetic on , not a further physical consequence, and no step of the forcing argument uses the value; minimality enters once, through Proposition 4, as Hamiltonicity, which fixes the length in terms of D rather than the reverse. The companion paper is where the count carries weight, as the eight against which the cost of a surface pass is compared.
A second consequence constrains the substrate. By Corollary 2 the admissible substrates are exactly the integral homology 3-spheres, so the recognizer inhabits a space with no homology of its own in the degrees that carry recognition, and the first homology of the designated complement is . Every integral first-homology class in that complement is determined by its linking number with the recognized locus. Complements of several loci can carry several independent such integers.
12. Related Work
The compatibility arguments [18,19,20,21] investigate dimensional restrictions from specified orbital, wave, or matter dynamics. Their conclusions depend on which laws are continued to other dimensions; the present theorem instead uses a specified complementary-homology requirement. Compactification and dynamical compactification programmes [22,23,24,25,26,27] study the number of large dimensions within higher-dimensional models, with geometric and dynamical premises of their own. The present construction assumes no higher-dimensional ambient space. These different premises and explanatory targets do not by themselves rank the approaches. The singularity results [28,29,30,31] establish that particular low dimensions are exceptional without selecting three among them. Closest in spirit are constraint-intersection arguments, which impose several demands and intersect the admissible sets; such an argument says which dimension survives a list of demands, whereas Section 10 asks which clause of a single selecting demand carries the integer.
One point of contact is exact, being the closest that literature comes to a selection. Take the flux-conserving force law with ; a circular orbit of a central force is stable exactly when [32], and here
negative if and only if . That is Ehrenfest’s bound in one line, and it is an upper bound only, admitting and alike, so closing it to a single value takes a second demand from outside the calculation. Axiom 4 needs no dynamical law and no notion of orbit; its second demand is closedness, which Proposition 17 prices exactly.
Whitrow [33] and Büchel [34] argued from the stability of orbits and the propagation of waves to three as the dimension in which physics as we know it is possible; theirs are arguments about the laws, and they fall inside the compatibility class above. Callender [35] reviewed this whole line and raised the objection every such argument must answer: given that three has many properties no other integer has, finding one of them is not yet an explanation unless the property is demanded for a reason that does not already know the answer. The present argument meets that objection where it stands. The demand is stated about recognition, not about space, and the paper locates the exact clause of the demand that carries the integer (Section 10) and proves each property of the space it uses to be sharp (Section 9.2). Whether the demand is more than a restatement of “two loops lock” is the question the companion paper takes up. The closest prior work in method is Müller and Masanes [36], who derive three from information-theoretic postulates about a single quantum bit; that argument is about the state space of the smallest quantum system and its rotations, this one about the record of the smallest completed act, and the two select three from different objects. Dakić and Brukner [37] ask why the dimension of the state space of an elementary system should agree with the dimension of the space the laboratory sits in, and answer with a closeness condition tying the two; that is the alignment question of Remark 4, asked there of quantum theory and here of a recognizer’s primitives. The one prior argument that reaches three through the same topological fact as this paper is that of Berera, Buniy, Kephart, Päs and Rosa [38], who take the early vacuum to be a network of knotted and linked flux tubes and observe that such a network is topologically stable only in three space dimensions. There the linked loops are field configurations whose stability drives inflation; here they are the run and its record, with no field and no dynamics, and the paper says which properties of the space the fact consumes and proves each sharp.
On the mathematical side nothing in Section 5 is new, and the paper does not present it as new. That two circles link only in three dimensions is Gauss’s observation made precise by Alexander duality [7]; that the linking number is the complete degree-one invariant of a circle’s complement in a homology 3-sphere is a standard consequence of the same duality; and the codimension count is the general position principle every topologist learns first. What the paper adds is on the other side of the equals sign: a statement about recognition, that the states of a system with D independent distinctions form a cube, that a shortest complete run is a circle, and that keeping the completed run is the same as a locked pair, with an audit of exactly which properties of the space each step consumes (Section 10) and a proof that each is sharp (Section 9.2). The companion paper proves the persistence equivalence under a ledger execution rule and an explicit phase-account domain restriction. The contribution is the translation and its sharpness, not the topology.
13. Open Problems
13.0.0.1. The Substrate Axioms
The refinement-limit construction of Proposition 1 realizes the stage as the completion of the ledger’s records, with dimension, 1-acyclicity, and the tameness of the realization (Proposition 2) all proved. What it does not supply is generality: the theorems here quantify over the whole axiomatic class, which the sharpness results of Section 9.2 need, and for a substrate handed over without the refinement data the clauses of Definition 2 remain hypotheses about it. A categorical route would realize the quotient as the 0-skeleton of a simplicial set whose realization is a 1-acyclic closed orientable D-manifold, for any such substrate. It needs additional hypotheses.
13.0.0.2. A Dimension-Dependent Recognition Operation
The chain splits the dimensional load between Proposition 3 and Theorem 5. A chain without the second step would need a recognition operation whose well-formedness is itself dimension-dependent, and none is available here: the binary factorization is dimension-agnostic, the substrate axioms admit models in every , and Proposition 3 constrains the locus rather than the ambient space. The persistence demand of the companion paper is a statement about recognition whose satisfiability depends on the dimension, but it selects through Theorem 5, not in place of it. Exhibiting an operation that selects without the codimension count, or proving that none exists, remains open.
Author Contributions
Conceptualization, J.W.; methodology, J.W. and S.P.-G.; validation, S.P.-G., and J.W.; formal analysis, S.P.-G., and J.W.; investigation, S.P.-G. and J.W.; writing—original draft preparation, J.W.; writing—review and editing, S.P.-G. and J.W. All authors have read and agreed to the published version of the manuscript.
Funding
This research received no external funding.
Data Availability Statement
The original contributions presented in this study are included in the article. Further inquiries can be directed to the corresponding author.
Conflicts of Interest
The authors declare no conflicts of interest.
Appendix A. An Intersection-Theoretic Proof of the Codimension Theorem
Section 5 routes the codimension count through duality. This appendix gives the count directly, by general position, which makes visible why is where linking lives: below it the embedding is too constrained, above it a bounding surface can be pushed off the curve. The hypotheses and conclusion are identical. The case still uses Poincaré duality, through Lemma 5; everything else is transversality, the Jordan curve theorem, and Hurewicz.
Lemma A1
(Codimension theorem, intersection-theoretic proof). Let be a closed connected orientable smooth D-manifold with and let be a smooth tame embedding of . Then if and only if .
Proof.
Case . Vacuous, as before.
Case . The classification of closed connected orientable surfaces ([16]) with the hypothesis forces , and the Jordan curve theorem ([7]) gives two path components with vanishing for .
Case . By Lemma 5, is an integral homology 3-sphere. Pick and a small smooth embedded 2-disk transverse to K meeting it only at x; its boundary m is the meridian. The linking homomorphism is well defined by the construction in the proof of Proposition 5, and because the meridian disk meets K once transversally, so in .
Case . Let L be a loop in ; since every class of is represented by a loop ([7]), it suffices to show . As , the class of L lies in the kernel of the Hurewicz map, the commutator subgroup, so L is based-homotopic in to . The compact orientable surface of genus g with one boundary circle is homotopy equivalent to a wedge of circles with free fundamental group on and boundary word , so sending , gives a map whose boundary restriction is based-homotopic to L; gluing a collar to carry that homotopy gives with , and for one reads . By smooth approximation rel boundary and transversality ([13]) take smooth and transverse to K, whereupon is a submanifold of dimension , hence empty. So maps into , and is the image of the boundary class under ; the first map already kills it, the boundary word being a product of commutators and the abelianization of its fundamental group. □
The three cases are the codimension count in geometric form: below three the embedding either has no room or separates the substrate into acyclic pieces; at three the recognized circle admits a meridian with linking number one; above three a bounding surface of dimension 2 and a curve of dimension 1 have , so a generic perturbation makes them disjoint. That is the whole of what “linking is a codimension-2 phenomenon” means, and it is what the duality proof packages.
References
- Pardo-Guerra, S.; Thapa, A.; Simons, M.; Washburn, J. Coherent comparison as information cost: axiomatic foundations for discrete ledger dynamics. Foundations 2026, 6(2), 17. [Google Scholar] [CrossRef]
- Pardo-Guerra, S.; Washburn, J. The process dimension of recognition: arity, cost, and the persistence of the completed act. Companion paper, 2026. [Google Scholar]
- Kirby, R. C.; Siebenmann, L. C. Foundational Essays on Topological Manifolds, Smoothings, and Triangulations . In Annals of Mathematics Studies; Princeton University Press, 1977; p. 88. [Google Scholar] [CrossRef]
- Bourbaki, N. General Topology, Chapters 1–4. In Elements of Mathematics; Springer: Berlin, 1995; Volume Ch. II §3. [Google Scholar]
- Engelking, R. Dimension Theory . In North-Holland Mathematical Library; North-Holland: Amsterdam, 1978; p. 19. [Google Scholar]
- Falconer, K. Fractal Geometry: Mathematical Foundations and Applications, 3rd edition; Wiley: Chichester, 2014. [Google Scholar]
- Hatcher, A. Algebraic Topology; Cambridge University Press, 2002. [Google Scholar]
- Fox, R. H.; Artin, E. Some wild cells and spheres in three-dimensional space. Ann. Math. (2) 49(4), 979–990, 1948. [CrossRef]
- Rourke, C. P.; Sanderson, B. J. Introduction to Piecewise-Linear Topology . In Ergebnisse der Mathematik und ihrer Grenzgebiete 69; Springer: Berlin, 1972. [Google Scholar] [CrossRef]
- Gray, F. Pulse Code Communication . U.S. Patent 2,632,058, 17 March 1953. [Google Scholar]
- Knuth, D. E. The Art of Computer Programming . In A: Combinatorial Algorithms, Part 1; Addison-Wesley, 2011; Vol. 4. [Google Scholar]
- Moise, E. E. Geometric Topology in Dimensions 2 and 3 . In Graduate Texts in Mathematics; Springer: New York, 1977; p. 47. [Google Scholar] [CrossRef]
- Hirsch, M. W. Differential Topology . In Graduate Texts in Mathematics; Springer: New York, 1976; p. 33. [Google Scholar] [CrossRef]
- Bredon, G. E. Topology and Geometry . In Graduate Texts in Mathematics 139; Springer: New York, 1993. [Google Scholar] [CrossRef]
- Spanier, E. H. Algebraic Topology; McGraw-Hill, 1966. [Google Scholar]
- Massey, W. S. A Basic Course in Algebraic Topology . In Graduate Texts in Mathematics; Springer: New York, 1991; p. 127. [Google Scholar] [CrossRef]
- Milnor, J. W. Topology from the Differentiable Viewpoint; University Press of Virginia: Charlottesville, 1965. [Google Scholar]
- Ehrenfest, P. In what way does it become manifest in the fundamental laws of physics that space has three dimensions? Proc. Amst. Acad. 1917, 20, 200–209. [Google Scholar]
- Tegmark, M. On the dimensionality of spacetime. Class. Quantum Gravity 1997, 14(4), L69–L75. [Google Scholar] [CrossRef]
- Caruso, F.; Moreira Xavier, R. On the physical problem of spatial dimensions: an alternative procedure to stability arguments. Fundam. Sci. 1987, 8(1), 73–91. [Google Scholar]
- Barrow, J. D.; Tipler, F. J. The Anthropic Cosmological Principle; Oxford University Press: New York, 1986. [Google Scholar]
- Kaluza, T. Zum Unitätsproblem der Physik. Sitzungsber. Preuss. Akad. Wiss. Berl. 1921, 966–972. [Google Scholar]
- Klein, O. Quantentheorie und fünfdimensionale Relativitätstheorie. Z. Phys. 37, 895–906, 1926. [CrossRef]
- Green, M. B.; Schwarz, J. H.; Witten, E. Superstring Theory . In Introduction; Cambridge University Press, 1987; Vol. 1. [Google Scholar]
- Polchinski, J. String Theory . In An Introduction to the Bosonic String; Cambridge University Press, 1998; Vol. 1. [Google Scholar]
- Brandenberger, R. H.; Vafa, C. Superstrings in the early universe. Nucl. Phys. B 1989, 316(2), 391–410. [Google Scholar] [CrossRef]
- Karch, A.; Randall, L. Relaxing to three dimensions. Phys. Rev. Lett. 2005, 95(16), 161601. [Google Scholar] [CrossRef] [PubMed]
- Freedman, M. H. The topology of four-dimensional manifolds. J. Differ. Geom. 1982, 17(3), 357–453. [Google Scholar] [CrossRef]
- Donaldson, S. K. An application of gauge theory to four-dimensional topology. J. Differ. Geom. 1983, 18(2), 279–315. [Google Scholar] [CrossRef]
- Taubes, C. H. Gauge theory on asymptotically periodic 4-manifolds. J. Differ. Geom. 1987, 25(3), 363–430. [Google Scholar] [CrossRef]
- Milnor, J. W. On manifolds homeomorphic to the 7-sphere. Ann. Math. (2) 1956, 64(2), 399–405. [Google Scholar] [CrossRef]
- Goldstein, H.; Poole, C. P.; Safko, J. L. Classical Mechanics, 3rd edition; Addison-Wesley: San Francisco, 2002; p. §3.6. [Google Scholar]
- Whitrow, G. J. Why physical space has three dimensions. Br. J. Philos. Sci. 1955, 6(21), 13–31. [Google Scholar] [CrossRef]
- Büchel, W. Why is space three-dimensional? Based on “Warum hat der Raum drei Dimensionen?”. In Physikalische Blätter;American Journal of Physics; Freeman, I. M., Translator; 1963; Volume 19 37, 12, p. 547–549 1222–1224. [Google Scholar] [CrossRef]
- Callender, C. Answers in search of a question: `proofs’ of the tri-dimensionality of space. Stud. Hist. Philos. Mod. Phys. 2005, 36(1), 113–136. [Google Scholar] [CrossRef]
- Müller, M. P.; Masanes, L. Three-dimensionality of space and the quantum bit: an information-theoretic approach. New J. Phys. 2013, 15, 053040. [Google Scholar] [CrossRef]
- Dakić, B.; Brukner, Č. The classical limit of a physical theory and the dimensionality of space. In Quantum Theory: Informational Foundations and Foils, Fundamental Theories of Physics; Chiribella, G., Spekkens, R. W., Eds.; Springer: Dordrecht, 2016; Volume 181, pp. pages 249–282. [Google Scholar] [CrossRef]
- Berera, A.; Buniy, R. V.; Kephart, T. W.; Päs, H.; Rosa, J. G. Knotty inflation and the dimensionality of spacetime. Eur. Phys. J. C 2017, 77(10), 682. [Google Scholar] [CrossRef] [PubMed]
Figure 4.
The stage the data constructs, drawn at . The level-n records hold the dyadic tallies , and the separation the acts force places them as the dyadic points of the solid cube (Lemma 1); a refinement step doubles the resolution while moving no record (Definition 3). The countable union of finite-level sites is dense, so the cube is its metric completion , unique up to an isometry fixing those sites (Proposition 1(i)); its covering and Hausdorff dimensions are exactly D (ii); every cycle posted on it bounds (iii); and its compactified interior is (iv). The two arrows are of different kinds. The first is forced: the completion of the sites is unique. The second is the closing of the stage, the step the space premise (Axiom 2) asks for: the boundary of the solid cube is discarded and one point is added at infinity. Section 7 shows why the stage must be closed: left open, it admits a false record (Figure 10). At the stage is the solid 3-cube and the compactified interior is .
Figure 4.
The stage the data constructs, drawn at . The level-n records hold the dyadic tallies , and the separation the acts force places them as the dyadic points of the solid cube (Lemma 1); a refinement step doubles the resolution while moving no record (Definition 3). The countable union of finite-level sites is dense, so the cube is its metric completion , unique up to an isometry fixing those sites (Proposition 1(i)); its covering and Hausdorff dimensions are exactly D (ii); every cycle posted on it bounds (iii); and its compactified interior is (iv). The two arrows are of different kinds. The first is forced: the completion of the sites is unique. The second is the closing of the stage, the step the space premise (Axiom 2) asks for: the boundary of the solid cube is discarded and one point is added at infinity. Section 7 shows why the stage must be closed: left open, it admits a false record (Figure 10). At the stage is the solid 3-cube and the compactified interior is .
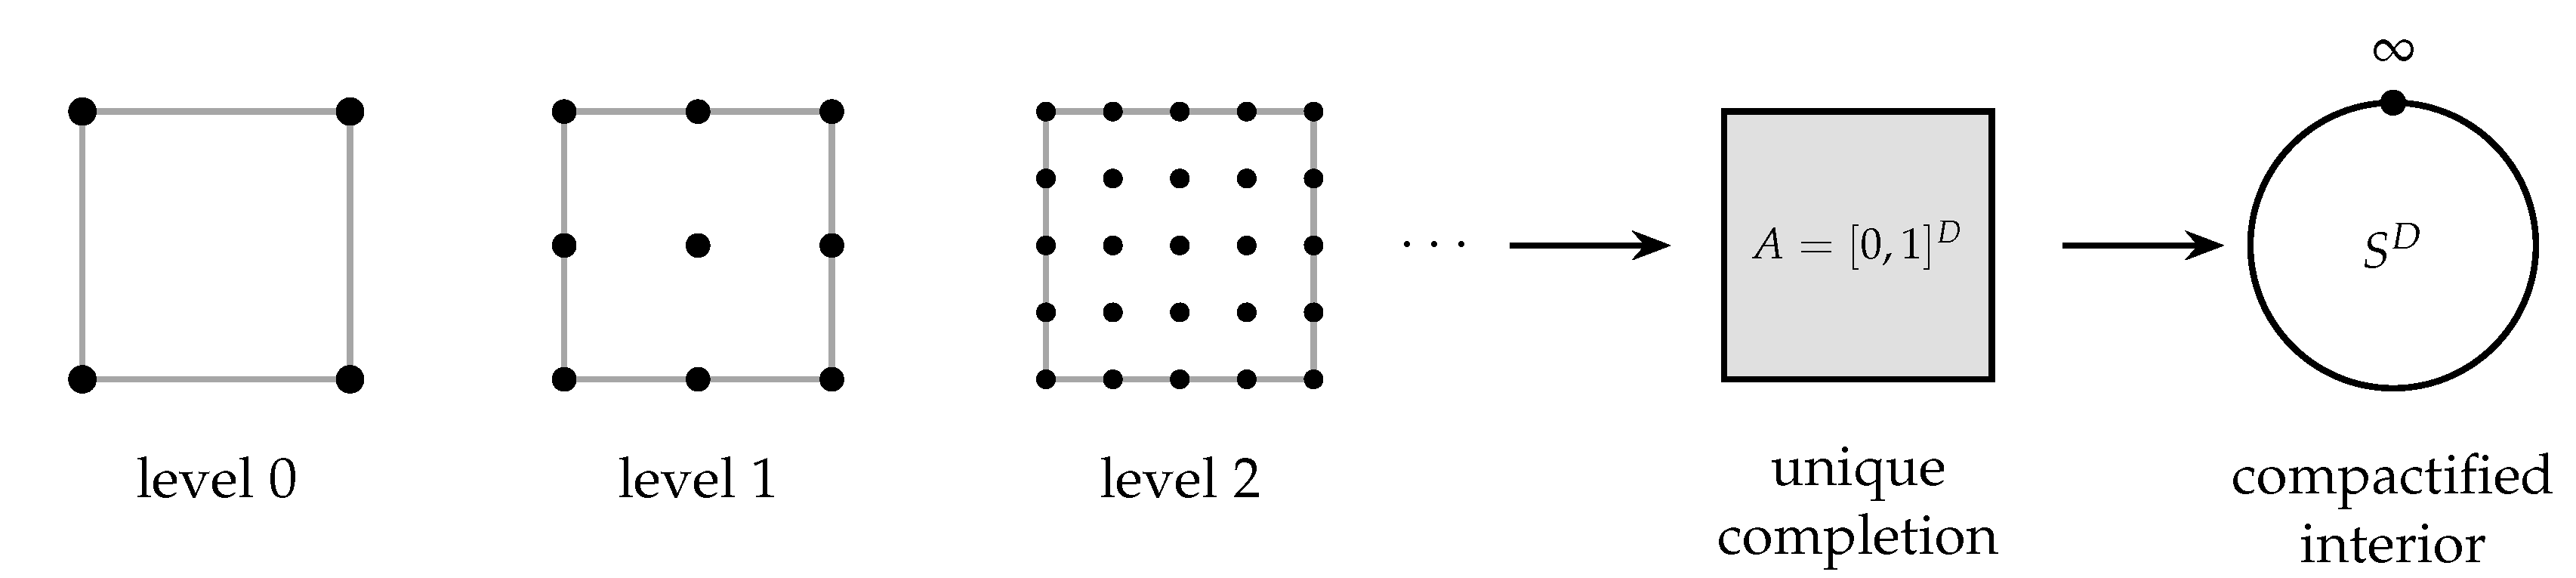
Figure 5.
What the minimality clause rules out. Left: the shortest complete walk on the 3-cube visits each corner once and its image is a circle (Lemma 3, Proposition 4). Middle: a complete walk that revisits corners (circled) sweeps a path that meets itself; its image is not a circle. Right: a walk that travels every edge sweeps the whole graph, whose first Betti number is 5. The requirement in Section 4 is stated about the recognizer’s shortest complete run, so the locus it names is a circle.
Figure 5.
What the minimality clause rules out. Left: the shortest complete walk on the 3-cube visits each corner once and its image is a circle (Lemma 3, Proposition 4). Middle: a complete walk that revisits corners (circled) sweeps a path that meets itself; its image is not a circle. Right: a walk that travels every edge sweeps the whole graph, whose first Betti number is 5. The requirement in Section 4 is stated about the recognizer’s shortest complete run, so the locus it names is a circle.
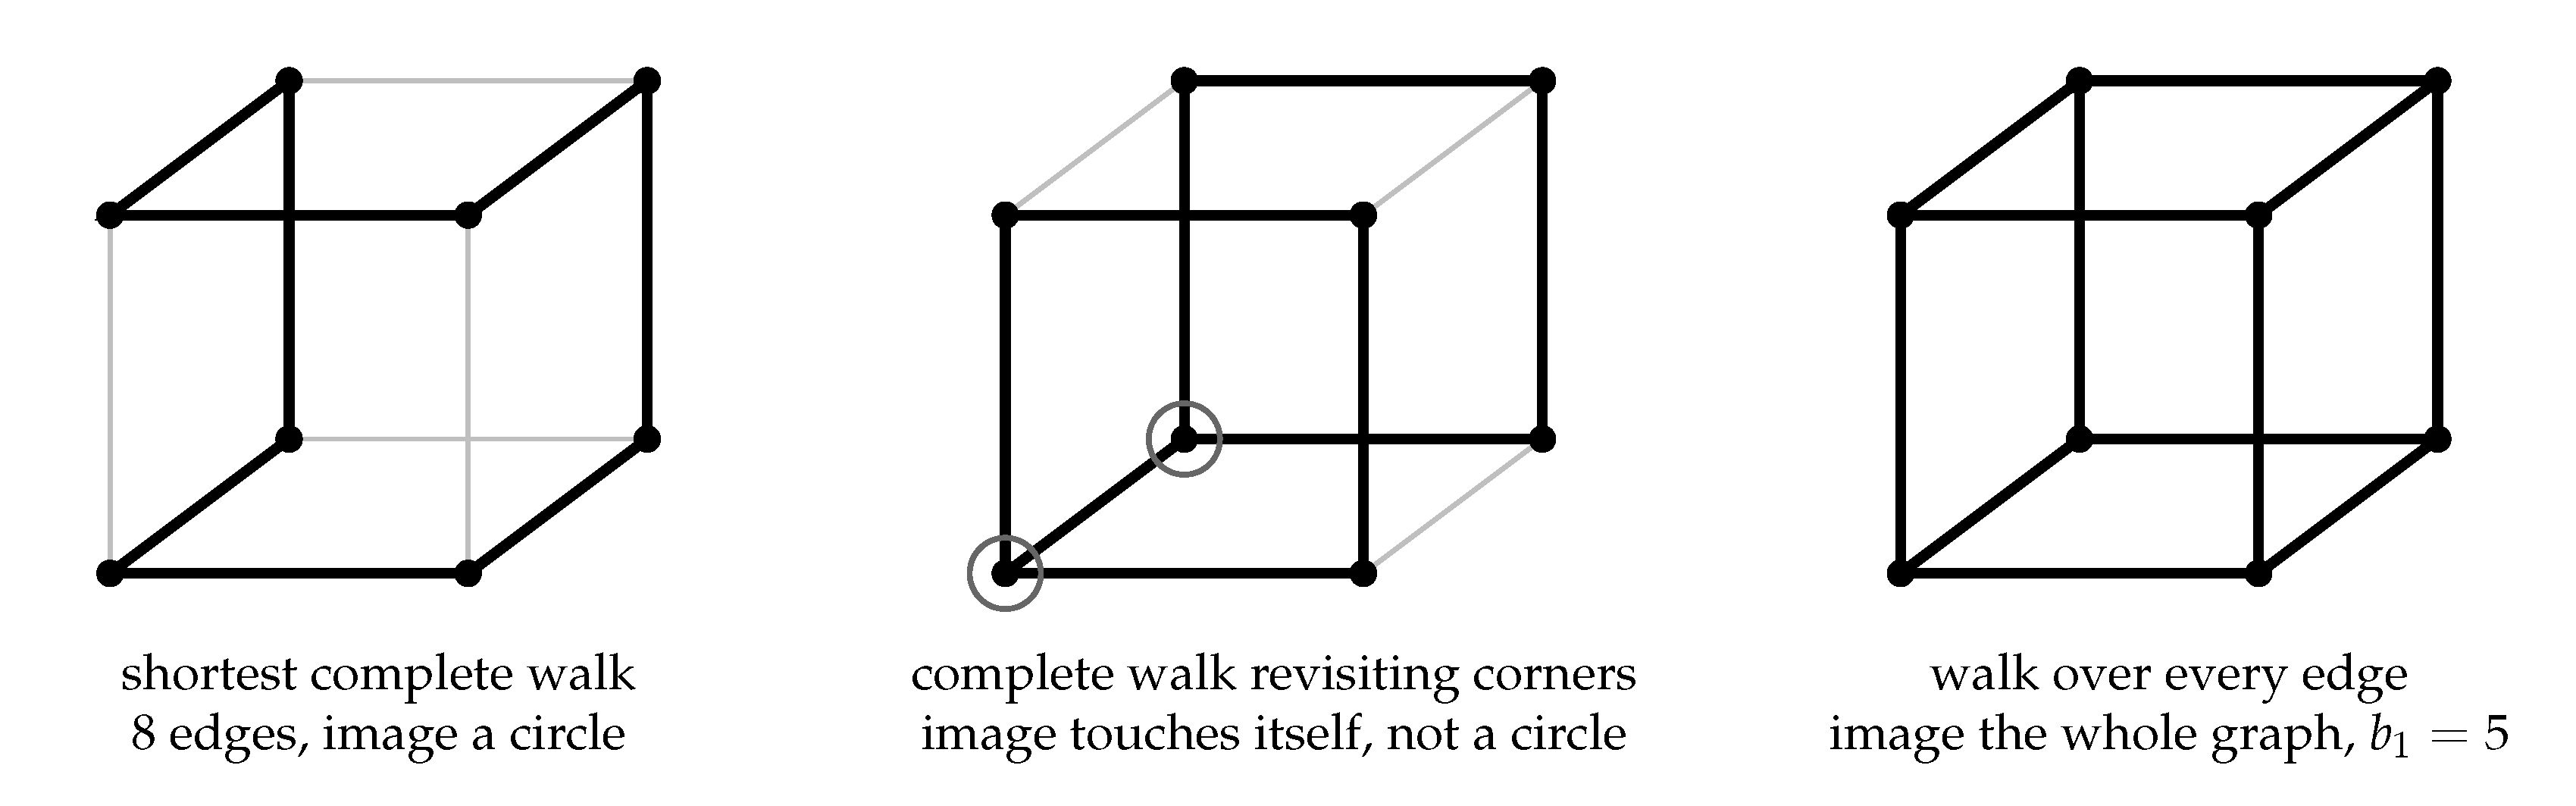
Figure 6.
Why the record is not a second run on the same cube. Any two complete runs on one embedded cube pass through all eight corners, so they meet, and a loop cannot be locked to a loop it touches. The record L is therefore the path of some recognizer the space admits, placed away from K (Definition 6). The requirement quantifies over what the space could run, not over the one recognizer doing the demanding; Proposition 10 shows that every reading of “could run” between these two extremes selects the same dimension.
Figure 6.
Why the record is not a second run on the same cube. Any two complete runs on one embedded cube pass through all eight corners, so they meet, and a loop cannot be locked to a loop it touches. The record L is therefore the path of some recognizer the space admits, placed away from K (Definition 6). The requirement quantifies over what the space could run, not over the one recognizer doing the demanding; Proposition 10 shows that every reading of “could run” between these two extremes selects the same dimension.
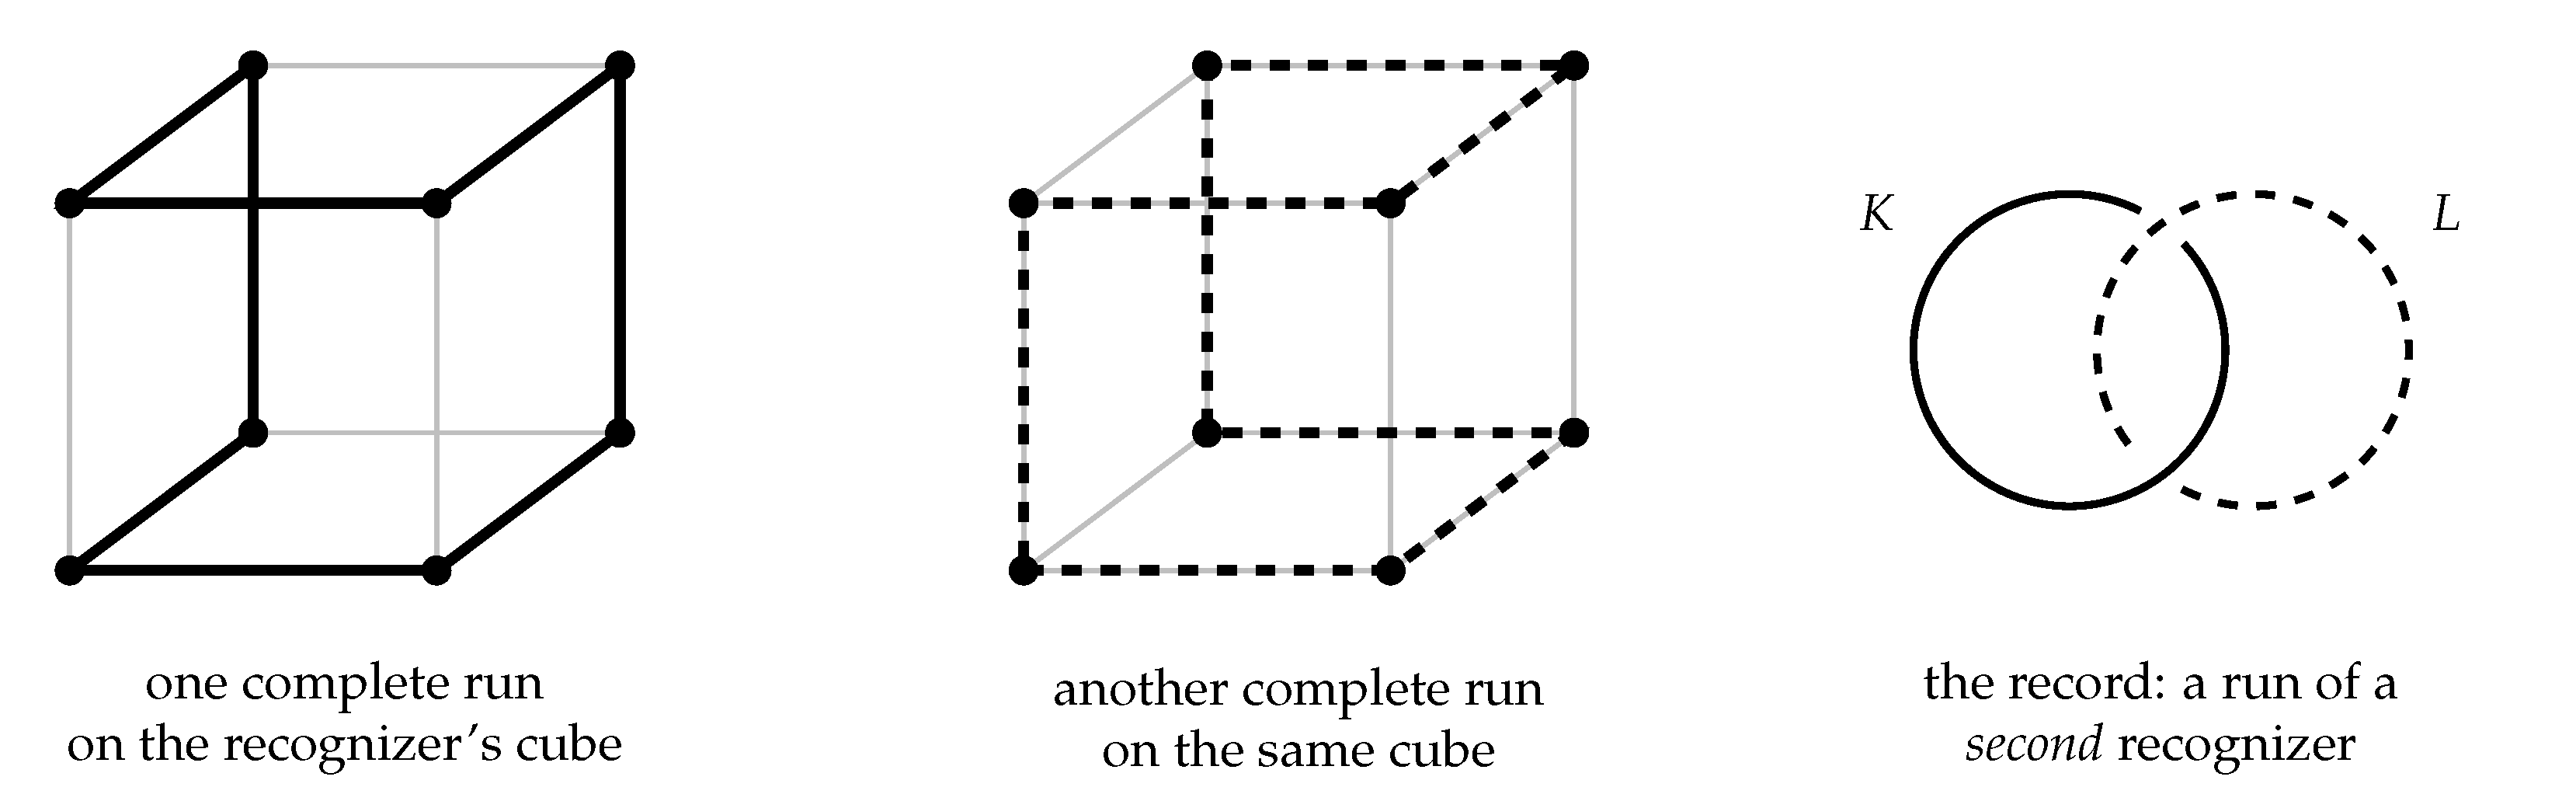
Figure 9.
The whole argument. Grey boxes are the four premises; white boxes are the three facts proved from them; the heavy box is the conclusion. The requirement is the only premise that fails in some dimension, and it is what carries the number (Proposition 16).
Figure 9.
The whole argument. Grey boxes are the four premises; white boxes are the three facts proved from them; the heavy box is the conclusion. The requirement is the only premise that fails in some dimension, and it is what carries the number (Proposition 16).
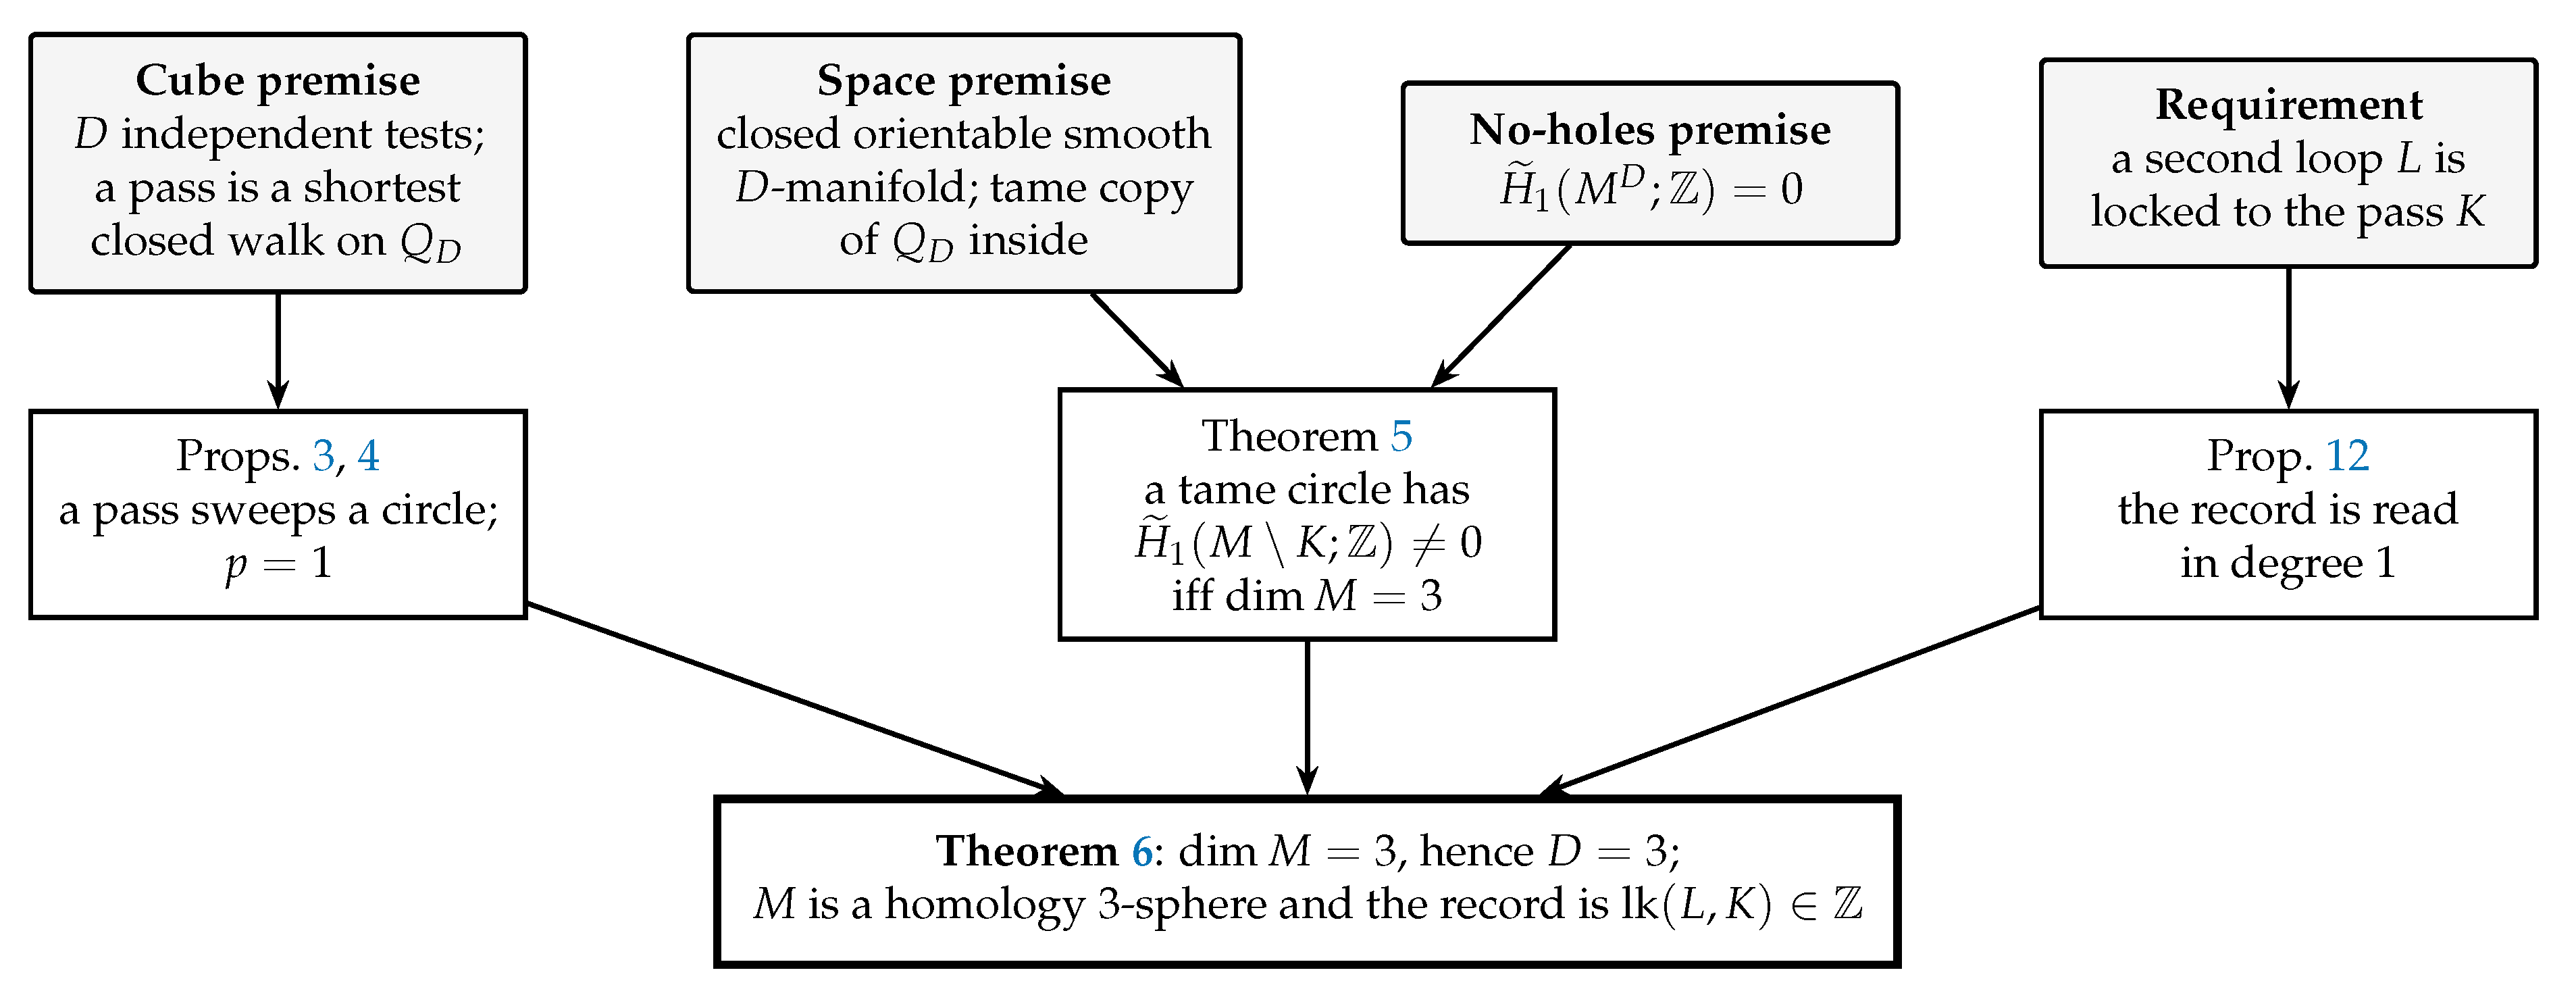
Figure 10.
Why the space must be closed. Left: in the plane, a loop L drawn around K cannot be shrunk without crossing K, so the plane satisfies the requirement at (Proposition 17(i)). But what keeps L in place is the point at infinity, marked ∞: the plane has an outside, and “L is between K and the outside” is a fact about three objects, not two. Right: close the plane to a sphere by adding that point, and L slides over the back and shrinks to nothing away from K. On the complementary first-homology record vanishes. The disk shows the same thing with the boundary circle in the role of the marked point (Proposition 17(ii)).
Figure 10.
Why the space must be closed. Left: in the plane, a loop L drawn around K cannot be shrunk without crossing K, so the plane satisfies the requirement at (Proposition 17(i)). But what keeps L in place is the point at infinity, marked ∞: the plane has an outside, and “L is between K and the outside” is a fact about three objects, not two. Right: close the plane to a sphere by adding that point, and L slides over the back and shrinks to nothing away from K. On the complementary first-homology record vanishes. The disk shows the same thing with the boundary circle in the role of the marked point (Proposition 17(ii)).
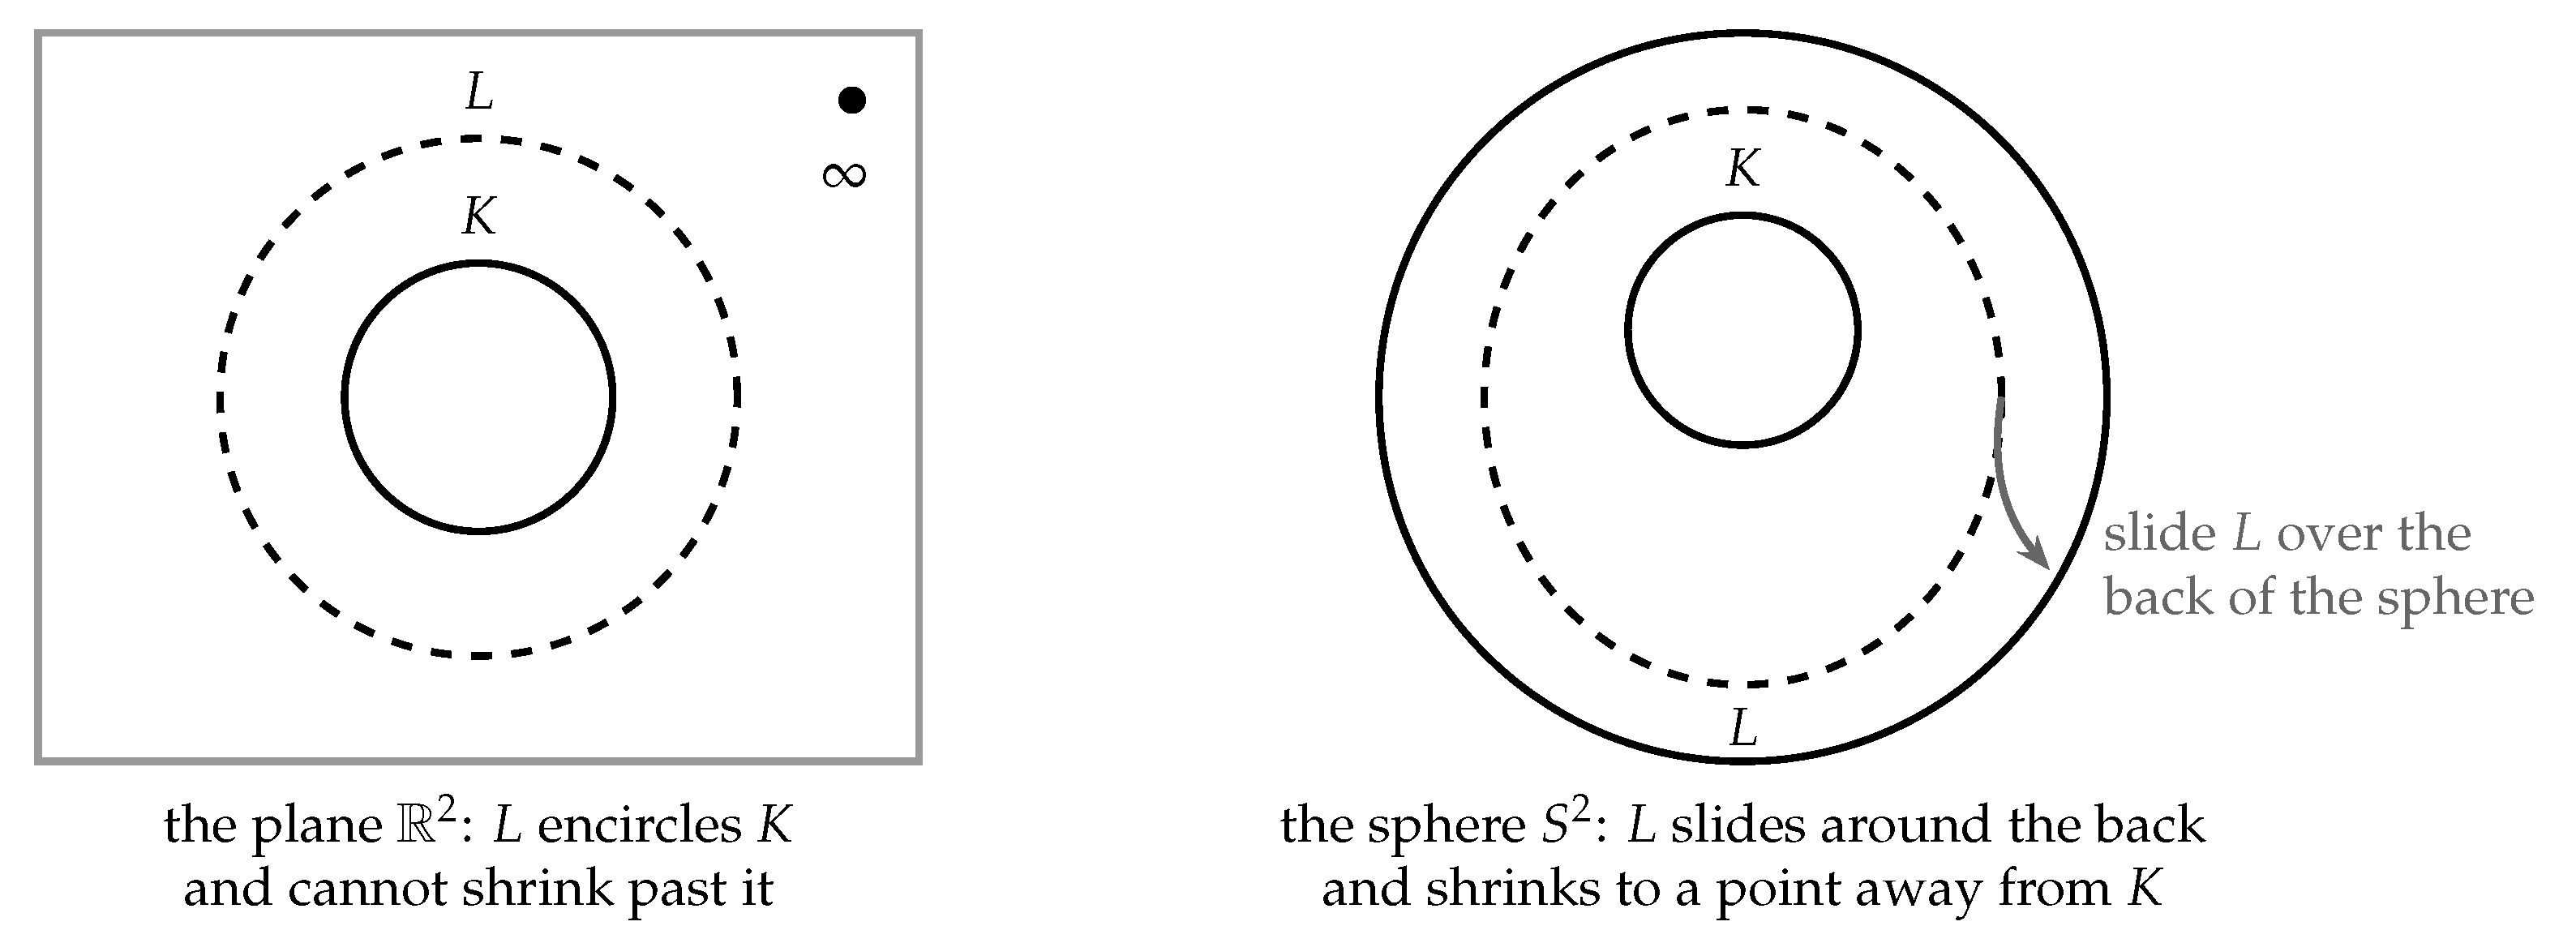
Figure 12.
The five parameters of the demand (Theorems 8 and 9). Only the dimension of the swept locus and the degree in which the record is read move the conclusion, and the requirement’s ownership clause forces them equal (Proposition 12).
Figure 12.
The five parameters of the demand (Theorems 8 and 9). Only the dimension of the swept locus and the degree in which the record is read move the conclusion, and the requirement’s ownership clause forces them equal (Proposition 12).
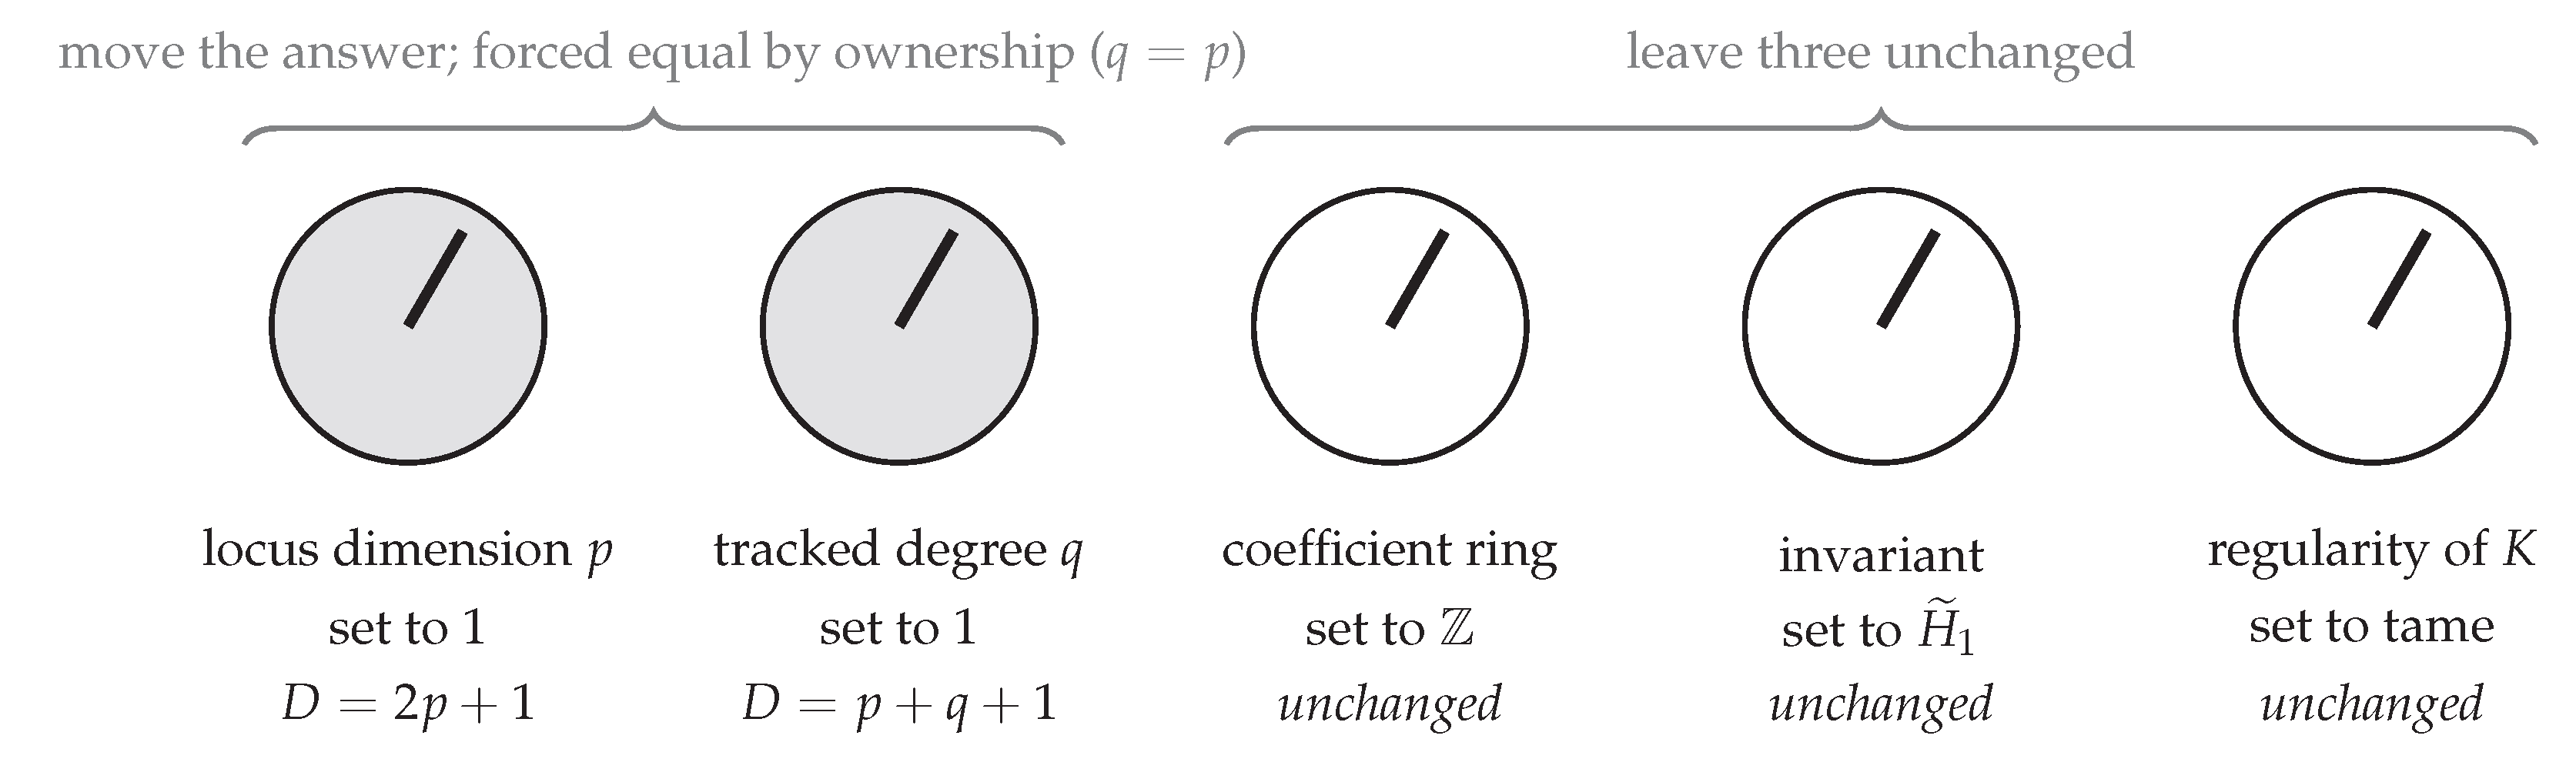
Table 1.
Words used in this paper.
| Word | Mathematical object | Plain gloss |
|---|---|---|
| recognizer | a map from a set C of configurations | a system that tells configurations apart by D yes-or-no tests |
| primitive | one coordinate | one of the yes-or-no tests |
| state | a point of ; a vertex of the cube graph | one full pattern of answers |
| entry | one edge of , traversed once | one elementary act: one answer flips |
| completed act, pass | a closed walk in visiting every vertex, of minimal length | a full run through all the states, back to the start |
| recognized locus | the image of the pass in the substrate; a circle K | the path the run sweeps |
| substrate | a closed connected orientable smooth D-manifold containing a tame copy of | the space the states sit in |
| probe, record | a second loop that some recognizer could run | the loop that registers the run |
| the requirement | in | L is locked to K; the run is kept |
| linking number | how many times L winds around K |
Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license (http://creativecommons.org/licenses/by/4.0/).
Copyright: This open access article is published under a Creative Commons CC BY 4.0 license, which permit the free download, distribution, and reuse, provided that the author and preprint are cited in any reuse.