

Submitted:
04 September 2026
Posted:
04 September 2026
You are already at the latest version
Abstract
Friction modeling in finite element simulations of cold forging is commonly based on analytical formulations ranging from the Coulomb and shear friction laws to advanced models incorporating multiple tribological state variables. However, fundamentally different friction formulations are difficult to compare directly because their parameters refer to different physical quantities. This work presents a systematic benchmark of conventional, extended analytical and machine-learning-based friction models under identical tribological boundary conditions. Sliding compression tests covering a wide range of contact conditions are combined with finite element simulations to establish a time-resolved database of local tribological state variables. To enable a physically consistent and model-independent comparison, all models are evaluated on the common level of frictional shear stress. Conventional friction models exhibit pronounced load-dependent residual structures, while extended analytical formulations reduce but do not eliminate systematic deviations. The neural-network-based formulations introduced in this study, predicting either the coefficient of friction, the friction factor or the frictional shear stress directly, achieve the highest predictive accuracy, with nMAE values of 0.85–0.96% relative to the mean flow stress. Despite their different internal parameterizations, these models converge towards highly similar frictional shear stress predictions. Explainability analyses further show that similar predictive behavior on the stress level is achieved through formulation-dependent relationships on the parameter level. The results therefore reveal a distinction between stress-level convergence and parameter-level divergence in data-driven friction modeling.
Keywords:
cold forging
; tribology
; friction modeling
; explainable AI
1. Introduction
Cold forging is widely employed in industrial production, where numerical simulation has become an essential tool for process design and optimization [2,3,4]. Among the various modeling aspects, friction at the tool–workpiece interface plays a decisive role, as it directly affects material flow and process stability [5]. In industrial practice, zinc phosphate-based lubrication systems are still predominantly used despite their ecological impact and economic cost. Against this background, environmentally benign alternatives have gained increasing attention [6]. These lubricants, however, often exhibit pronounced friction behavior that depends on load, temperature, and state, which fundamentally challenges the assumptions underlying conventional friction models [7]. This challenge is further amplified by the broad range of tribological conditions occurring in cold forging, including strongly varying contact stresses, temperatures and sliding conditions. Friction models must therefore be capable of representing complex and coupled friction behavior over a wide parameter space.
Despite this tribological complexity, friction in finite element simulations of cold forging is still commonly represented by simplified formulations such as the Coulomb or shear friction law, in which the model-specific friction parameter (µ or m) is typically assumed to be constant and independent of the local tribological state [8,9]. Consequently, significant deviations between predicted and experimentally observed friction behavior can occur, particularly when modern lubricant systems are applied. Numerous advanced analytical and data-driven friction models have therefore been proposed to improve predictive accuracy under varying contact conditions. However, these approaches differ substantially in their underlying physical assumptions, reference quantities and functional formulations, which complicates a direct and physically consistent comparison of their predictive performance.
To date, a systematic comparison of fundamentally different friction-model formulations under identical tribological conditions remains challenging because their internal friction parameters are defined with respect to different physical reference quantities. A model-independent assessment therefore requires comparison on the common level of frictional shear stress. Moreover, for machine-learning-based friction models, it remains unclear to what extent the underlying analytical formulation affects the relationships learned from the tribological state variables, even when similar frictional shear stresses are predicted. Against this background, the present study systematically benchmarks analytical and machine-learning-based friction models on the common frictional shear stress level and subsequently investigates how the underlying friction-law formulation influences the internal relationships learned by the machine-learning models.
2. State of the art
In cold forging, friction is commonly described by analytical models that relate the frictional shear stress τf to either the contact normal stress σn or the material flow stress [2,8]. The fundamental formulations considered in this context are the Coulomb friction model, the shear friction model and combined transition models.
Coulomb friction models [10] assume a proportional relationship between frictional shear stress and contact normal stress via a constant coefficient of friction μ, according to . From a contact-mechanical perspective, the increase in friction with normal load can be associated with progressive asperity flattening and the resulting increase in real contact area. However, as the real contact area approaches the apparent contact area at high normal pressures, this proportionality becomes increasingly invalid. Consequently, the Coulomb formulation does not provide an intrinsic upper limit for the transferable frictional shear stress and may considerably overestimate friction under severe cold-forging conditions [9].
Shear friction models [11], in contrast, relate the frictional shear stress to the shear yield stress of the workpiece material via a friction factor m, according to . Rather than describing the pressure-dependent increase in real contact area, this formulation represents the limiting condition in which the transferable shear stress is governed by the shear resistance of the workpiece material. It therefore provides an upper limit for frictional shear stress but neglects its dependence on contact normal stress, making the formulation less suitable at lower pressures and under well-lubricated conditions [12].
Combined friction models have been proposed to bridge the conceptual gap between Coulomb-type and shear-stress-limited friction. The model proposed by Orowan [13] introduces a transition between the two regimes by accounting for plastic deformation within the contact zone. Continuous transition models, such as the formulation proposed by Shaw et al. [14], enable a smooth transition between the limiting cases.
Extended analytical friction models have been developed beyond these fundamental formulations to account for additional tribological state variables. Such approaches describe friction parameters as functions of quantities such as contact normal stress, surface enlargement, relative velocity and temperature [7,15]. Compared with constant-parameter models, these formulations provide greater flexibility for representing changing contact conditions while retaining an explicit analytical relationship. Nevertheless, the underlying functional form and the interactions between the considered state variables remain predefined by the respective model formulation.
Despite these refinements, considerable deviations may remain under the strongly varying contact conditions occurring in cold forging. To illustrate this limitation for the tribological system investigated in the present study, Figure 1 compares the fundamental friction laws with frictional shear stresses derived from the measured forces and determined by finite element simulations of the sliding compression tests. The resulting frictional shear stresses vary considerably and are not adequately represented by the conventional model formulations over the entire investigated range. While their numerical efficiency and ease of parameterization make analytical friction models attractive for industrial applications, the pronounced nonlinear and state-dependent behavior challenges the ability of predefined functional relationships to comprehensively represent the friction response. A fundamentally different modeling strategy is pursued by machine-learning-based friction models, in which friction is represented as a function of multiple influencing variables without prescribing a fixed analytical relationship.
Neural-network-based friction models, such as the model proposed by Volz et al. [8], enable a flexible representation of nonlinear interactions based on tribometer-derived training data and aim at a process-independent description of friction behavior within the represented load range. Depending on the model formulation, data-driven approaches can either predict state-dependent friction parameters within an underlying analytical friction law or directly predict the resulting frictional response. Consequently, even when different data-driven formulations ultimately describe the same frictional shear stress, the analytical structure in which the machine-learning model is embedded may influence the relationships that have to be learned from the data.
The increased flexibility of machine-learning-based friction models is accompanied by limited direct interpretability. Conventional error metrics quantify predictive performance but provide only limited information about how individual tribological state variables contribute to a model prediction. Explainable artificial intelligence (XAI) methods provide additional means to analyze the influence of input variables and the relationships represented by complex machine-learning models. SHapley Additive exPlanations (SHAP) assign feature-specific contributions to individual model predictions and can thereby be used to investigate both global feature importance and local model behavior [16]. Such feature-attribution approaches have increasingly been applied in engineering applications to reveal interpretable relationships between process parameters and model outputs [17].
3. Motivation, Aim and Methodology
A physically consistent comparison of the investigated friction models requires a common evaluation quantity, since their internal friction parameters are defined with respect to different physical reference quantities. Therefore, all model formulations are benchmarked on the level of frictional shear stress under identical tribological boundary conditions.
The present study pursues two objectives. First, analytical and machine-learning-based friction models of different complexity are systematically benchmarked with respect to their ability to predict frictional shear stress. Second, the influence of the underlying friction-law formulation on machine-learning-based friction modeling is investigated. For this purpose, the input space of the previously proposed Coulomb-based neural network [8] is extended by the flow stress σflow, such that all three investigated neural-network formulations are provided with an identical set of input variables:
- Contact normal stress: σn,
- Surface enlargement: ψ,
- Relative velocity: vrel,
- Sliding distance: sd,
- Contact temperature: Tcontact,
- Flow stress: σflow.
The models predict either the coefficient of friction μ, the friction factor m, or the frictional shear stress τf directly. Consequently, the formulations differ only in their predicted target quantity and the associated analytical friction-law structure, enabling the influence of the underlying formulation on the learned relationships to be investigated independently of the input information provided to the models.
The data required for model parameterization, training and evaluation are obtained from sliding compression tests combined with finite element simulations. All models are evaluated using the same independent validation dataset. Predictive performance is assessed exclusively on the frictional shear stress level using the mean absolute error (MAE), the normalized mean absolute error (nMAE), and residual distributions. The nMAE is calculated using the mean flow stress as the normalization reference.
To complement the evaluation of predictive accuracy, the machine-learning formulations with the common extended input space are analyzed using SHAP. The analysis is performed both on the common frictional shear stress level τf and on the formulation-specific parameter levels μ and m. This enables the influence of the underlying analytical friction law on the relationships learned by the neural networks to be distinguished from their resulting predictive performance.
Table 1 summarizes all investigated friction models. Constant parameter values of μ=0.08, μ=0.04, and m=0.12 are additionally included as industrial reference cases.
4. Data Acquisition at the Frictional Shear Stress Level
The parameterization and evaluation of the investigated friction models require a database covering a wide range of tribological loading conditions and their temporal evolution during sliding. Therefore, the benchmark is based on sliding compression tests [19], which enable an independent and systematic variation of the relevant experimental boundary conditions and, simultaneously, the time-resolved observation of a wide range of tribological states. The functional principle of the test setup is shown in Figure 2, while the investigated experimental space is summarized in Table 2. The four process parameters were varied in a full factorial design at three levels, resulting in 81 sliding compression tests. During data preparation, 7 tests were excluded due to wear-related deviations, reducing the training basis to 74 tests with 40,700 processed data points. In addition, 30 randomly selected sliding compression tests comprising 16,500 data points were reserved exclusively for validation.
To obtain the local tribological quantities required for friction modeling, the sliding compression tests are reproduced by finite element simulations using the modeling approach of Volz et al. [8]. The simulation setup and modeling assumptions are adopted from this previous work. For each sliding compression test, the experimentally measured friction-force and normal-force histories are used to determine the time-dependent coefficient of friction prescribed in the simulation. This enables the experimentally observed friction response to be reproduced while providing access to local quantities that cannot be obtained directly from the measurements. The resulting simulated force histories agree well with the experimental data, yielding a coefficient of determination of R2=0.961. The reproduction quality of the experimentally measured force histories is illustrated for representative sliding compression tests in Figure 3. In particular, the local frictional shear stress τf obtained from the simulations is used as the common physical quantity for the subsequent comparison of the different friction-model formulations. Further details on the finite element model, boundary conditions, and numerical implementation are provided by Volz et al. [8].
Based on the resulting contact conditions, the quantities used for friction modeling are obtained from both experiments and finite element simulations, as summarized in Table 3. Since the FE-based quantities vary spatially over the contact area [20], the 95th percentile is used as a characteristic value for the respective contact state. The combined experimental–numerical procedure thus provides a consistent time-resolved database of characteristic tribological state variables and corresponding reference quantities for the training and validation of the investigated friction models.
5. Friction Model Training and Evaluation Methodology
The same training and independent validation datasets described in Section 4 are used throughout the benchmark. Model training or parameter identification is performed according to the respective friction-model formulation. To account for variability introduced by model training and parameter identification, the complete procedure is repeated independently ten times for each investigated model. Predictive performance is therefore reported as the mean value and corresponding standard deviation across the ten runs. The previously proposed Coulomb-based neural network is implemented according to Volz et al. [8]. For the three formulation-specific neural networks introduced in Section 3, preprocessing and training procedures are kept identical. For evaluation, the outputs of all investigated models are expressed on the common frictional shear stress level. Models predicting a friction parameter, such as μ or m, are converted to τf using their respective analytical friction laws, whereas models predicting τf directly require no additional transformation.
An exception is made for the logarithmic extended Coulomb model. Due to the comparatively high computational effort associated with its parameter identification [7,18], the complete time-resolved training dataset cannot be processed directly. Instead, the data of each sliding compression test are averaged, and 54 points are randomly selected from the resulting training dataset for each parameter-identification run. As for the other models, the procedure is repeated ten times.
For all investigated models, the predicted frictional shear stresses are compared with the corresponding reference values obtained from the experiment-driven finite element simulations described in Section 4. Model performance is quantified using the mean absolute error (MAE) and normalized mean absolute error MAE (nMAE), with the latter normalized by the mean measured flow stress of 667 MPa:
In addition to the global error metrics, residuals are calculated according to
and evaluated over the complete validation dataset to identify systematic and load-dependent deviations that may not be reflected by the global error metrics.
For the three formulation-specific neural networks, the evaluation is complemented by SHapley Additive exPlanations (SHAP). SHAP decomposes individual model predictions into feature-specific contributions, whereby the magnitude of a SHAP value reflects the strength of a contribution and its sign indicates whether the respective feature increases or decreases the predicted output.
SHAP values are calculated by evaluating all possible combinations of the six input variables. Because only six variables are considered, all () possible combinations can be evaluated directly. The contribution of each variable is determined from the resulting changes in model prediction when this variable is included or excluded. If a variable is excluded, its unknown value is represented by values from 80 randomly selected states of the independent validation dataset, and the corresponding model predictions are averaged. SHAP values are evaluated for 600 randomly selected validation states.
Global feature importance is quantified by the mean absolute SHAP value of each input variable. To enable a direct comparison between the three model formulations, these values are normalized by the sum over all six input variables, such that the relative feature importances of each model sum to unity. The similarity of the resulting feature-importance distributions is quantified using cosine similarity.
The presented SHAP summary and dependence plots are based on one representative trained model. To assess whether the identified global feature-importance patterns depend on stochastic neural-network training, the analysis is additionally repeated for three independently trained models with different random seeds.
The analysis is first performed on the common frictional shear stress level τf, considering the complete model mapping including the respective analytical friction law where applicable. Subsequently, the Coulomb- and shear-based neural networks are analyzed on their formulation-specific output levels μ and m. Selected relationships are additionally quantified by local sensitivity decompositions to distinguish dependencies explicitly imposed by the analytical friction law from those represented by the neural network.
6. Evaluation and Discussion of Friction Model Performance
Figure 4 presents the residuals between reference and predicted frictional shear stresses together with the corresponding probability density distributions for all investigated friction models. The results reveal pronounced differences both in overall prediction accuracy and in the systematic structure of the residuals.
The constant Coulomb models exhibit the largest deviations. For μ=0.08, the frictional shear stress is systematically overpredicted over almost the entire investigated range, resulting in an MAE of 87.16 MPa and an nMAE of 13.07%. Reducing the coefficient of friction to μ=0.04 considerably decreases the error, although pronounced load-dependent deviations remain. Parameter identification based on the training data yields μ=0.022 and further reduces the MAE to 11.72 MPa. Nevertheless, the residuals change systematically from predominantly negative values at low frictional shear stresses to positive values at higher stresses. Parameter calibration therefore reduces the overall error but does not eliminate the systematic deviations associated with the predefined proportional relationship between contact normal stress and frictional shear stress.
The shear friction models exhibit a different but likewise systematic residual pattern. Both m=0.12 and the identified value m=0.074 increasingly underestimate high frictional shear stresses. This behavior indicates that, for the investigated lubricant system, the frictional shear stress remains predominantly proportional to the contact normal stress over the entire investigated range, as is also evident from Figure 1. Consequently, no transition toward a shear-limited friction regime is observed at high contact normal stresses. The Orowan model achieves an MAE of 13.76 MPa and shows a residual distribution similar to that of the calibrated shear friction model. Under the investigated conditions, the transition between Coulomb- and shear-limited friction therefore does not provide a consistent improvement over the individually calibrated formulations. Overall, the results of the fundamental and combined analytical models indicate that parameter calibration and increasing model complexity alone are insufficient to represent the strongly state-dependent friction behavior over the complete investigated range.
Extended analytical Coulomb models can provide further improvement by incorporating additional tribological state variables. The logarithmic and multiplicative-exponential formulations achieve MAEs of 11.31 MPa and 8.74 MPa, respectively, and substantially reduce the systematic deviations observed for the fundamental friction laws. Nevertheless, structured residuals remain, particularly at higher frictional shear stresses.
The neural-network-based Coulomb model according to Volz et al. [8] further reduces the prediction error, achieving an MAE of 8.47 MPa and an nMAE of 1.27%. Its residuals are more uniformly distributed around zero and exhibit less pronounced systematic trends than those of the analytical formulations. The three formulation-specific neural networks investigated in the present study provide a further improvement. The direct friction-stress, shear-based and Coulomb-based neural networks achieve MAEs of (6.39 ± 0.79) MPa, (5.68 ± 0.62) MPa and (6.17 ± 0.45) MPa, respectively. Their corresponding nMAE values range between 0.85% and 0.96%. In all three cases, the residual distributions are narrowly centered around zero and exhibit considerably less systematic structure than those of the analytical models.
Although the shear-based neural network achieves the lowest numerical error, the differences between the three formulation-specific neural networks are comparatively small. The error metrics therefore do not indicate a decisive advantage of one underlying friction-law formulation over the others on the common frictional shear stress level. Rather, the results demonstrate that the flexibility of the neural networks allows them to compensate for limitations of the imposed analytical formulation by learning state-dependent effective friction parameters. Consequently, a low prediction error alone cannot be interpreted as evidence that the underlying friction law provides a physically appropriate representation of tribological behavior. Even a restrictive or physically inadequate formulation may yield accurate frictional shear stress predictions if its deficiencies can be compensated by the learned parameter function.
Similar predictive accuracy, however, does not necessarily imply similar internal model behavior. Whether the three formulations represent the influence of the tribological state variables in a comparable manner is therefore investigated in the following section using SHAP-based model interpretation and complementary sensitivity analyses.
The presented results are limited to the tribological conditions represented by the sliding compression test dataset. The neural networks are specific to the investigated lubricant system and require new training data for other lubricants. Analytical friction models, in contrast, remain easier to interpret and implement.
7. Explainability-Based Evaluation and Discussion of ML-Based Friction Formulations
The comparable prediction errors of the three ML-based friction formulations indicate that their different internal parameterizations have only a minor influence on the resulting frictional shear stress. Pairwise Pearson correlation coefficients between the predicted frictional shear stresses range from 0.984 to 0.996, with mean absolute differences between 1.74 and 3.73 MPa. Thus, all three formulations converge towards highly similar predictions on the common frictional shear stress level.
Figure 5 compares the relative mean absolute SHAP values on the common stress level and on the formulation-specific parameter levels. A large absolute SHAP value means that the corresponding tribological variable has a strong influence on the model prediction, whereas a small value indicates a minor influence. On the stress level, all three models exhibit highly similar global feature importance. Contact temperature and contact normal stress dominate the predictions, followed by relative velocity, whereas the remaining variables show considerably smaller contributions. The similarity is quantitatively supported by pairwise cosine similarities between 0.993 and 0.997. In contrast, the feature-importance distributions differ more clearly on the formulation-specific parameter levels, indicating that similar frictional shear stresses are obtained through different internal representations.
Figure 6 provides further insight into the direction of these relationships. Increasing contact temperature shifts the SHAP contributions from strongly positive to moderately negative values for all three model outputs. Thus, low contact temperatures strongly increase the predicted friction quantity, whereas high temperatures reduce it with a comparatively smaller contribution. More pronounced formulation-dependent differences occur for contact normal stress. While increasing contact normal stress has a strong positive influence on the directly predicted frictional shear stress, it predominantly reduces the coefficient of friction μ in the Coulomb-based model and increases the friction factor m in the shear-based model. Thus, the neural networks compensate for limitations of the imposed friction-law structure: the Coulomb-based model reduces μ with increasing normal stress to moderate the explicitly imposed normal-stress dependence, whereas the shear-based model increases m to represent a normal-stress dependence that is absent from the underlying shear friction law.
The corresponding dependence plots in Figure 7 resolve these relationships over the investigated input range. For the direct friction-stress model, increasing contact normal stress leads to increasingly positive contributions to the predicted frictional shear stress. In the Coulomb-based formulation, μ predominantly decreases with increasing contact normal stress, thereby moderating the positive normal-stress dependence already imposed by the Coulomb friction law. Such a pressure dependence of the coefficient of friction is consistent with previous tribological investigations in cold forging by Volz et al. [7], which demonstrated that the coefficient of friction varies systematically with the prevailing tribological loads. In contrast, the shear-based formulation shows an increasing friction factor m with increasing contact normal stress. This behavior is consistent with observations by Kraus et al. [21], who reported increasing friction factors with contact pressure and attributed this behavior to the absence of an explicit pressure dependence in the classical shear friction law. Accordingly, a pressure-dependent m can compensate for the missing direct influence of contact normal stress on the predicted frictional shear stress.
The sensitivity decomposition confirms this interpretation: for approximately 60% of the validation states, the learned contribution counteracts the explicit Coulomb contribution, while the resulting sensitivity remains positive for approximately 93% of the states.
For the shear-based formulation, σn is not explicitly included in , and its positive influence on frictional shear stress must therefore be represented through the predicted friction factor m. Accordingly, m increases strongly with σn. The dependence on flow stress is less uniform. Although m tends to decrease with increasing σflow, the derivative is negative for only 48.3% of the validation states, indicating that the explicitly imposed flow-stress dependence is locally either moderated or reinforced.
Overall, the results reveal a clear distinction between stress-level convergence and parameter-level divergence. The three ML-based formulations predict highly similar frictional shear stresses, while the relationships represented by the formulation-specific quantities μ and m differ substantially. These quantities should therefore be interpreted as formulation-dependent effective friction parameters rather than as directly interchangeable representations of the tribological behavior.
8. Conclusions
This study presents a systematic benchmark of analytical and machine-learning-based friction models for cold forging under identical tribological boundary conditions. By evaluating all formulations on the common level of frictional shear stress τf, models based on fundamentally different friction concepts can be compared consistently despite their different internal parameterizations.
The key findings of this study can be summarized as follows:
- Conventional Coulomb, shear, and combined friction models exhibit pronounced load-dependent residual structures. Parameter calibration reduces the overall error but cannot eliminate systematic deviations associated with their predefined analytical relationships.
- Extended analytical models improve predictive accuracy by incorporating additional tribological state variables, although structured residuals remain over the investigated range.
- The three formulation-specific neural networks achieve the highest predictive accuracy, with nMAE values between 0.85% and 0.96%, corresponding to MAEs between 5.68 and 6.39 MPa. No decisive advantage of predicting μ, m, or τf directly is observed on the common frictional shear stress level.
- The three neural-network formulations show highly similar global feature-attribution patterns on the stress level, with contact temperature and contact normal stress identified as the dominant influencing variables.
- The SHAP-based analysis makes the influence of individual tribological state variables on the predicted friction response transparent and thereby partly addresses the black-box character of data-driven friction models. Beyond model interpretation, it enables tribological relationships learned from the experimental data to be identified and assessed.
- Pronounced differences emerge on the formulation-specific parameter levels. The Coulomb-based network partly moderates the explicitly imposed normal-stress dependence through μ, whereas the shear-based network represents the missing normal-stress dependence through m. Thus, comparable predictions on the stress level do not imply identical internal model behavior, and μ(x) and m(x) should be regarded as formulation-dependent effective friction parameters. A comparison on the frictional shear stress level provides a physically consistent and model-independent basis for benchmarking fundamentally different friction formulations.
Overall, the results reveal a distinction between stress-level convergence and parameter-level divergence in machine-learning-based friction modeling. The combination of a common stress-level benchmark with explainability analysis enables predictive performance and formulation-dependent internal model behavior to be assessed consistently.
Author Contributions
Conceptualization, J.L. and P.G.; methodology, J.L., F.S. and S.V.; software, J.L. and F.S.; validation, J.L. and F.S.; formal analysis, J.L. and F.S.; investigation, J.L., F.S. and S.V.; resources, P.G.; data curation, J.L., F.S. and S.V.; writing—original draft preparation, J.L.; writing—review and editing, F.S., S.V. and P.G.; visualization, J.L. and F.S.; supervision, P.G.; project administration, J.L. and P.G.; funding acquisition, P.G. All authors have read and agreed to the published version of the manuscript.
Funding
The authors would like to thank the German Research Foundation (DFG) for funding the project ‘Friction models for cold forging based on machine learning’ with project number 563455474.
Data Availability Statement
The data supporting the findings of this study are available from the corresponding author upon reasonable request.
Acknowledgments
The authors would like to thank ZWEZ for the valuable collaboration and for providing the lubricant used in this study. During the preparation of this manuscript, the authors used ChatGPT (OpenAI) for programming assistance and for language editing and refinement of the manuscript. The authors reviewed and edited the output and take full responsibility for the content of this publication.
Conflicts of Interest
The authors declare no conflicts of interest.
Abbreviations
The following abbreviations are used in this manuscript:
| AI | Artificial Intelligence |
| DFG | German Research Foundation |
| ICTMP | International Conference on Tribology in Manufacturing Processes |
| LOWESS | Locally Weighted Scatterplot Smoothing |
| MAE | Mean Absolute Error |
| ML | Machine Learning |
| nMAE | Normalized Mean Absolute Error |
| SHAP | SHapley Additive exPlanations |
| SCT | Sliding Compression Test |
| XAI | Explainable Artificial Intelligence |
References
- Launhardt, J.; Schmittinger, F.; Volz, S.; Groche, P. Comparison of Conventional and Data-Driven Friction Models for Cold Forging on a Shear Stress Level.
- Doege, E.; Behrens, B.A. Handbuch Umformtechnik; Springer Vieweg: Berlin, 2010; ISBN 978-3-662-43890-9.
- Lagat, D.; Munawar, H.; Akhusama, E.; Alugongo, A.; Rutto, H. Predictive Numerical Modeling of Inelastic Buckling for Process Optimization in Cold Forging of Aluminum, Stainless Steel, and Copper. Processes 2025, 13, 3177. [CrossRef]
- Volk, W.; Groche, P.; Brosius, A.; Ghiotti, A.; Kinsey, B.; Liewald, M.; Madej, L.; Min, J.; Yanagimoto, J. Models and Modelling for Process Limits in Metal Forming. CIRP Annals Manufacturing Technology 2019, 68, 775–798. [CrossRef]
- Wanheim, T. Friction At High Normal Pressures. Wear 1973, 225–244.
- Groche, P.; Zang, S.; Müller, C.; Bodenmüller, D. A Study on the Performance of Environmentally Benign Lubricants at Elevated Temperatures in Bulk Metal Forming. J Manuf Process 2015, 20, 425–430. [CrossRef]
- Volz, S.; Launhardt, J.; Bay, N.; Hu, C.; Moreau, P.; Dubar, L.; Nielsen, C.; Hayakawa, K.; Kitamura, K.; Groche, P. International Round Robin Test of Environmentally Benign Lubricants for Cold Forging. CIRP Ann 2023, 72, 245–250. [CrossRef]
- Volz, S.; Launhardt, J.; Groche, P. Advanced Friction Modelling for Cold Forging Using a Feed Forward Neural Network 2025.
- Nielsen, C.; Bay, N. Overview of Friction Modelling in Metal Forming Processes. Procedia Engineering 2017, 207, 2257–2262. [CrossRef]
- Coulomb, C.A. Théorie Des Machines Simples: En Ayant Égard Au Frottement de Leurs Parties et à La Roideur Des Cordages; 1821;
- Bowden, F.; Tabor, D. MECHANISM OF METALLIC FRICTION. Nature 1942, 197–199.
- Lüchinger, M.; Velkavrh, I.; Kern, K.; Baumgartner, M.; Klien, S.; Diem, A.; Schreiner, M.; Tillmann, W. Development of a Constitutive Model for Friction in Bulk Metal Forming. Lubricants 2018, 6, 42. [CrossRef]
- Orowan, E. The Calculation of Roll Pressure in Hot and Cold Flat Rolling. Proceedings of the Institution of Mechanical Engineers 1943, 150.
- Shaw, M., C.; Ber, A.; Mamin, P.A. Friction Characteristics of Sliding Surfaces Undergoing Subsurface Plastic Flow. Journal of Basic Engineering 1960.
- Bay, N.; Eriksen, M.; Tan, X.; Wibom, O. A Friction Model for Cold Forging of Aluminum, Steel and Stainless Steel Provided with Conversion Coating and Solid Film Lubricant. CIRP Annals 2011, 60, 303–306. [CrossRef]
- Lundberg, S.M.; Lee, S.-I. A Unified Approach to Interpreting Model Predictions.
- Ackermann, M.; Haase, C. Machine Learning-Based Identification of Interpretable Process-Structure Linkages in Metal Additive Manufacturing. Additive Manufacturing 2023, 71, 103585. [CrossRef]
- Groche, P.; Kramer, P.; Bay, N.; Dubar, L.; Hayakawa, K.; Hu, C.; Kitamura, K.; Moreau, P. Friction Coefficients in Cold Forging: A Global Perspective. CIRP Ann 2018, 67, 261–264. [CrossRef]
- Groche, P.; Müller, C.; Keller, M. A New Concept of the Sliding Compression Test to Independently Investigate the Contact Normal Stress and the Surface Enlargement. AMR 2014, 939, 473–480. [CrossRef]
- Groche, P.; Stahlmann, J.; Müller, C. Mechanical Conditions in Bulk Metal Forming Tribometers—Part Two. Tribology International 2013, 66, 345–351. [CrossRef]
- Kraus, M.; Lenzen, M.; Merklein, M. Contact Pressure-Dependent Friction Characterization by Using a Single Sheet Metal Compression Test. Wear 2021, 476, 203679. [CrossRef]
Figure 1.
Application of analytical friction models to experimental data from sliding compression tests assuming identical flow stress for all tests.
Figure 1.
Application of analytical friction models to experimental data from sliding compression tests assuming identical flow stress for all tests.
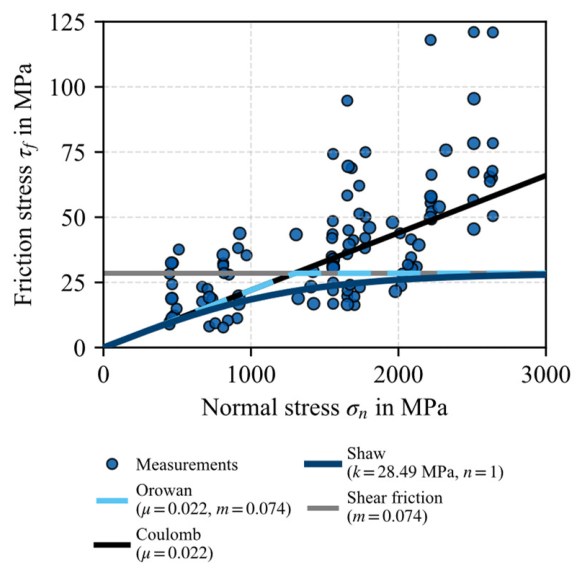
Figure 2.
Functional principle of the sliding compression test.
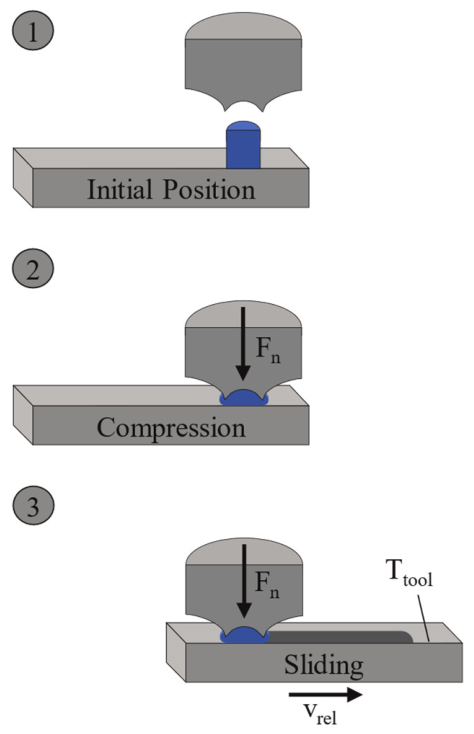
Figure 3.
Comparison of measured and simulation-based friction-force time series for representative sliding compression tests.
Figure 3.
Comparison of measured and simulation-based friction-force time series for representative sliding compression tests.
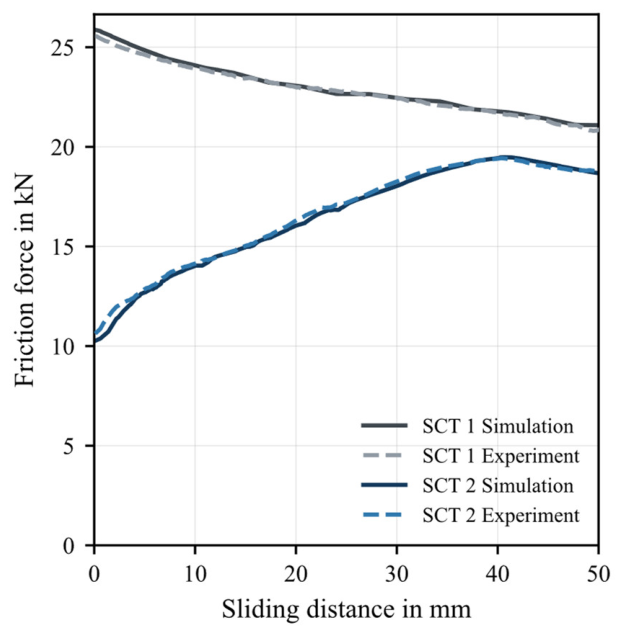
Figure 4.
Residuals of all investigated friction models over the validation dataset. Hexagonal binning indicates point density, while the side distributions show residual density. MAE and nMAE are reported as mean ± standard deviation across ten runs where applicable.
Figure 4.
Residuals of all investigated friction models over the validation dataset. Hexagonal binning indicates point density, while the side distributions show residual density. MAE and nMAE are reported as mean ± standard deviation across ten runs where applicable.
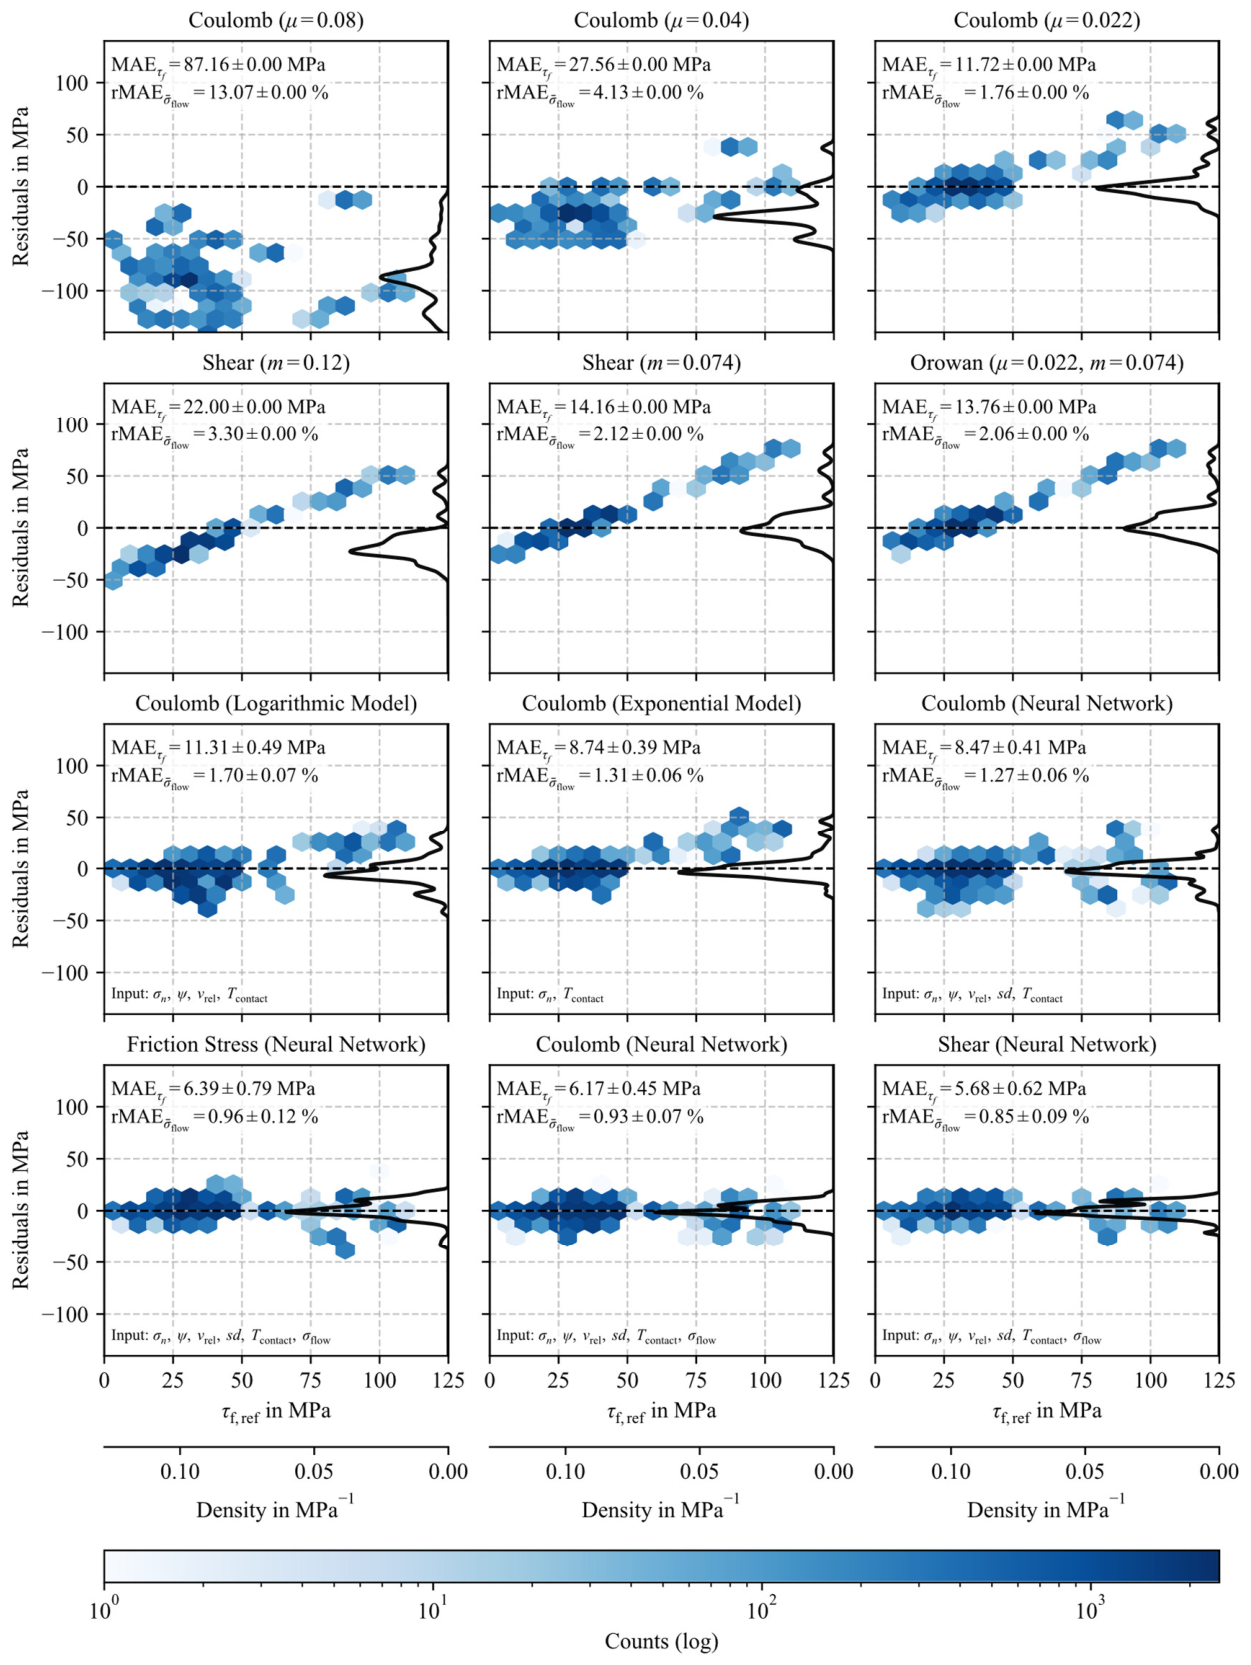
Figure 5.
Relative mean absolute SHAP values on the common stress level and formulation-specific parameter levels.
Figure 5.
Relative mean absolute SHAP values on the common stress level and formulation-specific parameter levels.
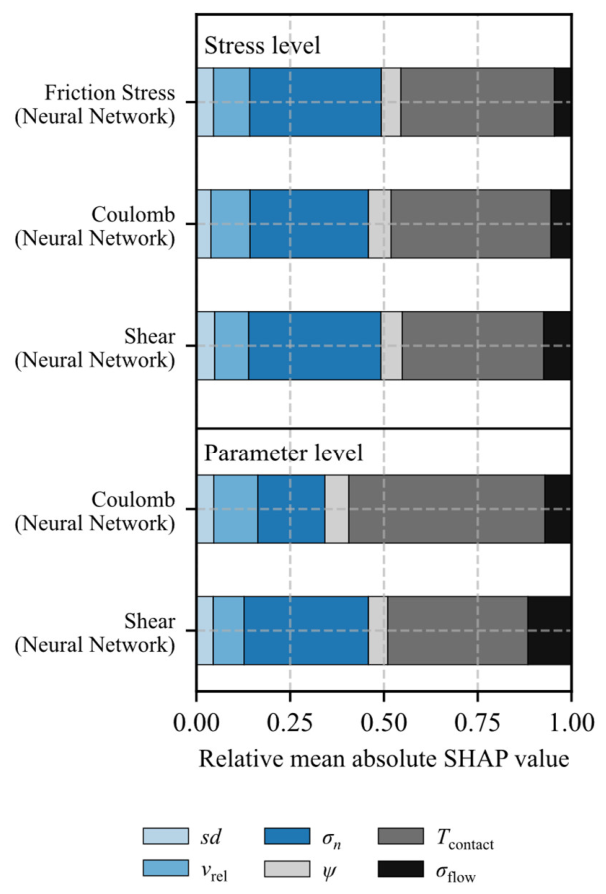
Figure 6.
SHAP summary plots for the three ML-based friction formulations.
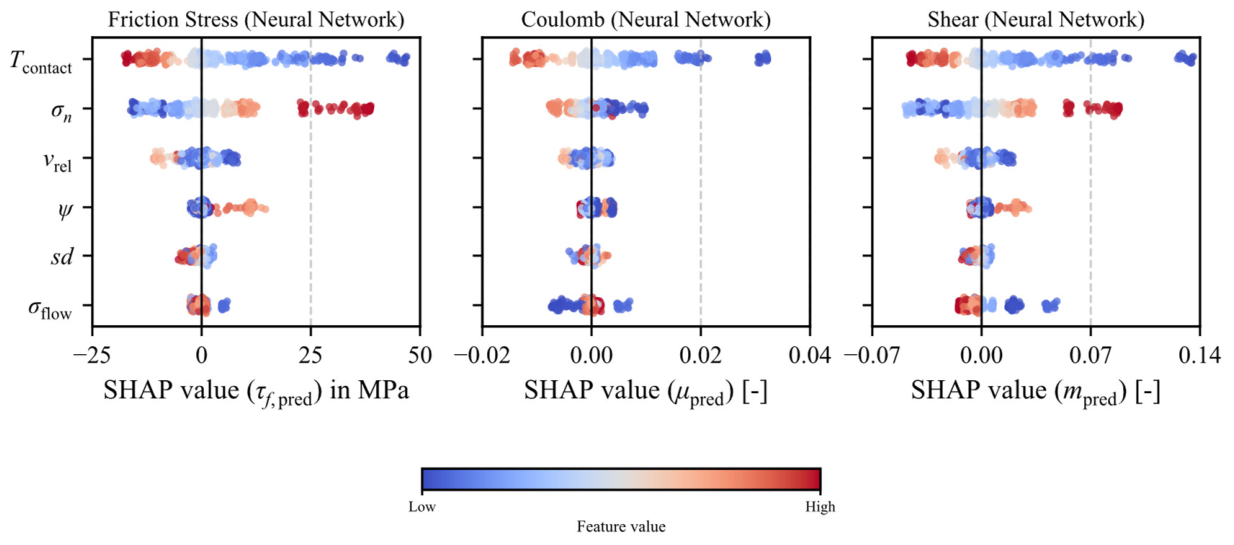
Figure 7.
SHAP dependence plots for contact normal stress and flow stress, including LOWESS trends.
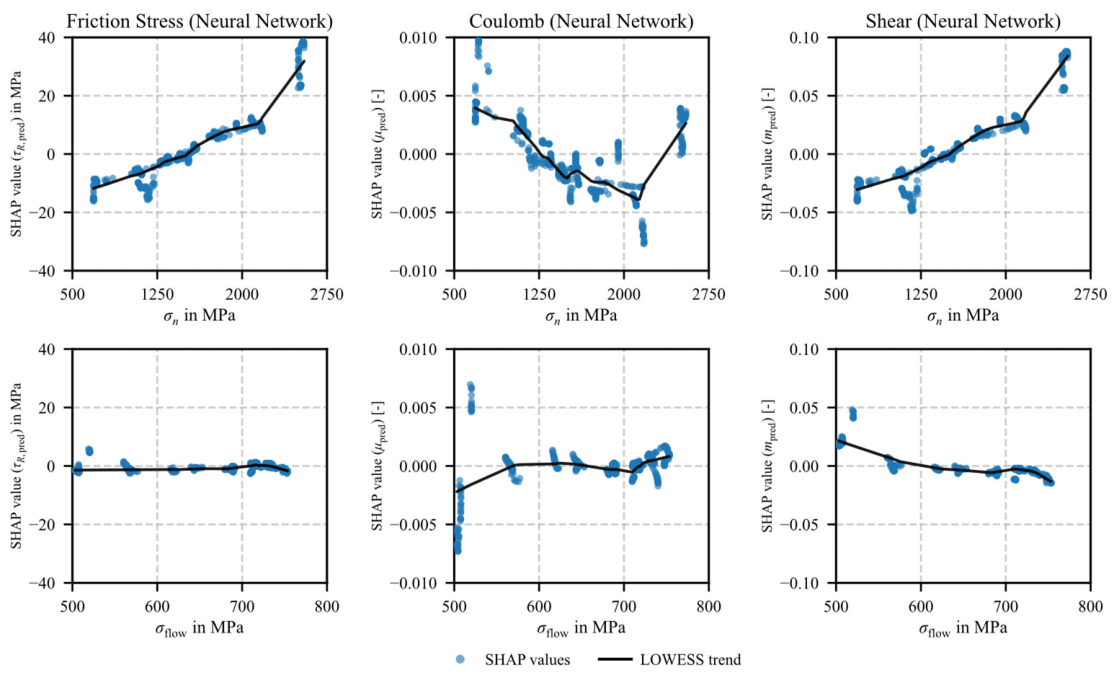

Table 1.
Overview of the friction models investigated.
| Model | Friction formulation | State variables1. | Ref. |
|---|---|---|---|
| Coulomb | μ = 0.08 | - | [18] |
| Coulomb | μ = 0.04 | - | [7] |
| Coulomb, calibrated | μ = median | - | - |
| Shear friction | m = 0.12 | - | [5] |
| Shear friction calibrated | m = median | - | - |
| Orowan | μ = median, m = median | - | [13] |
| Extended Coulomb | Logarithmic formulation | σn, ψ, vrel, Tcontact | [7,18] |
| Extended Coulomb | Exponential formulation | σn, Ttool | [15] |
| ML-based Coulomb | Neural Network | σn, ψ, vrel, sd, Tcontact | [8] |
| ML-based friction stress | Neural Network | σn, ψ, vrel, sd, Tcontact, σflow | - |
| ML-based Coulomb | Neural Network | σn, ψ, vrel, sd, Tcontact, σflow | - |
| ML-based shear | Neural Network | σn, ψ, vrel, sd, Tcontact, σflow | - |
1. State variables refer to quantities used for the state-dependent parameterization or direct prediction of friction. Variables inherent to the fundamental friction law, such as σn in the Coulomb law, are not listed separately.
Table 2.
Experimental parameter ranges of the sliding compression test.
| Process Parameters | Test Area |
|---|---|
| Normal stress σn in MPa | 500 – 2750 |
| Surface enlargement ψ [-] | 1 – 20 |
| Sliding velocity vrel in mm/s | 5 – 500 |
| Tool temperature in °C | 20 - 200 |
Table 3.
Origin of the experimental and numerical quantities used in the friction modeling.
| Quantity | Origin |
|---|---|
| σn | FE simulation |
| Ψ | FE simulation |
| vrel | Experiment |
| sd | Experiment |
| Tcontact | FE simulation |
| σflow | FE simulation |
| τf | FE simulation |
| µ | Experiment |
| m | FE simulation |
Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license (http://creativecommons.org/licenses/by/4.0/).
Copyright: This open access article is published under a Creative Commons CC BY 4.0 license, which permit the free download, distribution, and reuse, provided that the author and preprint are cited in any reuse.