

Submitted:
01 September 2026
Posted:
02 September 2026
You are already at the latest version
Abstract
Road traffic is the main source of exposure to environmental noise in Europe and Directive 2002/49/EC requires the competent authorities to evaluate and manage it. In port cities, a significant portion of this exposure is generated by road traffic induced by ferry embarkation and disembarkation operations: a pulsating and highly non-stationary source, which standard forecasting methods, designed to return long-term average indicators, describe only in aggregate form. This work compares two forecasting approaches applied to the same waterfront of Olbia (Sardinia, Italy) and addresses a question of an operational rather than metrological nature: which model provides the information that a specific noise management decision actually needs. A physical model based on ISO 9613 and the CNOSSOS-EU methodology was implemented in CadnaA and calibrated on continuous monitoring data conducted in three receptor locations during a low and a high season. A non-linear autoregressive artificial neural network, developed and experimentally validated previously on the same waterfront, was used to predict the equivalent sound pressure level starting from vehicle flow data alone. The Lday, Levening and Lnight indicators returned by the two models are compared, together with the required input data, the spatial and temporal resolution, the latency and the installation and update costs over the five-year cycle of the strategic acoustic mapping. The differences between the two models reach 14 dB in low-flow night periods, while the calculation times vary between 3 and 36 h for the physical model versus an almost real-time inference for the neural one. The two approaches are complementary and not alternative: the physical model remains necessary for planning and for scenarios not yet implemented, while the operational and intraday management of noise in a ferry port is better served by data-driven prediction. The two models agree within 1 dB on average during the day and evening periods, whereas at night the neural model returns systematically higher levels, by 5.4 dB on average and by up to 14 dB, at all receiver positions and in both seasons.
Keywords:
road traffic noise
; artificial neural networks
; decision support
; port city
; CNOSSOS-EU
; noise action planning
; environmental noise directive
1. Introduction
Road traffic noise, according to data published by the EEA [1] is the most frequent source of outdoor noise pollution in Europe [2,3] and affects various aspects of the health of the population [4,5], and the quality of the built environment in terms of decrease in value [6,7]. The management of noise pollution and the mitigation of the noise produced by the various sources with particular reference to that generated by road traffic [3,8,9,10,11] is today more than ever a primary objective to preserve people's health and the quality of the environment [1,12,13]. The settlings and decisions taken by the institutions to manage and mitigate this phenomenon are often based on the use of collected data and forecasts made according to standardized methodologies as found in EU directives [12,13,14,15]. More and more often a need arises, as a support to the continuous decision-making process, to obtain reliable forecasts based on the observation of events, directly or indirectly connected with noise, which can vary day by day such as the number and type of means of transport transiting in a given road section. This study takes into consideration the noise generated by road traffic because of boarding and disembarking operations from ferries operating in port cities. We present an analysis carried out on a case study in the city of Olbia in Sardinia aimed at managing noise emission [16]. Models for traffic noise prediction vary in parameterization and therefore can produce different forecast estimates of noise levels depending on the spatial location of emission sources and the propagation field. This paper analyzes the classical models based on the physics of propagation [17] and models based on algorithms for neural learning networks [18,19,20,21], to evaluate the advantages of the latter in the management of the noise and related costs [22]. As regards the physical models, various methodologies have been analyzed, some of them based also on the use of GIS [23,24,25]. Among the various models the three best known [17] are: 1) the European standard, 2) noise assessment methods in common for EU Member States (hereinafter, CNOSSOS) [14,26,27,28], Nord2000 [29,30,31,32,33,34,35,36,37,38,39,40,41,42,43,44] and 3) exposure to noise (Tranex) model based on the UK methodology [17], in terms of source and propagation characteristics. The aim of this work is to investigate and compare the different types of forecasting models. The calculation models based on the physics of noise propagation developed for the assessment of the acoustic impact estimation in terms of noise levels in the environment are starting from certain input parameters and from hypotheses and theoretical formulations regarding the propagation environment and the various causes of acoustic attenuation [1,17,29,30,31,32,33,34,35,36,37,38,39,40,41,42,43,44]. Non-physical models, for example those based on neural networks, base their calculations on mathematical models based on artificial intelligence that "learn" from the measured noise data [18,21]. An artificial neural network ANN is a quantitative mathematical model produced by artificial intelligence and inspired by the structure and functioning of the brain. What characterizes the nervous system is the ability to gain experience from examples; trying to imitate this feature through the model algorithms a powerful tool emerges , usually implemented on computers, called ANN or by new conception EANN (Artificial Neural Emotional Network) [18] and defined as "networks of simple elements interconnected in parallel in large measure and whose hierarchical organization is designed to interact with real world objects in a similar way to the biological nervous system ". In practical terms, ANNs are characterized as statistical data structures organized as modeling tools; they can be used to simulate complex relationships between inputs and outputs that other analytic functions cannot represent. Another aspect that affects the prediction of the noise pollution generated by the road traffic source and the dynamic character of this, is that many forecast models in fact are limited to determine average data based on the LAeq that represent a static condition of the traffic source. A more detailed forecasting should be based on dynamic models that predict the variation over time of the sound emission of the traffic source as a function of different parameters [45]. This work presents the analyses and comparison of the results obtained in a real case using a physical model implemented in CadnaA software environment [46] and a neural network model implemented on Matlab [47]. The latter model on Matlab was developed with the aim of providing a powerful tool, based only on traffic data, which would allow the noise generated by the source to be predicted in real time to offer data and indicators which are necessary for the management and mitigation of this type of noise pollution.
The neural model employed in this study is the adaptive nonlinear autoregressive network developed and experimentally validated by Baccoli et al. [16] on the same waterfront and on the same measurement campaign; its architecture, training strategy, and predictive performance are reported there and are not reviewed here. The contribution of this work is of a different nature. For the same site, a physical forecasting model compliant with ISO 9613 and the CNOSSOS-EU methodology is implemented and calibrated; the two approaches are then compared on the acoustic indicators prescribed by Directive 2002/49/EC and the respective operational areas are evaluated in terms of input data required, temporal and spatial resolution, calculation times and costs. The question addressed is therefore not which model most faithfully reproduces the measured levels, but which model provides, at the moment in which it is needed and for the resolution for which it is needed, the information on which a specific management decision depends.
2. Noise Management Decisions and Their Information Requirements
Noise management is not a single activity but a family of decisions, taken by different subjects, over different time horizons and based on different information. Directive 2002/49/EC explicitly names two of them. Article 7 prescribes the strategic noise map, to be reviewed at least every five years, which describes the exposure over the entire agglomeration in terms of the long-term indicators Lden and Lnight. Article 8 prescribes the action plan, which selects and prioritizes mitigation measures and must therefore compare states of the environment that do not yet exist. In a port city, two further levels actually operate, which the Directive does not mention: the tactical decisions taken when the call schedule is agreed with the shipping companies, typically a few days in advance, and the operational decisions taken while embarkation and disembarkation are in progress. Table 1 summarizes the four levels. What separates them is not the accuracy required for prediction, but two other properties. The first is the time constant of the decision, which sets an upper limit on the acceptable latency of the prediction: a map reviewed every five years tolerates a calculation that takes a day and a half, a decision on the routing of vehicles leaving a mooring does not. The second is the nature of the information available at the time the decision is made. Strategic and tactical decisions are made on hypothetical or planned traffic, which must be estimated; operational ones are based on observed traffic, which in a modern terminal is already counted and classified for access control, mooring management and security, and is therefore available at no additional cost. The two properties point in opposite directions. A physical model derives the sound field from an explicit description of sources, propagation and receptors, and can therefore be applied to any configuration, including one never built and never measured. This is exactly what the strategic and planning levels require, and no data driven model can replace it: a network trained on observations cannot predict the effect of a barrier that does not exist. However, the same explicitness imposes a geometric model to be built and calibrated, a stationary representation of the source on the reference interval and a calculation time that grows with the resolution of the grid. At the operational level these elements become disqualifying: the hourly flow rate that the standard method accepts as input averages precisely the phenomenon of a few hundred vehicles released in a few minutes from the docking of a ferry which generates the disturbance complained of by the residents. A model identified on measured data, in contrast, returns the level associated with an observed traffic state at the resolution at which that state is observed, with a latency limited only by the acquisition of the vehicle count and without any description of the propagation environment. However, it cannot be applied to a configuration that has not been seen, it cannot be transferred to a different site without a new measurement campaign, and it does not offer any traceability with respect to the calculation method prescribed by Annex II of the Directive. It is a tool for levels where the environment is fixed and traffic varies, not for those where the environment itself is the object of the decision. The comparison presented in the following sections should therefore be read in this light. It is not a ranking of accuracy between two competing methods, but the verification of the correspondence between what each model is able to provide and what each decision requires as well as, where both models are applicable, the price that each imposes in terms of time and cost.
3. Prediction Models
The management of noise deriving from the various sources is today more than ever at the center of sustainable management policy choices that consider the cost-benefit ratio [22]. Various forecasting tools are required to simulate acoustic fields with speed, precision and possibly make use of indirect data often acquired for other aspects [18,21].
3.1. Physical Forecasting Models
There are different physical models for the evaluation of noise generated by road traffic, the main types can be classified as in the following list:
- Simplified numerical models
- Complex numerical models: the NMPB model
- Complex numerical models: the CNOSSOS model
The different physical models in turn use sub-models necessary to characterize the different input data which can be summarized in the following list:
- Source model
- Traffic model
- Noise model
Figure 1 shows the workflow normally used by physical models.
Several variables influence the performance of physical prediction models in determining the sound pressure levels of the noise, when applied to different practical configurations including the determination of noise from traffic flows [48,49]. The discrepancies in performance can therefore be linked to differences in the parameterization elements of the CNOSSOS, NORD2000 and Tranex [17] models. According to Khan [17] in most cases, both CNOSSOS and Tranex reproduced the Laeq levels of Nord2000 (2006 version) [29,30,31,32,33,34,35,36,37,38,39,40,41,42,43,44] within three to five dBA (CNOSSOS: 87%, Tranex: 94%). The differences in the Laeq levels of CNOSSOS, compared to Nord2000, may be related to several shortcomings of the existing CNOSSOS algorithms (e.g. Ground attenuation, multiple diffractions and average ground plane). Analyses show that more research is needed to improve CNOSSOS for its implementation in the EU standard [14,50]. In this context, the amendments for CNOSSOS proposed by an EU working group hold significant potential. Overall, both CNOSSOS and Tranex produced similar results, with Tranex reproducing the Nord2000 Laeq values slightly better than CNOSSOS.
3.1.1. Calculation of Sound Levels
Different calculation methods and databases can be used to determine the forecast noise levels deriving from road traffic. The names of the main models available today are shown hereafter:
- CNOSSOS Roads (EU)
- NF S 31-133 (NMPB 2008) (EU)
- RLS-90 (Germany)
- VDI 3722 Bl. 2 (Germany)
- RVS 04.02.11 (Austria)
- SonRoad (Switzerland)
- StL-86 (Switzerland)
- XP S 31-133 (France) (Guide du bruit 1980)
- Ut2-1.302: 2000, MSZ07-2904: 1990, MSZ15036: 2002 (Hungary)
- SRM II (Netherlands)
- TemaNord 1996: 525 (Scandinavia)
- CRTN (Great Britain)
These forecasting models are implemented within various commercial software such as CadnaA [46] and IMMI The IMMI software [51], for example, produced by Wölfel, implements the road sound source model imposed by the END and the Decree Law 194 / 2005 Annex II: "NMPB Routes-96 (SETRACERTU-LCPC-CSTB)" which involves the following parameters:
The NMPB sound emissions database obtained from: "Guide du Bruit des transports terrestres, fascicule prévision des niveaux sonores, CETUR 1980"
The input data:
Traffic flows (variable over time)
Speed (variable with flow)
Traffic composition
Road gradient
3.1.2. Estimation of Traffic Flow and Speed
3.1.3. Traffic Models and Classification
As stated, traffic models can be based on different physical and non-physical parameters, all these can in any case be classified, on the basis of the results obtained as a function of time or not, according to the following types:
- Static traffic patterns - when they reproduce steady average conditions.
- Dynamic traffic patterns - when they reproduce the traffic scenario over time.
Figure 3 shows the difference between the two models.
In the use of traffic models taking into account their purpose, it is necessary to focus on the different peculiarities [53,54,55]. Figure 4 shows a summary of what can be deduced from various studies analyzed in relation to the fields of use of the different road traffic models.
By considering the numerous forecasting models present and used in the various countries, it is observed that these require databases and information that are often onerous to find. On the contrary, performing instrumental measurements of the field of noise or directly evaluating correlated parameters is less complex. This aspect will be taken into consideration in the next paragraph where we will discuss the sound level prediction methodology based on the use of neural networks. In conclusion, physical prediction models are influenced by various parameters and require high costs and long times for their implementation and calibration on a real case. They have the advantage that they can be used in any context and phase with specific reference to the design of new roads or road networks.
3.2. Neural Networks Based Forecasting Models
A brain neuron is a cell structured by a body, by extensions called dendrites, and among them one with a major expansion called axon. A series of small protuberances called synapses branch off from the axon, and act as contact elements with other neurons. Neurons are capable to transmit an electrical signal along their axons, and when this electrical signal arrives near the synapses, they release a certain amount of chemicals, called neurotransmitters, into the small space that separates them from the dendrite or body of the neuron to which they are attached, called the synaptic cleft. The amount of neurotransmitter released into the synaptic cleft constitutes in a certain sense the conductivity of the synapse, that is, it detects how the neuron enhances or attenuates the electrical signal arriving from the axon. If the sum of the currents arriving at the base of the axon exceeds a certain threshold, a current impulse, called spike, of a certain level and of short duration (2-5 milliseconds) is generated; in this case there will be an active behavior, vice versa if a certain threshold value is not reached, we will have a passive behavior, i.e. the impulse is not generated. The spike travels along the axon itself towards the synapses and these release neurotransmitters; the process is repeated in this way for the downstream neurons. In an artificial neural network, neurons are represented as units capable of processing, in a very simple way, the signals they receive from other neurons. The synapses are represented as connections between the units and the electrical signal that travels along the axon is represented with a number, generally between 0 and 1. The conductivity of the synapses is represented with a number called the weight of the connection. The effect of the weight on the signal carried by the connection is modeled by multiplying the signal itself by the weight before it reaches the downstream unit [19]. Figure 5 shows the conceptual scheme of a biological and artificial neural network.
3.2.1. Network Learning Methodologies
Network learning is the methodology used to train the network of neurons; given therefore a specific task to solve and a class of functions F, it means to employ a set of observations to find f in (ϵ) F set which solves the problem in an optimal way. Once such a choice has been made, it is decided by which rules the individual weights should be varied, that is the law of learning. There are three major learning paradigms, each one corresponding to a particular abstract learning task:
- Supervised learning
- Unsupervised learning
- Reinforced learning
Supervised learning, suitable if you have a set of data for training including typical examples of inputs with corresponding outputs: in this way the network can learn to infer the relationship that binds them. Schematically represented in Figure 6/a, it provides for the presentation of a set of “training set” examples, consisting of the pairs Xk and Ydk, respectively the k-th input and the k-th desired output. The real output Yk is compared with the desired one, and the weights are adjusted in such a way as to minimize their difference. The training set is cyclically presented until Yk is about Ydk. During the first training phase, by means of an appropriate algorithm, typically Error-Back Propagation, an attempt is made to make the network acquire the information contained in the training set; in a subsequent phase called generalization, the model obtained is used to analyze new entries.
Unsupervised learning, illustrated in the general scheme represented in Figure 6 / b, is based on training algorithms that modify the weights of the network by referring them exclusively to a set of data that includes only the input variables. These algorithms attempt to group the input data and therefore identify suitable clusters representative of the data themselves, typically making use of topological or probabilistic methods. Unsupervised learning is also employed to develop data compression techniques. Data are presented from a validation set that includes the training set.
Reinforced learning, on the other hand, represents a compromise between supervised and unsupervised learning. In it, the information provided to the network is minimized, just to indicate whether the network response is correct or incorrect [20]. The model implemented for the prediction of road noise [18,21] is based on the observation of vehicular traffic in certain conditions and on acoustic data detected in the site under investigation simultaneously with traffic monitoring.
4. Case Study and Experimental Set-Up
To evaluate the effectiveness for decision-making management in terms of time and costs [22] that physical forecasting models and forecasting models exploiting neural networks allow, both of them were applied to a case study where acoustic indicators obtained through the models were monitored with the aid of high precision measurement and control units. In particular, the physical model applied to the case study was inserted on the CadnaA [46] software which implements the ISO 9613 [56,57] and the CNOSSOS protocol [14,50]. Meanwhile for the neural network model all the implementations were performed on the Matlab platform [47].
4.1. Case Study Description
The case study analyzed refers to a site in Olbia [16], a city overlooking the Mediterranean Sea located in Sardinia. The city has one of the most important ports in Sardinia both from a tourist and a commercial point of view. The survey area concerns the waterfront area normally subjected to major noise levels that affect the environment and the next buildings [7,58], due to a large road traffic especially during the disembarkation and embarkation period at the routes to and from Sardinia in the summer season. Figure 7 highlights the study area on the satellite map, with the main vehicular routes,
4.2. Measurement Campaign and Instrumentation
The acoustic and traffic data used in this study were obtained from the monitoring campaign described in [16], to which the reader is referred for the criteria adopted in selecting the measurement locations. The campaign comprised two continuous 72-hour monitoring periods, chosen to represent the two traffic regimes characterizing the port waterfront: 24-27 March 2019, representative of the low season period (October to May), during which traffic volumes are generated primarily by residents' daily routines and ordinary economic activities; and 24-27 August 2019, representative of the high season period (June to September), during which traffic volumes increase by between 730% and 1000% relative to the annual average, reaching their peak during the third weekend of August. Sound pressure levels were continuously monitored at three receptor locations along the port waterfront, selected to represent different traffic conditions: the "Principe Umberto" roundabout (A), a signalized intersection in front of the town hall (B), and the entrance to a vehicular underpass (C). Measurements were carried out using Class 1 sound level analyzers (01dB, SOLO model), compliant with IEC 61672-1, equipped with a preamplifier and microphone assembly and protected by outdoor weatherproof kits for prolonged field deployment. The instruments were installed at a height of 3 m above ground level and at a distance ranging from 0.5 to 1 m from the nearest road edge, mounted on public lighting poles and positioned under free-field conditions with respect to reflecting surfaces. The metrological calibration of the analyzers was periodically certified by an accredited body with reference to primary standards, in accordance with applicable national regulations, and the corresponding calibration certificates remained valid throughout the entire monitoring campaign. Field calibration was verified using a Class 1 acoustic calibrator before and after each monitoring period, and in no case did the deviation from the initial calibration exceed ±0.5 dB. The A-weighted equivalent continuous sound pressure level was recorded with a 100 ms integration time over the entire audible frequency range and subsequently aggregated into 1-minute levels (LAeq,1min), which were used as the target variable for the neural network model, and hourly levels, which were used for comparison with the physical model. Traffic flows were monitored simultaneously at eleven road sections located along the main access routes to and from the Isola Bianca ferry terminal, using eleven video sensors equipped with automatic vehicle classification software. Four sections were bidirectional and seven were one-way, resulting in a total of fifteen independently monitored traffic lanes. For each lane, the sensors provided traffic volume, travel direction, and average speed, disaggregated by vehicle category according to the classification scheme adopted in CNOSSOS-EU [14]. Meteorological conditions during the two monitoring periods were variable and were obtained from the regional meteorological network. Records affected by anomalies or inconsistencies were excluded from the analysis and accounted for approximately 10% of the total dataset.
5. Comparative Analysis
5.1. The Physical Model Implemented in Cadna Software
The calculation of the values of the acoustic indicators (levels) in output Ld (day), Le (evening), Ln (night), Lden (day, evening and night) in the points of the map grid and in correspondence with the receptors is performed according to the ISO 9613 standard [56,57] by entering the traffic data on an hourly basis according to the aforementioned CNOSSOS – EU methodology [14,50], specifying, in detail, the number of vehicles, the percentages for each class of them, the travel speed. Based on the static hourly traffic flow Qm, the sound power emitted for each meter of length by the linear source representing the single road section, is estimated in frequency bands. The expected levels in the calculation and the environmental noise levels as detected through 3 monitoring stations installed on the site were compared to calibrate the noise map processing model to the real case under study. To this end, some series of sample intervals were identified extracted from the database of the acquisitions carried out on 25, 26, 27 and 28 March. For each interval the data of the vehicular passages detected in each of the ten available sections were extrapolated. By analyzing and modeling the flows, the hourly "flows" were then obtained, divided by vehicle classes, in the road sections of the port front area. The equivalent sound pressure levels (Leq (A)) relating to the hourly intervals analyzed were calculated for each phonometric survey station.
Figure 8.
Results obtained with the simulations made with the physical model for the sample hourly intervals selected within each reference period.
Figure 8.
Results obtained with the simulations made with the physical model for the sample hourly intervals selected within each reference period.
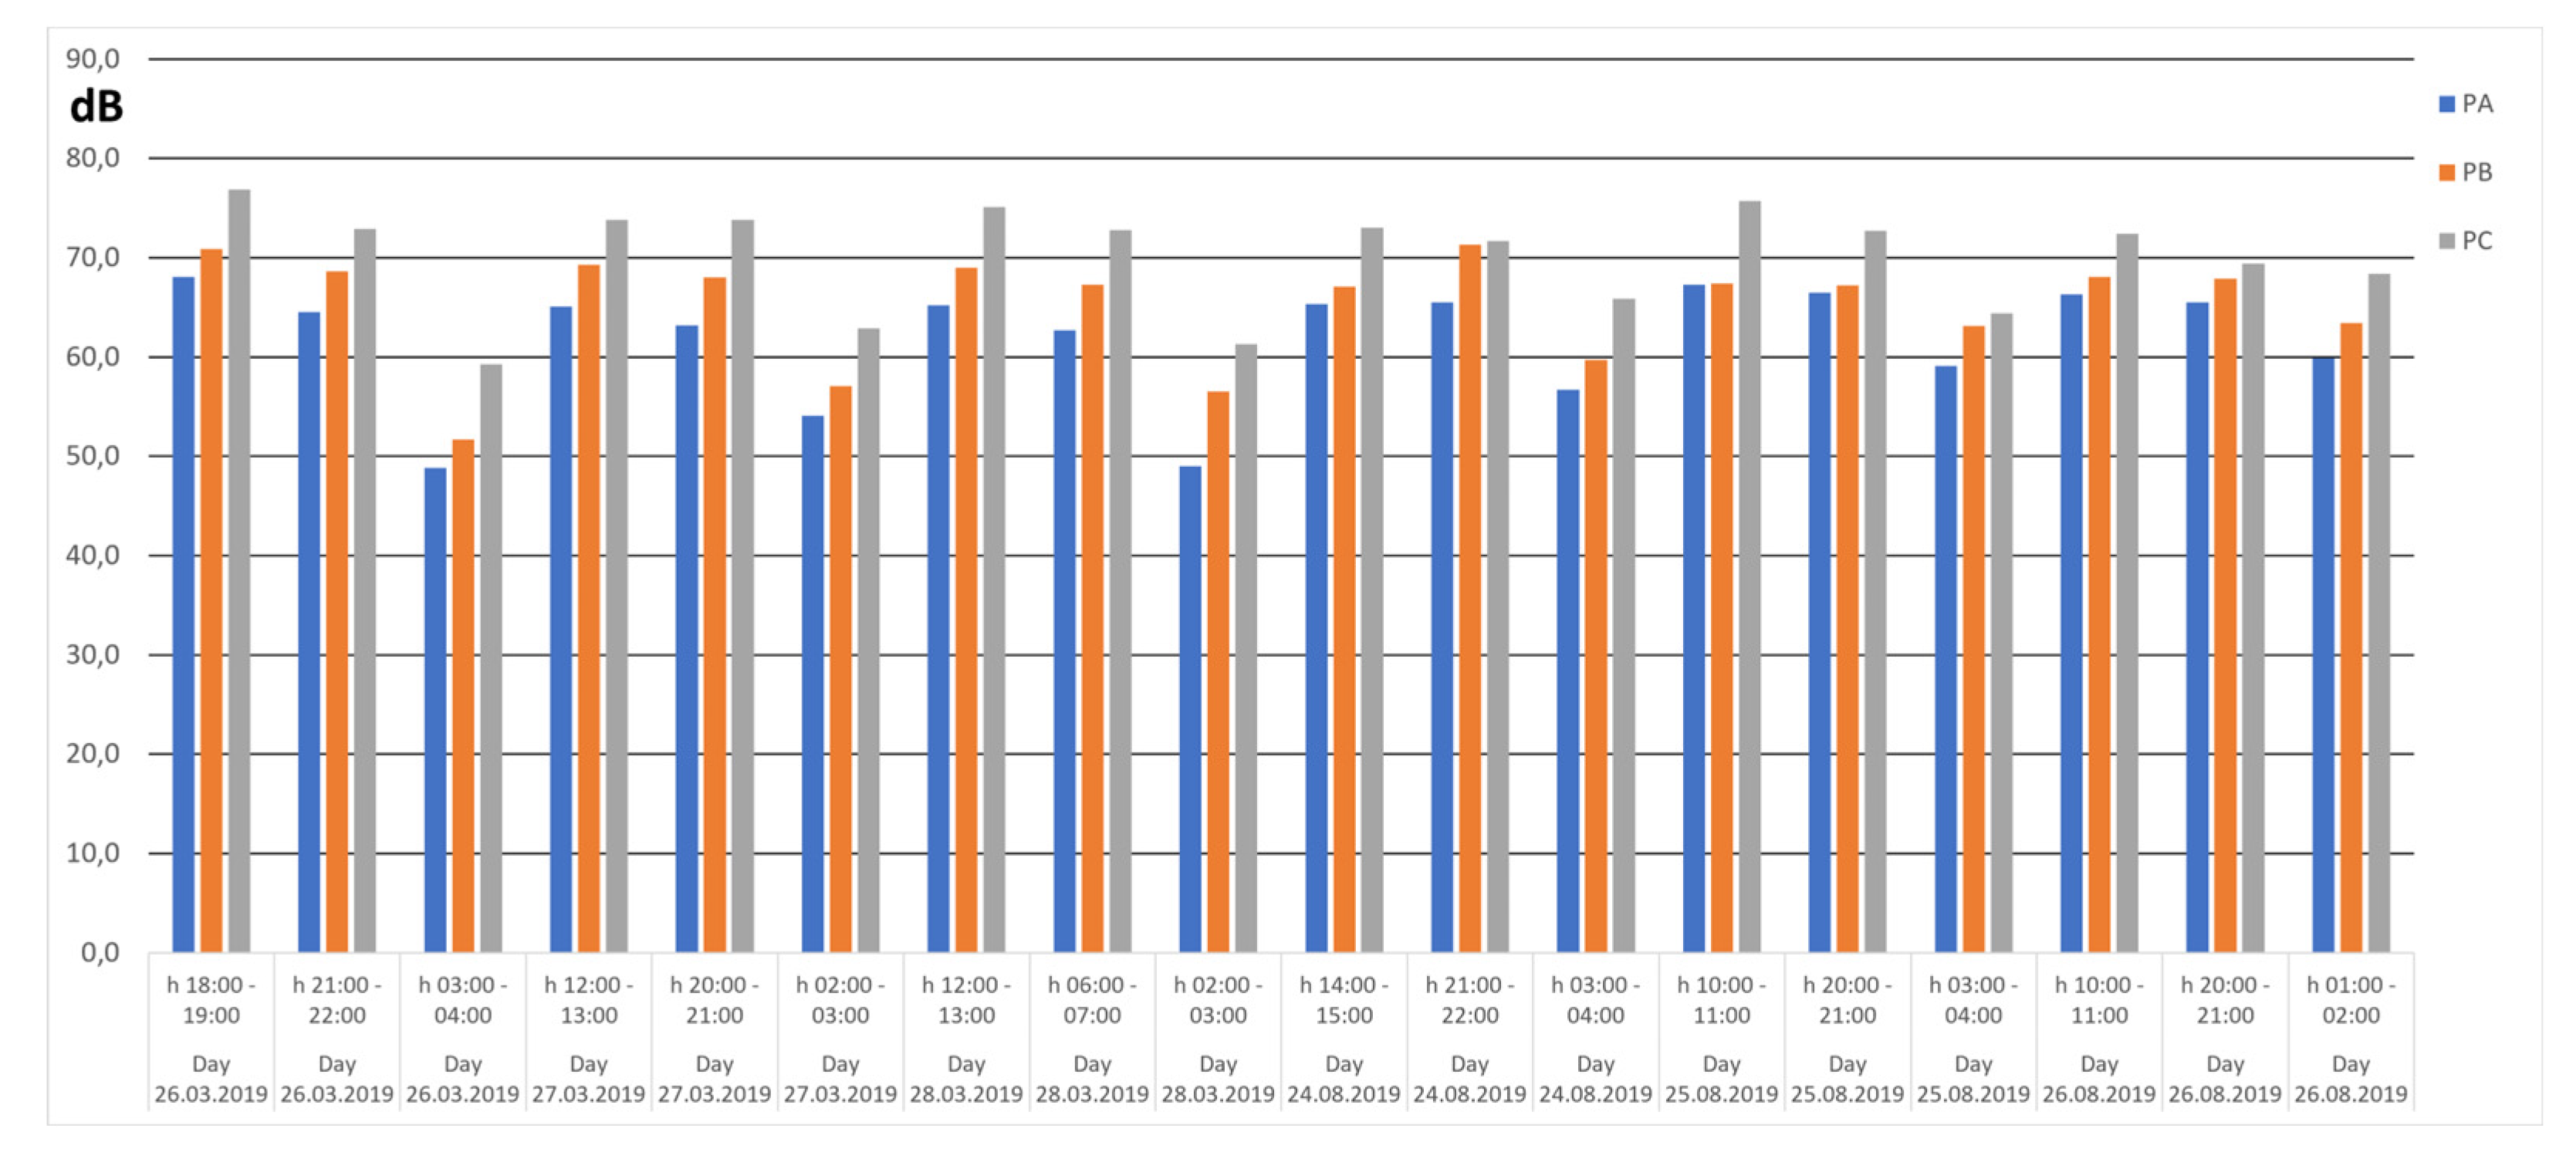
5.2. The Neural Network Model
The neural model adopted in this study is the adaptive nonlinear autoregressive network with exogenous inputs (NARX) developed by Baccoli et al. [16] and implemented in MATLAB environment [47]. As an exogenous input, the network receives the time series of the flow rate and average speed of each vehicle class, defined according to CNOSSOS-EU [14], for each of the fifteen lanes that make up the road sections of the port front; as a feedback input it receives the regressors of the previously observed noise sequence. The output is the A-weighted equivalent continuous sound pressure level, averaged over a one minute integration time, LAeq,1′. The network architecture, multi-time step training strategy, and identification procedure are described in detail in [16] and are not repeated here. The predictive performances of the model were evaluated in [16] on the same measurement campaign used in the present work, with training and test sets comprising respectively 9–11% and 89–91% of the experimental recordings respectively. The prediction error of LAeq,1′ remains within ±0.5 dB throughout the low season in all three receptor locations, and in location A during the high season; in stations B and C in high season the error remains largely within the same interval but increases in different night intervals, in which sources not attributable to road traffic contribute appreciably to the measured level. For the purposes of this comparison, the minute forecasts were aggregated into hourly levels and subsequently into the Lday, Levening and Lnight indicators defined by Directive 2002/49/EC [12].
5.3. Results Obtained from Forecasting Models and Measured Data
The comparison presented in Figure 9 does not intend to establish which of the two models more faithfully reproduces the measured levels: this evaluation is reported in [16] for the neural model and in paragraph 5.1 for the physical one. Its purpose is to show that the two models, applied to the same site and the same traffic data, return information of a different nature. The practical consequence is that the two models diverge precisely in the conditions that matter most for the management of a ferry terminal, and that they do so in a predictable direction.
Table 2 summarises the comparison across the criteria that determine the applicability of each model. The cost figures refer to the installation described in this study and are indicative. The set-up cost of the physical model (approximately 50 k€) comprises the topographic and building survey, the acoustic characterisation of ground and façades, the construction and calibration of the computational model, the software licence and the short measurement series required for calibration; that of the neural model (approximately 80 k€) is dominated by the permanent monitoring infrastructure — the sound level analysers and the video sensors for classified vehicle counting — and includes the identification of the network. Over the five-year review cycle prescribed by Article 7 of the Directive the two routes therefore amount to approximately 60 k€ and 85 k€ respectively, updating being less onerous for the neural model (5 k€, essentially the maintenance of the monitoring stations) than for the physical one (10 k€, the revision of the geometric model and of the calibration measurements). The data-driven route is thus not the less expensive one, and it is not adopted for that reason. Its cost is dominated by a permanent monitoring infrastructure whose output — a continuous, classified record of traffic and of noise — the physical model neither requires nor is able to exploit, and which serves purposes well beyond noise prediction. Where such an infrastructure is already in place, as is increasingly the case in port areas subject to environmental monitoring obligations, the marginal cost of the neural model reduces to the identification of the network alone, and the balance is reversed. The relevant question is therefore not which model is cheaper in absolute terms, but whether the monitoring on which the data-driven route depends is a cost of the prediction or a cost that the authority is already bearing for other reasons.
Table 3 reports the difference between the two models over the fourteen reference periods for which both are available. During the day period the two models agree closely: the mean absolute difference across the three receiver positions is 0.8 dB and never exceeds 3.1 dB. During the evening period the agreement is comparable, with a mean absolute difference of 1.2 dB and a maximum of 4.6 dB. During the night period the picture changes. The neural model returns systematically higher levels than the physical one at all three positions, in both seasons and in every one of the twelve cases, with a mean difference of +5.4 dB and a maximum of 14.1 dB, observed at position A on 26 March.
The sign of the discrepancy is therefore not random, and it is what the two modelling assumptions predict. Where the flow is dense and approximately steady, the hourly mean that the standard method accepts as input describes the source adequately and the two approaches converge. Where the flow is intermittent, the same mean distributes the emission of a compact platoon of vehicles over an interval in which the road is otherwise almost silent; the level it returns therefore falls below the one that the neural model reconstructs from the traffic count at the resolution at which the count is taken. The divergence is not a measure of the error of either model, but of the information that hourly aggregation discards, and it is largest precisely in the reference period on which the night-time limits of the Directive are assessed. Figure 10 shows the same differences period by period: the sign of the discrepancy is negative or negligible throughout the day and evening periods and turns positive, without exception, at night.
6. Discussion
6.1. Where the Two Models Agree and Where They Diverge
The pattern of agreement observed in section 5.3 is consistent with the hypotheses of the two approaches. Under conditions of dense and approximately stationary flow the traffic state is well summarized by an hourly average, the emission of the road section is close to that of an equivalent linear source and the standard method operates in the regime for which it has been calibrated. In conditions of intermittent flow neither of the two conditions applies. A ferry call releases a compact platoon within a few minutes, followed by long intervals of near silence; the hourly average that the standard method accepts as input represents neither one state nor the other, and the resulting indicator describes an hour that never existed. The neural model, which receives the flow at the resolution at which it is counted, preserves this structure. The divergence observed at night is therefore not evidence of an error in one model or the other, but the measure of the information that hourly aggregation discards.
6.2. Limitations of the Physical Model
In addition to the temporal aggregation just discussed, the physical model carries the cost of its own explicitness. The geometric description of the site, the acoustic characterization of the ground and facades and the calibration on the measured levels require considerable effort and must be repeated whenever the built environment changes. The calculation time increases with the resolution of the grid, varying in the case under consideration between 3 and 36 h. Weather conditions, which strongly affect propagation at typical waterfront distances, are represented by long-term statistics rather than the conditions actually present in the interval of interest. Finally, discrepancies between standard methods are not in themselves negligible: Khan et al. [17] report differences between three and five dB(A) between CNOSSOS-EU, Nord2000 and TRANEX in most configurations examined, which sets a lower limit on the accuracy achievable at this level, regardless of the care taken in calibration.
6.3. Limitations of the Data-Driven Model
The neural model is subject to specular limits, and more stringent than the results alone would suggest. It is site-specific: identified on observations collected in three locations on a waterfront, it cannot be transferred to another terminal, nor to a different location within the same terminal, without a new measurement campaign. It cannot represent a configuration that it has not observed and is therefore inapplicable to the evaluation of mitigation measures, which is precisely the task of the action plan. Its output has no traceability with respect to the calculation method prescribed by Annex II of the Directive and cannot be used where a formal demonstration of conformity is required. It is a black box in the sense that a deviation between prediction and measurement cannot be attributed to an identifiable physical term. And, as reported in [16] and recalled in section 5.2, its accuracy degrades in the high season night intervals in two of the three locations, where sources not attributable to road traffic, restaurants, bars and the movement of tourists on foot, contribute appreciably to the measured level: a model driven only by traffic data cannot, by construction, take this into account.
A further limitation concerns costs. The forecasts themselves are inexpensive, but the model depends on a monitoring campaign conducted at the same time as the classified vehicle count, which is the single largest expense item of the entire exercise. The economic argument in favor of the data-driven approach is therefore valid only where such monitoring is already present or is installed for other purposes - as is increasingly the case in ports subject to environmental monitoring obligations - and should not be generalized beyond this condition.
6.4. Complementarity, and the Limits of This Study
Overall, these considerations support a reading of the two approaches as complementary rather than competing, with a clear division of the decision space outlined in section 2. They also delimit what the present study can claim. The comparison was carried out at three receiver positions of a single waterfront, over six days distributed in two seasons of a single year; the cost estimates in section 5 are indicative and derived from this specific installation; and the agreement between the two models in dense traffic conditions, although encouraging, was tested on aggregate indicators rather than on the complete temporal profile. The extension of the comparison to other terminals, and its repetition of where a measured reference is available for each reference period, would allow the boundary between the two areas of applicability to be drawn with greater certainty than current data allow.
7. Conclusions
The present work compared a physical forecasting model of road traffic noise, compliant with ISO 9613 and CNOSSOS-EU and implemented in a commercial computing environment, with a data driven model based on a non-linear autoregressive neural network, applied to the same port front and to the same measurement campaign. The two approaches were found to be in close agreement in dense and approximately stationary traffic conditions and to diverge under the intermittent flow regimes generated by ferry calls, where the hourly aggregation required by the standard method cannot represent the source dynamics.
The two models are therefore complementary and not alternative, and the choice between them depends on the decision to support rather than on accuracy alone. The strategic noise mapping referred to in Article 7 of Directive 2002/49/EC, and the evaluation of mitigation measures not yet implemented, require the spatial coverage, the ability to simulate scenarios and the regulatory traceability that only the physical model offers. On the contrary, the operational management of a ferry terminal, disembarkation planning, routing, information to residents, verification of compliance with limits during peak calls, requires intra-hourly resolution forecasts, continuously updated starting from traffic data that the port and municipal authorities already collect for other purposes; and for these decisions the neural model provides information that the standard method is not able to produce within a useful time and, where continuous monitoring is already in place, at negligible marginal cost. The extension of the approach to other terminals and the quantification of the cost of the monitoring campaign on which the data driven model depends constitute the natural developments of this work.
Author Contributions
Conceptualization, Mastino.CC. and Baccoli.R.; methodology, Mastino.CC.; software, Mastino.CC.; validation, Mastino.CC., Marini. M. and Baccoli.R.; formal analysis, Baccoli.R.; investigation, Mastino.CC.; resources, Mastino.CC.; data curation, Baccoli.R.; writing—original draft preparation, Mastino.CC.; writing—review and editing, Marini. M.; visualization, Marini. M.; supervision, Mastino.CC.; project administration, Mastino.CC.; All authors have read and agreed to the published version of the manuscript.
Acknowledgments
This work was done within the program Interreg IT-FR Italia Francia Marittimo 2014-2020 in Project LIST PORT (https://interreg-maritime.eu/it/web/listport/progetto) and Project DECIBEL (https://interreg-maritime.eu/web/decibel).
References
- EEA European Environment Agency.
- Wrótny, M.; Bohatkiewicz, J. Traffic Noise and Inhabitant Health—A Comparison of Road and Rail Noise. Sustainability 2021, 13, 7340. [Google Scholar] [CrossRef]
- Franchi, L.; Vanelslander, T. Port Greening: Discrete Choice Analysis Investigation on Environmental Parameters Affecting Container Shipping Companies’ Behaviors. Sustainability 2021, 13, 7010. [Google Scholar] [CrossRef]
- Cai, Y.; Zijlema, W.L.; Sørgjerd, E.P.; Doiron, D.; de Hoogh, K.; Hodgson, S.; Wolffenbuttel, B.; Gulliver, J.; Hansell, A.L.; Nieuwenhuijsen, M.; et al. Impact of Road Traffic Noise on Obesity Measures: Observational Study of Three European Cohorts. Environ. Res. 2020, 191, 110013. [Google Scholar] [CrossRef] [PubMed]
- Weltgesundheitsorganisation. Regionalbüro für Europa Environmental Noise Guidelines for the European Region; 2018; ISBN 978-92-890-5356-3. [Google Scholar]
- Kuehnel, N.; Moeckel, R. Impact of Simulation-Based Traffic Noise on Rent Prices. Transp. Res. Part Transp. Environ. 2020, 78, 102191. [Google Scholar] [CrossRef]
- Szczepańska, A.; Senetra, A.; Wasilewicz-Pszczółkowska, M. The Influence of Traffic Noise on Apartment Prices on the Example of a European Urban Agglomeration. Sustainability 2020, 12, 801. [Google Scholar] [CrossRef]
- Heyes, G.; Hooper, P.; Raje, F.; Flindell, I.; Dimitriu, D.; Galatioto, F.; Burtea, N.E.; Ohlenforst, B.; Konovalova, O. The Role of Communication and Engagement in Airport Noise Management. Sustainability 2021, 13, 6088. [Google Scholar] [CrossRef]
- Orga, F.; Mitchell, A.; Freixes, M.; Aletta, F.; Alsina-Pagès, R.M.; Foraster, M. Multilevel Annoyance Modelling of Short Environmental Sound Recordings. Sustainability 2021, 13, 5779. [Google Scholar] [CrossRef]
- Nastasi, M.; Fredianelli, L.; Bernardini, M.; Teti, L.; Fidecaro, F.; Licitra, G. Parameters Affecting Noise Emitted by Ships Moving in Port Areas. Sustainability 2020, 12, 8742. [Google Scholar] [CrossRef]
- Fredianelli, L.; Nastasi, M.; Bernardini, M.; Fidecaro, F.; Licitra, G. Pass-by Characterization of Noise Emitted by Different Categories of Seagoing Ships in Ports. Sustainability 2020, 12, 1740. [Google Scholar] [CrossRef]
- Directive 2002/49/EC on the Assessment and Management of Environmental Noise; 2002; Vol. Official Journal of the European Communities.
- Directive 2014/24/EU of the European Parliament and of the Council of 26 February 2014 on Public Procurement and Repealing Directive 2004/18/EC Text with EEA Relevance 2014.
- European Commission. Joint Research Centre. ICHP. Common Noise Assessment Methods in Europe (CNOSSOS-EU): To Be Used by the EU Member States for Strategic Noise Mapping Following Adoption as Specified in the Environmental Noise Directive 2002/49/EC; Publications Office: LU, 2012. [Google Scholar]
- Directive (EU) 2018/844 of the European Parliament and of the Council of 30 May 2018 Amending Directive 2010/31/EU on the Energy Performance of Buildings and Directive 2012/27/EU on Energy Efficiency. 17. [PubMed]
- Baccoli, R.; Sollai, F.; Medda, A.; Piccolo, A.; Fadda, P. An Adaptive Nonlinear Autoregressive ANN Model for High Time Resolution Traffic Noise Predictions. Experimental Results for a Port City Waterfront. Build. Environ. 2022, 207, 108551. [Google Scholar] [CrossRef]
- Khan, J.; Ketzel, M.; Jensen, S.S.; Gulliver, J.; Thysell, E.; Hertel, O. Comparison of Road Traffic Noise Prediction Models: CNOSSOS-EU, Nord2000 and TRANEX. Environ. Pollut. 2021, 270, 116240. [Google Scholar] [CrossRef] [PubMed]
- Nourani, V.; Gökçekuş, H.; Umar, I.K.; Najafi, H. An Emotional Artificial Neural Network for Prediction of Vehicular Traffic Noise. Sci. Total Environ. 2020, 707, 136134. [Google Scholar] [CrossRef] [PubMed]
- Baldassarre, G. Introduzione Alle Reti Neurali 2018. [CrossRef]
- Pioggia, E. Reti neurali artificiali; Cagliari, 2010. [Google Scholar]
- Nourani, V.; Gökçekuş, H.; Umar, I.K. Artificial Intelligence Based Ensemble Model for Prediction of Vehicular Traffic Noise. Environ. Res. 2020, 180, 108852. [Google Scholar] [CrossRef] [PubMed]
- Mrówczyńska, M.; Sztubecka, M.; Skiba, M.; Bazan-Krzywoszańska, A.; Bejga, P. The Use of Artificial Intelligence as a Tool Supporting Sustainable Development Local Policy. Sustainability 2019, 11, 4199. [Google Scholar] [CrossRef]
- Puyana-Romero, V.; Cueto, J.L.; Gey, R. A 3D GIS Tool for the Detection of Noise Hot-Spots from Major Roads. Transp. Res. Part Transp. Environ. 2020, 84, 102376. [Google Scholar] [CrossRef]
- Bocher, E.; Guillaume, G.; Picaut, J.; Petit, G.; Fortin, N. NoiseModelling: An Open Source GIS Based Tool to Produce Environmental Noise Maps. 2019. [Google Scholar] [CrossRef]
- Lines, T.; Basiri, A. 3D Map Creation Using Crowdsourced GNSS Data. Comput. Environ. Urban Syst. 2021, 89, 101671. [Google Scholar] [CrossRef]
- Peng, J.; Parnell, J.; Kessissoglou, N. Spatially Differentiated Profiles for Road Traffic Noise Pollution across a State Road Network. Appl. Acoust. 2021, 172, 107641. [Google Scholar] [CrossRef]
- Khan, J.; Kakosimos, K.; Jensen, S.S.; Hertel, O.; Sørensen, M.; Gulliver, J.; Ketzel, M. The Spatial Relationship between Traffic-Related Air Pollution and Noise in Two Danish Cities: Implications for Health-Related Studies. Sci. Total Environ. 2020, 726, 138577. [Google Scholar] [CrossRef] [PubMed]
- European Environment Agency. Noise in Europe 2014; Publications Office: LU, 2014. [Google Scholar]
- Plovsing, B. Revised Test Cases for Control of Nord2000-Road. 23.
- Plovsing, B. Revised Test Cases for Updated Version of Nord2000-Road. 35.
- DELTA Nord2000. Comprehensive Outdoor Sound Propagation Model. Part 1: Propagation in an Atmosphere without Significant Refraction. 2006. [Google Scholar] [PubMed]
- Appelqvist Suurhiekka, Paul. Wind Farm - Calculation of Noise from Wind Tubines - Project Report 2008.
- Ahearn, M.J.; Boeker, E.R.; Rosenbaum, J.E.; Gerbi, P.J.; Roof, C.J. THE ANALYSIS OF MODELING AIRCRAFT NOISE WITH THE NORD2000 NOISE MODEL 2012. [CrossRef]
- Kragh, J. Traffic Noise Prediction Whit NORD2000 2011. [PubMed]
- Jónsson, G.B.; Jacobsen, F. A COMPARISON OF TWO ENGINEERING MODELS FOR SOUND PROPAGATION: HARMONOISE AND NORD2000. 2008, 11. [Google Scholar]
- Nota, R.; Jonasson, H.G.; van Maercke, D.; Taraldsen, G.; Watts, G.; Witte, J. Harmonoise: Simplification of Comprehensive Source and Propagation Models into an Accurate and Practicable Engineering Method. 7.
- Brandtsegg, M. Brukerveileder Nord2000 Road Norsk Oversett Else Og Implementering i NorStøy 2014.
- Klinkby, J. NORD2000 VS. THE EXISTING NORDIC PROPAGATION MODELS. 6.
- Eurasto, R. NORD2000 for Road Traffic Noise Prediction Weather Classes and Statistics 2006.
- Plovsing, B. Comprehensive Outdoor Sound Propagation Model. Part 2: Propagation in an Atmosphere with Refraction; 50, 2000. [Google Scholar]
- Sørensen, T. THE NORD2000 IMPLEMENTATION 2012. [CrossRef]
- Reduction of Nord2000 Calculation Time - Rapport Nr.23 2010.
- Test Cases for Railway Noise Nord2000 2014
- Kragh, J.; Jonasson, H.; Plovsing, B.; Sarinen, A. User’s Guide Nord2000 Road 2006. [PubMed]
- Lan, Z.; He, C.; Cai, M. Urban Road Traffic Noise Spatiotemporal Distribution Mapping Using Multisource Data. Transp. Res. Part Transp. Environ. 2020, 82, 102323. [Google Scholar] [CrossRef]
- CadnaA - Https://Www.Datakustik.Com.
- MatLab - Https://It.Mathworks.Com/.
- Abdulmawjoud, A.A.; Jamel, M.G.; Al-Taei, A.A. Traffic Flow Parameters Development Modelling at Traffic Calming Measures Located on Arterial Roads. Ain Shams Eng. J. 2021, 12, 437–444. [Google Scholar] [CrossRef]
- Jones, R.R.K.; Waters, D.M. Traffic Noise Annoyance near Light Controlled Intersections. Appl. Acoust. 1981, 14, 7–13. [Google Scholar] [CrossRef]
- Kephalopoulos, S.; Paviotti, M.; Anfosso-Lédée, F.; Van Maercke, D.; Shilton, S.; Jones, N. Advances in the Development of Common Noise Assessment Methods in Europe: The CNOSSOS-EU Framework for Strategic Environmental Noise Mapping. Sci. Total Environ. 2014, 482–483, 400–410. [Google Scholar] [CrossRef] [PubMed]
- IMMI. Available online: Https://Www.Immi.Eu/En/Cookiebar/Save.Html.
- Yang, W.; Cai, M.; Luo, P. The Calculation of Road Traffic Noise Spectrum Based on the Noise Spectral Characteristics of Single Vehicles. Appl. Acoust. 2020, 160, 107128. [Google Scholar] [CrossRef]
- Bert, P. IMAGINE - Improved Methods for the Assessment of the Generic Impact of Noise in the Environment - Assessment Programme for Parameters of the “General” European Vehicle Fleet - Deliverable D3 of the IMAGINE Project 2006. [PubMed]
- Bert, P. IMAGINE - Improved Methods for the Assessment of the Generic Impact of Noise in the Environment - The Noise Emission Model For European Road Traffic Deliverable 11 of the IMAGINE Project 2007. [PubMed]
- Wilmink, I. IMAGINE - Improved Methods for the Assessment of the Generic Impact of Noise in the Environment - Guidelines for the Use of Traffic Models for Noise Mapping and Noise Action Planning - Deliverable 7 of the IMAGINE Project 2006. [PubMed]
- ISO 9613-1; Acoustics - Attenuation of Sound during Propagation Outdoors - Part 1: Calculation of the Absorption of Sound by the Atmosphere 1993.
- ISO 9613-2; Acoustics - Attenuation of Sound during Propagation Outdoors - Part 2: General Method of Calculation 1996.
- Benocci, R.; Brambilla, G.; Bisceglie, A.; Zambon, G. Eco-Acoustic Indices to Evaluate Soundscape Degradation Due to Human Intrusion. Sustainability 2020, 12, 10455. [Google Scholar] [CrossRef]
Figure 1.
Workflow for physical calculation models and NN Models of road noise.
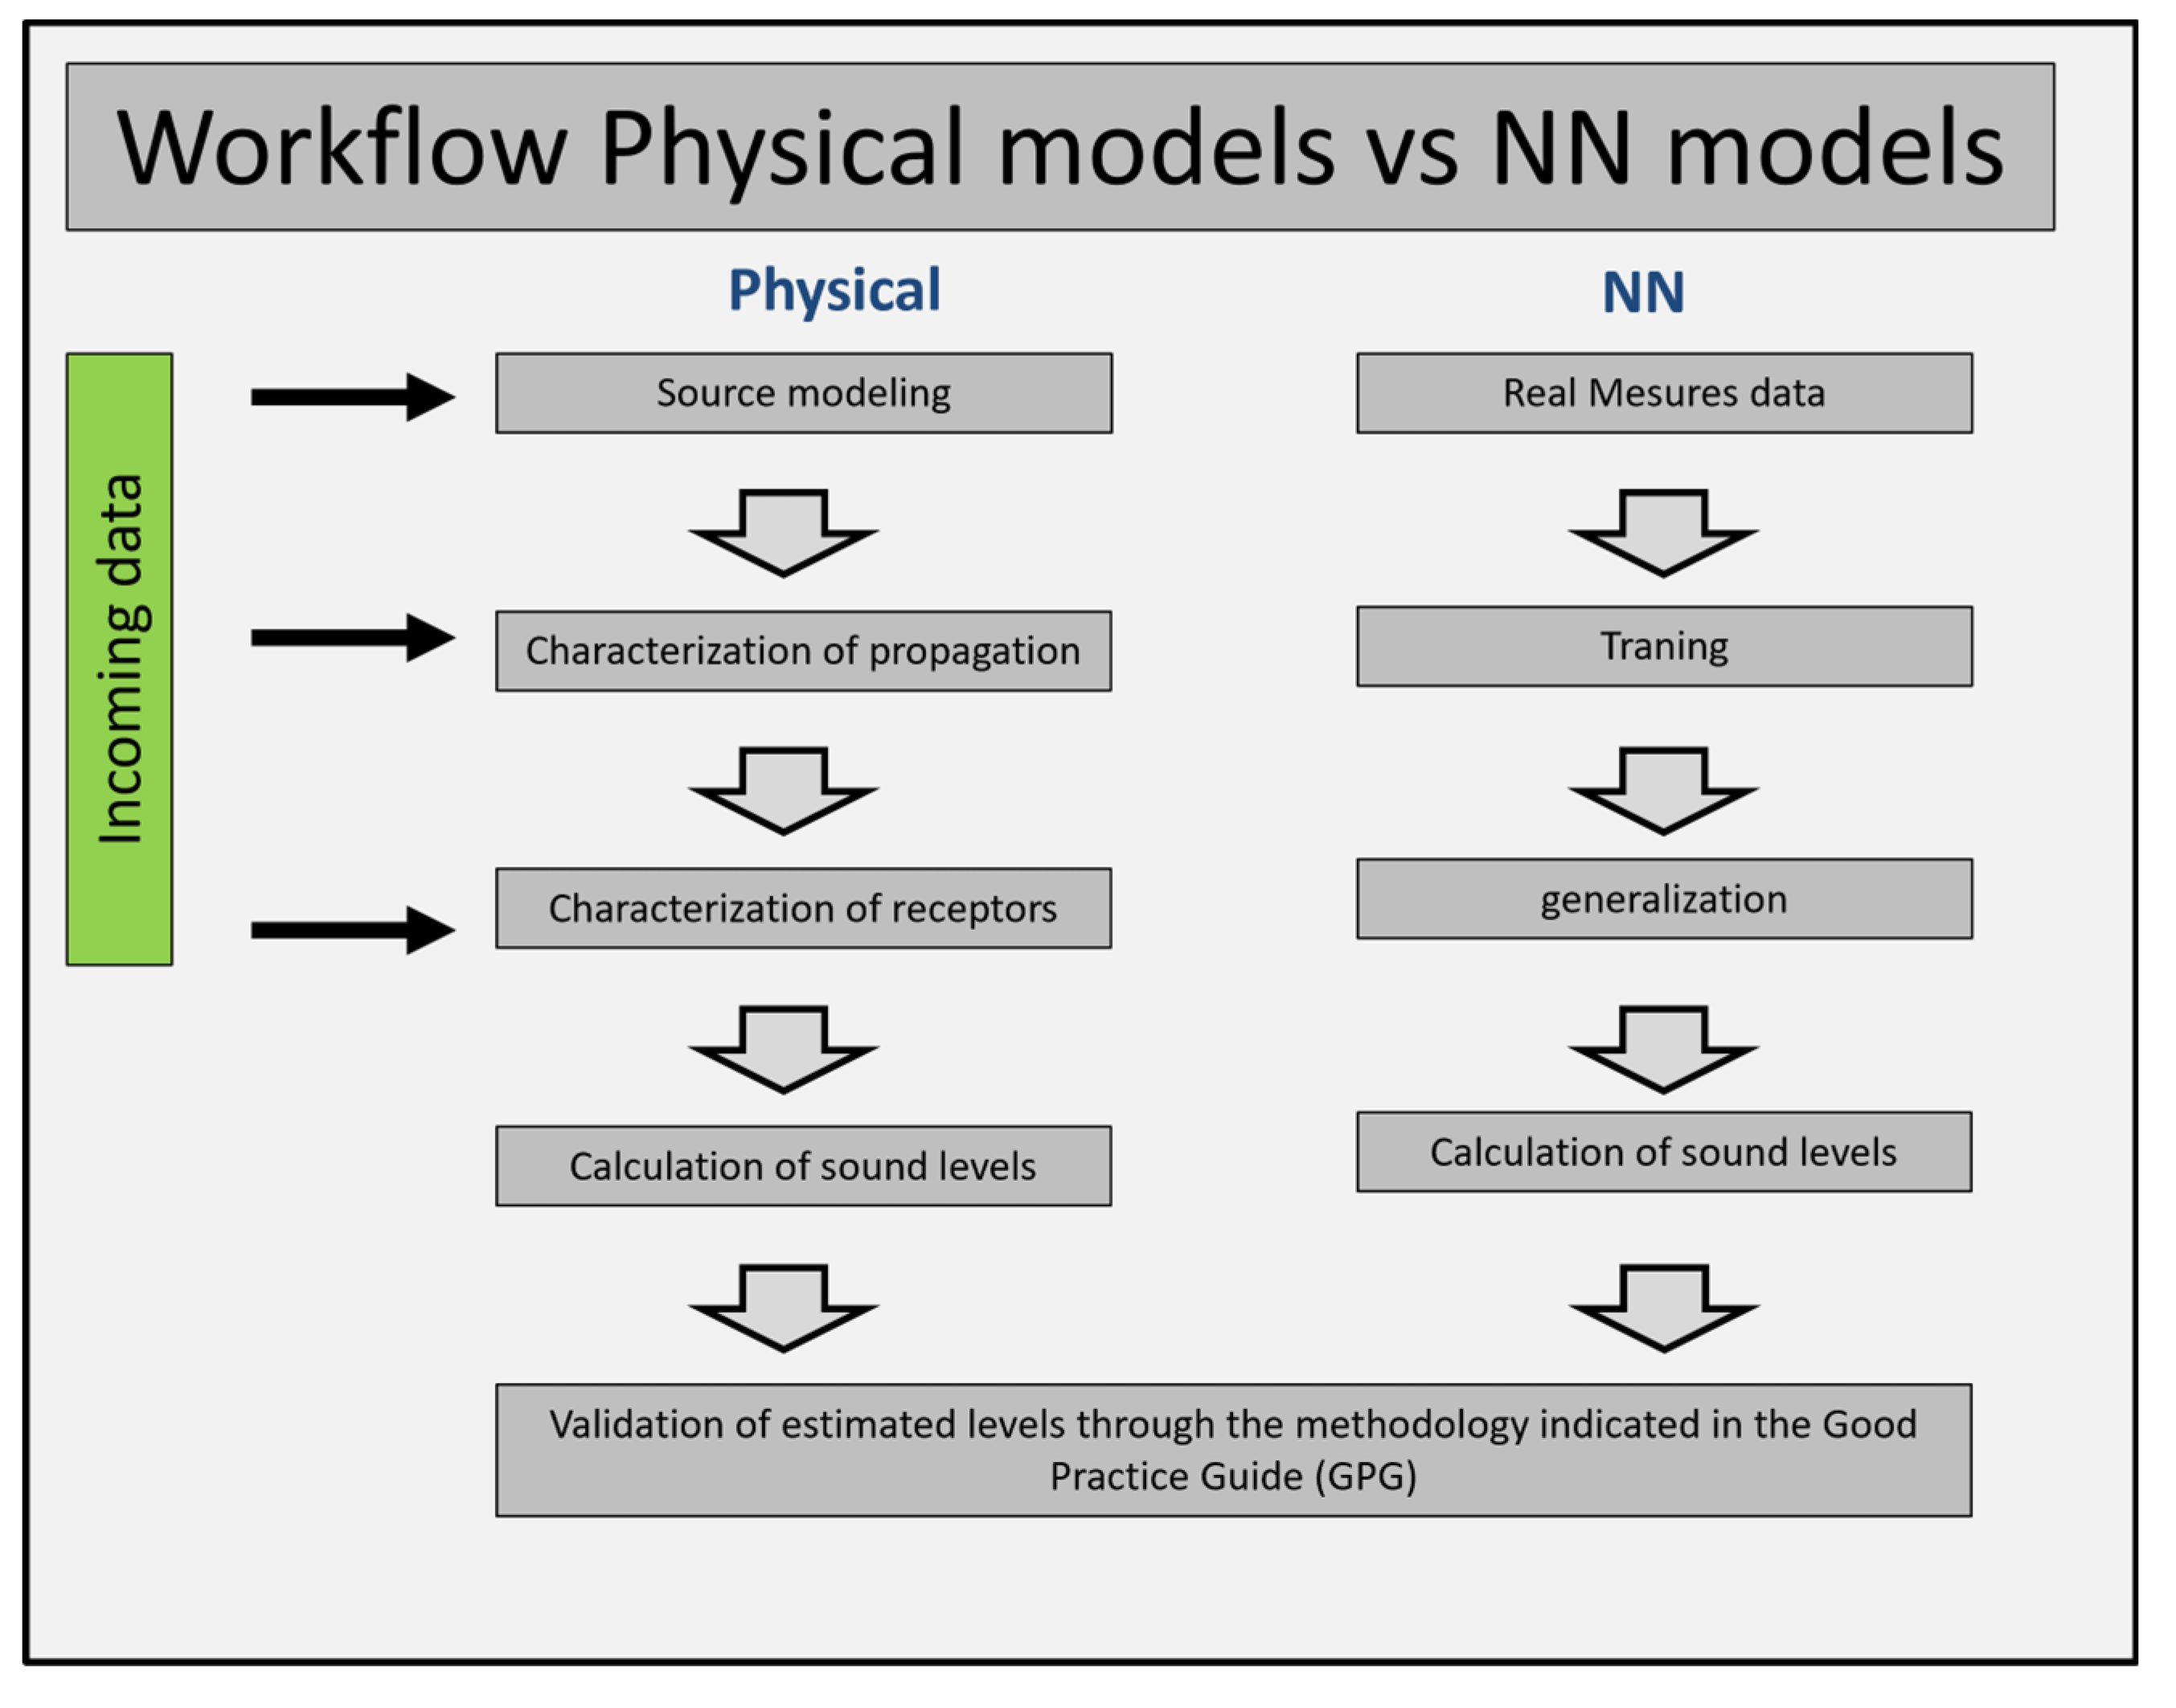
Figure 2.
Flow and velocity estimation scheme for noise mapping.
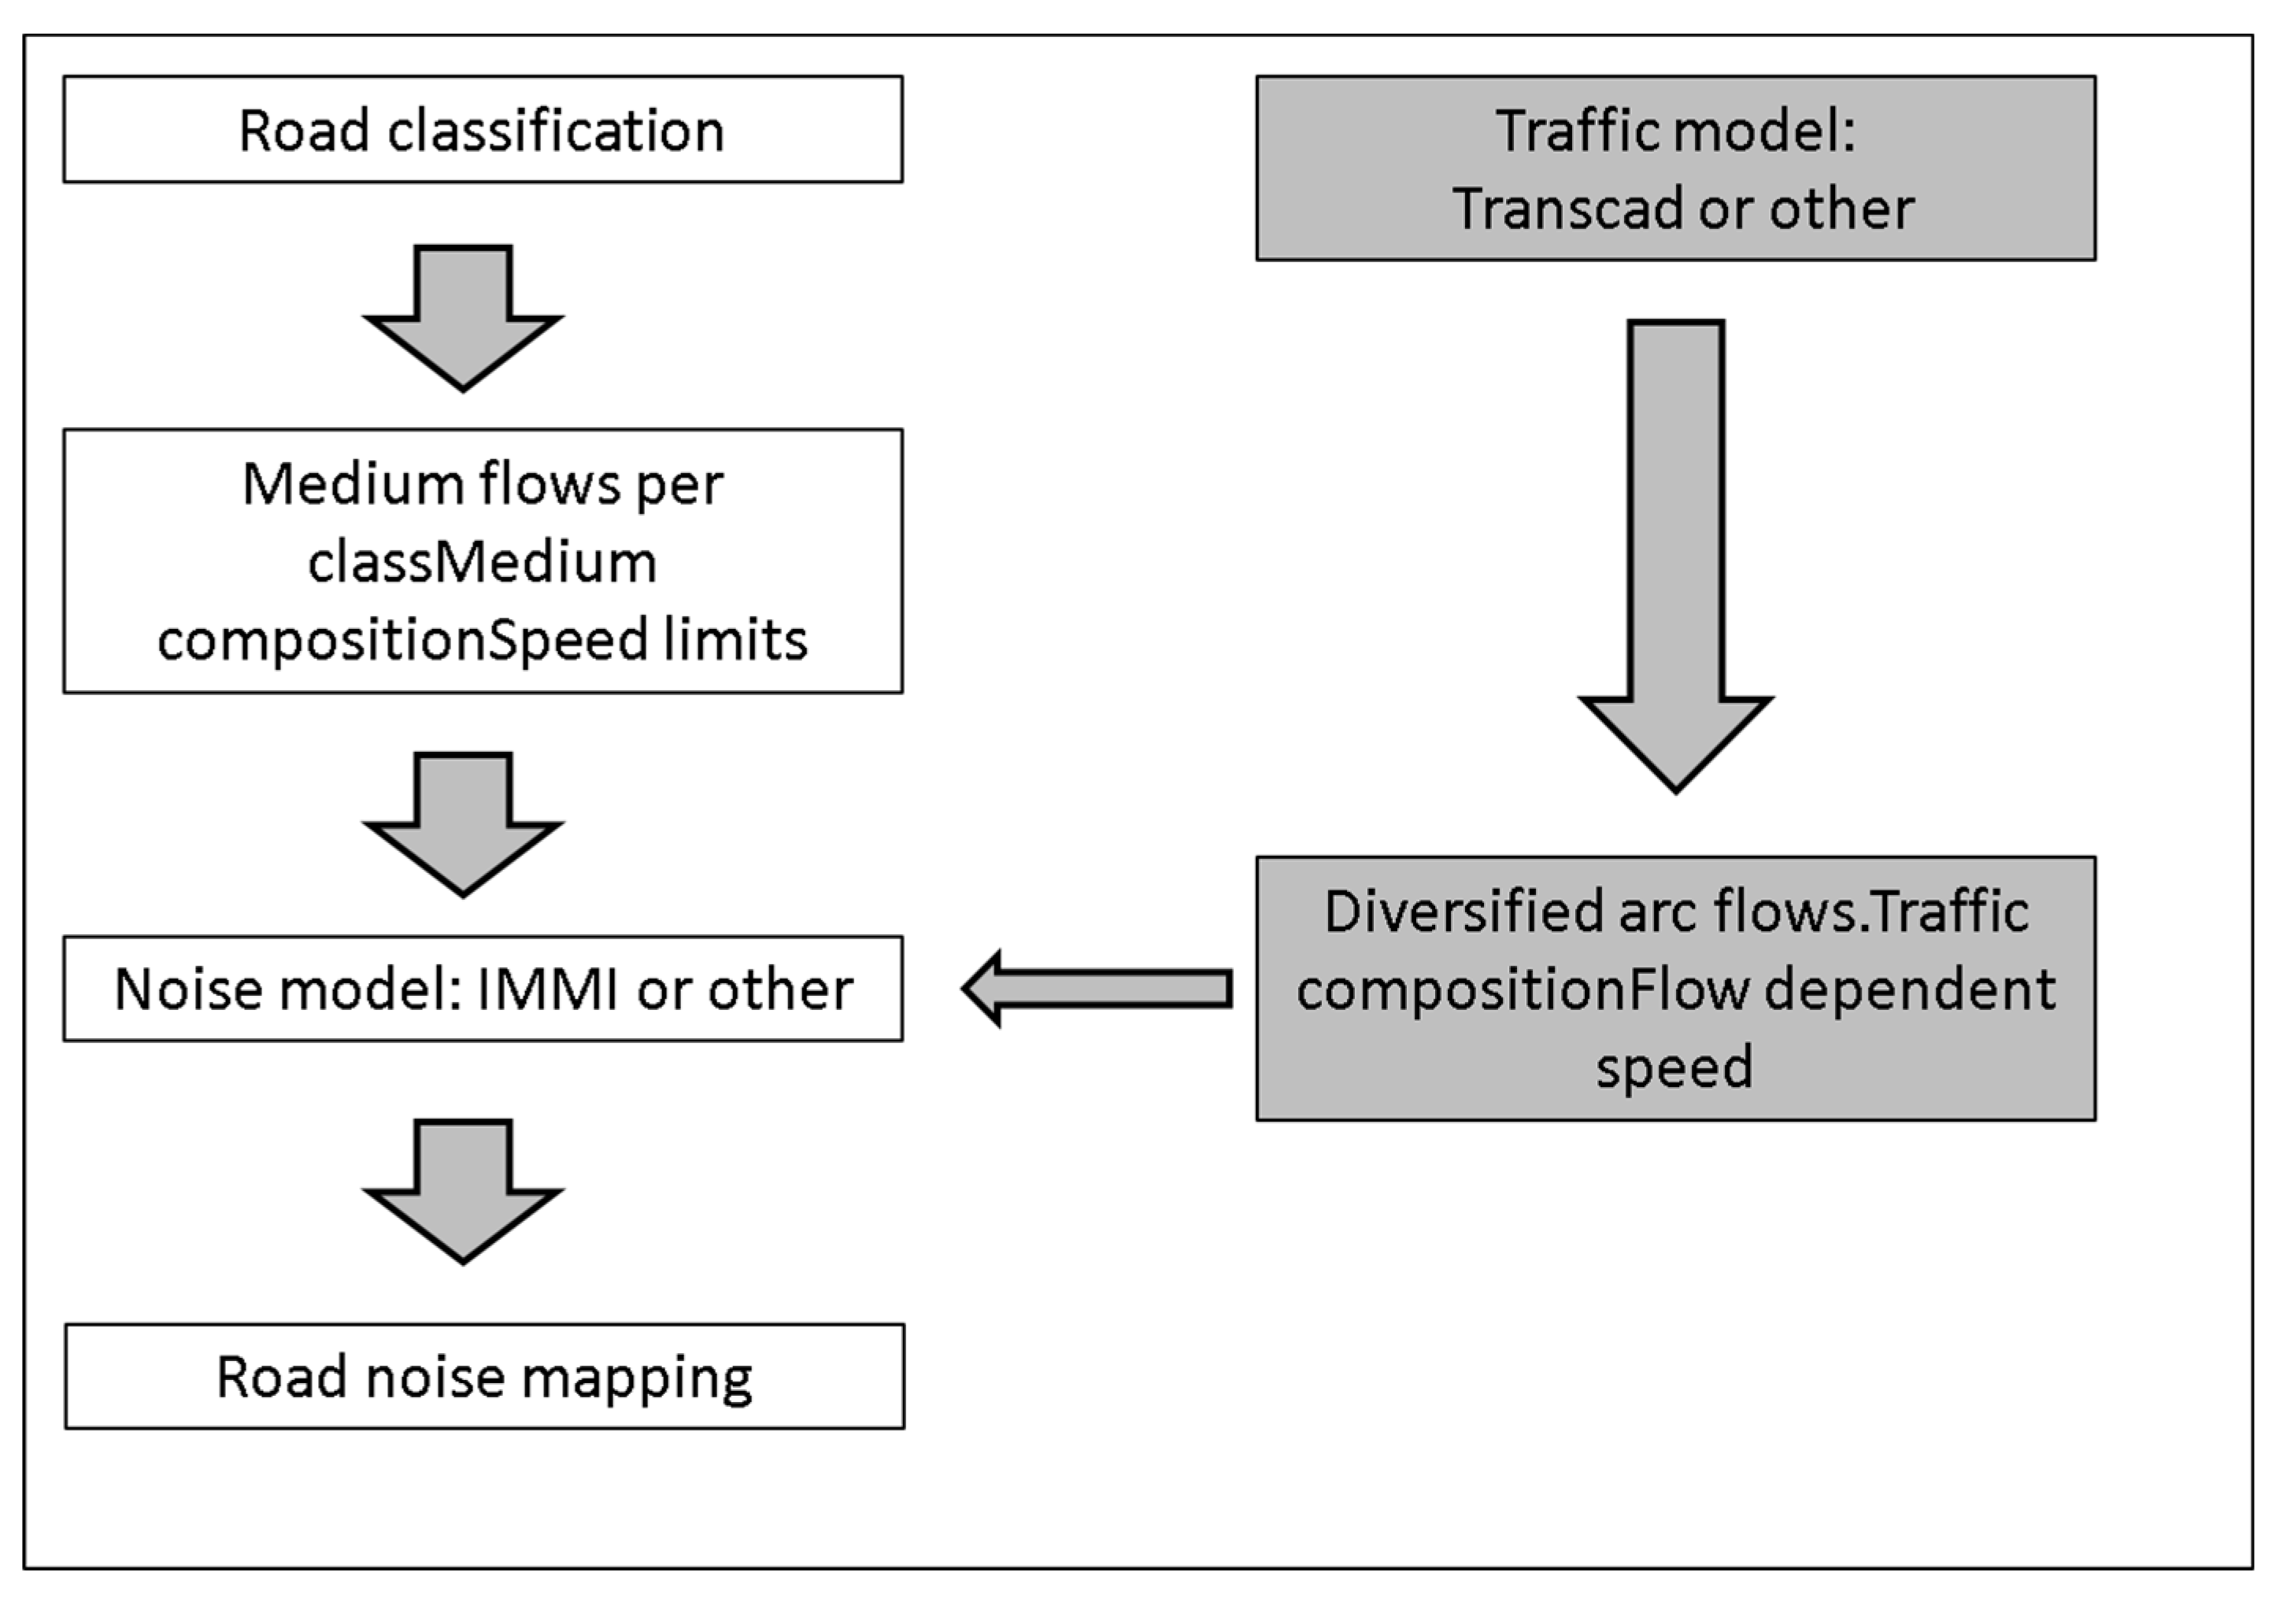
Figure 3.
Trend over time of static and dynamic models.
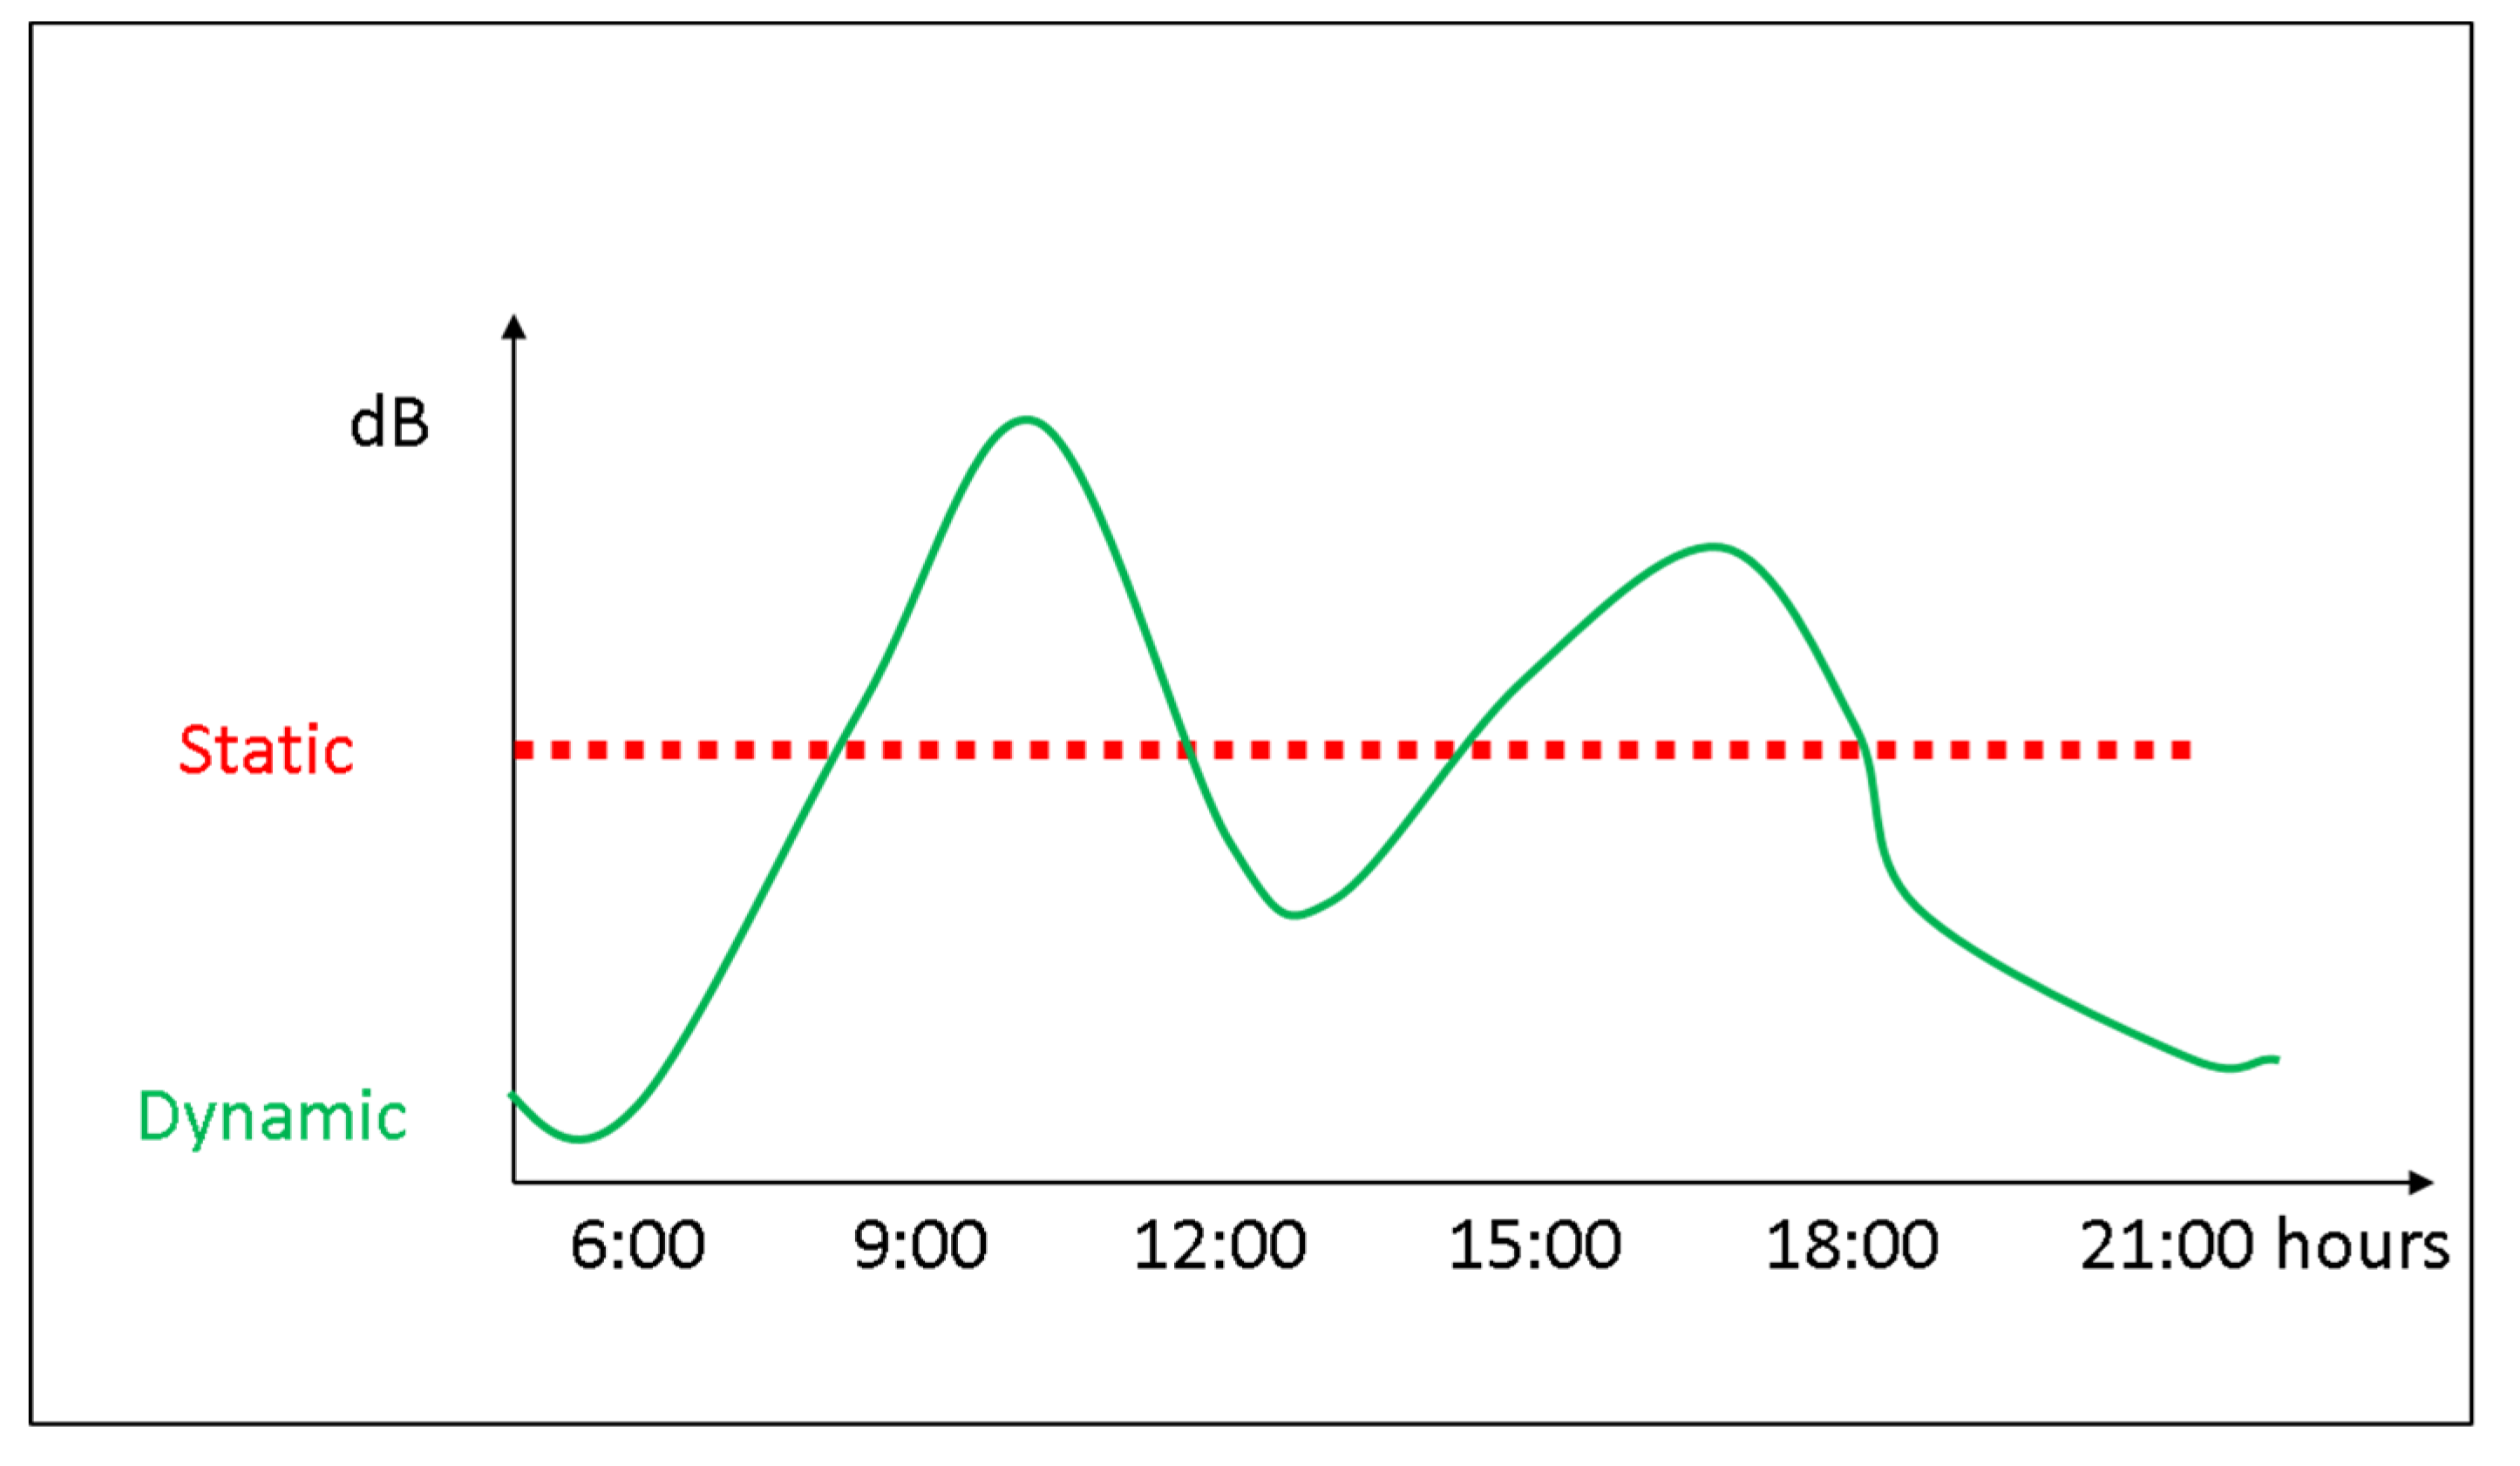
Figure 4.
Areas of application of static and dynamic models by variable, by study area and by study period.
Figure 4.
Areas of application of static and dynamic models by variable, by study area and by study period.
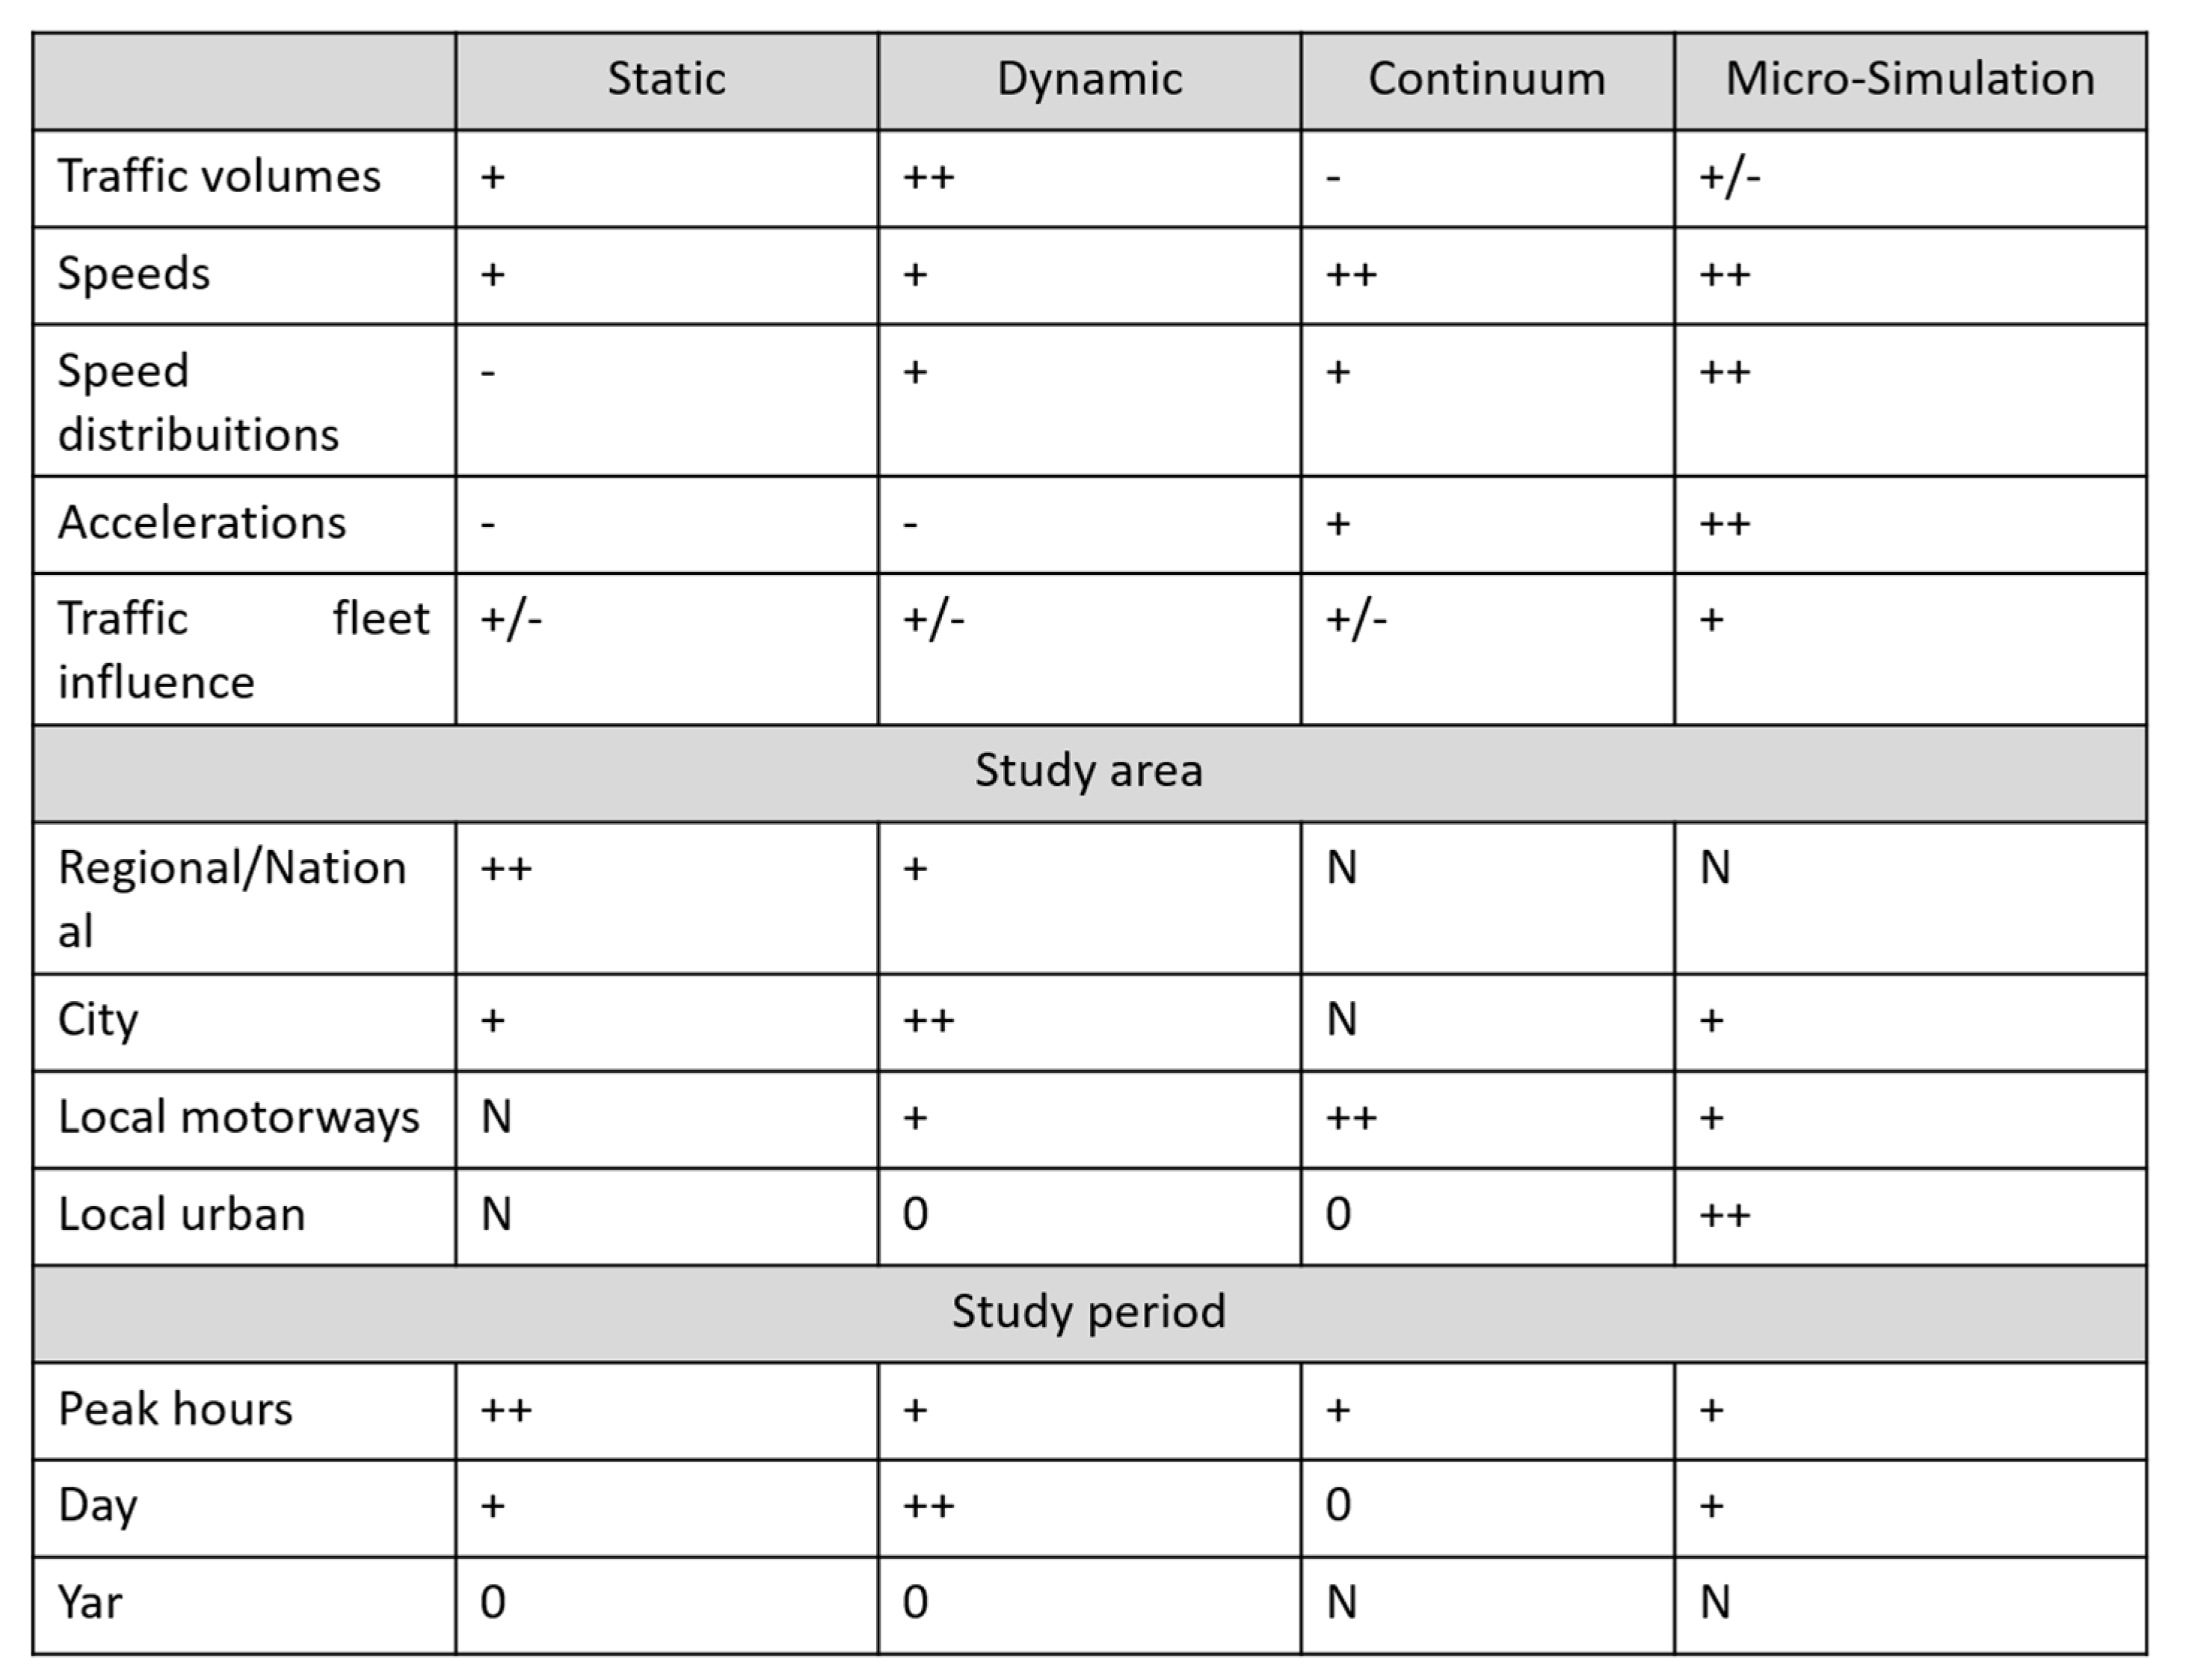
Figure 5.
Conceptual schemes of Biological and Artificial neural networks.
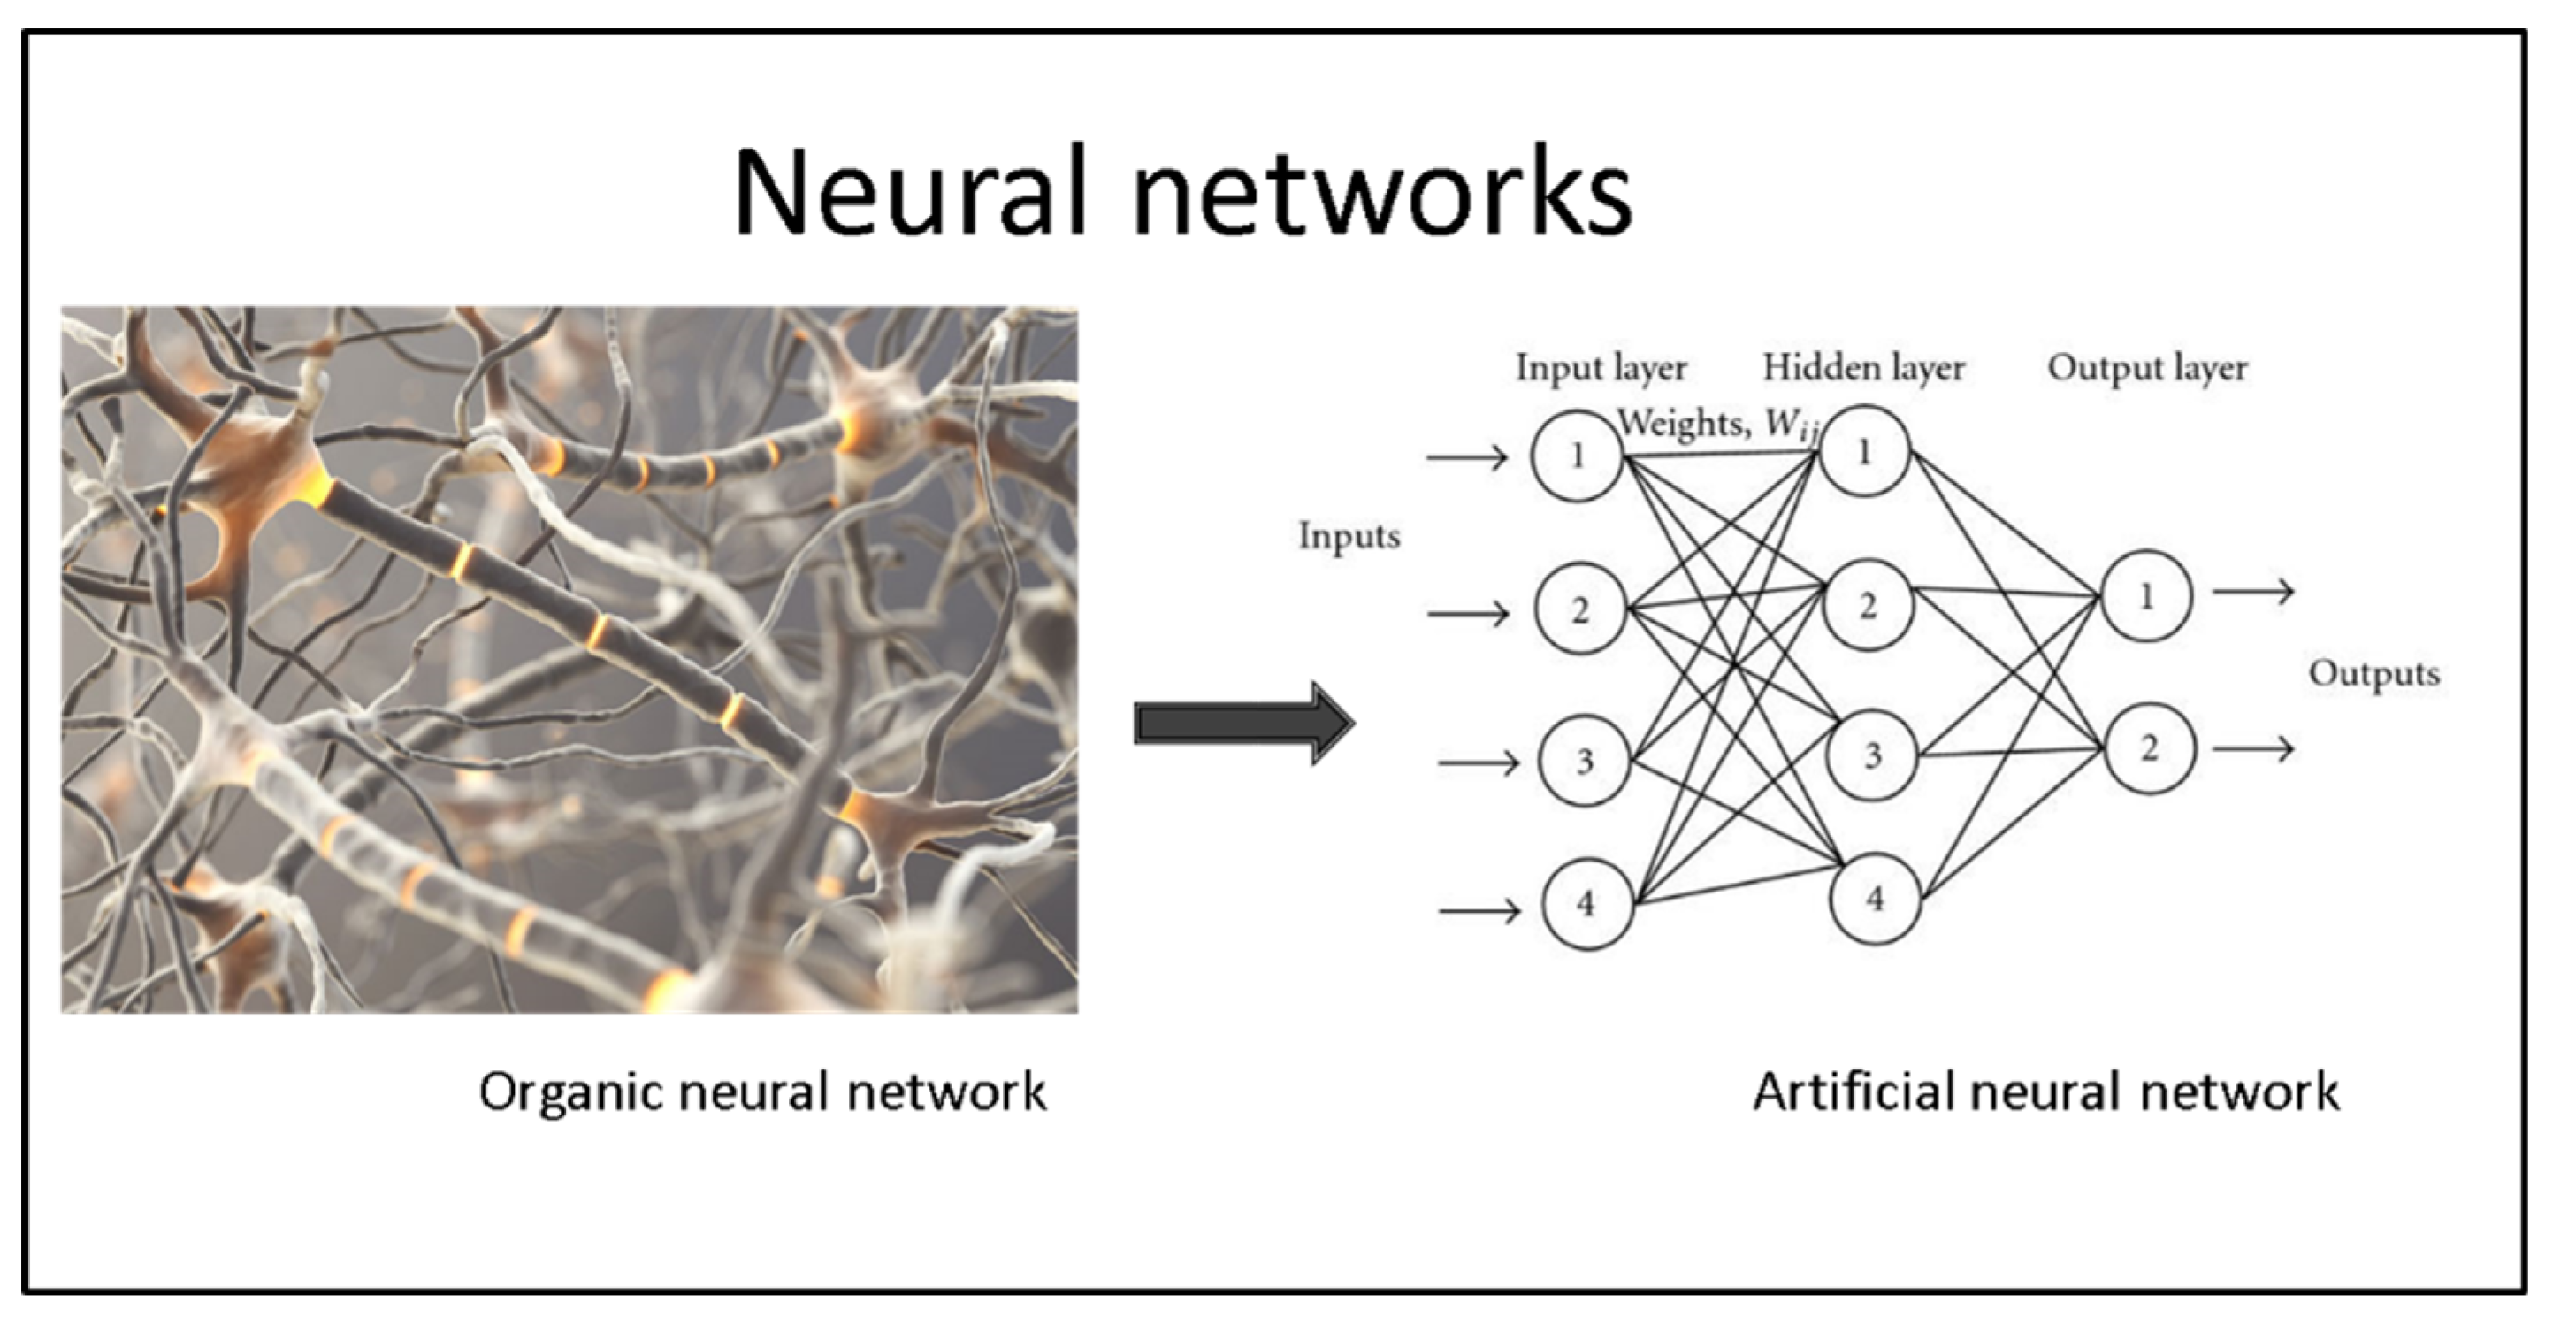
Figure 6.
NN Learning scheme, a) supervised - b) unsupervised.
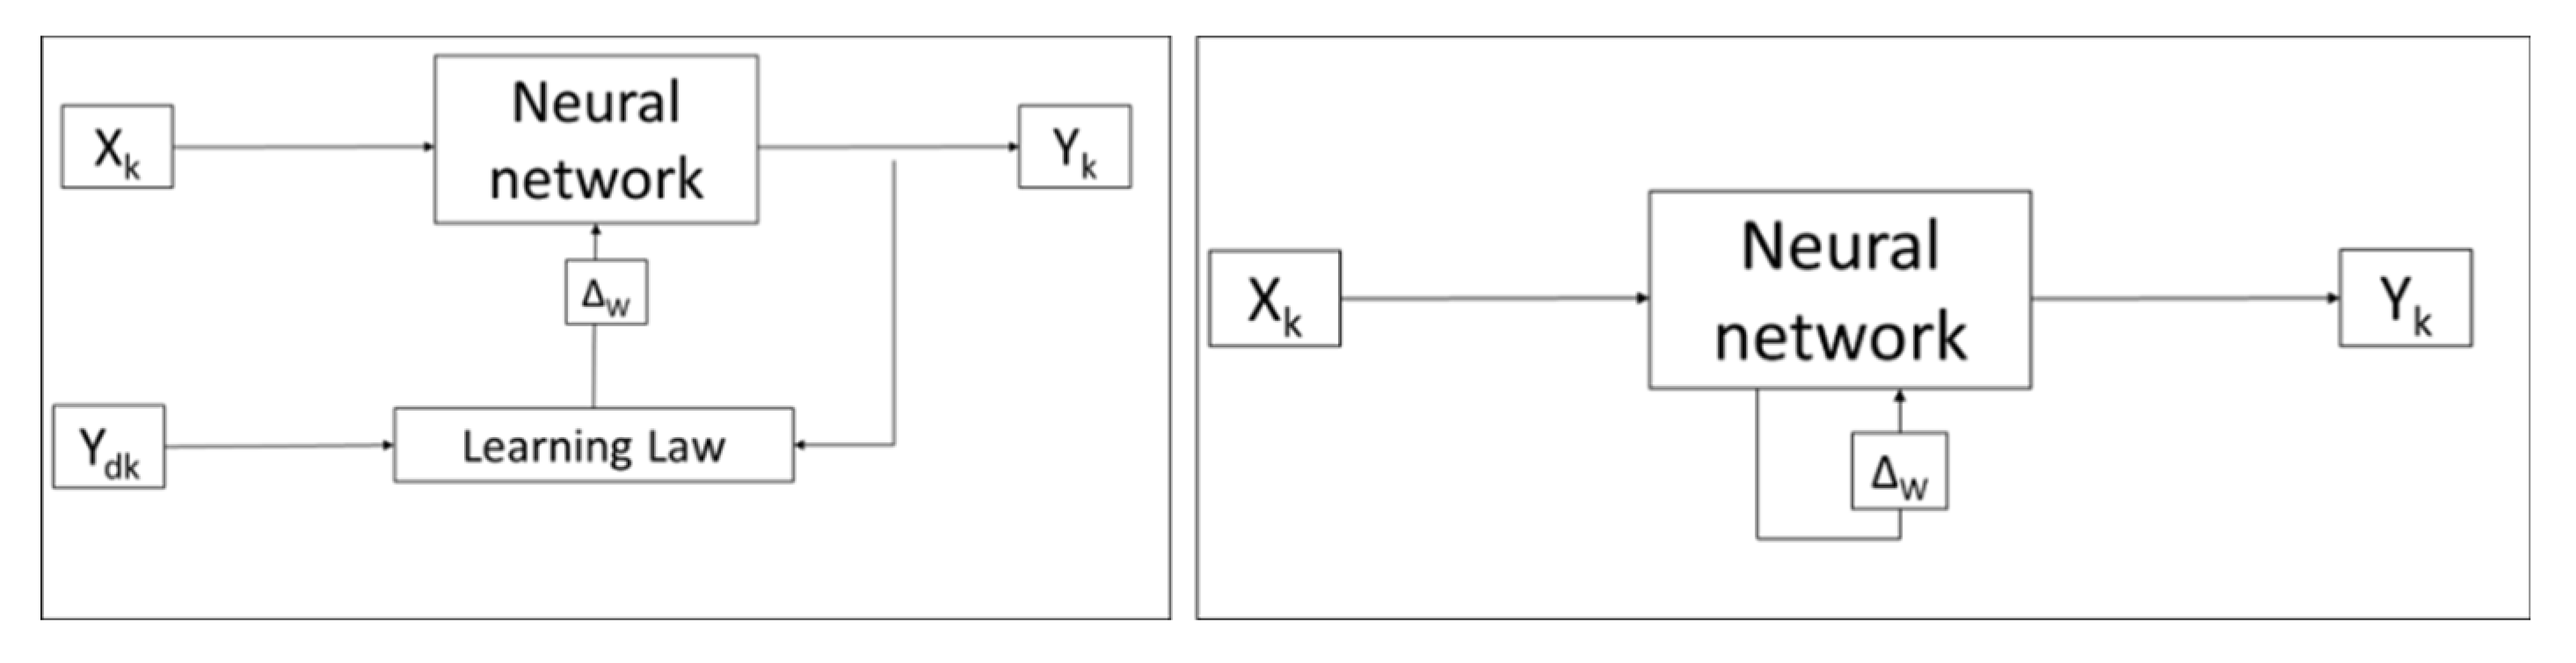
Figure 7.
Area affected by the case study.
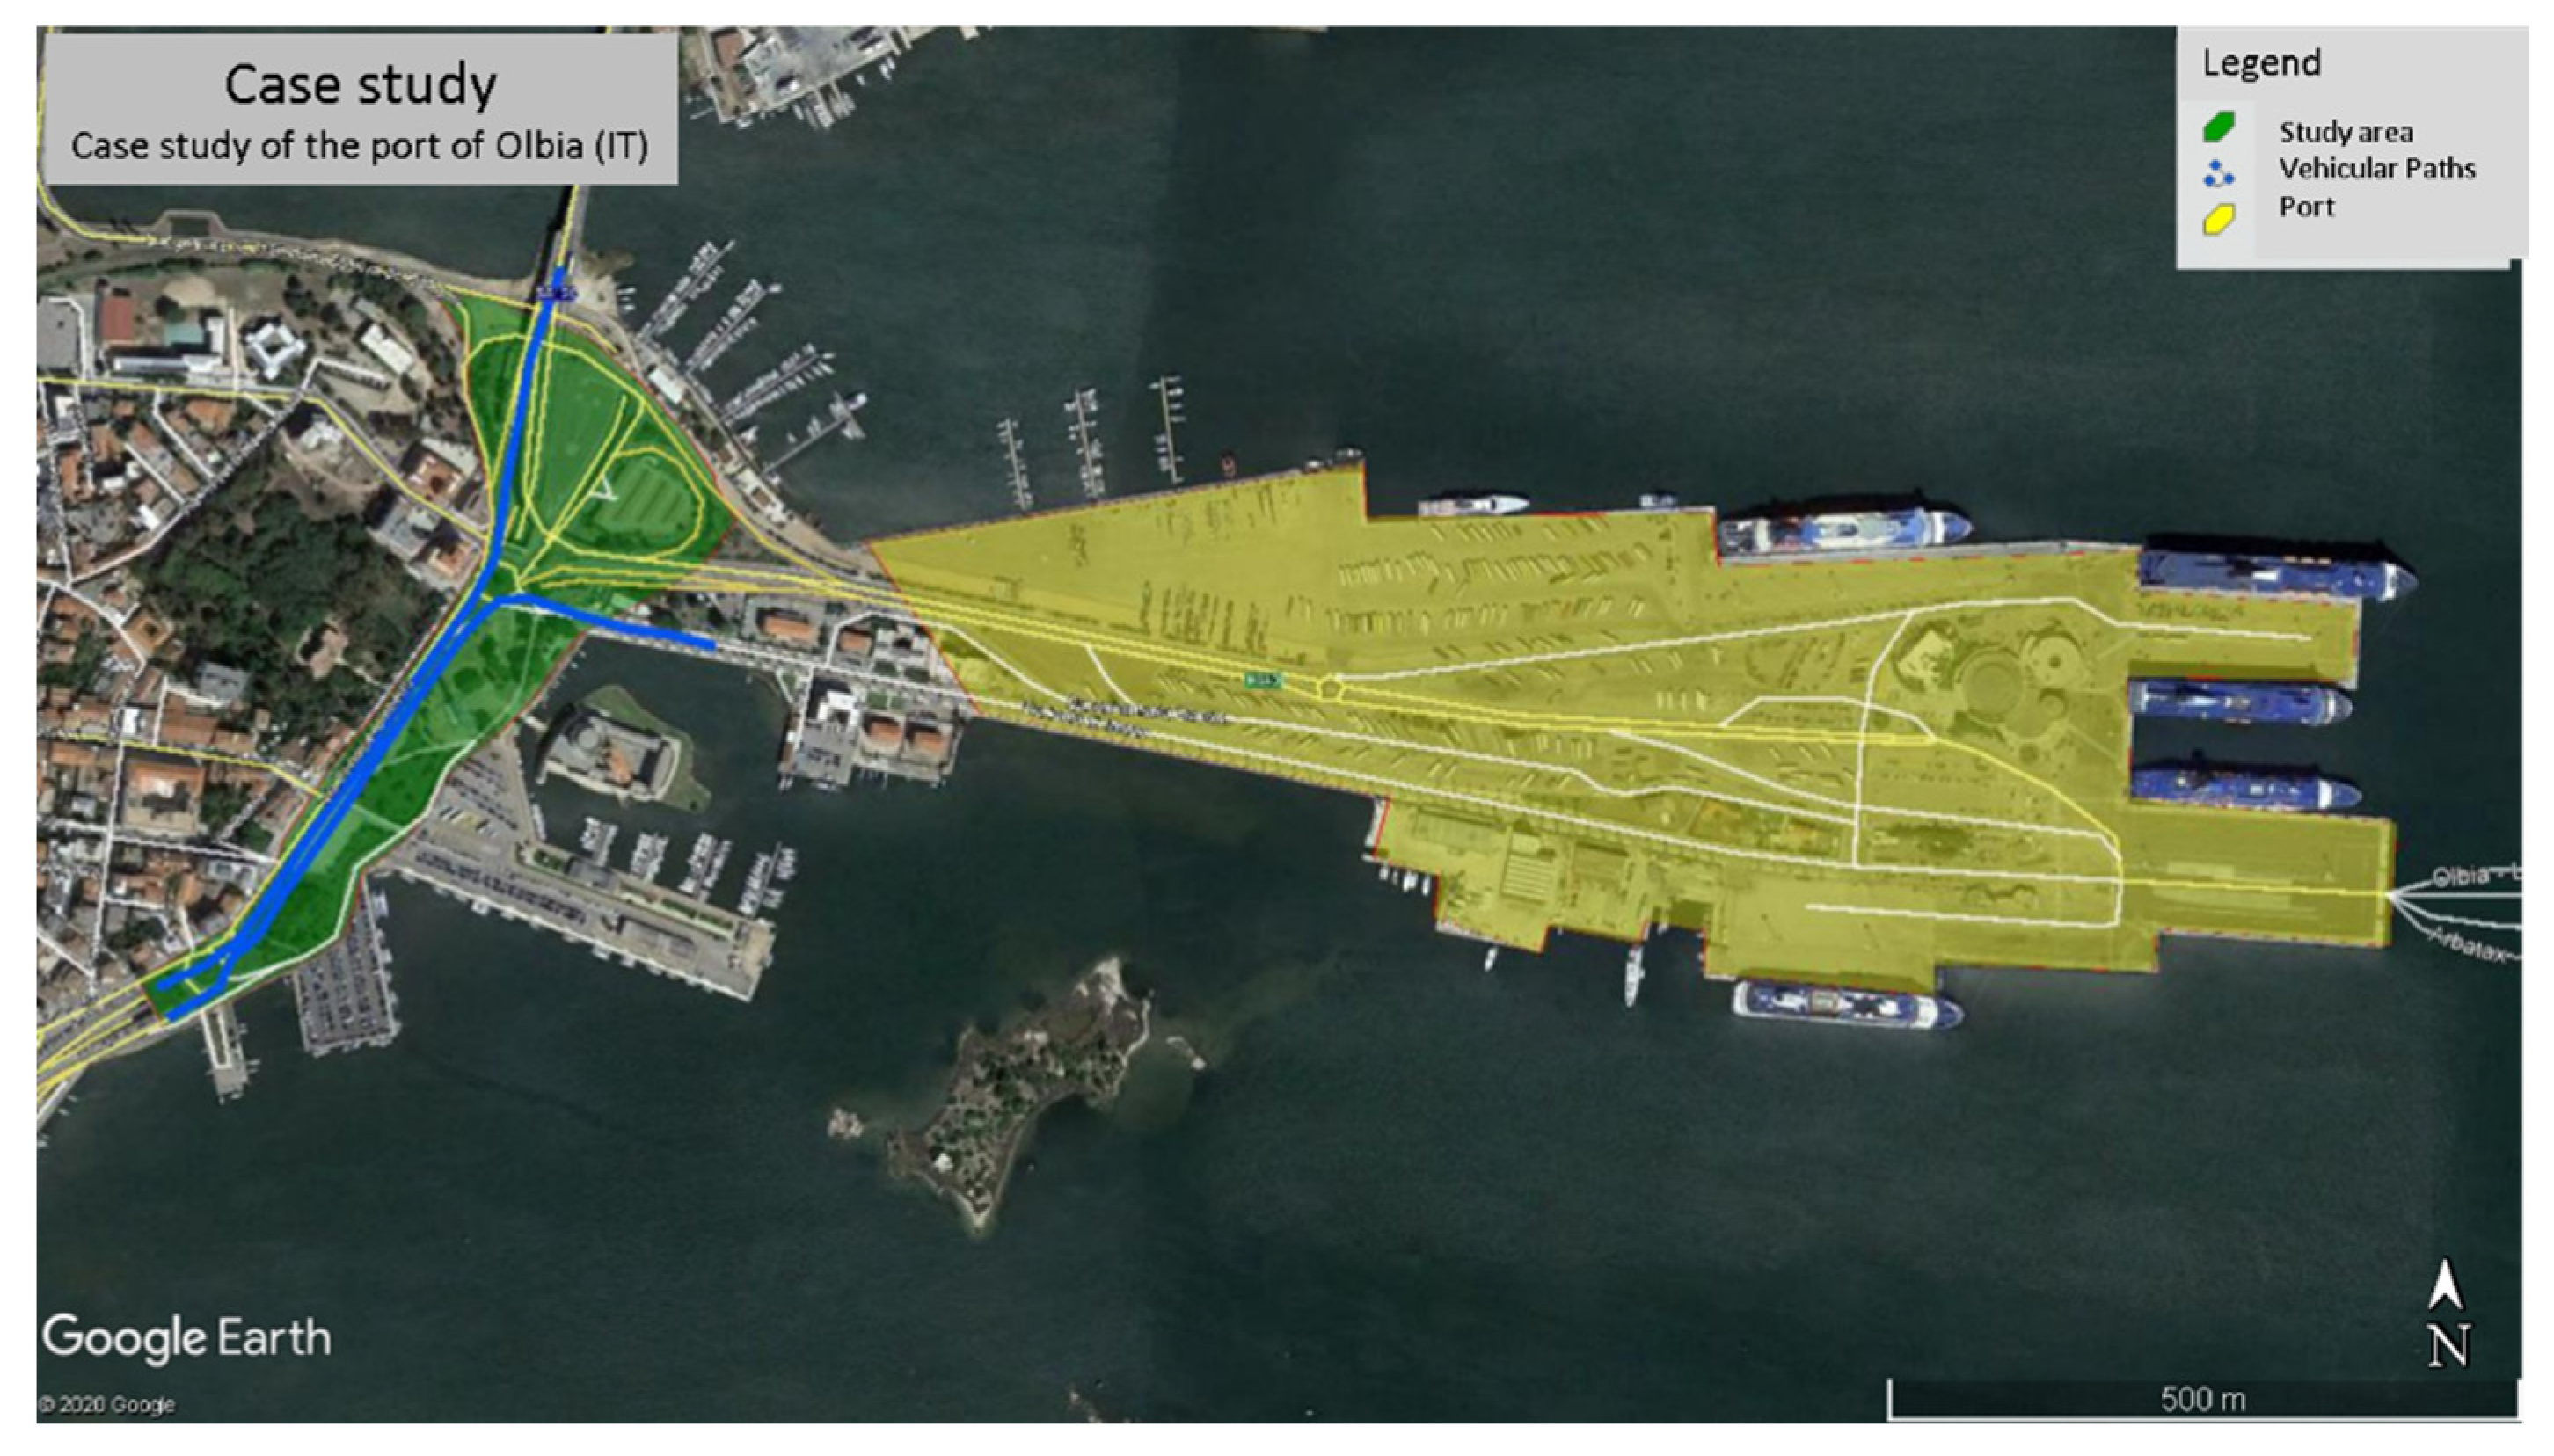
Figure 9.
Comparison between the neural network model (NNM) and the physical model (PhM) over the three reference periods of Directive 2002/49/EC, at the three receiver positions A, B and C. Reference periods for which the neural model is not available are omitted.
Figure 9.
Comparison between the neural network model (NNM) and the physical model (PhM) over the three reference periods of Directive 2002/49/EC, at the three receiver positions A, B and C. Reference periods for which the neural model is not available are omitted.
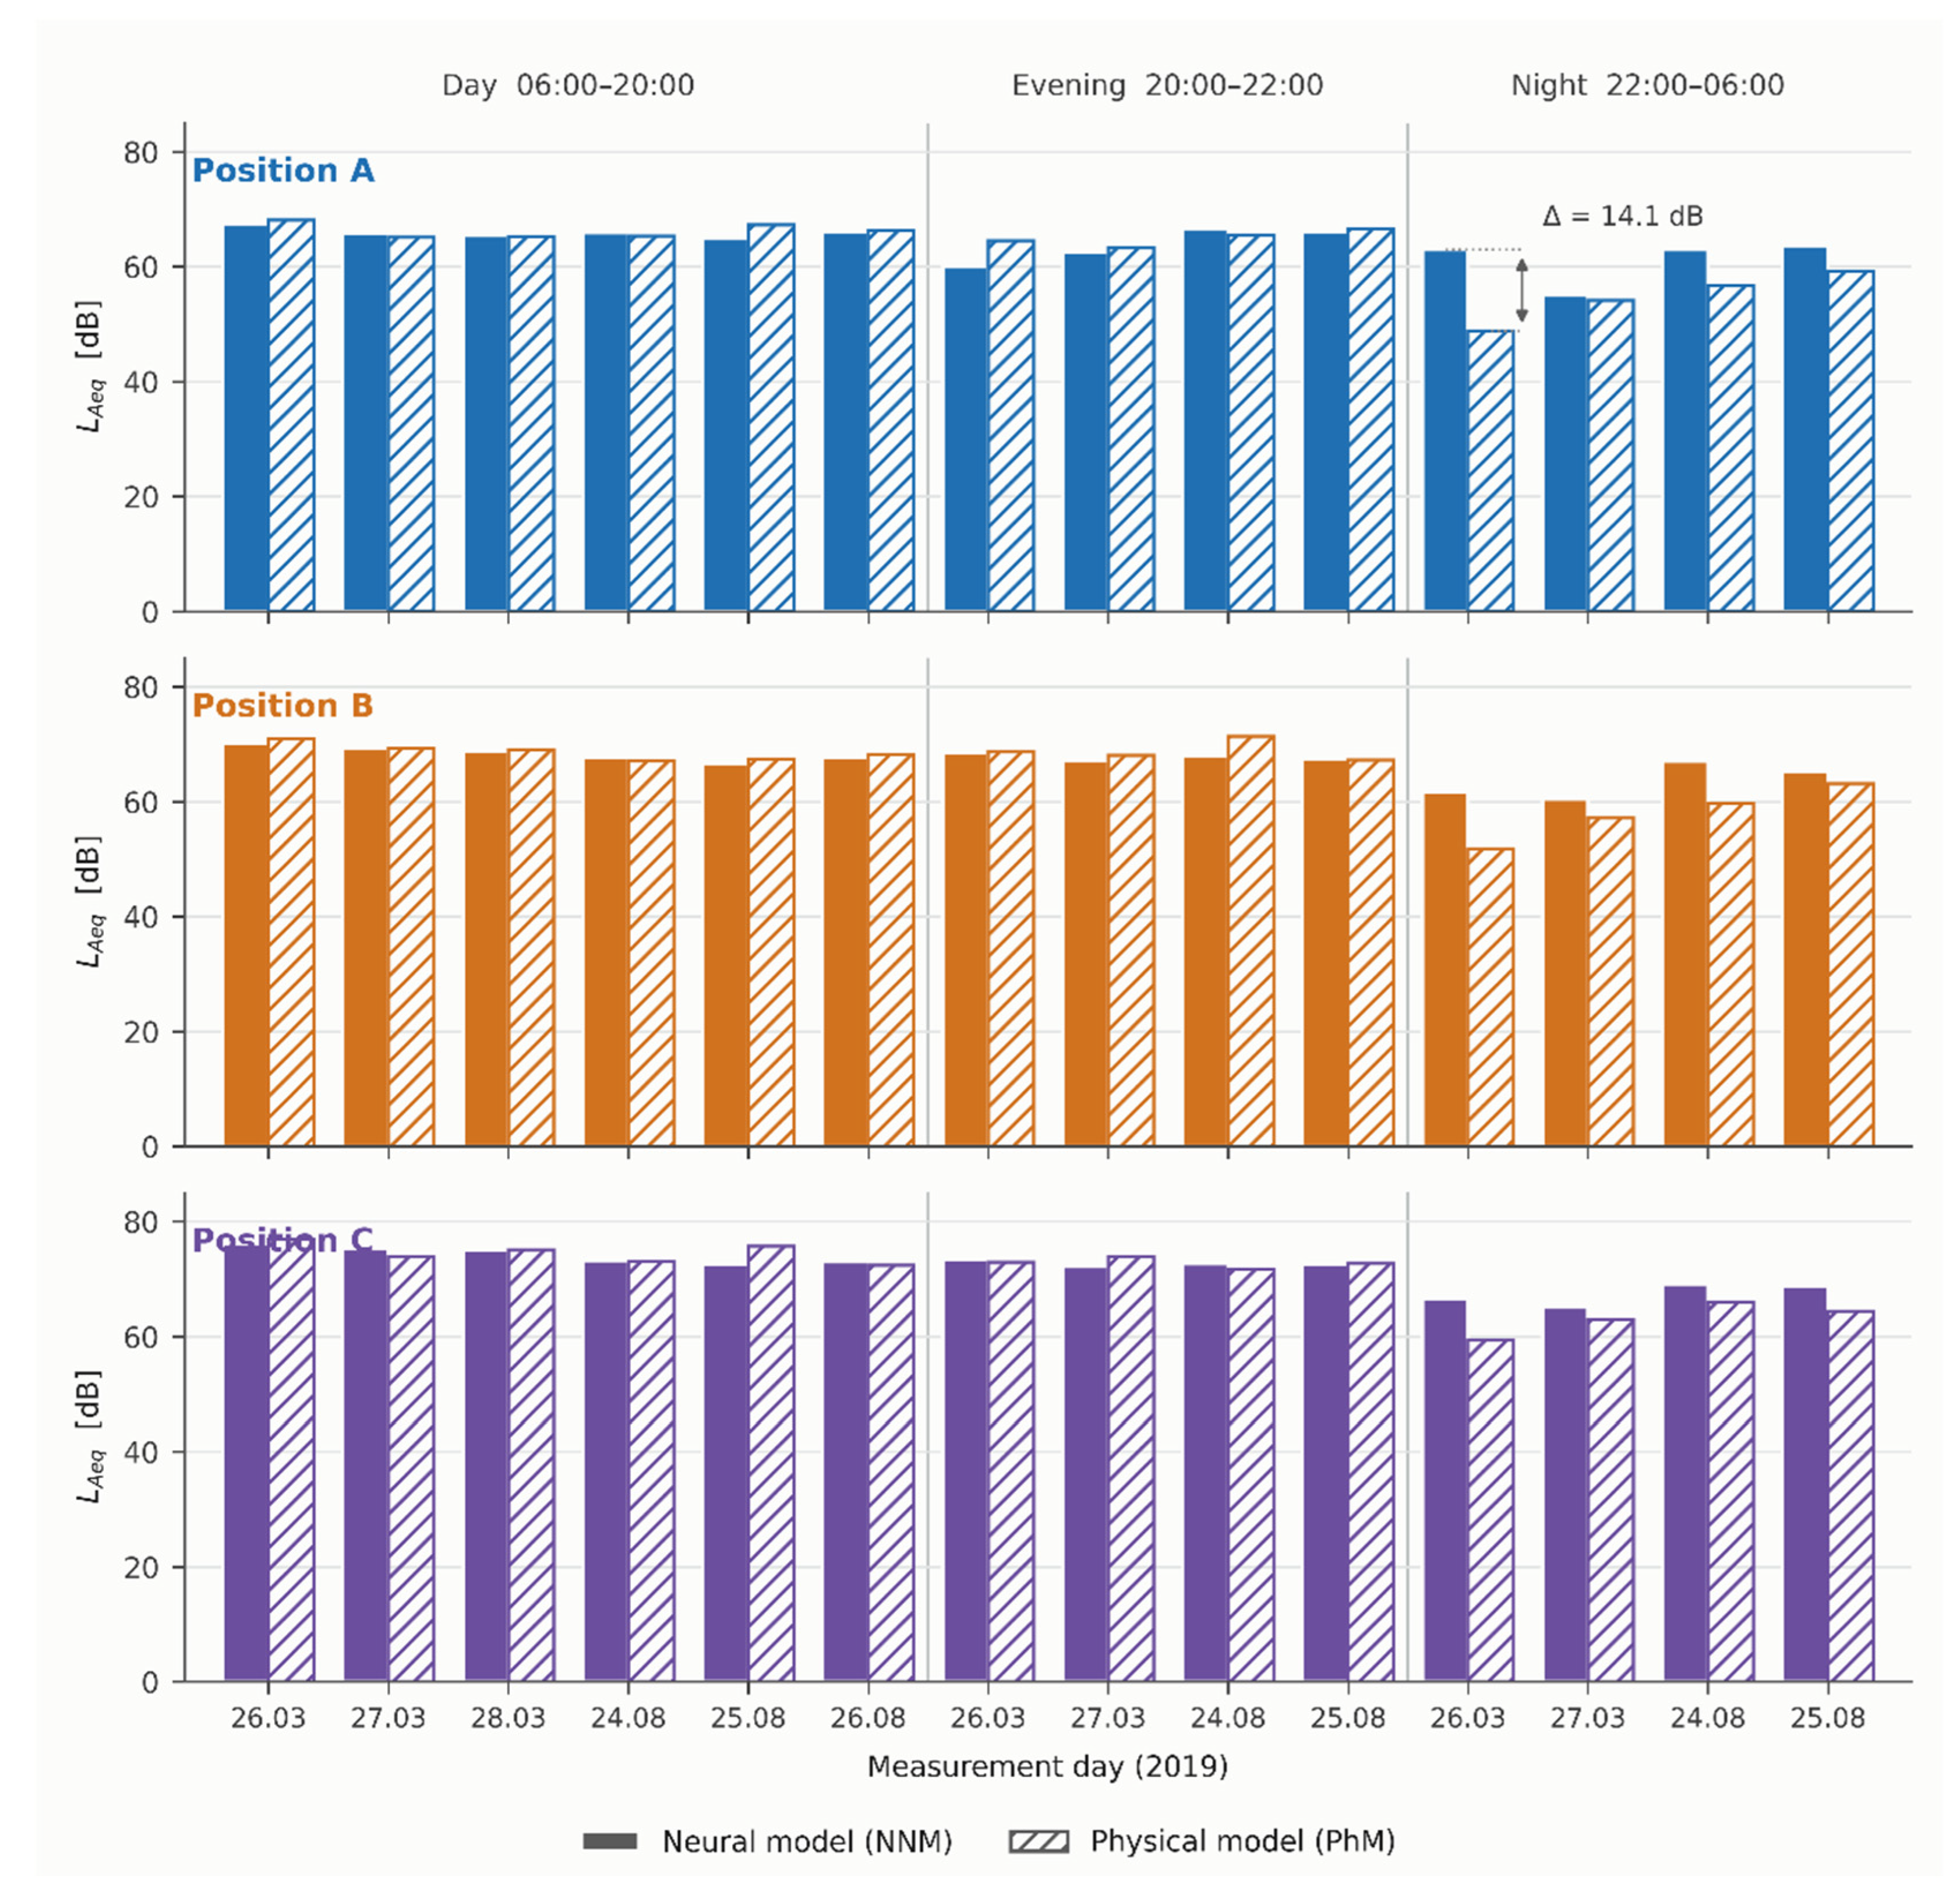
Figure 10.
Difference Δ = LAeq,NNM − LAeq,PhM between the neural network model and the physical model, by reference period and receiver position (A, B, C). Positive values indicate that the neural model returns to the higher level. The difference remains within ±3.5 dB throughout the day and evening periods, with no systematic sign, and becomes positive at every receiver position, on every measurement day and in both seasons during the night period, reaching 14.1 dB at position A on 26 March.
Figure 10.
Difference Δ = LAeq,NNM − LAeq,PhM between the neural network model and the physical model, by reference period and receiver position (A, B, C). Positive values indicate that the neural model returns to the higher level. The difference remains within ±3.5 dB throughout the day and evening periods, with no systematic sign, and becomes positive at every receiver position, on every measurement day and in both seasons during the night period, reaching 14.1 dB at position A on 26 March.
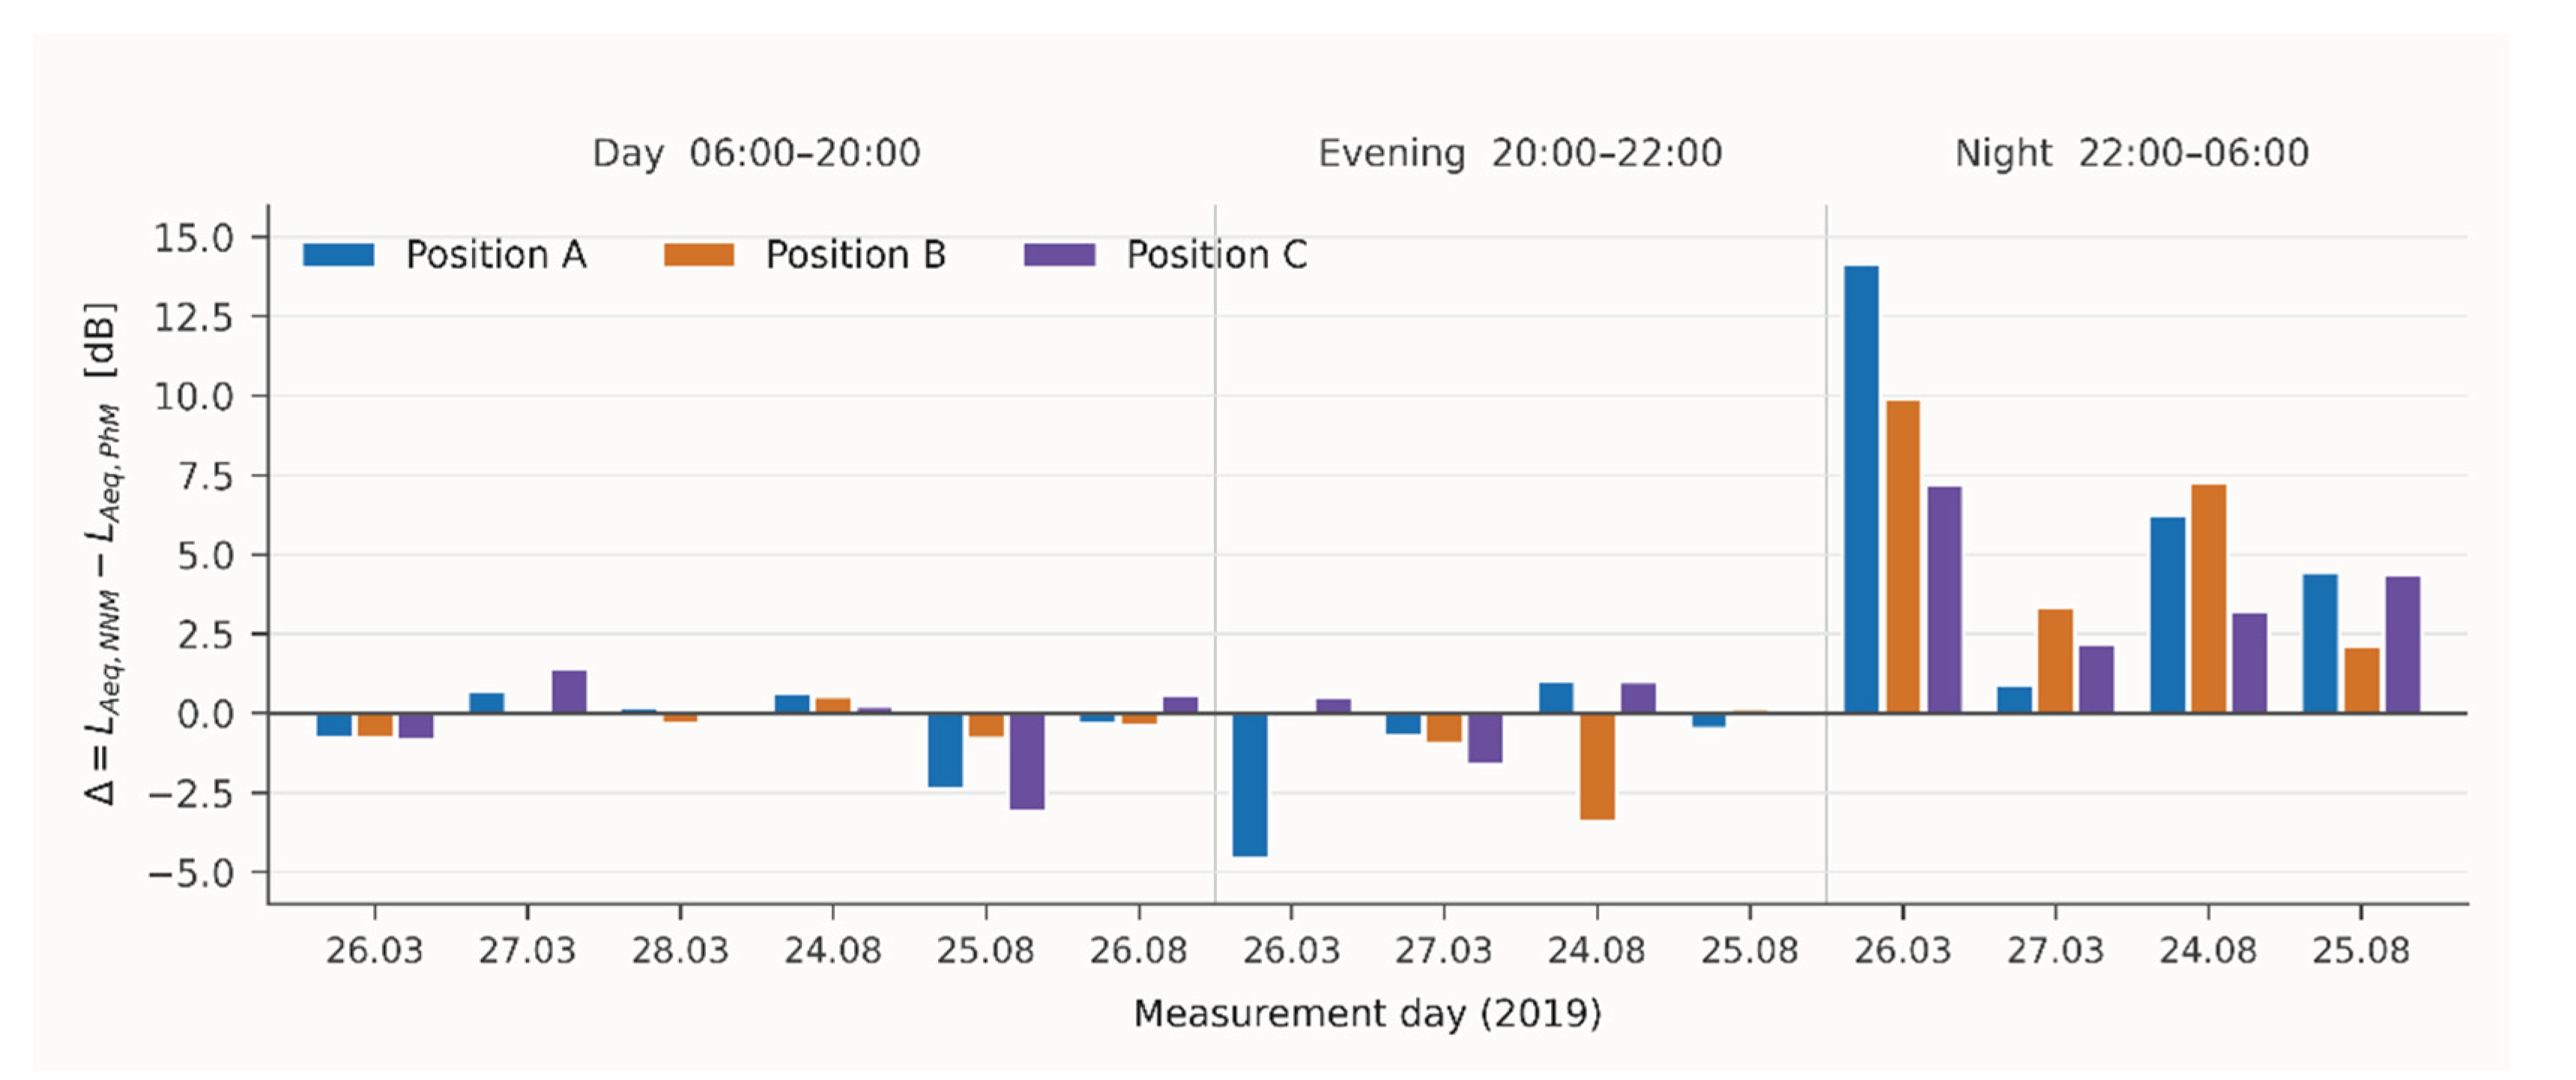

Table 1.
Noise management decision levels and their information requirements.
| Decision level | Horizon | Information required | Model able to provide it |
|---|---|---|---|
| Strategic mapping (Art. 7) | 5 years | Lden, Lnight over the whole domain, on a grid, traceable to Annex II | Physical only |
| Action planning (Art. 8) | Months | Difference between the present state and scenarios not yet realised | Physical only |
| Tactical (call schedule) | Days | Expected levels by reference period as a function of the planned call programme | Both — the comparison is decisive here |
| Operational (berth management) | Hours to minutes | Continuously updated prediction from traffic data already being collected | Data-driven only |
Table 2.
Comparative table of methodologies.
| Criterion | Physical model (CadnaA / CNOSSOS-EU) | Neural model (NARX) |
|---|---|---|
| Input data | Road geometry, buildings, ground, traffic flows and speeds by class, meteorology | Flow rate and speed by class and lane (15 lanes) + noise regressors |
| Availability of input data | To be estimated or surveyed | Already collected for terminal operations |
| Temporal resolution | Hourly, aggregated into Lday / Levening / Lnight | 1 min (LAeq,1′) |
| Spatial coverage | Full domain, grid map + receivers | Instrumented positions only (A, B, C) |
| Latency | 3–36 h depending on grid resolution | Near-real-time inference |
| Set-up requirement | Geometric model + acoustic characterisation + calibration | Monitoring campaign + classified counting + training |
| Set-up cost | 50 k€ | 80 k€ |
| 5-year updating cost | 10 k€ | 5 k€ |
| Use on unrealised scenarios | Yes | No |
| Transferability to another site | Yes, with new geometry | No, requires a new campaign |
| Regulatory traceability | Full (Annex II, Dir. 2002/49/EC) | None |
| Interpretability | Explicit physical terms | Black box |
Table 3.
Difference Δ = LAeq,NNM − LAeq,PhM between the neural and the physical model, by reference period and receiver position. All values in dB.
Table 3.
Difference Δ = LAeq,NNM − LAeq,PhM between the neural and the physical model, by reference period and receiver position. All values in dB.
| Reference period | Mean Δ, A | Mean Δ, B | Mean Δ, C | Mean |Δ| | Max |Δ| |
|---|---|---|---|---|---|
| 06:00–20:00 (day) | −0.33 | −0.31 | −0.30 | 0.78 | 3.09 |
| 20:00–22:00 (evening) | −1.20 | −1.09 | −0.06 | 1.22 | 4.57 |
| 22:00–06:00 (night) | +6.43 | +5.65 | +4.23 | 5.43 | 14.13 |
Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license (http://creativecommons.org/licenses/by/4.0/).
Copyright: This open access article is published under a Creative Commons CC BY 4.0 license, which permit the free download, distribution, and reuse, provided that the author and preprint are cited in any reuse.