

Submitted:
16 September 2026
Posted:
18 September 2026
You are already at the latest version
Abstract
Let \( A \) be an invertible normal hyperbolic operator on a complex Hilbert space \( H \). We obtain an exact spectral formula for the optimal uniform shadowability constant \( Shad(A) \), sharpening the general additive Green-operator estimates to a Euclidean combination of the stable and unstable spectral contributions. If both spectral components are nonempty, set \( \alpha(A)=1-\max\{|\lambda|:\lambda\in\sigma(A),\ |\lambda|<1\}, \) and \( \beta(A)=\min\{|\lambda|:\lambda\in\sigma(A),\ |\lambda|>1\}-1. \) We prove the exact formula \( Shad(A)=\left(\alpha(A)^{-2}+\beta(A)^{-2}\right)^{1/2}, \) with the corresponding one-sided formulas when only one spectral component is present. We further relate this exact constant to the robustness of hyperbolicity. Let \( r_{\mathrm{hyp}}(A) \) denote the operator-norm distance from \( A \) to the loss of hyperbolicity. We obtain the sharp universal ratio \( 1\le r_{\mathrm{hyp}}(A)Shad(A)\le\sqrt{2}. \) Both constants are optimal. In the mixed case, \( r_{\mathrm{hyp}}(A)Shad(A)=\left[1+\left(\frac{\min\{\alpha(A),\beta(A)\}}{\max\{\alpha(A),\beta(A)\}}\right)^2 \right]^{1/2}. \) Thus the normalized shadowability constant is determined exactly by the relative balance of the stable and unstable spectral gaps.
Keywords:
shadowing property
; normal operator
; hyperbolicity
; stability radius
; Ulam stability
; linear difference equation
MSC: Primary 37C50; 47A10; Secondary 39A30; 47A55
1. Introduction
The shadowing property is a fundamental notion in dynamical systems that describes whether approximate trajectories can be uniformly traced by exact trajectories. In the setting of linear dynamics, shadowing is closely related to spectral hyperbolicity, although the relationship becomes substantially more subtle in infinite-dimensional spaces. It is classical that every invertible hyperbolic operator on a Banach space has the shadowing property; see [1,2] and also [3]. The converse, however, fails in general in infinite dimensions: Bernardes, Cirilo, Darji, Messaoudi and Pujals constructed nonhyperbolic invertible operators with the shadowing property, thereby exhibiting a phenomenon that has no direct finite-dimensional analogue [4]. Subsequent work has further investigated generalized hyperbolicity and shadowing for classes of operators on function and sequence spaces [5,6].
For the class of normal operators the qualitative question is completely settled. Mazur proved that a normal operator on a Hilbert space is hyperbolic if and only if it has the shadowing property, by reducing the problem, through the spectral theorem, to multiplication operators [7]; a streamlined proof is given in [4], where the positive shadowing property is also treated for not necessarily invertible normal operators. More recently, Pituk obtained a spectral characterization valid for every invertible Hilbert-space operator, showing that the shadowing property is equivalent to the right spectrum being disjoint from the unit circle [8]. Since the right spectrum of a normal operator coincides with its spectrum, the two results agree on the class considered here. In the same direction, the relation between the shadowing property and generalized hyperbolicity has recently been clarified in [9], and the equivalence of the various notions of hyperbolicity, stability and shadowing for linear operators has been further investigated in [10]. For normal operators the qualitative picture is therefore complete.
The results quoted above answer the qualitative question of whether shadowing occurs. The complementary task is quantitative: one asks how the shadowing error depends on the size of the underlying perturbation. Morales and Nguyen developed such a quantitative viewpoint for linear operators by introducing a shadowability constant and relating it, for hyperbolic operators, to the inverse of the difference operator associated with the inhomogeneous recurrence [11]. More precisely, for an invertible hyperbolic operator A acting on a Banach space, the optimal uniform shadowability constant can be represented as the norm of the inverse of the operator
on the space of bounded bi-infinite sequences. This formulation turns the quantitative shadowing problem into an operator-norm problem.
A closely related quantitative theory has developed under the name of Hyers–Ulam stability. For linear difference equations, the best Ulam constant measures the smallest uniform factor controlling the distance between approximate and exact solutions. Optimal constants have been studied for first-order and higher-order difference equations, for equations with constant or alternating step sizes, and for Banach-space-valued recurrences; see, for example, [12,13,14,15]. In particular, this literature emphasizes that the determination of a best stability constant provides substantially more information than the mere existence of an Ulam stability estimate. The relation between bounded solvability, discrete dichotomies and robustness is also closely connected with the classical theory of admissibility for difference equations; see, for instance, [16]. The purpose of the present paper is to compare two quantitative features of a hyperbolic linear system: the optimal amplification of bounded pseudotrajectory errors and the operator-norm distance to the loss of hyperbolicity. This leads naturally to the hyperbolicity margin
where H is a complex Hilbert space and
Thus measures the operator-norm distance from A to the boundary of the set of hyperbolic operators. Our main results provide a sharp quantitative description in the normal Hilbert-space setting. Let be invertible, normal and hyperbolic, and suppose first that its spectrum has nonempty components on both sides of the unit circle. Define
and
The corresponding stable and unstable spectral gaps are
To the best of our knowledge, no exact formula for the optimal uniform shadowability constant in terms of the stable and unstable spectral gaps has previously been obtained for normal hyperbolic operators on arbitrary Hilbert spaces. The available general Green-operator estimates are additive in the stable and unstable contributions. In the normal Hilbert-space setting, we show that orthogonality changes this additive estimate into an exact Euclidean formula.
Our first main theorem establishes the exact identity
If the spectrum is entirely contained in the open unit disk, that is, if , the formula reduces to
whereas in the purely unstable case,
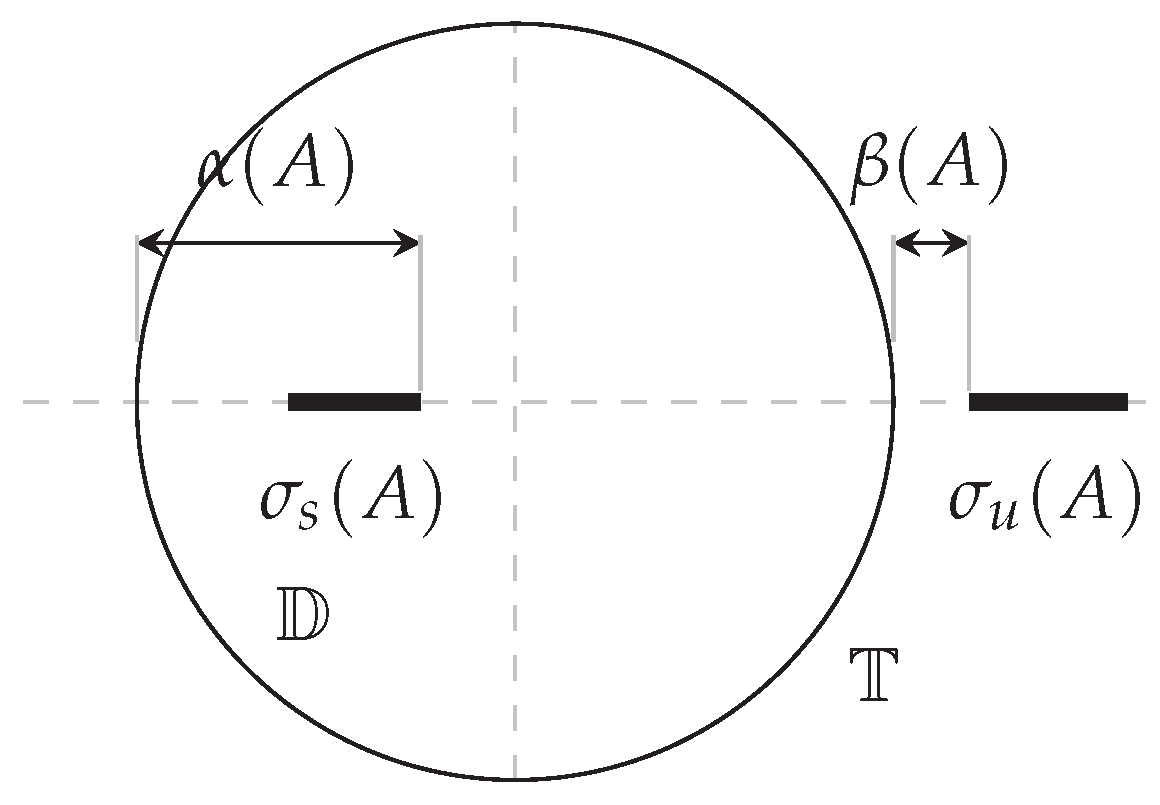
The geometry behind (1) is specifically Hilbertian; see Figure 1 for the spectral configuration underlying the two gap parameters. For a normal operator, the stable and unstable spectral subspaces form an orthogonal decomposition. The two components of the Green operator can therefore be combined quadratically rather than by a triangle inequality. This immediately suggests the upper estimate in (1), but sharpness requires an additional argument. We construct a bounded forcing whose negative-time part asymptotically maximizes the stable response and whose nonnegative-time part asymptotically maximizes the unstable response. Approximate eigenvectors associated with the two extremal spectral points align the corresponding finite Green sums. Since the two forcing components occupy disjoint time intervals, they can be combined without increasing the norm of the forcing. The quantitative statement is thus considerably finer than the qualitative one: the identity (1) describes how the optimal amplification degenerates as the spectrum approaches the unit circle. In this sense, it provides a quantitative refinement of the qualitative hyperbolicity–shadowing equivalence for normal operators established in [7].
The second main result relates the exact shadowability constant to the robustness of hyperbolicity. We first show that for an arbitrary hyperbolic operator
For normal operators the spectral theorem gives an explicit expression for the hyperbolicity margin. In the mixed stable–unstable case,
Combining this identity with (1) yields
where
Consequently,
The upper constant is attained precisely when the stable and unstable spectral gaps are equal. The lower value 1 is attained in the one-sided stable and unstable cases, while the inequality is strict on the left whenever both spectral components are nonempty.
Thus the normalized shadowability constant is governed by the relative balance of the stable and unstable spectral gaps rather than by their absolute size alone.
Two features of the quantitative theory deserve emphasis at the outset. First, the right-hand side of (1) is the norm of the inverse of the difference operator , whereas a qualitative shadowing statement for hyperbolic operators produces only the existence of a bounded solution and hence an unspecified finite constant. Second, the difference operator treats past and future asymmetrically, so that the two one-sided cases in Corollary 1 have to be treated separately.
The paper is organized as follows. In Section 2 we introduce the notation used throughout the paper, recall the difference-operator formulation of uniform linear shadowing, and establish the basic relation between the shadowability constant and the hyperbolicity margin. Section 3 contains the exact computation of the shadowability constant for normal hyperbolic operators. In Section 4 we derive the sharp stability ratio (4), characterize the equality cases, and give examples showing that the constants cannot be improved, including an infinite-dimensional example whose spectra have no spectral-edge eigenvalues. Section 5 contains concluding remarks and indicates possible extensions beyond the normal setting.
2. Preliminaries and Hyperbolicity Margins
Throughout the paper, H denotes a complex Hilbert space with norm , and denotes the Banach algebra of all bounded linear operators on H, equipped with the operator norm, which is also denoted by . The identity operator on H is denoted by I. For , its spectrum is denoted by .
We write
An operator is called hyperbolic if
In what follows, whenever bi-infinite dynamics are considered, the operator A is assumed to be invertible.
For a hyperbolic operator A, define the stable and unstable parts of the spectrum by
Since is compact and disjoint from , these two sets are disjoint compact spectral subsets and
Let and denote the Riesz spectral projections associated with and , respectively. We set
and denote the corresponding restrictions of A by
Then
and both and are invariant under A. If A is normal, the spectral theorem [17] implies that and are reducing and orthogonal. In that case,
Whenever , we define
Similarly, whenever , we define
Hyperbolicity implies
whenever the corresponding spectral component is nonempty. For brevity, when the operator is fixed we write
instead of
2.1. The Difference Operator and the Shadowability Constant
Let
equipped with the norm
For , define the difference operator
by
Following Morales and Nguyen [11], the shadowability constant of an invertible linear operator A is denoted by . Equivalently, is the infimum of all constants with the following property: for every there exists satisfying
and
For hyperbolic A, the difference operator is invertible and
Indeed, is bijective by Lemma 1 below, so its inverse is bounded by the open mapping theorem, and (16) merely restates the definition of the operator norm together with the scale invariance of (15). We shall use (16) throughout the paper.
The inverse of admits the usual Green representation. For completeness, we record the formula in the notation used here.
Lemma 1.
Let be invertible and hyperbolic. For every , the unique bounded solution of (14) is given by
Both series converge in H, uniformly with respect to n for e ranging over bounded subsets of .
Proof.
Since
we have
where denotes the spectral radius. Choose numbers satisfying
By the spectral radius formula, there exist constants such that
Hence both series in (17) converge absolutely and uniformly in n whenever is bounded.
Set
Then
whereas
Therefore
Similarly, define
A direct index shift gives
It remains to prove uniqueness. Suppose that satisfies
Write , where and . For every ,
Hence
Letting gives . Similarly,
and therefore
Thus , and consequently for every . □
Remark 1.
Formula (17) exhibits an asymmetry that will be crucial in Section 3: at a fixed time n, the stable component of the bounded response depends only on the forcing at times strictly smaller than n, whereas the unstable component depends only on the forcing at times greater than or equal to n. This separation allows the two components to be optimized simultaneously under a single constraint.
2.2. The Hyperbolicity Margin
We now introduce the second quantitative object considered in this paper.
Definition 1.
Let be hyperbolic. The hyperbolicity margin of A is
Thus is the operator-norm distance from A to the complement of the set of hyperbolic operators. The following resolvent characterization is standard in stability-radius theory; see, e.g., [18]. We include the short proof for completeness.
Proposition 1.
Let be hyperbolic. Then
Proof.
We first recall that if is invertible, then
where denotes the group of bounded invertible operators on H.
Indeed, if satisfies
then
is invertible by the Neumann series. Hence the left-hand side of (22) is at least .
For the reverse inequality, set
Since B is invertible,
Given , choose a unit vector such that
Define the rank-one operator by
Then
so is not invertible. Moreover, , so Cauchy–Schwarz gives , while testing on gives the reverse inequality. Hence
Letting proves (22).
Now fix . Since A is hyperbolic, is invertible. The condition
is equivalent to the noninvertibility of
The map
is norm-continuous on the compact set . Hence the continuous positive function attains a maximum there, and taking reciprocals turns that maximum into the minimum of . Therefore
□
The resolvent characterization immediately gives a universal lower bound for the shadowability constant.
Proposition 2.
Let be invertible and hyperbolic. Then
Equivalently,
Proof.
Fix and a nonzero vector . Define by
Since ,
Define
Then and
Thus, by (16),
Taking the supremum over all gives
Since this holds for every ,
Proposition 1 now gives (23). □
Remark 2.
Proposition 2 does not require normality. It shows that the reciprocal hyperbolicity margin is a universal lower bound for uniform shadowing amplification. The normal case considered in the next section is distinguished by the fact that the gap between these two quantities can be determined exactly.
3. Sharp Shadowability Bounds for Normal Hyperbolic Operators
We now assume that is normal, invertible and hyperbolic. The orthogonality of the stable and unstable spectral subspaces makes it possible to sharpen the general Green-operator estimate to an exact formula.
We begin with the mixed case, in which
Theorem 1.
Let H be a complex Hilbert space and let be an invertible normal hyperbolic operator. Suppose that both and are nonempty. Then
Proof.
We divide the proof into the upper and lower estimates.
Step 1: the upper estimate. Let
and put
By Lemma 1,
where
and
Since A is normal, . Hence
The restrictions and are normal. By the spectral theorem,
Moreover, is an orthogonal projection, so . Consequently,
Similarly, since is normal and
we have
Thus
Step 2: approximate eigenvectors at the edge. Since and are compact and nonempty, there exist
such that
Write
where .
For a bounded normal operator, every spectral value belongs to its approximate point spectrum [17]. Applied to the normal restrictions and , this yields sequences of unit vectors
such that
and
as .
For the unstable component, observe that
Hence (32) gives
Applying the preceding finite-power argument to yields
Step 3: a past–future forcing. For each , define
by
The two nonzero parts in (35) have disjoint time supports, and all nonzero entries are unit vectors. Therefore
Let
At time , the Green representation gives
where
and
Likewise, by (34),
Since , , and ,
By (36) and the definition of ,
Letting therefore gives
Finally, letting in (41) yields
Thus
Corollary 1.
Let H be a complex Hilbert space and let be an invertible normal hyperbolic operator.
- (i)
- If , then
- (ii)
- If , then
Proof.
We prove only the stable case, since the unstable case is analogous. If , then and the Green representation reduces to
Normality gives , and therefore
The reverse inequality follows from the same finite, phase-aligned approximate eigenvector construction used in the proof of Theorem 1, with the unstable forcing omitted. Hence
The purely unstable case is analogous to the stable one. If , the Green representation becomes
Since is normal and
we obtain
For the reverse inequality, choose such that and write . Using unit approximate eigenvectors associated with and the finite future forcing
with otherwise, the argument in Step 3 of Theorem 1 gives
Letting yields
Therefore
□
Remark 3.
In the mixed case, Theorem 1 gives the Euclidean combination
rather than the additive estimate
The additive expression is what one obtains for a general Banach-space splitting : the estimate of [11], applied to the hyperbolic splitting of a normal operator and combined with and , yields exactly . The improvement to (25) is thus a direct consequence of two facts specific to the present setting: the stable and unstable subspaces are orthogonal, and their extremal responses can be generated by forcing supported on disjoint parts of the time axis.
4. Stability Ratios and Sharpness
We now combine the exact shadowability formula with the hyperbolicity margin introduced in Definition 1.
We first identify the latter explicitly in the normal case.
Proposition 3.
Let H be a complex Hilbert space and let be a normal hyperbolic operator. Then
where
In particular, if both and are nonempty, then
If , then
while if , then
Proof.
For a normal operator and every , the spectral theorem gives
where
Combining (49) with Proposition 1, we obtain
This proves (45).
Suppose now that both spectral components are nonempty. For ,
Hence
and
Since
it follows that
The one-sided cases follow in the same way. □
We can now state the second main theorem.
Theorem 2.
Let H be a complex Hilbert space and let be an invertible normal hyperbolic operator. Then
Both constants in (50) are optimal.
If both and are nonempty, then
Consequently,
in the mixed case, and equality in the upper bound holds if and only if
If the spectrum is one-sided, then
Proof.
Suppose first that both spectral components are nonempty. By Theorem 1 and Proposition 3,
and
Set
Since
we obtain
The upper equality holds precisely when
which is equivalent to
Now suppose that . By Corollary 1 and Proposition 3,
and hence
The purely unstable case is identical, using
Thus (50) holds in all cases. □
Remark 4.
In the mixed case, define the spectral-balance parameter
Then Theorem 2 may be written in the compact form
Thus the normalized shadowability constant is determined entirely by the relative balance of the two spectral gaps.
We next give two examples illustrating the equality cases.
Example 1
(The lower constant). Let and let
on any nonzero complex Hilbert space H. Then A is normal, invertible and purely stable. We have
Hence
and
Therefore
Thus the lower constant in (50) is attained.
Example 2
(A balanced finite-dimensional model). Let and consider
acting on with its standard Hilbert norm. Then is normal, invertible and hyperbolic, with
Therefore
and hence
Thus the upper constant in (50) is already sharp in dimension two.
The next example shows that the upper constant remains sharp in an infinite-dimensional setting with continuous spectrum.
Example 3
(Continuous spectrum and sharpness). Let
and fix
Define
where
and
Then is a bounded normal operator. Its spectrum is
Since , the first interval lies strictly inside the unit disk and the second lies strictly outside it. Hence is invertible and hyperbolic.
Moreover,
and
Therefore
By Theorem 1,
while Proposition 3 gives
Consequently,
The spectral endpoints and belong to the spectra of the corresponding multiplication operators but are not eigenvalues. Thus sharpness does not depend on the existence of spectral-edge eigenvectors.
Remark 5.
Formula (56) also describes the two asymptotic regimes. If along a family of mixed normal hyperbolic operators, then
If , then
5. Concluding Remarks
We have determined the optimal uniform shadowability constant for invertible normal hyperbolic operators on complex Hilbert spaces. In the mixed case,
while in the one-sided cases and . Comparison with the operator-norm distance to loss of hyperbolicity yields the sharp bound
The normalized quantity is determined entirely by the relative balance of the stable and unstable spectral gaps. In particular, the exact formula is not merely a refinement of the existence of a bounded solution: it identifies that solution as the inverse of the difference operator and computes its norm exactly.
Normality is essential to the present argument: it provides both the orthogonality of the stable and unstable spectral subspaces and the spectral-edge approximate eigenvectors used in the sharpness construction. Proposition 2 requires no normality and yields the lower bound for every invertible hyperbolic operator. The open question is therefore not the lower bound but the upper one. Without normality, nonorthogonal spectral projections and resolvent amplification may substantially increase the product, and a natural problem is to identify geometric or resolvent conditions under which quantitative upper bounds for persist beyond the normal setting.
References
- Ombach, J. The Simplest Shadowing. Ann. Pol. Math. 1993, 58, 253–258. [Google Scholar] [CrossRef]
- Ombach, J. The Shadowing Lemma in the Linear Case. Univ. Iagell. Acta Math. 1994, 31, 69–74. [Google Scholar]
- Palmer, K. Shadowing in Dynamical Systems; Kluwer Academic Publishers: Dordrecht, 2000. [Google Scholar] [CrossRef]
- Bernardes, N.C., Jr.; Cirilo, P.R.; Darji, U.B.; Messaoudi, A.; Pujals, E.R. Expansivity and Shadowing in Linear Dynamics. J. Math. Anal. Appl. 2018, 461, 796–816. [Google Scholar] [CrossRef]
- D’Aniello, E.; Darji, U.B.; Maiuriello, M. Generalized Hyperbolicity and Shadowing in Lp Spaces. J. Differ. Equ. 2021, 298, 68–94. [Google Scholar] [CrossRef]
- Bernardes, N.C., Jr.; Peris, A. On Shadowing and Chain Recurrence in Linear Dynamics. Adv. Math. 2024, 441, 109539. [Google Scholar] [CrossRef]
- Mazur, M. Hyperbolicity, Expansivity and Shadowing for the Class of Normal Operators. Funct. Differ. Equ. 2000, 7, 147–156. [Google Scholar]
- Pituk, M. Spectral characterization of shadowing for linear operators on hilbert spaces. arXiv 2025, arXiv:math. [Google Scholar]
- Pituk, M. Resolving the generalized hyperbolicity conjecture for shadowing. arXiv 2026, arXiv:math. [Google Scholar]
- Messaoudi, A.; Tofanin Neto, J.; Saavedra, M.; Tsokanos, I. On Generalized Hyperbolicity, Stability, and Shadowing for Linear Operators. arXiv 2026, arXiv:math. [Google Scholar]
- Morales, C.A.; Nguyen, T. Quantifying the Shadowing Property. J. Dyn. Differ. Equ. 2025, 37, 1295–1314. [Google Scholar] [CrossRef]
- Anderson, D.R.; Onitsuka, M. Best Constant for Hyers–Ulam Stability of Two Step Sizes Linear Difference Equations. J. Math. Anal. Appl. 2021, 496, 124807. [Google Scholar] [CrossRef]
- Baias, A.R.; Blaga, F.; Popa, D. On the best Ulam constant of a first order linear difference equation in Banach spaces. Acta Math. Hung. 2021, 163, 563–575. [Google Scholar] [CrossRef]
- Baias, A.R.; Popa, D. On the Best Ulam Constant of a Higher Order Linear Difference Equation. Bull. Des. Sci. Mathématiques 2021, 166, 102928. [Google Scholar] [CrossRef]
- Yuan, T.; Xu, B.; Brzdęk, J. On the Best Ulam Constant and Solutions of the Higher Order Linear Difference Equation with Constant Coefficients. Math. Ann. 2025, 393, 2057–2093. [Google Scholar] [CrossRef]
- Zhou, L.; Zhang, W. Admissibility and Roughness of Nonuniform Exponential Dichotomies for Difference Equations. J. Funct. Anal. 2016, 271, 1087–1129. [Google Scholar] [CrossRef]
- Conway, J.B. A Course in Functional Analysis, second ed.; Graduate Texts in Mathematics; Springer-Verlag: New York, 1990; Vol. 96. [Google Scholar] [CrossRef]
- Hinrichsen, D.; Pritchard, A.J. Stability Radii of Linear Systems. Syst. Control Lett. 1986, 7, 1–10. [Google Scholar] [CrossRef]
Figure 1.
Spectral picture of a normal hyperbolic operator with both spectral components present. The unit circle separates the stable part from the unstable part . The two gap parameters and measure the distances of the two components from the unit circle; the hyperbolicity margin equals the smaller of them, .
Figure 1.
Spectral picture of a normal hyperbolic operator with both spectral components present. The unit circle separates the stable part from the unstable part . The two gap parameters and measure the distances of the two components from the unit circle; the hyperbolicity margin equals the smaller of them, .
Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license (http://creativecommons.org/licenses/by/4.0/).
Copyright: This open access article is published under a Creative Commons CC BY 4.0 license, which permit the free download, distribution, and reuse, provided that the author and preprint are cited in any reuse.