

Submitted:
02 September 2026
Posted:
03 September 2026
You are already at the latest version
Abstract
In empirical sciences, the inductive construction of mathematical models relies on observations from controlled experiments, yet the conditions under which such constructions yield well-defined deterministic dynamics remain largely implicit. Within the framework of Axiomatic System Dynamics (ASD), this paper develops an algebraic theory of inductive mathematical modeling based on an ontological-epistemological dual structure. The modeling domain (MD) is formalized as a mathematical structure encoding initial conditions, loading protocols, and admissible loading ranges, thereby characterizing model applicability and the mechanisms of failure under improper extrapolation. Weak and strong validity conditions characterize, respectively, the uniqueness and dynamical closure of observable parameter evolution, yielding an algebraic constraint structure for mathematical models and their induced state-space representations. Generalized state parameters incorporate loading-history information, and an existence theorem is established. Difference representations of state and parameters provide an algebraic basis for comparative experiments, controlled-variable methods and causal inference. Together, these results establish a unified algebraic framework for inductive mathematical modeling and provide a principled basis for designing informative and computationally tractable experiments.
Keywords:
inductive mathematical modeling
; Axiomatic System Dynamics (ASD)
; modeling domain
; deterministic dynamics
; observable parameter
; validity condition
; state parameter
; state-space representation
; generalized state parameter
MSC: 93A30; 93A05; 37N35; 93B25
1. Introduction
Despite the diversity of research objects, system properties, and mathematical formulations across the natural sciences, the essence of mathematical modeling may ultimately be viewed as the quantitative characterization of system properties and their evolutionary laws.
From the perspective of modern systems science, a broad class of deterministic mathematical models can be represented within the framework of state-space theory [1,2,3] by the following system of equations:
Here, the state equation describes the evolution of the state variable under the input , while the observation equation maps the state to the corresponding observable output . Through this formulation, the evolutionary behavior of the property of interest () driven by external actions is characterized, thereby fulfilling the objective of mathematical modeling.
Grounded in state-space theory, systems science has developed a spectrum of theoretical branches and analytical tools: system identification [4,5,6] addresses the construction of system models and the estimation of their parameters from observational data; (latent) state representation learning [7,8,9,10] seeks to extract dynamically meaningful state representations from empirical data; behavioral systems theory [11,12,13] dispenses with the conventional causal input-output paradigm, taking system behavior at the center of analysis; factor dynamics [14,15], together with behavioral equivalence [16,17], employs quotient maps and dynamical commutation relations to characterize the preservation of dynamics, order reduction, and equivalence across distinct state representations.
Concurrently, with respect to the formalization of mathematical models per se, Mesarovic and Takahara [18] developed a formal foundation for general systems theory based on set algebra; Takahashi and Takahara [19] formulated a logical systems-theoretic methodology for the formal description of heterogeneous models; Zeigler [20,21] established the formal modeling and simulation framework of the discrete event system specification (DEVS). Collectively, these developments have substantially broadened the mathematical foundations of modern systems science and its related areas.
Nevertheless, in the empirical sciences and engineering, the system under investigation is typically regarded as an objectively existing entity governed by underlying dynamical laws that are independent of the observer. The researcher can neither fully access the system’s ontological state nor exhaust its internal information. Accordingly, the inductive construction of a mathematical model proceeds through an epistemological process: controlled experiments are designed by prescribing initial conditions and loading protocols or control interventions, while the resulting evolutionary behavior of observable parameters (such as stress, strain, and temperature) is measured and recorded. These observations, together with the imposed experimental constraints, provide the basis for inferring deterministic mathematical relations or dynamical equations.
Consequently, the inductive modeling process can be formalized, within the state-space framework, as the ontological-epistemological dual structure illustrated in Figure 1(a).
At the ontological dynamics layer, the equation describes the evolution of the system’s ontological state driven by the ontological input , thereby representing the underlying dynamical laws governing the system.
At the epistemological observation and modeling layer, denote observable parameters of the system, each formalized as a projection of the state , where the projection maps are determined by the corresponding parameter types. Similarly, denotes the encoding of the loading protocol (e.g., “increase by 1 kPa” or “decrease by 1 °C”), formalized as a projection of the ontological input , where the projection map is determined by the designated loading protocol and its encoding scheme.
In a controlled experiment, a prescribed loading path is applied to the system, giving rise to the observed parameter evolutions . These sequences do not constitute the system’s ontological dynamics itself; rather, they are epistemological projections of the underlying dynamics realized under the specified experimental configuration.
The scope of a controlled experiment can be formalized as a modeling domain , as illustrated in Figure 1(b). Here, denotes the selected loading protocol together with its encoding scheme, while denotes the prescribed initial condition. In experimental practice, it is generally impossible to constrain the ontological initial state to a single value; rather, given the finite information available about the initial condition, one can only restrict it to a specific subset of the state space, namely . Furthermore, denotes the loading scope, defined as the set of all admissible loading paths .
Given that constitutes a subset of the state space , and that an individual encoding can, at most, constrain the ontological input to a specific fiber , the evolution of the system under a prescribed loading path is deterministic and reproducible only in the sense of set-valued state evolution .
Consequently, within the context of controlled experiments, the inductive construction of a deterministic mathematical model gives rise to the following fundamental questions:
- Is the evolutionary behavior of the observed parameters unique across repeated trials? That is, does the loading path uniquely determine the evolutionary paths ?
- Does a given parameter contain sufficient information to determine its own evolution, thereby qualifying as a valid state variable? That is, does there exist a well-defined dynamical equation ?
- Does a single-valued mapping relation hold between the two types of parameters? Specifically, does there exist a function ?
- How does the choice of the modeling domain affect these algebraic properties?
It is evident that these criteria do not presuppose the validity of Equation (1); rather, they characterize the conditions under which a state-space representation can be established. This leads to the fundamental meta-modeling question addressed in this paper: under what algebraic and topological conditions does an observable parameter admit a well-defined, single-valued, and deterministic dynamical characterization?
Existing theories provide a broad range of mathematical tools for analyzing system structure, behavior, and representation, but generally take the relevant mathematical structures as given. By contrast, inductive mathematical modeling seeks to construct such structures from observations, loading controls, and initial condition constraints imposed on an objectively existing system.
This construction is organized by the modeling domain (MD), which specifies the admissible experimental configurations within which a mathematical model is constructed and its validity is evaluated. Although the MD is epistemological in nature, its specification determines the algebraic properties exhibited by observable parameters within the domain and, consequently, constrains the form and domain of applicability of the resulting mathematical model.
In conventional modeling practice, however, the MD is typically specified through empirical heuristics and lacks a unified mathematical formulation. A rigorous formalization of the MD and the inductive modeling process therefore provides both a theoretical basis for understanding how deterministic mathematical models are constructed from ontological dynamics through controlled experimentation and a rigorous, operational mathematical foundation for the design of informative and tractable experiments.
Motivated by these considerations, our previous work established the meta-modeling framework of Axiomatic System Dynamics (ASD) [22]. Within this framework, ontological dynamics are represented by conceptual models composed of generalized constitutive relationships (GCRs), which encode causal relations in a minimal “state-action-state increment” form. Mathematical models are formulated as mathematical realizations of the corresponding conceptual models.
However, the core concepts underlying this ontological-epistemological dual structure—including the ontological state, epistemological parameter, internal/external actions, state parameter, and action quantification—have not yet been given a rigorous algebraic characterization.
Following the principle of minimal mathematical structure, this paper develops an algebraic theory of mathematical modeling within the ASD framework. The theory formalizes the inductive construction of deterministic mathematical models from controlled experimentation, establishes algebraic criteria for the well-definedness and dynamical validity of observable parameters, and makes explicit the algebraic structures and structural relations that remain implicit in conventional modeling practice.
2. Ontological Dynamics Layer
2.1. Ontological Dynamics Structure
Within the mathematical modeling framework of Axiomatic System Dynamics (ASD), the evolution of a system is grounded in the ontological dynamics structure. This structure is defined as the tuple:
The relationships among its core concepts are illustrated in Figure 2.
Let denote the time domain, with element termed time point. Let denote the characteristic time scale. Any interval
is referred to as a basic evolution interval.
Within the ASD framework, the evolution law of the system state is defined on each basic evolution interval , and is independent of the temporal base point . Accordingly, all dynamical operators introduced subsequently (e.g., and ) are assumed to satisfy time-translation invariance. For simplicity, we restrict attention to the idealized setting in which and is a prescribed constant.
At the ontological dynamics layer, except for the time domain and the characteristic time scale , all other components of the tuple are assigned ontological status. More precisely, although their mathematical structures are assumed to exist objectively and uniquely, they are epistemically inaccessible; their specific mathematical forms cannot be determined by direct observation and are therefore treated as abstract system entities independent of any particular observation or measurement procedure.
Let denote the state space, with each called a state. The state encapsulates the complete information of the system, sufficient to determine its evolution under any action, and exists uniquely at any given instant .
Let denote the action space, with each called an action. The action constitutes the sole factor that changes the system state, and exists uniquely within any basic evolution interval .
The function
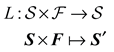 is called the ontological dynamics operator. It characterizes the system’s ontological dynamics, formulated as:
This equation constitutes as the rigorous algebraic realization of ASD Axiom 1, representing the minimal unit of causality. It dictates that the state at time and the total action exerted over jointly and uniquely determine the updated state at time .
The function
is called the internal action generation operator. The element in the action space
is termed the internal action, characterizing the endogenous driving factor for the system’s spontaneous evolution. This equation constitutes the rigorous algebraic realization of ASD Axiom 2, signifying that the state at time uniquely determines the internal action over the interval .
Let denote the external action space, defined as the set of all transformations on the action space . Its element , termed the external action, characterizes the exogenous driving factor for the system’s evolution and exists uniquely within any basic evolution interval .
Algebraically, the external action manifests as a mapping and shift applied to the internal action . Consequently, the total action exerted upon the system is formulated as the application of the external action to the internal action:
Combining the preceding definitions, over any basic evolution interval , the ontological dynamics equation is ultimately formulated as:
which characterizes the evolution of the system state on a discrete time scale.
Furthermore, given an initial state and a sequence of external actions , the corresponding state sequence can be uniquely constructed by the recursion:
This induces the state path generation operator:
yielding:
Physically, provided the initial state corresponds to the initial time , the system state at any subsequent time is given by in the above sequence.
2.2. Difference Representation of the State
The variation of the system state can be described by an appropriate algebraic structure. We define a difference representation of the state as the triple:
The relationships among its core concepts are illustrated in Figure 3(a).
Let the abelian group denote the state increment space, whose element is called the state increment, with the additive identity of the group denoted by . The function
is called the state difference operator. For , the induced map
is a bijection. Moreover, for , Chasles’ relation holds:
This uniquely induces the map
called the state update operator. Its operation can be denoted as:
This algebraic structure formulates the state space as an abelian -torsor [23,24]. While the states themselves do not admit a meaningful addition operation, the difference between any two states possesses a unique representative element within the group . Further discussion regarding the difference representation and its properties is given in Appendix A.
Under the axioms of Zermelo–Fraenkel set theory with the Axiom of Choice (ZFC), a difference representation satisfying the above definition necessarily exists, although its construction is generally non-unique. Indeed, for any given state space , there exists an abelian group equipotent with . Given any bijection , one may define and subsequently induce the operator . This yields a valid difference representation .
Based on the difference representation of the state, the ontological dynamics equation can be recast into the equivalent form governed by the state increment
where the ontological dynamics operator in increment form is defined by
The generalized constitutive relationship (GCR) in ASD Axiom 1,
is intrinsically an equivalent representation of Equation (3).
Furthermore, the difference representation of the state provides the algebraic foundation for deriving the induction principle of external actions (i.e., the B-A principle) in ASD.
Within the external action space , we define the identity map as the zero external action element, denoted by . When , the system evolves without external intervention, and the total action reduces to the internal action:
For any given state and external action , the increment-form ontological dynamics operator yields two state increments:
Here, constitutes the state increment driven purely by the internal action , representing the system’s spontaneous evolution, or baseline response, in the absence of external action; conversely, represents the net contribution of the external action to the evolution of the system state. It should be emphasized that, throughout this decomposition, the generation of the internal action remains constrained by Axiom 2 (Eq. 2).
Recasting the above relations into the GCR form yields the classical statement of the B-A principle:
By virtue of the algebraic properties of the -torsor, the physical intuition underlying the B-A principle (as illustrated in Figure 3(b)) is thereby endowed with rigorous algebraic legitimacy.
3. Observation and Modeling Layer
3.1. Observation and Modeling Structure
Mathematical modeling does not directly operate on the underlying ontological dynamics structure . Instead, it operates on the observation and modeling structure at the epistemological level. This structure is defined as the tuple:
The relationships among its core concepts are illustrated in Figure 4.
This layer introduces a set of epistemological constructs, whose mathematical structures are taken as known or can be determined through observation. These constructs are dual to the corresponding ontological entities at the ontological dynamics layer.
Let denote the parameter space, whose element is called parameter. In contrast to the ontological state, a parameter constitutes an observable property of the system; it represents a subset of the information encapsulated in the state and serves as its quantitative characterization (e.g., position, mass, temperature, and color).
System parameters may differ in type. Selecting a particular type of observable parameter is mathematically equivalent to specifying the corresponding parameter space . For any given parameter space , the parameter at each time point is uniquely determined by the system state at that time. There exists a mapping:
called the observation operator. Its mapping rule depends solely on the selection of .
Let denote the target parameter space, whose element is called target parameter. In modeling practice, it is neither necessary nor generally possible to account for all observable properties of a system. Instead, attention is restricted to those properties most relevant to the modeling objective. The target parameter represents these selected properties.
Consequently, the fundamental objective of mathematical modeling can be formalized as the construction of dynamical equations governing the target parameter . For instance, in modeling the motion of a ball, its spatial coordinates, possibly together with its shape and spatial orientation, may constitute the target parameters, whereas properties such as color or price are typically excluded.
The target parameter is thus a distinguished type of parameter selected according to the modeling objective. For any given target parameter space , the corresponding observation operator is denoted as
Its mapping rule depends solely on the selection of .
Let denote the external action encoding space, whose element is called the external action encoding. In modeling practice, the ontological external action acting on the system must be encoded into an operational quantitative representation. Such encoding is a fundamental prerequisite for model construction, as it enables the researcher to design and perform controlled experiments in a reproducible manner.
Selecting a specific encoding scheme is mathematically equivalent to specifying a corresponding external action encoding space . For any prescribed , there exists a mapping:
called the external action encoding operator. Its mapping rule depends solely on the selection of .
Let denote the information constraint space, whose element is called constraint information. The constraint information represents empirical information capable of reducing or eliminating the uncertainty of the system state. In controlled experiments, information about the initial state is typically required to ensure experimental validity. Such information, denoted by , constrains the admissible range of the initial state . It may include the system’s initial properties, preparation history, and environmental conditions. There exists a mapping:
 called the information constraint operator, where denotes the power set of the state space . The subset
defines the admissible set of the initial state delineated by the constraint information , representing the reduction of uncertainty in the initial state.
In summary, within the observation and modeling structure , the parameter , target parameter , external action encoding , and constraint information are epistemological constructs. Likewise, the parameter space , target parameter space , and external action encoding space are epistemological in nature, as their specification depends on the modeling objective and the modeler’s choices.
By contrast, the information constraint space itself is ontological. In the real world, a system may possess arbitrarily many types of properties and forms of historical information, whereas only a finite and partial subset of them can be known or used as constraint information in a given modeling process.
Moreover, because the domains or codomains of the observation operators , the external action encoding operator , and the information constraint operator involve ontological spaces, these operators are, in their full mathematical meaning, ontological entities as well. Nevertheless, their specific mapping rules are uniquely induced by the epistemological spaces () selected by the modeler.
3.2. Encoding of External Actions
ASD introduces a class of encoding and quantification methods for external actions known as the “external action path method”. This method can now be formalized in a more rigorous algebraic language.
For convenience, we denote by the set of all functions from a set to a set .
Given a set , define the function space
where ranges over all possible basic evolution intervals, denotes the set of functions from to .
Define an equivalence relation on by
where . Intuitively, two functions and are equivalent under if and only if their graphs in the space coincide exactly by a translation along the time axis, as illustrated in Figure 5.
Let the quotient space of induced by be denoted by , and let denote the equivalence class of . Choose the external action encoding space as . Then, for any given function , the external action encoding of the system over a basic evolution interval is defined as
where denotes the restriction of to . We refer to this encoding scheme as the external action path method, and the function as an external action path.
Evidently, for , the map
is a bijection. Hence, on any basic evolution interval , the collection of local functions , taken as representatives, traverses every equivalence class exactly once.
In modeling practice, when the external action exerted on a system can be fully represented by the active control of certain system parameters, the corresponding time-dependent parameter trajectories can serve as external action paths, thereby providing an encoding of the external action.
For example, in constructing the stress–strain constitutive relation of a material element [25], if the experiment is conducted under strict stress control, the stress trajectory constitutes an external action path. Accordingly, on any basic evolution interval , the external action encoding is given by
Clearly, if the stress trajectories over two distinct basic evolution intervals have identical geometric forms, their external action encodings are regarded as identical. This is consistent with the physical intuition underlying controlled experiments.
The bijectivity of the map (Eq. 6) implies that distinct function segments correspond to distinct encodings , yielding a highly fine-grained encoding scheme. In modeling practice, however, it is often desirable to further identify fine-grained encodings that produce equivalent dynamical effects, based on the dynamical characteristics of the system, thereby constructing a coarser encoding scheme.
Algebraically, this is equivalent to introducing an equivalence relation on the original quotient space , together with the canonical projection
This yields a new external action encoding space , with the corresponding external action encoding operator . Accordingly, on any basic evolution interval , the resulting coarse-grained external action encoding is
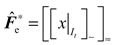
Continuing with the example of constitutive modeling of materials, suppose that, based on the fine-grained encoding in Equation (7), we further define the equivalence relation such that two equivalence classes are equivalent whenever their representative stress increments are identical; that is
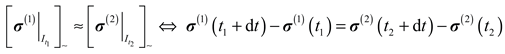
It is straightforward to verify that this definition is independent of the choice of representatives and is therefore well defined. The stress increment can then be used directly as the coarse-grained encoding of these equivalence classes, yielding
This construction reduces to the stress-increment-based constitutive modeling approach widely used in continuum mechanics and plasticity theory.
In essence, this encoding retains only the endpoint information of the segment over the basic evolution interval , and therefore matches the temporal granularity set by the characteristic time scale . It thus represents a common coarse-graining scheme based on the external action path method.
3.3. Modeling Domain
Within the observation and modeling structure , the epistemological constructs can be decomposed into two independent dimensions: “observation” and “control”. The former concerns the selection of target parameters and other parameters ; the latter concerns the control of the system’s initial state and external actions. “Control” is a prerequisite for controlled experimentation and determines the domain of applicability of the resulting mathematical model. Algebraically, this domain is represented by the modeling domain, defined as the tuple
The relationships among its core concepts are illustrated in Figure 6(c).
Within the modeling domain , denotes the prescribed external action encoding space, i.e., the selected encoding scheme. The set comprises all constraint information used to restrict the system’s initial state. Under the information constraint operator , its image
represents the collection of all admissible initial state sets . Moreover, denotes the set of all admissible sequences of external action encodings . For simplicity, we restrict our analysis to the basic case in which and are mutually independent.
In practice, given constraint information , it is generally impossible to restrict the system to a unique initial state . Instead, only constrains to lie within the admissible set , namely . Likewise, a given external action encoding generally determines the ontological external action only up to the fiber , namely .Accordingly, for a fixed sequence of external action encodings , the evolution that can be determined uniquely is generally limited to the corresponding sequence of state sets. This evolution is therefore naturally described by set-valued dynamics [26].
In general, suppose that the system state at time is constrained to a state set , and that the external action encoding applied over the basic evolution interval is . Then, according to the ontological dynamics, the updated state set at time is given by
This induces the set-valued dynamics operator
Accordingly, the one-step evolution of the state set can be written as
This set-valued evolution can be represented schematically by a circle-arrow diagram on the state space (Figure 6(a)), in which circles denote state sets and arrows denote external action encodings. Since the length and direction of an arrow are constrained by the successive state sets, distinct external action encodings must, strictly speaking, be distinguished by additional graphical attributes, such as arrow color, line style, or explicit encoding labels.
Furthermore, given an initial state set and a sequence of external action encodings , the recursion
uniquely generates the corresponding sequence of state sets . This induces the state set path generation operator
equivalently
Intuitively, this sequence corresponds to a circle-arrow chain in the state space, as illustrated in Figure 6(b).
Now, for a given modeling domain , any choice of
uniquely determines the corresponding sequence of state sets:
Although this sequence resides in the ontological space , it is logically determined by the epistemological constructs and . This algebraic property constitutes the theoretical foundation of controlled experimentation.
To further characterize the scope of mathematical modeling, we define the following sets from the modeling domain .
The admissible state set sequence space
is the set of all state set sequences that can be generated within the modeling domain.
The dynamics unit space
has elements called dynamics units. Each dynamics unit represents a dynamical relation that must be considered within the modeling domain.
The input combination space
is the set of admissible input combinations abstracted from the dynamics units .
The reachable state set space
is the collection of state sets that may arise within the modeling domain.
The reachable state space
is the set of states that may occur within the modeling domain.
Intuitively, as illustrated in Figure 6(c), contains all circle-arrow chains admissible within the modeling domain . The sets and contain, respectively, all circle-arrow-circle and circle-arrow configurations occurring in these chains. collects all distinct circles appearing in the admissible chains, while is the region of the state space covered by these circles.
All concepts defined above from the modeling domain are independent of the choice of parameter type. However, the existence of a deterministic mathematical model requires an algebraic compatibility between the modeling domain and the observed parameter type.
For any given parameter type , a state set is said to be monochromatic with respect to this parameter if its image under the observation operator constitutes a singleton, i.e.,
where denotes the cardinality of a set. This condition means that all states yield the same parameter value . From an algebraic-topological perspective, this condition is equivalent to
that is, is contained in the fiber associated with a unique parameter value . We then call the color of the monochromatic state set , and write
For a given modeling domain , a parameter type is said to satisfy the weak validity condition if every reachable state set within is monochromatic with respect to this parameter, namely,
This condition is concisely denoted by the relation:
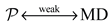
Geometrically, the modeling domain generates all admissible circle-arrow chains in the state space, while each parameter type defines a distinct coloring scheme for the state space. Under a given coloring scheme, the state space is partitioned into color regions (fibers ), as illustrated in Figure 7(a). The weak validity condition requires every circle in every admissible circle-arrow chain to lie entirely within a monochromatic region.
Physically, the weak validity condition of a parameter constitutes the prerequisite ensuring the reproducibility and inducibility of its evolutionary behavior in controlled experiments. If this condition fails, uncertainty in the underlying ontological state “leaks” into the parameter observation. Consequently, even if the initial condition and the loading path are strictly fixed, the observed parameter evolution may still manifest bifurcation and dispersion (Figure 7(b)). In such a case, the logical foundation for a deterministic dynamical equation is no longer satisfied.
As an example, consider constitutive modeling of materials. Under prescribed initial condition and loading path, the macroscopic strain field of a material specimen generally exhibits robust reproducibility, provided that the specimen does not undergo failure. However, once the prescribed loading protocol leads to failure, the post-failure deformation patterns, such as the morphology of macroscopic fracture bands, typically manifest significant variance across repeated trials. Consequently, the “strain field” as a parameter fails to satisfy the weak validity condition within the modeling domain.
In summary, since the target parameter directly reflects the modeling objective, a necessary condition for constructing a deterministic mathematical model is the weak validity condition of the target parameter:
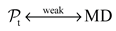
This condition is assumed to hold throughout the subsequent analysis.
In modeling practice, this condition is typically satisfied through iterative trial and refinement, by adjusting the three components of the modeling domain so that all circles in the resulting circle-arrow chains are monochromatic with respect to the target parameter.
3.4. State Parameter Modeling Method
3.4.1. Strong Validity Condition
For a given modeling domain and any parameter type satisfying the weak validity condition, the dynamics unit space induces the colored dynamics unit space
This set comprises all dynamics units after epistemological coloring. For a unit , the pair represents the color input combination, while represents the output color, as illustrated in Figure 8.
Similarly, the input combination space induces the color input combination space
This set comprises all admissible color input combinations .
Finally, the reachable state set space induces the reachable color space
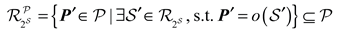 which comprises all parameter values occurring in the admissible color input combinations .
From the preceding definitions, it follows that
Mathematically, the relation set defines a well-defined function from to if and only if
That is, every admissible color input combination must induce an output color that exists and is unique. The existence requirement is guaranteed by the construction of .
We refer to the above condition as the strong validity condition for the parameter type , denoted by the relation
By definition, strong validity implies weak validity:
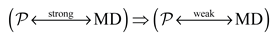
Once a parameter type satisfies the strong validity condition, the colored dynamics unit space induces the corresponding dynamics operator for this parameter
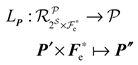
The one-step evolution of the parameter is therefore given by
At this point, the set-valued state evolution and the parameter evolution commute:
or, equivalently,
This algebraic property implies that, within the modeling domain , the updated parameter value is uniquely determined by the current parameter value and the prescribed external action encoding , independently of the particular ontological dynamics unit or input combination through which the evolution is realized, as illustrated in Figure 9.
Thus, the operator constitutes the dynamical equation or mathematical model for the parameter within the modeling domain .
In summary, the strong validity condition for a parameter type constitutes the necessary and sufficient condition for the existence of its deterministic dynamical equation. This condition effectively decouples the parameter’s evolution from the unknowable ontological operator , endowing it with an independent self-consistent epistemological law . If the condition fails, the parameter does not contain sufficient information to determine its own evolution.
Geometrically, identifying a strong valid parameter is equivalent to the following procedure. First, verify that every circle in the admissible circle-arrow chains is monochromatic (the weak validity condition). Next, verify that for all circle-arrow pairs having the same color combination, denoted by , the circles to which they point all have the same color (the strong validity condition). Finally, aggregating these chromatic input-output relations yields the mathematical model for the parameter.
3.4.2. Global Strong Validity Condition
To clarify the domain of applicability of the dynamics operator , for define
This set comprises all external action encodings that the input color can undergo within the modeling domain. Accordingly, the domain of can be decomposed as
We say that a strong valid parameter type is global strong valid if, in addition, it satisfies
This condition is denoted by the relation
The above property is illustrated schematically in Figure 10(a). Compared with strong validity (Eq. 8), global strong validity endows the operator with stronger extrapolation robustness. Specifically, consider any monochromatic subset with color , regardless of whether itself belongs to the reachable state set space . Whenever the color input combination lies within the domain of , the operator uniquely determines the output color of the updated state set .
By definition,
the converse does not necessarily hold. The reason is that, even if one selects a reachable state set of color , the admissible color input combination does not, in general, imply . If is not an admissible input combination within the modeling domain , then the updated state set falls outside the original algebraic constraints. In this case, neither the monochromaticity of nor its color can be guaranteed by the operator ; moreover, there is no assurance that remains within the reachable state space , as illustrated in Figure10(b).
The one-way implication in Equation (10) reveals the domain of applicability of the operator , i.e., the mathematical model. This domain is strictly constrained by the modeling domain to the color transformations realized by admissible dynamics units . Applying beyond these admissible configurations, as in the more general setting described by Equation (9), constitutes an unjustified extrapolation of the mathematical model. Figure 10(b) unveils the underlying mechanism responsible for the predictive failure under such improper extrapolation.
A basic sufficient condition ensuring that a parameter type is global strong valid is given by
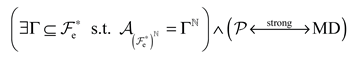
This condition means that all admissible sequences of external action encodings are freely generated, without additional constraints, by a fixed generating set . Consequently,
The system then manifests stronger property
as illustrated in Figure 10(c).
3.4.3. State Parameter
For a given modeling domain , let and be two parameter types satisfying the weak validity condition. Suppose that, within the reachable state space , they satisfy the following fiber inclusion relation:
Then is said to be finer than , denoted by the partial order relation
Geometrically, this means that, within the reachable state space , every monochromatic region with respect to is necessarily monochromatic with respect to . This relation therefore induces the canonical projection
In general, if a parameter type satisfies the strong validity condition and is finer than the target parameter , i.e.,
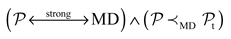
Then this parameter type is called a state parameter. Hereafter, state parameters are denoted by .
The target parameter need not itself satisfy the strong validity condition; that is, the information encoded by might be insufficient to determine its evolution in a closed manner. Nevertheless, its dynamics within the modeling domain can be described indirectly through the dynamics operator of the state parameter , together with the projection operator between them, as illustrated in Figure 11.
In summary, within the ASD framework, a mathematical model formulated via the state parameter method is formally equivalent to the following algebraic constraint structure:
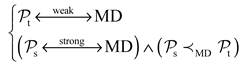
The resulting complete system of dynamical equations is given by:
Here, the dynamics operator constitutes the dynamic evolution equation governing the update of the state parameter, whereas the projection operator constitutes the static constraint equation relating the state parameter to the target parameter. Their coupling yields a closed determination of the target parameter’s evolutionary behavior. Fundamentally, this structure constitutes the algebraic foundation for the state-space representation prevalent in modern systems science and control theory.
It should be noted that, for a given target parameter type and modeling domain , a state parameter need not exist. Consequently, the construction of a mathematical model can be viewed as an iterative process of trial and refinement, in which the modeling domain and the candidate parameter type are repeatedly adjusted to satisfy the algebraic constraint structure specified above. A more advanced modeling task is to identify, among all admissible pairs , those that offer broad applicability while maintaining a parsimonious dynamical equation structure.
3.5. Generalized State Parameter Modeling Method
For complex systems exhibiting path dependence, generalized state parameters that incorporate historical information may be required to achieve dynamical closure. To formalize this idea algebraically, we extend the existing observation and modeling structure by introducing several additional mathematical constructs.
In this work, we consider the basic case in which the generalized state parameter incorporates loading-history information. The more general case involving histories of observable parameters can be formulated analogously within the same algebraic framework, but is beyond the scope of the present work.
3.5.1. Augmented Dynamics Unit
Define the loading history space
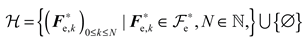 whose element is called loading history. This space contains all finite-length sequences of external action encodings
together with the empty set , representing the absence of prior loading.
Define the loading history dynamics operator
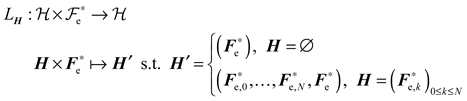
This operator represents the trivial update rule for the loading history. For any prescribed sequence of external action encodings , the recursion
uniquely generates the corresponding loading history sequence . This induces the loading history path generation operator
Evidently, this operator constitutes an injection.
To characterize the cumulative evolution of a state set driven by a loading history, define
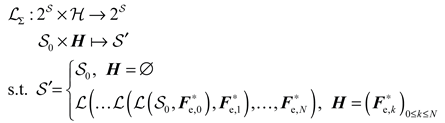
This serves as the set-valued dynamics operator adapted for loading history inputs. The expression
represents the state set reached from the initial state set after the system undergoes the loading history , which involves repeated application of the one-step set-valued dynamics operator .
Now, for a given modeling domain , we define the following sets.
The augmented dynamics unit space
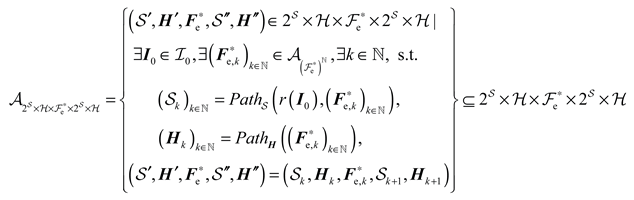
Its element is called augmented dynamics unit. Each unit represents a coupled dynamical relation that must be considered within the modeling domain:
The cartesian product is called an augmented state. Schematically, as illustrated in Figure 12, this construction amounts to augmenting each circle in the original circle-arrow chains with its loading history .
The augmented input combination space
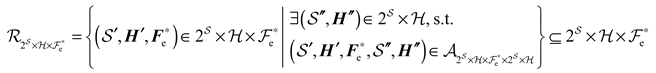
which comprises all admissible augmented input combinations .
Finally, the reachable augmented state space
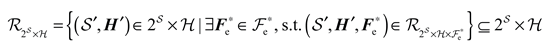 which comprises all augmented states that may arise within the modeling domain.
3.5.2. Generalized Parameter
A loading history typically contains substantial redundant information and therefore requires effective information compression. Mathematically, this is achieved by introducing a history compression operator
where is called the compressed loading history space, and its element is called compressed loading history.
In contrast to the parameter’s observation operator , the history compression operator constitutes a purely epistemological construct. Its specification involves both the choice of codomain and the corresponding mapping rule.
For any prescribed parameter type and history compression operator , one obtains a mathematical structure referred to as a generalized parameter, denoted by the tuple
Here, identifies the type of the generalized parameter, while is called the generalized parameter space, whose element is called generalized parameter. When no ambiguity arises, we use directly to denote both a generalized parameter value and its type .
Define the generalized observation operator
Equivalently,
Thus, the generalized parameter value obtained from through observation and history compression, consists precisely of the parameter value determined by the state , together with the compressed loading history
It should be emphasized that, because a loading history is contingent upon the artificially prescribed “initial state” or “initial time,” it cannot be determined solely by direct observation of the system’s current state. Consequently, a generalized parameter , considered independently of a specific modeling domain , has no well-defined physical meaning. This constitutes the fundamental epistemological divergence between generalized parameters and conventional parameters.
For a given modeling domain , if the constituent parameter type in satisfies the weak validity condition, then the corresponding generalized parameter type is said to satisfy the weak validity condition, denoted as
Formally, this definition is equivalent to
3.5.3. Generalized State Parameter
For a given modeling domain and any generalized parameter type satisfying the weak validity condition, the augmented dynamics unit space induces the colored augmented dynamics unit space
This set comprises all augmented dynamics units after coloring by the generalized observation operator . For a unit , the pair represents the augmented color input combination, while represents the augmented output color, as illustrated in Figure 13.
Similarly, the augmented input combination space induces the augmented color input combination space
This set comprises all augmented color input combinations admissible within the modeling domain.
Finally, the reachable augmented state space induces the reachable augmented color space
This set comprises all generalized parameter values occurring in the admissible augmented color input combinations .
From the preceding definitions,
Mathematically, the relation set defines a well-defined function from to if and only if
That is, every admissible augmented color input combination must induce an augmented output color that exists and is unique. The existence requirement is guaranteed by the construction of .
Analogous to the discussion in Section 3.4.1, we refer to the above condition as the strong validity condition for the generalized parameter type , denoted by the relation
By definition, strong validity implies weak validity:
Once the generalized parameter type satisfies the strong validity condition, the colored augmented dynamics unit space induces the corresponding dynamics operator
The one-step evolution of the generalized parameter is therefore given by
The augmented state evolution and the generalized parameter evolution then commute:
Equivalently,
This algebraic property implies that, within the given modeling domain , the generalized parameter admits a closed dynamical equation that is independent of the underlying augmented state .
Furthermore, to compare the informational “fineness” between the generalized parameter and the target parameter , we construct, from the reachable augmented state space , the coupling constraint set
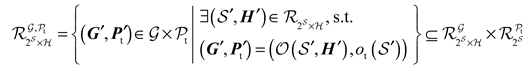
This set comprises all admissible pairs within the modeling domain. If
then defines a well-defined function from to . In this case, we say that the generalized parameter is finer than the target parameter , denoted by the partial-order relation
The relation naturally induces the projection operator
In general, if a generalized parameter type satisfies the strong validity condition and is finer than the target parameter , i.e.,
then is called a generalized state parameter. Hereafter, generalized state parameters are denoted by .
In summary, within the ASD framework, a mathematical model formulated via the generalized state parameter method is formally equivalent to the following algebraic constraint structure:
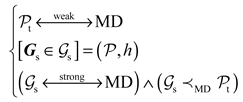
The resulting complete system of dynamical equations is given by:
Here, the dynamics operator constitutes the dynamic evolution equation governing the update of the generalized state parameter, whereas the projection operator constitutes the static constraint equation relating the generalized state parameter to the target parameter.
3.5.4. Existence Theorem for Generalized State Parameters
Comparing the generalized state parameter method with the state parameter method, although their algebraic constraint structures (Eqs. 13 and 11) are highly isomorphic, the former exhibits a substantial advantage in terms of the existence of mathematical models.
For an arbitrary prescribed modeling domain and a target parameter satisfying the weak validity condition, a state parameter need not exist. Indeed, for certain systems, there may not even exist a parameter type satisfying the strong validity condition.
The underlying difficulty has two aspects. On the one hand, the intrinsic topological properties of the dynamics unit space induced by may preclude any observable parameter type from qualifying as a state parameter. On the other hand, even when a state parameter exists theoretically, it may be practically inaccessible, since its identification or construction cannot, in general, be achieved by exhaustive enumeration.
In contrast, the existence of a generalized state parameter is readily guaranteed algebraically. For any given modeling domain and any target parameter satisfying the weak validity condition, if the set of initial constraint information is a singleton, namely:
Then one can always construct a generalized parameter type
that qualifies as a generalized state parameter. Here, denotes the identity transformation on the loading history space . The weak validity of , together with its being finer than the target parameter , follows immediately from the choice of its constituent parameter type, which is taken to be itself.
Let the unique initial constraint information be . By the set-valued dynamics operator adapted for loading history inputs (Eq. 12), every reachable augmented state within the modeling domain necessarily satisfies
This property ensures that every colored augmented dynamics unit satisfies
Hence, is uniquely determined by the pair . Therefore, the generalized parameter type satisfies the strong validity condition and consequently qualifies as a generalized state parameter.
Based on the preceding derivations, we obtain the following theorem.
Theorem 1 (Existence of Generalized State Parameters). If the set of initial constraint information in the modeling domain is a singleton, then for any target parameter satisfying the weak validity condition, there exists at least one generalized state parameter .
This theorem establishes a theoretical lower bound for the existence of mathematical models. It implies that, in the study of complex systems, as long as the initial conditions can be rigorously controlled and the history of external loading can be recorded without any information loss, a deterministic mathematical model governing the system’s evolution necessarily exists theoretically.
More generally, if the set of initial constraint information in contains multiple elements, then for each , one can construct a corresponding generalized state parameter , thereby yielding a family of mathematical models parameterized by the initial condition. In repeated experimental trials, the model branch corresponding to the calibrated can, in principle, be selected for each trial, providing a consistent framework for describing and predicting the evolution of the target parameter.
3.5.5. Construction of the History Compression Operator
In engineering and computational practice, however, constructing a generalized state parameter using the uncompressed loading history , i.e., with , is generally intractable. It is necessary to construct an appropriate history compression operator that extracts from only the information that relevant to the current dynamical response.
It is worth noting that explicitly and globally prescribing a compression operator , even with a high compression ratio, may still incur substantial computational costs. Schematically, as illustrated in Figure 14(a), the loading history associated with each circle in the circle-arrow chains must first be retained before can be applied to obtain the compressed value . Since the amount of information contained in increases with the position of the circle along the chain, the resulting memory and computational costs may grow rapidly with the number of time steps.
To this end, modeling practice generally adopts a local-to-global strategy: a local dynamics operator is first constructed for the compressed loading history , after which the global history compression operator is induced recursively.
Specifically, an appropriate lower-dimensional space is first selected as the compressed loading history space , together with a designated reference element . A dynamics operator for is then introduced:
thereby endowing the compressed history with the Markov property. Based on this one-step update operator, the global history compression operator is induced by recursion
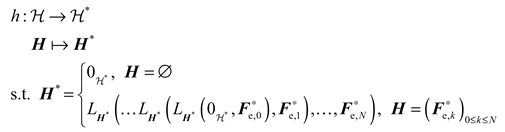
Under this strategy, schematically (Figure 14(b)), the compressed history of a successor circle in a circle–arrow chain can be derived directly from the compressed history of its predecessor and the external action encoding connecting them, using the one-step update rule
Consequently, starting from the reference history assigned to the initial circle, the sequence of compressed loading histories can be generated recursively through local updates, thereby eliminating the need to retain the complete loading history .
Taking constitutive modeling of materials as an example, the chosen compressed loading history space corresponds, in continuum mechanics and elastoplasticity theory [27,28], to the internal variable space used to characterize the material’s internal state, with typical internal variables including plastic strain, damage variables, and hardening parameters. The dynamics operator then governs the one-step evolution of these internal variables under external loading, typically through physically motivated relations such as yield criteria, flow rules, and hardening laws.
From an algebraic perspective, the essential differences among constitutive models lie in their choices of the compressed loading history space and its dynamics operator . These choices determine the corresponding history compression operator and, consequently, the generalized state parameter , with each resulting state representation carrying its own physical interpretation and predictive capability. Thus, a broad class of existing constitutive theories can be represented and compared within a unified generalized state parameter modeling framework.
4. Difference Representation of Parameters and the Consistency Theorem
Under the ZFC framework, for any given parameter type , there exists a corresponding difference representation . For example, when the parameter space is the finite-dimensional Euclidean space , a canonical difference representation is , where and − denote the standard addition and subtraction operations on , respectively.
Furthermore, for a given modeling domain , if satisfies the strong validity condition, its dynamical equation can be recast in an equivalent increment-based form:
where the dynamics operator adapted for incremental output is defined by
Now choose, within the external action encoding space , an element as the zero external action encoding—formally representing the condition of “exerting no external influence upon the system”—then for any given parameter value and external action encoding , one can define two parameter increments:
Here, represents the spontaneous evolution, or baseline response, of the system under the “no external action” condition calibrated by , whereas represents the net contribution of the intervention of the external influence encoded by to the parameter evolution.
Recasting the above relations into the GCR form yields the epistemological B-A principle:
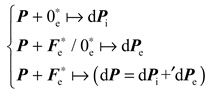
Within the ASD framework, this system of equations represents the epistemological projection of the state-increment form B-A principle (Eq. 5). It can also be understood as the operational mathematical model obtained through a specific mathematical realization of the conceptual model in Equation (5), which encodes the underlying causal structure.
Comparing the preceding analysis of parameter increments with that of state increments yields an important implication: at the epistemological level, the distinction between a system’s internal and external actions depends fundamentally on the chosen baseline . This distinction is therefore neither absolute nor an objective or a priori physical law.
Relative to the designated baseline , the net contribution associated with the external action encoding is not directly observable. It can only be identified indirectly through controlled comparative experiments by taking the difference . Formally, is attributed to the “net external action” relative to the prescribed baseline. This algebraic decomposition constitutes the underlying logic for causal inference and the method of controlled variables widely used in the experimental sciences.
For a given state space with difference representation , and a parameter type with difference representation , the two representations are said to be consistent if the map induced by the observation operator :
constitutes a well-defined group homomorphism. This consistency implies that the algebraic structure governing parameter increments is naturally induced, by the observation operator , as a projection of the algebraic structure governing state increments (Figure 15).
Because the state space is ontological, its difference representation is of theoretical significance only. In practice, one can construct only the parameter type and its difference representation . The question thus arises: whether there exists, in principle, a difference representation of for which the above consistency condition holds. The answer is given by the following theorem; a constructive proof is provided in Appendix A.
Theorem 2 (Consistency Theorem of Difference Representations). For any given parameter type and any difference representation , there exists a difference representation of the state space satisfying the consistency condition if and only if: such that the image set constitutes a subgroup of , and for , the fibers possess identical cardinality.
If the state space is interpreted as the set of underlying microstates of the system, the equal-cardinality condition on the fibers implies that every observable parameter value corresponds to the same number of microstates. Whether this stringent isentropic condition holds is independent of the particular choice of the difference representation and of the modeling domain ; rather, it constitutes an intrinsic property of the parameter type itself.
5. Conclusions
Following the principle of minimal mathematical structure, this paper develops an algebraic theory of inductive mathematical modeling. The theory formalizes the construction of deterministic mathematical models from observations and constraints obtained through controlled experiments. Based on the ontological-epistemological dual structure, the four questions posed in the introduction can now be answered explicitly:
- The evolutionary behavior of a given parameter can be uniquely determined across repeated experimental trials if and only if the parameter type satisfies the weak validity condition.
- A given parameter contains sufficient information to determine its own evolution, thereby qualifying as a state variable if and only if the parameter type satisfies the strong validity condition.
- A single-valued mapping relation exists between two parameter types if and only if they satisfy the fiber inclusion relation within the reachable state space.
- All of the above properties are jointly determined by the choice of the parameter type and the modeling domain .
Within this framework, a mathematical model can be formalized by an algebraic constraint structure:
The complete mathematical equations derived thereof manifest in the classical state-space form:
These results demonstrate that the present work does not propose a specific state-space model. Rather, it identifies the algebraic conditions and epistemological construction mechanisms under which deterministic mathematical models can be inductively constructed from ontological dynamics.
Within this framework, the modeling domain (MD) encodes the initial conditions, loading protocols, and admissible loading ranges as mathematical structures, thereby providing a rigorous algebraic characterization of both the domain of model applicability and the mechanisms underlying failure under improper extrapolation.
The external action path method formalizes a class of external action encoding schemes widely used in modeling practice.
The difference representations of state and parameters provide an algebraic foundation for comparative experiments, controlled-variable methods, and causal inference.
The generalized state parameter and its existence theorem provide a unified algebraic formulation for modeling approaches that incorporate loading-history information, including the internal variable method.
More broadly, this work develops a normative meta-modeling theory for the inductive construction of deterministic mathematical models, starting from a minimal state-action-state causal structure. Within the ASD framework, mathematical modeling has two complementary dimensions: induction from observations and deduction from conceptual models. The present work is confined to the inductive dimension and does not address empirical parameter fitting, heuristic model selection, stochastic perturbations, measurement noise, or heterogeneity in the underlying ontological dynamics across different systems.
Building on the ontological-epistemological structure established in this work, future research may incorporate theoretical tools from probability theory, system identification, and state representation learning to extend the present framework toward a more general algebraic foundation for mathematical modeling. In particular, the deductive dimension of ASD—namely, the formal construction of conceptual models and their subsequent mathematical realization—remains an important direction for further development.
Author Contributions
Conceptualization, F.X.; methodology, F.X.; software, F.X.; validation, T.X.; formal analysis, F.X.; investigation, F.X.; resources, T.X.; data curation, T.X.; writing—original draft preparation, F.X.; writing—review and editing, T.X.; visualization, F.X.; supervision, T.X.; project administration, T.X.; funding acquisition, T.X.
Funding
This research was funded by the Natural Science Foundation of Zhejiang Province, grant number LZ24E080002.
Data Availability Statement
No new data were created or analyzed in this study. Data sharing is not applicable to this article.
Acknowledgments
The author gratefully acknowledges Fangjie Lian, a former undergraduate classmate, for many stimulating discussions and debates on traditional Chinese medicine and Western medicine. These discussions were an important source of inspiration for the development of Axiomatic System Dynamics (ASD) and, ultimately, the present work.
Conflicts of Interest
The authors declare no conflicts of interest.
Appendix A
Definition A1 (Difference Representation). Let be any nonempty set. A triple
is called a difference representation of if the following conditions hold.
(i) is an abelian group, called the increment space, with additive identity denoted by
.
(ii) is called the difference operator, defined by
For , the induced map
is bijective. Moreover, for , the Chasles relation holds:
(iii) is called the update operator, defined by
The operation is abbreviated as
.
The above definition directly yields several fundamental algebraic properties of the difference representation.
Property A1. If is a difference representation of , then, for
the following properties hold:
(i)
(ii)
(iii)
(iv)
(v)
When is interpreted as a state space, Property A1 is perfectly consistent with our physical intuition of “state variation”. Algebraically, the difference representation endows with the structure of an abelian -torsor. Since a torsor admits an equivalent construction as a free and transitive group action on a set, the following proposition is established.
Proposition A1. Let be any nonempty set and let be an abelian group with additive identity . Suppose that
satisfies the following group action axioms:
(i)
(ii)
(iii)
Then condition (iii) uniquely induces the map
and the resulting triple is a difference representation of
.
The proof of Proposition A1 is straightforward and is thus omitted. Indeed, the update operator induced by the difference operator in Definition A1 necessarily satisfies the group action axioms in Proposition A1. Furthermore, the update operator , when processed through the method in Proposition A1, uniquely re-induces the identical difference operator . This proves the equivalence of the two definition approaches.
We next prove Theorem 2 in Section 4. To this end, we first recall the following proposition, which holds within the ZFC axiomatic framework and serves as the basis for the constructive proof. Since this result is standard in abstract algebra, we omit its proof and refer the reader to [29].
Lemma A1. For any nonempty set , there exists a binary operation such that constitutes an abelian group.
Proposition A2. For any given set , abelian group , and function . There exists a binary operation on such that constitutes an abelian group and constitutes a group homomorphism if and only if the image set forms a subgroup of , and for , the fibers possess identical cardinality.
Proof. Necessity. Let and denote the identity elements of and , respectively, and let denote the kernel of . Since is a group homomorphism, the First Isomorphism Theorem in group theory implies that is a subgroup of and is a subgroup of .
Moreover, for ,
Thus every fiber is a coset of in . Hence, all such fibers have identical cardinality.
Sufficiency. Since , it follows that . By Lemma A1, there exists a binary operation on such that constitutes an abelian group. Denote its identity element by .
We then define a binary operation on the product space by
Under this operation, forms an abelian group with the identity element
Given that for , the fibers possess identical cardinality. For , one can select a bijection
thereby enabling the construction of a global bijection
This uniquely induces a binary operation on such that constitutes an abelian group, satisfying the group isomorphism relation
Evidently, the composite function is the natural projection from onto , namely,
Consequently, constitutes a group homomorphism. Furthermore, since is a group isomorphism, it follows that is also a group homomorphism. □
Utilizing Proposition A2, the rigorous proof for Theorem 2 in this manuscript (denoted here as Theorem A1) can now be presented.
Theorem A1. For any prescribed parameter type and its difference representation . There exists a difference representation of the state space such that the map induced by the observation operator :
constitutes a well-defined group homomorphism if and only if: such that the image set constitutes a subgroup of , and for , the fibers possess identical cardinality.
Proof. Necessity. Arbitrarily choose and let . By the definition of the difference representation, the difference operators and respectively induce the bijections and . These bijections uniquely induce binary operations on and on , respectively, such that the following abelian group isomorphisms hold
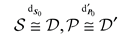
Through the function composition, it is straightforward to verify that:
Since each of the three functions on the left-hand side is a group homomorphism, the observation operator constitutes a group homomorphism as well. Consequently, the composite function:
is a group homomorphism.
By Proposition A2,
forms a subgroup of . Furthermore, since is a group homomorphism, for , the fibers possess identical cardinality.
Sufficiency. For the satisfying the prescribed condition, the bijection uniquely induces a binary operation on , thereby establishing the abelian group isomorphism

Given that is a subgroup of , it follows from the isomorphism that constitutes a subgroup of . Hence the conditions of Proposition A2 are satisfied, and there exists a binary operation on such that forms an abelian group, and the observation operator constitutes a group homomorphism.
Consequently, by defining the abelian group , the difference operator is defined as:
Predicated on this operator, the corresponding difference representation can be uniquely constructed. Under this difference representation, is a group homomorphism. Moreover, for :
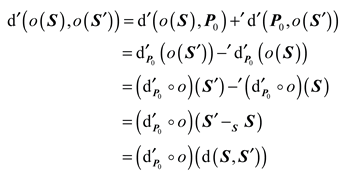
Therefore, the function induced by the observation operator :
is exactly the group homomorphism . Therefore, is itself a group homomorphism. □
References
- Kalman, R.E. Mathematical description of linear dynamical systems. J. Soc. Ind. Appl. Math. Ser. A Control 1963, 1(2), 152–92. [Google Scholar] [CrossRef]
- Sontag, E.D. Mathematical control theory; Springer-Verlag: New York, Jul 1998. [Google Scholar]
- Zadeh, L.; Desoer, C. Linear system theory: the state space approach; Courier Dover Publications, 24 Jul 2008. [Google Scholar]
- Åström, K.J.; Eykhoff, P. System identification—a survey. Automatica 1971, 7(2), 123–62. [Google Scholar] [CrossRef]
- Ljung, L. System identification; Univ., 29 May 1995. [Google Scholar]
- Sivaranjani, S.; Shi, Y.; Atanasov, N.; Duong, T.; Feng, J.; Martin, T.; Xu, Y.; Gupta, V.; Allgöwer, F. Control-oriented system identification: Classical, learning, and physics-informed approaches. Annu. Rev. Control 2026, 62, 101067. [Google Scholar] [CrossRef]
- Watter, M.; Springenberg, J.; Boedecker, J.; Riedmiller, M. Embed to control: A locally linear latent dynamics model for control from raw images. Adv. Neural Inf. Process. Syst. 2015, 28. [Google Scholar]
- Lesort, T.; Díaz-Rodríguez, N.; Goudou, J.F.; Filliat, D. State representation learning for control: An overview. Neural Netw. 2018, 108, 379–92. [Google Scholar] [CrossRef] [PubMed]
- Hafner, D.; Lillicrap, T.; Fischer, I.; Villegas, R.; Ha, D.; Lee, H.; Davidson, J. Learning latent dynamics for planning from pixels. InInternational conference on machine learning, 2019 May 24; PMLR; pp. 2555–2565. [Google Scholar]
- Echchahed, A.; Castro, P.S. A survey of state representation learning for deep reinforcement learning. arXiv 2025, arXiv:2506.17518. [Google Scholar]
- Willems, J.C. Paradigms and puzzles in the theory of dynamical systems. IEEE Trans. Autom. Control 1991, 36(3), 259–94. [Google Scholar] [CrossRef]
- Willems, J.C. The behavioral approach to open and interconnected systems. IEEE Control Syst. Mag. 2007, 27(6), 46–99. [Google Scholar] [CrossRef]
- Markovsky, I.; Dörfler, F. Behavioral systems theory in data-driven analysis, signal processing, and control. Annu. Rev. Control 2021, 52, 42–64. [Google Scholar] [CrossRef]
- Arbib, M.A.; Manes, E.G. Foundations of system theory: decomposable systems. Automatica 1974, 10(3), 285–302. [Google Scholar] [CrossRef]
- Katok, A.; Katok, A.B.; Hasselblatt, B. Introduction to the modern theory of dynamical systems; Cambridge university press, 1995. [Google Scholar]
- Van der Schaft, A.J. Equivalence of dynamical systems by bisimulation. IEEE Trans. Autom. Control 2004, 49(12), 2160–72. [Google Scholar] [CrossRef]
- Bisping, B. Process equivalence problems as energy games. InInternational Conference on Computer Aided Verification, 2023 Jul 17; Springer Nature Switzerland: Cham; pp. 85–106. [Google Scholar]
- Mesarovic, M.D.; Takahara, Y. General systems theory: mathematical foundations; Academic press, 21 Mar 1975. [Google Scholar]
- Takahashi, S.; Takahara, Y. Logical approach to systems theory; Springer: New York, Jun 1995. [Google Scholar]
- Zeigler, B.P.; Praehofer, H.; Kim, T.G. Theory of modelling and simulation; Wiley: New York, May 1976. [Google Scholar]
- Vangheluwe, H. The discrete event system specification (DEVS) formalism. In Course Notes, Course: Modeling and Simulation (COMP522A); McGill University, Montreal Canada, 2001; p. 13. [Google Scholar]
- Xia, F.; Xia, T. The Logic Structure Behind Mathematical Models: An Axiomatic Framework for System Dynamics. Systems 2026, 14(7), 873. [Google Scholar] [CrossRef]
- Skorobogatov, A. Torsors and rational points; Cambridge University Press, 5 Jul 2001. [Google Scholar]
- Milne, J.S. Algebraic groups: the theory of group schemes of finite type over a field; Cambridge University Press, 21 Sep 2017. [Google Scholar]
- Reddy, J.N. An introduction to continuum mechanics; Cambridge university press, 29 Jul 2013. [Google Scholar]
- Aubin, J.P. Set-valued analysis. In InMutational and Morphological Analysis: Tools for Shape Evolution and Morphogenesis; Birkhäuser Boston: Boston, MA, 1990; pp. 205–264. [Google Scholar]
- Horstemeyer, M.F.; Bammann, D.J. Historical review of internal state variable theory for inelasticity. Int. J. Plast. 2010, 26(9), 1310–34. [Google Scholar] [CrossRef]
- Maugin, G.A. The saga of internal variables of state in continuum thermo-mechanics (1893–2013). Mech. Res. Commun. 2015, 69, 79–86. [Google Scholar] [CrossRef]
- Rotman, J.J. An introduction to the theory of groups; Springer Science & Business Media, 6 Dec 2012. [Google Scholar]
Figure 1.
(a) Ontological-epistemological dual structure of system evolution. (b) Modeling domain (MD). System evolution in controlled experiments is deterministic and reproducible in the sense of set-valued state evolution.
Figure 1.
(a) Ontological-epistemological dual structure of system evolution. (b) Modeling domain (MD). System evolution in controlled experiments is deterministic and reproducible in the sense of set-valued state evolution.
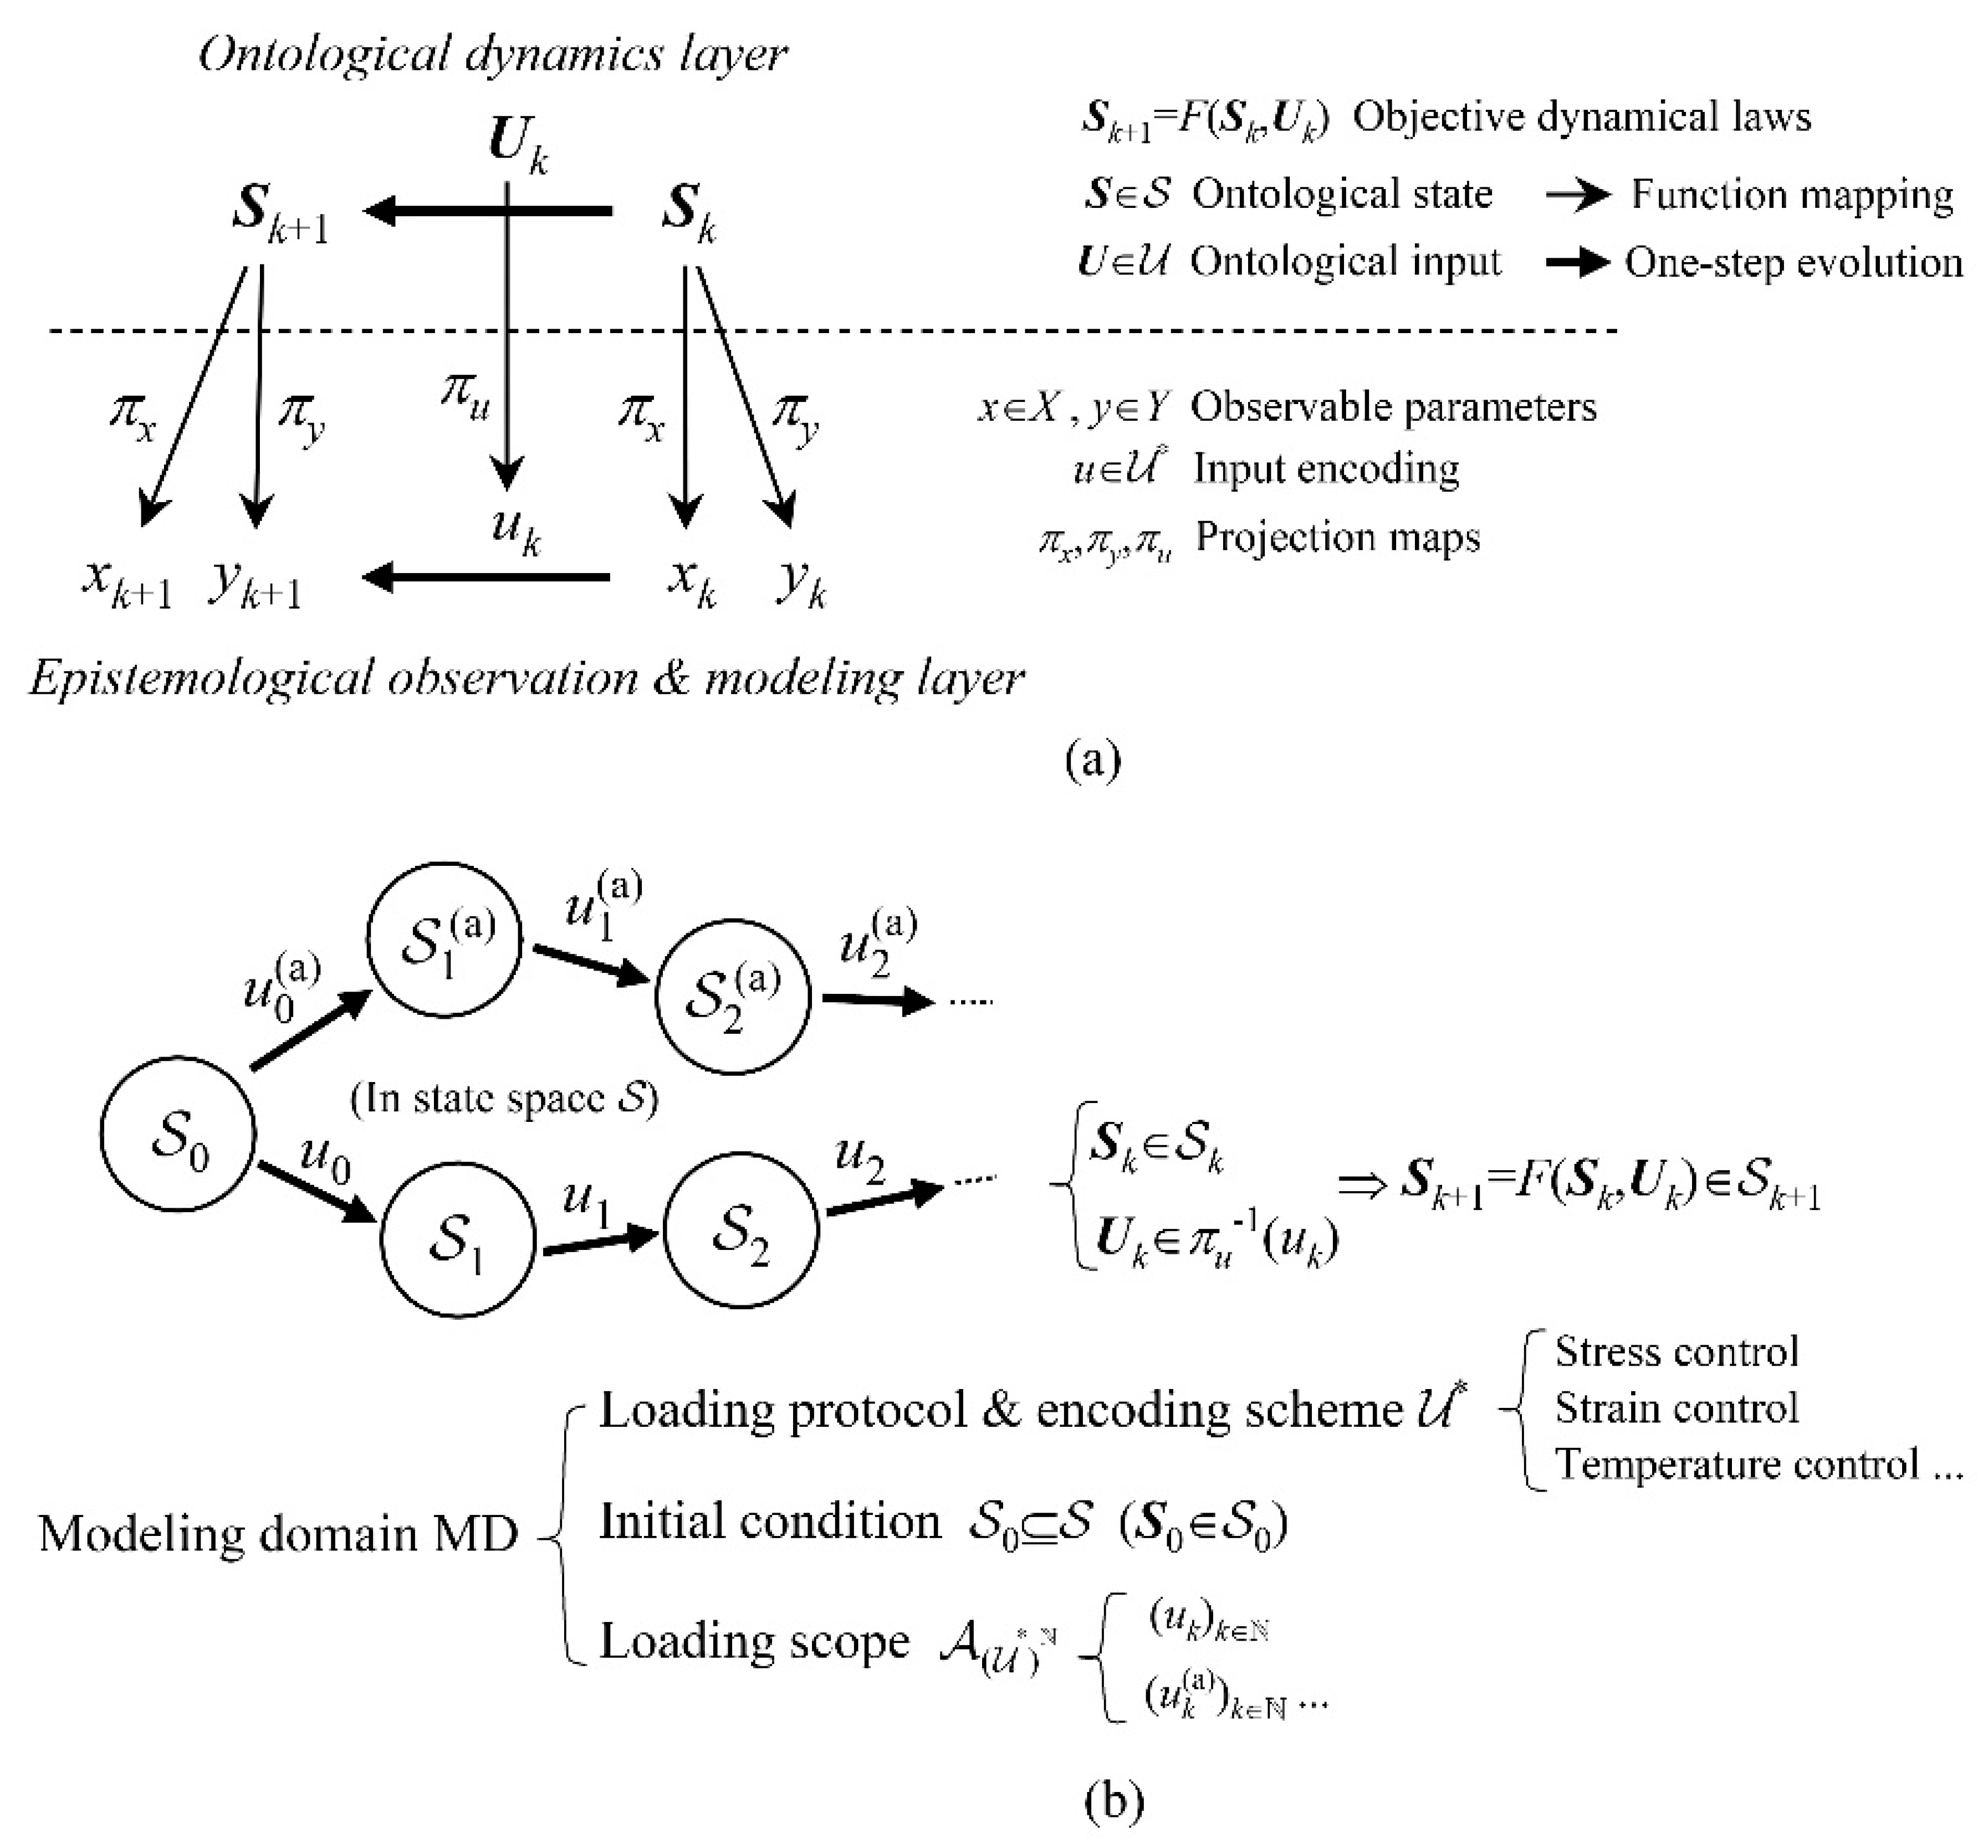
Figure 2.
Ontological dynamics structure, and the one-step evolution of the system state over a basic evolution interval.
Figure 2.
Ontological dynamics structure, and the one-step evolution of the system state over a basic evolution interval.
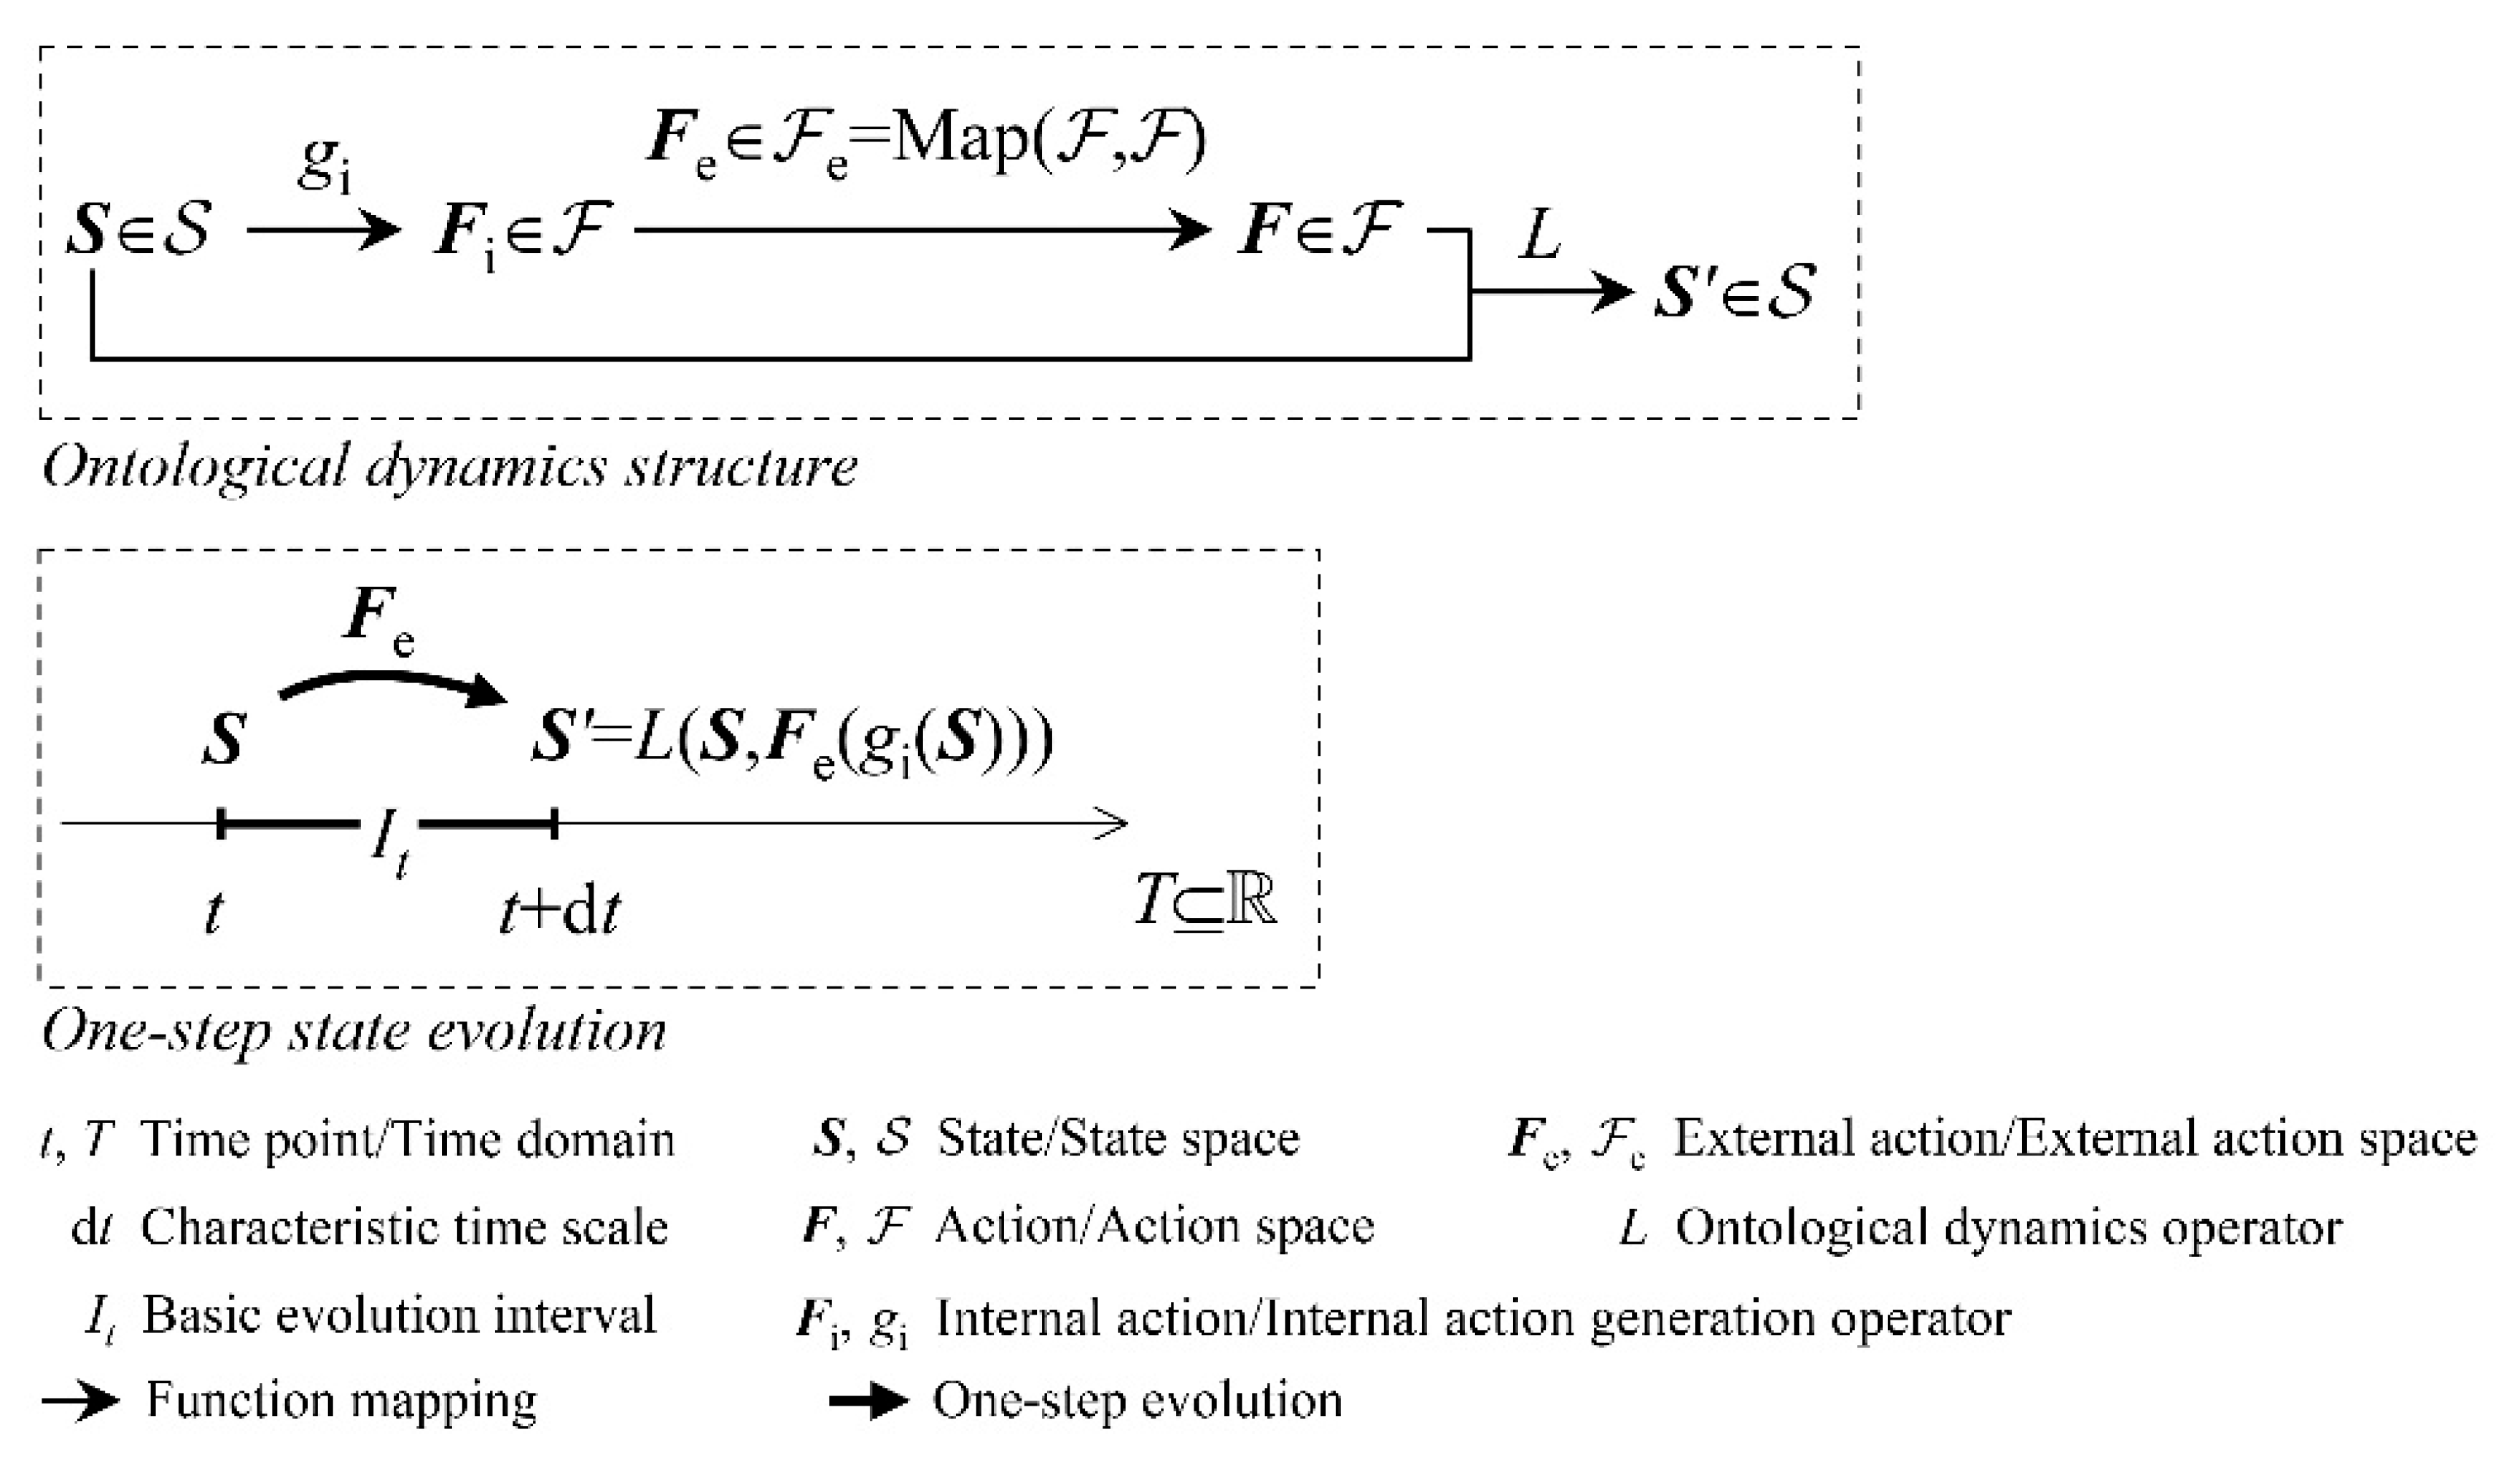
Figure 3.
(a) Difference representation of the state. (b) The induction principle of external actions (B-A principle) in ASD. The net contribution of an external action is identified through differences between comparative experiments.
Figure 3.
(a) Difference representation of the state. (b) The induction principle of external actions (B-A principle) in ASD. The net contribution of an external action is identified through differences between comparative experiments.
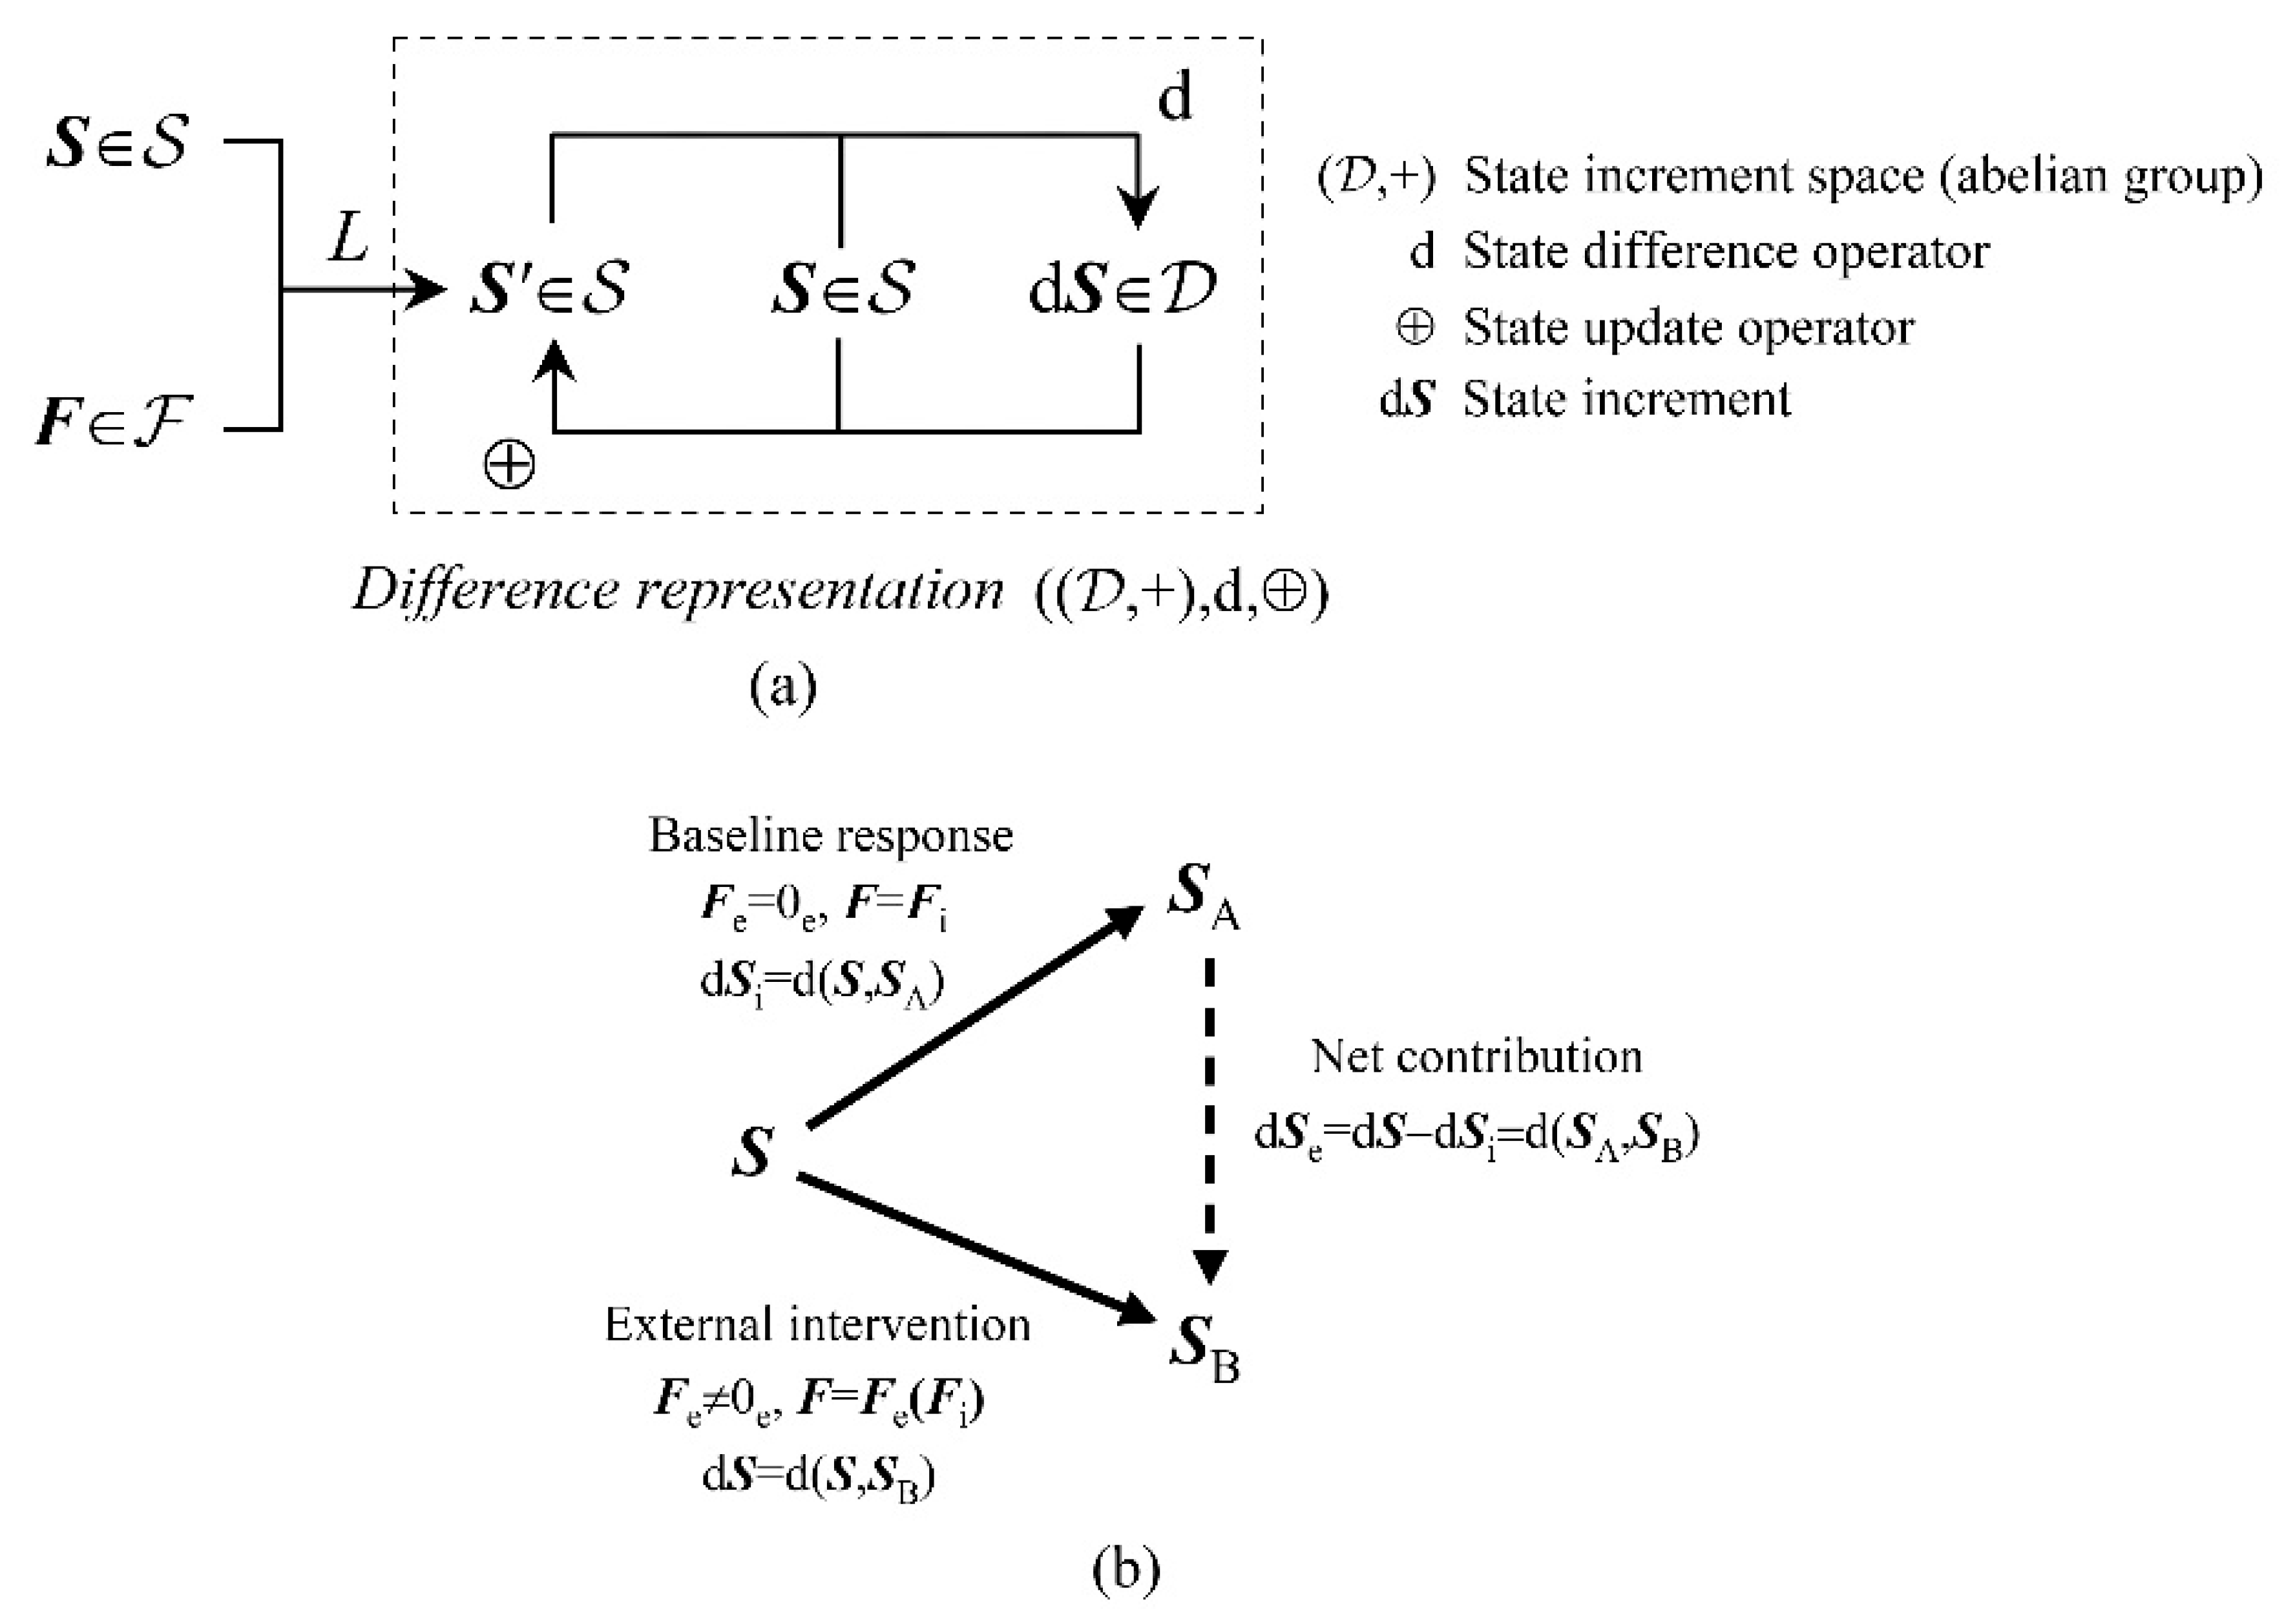
Figure 4.
Observation and modeling structure.
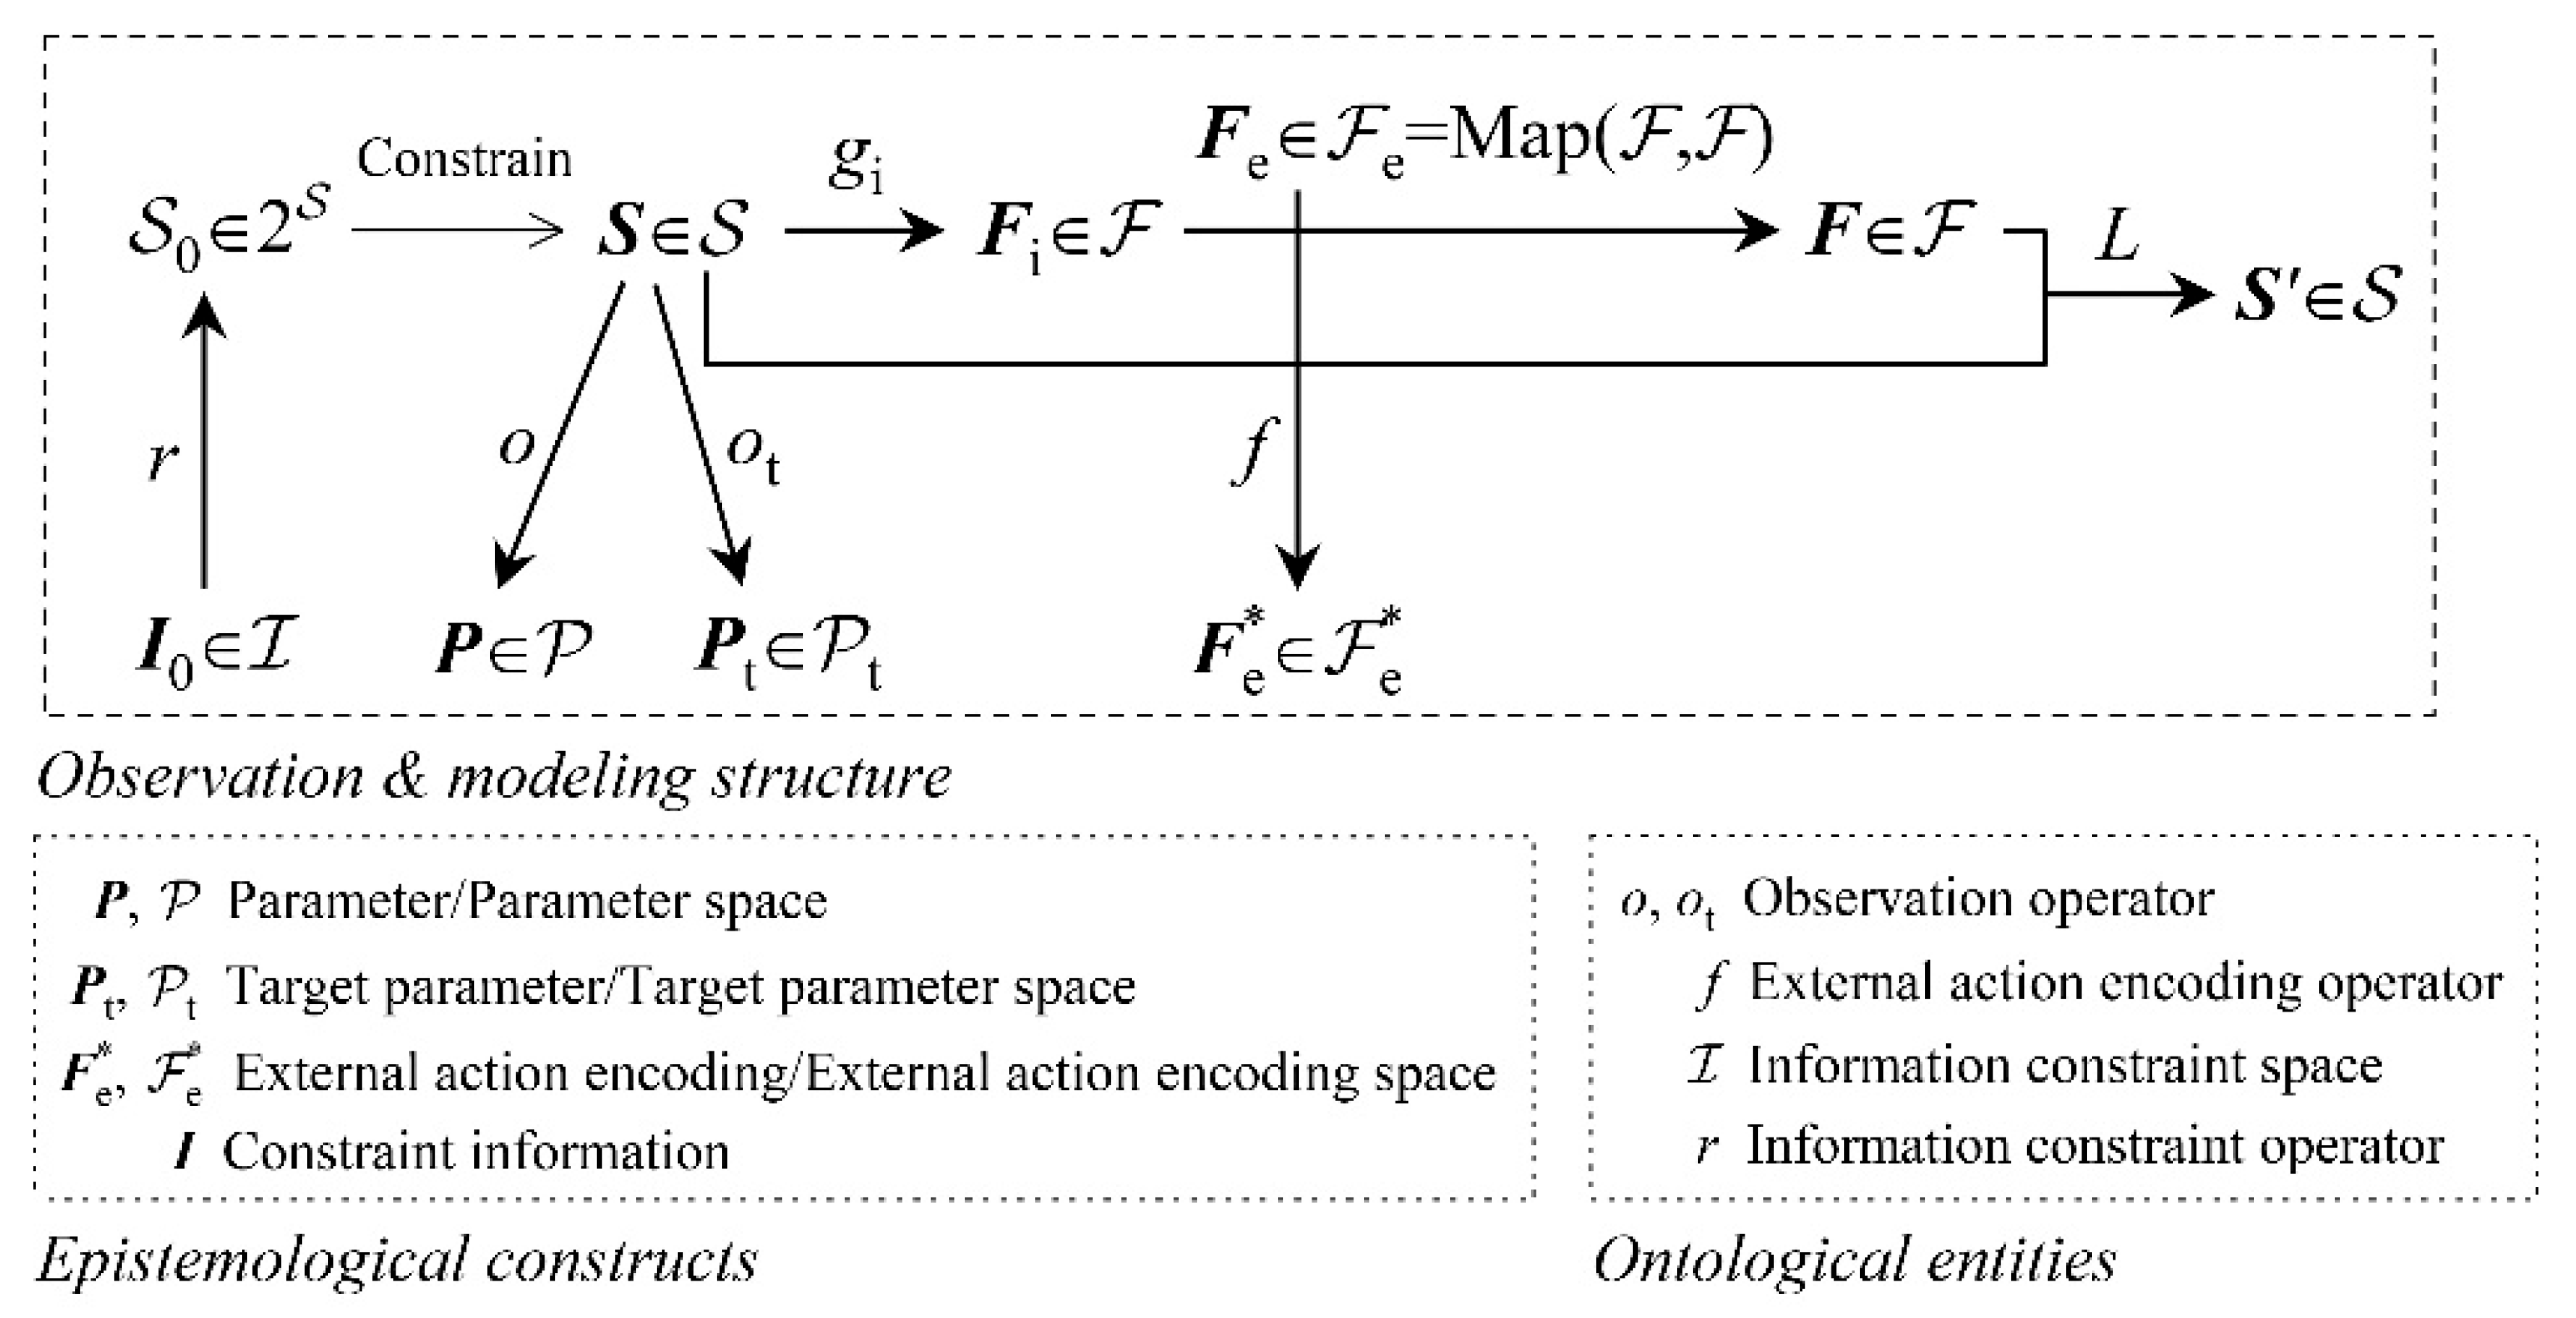
Figure 5.
The external action path method. The external action encoding over a basic evolution interval is the equivalence class induced by the restriction of the external action path to that interval. Function segments that coincide under a translation along the time axis are regarded as equivalent.
Figure 6.
(a) Circle-arrow diagram. Circles denote state sets, and arrows denote external action encodings. (b) Circle-arrow chain. The initial state set and the sequence of external action encodings uniquely determine the corresponding sequence of state sets. (c) All admissible circle-arrow chains within the modeling domain (MD). The circle-arrow-circle configurations in these chains constitute the dynamics units within MD.
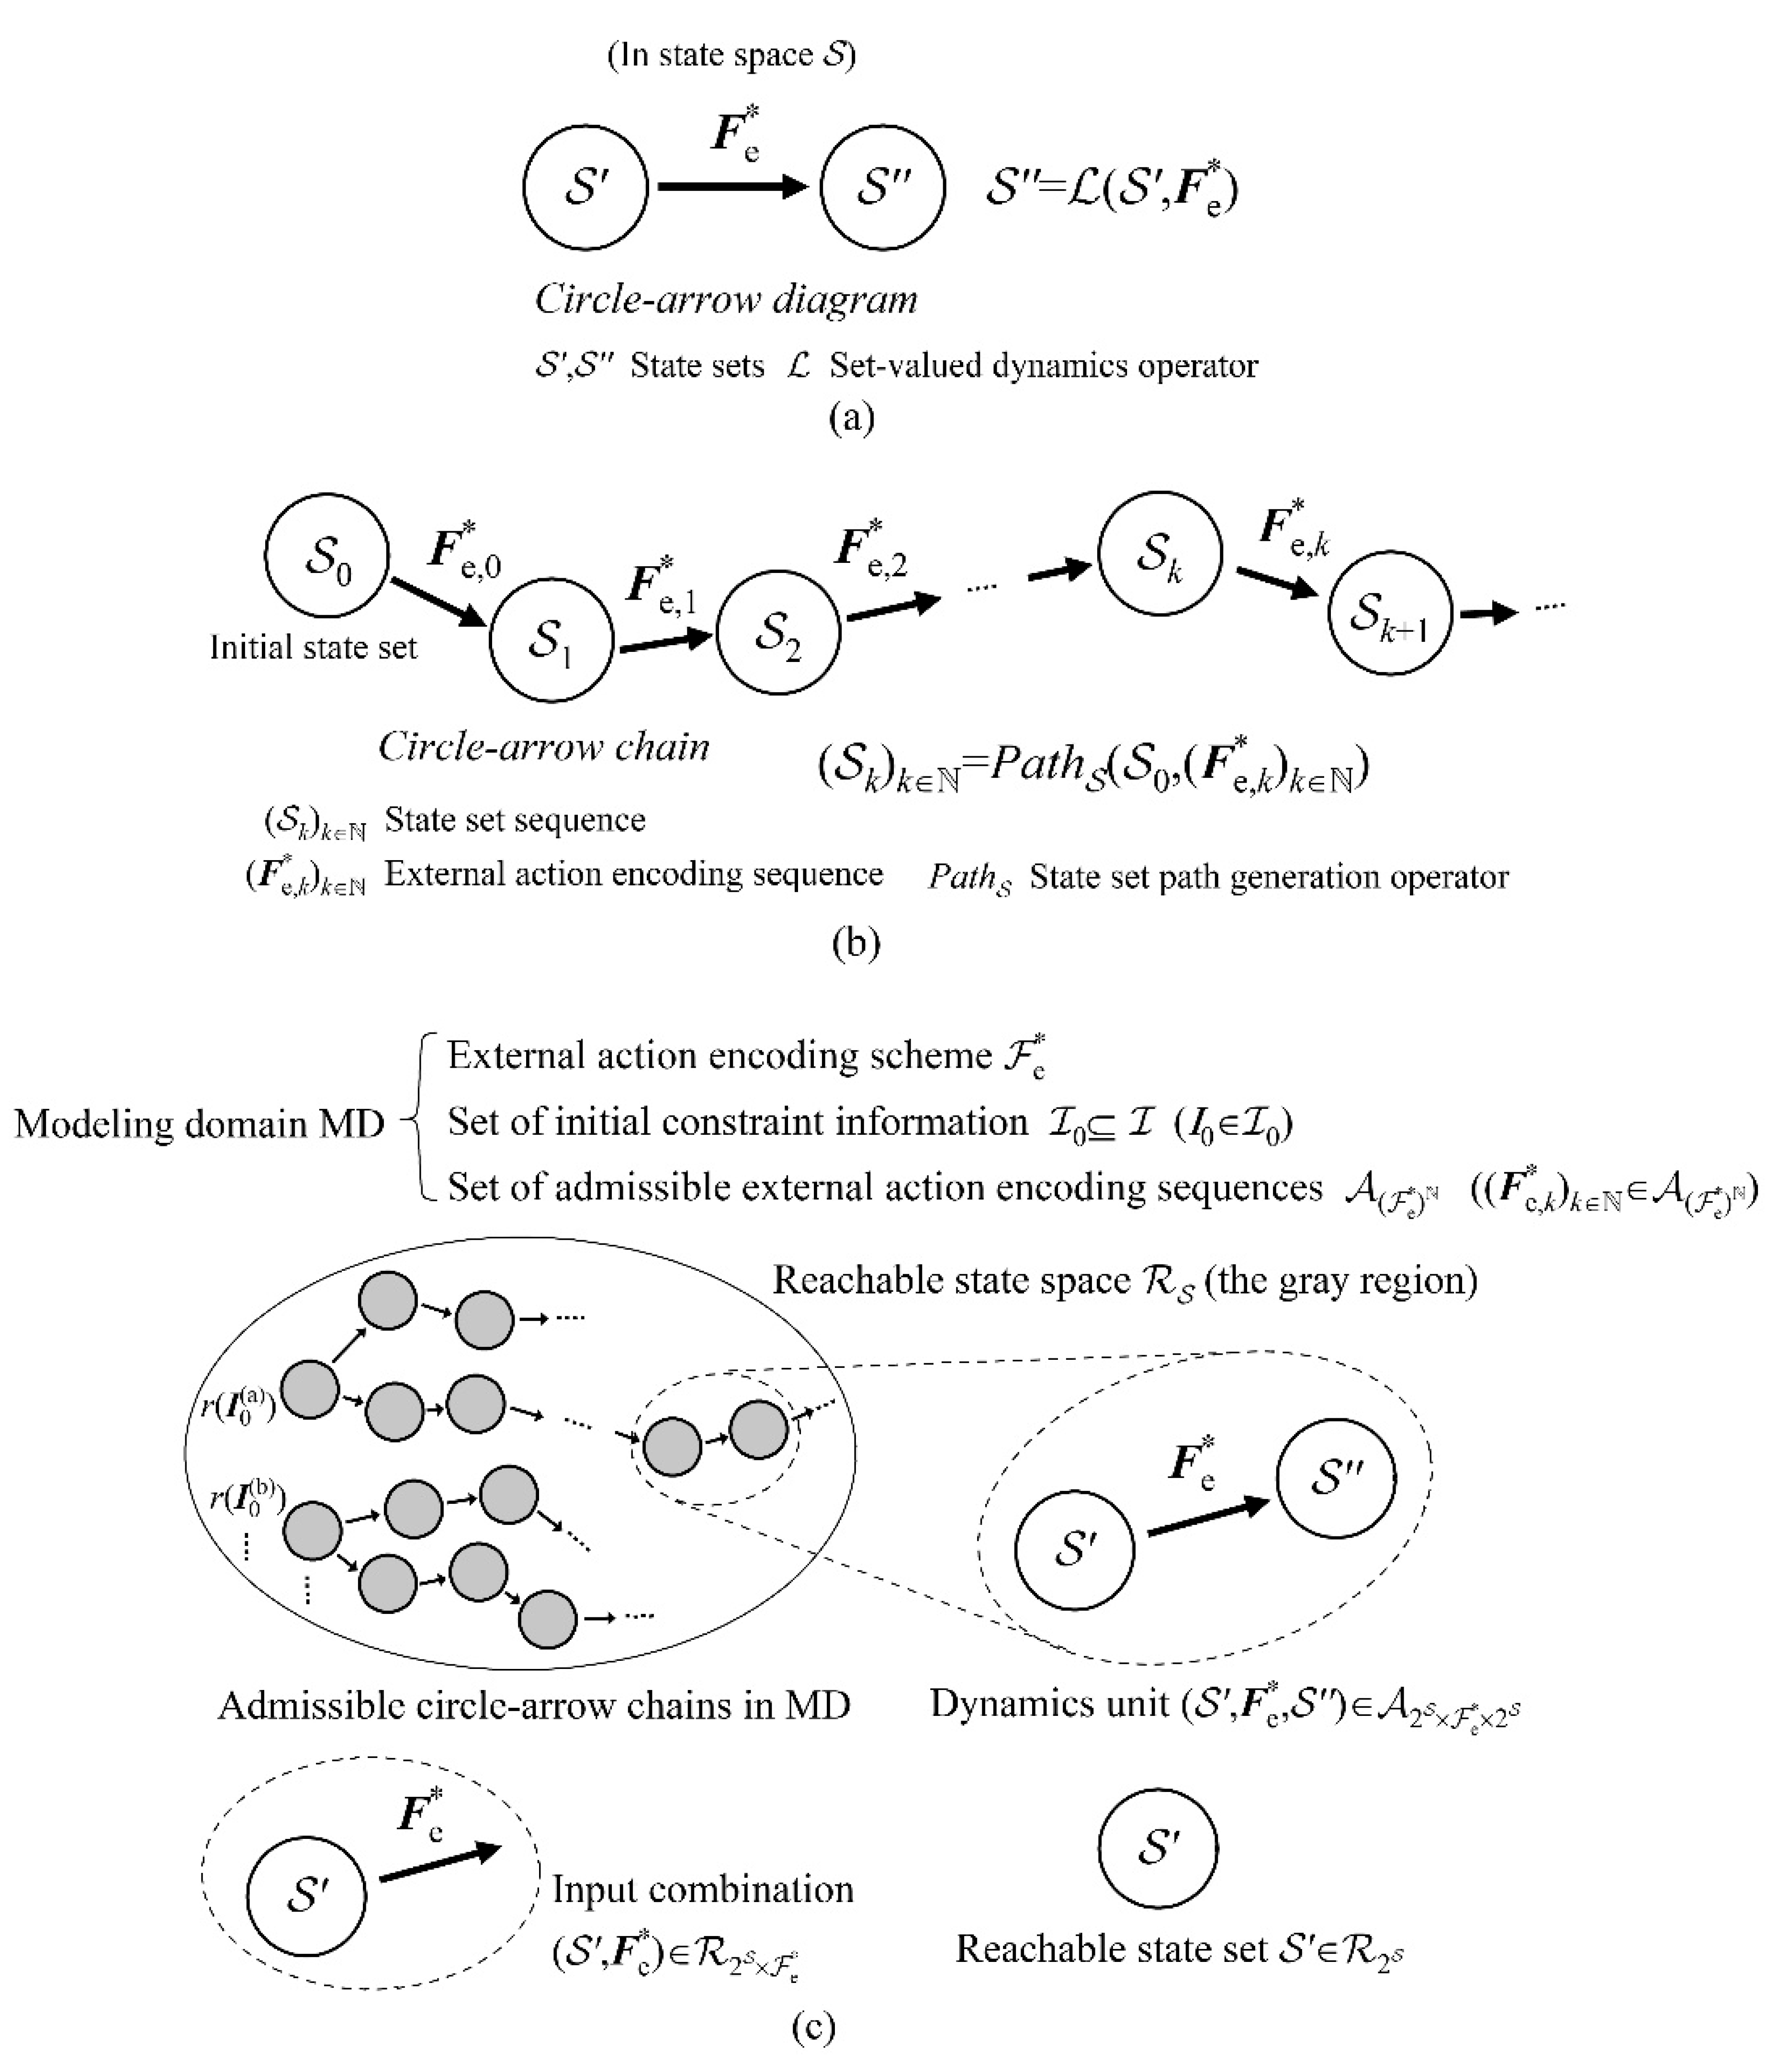
Figure 7.
(a) Weak validity condition of a parameter type. Every reachable state set within the modeling domain (MD) must be monochromatic with respect to the parameter. (b) If this condition fails, repeated trials under identical initial conditions and loading paths may yield non-unique parameter evolutions.
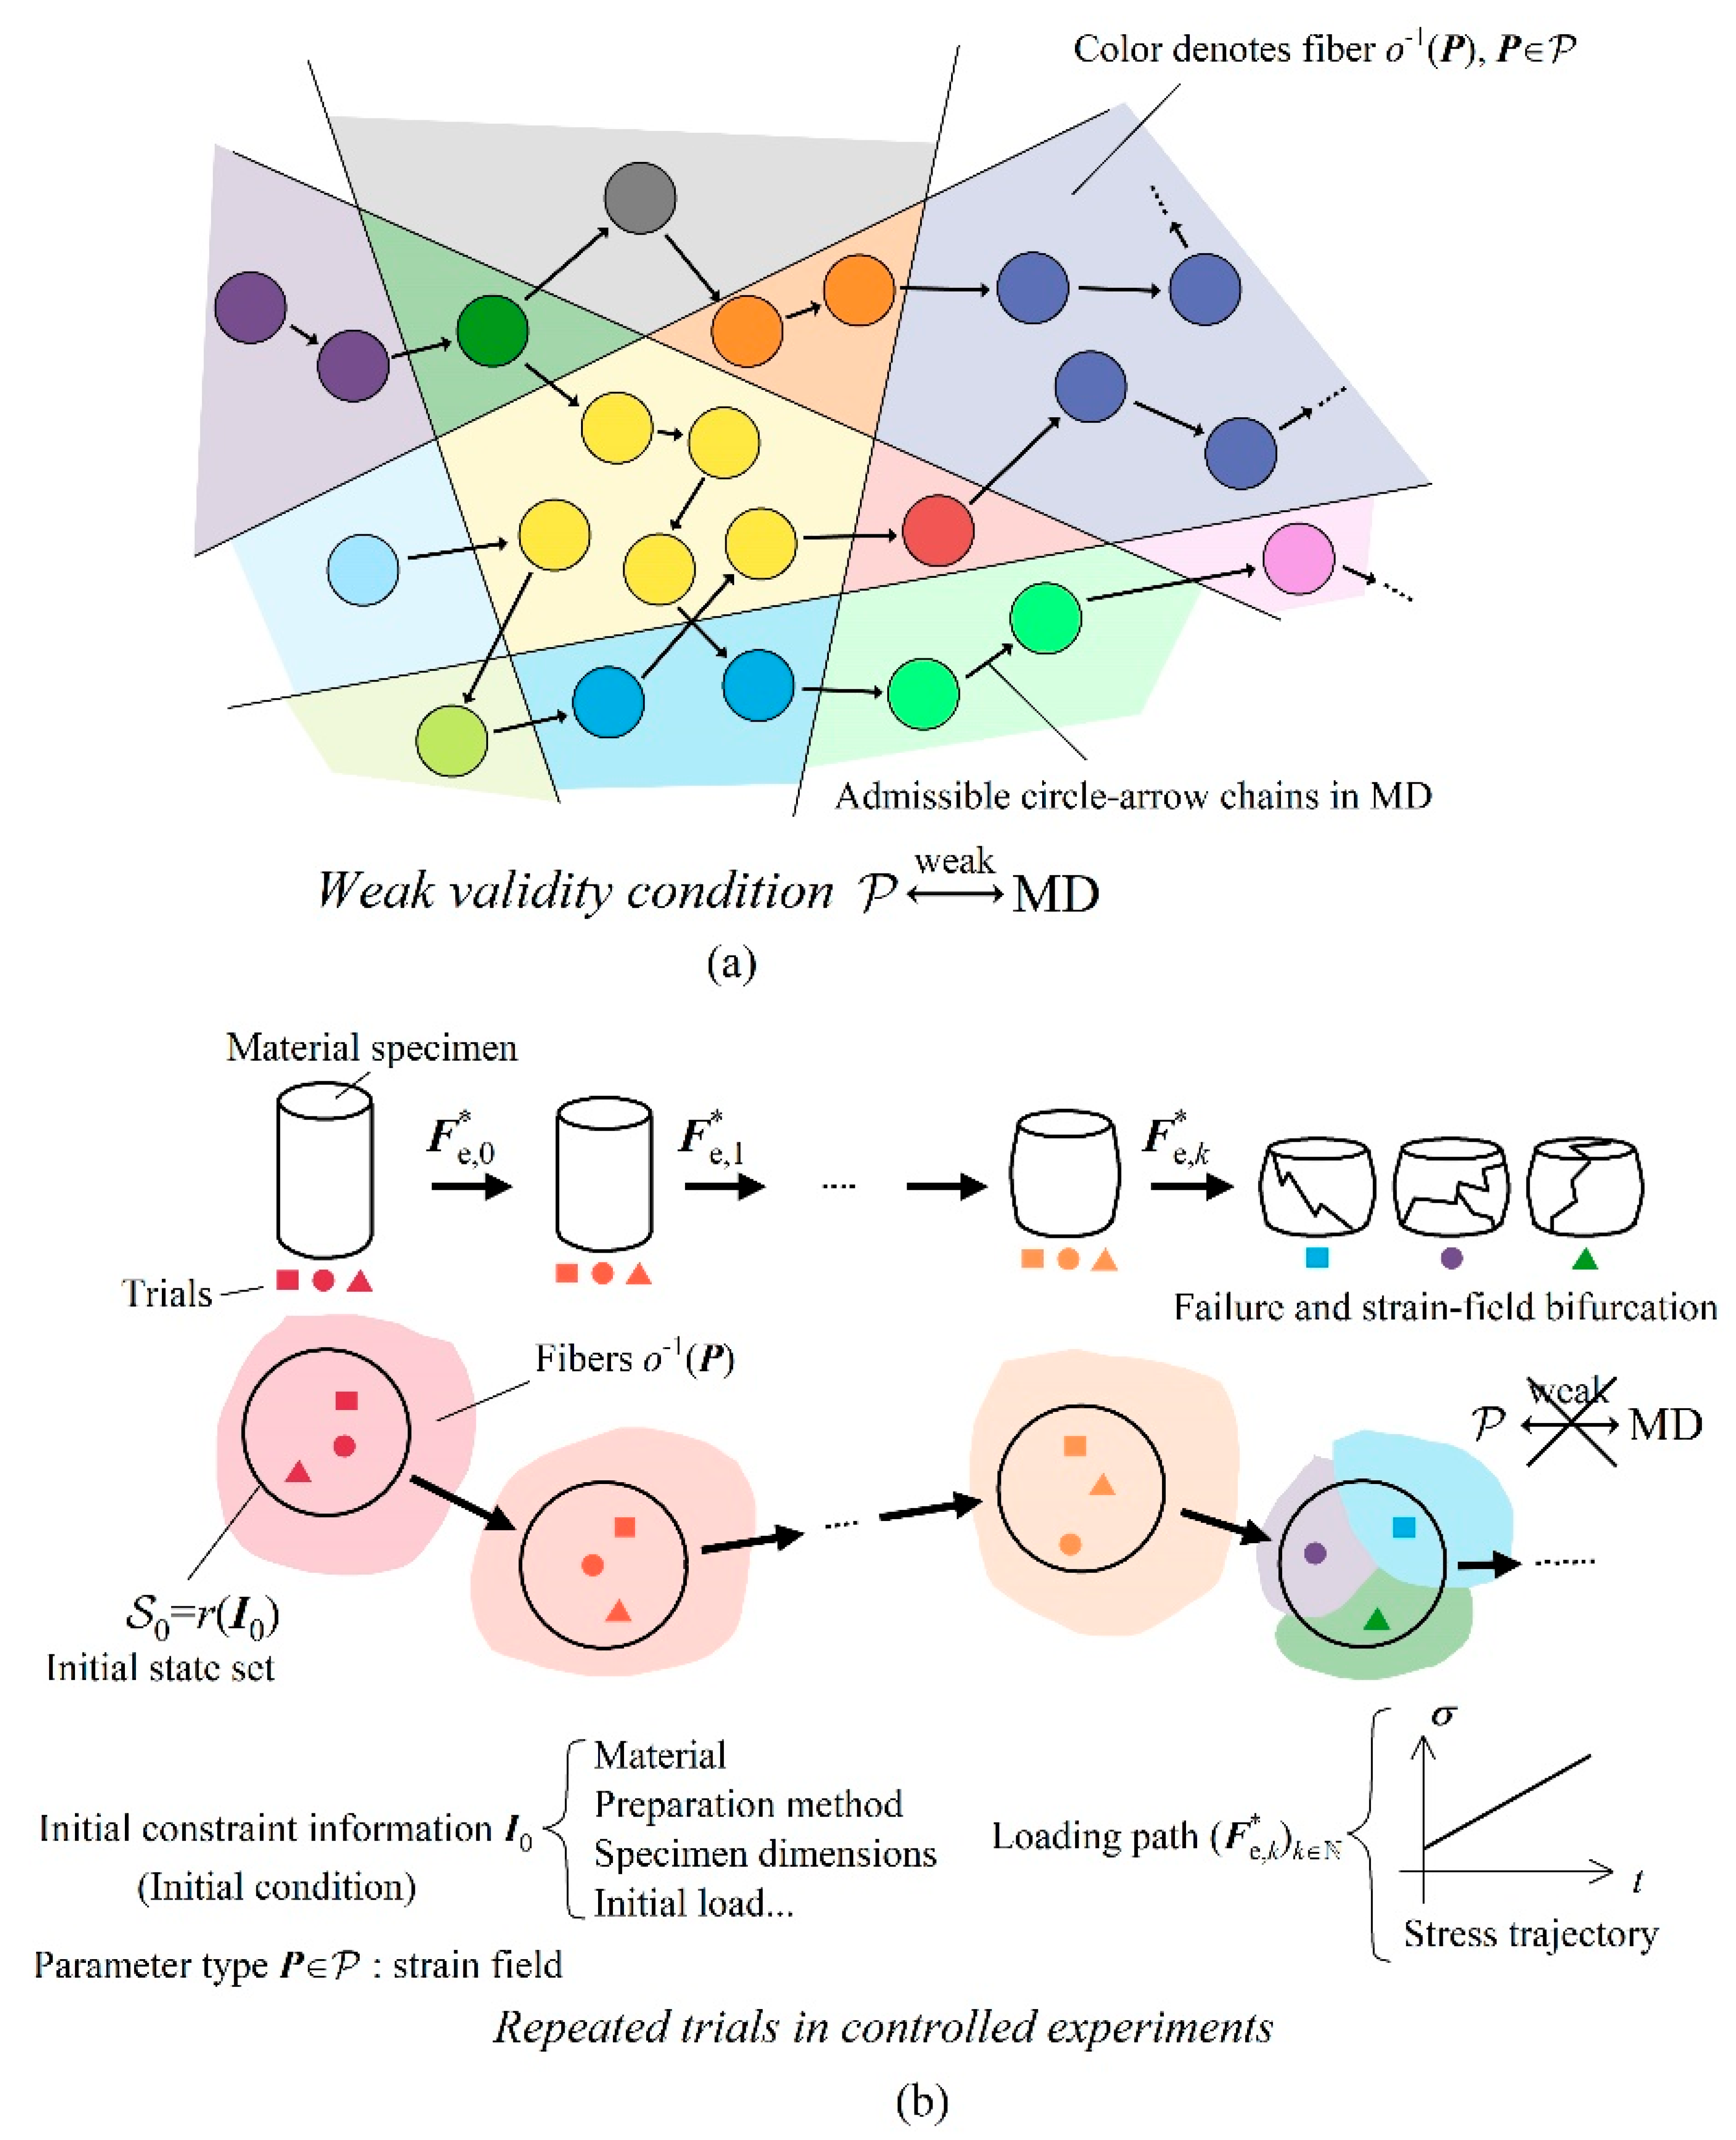
Figure 8.
A dynamics unit under parameter coloring is transformed into a colored dynamics unit comprising a color input combination and an output color.
Figure 8.
A dynamics unit under parameter coloring is transformed into a colored dynamics unit comprising a color input combination and an output color.
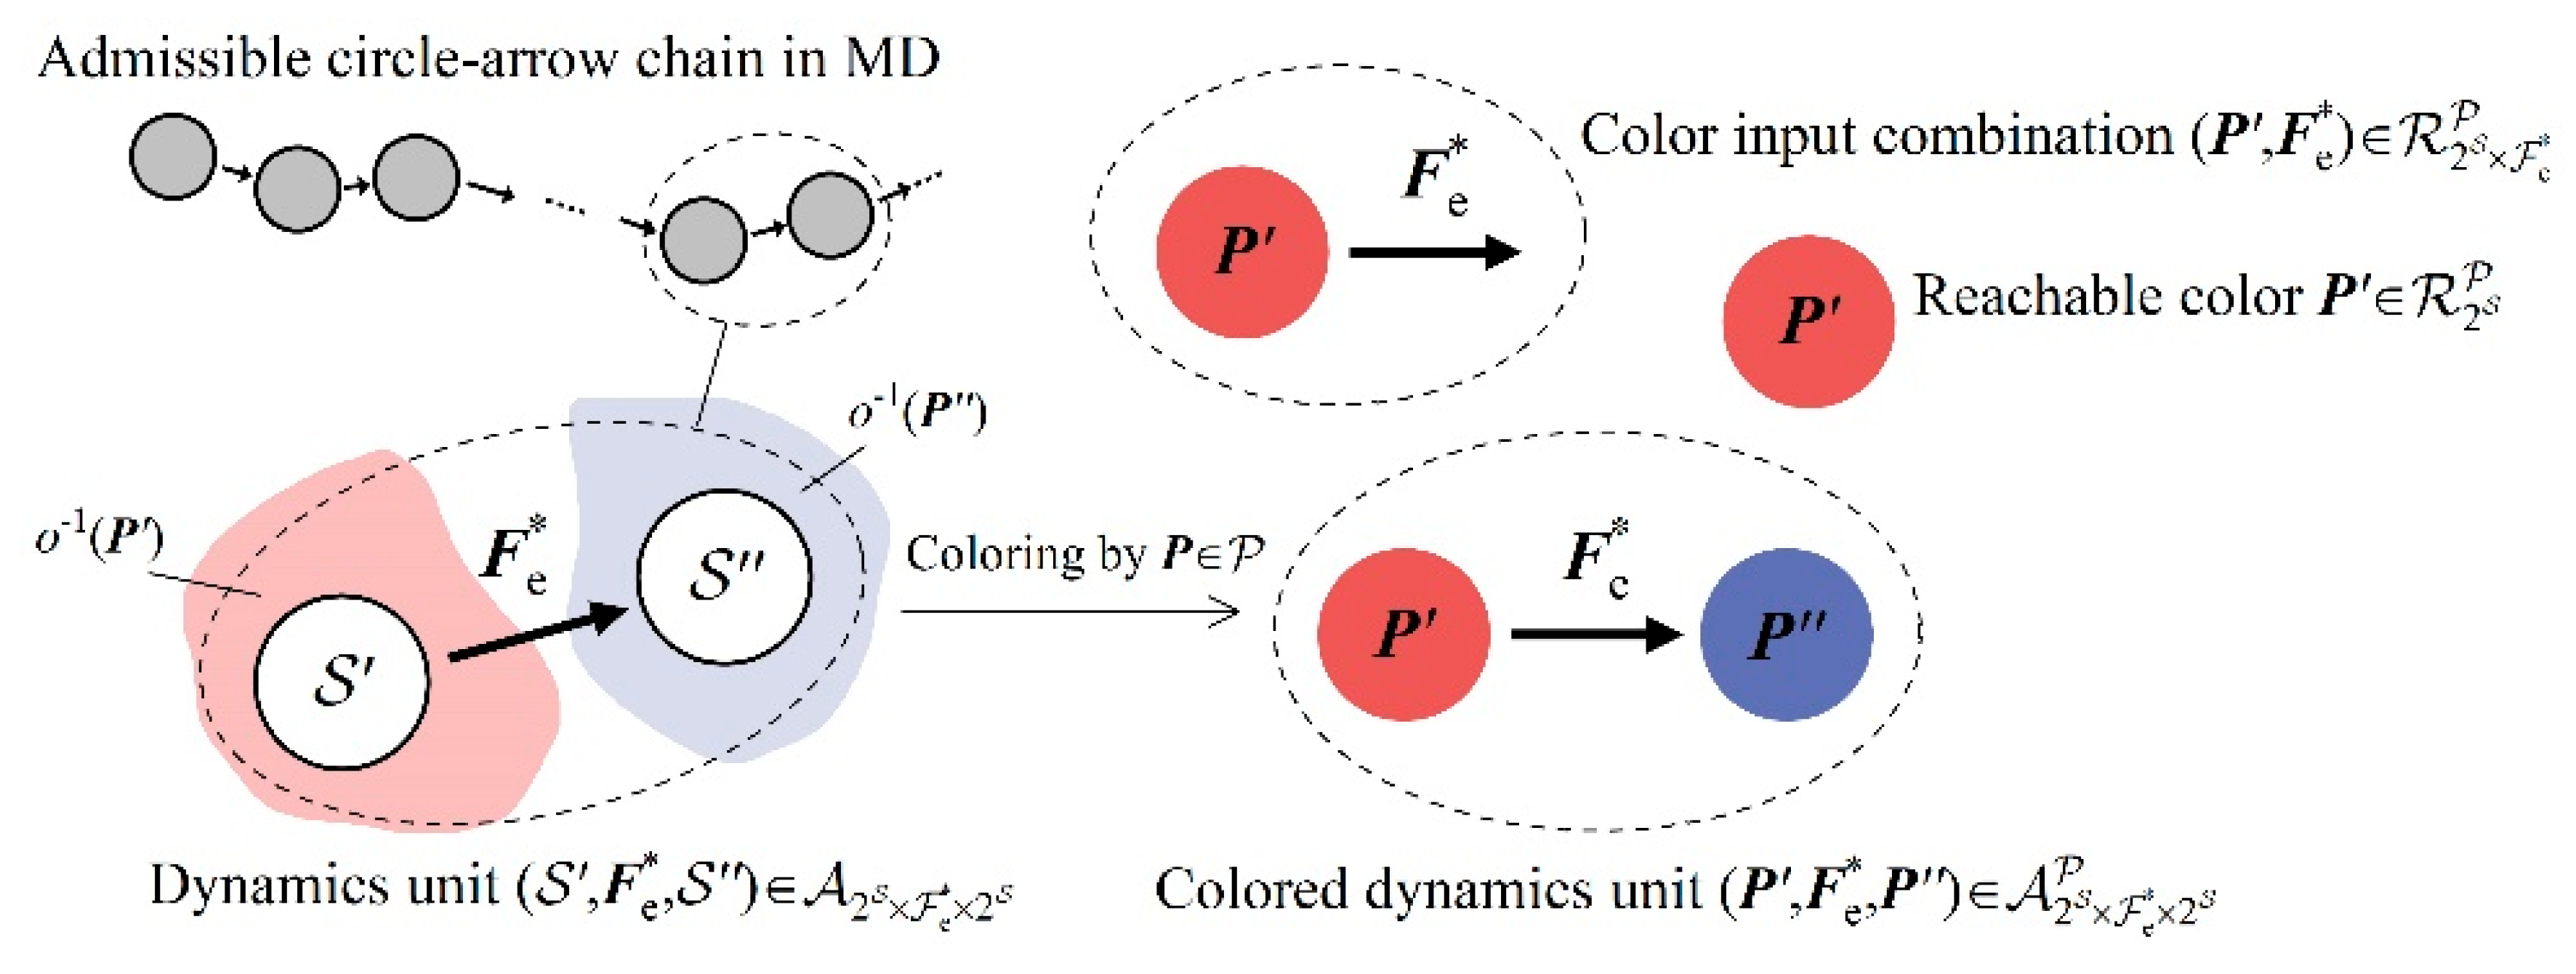
Figure 9.
Strong validity condition of a parameter type. Within the modeling domain (MD), all admissible circle-arrow pairs sharing the same color combination (illustrated by the red- combination) must point to circles of the same color (illustrated in blue).
Figure 9.
Strong validity condition of a parameter type. Within the modeling domain (MD), all admissible circle-arrow pairs sharing the same color combination (illustrated by the red- combination) must point to circles of the same color (illustrated in blue).
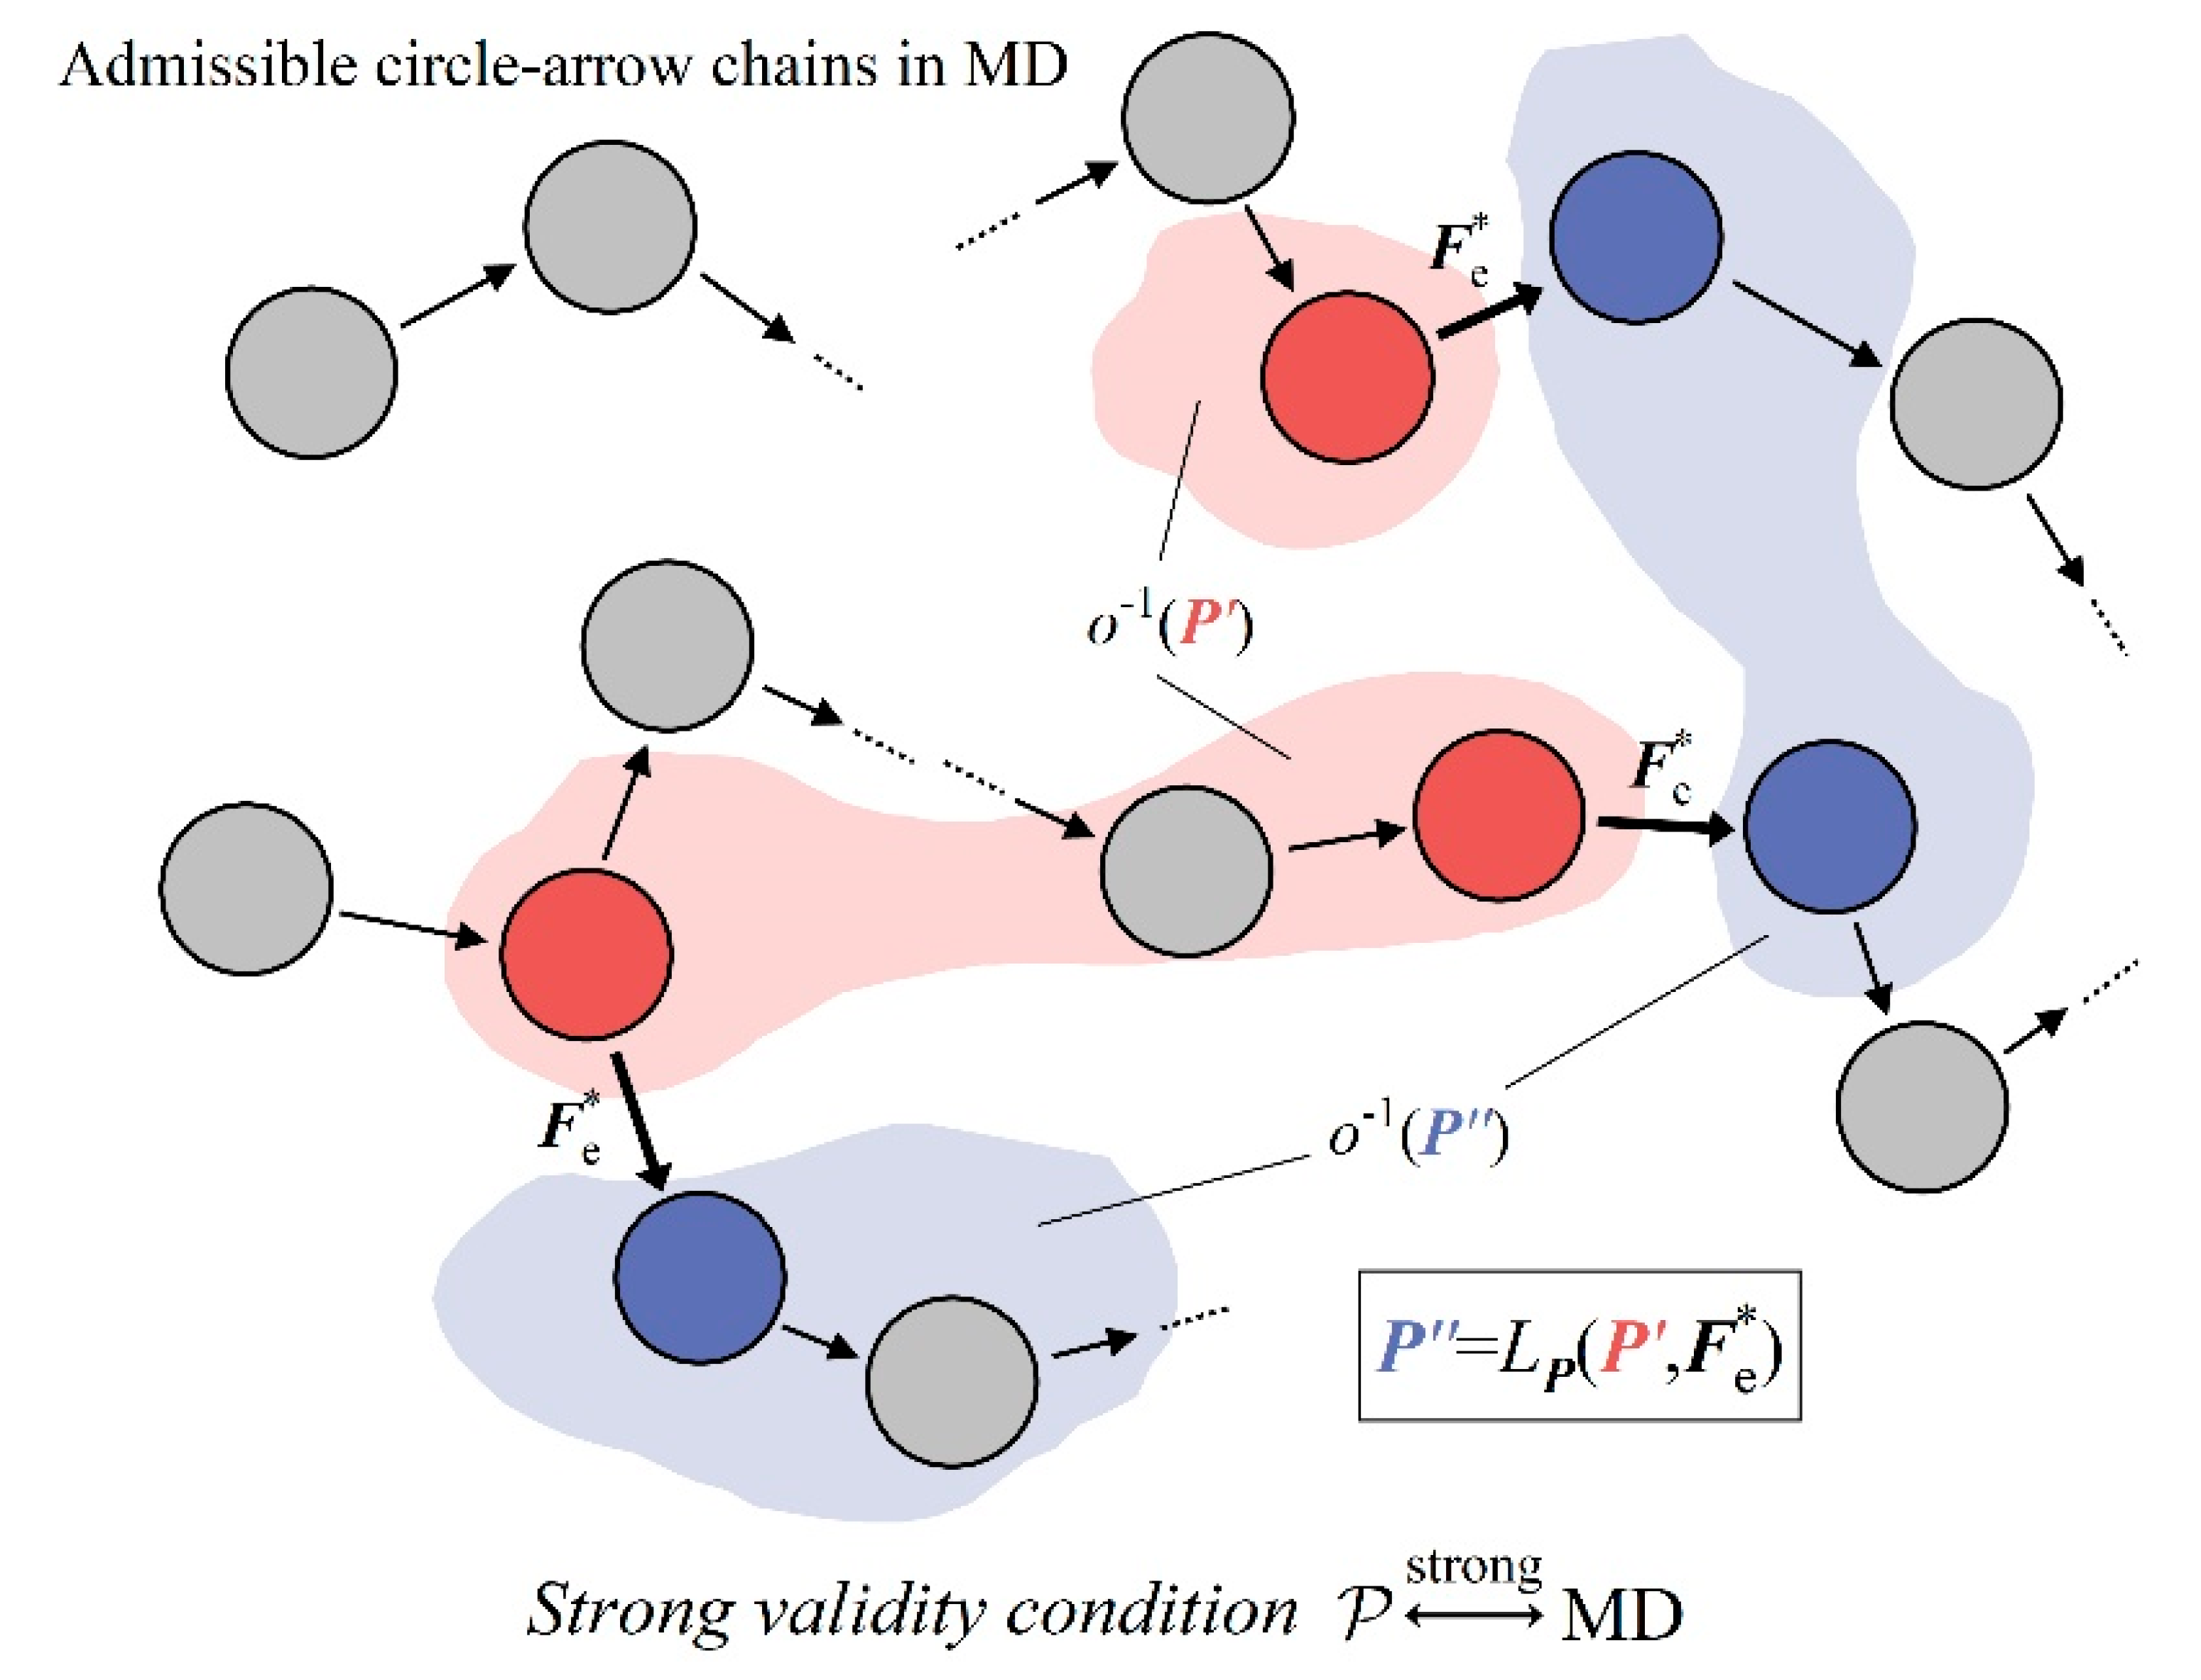
Figure 10.
(a) Global strong validity condition of a parameter type. For any monochromatic subset of the reachable state space, uniquely determines the one-step parameter evolution whenever the corresponding color input combination lies within its domain. (b) Strong validity does not imply global strong validity. is restricted to the color transitions realized by admissible dynamics units. (c) Under the conditions shown, global strong validity condition holds, and the updated state set remains within the reachable state space.
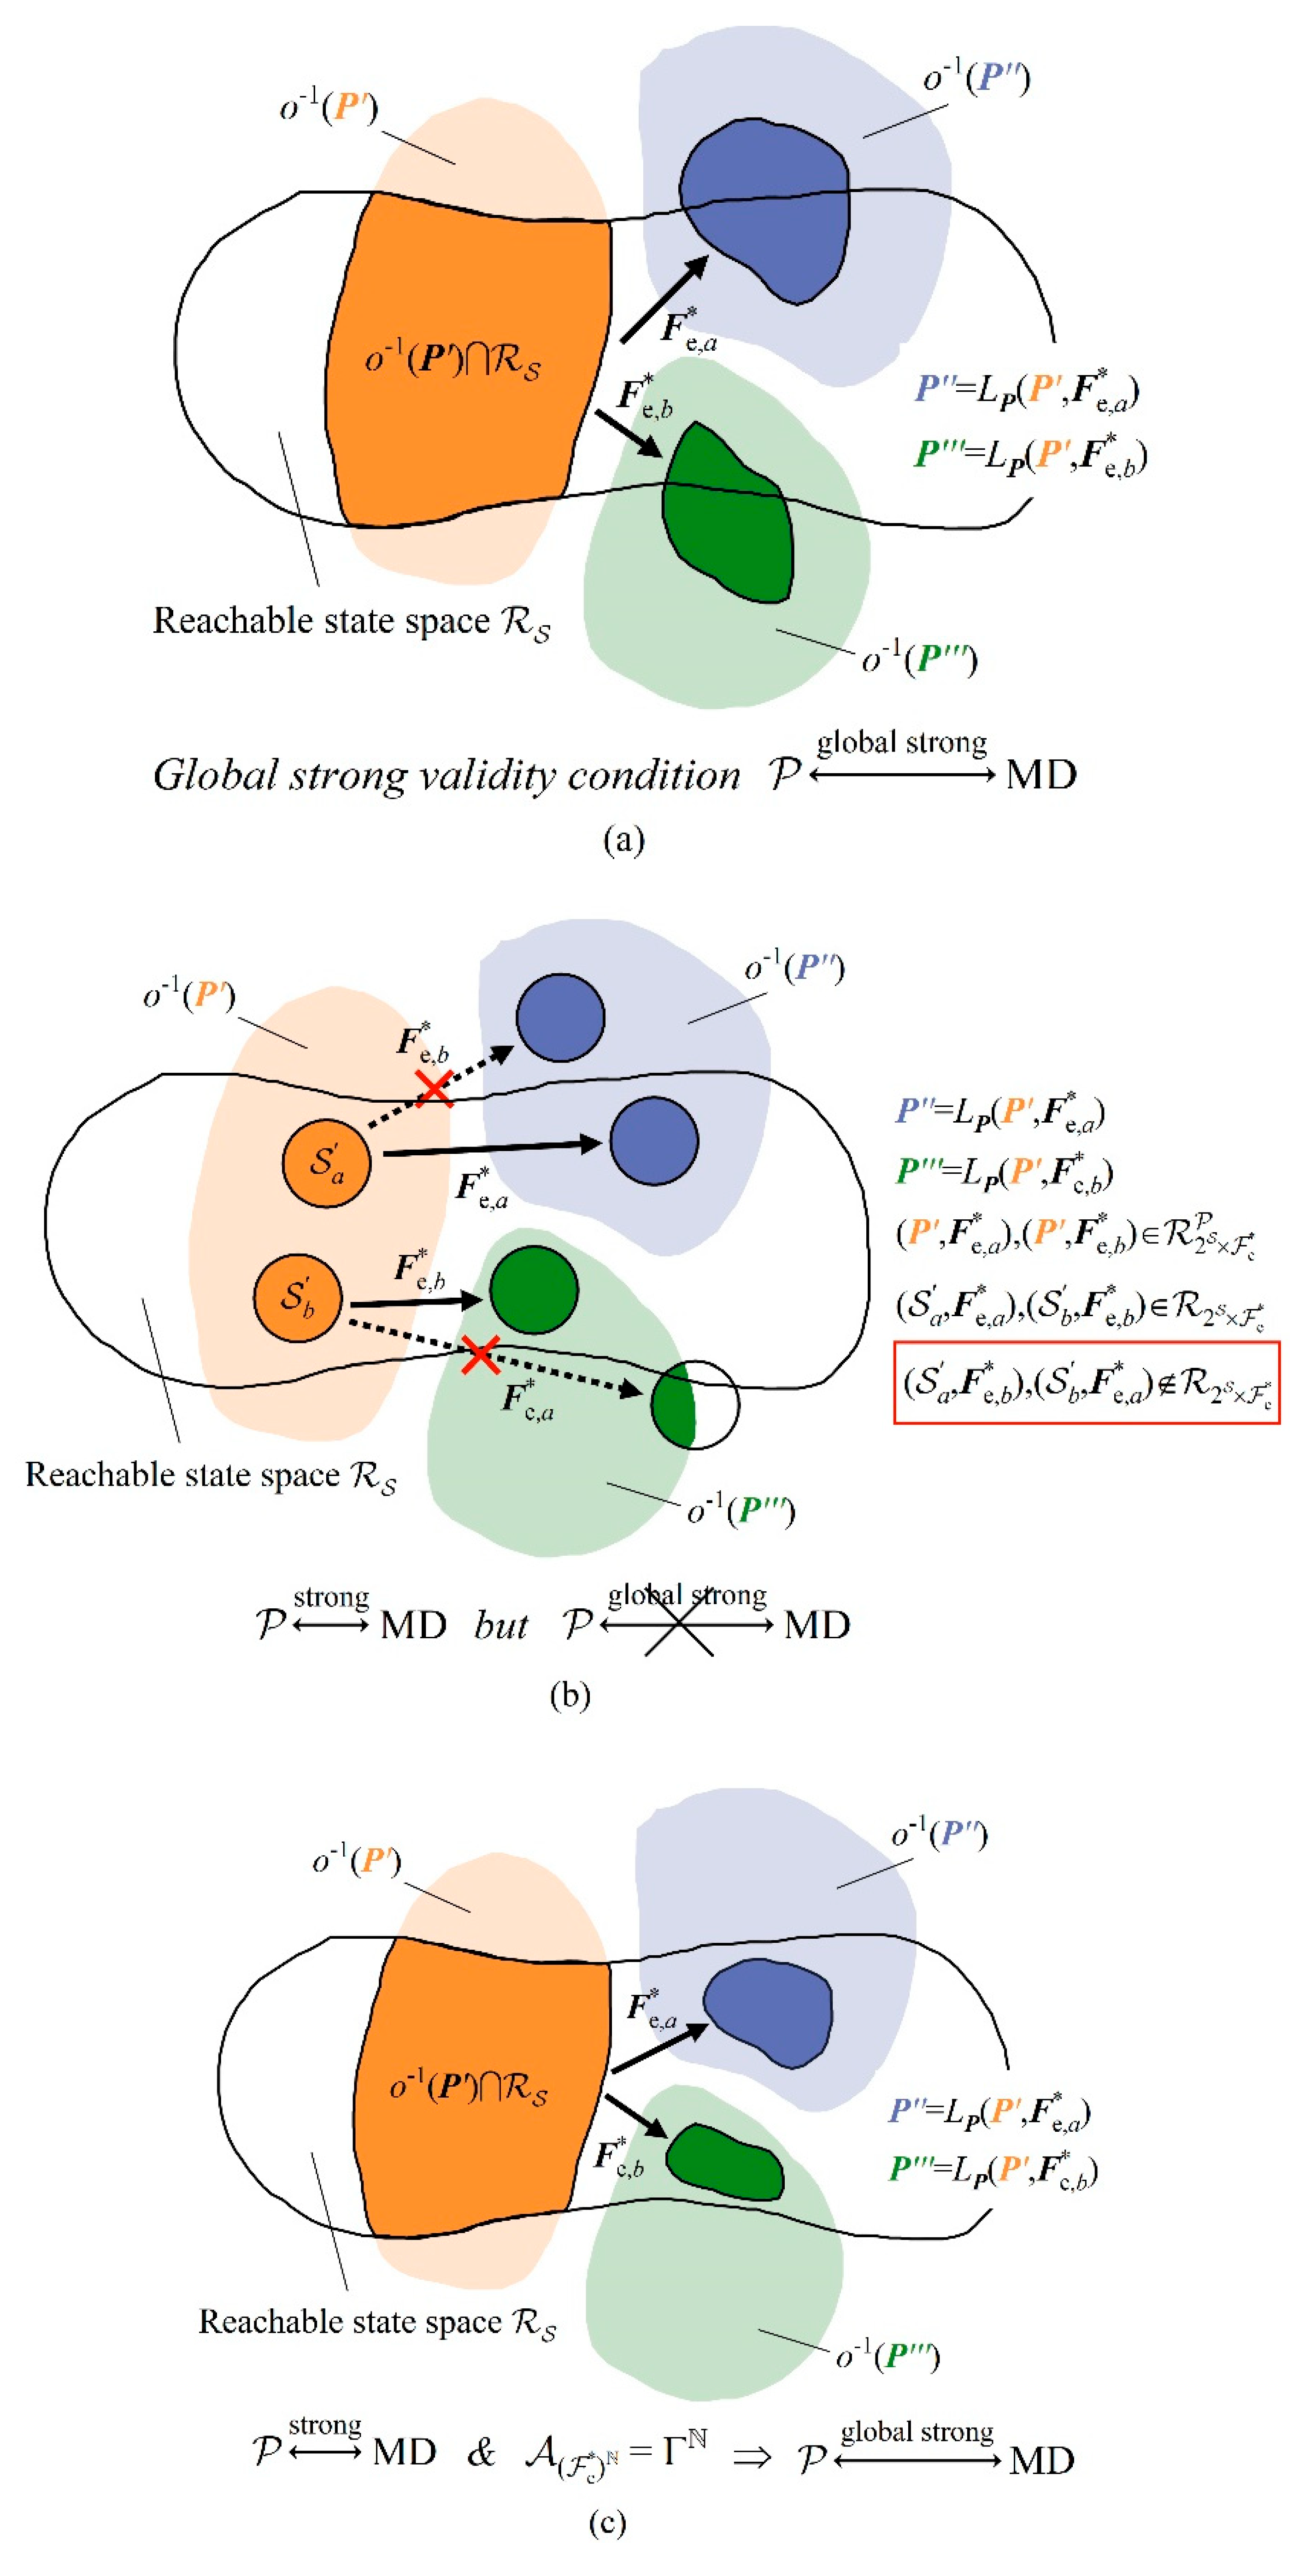
Figure 11.
The evolution of the target parameter is characterized by the dynamical equation of the state parameter and its projection onto the target parameter.
Figure 11.
The evolution of the target parameter is characterized by the dynamical equation of the state parameter and its projection onto the target parameter.
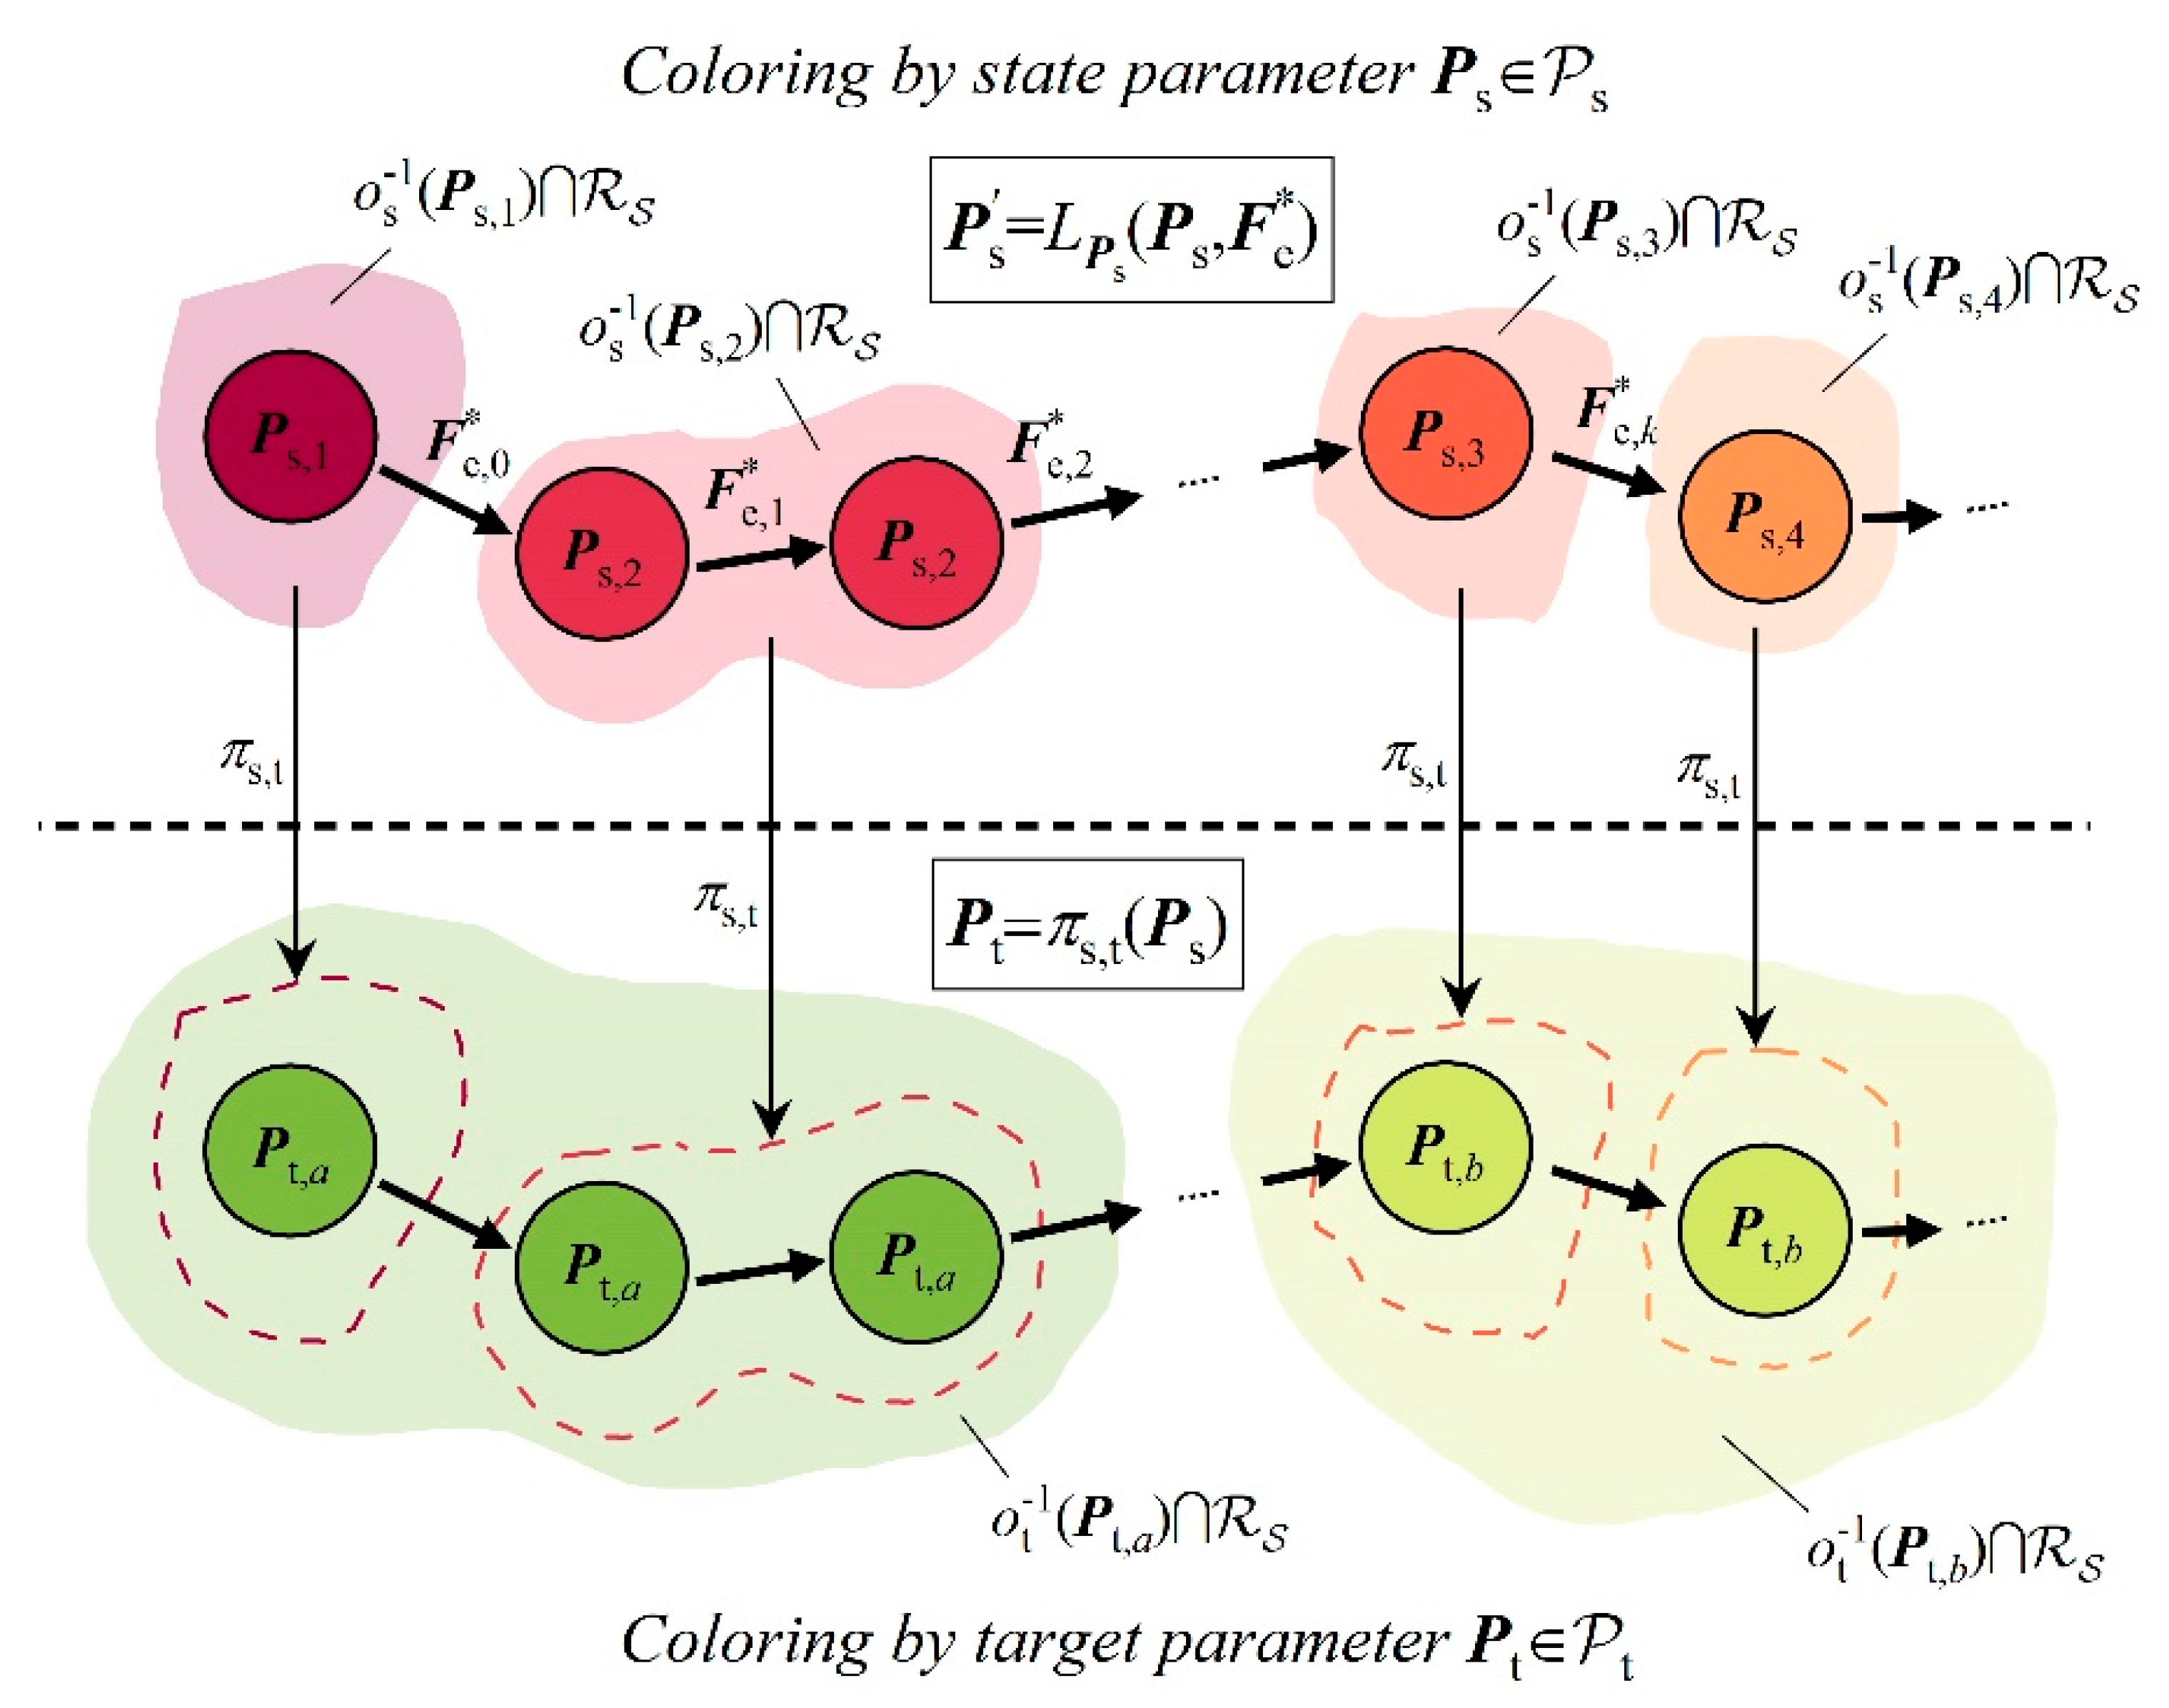
Figure 12.
Augmented circle-arrow chain, augmented dynamics unit, and augmented state within the modeling domain (MD), incorporating loading-history information.
Figure 12.
Augmented circle-arrow chain, augmented dynamics unit, and augmented state within the modeling domain (MD), incorporating loading-history information.
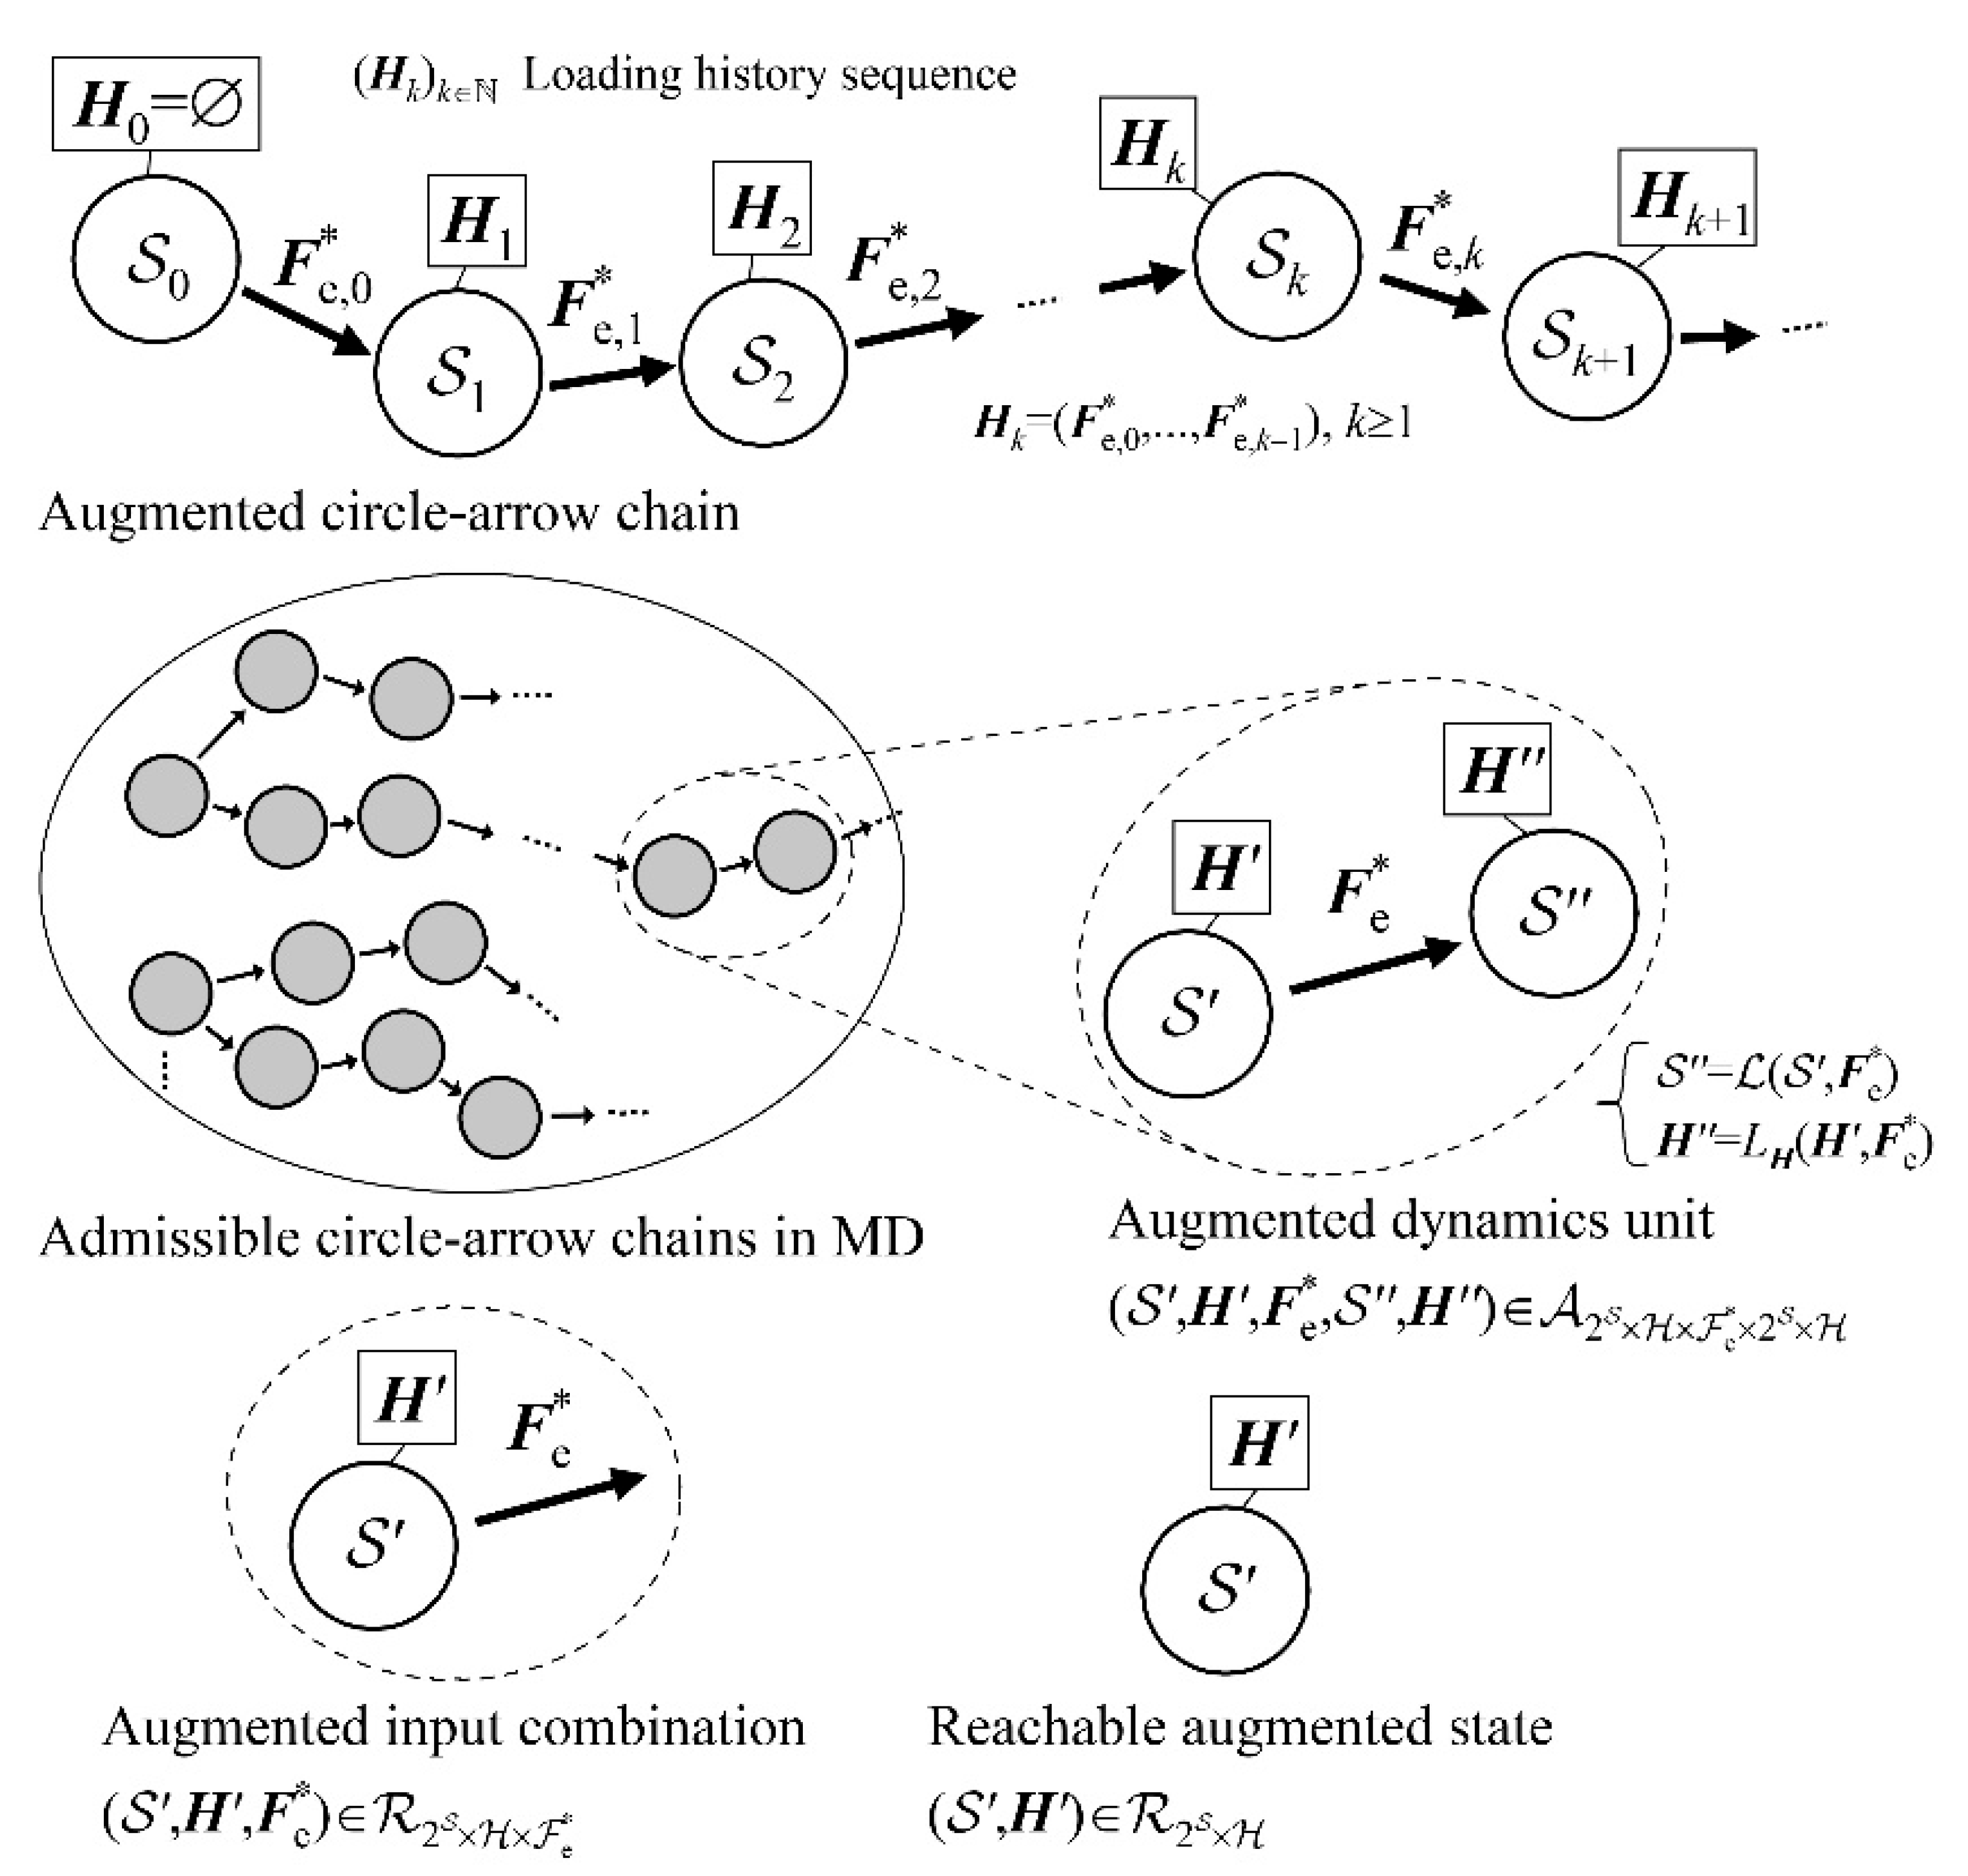
Figure 13.
Generalized parameter coloring transforms an augmented dynamics unit into a colored augmented dynamics unit.
Figure 13.
Generalized parameter coloring transforms an augmented dynamics unit into a colored augmented dynamics unit.
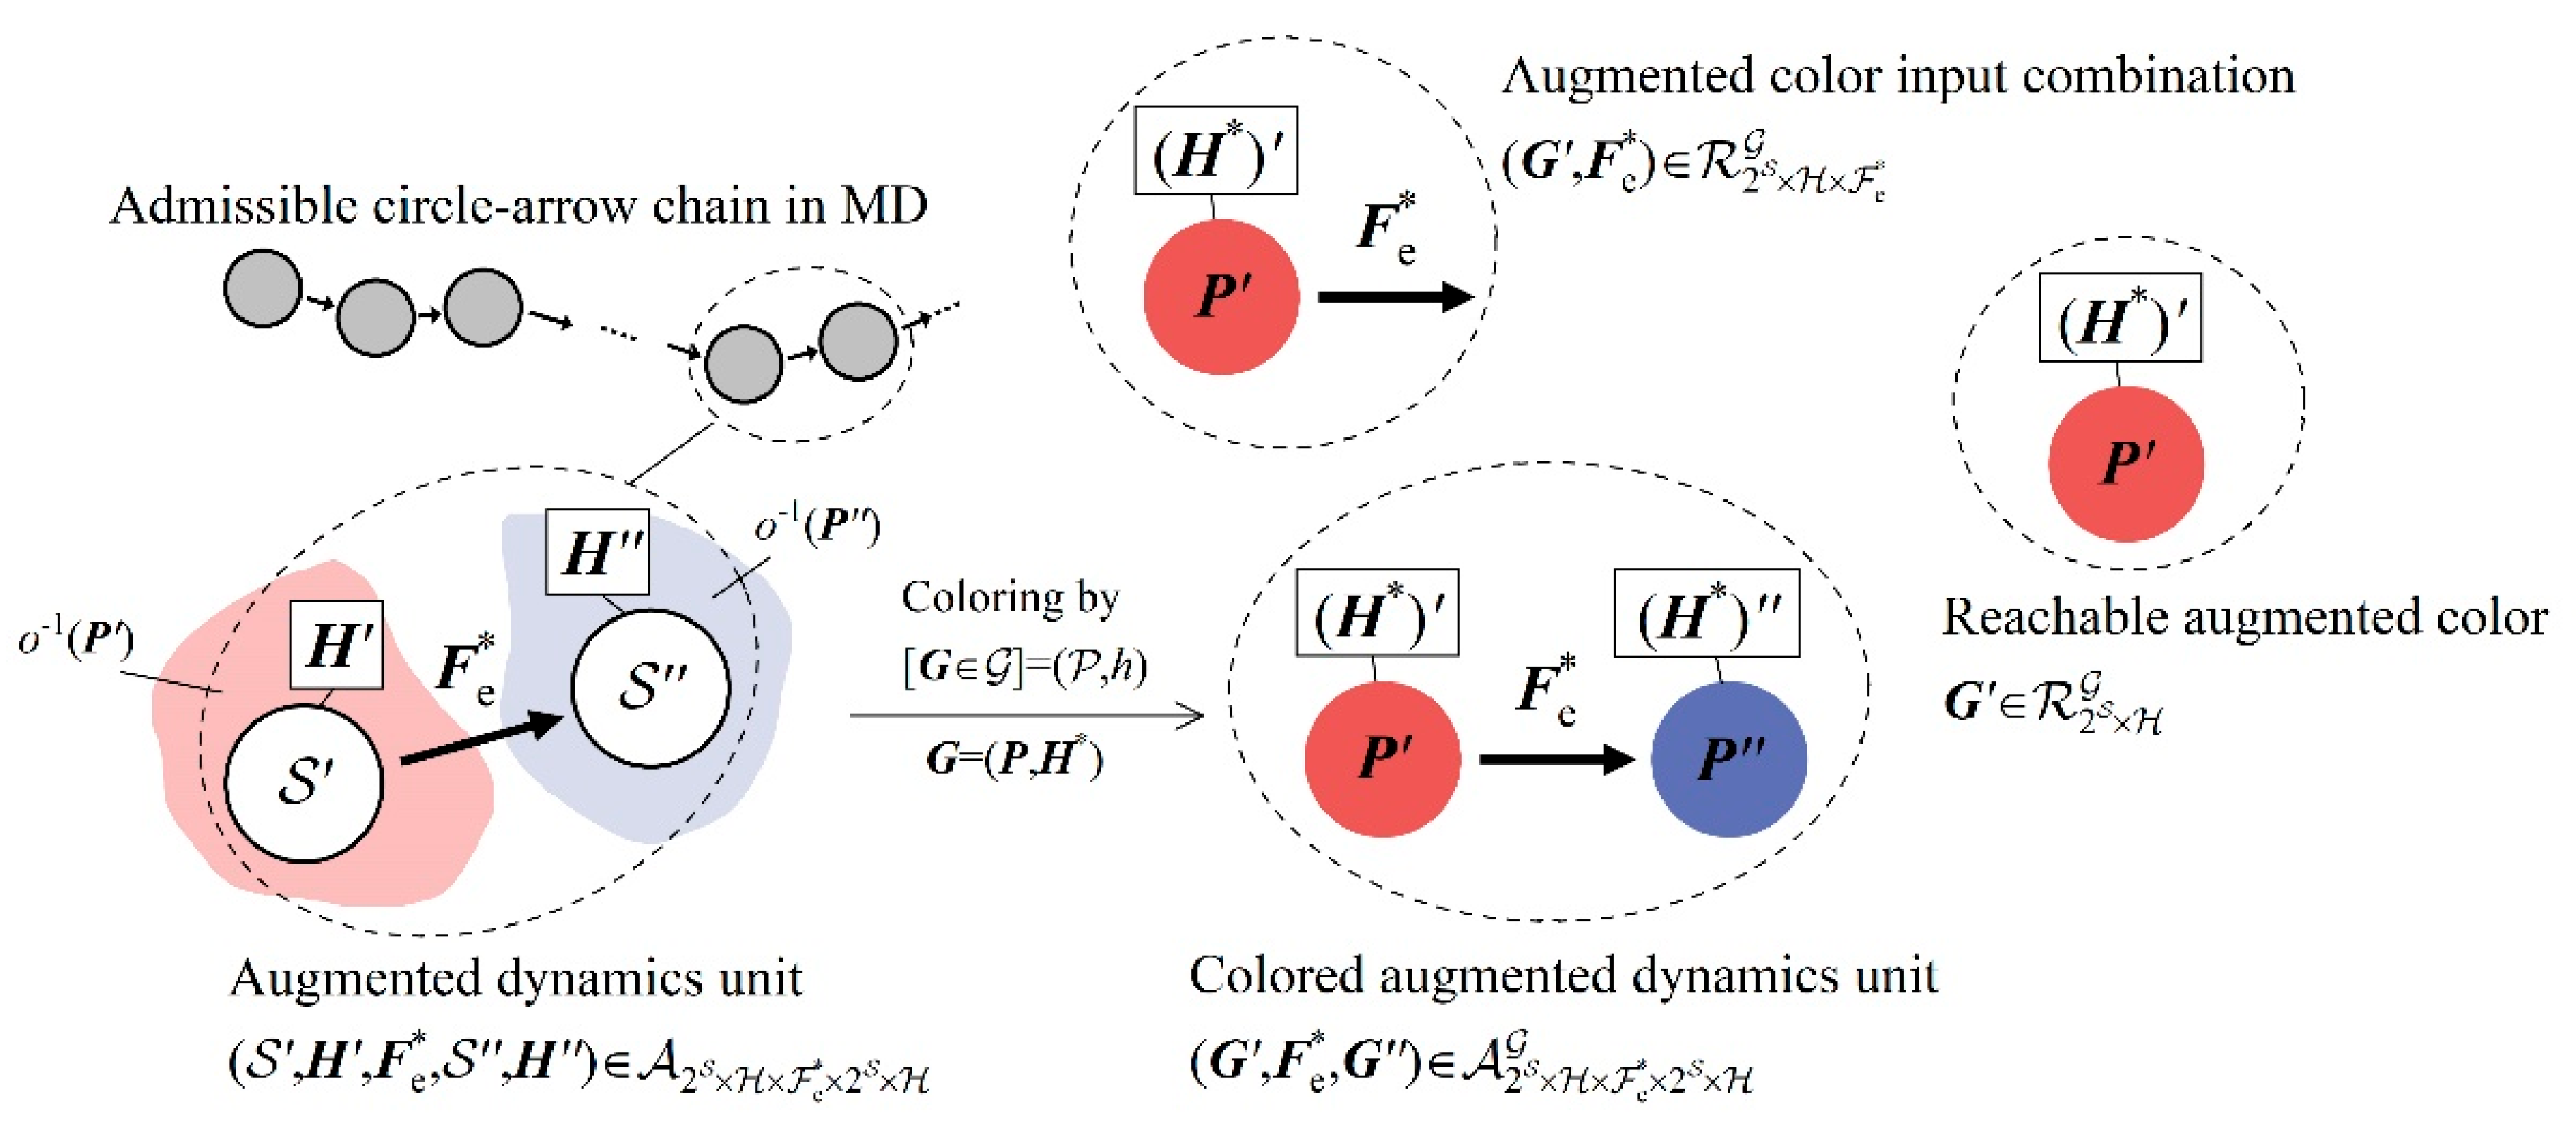
Figure 14.
(a) Direct application of a prescribed history compression operator requires storage of the complete loading history , leading to rapidly increasing memory requirements with the number of loading steps. (b) Recursive application of the one-step operator generates the compressed loading history without retaining the complete history .
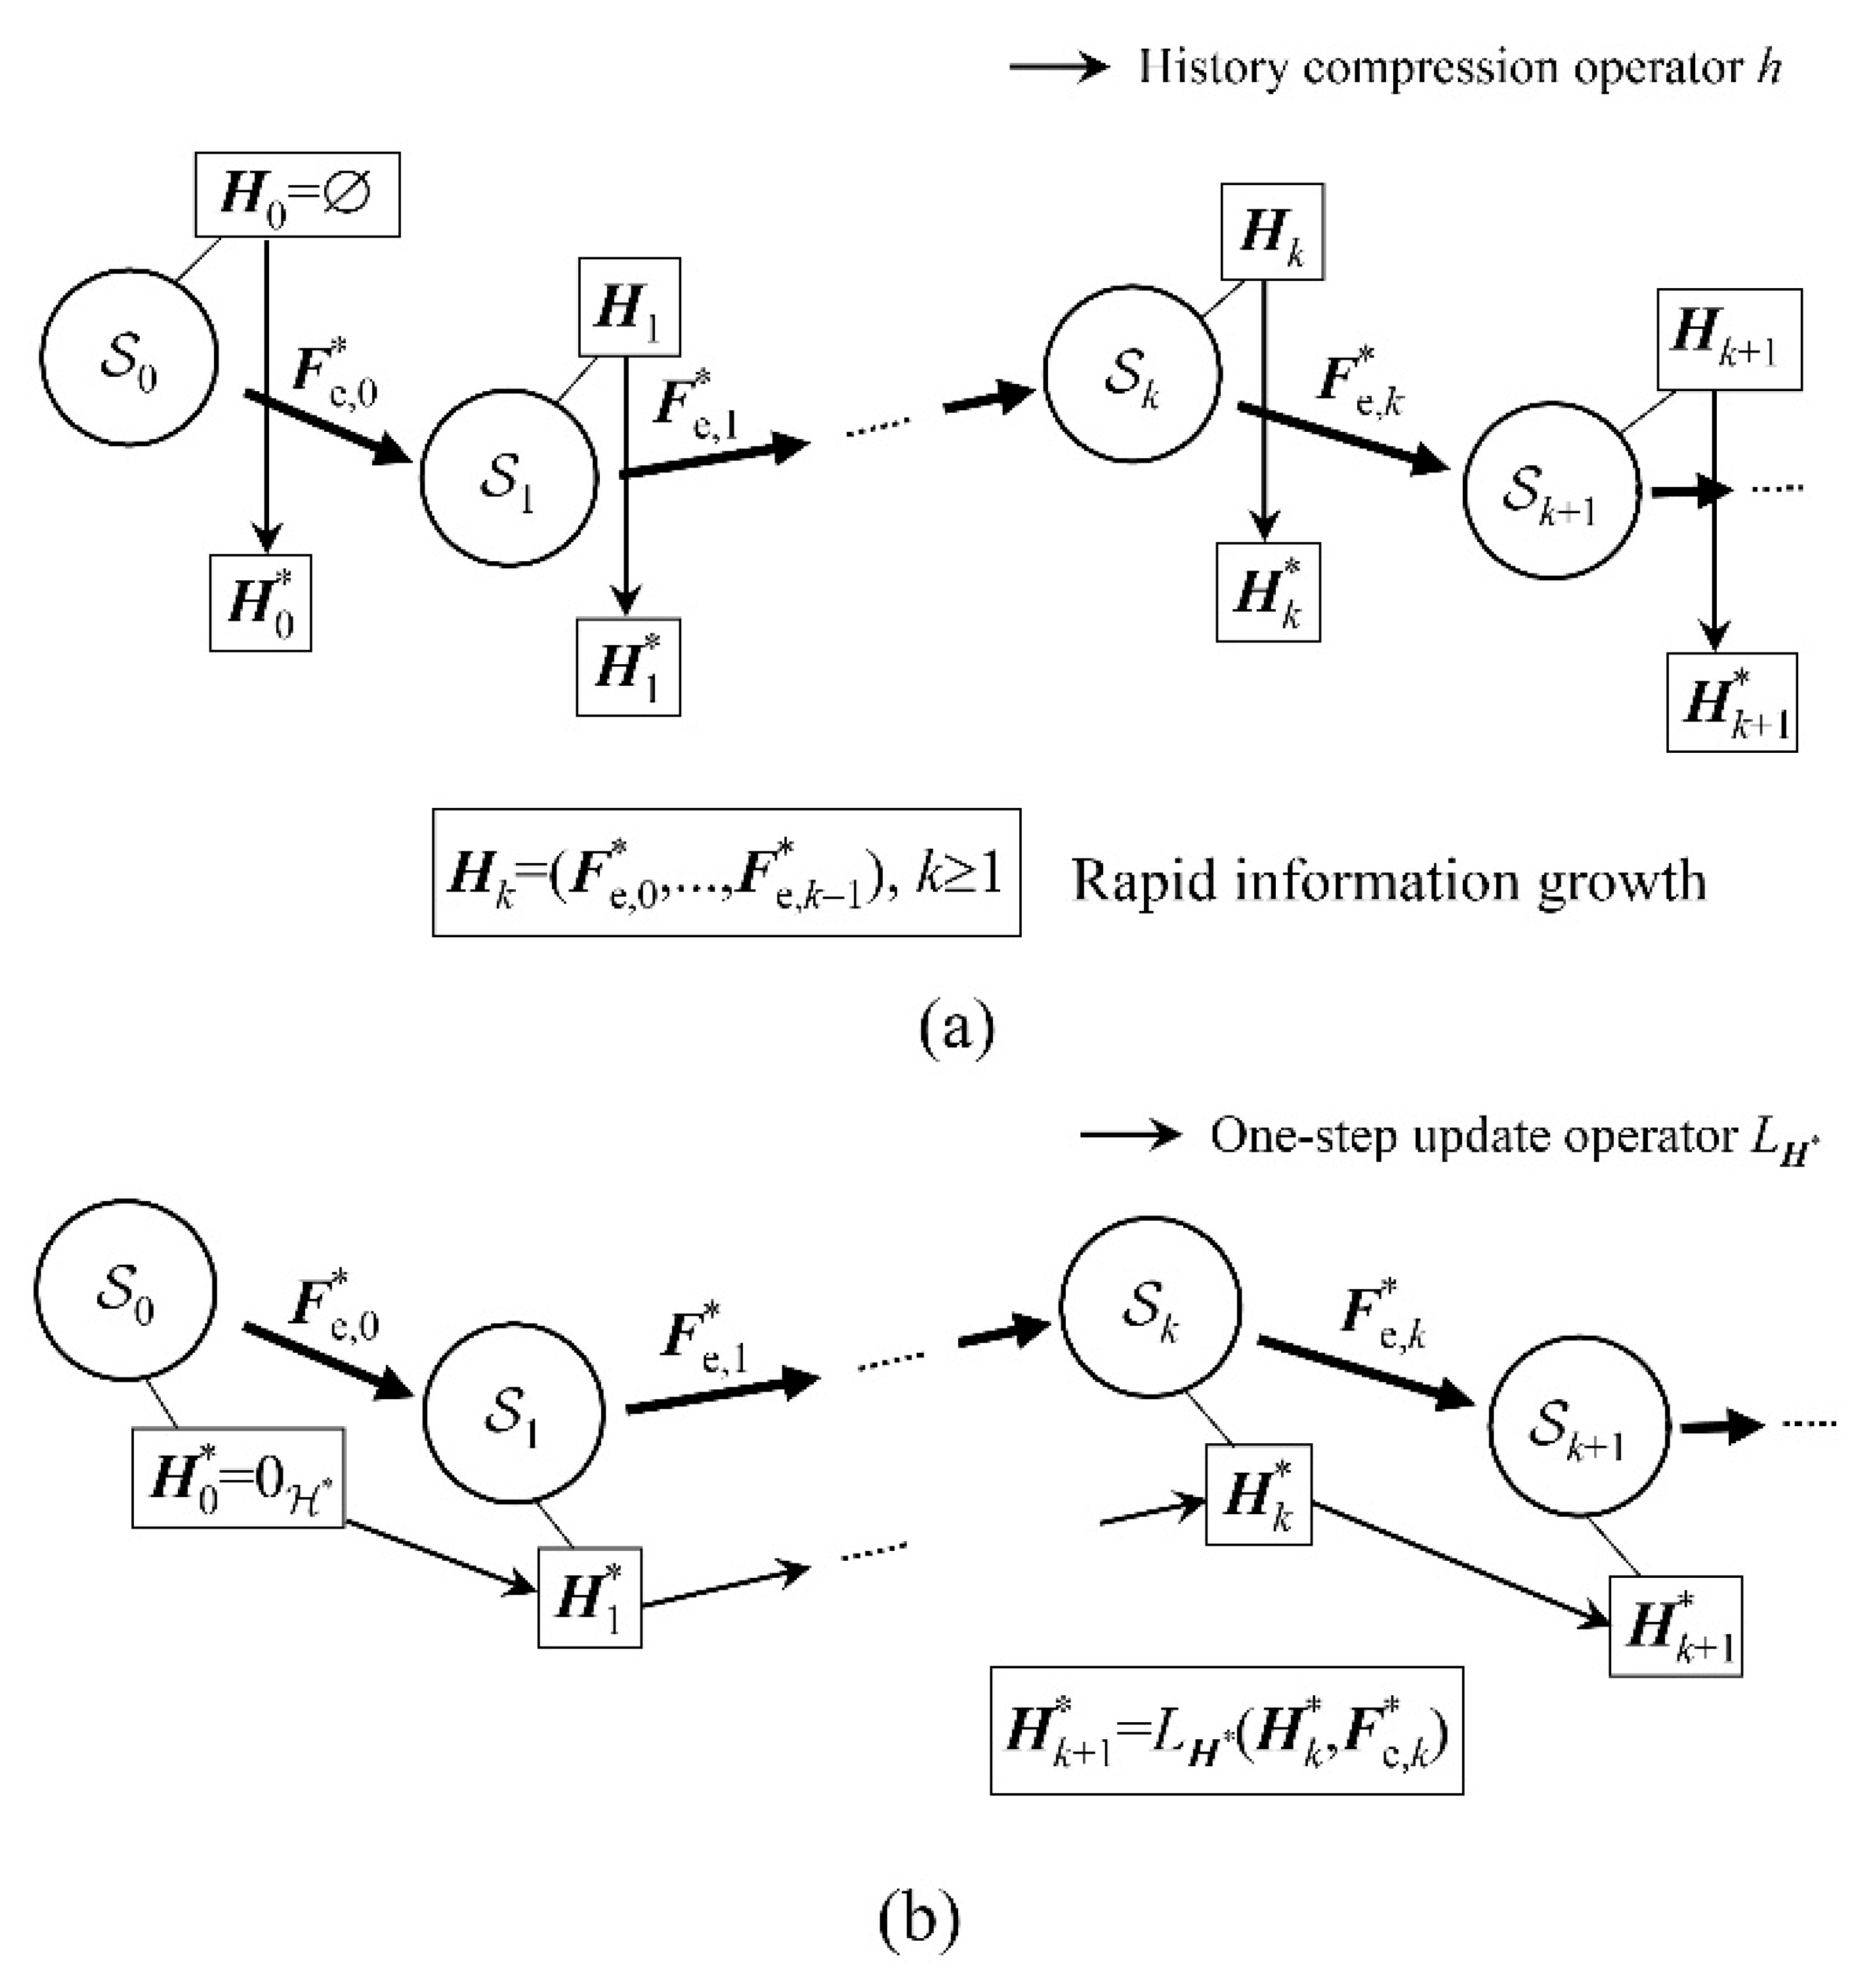
Figure 15.
Under the consistency condition between the difference representations of the state and parameter, the observation operator induces a well-defined group homomorphism from the state-increment space to the parameter-increment space.
Figure 15.
Under the consistency condition between the difference representations of the state and parameter, the observation operator induces a well-defined group homomorphism from the state-increment space to the parameter-increment space.
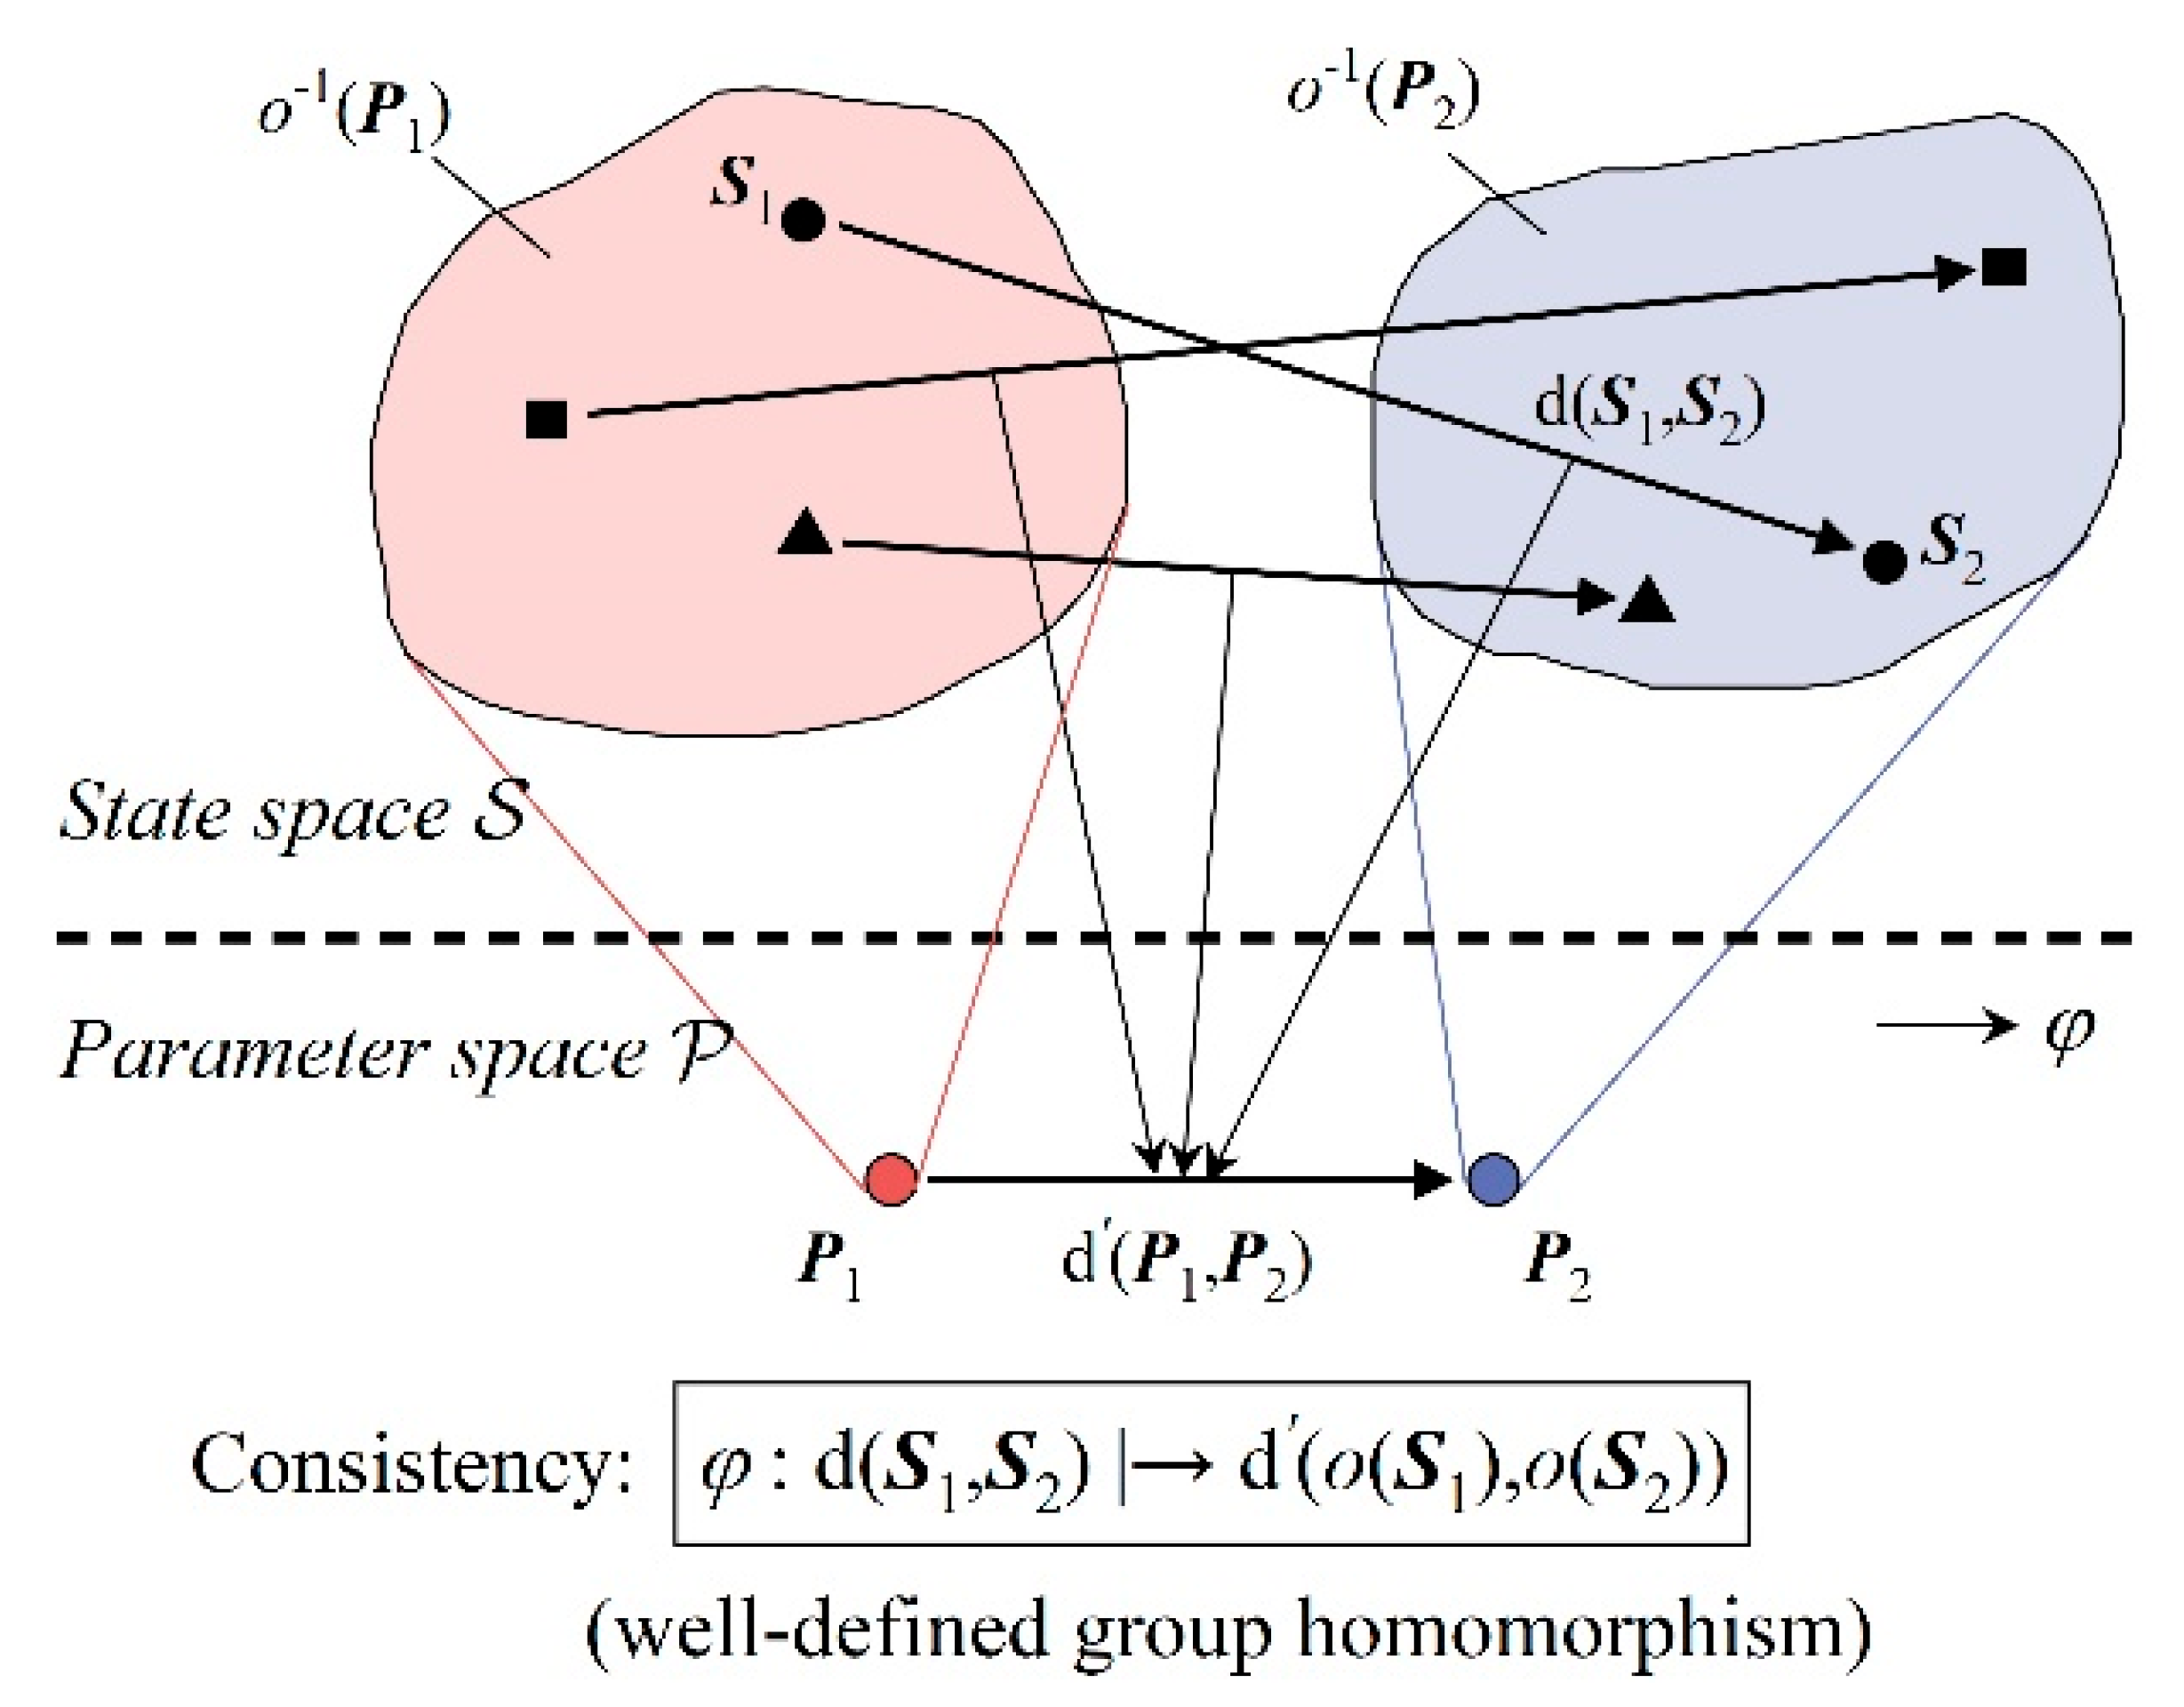
Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license (http://creativecommons.org/licenses/by/4.0/).
Copyright: This open access article is published under a Creative Commons CC BY 4.0 license, which permit the free download, distribution, and reuse, provided that the author and preprint are cited in any reuse.