
Submitted:
28 August 2026
Posted:
31 August 2026
You are already at the latest version
Abstract
Avalanche companion rescue provides the only realistic opportunity to locate and extricate a buried victim during the critical 10–15 min survival interval before organized rescue teams can normally arrive. Motivated by this stringent time constraint, this paper presents a physics-based waveformdomain framework for three-dimensional avalanche victim localization using a helmet-mounted Sparse Uniform Circular Array (SUCA) receiver and a compact cooperative RF beacon. Unlike conventional avalanche transceivers, which require sequential signal-search, coarse-search, and finesearch procedures, the proposed approach determines the victim’s three-dimensional coordinates directly by correlating the received waveform with a precomputed electromagnetic dictionary, enabling immediate guidance toward the estimated burial location. A comprehensive electromagnetic model incorporates realistic snow dielectric properties, propagation through snow and air, snow–air refraction, LOG-based deterministic multifrequency waveform generation, and dictionary-based localization. Numerical simulations demonstrate unique waveform representation throughout the investigated search region, complete recovery of all candidate victim locations under noiseless conditions, practical localization accuracy using a 0.5 m spatial grid, and a calculated 38 dB link margin under conservative very-wet-snow conditions. The proposed framework also supports several promising extensions beyond victim localization, including respiration monitoring, approximate body-orientation estimation, and enhanced victim detectability using passive conductive textile threads integrated into avalanche garments. Although demonstrated for avalanche companion rescue, the proposed waveform-domain localization framework represents a new operational concept for time-critical search-and-rescue and may be extended to a broad class of cooperative and non-cooperative RF sensing applications.
Keywords:
avalanche rescue
; three-dimensional localization
; sparse uniform circular array (SUCA)
; cooperative RF beacon
; waveform dictionary
; deterministic multifrequency dither
; snow dielectric modeling
; low-power RF sensing
; respiration monitoring
1. Introduction
Avalanche companion rescue is highly time-critical because victim survival decreases rapidly with burial duration, and uninjured companions may be the only rescuers available during the first minutes after burial [1,2]. Wallner et al. [2] reported that, even when the location of a simulated victim buried at a depth of 1 m was already known, approximately 7 min were required on average to free the airway, followed by an additional 3 min to initiate cardiopulmonary resuscitation. Consequently, reducing the time required for victim localization can provide additional time for excavation and medical access.
Current avalanche companion rescue relies primarily on 457 kHz avalanche transceivers. After burial, the surviving companion performs a sequence of signal search, coarse search, fine search, and pinpoint localization according to established rescue procedures [4,5]. Other technologies, including the RECCO system and ground-penetrating radar (GPR), have also been developed for buried-victim detection [6,7,8,9,10,11,12,13]. RECCO uses a 917 MHz transmitted signal and detects the 1834 MHz second harmonic reradiated by a passive nonlinear reflector [6,8], whereas GPR systems detect electromagnetic reflections from buried objects or human bodies [9,10,11,12,13]. These technologies provide important rescue capabilities but employ localization principles different from the waveform-domain method investigated here.
Recent search-and-rescue research has also examined complementary sensing and localization techniques. Denissova et al. developed a real-time avalanche-hazard monitoring system based on weather sensors and laser ranging [20]. He et al. proposed a single-drone search-and-rescue methodology using 5G-NR beam sweeping for victim localization [21], while Moro et al. demonstrated UAV-based user localization using an integrated sensing and communication system [22]. These approaches illustrate the increasing use of RF and remote-sensing technologies in search-and-rescue applications.
The present work addresses a different localization problem and employs a different physical mechanism. A cooperative RF beacon carried by the buried skier is localized using a Sparse Uniform Circular Array (SUCA) receiver carried by the surviving companion. Deterministic multifrequency dither is applied across the SUCA receiving channels, producing a composite waveform whose structure depends on the three-dimensional beacon location. The received waveform is then compared with a precomputed physical waveform dictionary to estimate the beacon position.
This waveform-domain localization principle was introduced in our prior work [3]. The present paper extends the formulation to the avalanche environment by incorporating electromagnetic propagation through snow, snow–air refraction, burial depth, attenuation, and rescue-specific operational constraints. The objective is to determine whether the three-dimensional beacon position can be estimated directly from the received waveform without requiring the conventional sequential coarse-to-fine localization procedure.
Figure 1.
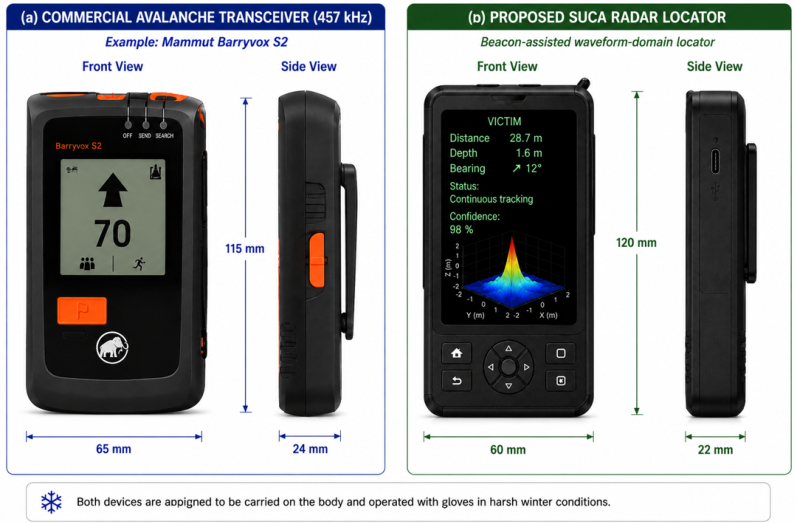
Comparison of companion rescue equipment: (a) commercial 457 kHz avalanche transceiver and (b) conceptual handheld beacon-assisted SUCA locator.
Figure 1.
Comparison of companion rescue equipment: (a) commercial 457 kHz avalanche transceiver and (b) conceptual handheld beacon-assisted SUCA locator.
The principal contributions of this work are:
- development of a beacon-assisted waveform-domain localization model for avalanche companion rescue;
- extension of the SUCA waveform-dictionary formulation to propagation through snow, including dielectric properties, attenuation, and snow–air refraction;
- numerical evaluation of three-dimensional victim localization, link-budget performance, and associated rescue-time implications.
The proposed 915 MHz system is intended as a complementary companion-rescue technology rather than an immediate replacement for standardized 457 kHz avalanche transceivers; the exact operating frequency and regulatory implementation will depend on the country of operation.
The remainder of this paper is organized as follows. Section 2 describes the proposed localization system, deployable SUCA antenna, propagation model, waveform generation, and dictionary construction. Section 3 presents the numerical results, including localization performance, power-budget analysis, and respiration-monitoring feasibility. Section 4 summarizes the conclusions and future work.
2. System Architecture
2.1. Operational Scenario
The left panel of Figure 2 illustrates the conventional avalanche transceiver search procedure. After reaching the last-seen point, the rescuer must perform a sequential signal search, followed by coarse search, fine search, and finally probe confirmation before excavation can begin. During the final search stage, the rescuer typically slows down considerably and often proceeds on foot while carefully following the transceiver indications. As the rescuer approaches the buried victim, movement becomes progressively slower in order to avoid overshooting the minimum-distance point before probing begins. Depending on the burial location, avalanche conditions, and rescuer experience, the complete localization procedure may require more than 10 min before excavation begins.
In contrast, the proposed rescue concept, illustrated in the right panel of Figure 2, the surviving skier immediately after the avalanche comes to rest just deploys the folded SUCA antenna in a manner similar to opening an umbrella, activates the search unit, which automatically disables his or her own beacon to eliminate self-interference, and is ready to move. With minimal training, the entire deployment procedure is expected to require not longer than one minute.
Since the beacon carried by the buried victim continuously transmits, the search unit automatically determines the victim’s three-dimensional location including its burial depth and displays these data on companion display. Then localization process is completed within a fraction of a second after activation.
Consequently, approximately 1–1.5 min after the avalanche comes to rest, the surviving companion begins skiing directly toward the estimated victim location while periodically correcting the travel direction according to the continuously updated data on display. The rescuer therefore remains focused on reaching the victim rather than performing the conventional signal-search, coarse-search, and fine-search procedures. For a victim located approximately 100 m from the rescuer, direct travel is expected to require from about 30 s under favorable conditions to several minutes over rough avalanche debris, depending on terrain, snow conditions, and skier ability. Consequently, in many practical situations excavation may begin within approximately 5–6 min after the avalanche stops. This time is expected to decrease further for shorter burial distances.
As the companion approaches the victim, the display is progressively updated with the victim’s body orientation and respiratory activity. This additional information helps minimize unnecessary excavation, accelerates access to the victim’s airway, and substantially increases the likelihood that the rescue operation can be completed within the critical 15-minute survival window, which often represents the difference between life and death for a avalanche victim.
The estimated 2–5 min rescue time in Figure 2 is an operational estimate resulting primarily from elimination of the conventional signal-search, coarse-search, and fine-search stages; after activation, the proposed system provides the companion directly with the estimated three-dimensional victim location.
2.2. Deployable SUCA Receiver Architecture
For the configuration considered in this work, the eleven SUCA elements are located on a circular ring of radius . This value specifies the electromagnetic radius of the element ring and not the overall radius of the deployable umbrella. To obtain a well-formed monopole radiation pattern directed primarily into the upper hemisphere, the metallized supporting ground screen should extend beyond the outer monopoles by approximately . Thus, the ground-screen radius is larger than by about half a wavelength. The exact final dimension will be established through electromagnetic and mechanical optimization of the prototype.
A. Deployable SUCA umbrella. The receiving aperture consists of eleven identical antenna elements uniformly distributed around a circular deployable umbrella structure. The lower metallized surface of the Kevlar sheet serves as a flexible substrate and common ground plane, while each antenna element is supported by a radial rib.
B. SUCA element. Each receiving element consists of a vertical monopole connected directly to a bandwidth-limiting filter, low-noise amplifier (LNA), and analog-to-digital converter (ADC). Placing the LNA and ADC directly at each antenna element minimizes analog transmission losses, preserves the receiver noise figure, and improves overall system sensitivity. The digitized output is transmitted to the central hub through the corresponding radial rib.
C. Radial rib. Each radial rib provides mechanical support for one antenna element and routes the required DC power and digital communication lines between the unit module and the central hub. For clarity, only the digital output connection is shown in Figure ??.
D. Central hub. The central hub receives the digital outputs from all eleven receiving modules, applies the deterministic multifrequency dither (DMD), combines the individual channels into a composite digital waveform, and transfers the resulting signal to the external controller for further processing.
E. External controller. The handheld controller performs the remaining receiver functions, including waveform processing, victim localization, body-orientation and respiration estimation, and presentation of the rescue information on the display. In future implementations, the displayed information could also be projected directly onto smart glasses, allowing completely hands-free operation.
F. Helmet-mounted configuration. During operation, the deployed SUCA receiver is mounted above the rescuer’s helmet, providing an unobstructed 360° field of view while leaving both hands free for avalanche rescue activities.
G. Deployment sequence. The umbrella mechanism enables rapid transition from a compact folded configuration to the fully deployed receiving aperture. With minimal training, deployment is expected to require approximately one minute, allowing the rescuer to begin victim localization almost immediately after the avalanche comes to rest.
A preliminary engineering estimate indicates that the folded SUCA receiver can be transported inside a standard avalanche backpack together with conventional rescue equipment. The final dimensions, weight, environmental sealing, and mechanical implementation will depend on the selected materials and level of electronic integration and will be optimized during future prototype development.
Once deployed, the SUCA receiver continuously updates the estimated victim position while the rescuer moves toward the burial location. Continuous localization enables immediate correction of the approach path and eliminates the sequential signal-search, coarse-search, and fine-search procedures required by conventional avalanche transceivers, thereby substantially reducing the time required to begin excavation.
The buried companion carries a cooperative active 1 mW CW beacon, while the SUCA operates as a receive-only antenna tuned to the beacon CW signal. No modulation or pulsed transmission is required.
2.3. Snow Dielectric Constant Modeling
Electromagnetic wave propagation through freshly deposited avalanche snow is governed by its complex relative permittivity, which determines both propagation velocity and signal attenuation. Since the proposed waveform-domain localization algorithm relies on accurate prediction of the relative propagation delays and amplitudes received by all SUCA elements, realistic modeling of the snow electromagnetic properties is essential.
In this work, the real part of the snow relative permittivity is calculated using the empirical model of Webb et al. [14], derived from in-situ measurements of snow density and volumetric liquid water content. The model is applicable in the low-frequency range approximately from 0.01 to 1.5 GHz, where the real part of snow permittivity varies only weakly with frequency [14]. For wet snow, Webb et al. obtained
where is the bulk snow density in , W is the volumetric liquid-water content expressed as a volume fraction, and is the relative permittivity of liquid water. Webb et al. use at C [14].
Equation (1) describes the effective permittivity of the air–ice–water mixture forming the snowpack. It should therefore not be compared directly with the relative permittivity of bulk solid ice, which is approximately 3.2 near 1 GHz. Because snow contains a substantial volume fraction of air, its effective permittivity can be considerably lower than that of solid ice. Increasing liquid-water content increases the effective snow permittivity, as represented by the second term of (1).
The imaginary part is modeled using the frequency-dependent dielectric loss of wet snow, including the contribution of liquid water and the small effective loss of the dry-snow component, following the experimental snow-dielectric literature [16]. Consequently, the complex relative permittivity is represented as
where denotes the snow density and W is the volumetric liquid water content.
Four representative avalanche snow conditions are considered throughout this work:
| Condition | W (vol./vol.) |
| Dry | 0.00 |
| Slightly wet | 0.01 |
| Wet | 0.03 |
| Very wet | 0.07 |
For all simulations, the snow density is assumed to be . Figure 3 shows the resulting frequency dependence of the real and imaginary parts of the complex relative permittivity for the four snow conditions considered in this study.
In practical avalanche rescue operations, the dielectric properties of freshly deposited avalanche snow are generally unknown and may vary with snow density, liquid water content, and local avalanche conditions. To account for this uncertainty, the proposed rescue system incorporates a compact snow dielectric sensor that measures the effective electromagnetic properties of the surrounding snow immediately before victim localization. Commercial devices such as the WISe (Water in Snow) dielectric sensor developed by A2 Photonic Sensors [15] provide this capability.
The measured dielectric constant is automatically used to select the corresponding electromagnetic propagation model and the appropriate waveform dictionary before beacon localization. Consequently, the localization algorithm operates with propagation parameters matched to the measured snow conditions rather than relying only on assumed dielectric properties.
Although avalanche debris may contain local variations in snow density, moisture, ice layers, and air voids, freshly deposited avalanche snow is produced by intensive mechanical mixing during avalanche flow. Therefore, a local dielectric measurement performed immediately before localization is expected to provide an estimate of the effective electromagnetic propagation medium within the immediate search region.
Future work will investigate adaptive propagation models capable of accounting for layered snow structures, localized ice lenses, air voids, and other dielectric inhomogeneities encountered under practical avalanche conditions.
2.4. Snow Propagation and Refraction
The proposed avalanche localization system operates in the 915 MHz Industrial, Scientific, and Medical (ISM) band, which is available for license-free operation under FCC Part 15 regulations [17]. The selected frequency represents a practical compromise between electromagnetic penetration into avalanche snow, antenna dimensions, available bandwidth, and localization accuracy. The availability of the 915 MHz ISM band has led to its widespread use in commercial short-range wireless applications. Furthermore, this frequency is close to the operating frequency of the commercial RECCO avalanche rescue system [7], demonstrating the practical suitability of the 900 MHz frequency range for electromagnetic propagation through avalanche snow.
Unlike conventional avalanche transceivers operating at 457 kHz, operation at 915 MHz enables a compact Sparse Uniform Circular Array (SUCA) while providing sufficient bandwidth for waveform-domain localization. More importantly, the much shorter wavelength at 915 MHz produces measurable inter-element phase differences across the compact SUCA aperture, which constitute the physical basis of the proposed localization method. At the conventional avalanche beacon frequency of 457 kHz, the free-space wavelength is approximately 656 m, making such phase-based localization impractical for a portable receiving array.
At 915 MHz, electromagnetic propagation is strongly affected by the dielectric properties of snow. The electrical wavelength inside snow is considerably shorter than in free space, and the dielectric contrast between snow and air produces noticeable refraction at the snow–air interface. As a result, the propagation path is no longer a straight line, and both the propagation delay and accumulated phase depend on the refracted trajectory. Accurate modeling of this effect is therefore essential for reliable waveform prediction and beacon localization. Ignoring snow–air refraction would introduce systematic errors in the predicted propagation delays and phases received by the SUCA elements, thereby degrading waveform prediction and localization accuracy.
The propagation model explicitly accounts for refraction by applying Fermat’s principle to every propagation path between the buried beacon and each SUCA receiving element. The electromagnetic wave is assumed to travel through two homogeneous media: avalanche snow and air. The unknown refraction point located on the snow–air interface is determined numerically by minimizing the optical path length,
where
denotes the refractive index of the corresponding medium, is the propagation distance inside snow, and is the propagation distance in air.
The optimization is performed independently for every receiving element and automatically satisfies the three-dimensional Snell refraction condition. Consequently, the physically correct propagation path is obtained for arbitrary beacon positions and arbitrary SUCA geometries.
Besides changing the propagation direction, refraction also modifies the electrical path length and therefore the accumulated propagation phase. Moreover, attenuation inside snow depends on the complex dielectric constant, introducing additional amplitude loss that increases with burial depth and snow moisture content. Both effects are incorporated into the signal model and subsequently into every waveform contained in the localization dictionary.
The resulting optical path lengths are subsequently used during waveform synthesis and dictionary generation. Consequently, every dictionary entry incorporates the combined effects of dielectric propagation, snow–air refraction, geometric spreading, and geometry-dependent phase delay. The resulting dictionary therefore represents the actual electromagnetic propagation conditions expected during avalanche rescue operations rather than an idealized free-space environment.
Figure 4 illustrates the three-dimensional propagation geometry between the buried avalanche beacon and the helmet-mounted SUCA unit. The figure shows the beacon located beneath the snow surface, the refracted propagation path, the corresponding refraction point, and the helmet-mounted receiving array positioned above the snow.
2.5. Waveform Generation
For every candidate beacon position, the received waveform is synthesized by coherently combining the responses of all SUCA receiving elements. Unlike conventional array processing, the signal received by each element is computed using the refracted propagation path obtained from the previous subsection. Accordingly, the propagation path to the m-th receiving element consists of a snow segment of length and an air segment of length . These two path segments jointly determine both the amplitude attenuation and the propagation phase of the received signal.
The physically received signals are first transformed using the previously proposed complex-logarithm (LOG) phase transformation described in [3]. This mathematical operation replaces the common propagation wavenumber of the received beacon signal by the assigned effective wavenumber of each SUCA receiving channel while preserving the physically modeled propagation amplitude. Consequently, the passive receiving SUCA becomes mathematically equivalent to its transmitting counterpart employing deterministic multifrequency dither (DMD), thereby enabling waveform-domain localization.
Each SUCA receiving element is assigned a deterministic multifrequency dither
where denotes the avalanche beacon carrier frequency and is the deterministic frequency offset assigned to the m-th receiving channel.
The corresponding complex propagation factor is expressed as
where is the free-space wavenumber and is the complex dielectric constant of snow. The exponential term represents the accumulated propagation phase, including the reduced propagation velocity and attenuation inside snow, while the inverse-distance term approximates geometric spreading. Consequently, both the amplitude and phase of every receiving channel are determined by the actual refracted propagation path.
The complex signal received by the m-th SUCA element is therefore
where the deterministic multifrequency dither causes each receiving element to contribute a distinct frequency component to the composite waveform.
To suppress common propagation effects and improve robustness against overall amplitude variations, every receiving channel is normalized with respect to the central SUCA element,
where denotes the signal received by the central SUCA element and is a small regularization constant introduced to prevent numerical instability.
The normalized composite waveform is obtained by coherently summing the responses of all SUCA receiving elements,
where M is the total number of receiving elements. Since every propagation factor depends on the refracted snow and air path lengths while each receiving channel is assigned its own deterministic multifrequency dither, the resulting composite waveform becomes a unique function of the three-dimensional beacon coordinates. Rather than estimating propagation delays individually, the proposed approach performs localization by matching the complete waveform against a precomputed dictionary of predicted waveforms.
To illustrate this principle, Figure 5 presents representative normalized composite waveform envelopes corresponding to three different beacon locations. The legend identifies the Cartesian beacon coordinates in meters according to the geometry shown in Figure 4.
As illustrated in Figure 5, deterministic multifrequency dither transforms the set of propagation delays and amplitudes received by the SUCA elements into a unique composite temporal waveform. Even small changes in beacon position modify the refracted propagation paths to all receiving elements, thereby changing both the relative amplitudes and phases of the individual channels. Consequently, the composite waveform evolves deterministically with beacon position, providing a unique waveform-domain signature for every three-dimensional location. This one-to-one correspondence between beacon position and composite waveform forms the physical foundation of the dictionary-based localization procedure described in the following subsection.
2.6. Dictionary-Based Localization
The localization algorithm is based on a dictionary of normalized composite waveforms corresponding to candidate beacon positions within the search volume. A three-dimensional Cartesian grid is constructed around the expected beacon location. Each grid node is represented by the coordinate vector
where denotes the total number of dictionary nodes. The physical waveform dictionary is generated offline and stored in memory before deployment. For the search region considered in this study, the complete dictionary occupies approximately , making storage straightforward for existing embedded hardware. The localization operation consists primarily of correlation of the received waveform with the precomputed dictionary and is naturally parallel; larger search regions increase the computational load approximately in proportion to the number of dictionary entries.
For every candidate position , the propagation paths from the beacon to all SUCA receiving elements are calculated using the snow propagation and refraction model described in the previous subsection. The resulting normalized composite waveform is then generated according to (8) and stored as the ℓ-th dictionary waveform
The complete waveform dictionary is therefore written as
where each column represents the waveform-domain signature associated with one candidate beacon location.
The received normalized waveform is modeled as
where is an unknown complex amplitude factor and is additive white complex Gaussian noise. The correlation in Eq. (12) compares the received composite waveform with the physical waveform associated with each predefined dictionary coordinate; the dictionary therefore forms a bank of location-dependent waveform references. Under the assumption of AWGN and equal prior probabilities for all dictionary nodes, beacon localization is performed by evaluating the normalized complex correlation between the received waveform and every waveform stored in the dictionary,
where denotes the Hermitian transpose.
The beacon position is estimated by selecting the dictionary node producing the maximum correlation,
and the corresponding three-dimensional beacon coordinates are obtained as
The correlation values obtained for all dictionary nodes form a three-dimensional correlation map whose global maximum directly indicates the estimated beacon location.
Figure 6 presents the maximum dictionary correlation projected onto the plane for an off-grid beacon location. Although the true beacon position does not coincide with a dictionary node, the correlation map exhibits a single dominant cluster centered near the true beacon location. No competing local maxima of comparable magnitude are observed, demonstrating that the measured waveform is associated with a unique region of the search space.
The localization algorithm first identifies the dominant correlation cluster and subsequently estimates the beacon coordinates by interpolating the correlation values within that cluster. Consequently, the final beacon estimate is not restricted to the discrete dictionary grid but achieves sub-grid localization accuracy. This behavior demonstrates that the proposed waveform-domain representation remains well conditioned for practical avalanche rescue, where buried victims are generally located at arbitrary positions within the search region.
2.7. Potential Victim Detectability and Body-Orientation Mode
The beacon-assisted localization framework described in the previous sections can be naturally extended by incorporating conductive threads into avalanche garments. The conductive threads are woven into selected regions of the fabric and remain completely passive, requiring neither a power source nor any electrical connection to the cooperative beacon. Their primary purpose is not to make the buried victim “glow” in the conventional sense, but to increase the effective radar cross section (RCS) and produce a stronger and more distinctive scattering signature at the operating frequency.
The enhanced scattering provides two important potential benefits. First, the increased effective RCS improves victim detectability, particularly for greater burial depths or lower signal-to-noise ratios. Second, the distributed conductive-thread pattern introduces additional spatial scattering features that may support estimation of the victim’s approximate body orientation after beacon localization.
Because the conductive threads are integrated directly into the garment, they preserve the flexibility, comfort, and normal functionality of the clothing while introducing no active electronic components. The selection of conductive materials, thread geometry, weaving pattern, environmental durability, and compatibility with existing avalanche safety equipment remain subjects for future engineering development.
After the buried beacon has been accurately localized, the SUCA receiver may switch from beacon-localization mode to a body-orientation mode. In this operating mode, the beacon position is already known and the remaining objective is not to reconstruct the complete body shape but to estimate the approximate orientation of the buried victim relative to the localized beacon.
This functionality can be implemented using a reduced waveform dictionary containing a limited number of representative body configurations rather than anatomically exact human models. Typical configurations include head-uphill, head-downhill, prone, supine, and left- or right-side orientations. For each configuration, the expected waveform perturbation relative to the localized beacon response is precomputed and stored in the orientation dictionary.
The measured waveform is subsequently compared with this reduced dictionary, and the best-matching entry provides an estimate of the victim’s body orientation. Such information may help rescuers select a more appropriate excavation direction, minimize unnecessary snow removal, reach the victim’s airway more rapidly, and further reduce the overall rescue time.
Thus, the proposed waveform-domain localization framework can first perform rapid three-dimensional beacon localization and subsequently estimate the victim’s approximate body orientation. This extension preserves the basic localization architecture while requiring only a compact orientation dictionary rather than a detailed patient-specific electromagnetic body model.
2.8. Rescue Time Budget
The probability of survival following complete avalanche burial decreases rapidly with increasing burial time, making rapid victim recovery the primary objective of every avalanche rescue operation. Figure 7 illustrates representative survival curves reported for Canadian and Swiss avalanche accidents together with the commonly accepted rescue phases [18,19].
The survival curves clearly demonstrate that every minute gained during the initial rescue effort increases the probability of a successful outcome. Consequently, reducing the time required to locate and reach the buried victim is one of the principal objectives of avalanche rescue technology.
The total rescue time can be divided into three principal phases: (1) locating and reaching the victim, (2) excavation and airway access, and (3) post-extrication medical care. Among these phases, only the first can be substantially improved by advances in localization technology. The excavation and medical phases depend primarily on burial depth, snow conditions, avalanche terrain, and the number and experience of rescuers, and therefore remain largely independent of the localization method.
Wallner et al. [2] reported that “...it takes an average of 7 minutes after location of a simulated avalanche victim, buried at a depth of 1 m, to free the airway, plus a further 3 minutes to initiate CPR in the standard supine position. This is more than two-thirds of the 15 minutes considered necessary for successful companion avalanche rescue.”
These observations indicate that victim localization should ideally be completed within approximately the first 5 min after burial, leaving sufficient time for excavation, airway access, and initiation of life-saving medical procedures.
As described in the Operational Scenario and illustrated in Figure 2, the proposed SUCA-based localization framework is expected to require approximately one minute for deployment, followed by nearly instantaneous beacon localization and direct travel toward the continuously updated victim position. Under representative conditions, excavation is therefore expected to begin within approximately 5–6 min after the avalanche comes to rest, compared with the 10–20 min typically required for conventional avalanche transceivers that rely on sequential signal-search, coarse-search, and fine-search procedures.
Consequently, the principal benefit of the proposed localization framework is not merely improved positioning accuracy but the recovery of several additional minutes for excavation, airway access, and life-saving medical intervention within the critical 15-minute survival window. Even a few minutes gained during the localization phase may represent the difference between life and death for a completely buried avalanche victim.
3. Simulation Results and Performance Evaluation
The proposed waveform-domain localization algorithm was evaluated using physics-based numerical simulations incorporating electromagnetic propagation through snow, refraction at the snow–air interface, deterministic multifrequency SUCA processing, and dictionary-based waveform matching. The simulations investigate localization performance for representative avalanche rescue scenarios, including off-grid beacon locations representative of practical avalanche burials.
3.1. Power Budget and Receiver Sensitivity
Power-budget analysis is an essential part of the proposed avalanche localization system because it establishes whether the signal transmitted by a buried beacon remains sufficiently strong after propagation through snow to be reliably detected by the SUCA receiver. The objective of this analysis is to determine the received signal power, compare it with the receiver sensitivity, and evaluate the available link margin under representative avalanche conditions.
The power-budget analysis follows the complete signal-processing chain developed in the previous sections. Starting from the beacon transmitted power, the electromagnetic propagation model predicts the received electric field at every SUCA element after propagation through snow and air. The received signals are subsequently processed using the previously described LOG-based deterministic multifrequency processing, producing the complete denormalized received waveform in physical units (V/m). From this waveform, the received signal power, receiver sensitivity, and available link margin are evaluated.
The time-averaged incident power density is calculated as
where is the free-space wave impedance and denotes averaging over one dither period.
The received power is then obtained from
where is the effective receiving aperture of the SUCA. The effective aperture is modeled as
where is the SUCA radius. A conservative aperture-efficiency factor of is adopted to account for the sparse receiving aperture together with practical implementation losses not included in the electromagnetic propagation model.
The receiver thermal noise power is calculated as
where k is Boltzmann’s constant, K is the reference receiver temperature, B is the receiver bandwidth, and F is the receiver noise factor. Throughout this work, a receiver bandwidth of 100 Hz and a receiver noise figure of 6 dB are assumed. A receiver signal-to-noise ratio of 30 dB is adopted to provide robust waveform matching and reliable dictionary correlation under conservative avalanche conditions.
Figure 8 presents the calculated link budget for the proposed 915 MHz avalanche localization system. The horizontal dashed line represents the minimum receiver sensitivity required for reliable waveform-domain localization, whereas the vertical dashed line corresponds to a standard 1 mW (0 dBm) avalanche beacon. For the assumed geometry and propagation conditions, the predicted received waveform power is approximately dBm, while the required receiver sensitivity is approximately dBm. The resulting link-budget margin is therefore approximately 38 dB.
The analysis was performed for very wet snow with a volumetric water content of , representing a conservative propagation scenario with increased dielectric losses. Even under these unfavorable conditions, the available 38 dB link-budget margin indicates considerable engineering margin. Consequently, all numerical results presented in this paper were obtained using the baseline SUCA configuration consisting of eleven ring elements, consistent with the array design introduced in [3].
The substantial link-budget margin also demonstrates considerable flexibility in the SUCA architecture. Preliminary simulations using only five ring elements while maintaining the same array diameter still achieved 100% recovery of all dictionary nodes and retained an approximately 33 dB link-budget margin. These encouraging preliminary results suggest that future practical systems may employ significantly simpler, lighter, and lower-cost SUCA configurations while preserving satisfactory localization performance. Optimization of the array geometry, however, is beyond the scope of the present work and will be addressed in future studies.
The power-budget analysis therefore confirms that the proposed waveform-domain localization framework is not limited by received signal strength under representative avalanche conditions but instead provides substantial engineering margin for practical implementation and future system miniaturization.
3.2. Dictionary Uniqueness Validation
Before evaluating localization performance under realistic operating conditions, it is first necessary to verify that every candidate victim position produces a unique waveform-domain signature. If two different locations generated identical waveforms, dictionary-based localization would become fundamentally ambiguous regardless of receiver noise, hardware performance, or signal-processing accuracy.
To validate the uniqueness of the proposed localization framework, a three-dimensional Cartesian grid with 0.5 m spacing in the x-, y-, and z-directions was generated around the expected victim location. For every grid node, the corresponding noiseless SUCA waveform was synthesized using the complete electromagnetic propagation model and stored in the waveform dictionary. Each synthesized waveform was then correlated with every dictionary entry, and the node producing the maximum correlation was selected as the estimated victim position.
Figure 9 summarizes the validation results. Every synthesized waveform was mapped back to its originating grid node, demonstrating that the proposed waveform-domain dictionary provides a unique representation of every candidate victim position within the search region. Consequently, in the absence of measurement noise and modeling uncertainties, the localization algorithm correctly identifies every grid location. Any localization degradation observed in subsequent simulations therefore originates from practical effects such as receiver noise, dielectric-property uncertainty, or finite grid resolution rather than from ambiguity of the waveform dictionary itself.
The validation was performed over a three-dimensional rescue region extending approximately 40.7 m in the x-direction and 19.2 m in the y-direction, corresponding to a snow-surface search area of approximately 781 m2 (8,407 ft2). The modeled burial depth ranged from 0.3 m to 2.8 m below the snow surface. Using a uniform grid spacing of 0.5 m in all three dimensions, the complete waveform dictionary contained 6,783 candidate victim positions.
The adopted 0.5 m grid spacing is also consistent with practical avalanche rescue procedures. Once the victim has been localized within a single grid cell, the estimated position is sufficiently accurate to begin excavation immediately, since the dimensions of the human body are considerably larger than the grid resolution. Further reduction of the grid spacing would substantially increase the dictionary size and the associated computational cost while providing little additional benefit during the time-critical rescue operation.
An important observation is that no blind regions, ambiguous locations, or duplicate waveform signatures were found throughout the entire search volume. Every candidate victim position was associated with a unique waveform-domain signature, demonstrating complete three-dimensional coverage of the rescue region by the proposed SUCA localization framework.
If no victim is detected within the current search region, the rescuer may simply rotate slightly to examine an adjacent region or load the precomputed waveform dictionary corresponding to the neighboring search area. In this manner, large avalanche fields can be covered sequentially without modifying the localization algorithm or reconfiguring the SUCA receiver.
An alternative operating mode is to place the SUCA directly on the snow surface. However, in this configuration the electromagnetic wave propagates almost entirely through the lossy snow layer. Consequently, propagation attenuation, particularly under wet-snow conditions, increases significantly, reducing the effective search region compared with the proposed helmet-mounted configuration.
3.3. Potential Respiration Monitoring
Following successful victim localization, the proposed waveform-domain localization framework may be operated in a dedicated observation mode to monitor slow physiological motion. The objective of this simulation is not to demonstrate a clinically validated respiration monitor but to investigate whether the same localized waveform can provide information about victim respiratory activity without additional hardware.
The nominal beacon position is denoted by
Respiration is represented by a small sinusoidal displacement of the victim’s chest
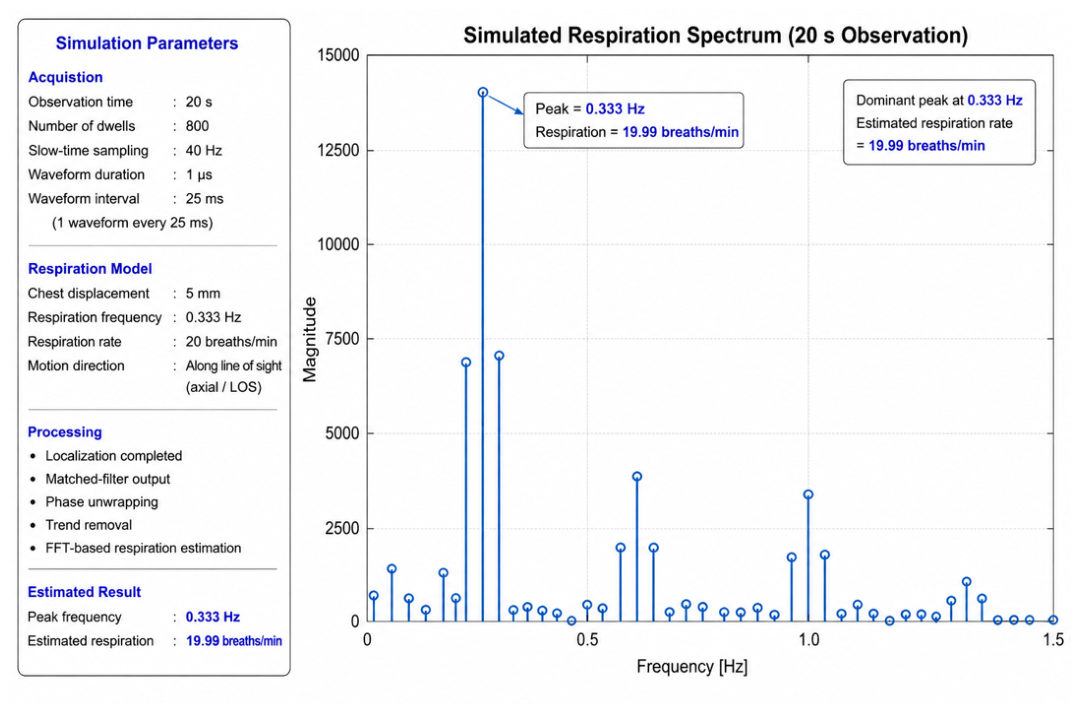
where is the chest-motion amplitude and is the breathing frequency. Throughout the present simulation, mm and Hz (approximately 20 breaths/min) are assumed. The instantaneous beacon position therefore becomes
For every slow-time sample, the refracted propagation path from the moving beacon position to each SUCA receiving element is recalculated using the same electromagnetic propagation model employed during victim localization. Consequently, both the snow propagation distance and the air propagation distance become slowly time varying.
The received complex electric field at the m-th SUCA element is computed as
where is the beacon transmit power, is the free-space wave impedance, is the complex propagation constant of snow, and is the free-space wavenumber.
The received signals are subsequently processed using the same LOG-based deterministic multifrequency waveform-generation procedure developed for localization. Consequently, the composite waveform contains a weak periodic phase variation produced solely by the breathing-induced displacement.
Finally, the instantaneous phase of the composite waveform is unwrapped, its slowly varying trend is removed, and a Fourier transform is applied to estimate the dominant breathing frequency.
Figure 10 presents the simulated respiration spectrum. A dominant spectral peak is observed at approximately 0.333 Hz, corresponding to an estimated breathing rate of 19.99 breaths/min for the simulated respiration rate of 20 breaths/min.
These preliminary simulation results indicate that, after successful victim localization, the same waveform-domain localization framework may also provide information about victim respiratory activity without additional sensing hardware. Experimental validation under realistic avalanche conditions remains future work, but the results demonstrate that respiration monitoring represents a promising extension of the proposed localization concept.
4. Conclusions
This paper presented a waveform-domain localization framework for three-dimensional avalanche rescue based on a helmet-mounted Sparse Uniform Circular Array and compact unit with and a cooperative beacon. Unlike conventional avalanche transceivers, which primarily estimate the direction and approximate distance to a buried beacon, the proposed approach determines the victim position directly from the complete received waveform by correlating it with a precomputed waveform dictionary.
A comprehensive electromagnetic model was developed, including realistic snow dielectric properties, propagation through snow and air, refraction at the snow–air interface, deterministic multifrequency waveform synthesis, and waveform-domain correlation processing. Simulation results demonstrated complete coverage of the investigated search region without blind areas or ambiguous locations. The adopted 0.5 m grid spacing was shown to provide localization accuracy appropriate for practical avalanche rescue while maintaining a manageable dictionary size.
The calculated link budget indicates a substantial power margin for the considered rescue scenarios, suggesting that reliable localization may be achieved with beacon transmit powers well below the 1 mW level under the modeled propagation conditions. Such low-power operation could enable lightweight, battery-efficient avalanche beacons while maintaining reliable localization performance.
The same electromagnetic framework was further shown to preserve the small periodic phase modulation produced by physiological chest motion. Numerical simulations therefore indicate that, following successful victim localization, the received waveform may also be used to estimate the victim’s respiration rate without additional sensing hardware, providing rescuers with valuable information regarding possible signs of life before excavation is completed.
From an implementation standpoint, several practical observations can be made. First, the waveform dictionary is generated offline and stored in memory before deployment. During rescue operation, localization requires only correlation of the measured waveform with the stored dictionary, making the processing naturally parallel and suitable for real-time implementation using modern embedded processors, GPUs, or FPGAs. Second, the memory requirements are modest. For the search region considered in this study, the complete dictionary occupies only about 28 MB, making storage straightforward for existing embedded hardware. Third, although only a single buried beacon was considered here, the same waveform-domain framework can be extended to multiple victims using sparse reconstruction techniques such as Orthogonal Matching Pursuit (OMP). Finally, operation near 915 MHz provides an effective compromise between propagation through snow and practical antenna dimensions for a compact helmet-mounted receiver.
Future work will focus on experimental validation using commercially available avalanche beacons and realistic snow conditions, development of a prototype helmet-mounted SUCA receiver, and field evaluation under representative avalanche conditions. The numerical results presented in this paper indicate that the proposed concept has the potential to extend avalanche rescue beyond victim localization by combining precise three-dimensional positioning, ultra-low-power beacon operation, and post-localization respiration monitoring within a single integrated system.
Use of Artificial Intelligence
During the preparation of this manuscript, the author used generative artificial intelligence (OpenAI ChatGPT) to assist with improving the clarity of the language, organization of the manuscript, and editorial presentation. The author reviewed and edited all AI-assisted content and takes full responsibility for the accuracy, originality, and scientific content of the manuscript.
References
- M. Hohlrieder, P. Mair, W. Wuertl, and H. Brugger, “The Impact of Avalanche Transceivers on Mortality from Avalanche Accidents,” High Altitude Medicine & Biology, vol. 6, no. 1, pp. 72–77, Spring 2005. [CrossRef]
- B. Wallner, L. Moroder, A. Brandt, P. Mair, S. Erhart, M. Bachler, G. Putzer, R. Turner, G. Strapazzon, M. Falk, and H. Brugger, “Extrication Times During Avalanche Companion Rescue: A Randomized Single-Blinded Manikin Study,” High Altitude Medicine & Biology, vol. 20, no. 4, pp. 347–355, 2019. [CrossRef]
- V. Volman and J. A. Nessel, Monostatic Waveform-Domain Passive Radar for Detection and Localization Using a Sparse Circular Array with Deterministic Frequency Dither, Sensors, 2026, 26(12), 3816. [CrossRef]
- Avalanche Canada, Companion Rescue, Avalanche Canada, Revelstoke, BC, Canada. Available: https://avalanche.ca.
- Mammut Sports Group AG, Barryvox Extended Reference Guide, User Manual, Seon, Switzerland, 2018.
- RECCO AB, RECCO Technology, Available: https://recco.com/technology/, Accessed: July 2026.
- K. Grasegger, G. Stapazzon, E. Procter, H. Brugger, and I. Soteras, “Avalanche Survival After Rescue With the RECCO Rescue System: A Case Report,” Wilderness & Environmental Medicine, vol. 27, no. 2, pp. 282–286, 2016.
- K. Rasilainen and V. Viikari, “Transponder Designs for Harmonic Radar Applications,” International Journal of Antennas and Propagation, vol. 2015, Article ID 976576, 2015.
- C. Jaedicke, “Snow Mass Quantification and Avalanche Victim Search by Ground Penetrating Radar,” Surveys in Geophysics, vol. 24, nos. 5–6, pp. 431–445, 2003.
- A. Instanes, I. Lønne, and K. Sandaker, “Location of Avalanche Victims with Ground-Penetrating Radar,” Cold Regions Science and Technology, vol. 38, no. 1, pp. 55–61, 2004.
- J. J. Modroo and G. R. Olhoeft, “Avalanche Rescue Using Ground Penetrating Radar,” Proc. 10th International Conference on Ground Penetrating Radar (GPR), Delft, The Netherlands, pp. 785–789, 2004.
- G. R. Olhoeft and J. J. Modroo, "Locating and Identifying Avalanche Victims with GPR," The Leading Edge, vol. 25, no. 3, pp. 306–308, March 2006.
- A. Heilig, M. Schneebeli, and W. Fellin, “Feasibility Study of a System for Airborne Detection of Avalanche Victims with Ground Penetrating Radar and a Possible Automatic Location Algorithm,” Cold Regions Science and Technology, vol. 51, nos. 2–3, pp. 178–190, 2008.
- R. W. Webb, A. Marziliano, D. McGrath, R. Bonnell, T. G. Meehan, C. Vuyovich, and H.-P. Marshall, “In Situ Determination of Dry and Wet Snow Permittivity: Improving Equations for Low Frequency Radar Applications,” Remote Sensing, vol. 13, no. 22, Art. 4617, 2021. [CrossRef]
- A2 Photonic Sensors, “WISe: Water in Snow Sensor,” Grenoble, France, 2019. Available: https://a2photonicsensors.com/wise-sensor-liquid-water-content-snow/. Accessed: Jul. 2026.
- M. E. Tiuri, A. H. Sihvola, E. G. Nyfors, and M. T. Hallikainen, “The Complex Dielectric Constant of Snow at Microwave Frequencies,” IEEE Journal of Oceanic Engineering, vol. OE-9, no. 5, pp. 377–382, Dec. 1984. [CrossRef]
- Federal Communications Commission, 47 CFR Part 15—Radio Frequency Devices, Section 15.247. Available: https://www.ecfr.gov/current/title-47/chapter-I/subchapter-A/part-15.
- S. Rauch, H. Brugger, M. Falk, et al., “Avalanche Survival Rates in Switzerland, 1981–2020,” JAMA Network Open, vol. 7, no. 9, Art. no. e2435253, 2024.
- H. Falk, H. Brugger, and M. Adler-Kastner, “Avalanche survival chances,” Nature, vol. 368, p. 21, 1994.
- N. Denissova, O. Petrova, E. Mashayev, and G. Daumova, “Real-Time Avalanche Hazard Monitoring System Based on Weather Sensors and a Laser Rangefinder,” Sensors, vol. 25, no. 9, Art. no. 2937, 2025. [CrossRef]
- M. He, K. Du, H. Huang, Q. Song, and X. Liu, “BWSAR: A Single-Drone Search-and-Rescue Methodology Leveraging 5G-NR Beam Sweeping Technologies for Victim Localization,” Electronics, vol. 13, no. 21, Art. no. 4317, 2024. [CrossRef]
- S. Moro, F. Linsalata, M. Manzoni, M. Magarini, and S. Tebaldini, “Enhancing User Localization with an Integrated Sensing and Communication (ISAC) System: An Experimental UAV Search-and-Rescue Use Case,” Remote Sensing, vol. 16, no. 16, Art. no. 3031, 2024. [CrossRef]
Figure 2.
Comparison of avalanche companion rescue methods: (a) conventional beacon search with sequential localization stages; (b) proposed beacon-assisted SUCA radar providing continuous three-dimensional victim localization for direct approach to the burial location.
Figure 2.
Comparison of avalanche companion rescue methods: (a) conventional beacon search with sequential localization stages; (b) proposed beacon-assisted SUCA radar providing continuous three-dimensional victim localization for direct approach to the burial location.
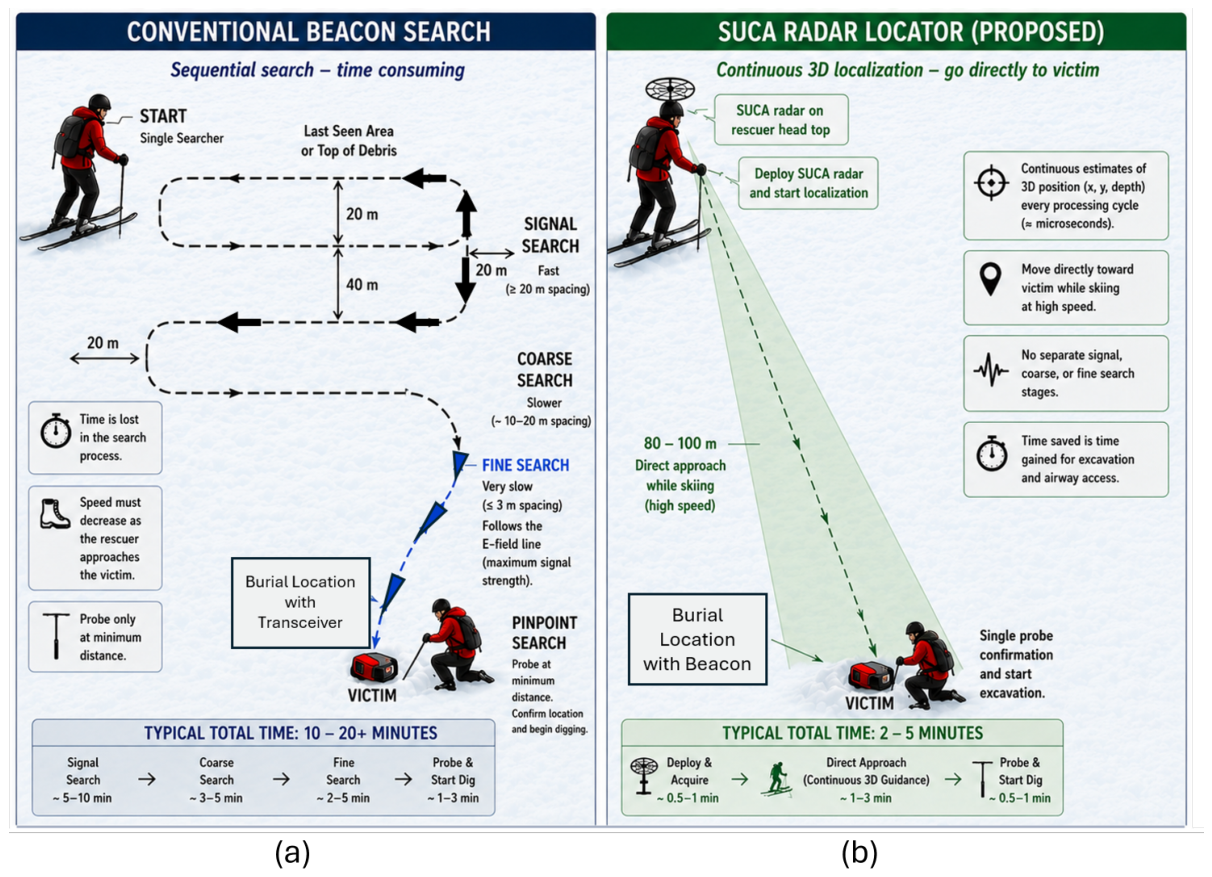
Figure 3.
Frequency dependence of the real and imaginary parts of the complex relative permittivity for representative avalanche snow conditions at . The real part is calculated using (1).
Figure 3.
Frequency dependence of the real and imaginary parts of the complex relative permittivity for representative avalanche snow conditions at . The real part is calculated using (1).
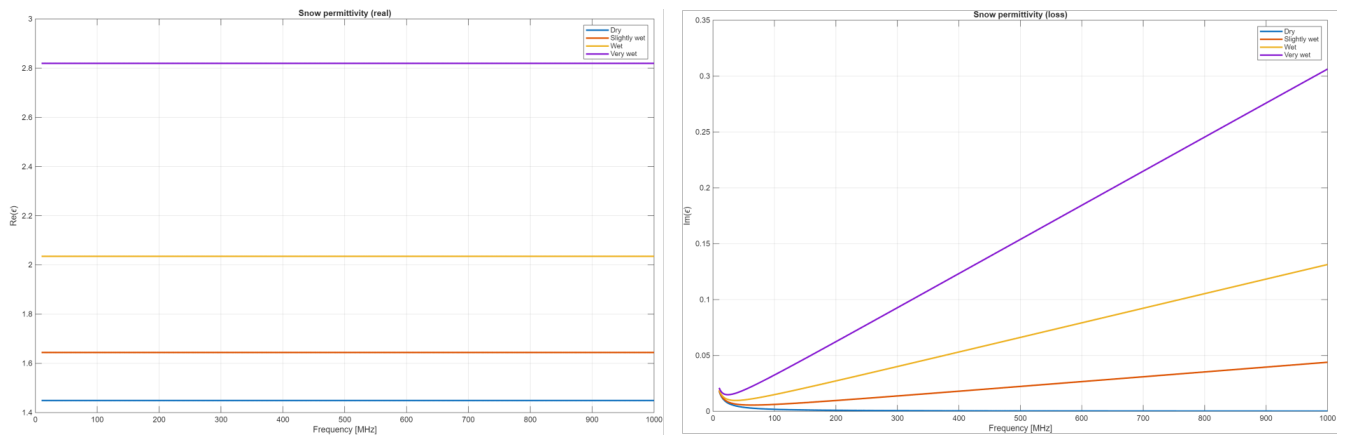
Figure 4.
Three-dimensional propagation geometry between a buried avalanche beacon and the helmet-mounted Sparse Uniform Circular Array (SUCA) unit showing the refracted propagation path through snow and air.
Figure 4.
Three-dimensional propagation geometry between a buried avalanche beacon and the helmet-mounted Sparse Uniform Circular Array (SUCA) unit showing the refracted propagation path through snow and air.
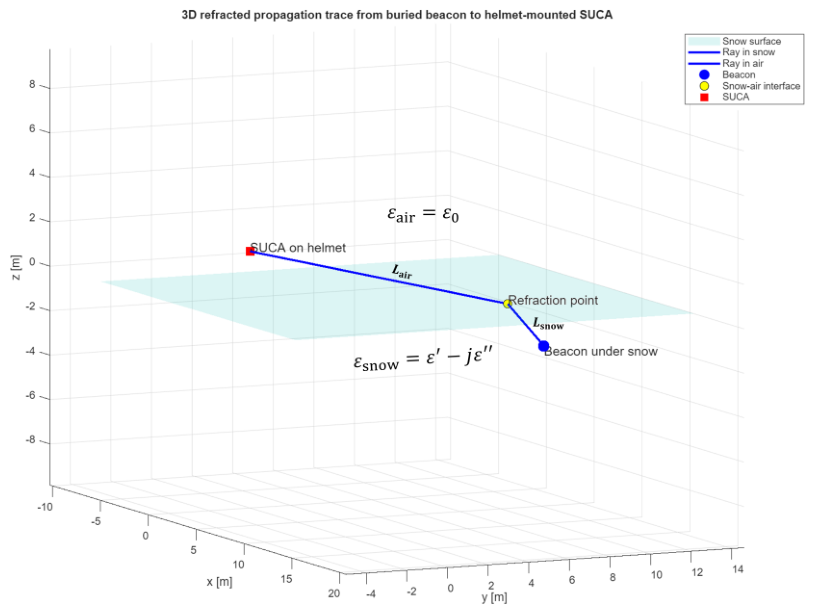
Figure 5.
Representative normalized composite waveform envelopes for three different beacon locations.
Figure 5.
Representative normalized composite waveform envelopes for three different beacon locations.
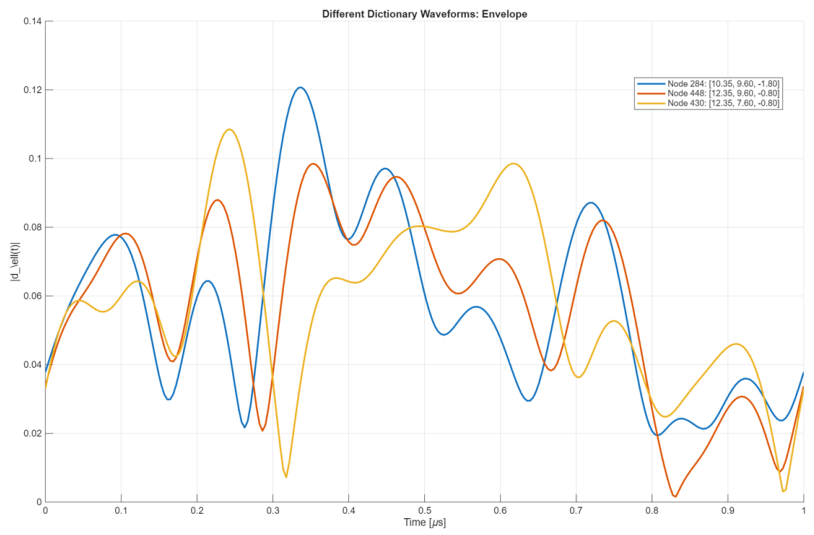
Figure 6.
Representative XY projection of the three-dimensional dictionary correlation map.
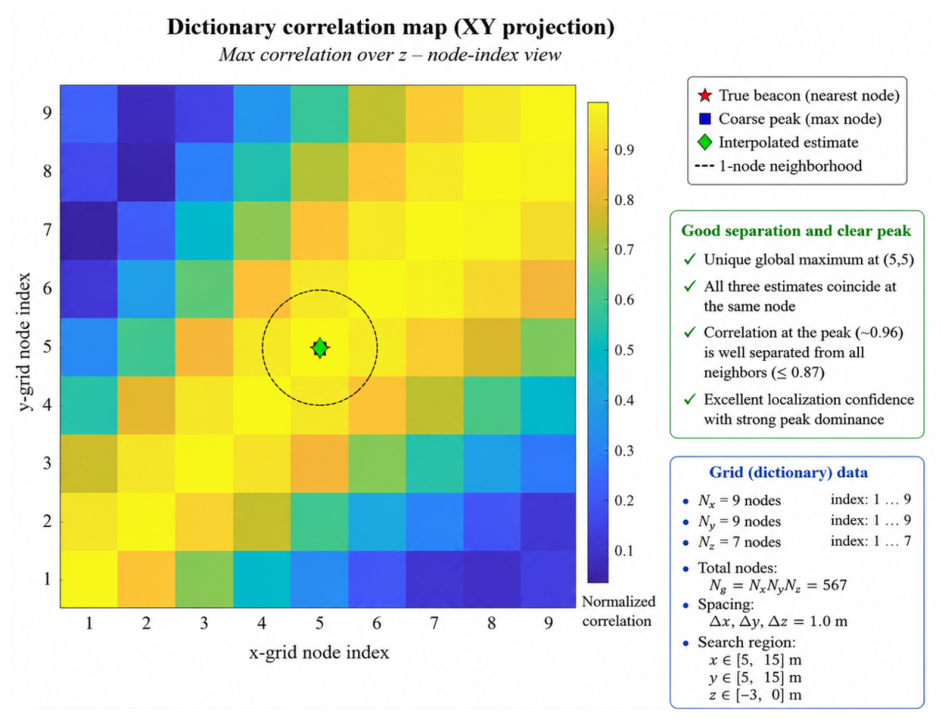
Figure 7.
Representative avalanche survival probability as a function of burial duration together with the principal rescue phases. The curves are based on published Canadian and Swiss avalanche accident statistics.
Figure 7.
Representative avalanche survival probability as a function of burial duration together with the principal rescue phases. The curves are based on published Canadian and Swiss avalanche accident statistics.
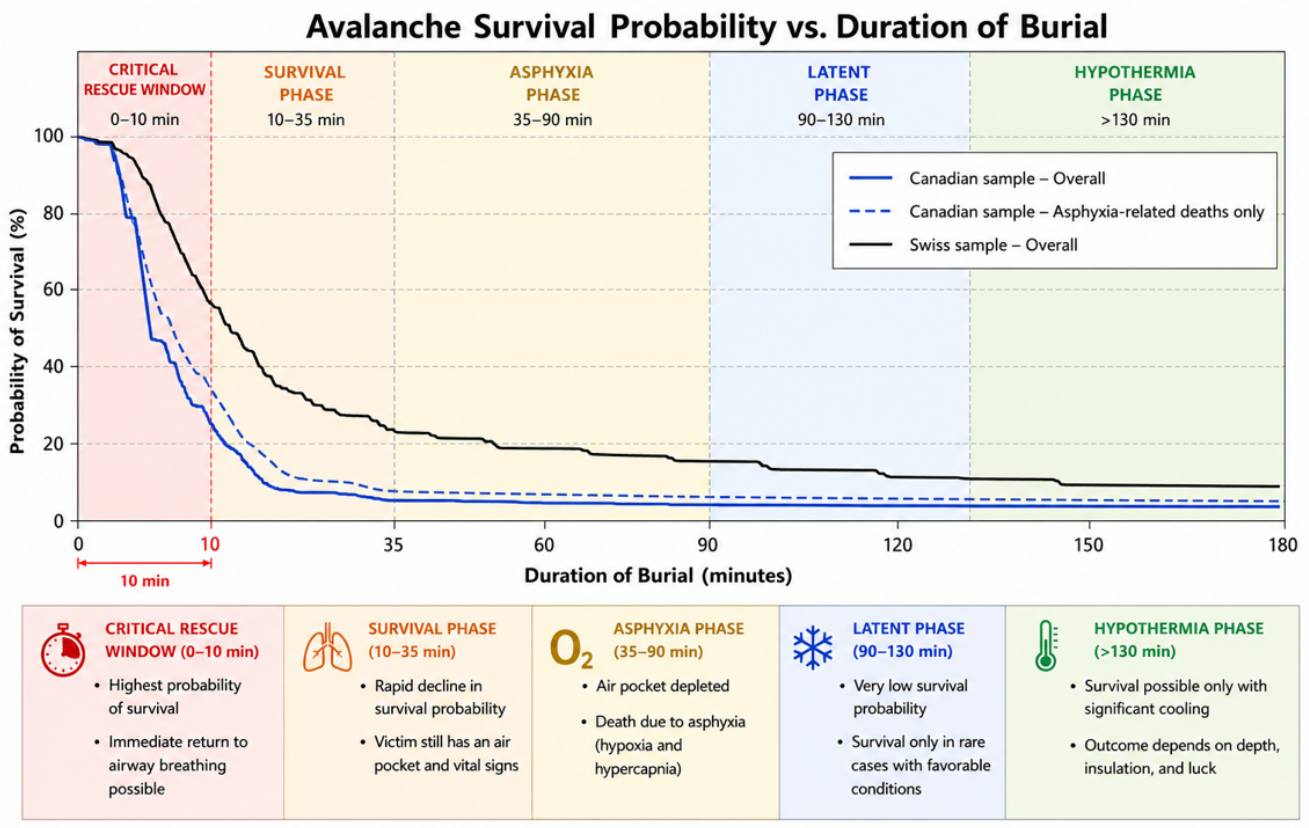
Figure 8.
Calculated link budget for the proposed 915 MHz avalanche localization system. The vertical dashed line indicates a standard 1 mW avalanche beacon, while the horizontal dashed line denotes the minimum required receiver sensitivity.
Figure 8.
Calculated link budget for the proposed 915 MHz avalanche localization system. The vertical dashed line indicates a standard 1 mW avalanche beacon, while the horizontal dashed line denotes the minimum required receiver sensitivity.
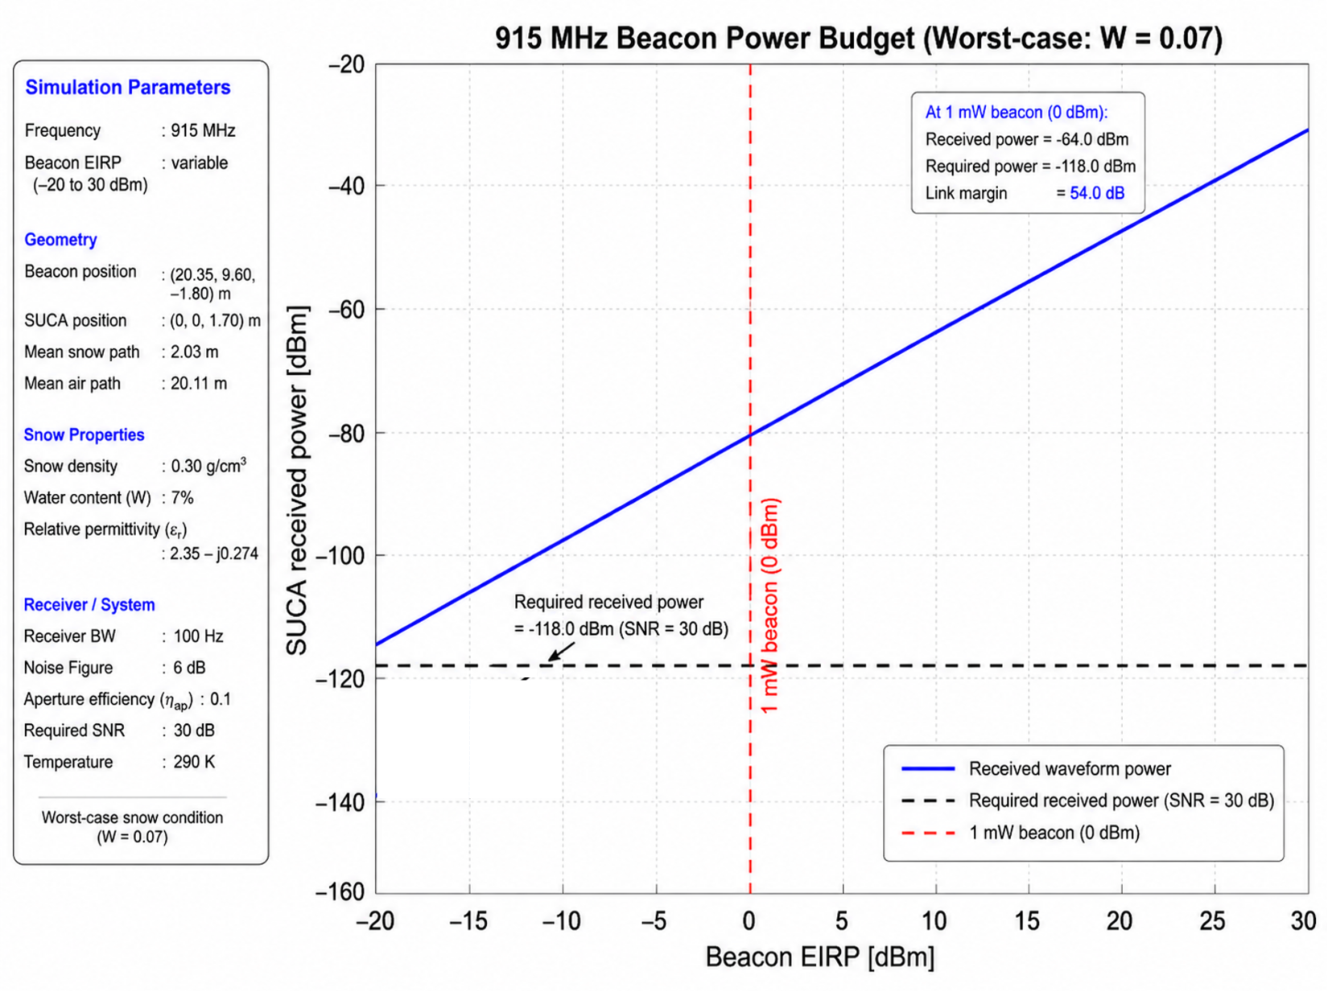
Figure 9.
Validation of the proposed waveform-domain localization algorithm using a noiseless 0.5 m search grid. Every candidate victim position is recovered correctly, confirming unique dictionary mapping throughout the search region.
Figure 9.
Validation of the proposed waveform-domain localization algorithm using a noiseless 0.5 m search grid. Every candidate victim position is recovered correctly, confirming unique dictionary mapping throughout the search region.
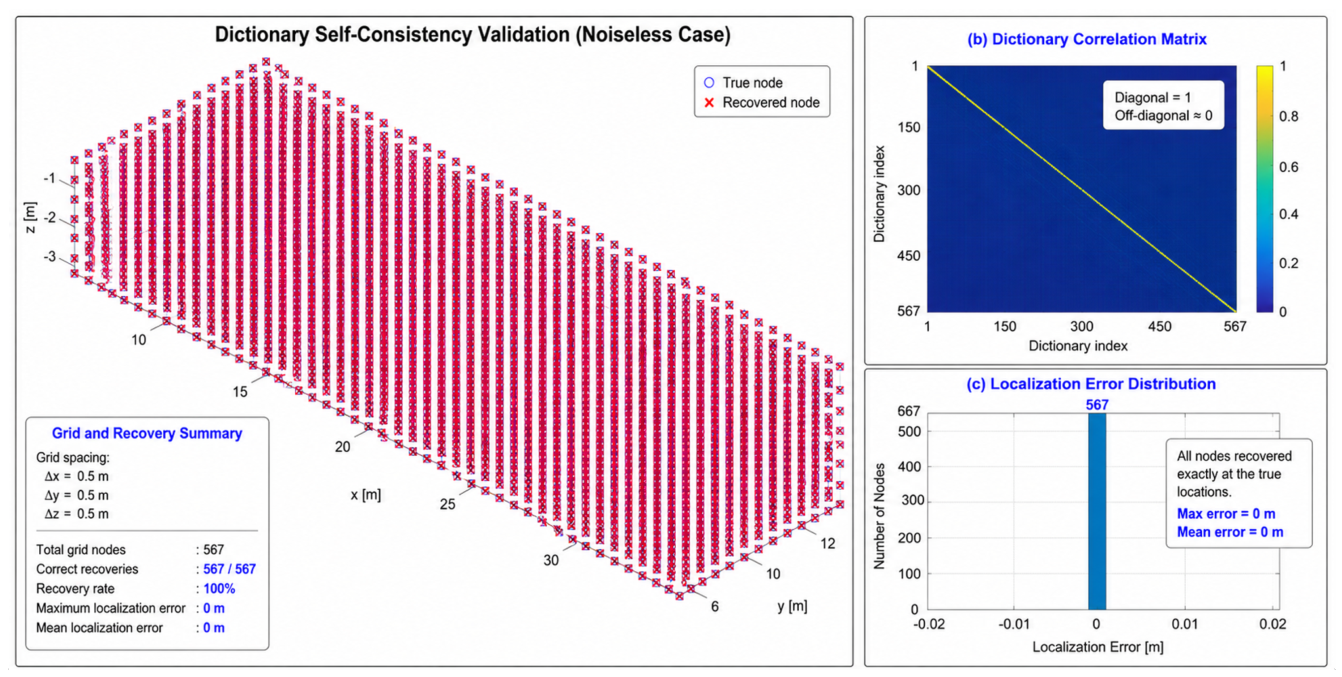
Figure 10.
FFT spectrum obtained from the simulated respiration experiment. A sinusoidal chest displacement of 5 mm at a respiration rate of 20 breaths/min produces a dominant spectral peak at 0.333 Hz, corresponding to an estimated breathing rate of 19.99 breaths/min.
Figure 10.
FFT spectrum obtained from the simulated respiration experiment. A sinusoidal chest displacement of 5 mm at a respiration rate of 20 breaths/min produces a dominant spectral peak at 0.333 Hz, corresponding to an estimated breathing rate of 19.99 breaths/min.
Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2026 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license (http://creativecommons.org/licenses/by/4.0/).
Copyright: This open access article is published under a Creative Commons CC BY 4.0 license, which permit the free download, distribution, and reuse, provided that the author and preprint are cited in any reuse.