

Submitted:
29 August 2023
Posted:
30 August 2023
You are already at the latest version
Abstract
A novel theoem is presented about a circle with four antipodal points, arbitrarily ordered counterclockwise (or clockwise), in a Euclidean plane.
Keywords:
Cyclic antipodal points.
MSC: 51N20
1. Four Cyclic Antipodal Points
A cyclic antipodal points of a circle in a Euclidean plane is a pair of points that are the intersections of the circle with a diameter of the circle. A circle with four cyclic antipodal points is shown in Figure 1. The distance between two points is given by
Theorem 1.
(A Four Cyclic Antipodal Points Theorem)..Let be a circle in the Euclidean plane with radius r, centered at , with four cyclic antipodal points , , and , such that the eight points are arbitrarily ordered counterclockwise (or clockwise), as shown in Figure 1.
Then, the four cyclic antipodal points satisfy the identity
Proof.
The proof is based on the elegant trigonometric identity
which holds for all that satisfy the condition
In order to realize (3) – (4) geometrically by a circle with four cyclic antipodal points, shown in Figure 1, we define the four O-vertex angles in Figure 1 as follows.
We note that , as required by Condition (4), since the points are ordered counterclockwise.
Applying the law of cosines to triangle AOB yields
so that
2. Special Cases
In the special case when and, hence, , the result (2) of Theorem 1 descends to
Noting that and , (10) yields
In a second special case, when and, hence, , the result (2) of Theorem 1 descends to
Corollary 1.
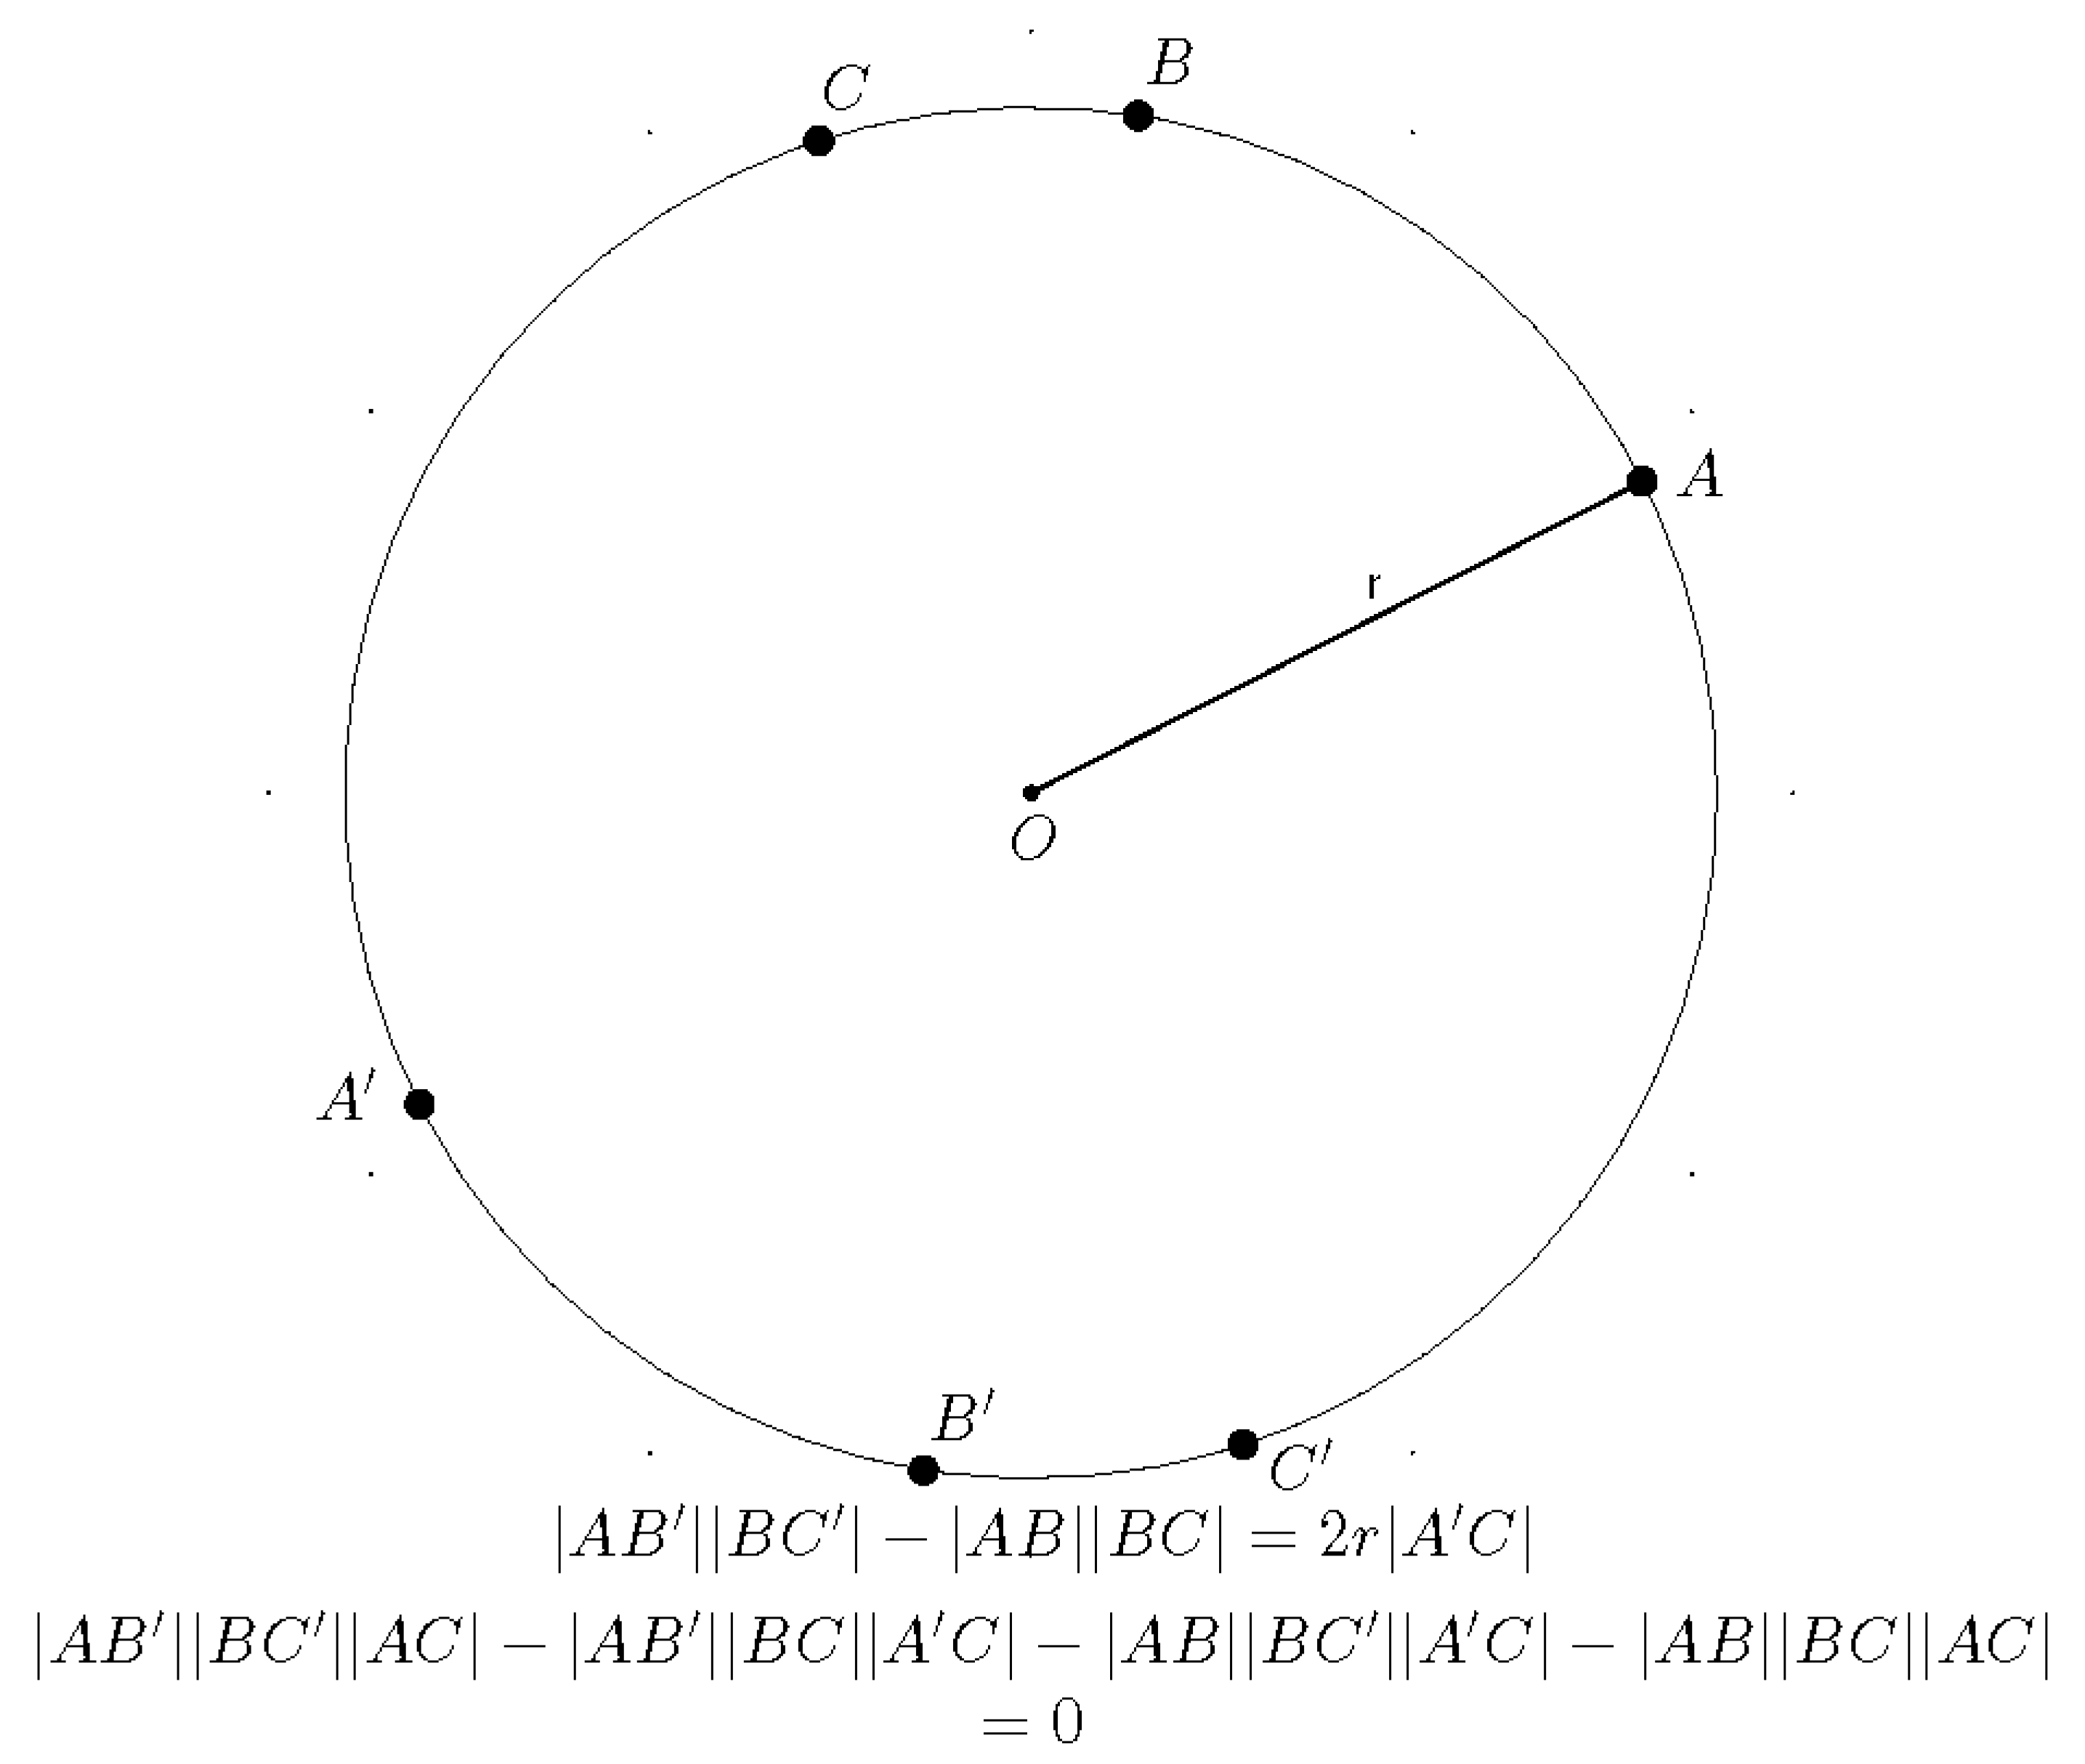
(A Three Cyclic Antipodal Points Theorem). Let be a circle in the Euclidean plane with radius r, centered at , with three cyclic antipodal points , and . The six points are arbitrarily ordered counterclockwise (or clockwise), as shown in Figure 2.
Then,
and
References
- Abraham, A. Ungar. Ptolemy’s theorem in the relativistic model of analytic hyperbolic geometry. Symmetry, 2023. [Google Scholar]
- Abraham, A. Ungar. The hyperbolic ptolemy’s theorem in the poincaré ball model of analytic hyperbolic geometry. Symmetry, 1487. [Google Scholar]
Figure 1.
Four cyclic antipodal points, , , , , on a circle centered at O with radius r, and their corresponding O-vertex angles . The points are arbitrarily ordered counterclockwise, implying . The identity of Theorem 1 is depicted, where , .
Figure 1.
Four cyclic antipodal points, , , , , on a circle centered at O with radius r, and their corresponding O-vertex angles . The points are arbitrarily ordered counterclockwise, implying . The identity of Theorem 1 is depicted, where , .
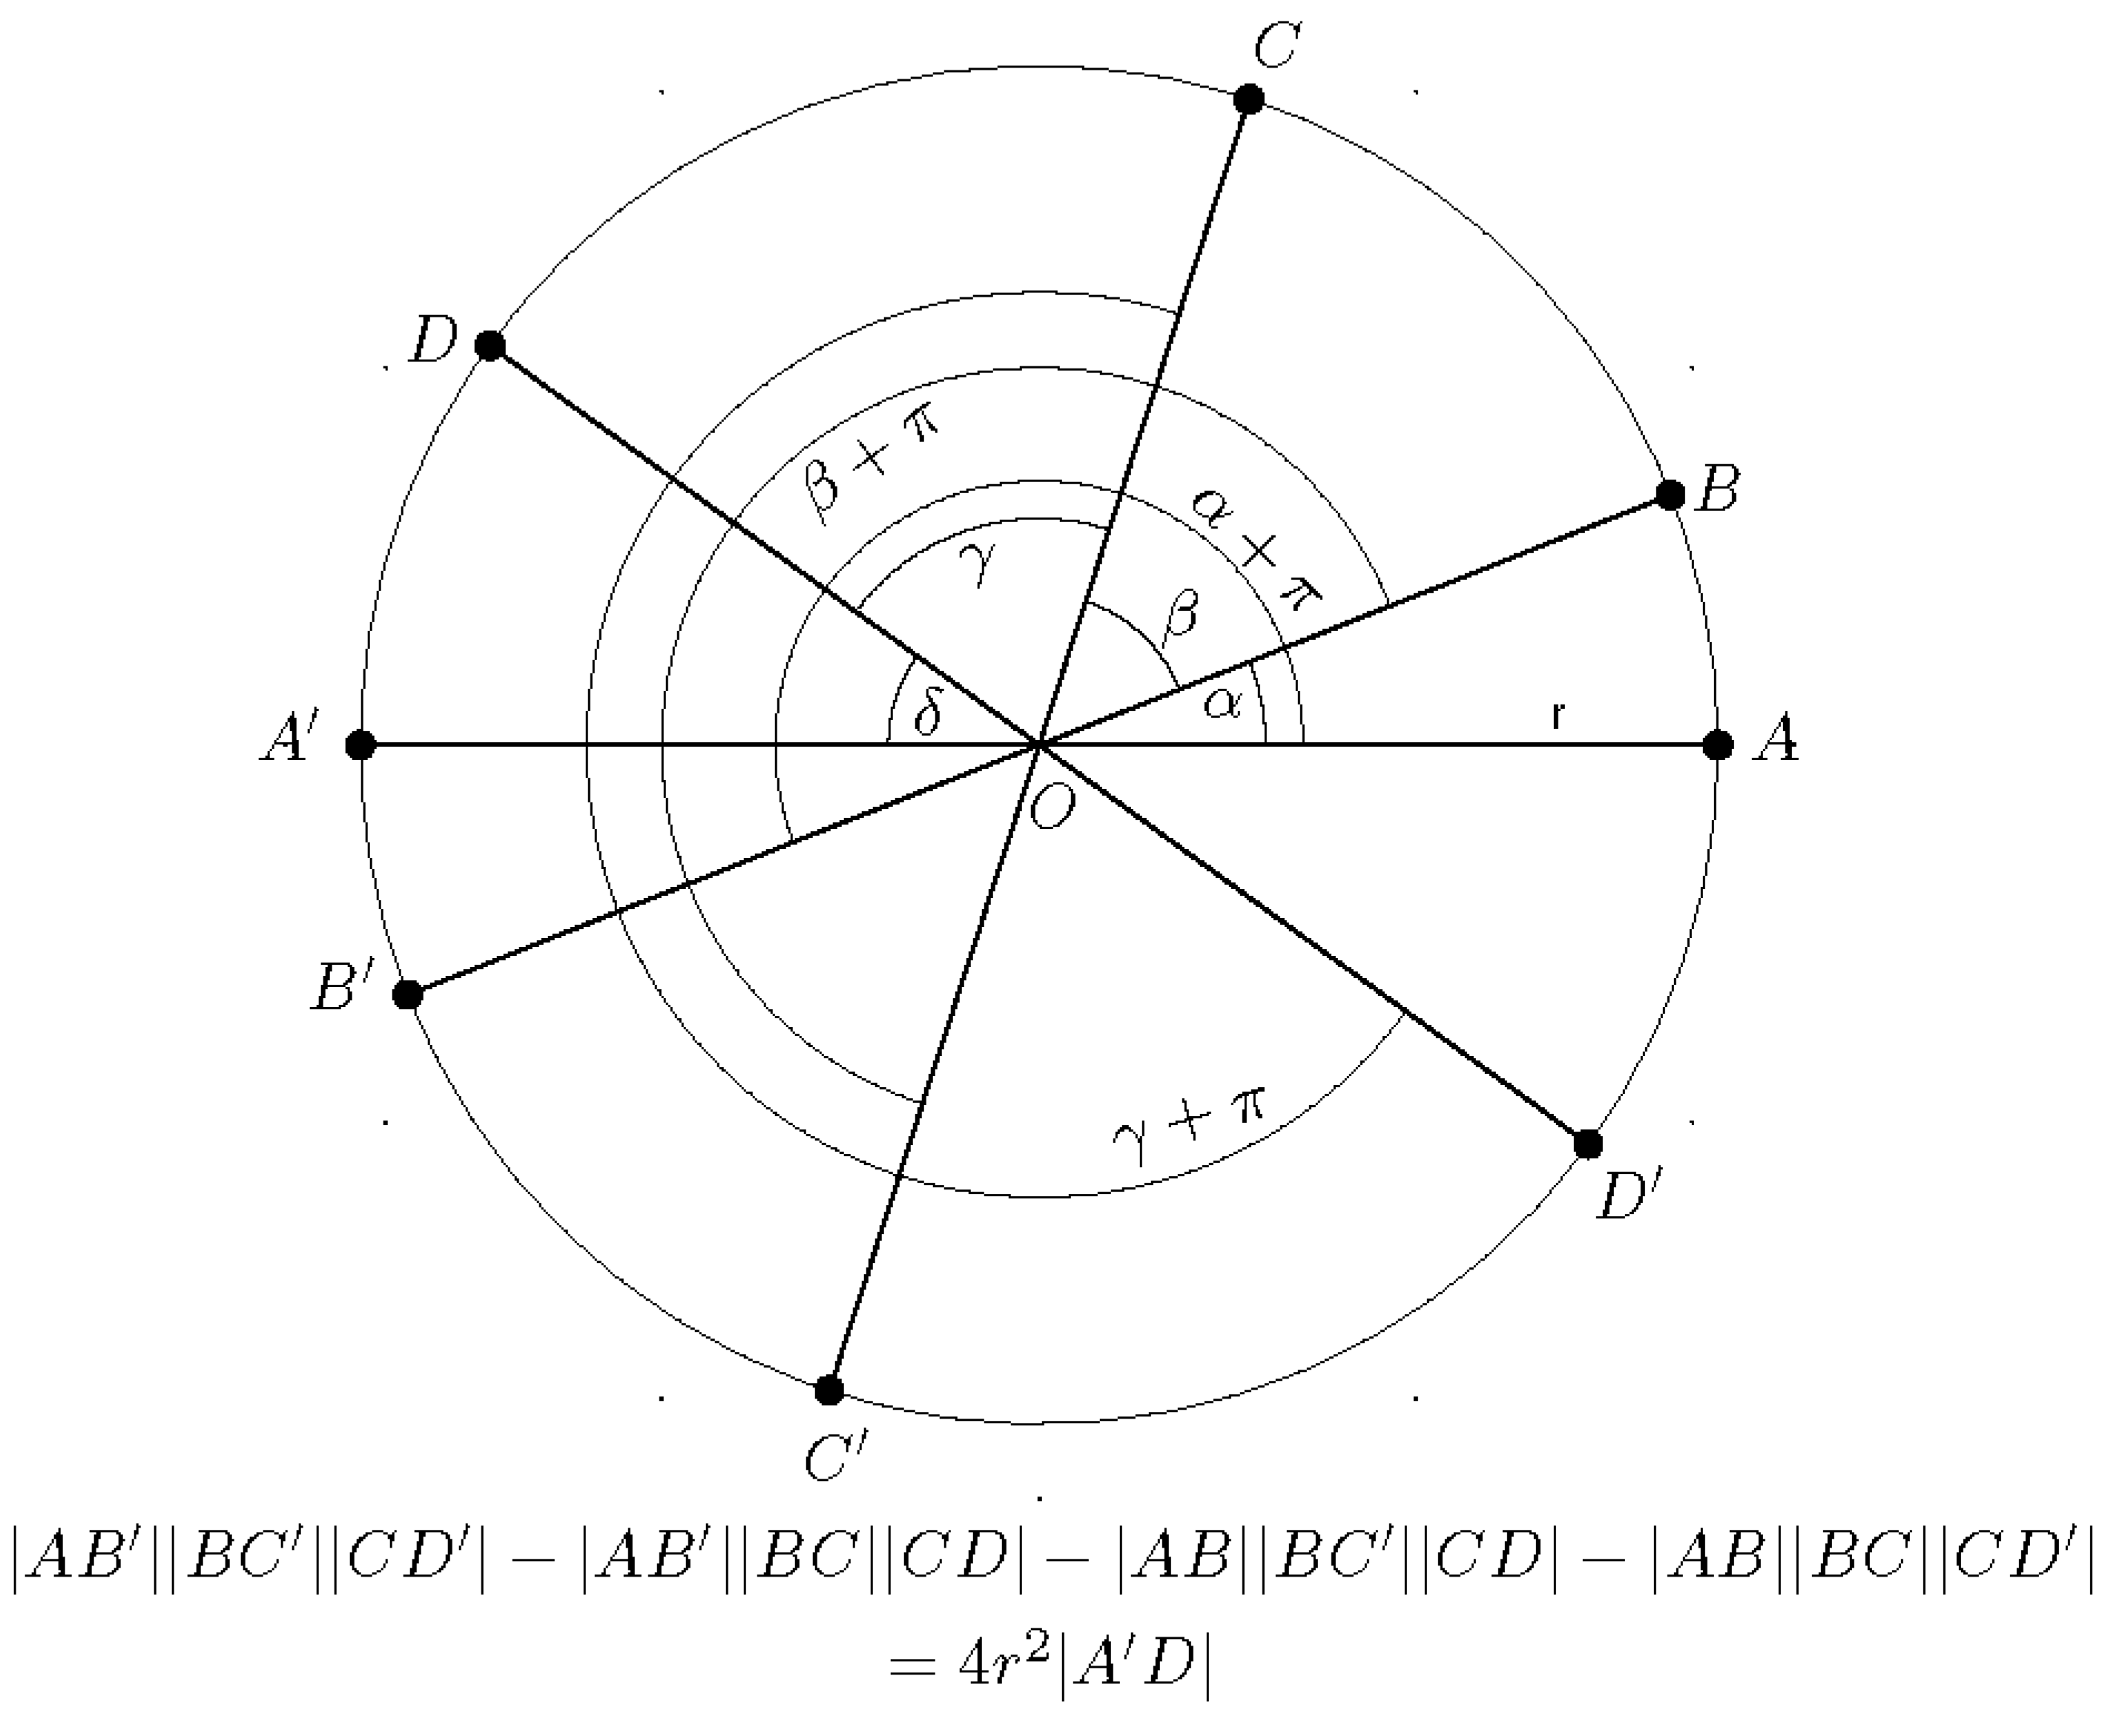
Figure 2.
Three cyclic antipodal points, , , , on a circle centered at O with radius r. The points are ordered counterclockwise. The two identities of Corrolary 1 are shown.
Figure 2.
Three cyclic antipodal points, , , , on a circle centered at O with radius r. The points are ordered counterclockwise. The two identities of Corrolary 1 are shown.
Disclaimer/Publisher’s Note: The statements, opinions and data contained in all publications are solely those of the individual author(s) and contributor(s) and not of MDPI and/or the editor(s). MDPI and/or the editor(s) disclaim responsibility for any injury to people or property resulting from any ideas, methods, instructions or products referred to in the content. |
© 2023 by the authors. Licensee MDPI, Basel, Switzerland. This article is an open access article distributed under the terms and conditions of the Creative Commons Attribution (CC BY) license (http://creativecommons.org/licenses/by/4.0/).
Copyright: This open access article is published under a Creative Commons CC BY 4.0 license, which permit the free download, distribution, and reuse, provided that the author and preprint are cited in any reuse.